My system attaches to the bottom of current apm systems and allows them to land on a user defined target (example targets provided) and when equipped with the supplementary electronics allows for recharging
This means that the copter is now capable of performing multiple missions and if combined with a ground vehicle it can be used as an extension of the ground robots capabilities thus creating a multi robot system
Example applications are
-surveillance
multiple copters watching an area
-environmental surveying
Can do mapping or remote sensing over a longer period due to recharge
if with agv it can move around the environment and perform a multitude of missions
-extending current agv operations
Aerial mapping / complimentary sensors
-improved aerial photography
capable of tracking a target
DETAILS
The cheap small GPS used on hobby UAVS are only accurate to +-5m and traditional landing systems simply move the copter to a predefined GPS location and slowly lower the craft hoping that there is nothing in the way and that the position is where you started. This is nowhere near accurate enough to allow the copters to dock and thus recharge themselves. Normally a human operator is required to move the copter from the landing site to a place where it can be recharged. This limits mission operation and requires a human operator to be physically present.
Utilizing recent advances in low power high performance computing and computer vision techniques my system will allow the copter to dock, recharge itself and when finished fly off again and continue its mission thus partially compensating for the poor endurance of multirotors.
Todo
- Design testing platform [DONE]
- Build testing platform [DONE]
- Test flightworthyness of platform [DONE]
- Design recharging electronics
- Design vision software for landing [DONE]
- Test integration of vision system with paltform
COMPONENTS
- 1×Hexacopter
- 1×Odroid u3 computer
- 1×Pixhawk autopilot
- 1×Usb webcam
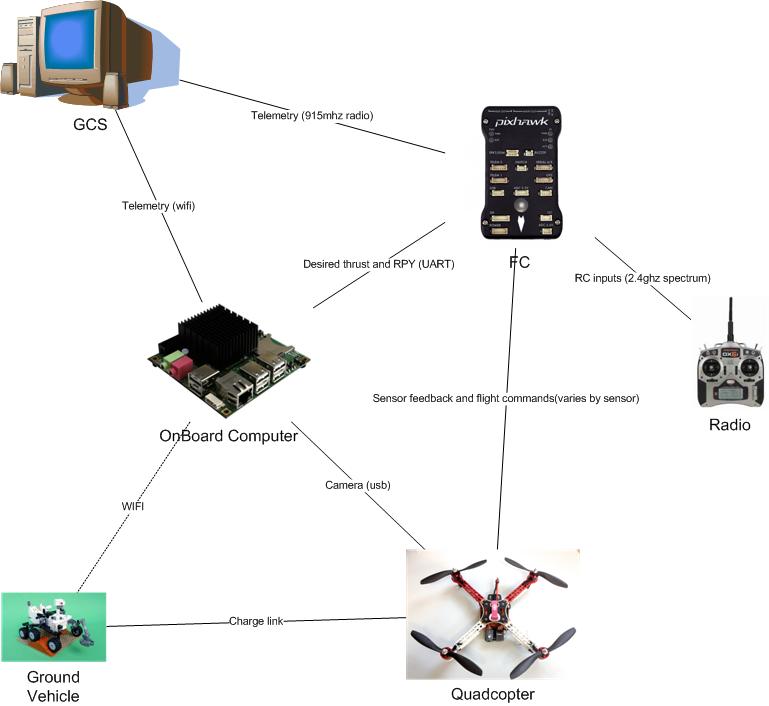
Simulation of autonomous landing
13 days ago • 0 comments
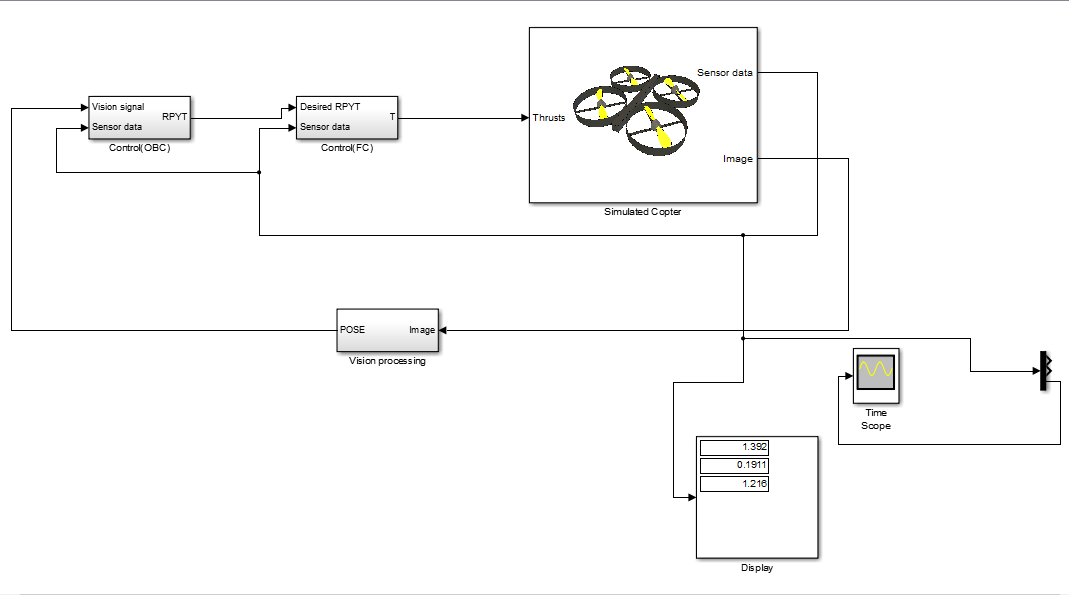
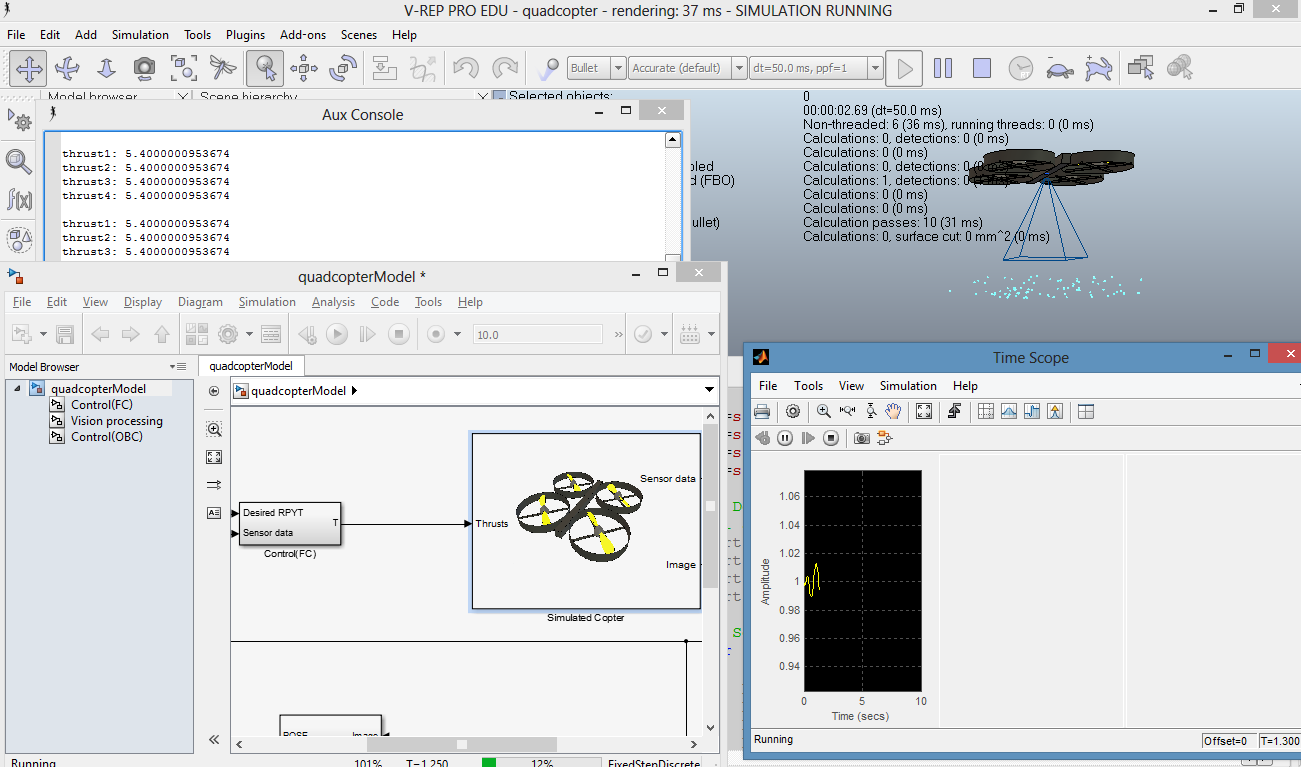
Using the free vrep simulation environment and my access to matlab and simulink via the university the simulation model of the copter has been developed and I can work on designing vision based control algorithms without the risk of crashing copters.

Comments
Very cool. Any video of it working outside of simulation?
Has it autonomously recharged?
is there link to the code/github somewhere?
Really cool :)