Roll and pitch estimation corrected for coriolis forces
(10% to 25% improved roll and pitch estimates)
"
According to
http://en.wikipedia.org/wiki/Coriolis_effect
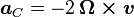
|omega_earth|=2*PI/day=2*3.14/(24*60*60)=7.27e-5[rad/s]
assume aircraft diving at 20m/s in earth reference frame
|ac|=2*7.27e-5*20=0.003[m/s^2]=3e-4[G]
assume we have 16bit ADC which covers 100% range of the useful voltage (overly optimistic),
and the accelerometer is quite sensitive with 6G full span (+/-3G) (overly optimistic, procerus claims +/-10G).
Therefore 6G is divided into 65536 counts.
3e-4G equals then to around 3 ADC counts which is below noise level of most
accelerometers which would be around 2^4, by eye.
Therefore coriolis acceleration is barely detectable (you can attach a plane to the rails, push it down, and the only deviating force will be at most those poor 2-4 counts on extremely sensitive ADC, overswamped by natural sensor noise).
How did they come to 10%/25%?
Where is an arorr in my calculation?

Comments
but qw-rv numerator in the first line... not sure.
-Beall
I am rarely thinking in non-inertial reference frames unless it's as big as earth, therefore I have attached Coriolis to a very large scale (coriolis is a clever name to imaginary force when you want to those simple Newton laws work when you are in rotating reference frame).