Hi guys,
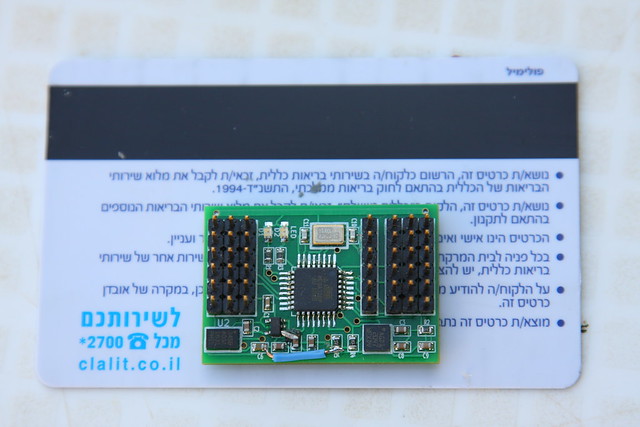
As promised I've started a port of the Ardupirates code to an "Arduinoless" state that should be able to run on Pipo.
I call it Pipopirate :)
It's not anywhere near functional but you can check it out on: http://code.google.com/p/pipo/
Hi guys,
As promised I've started a port of the Ardupirates code to an "Arduinoless" state that should be able to run on Pipo.
I call it Pipopirate :)
It's not anywhere near functional but you can check it out on: http://code.google.com/p/pipo/
You need to be a member of diydrones to add comments!

Comments
There are a total of 16 free IO channels. They can easily be configured for either Input or output.
It was conceived at first as a Pwm-in Pwm-out (Pipo) stabilization platform so yes, that it does really well. I'll upload a video of it stabilizing a pseudo-camera later today.
The real challenge is making it into a full fledged AP. Which I will :)
Hi guys,
First up. This is a very preliminary code. It will get better.
GPS, camera, etc will be added later on.
Just to be clear. I'm not trying to compete with the Ardupilot/ArduIMU. They'll always have more memory. If I wanted to do that I'd have made a board with a Cortex MCU (read - pipo v3).
This one is designed with a couple ideas in mind.
1) SMALL. Guys, I just weighed it and it came out to 6 grams! Kinda lighter than the other options.
2) On board MEMS sensors. No wiring and/or soldering to deal with.
3) The sensors' output is digital. Hence the ADC resolution does not matter.
This board is small and light enough to be used as a camera stabilization platform, a FPV assist platform, a Heli FBL controller and more. The ardupirates code is just the beginning :)
Sorry Pippo , what micro are you using ? 328 ? So you don't have a lot memory for using all feature of ArduPirates and you pwm output is very poor :(