After creating the Arduspyder. We decided to create a real hexa. These are pictures of the making, maiden will be this weekend. Because of the purpose this frame is build for we sadly did not opt for an Arducopter but the frame will take an Ardu, Openpilot CC, Microkopter or any other hexa capable electronics.
The baseplate design in Rhinoceros
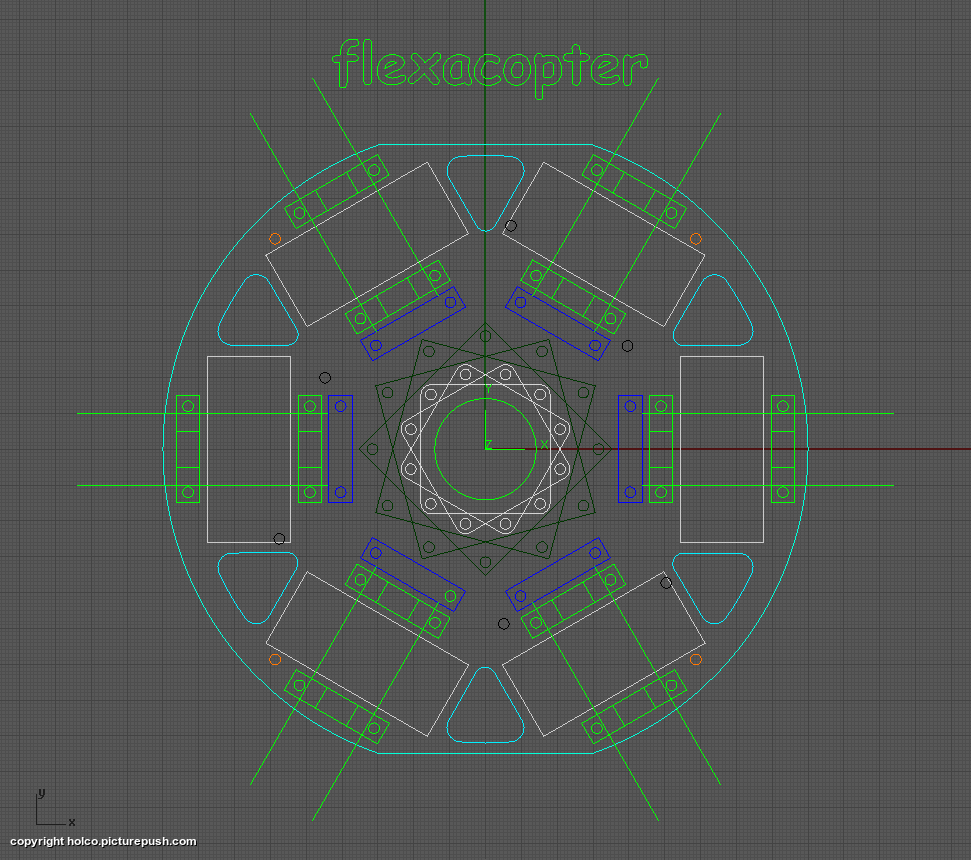
Finding the stupid MK BL-controller holes.
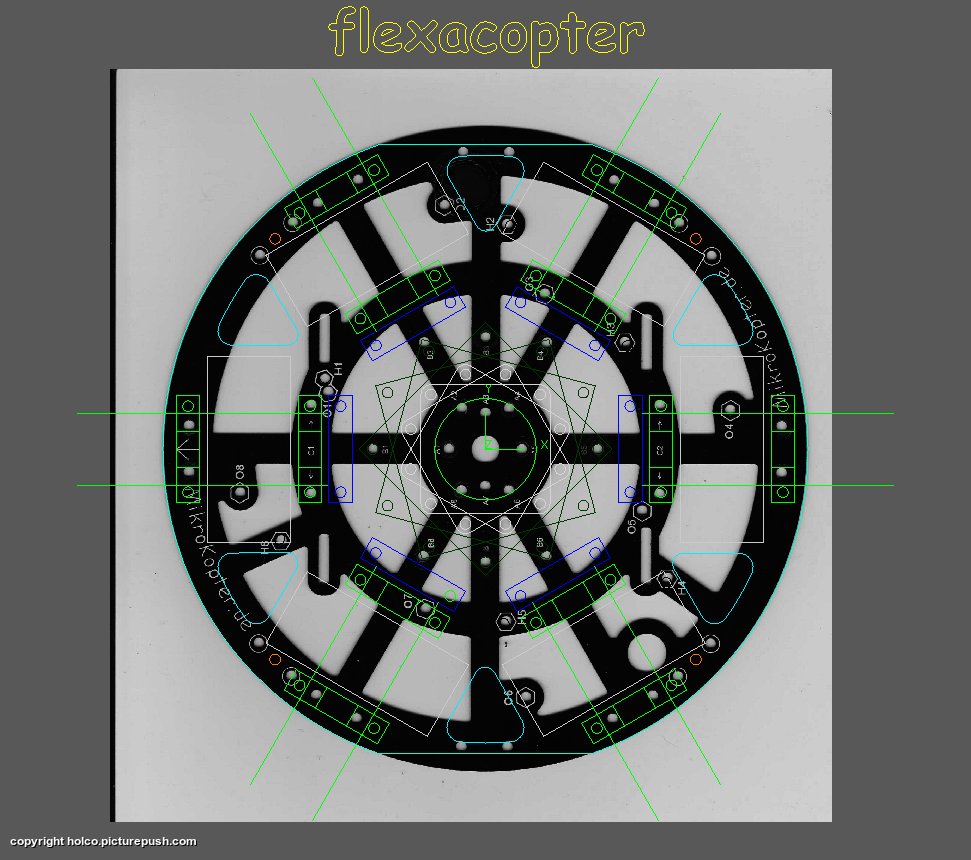
Testfitting the holes
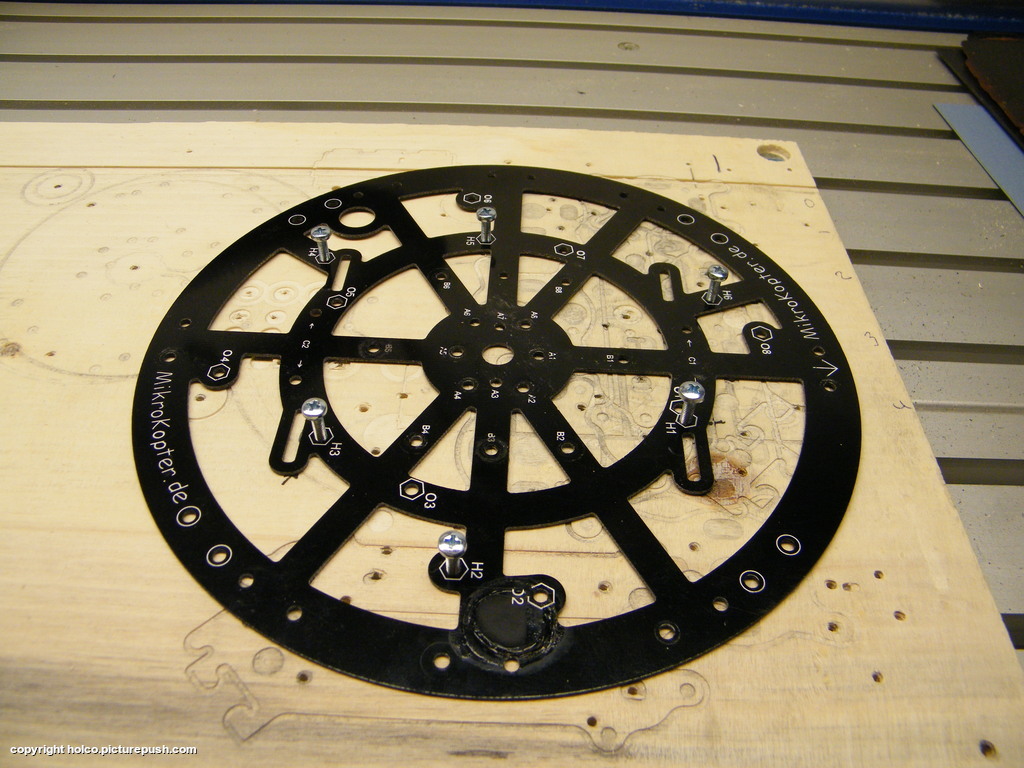
Testrun upper plate. 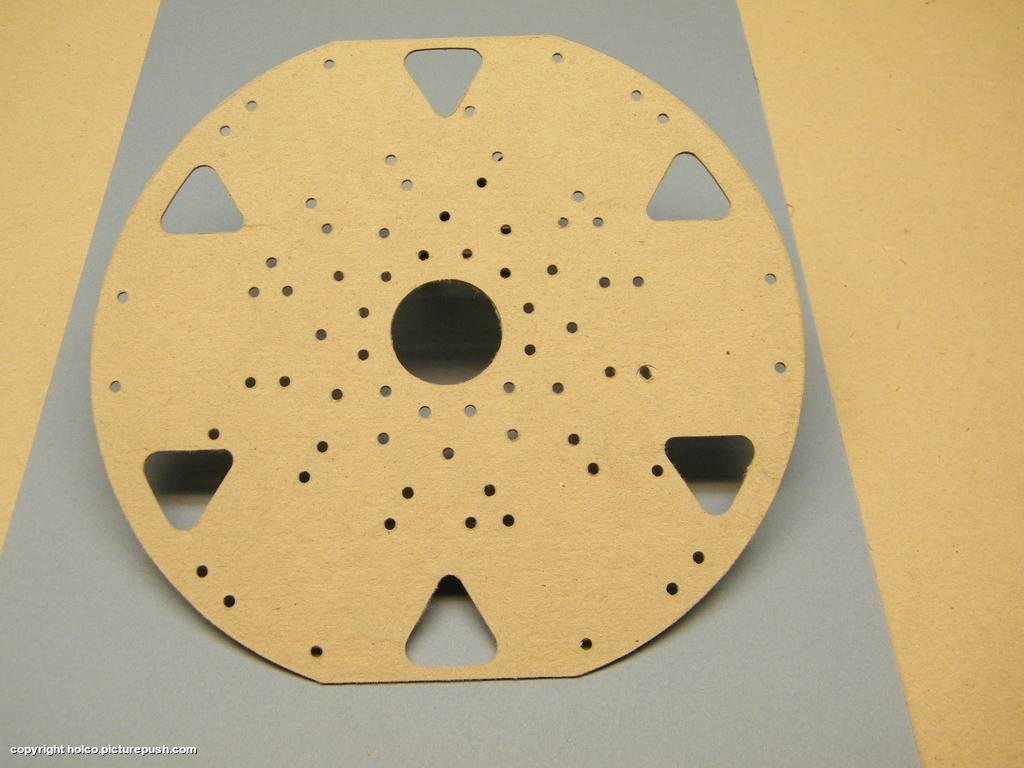
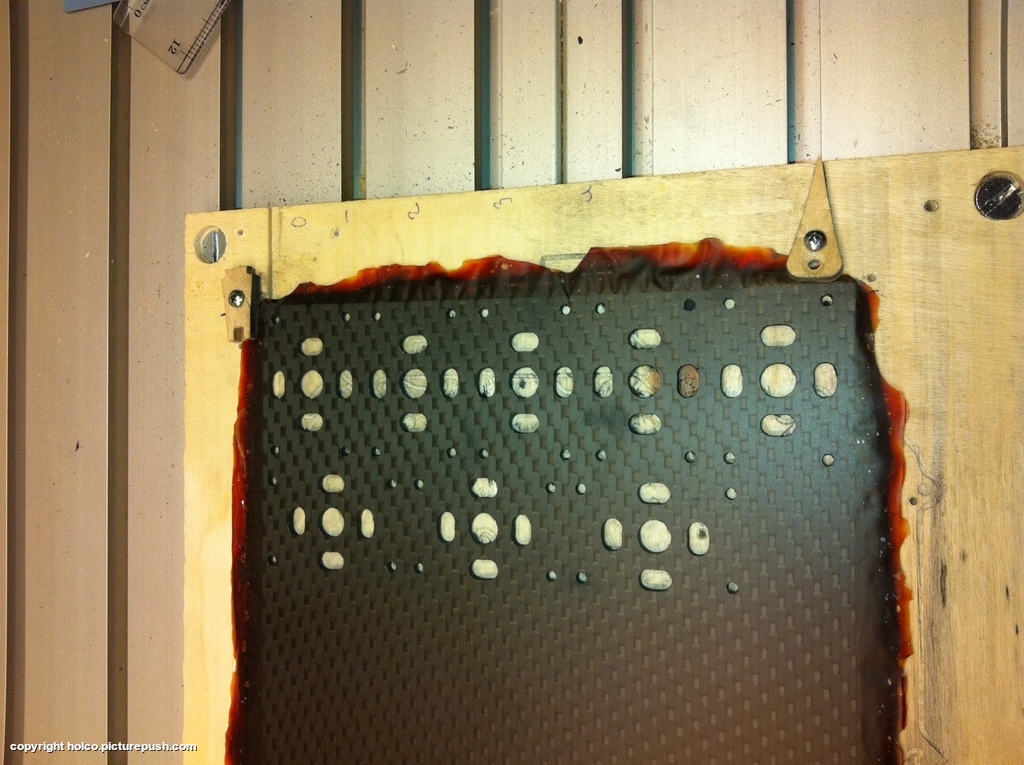
Routing the motormounts.
Video
Mounted motor.
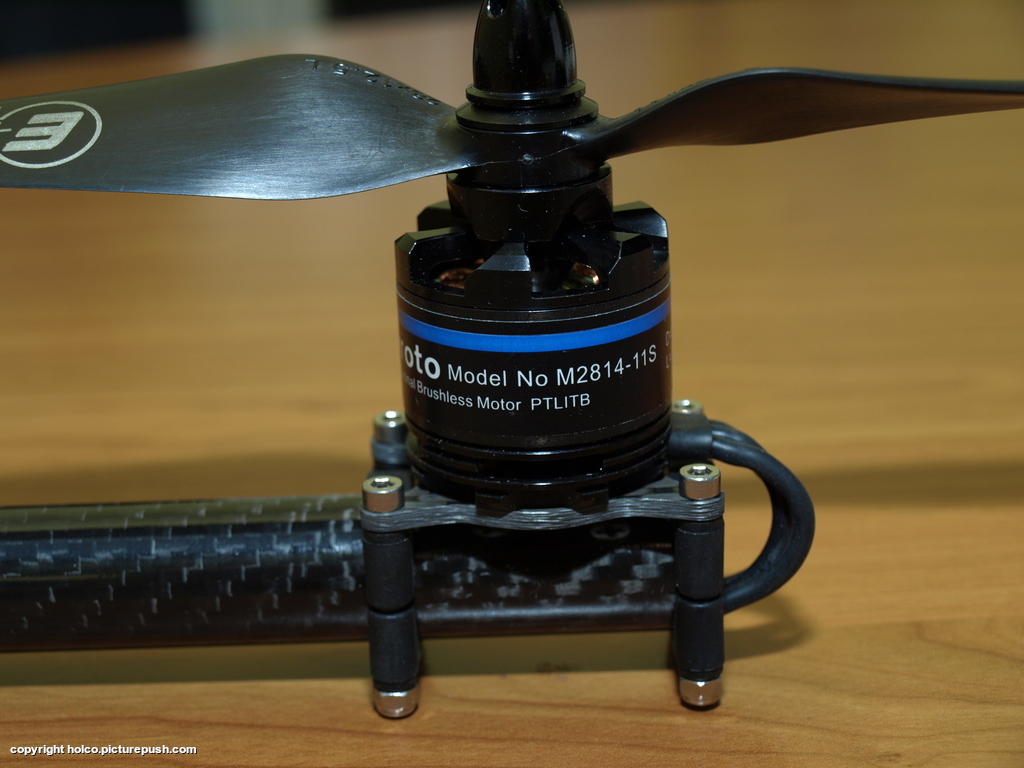
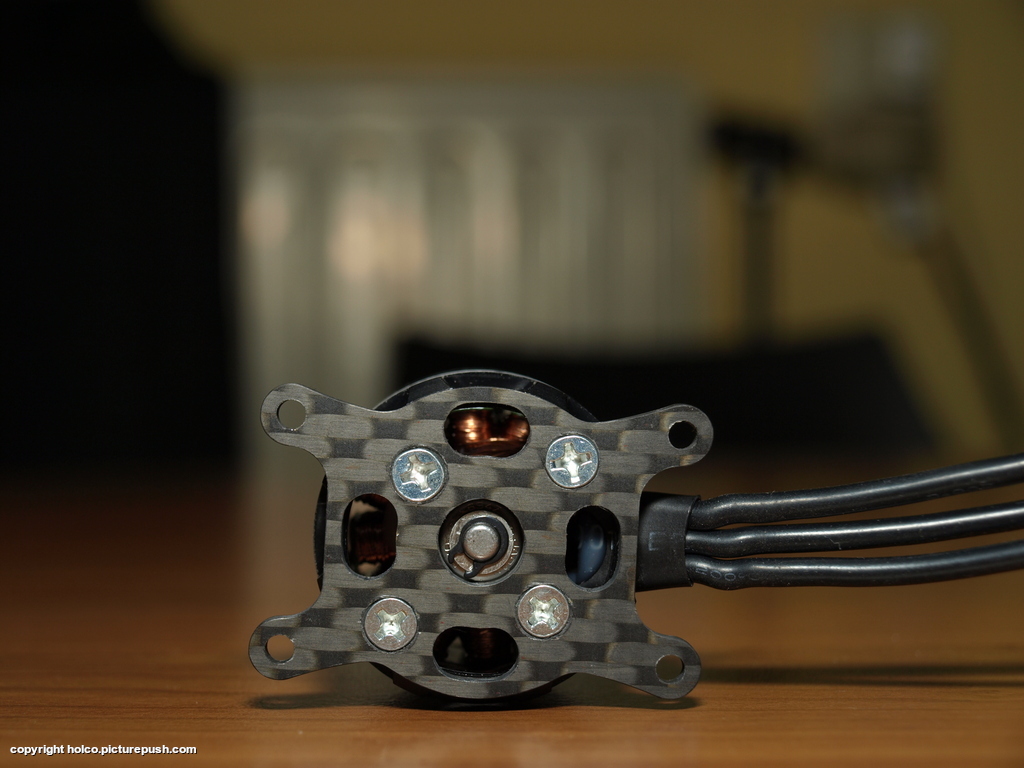
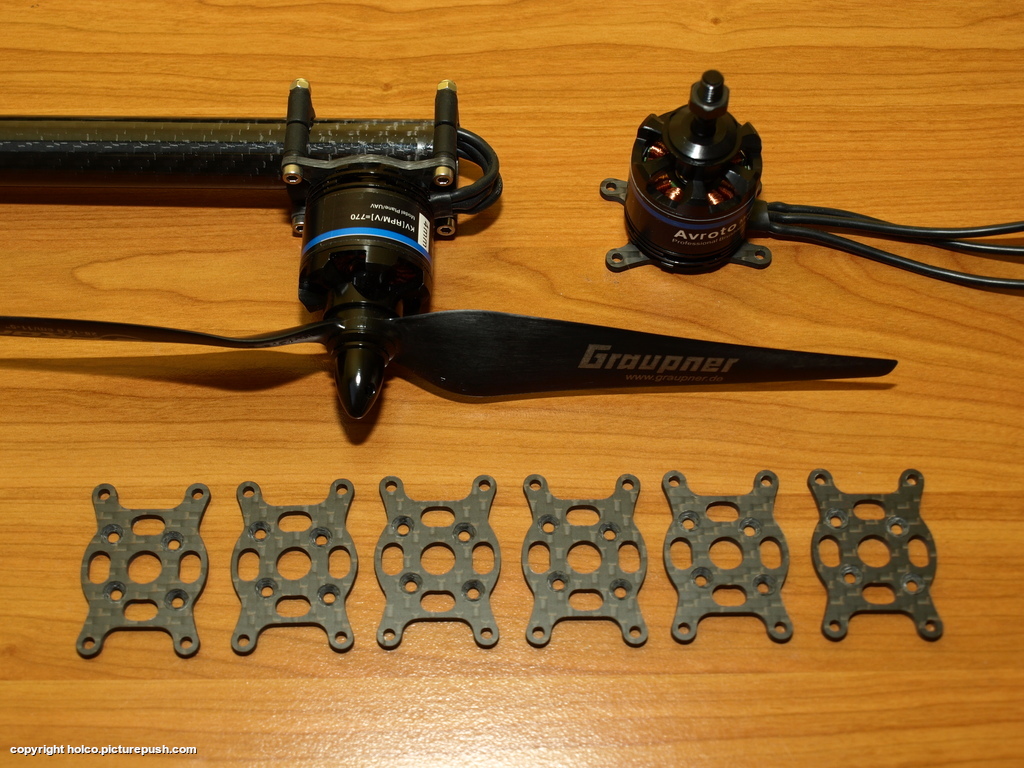
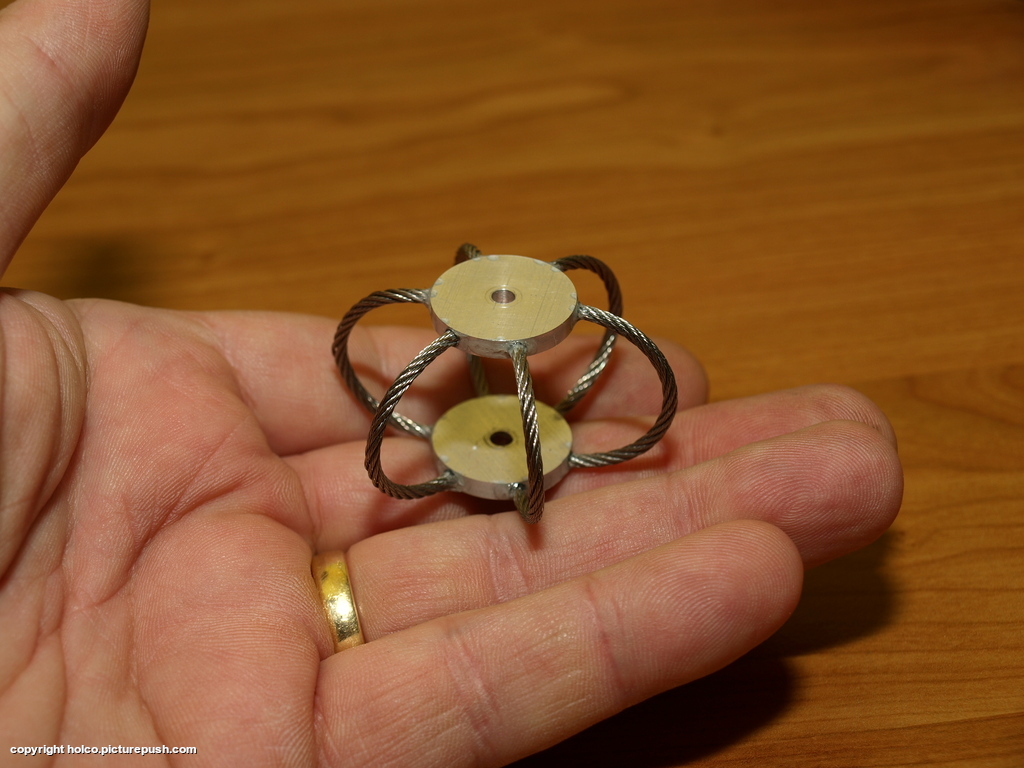
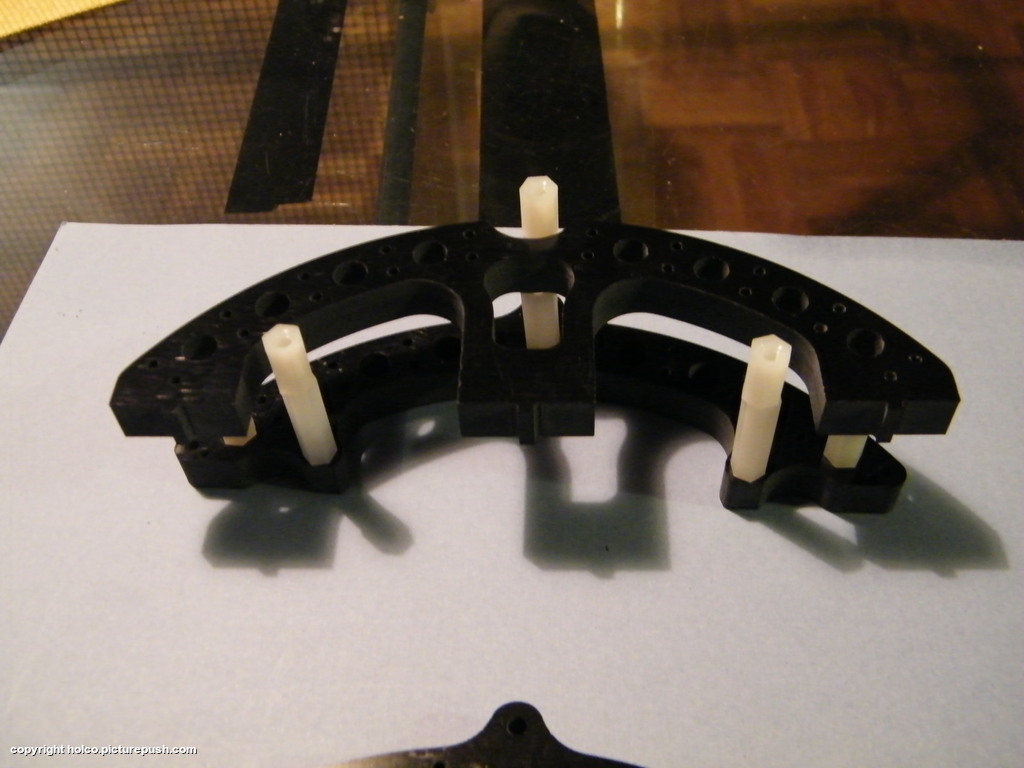
Proto wiredamper.
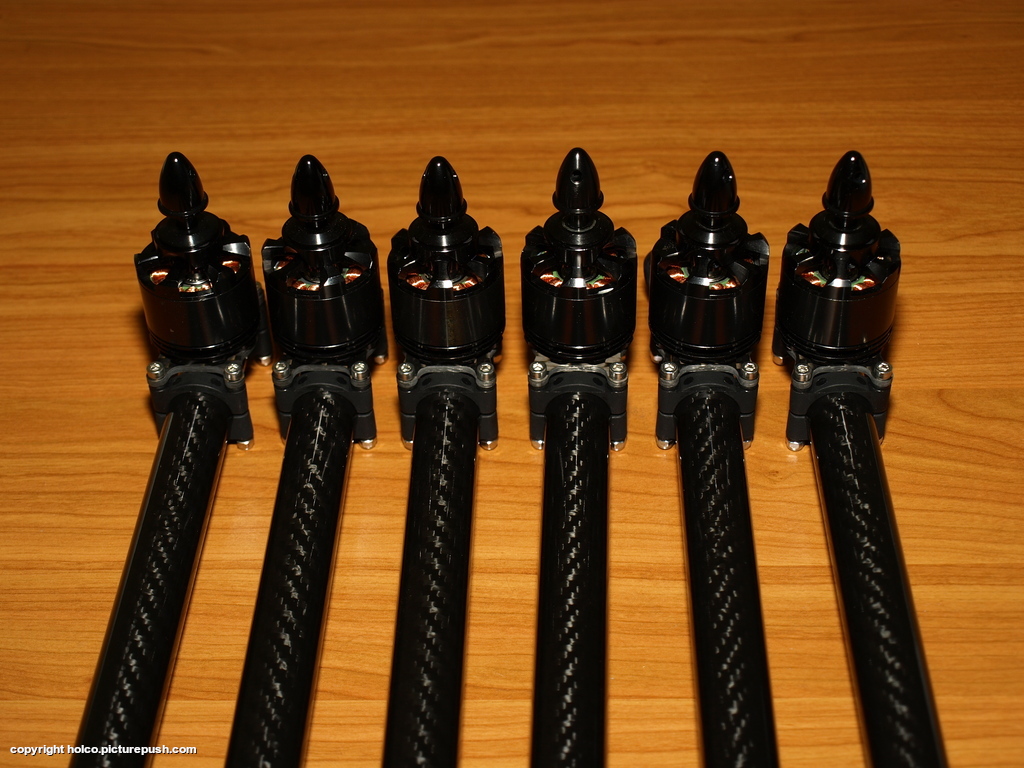
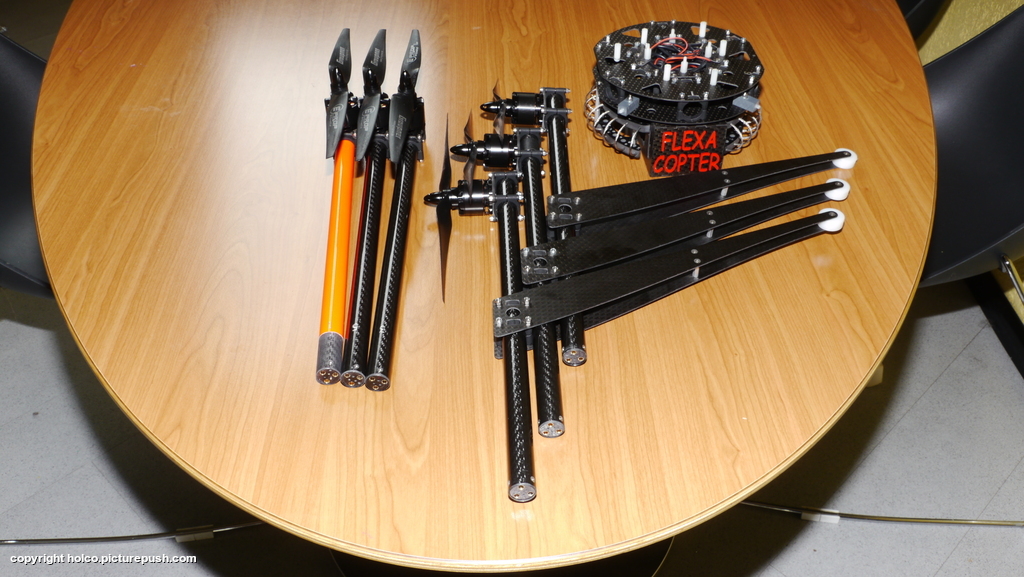
6 booms & motors
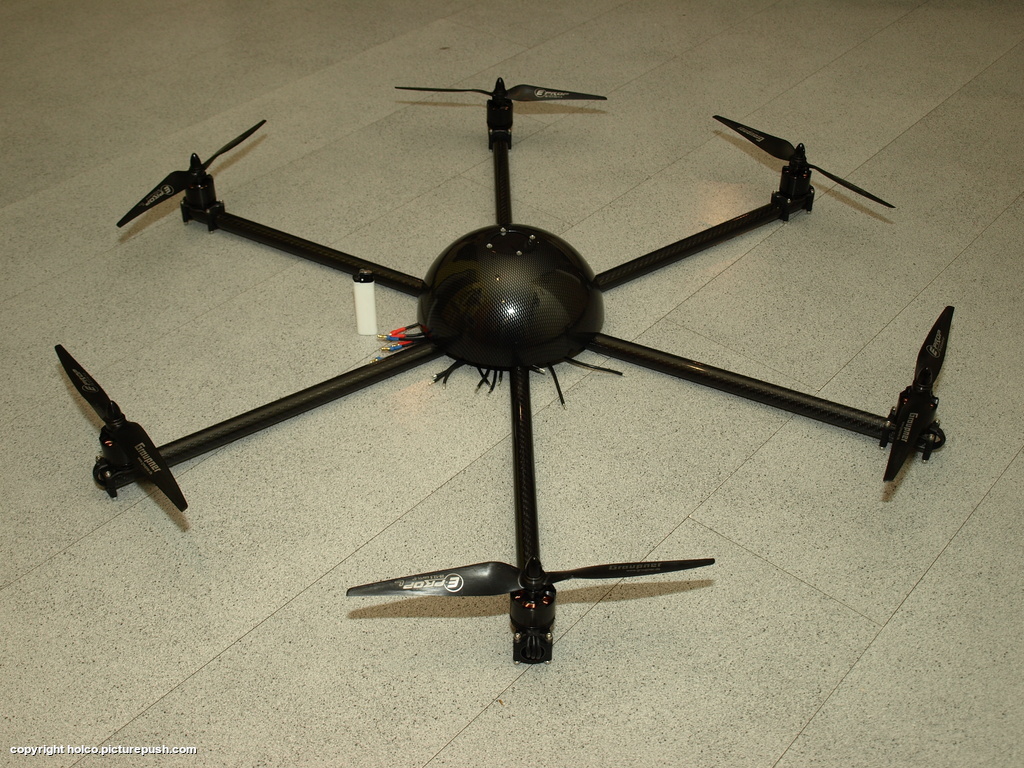
First mockup
Wiredamper study.
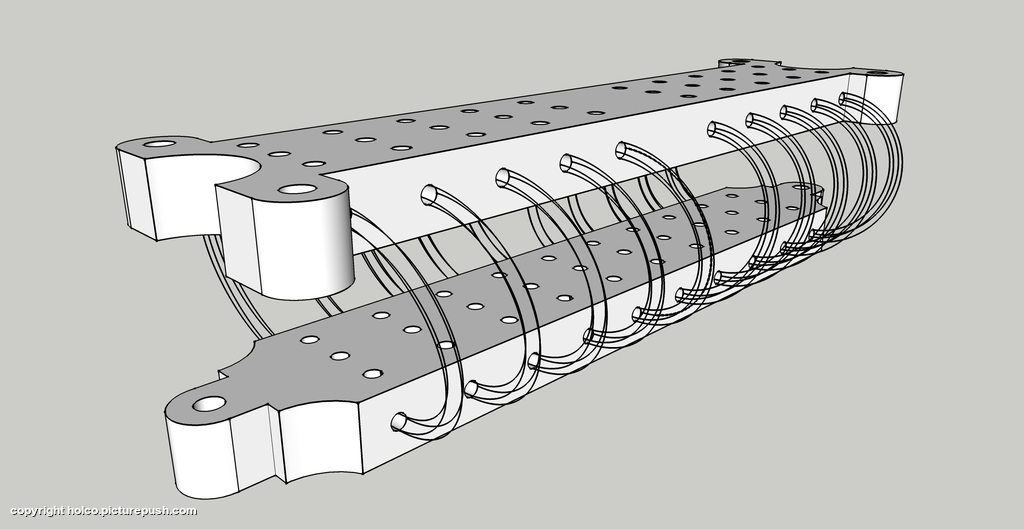
Easy on - off connectors tryout.
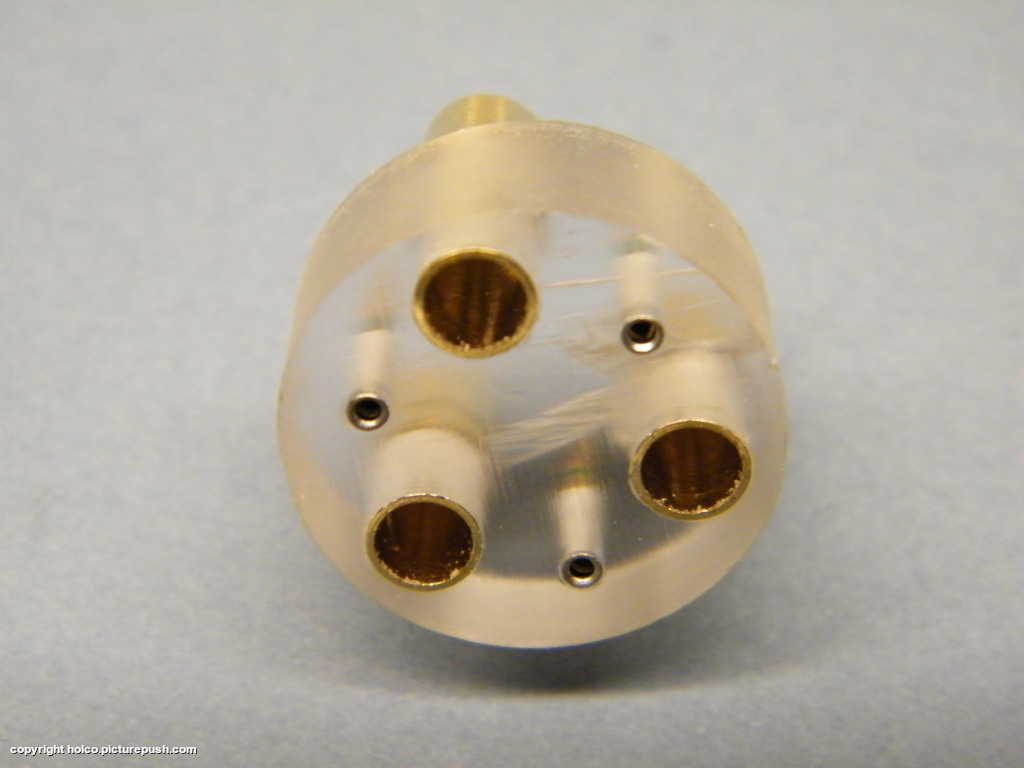
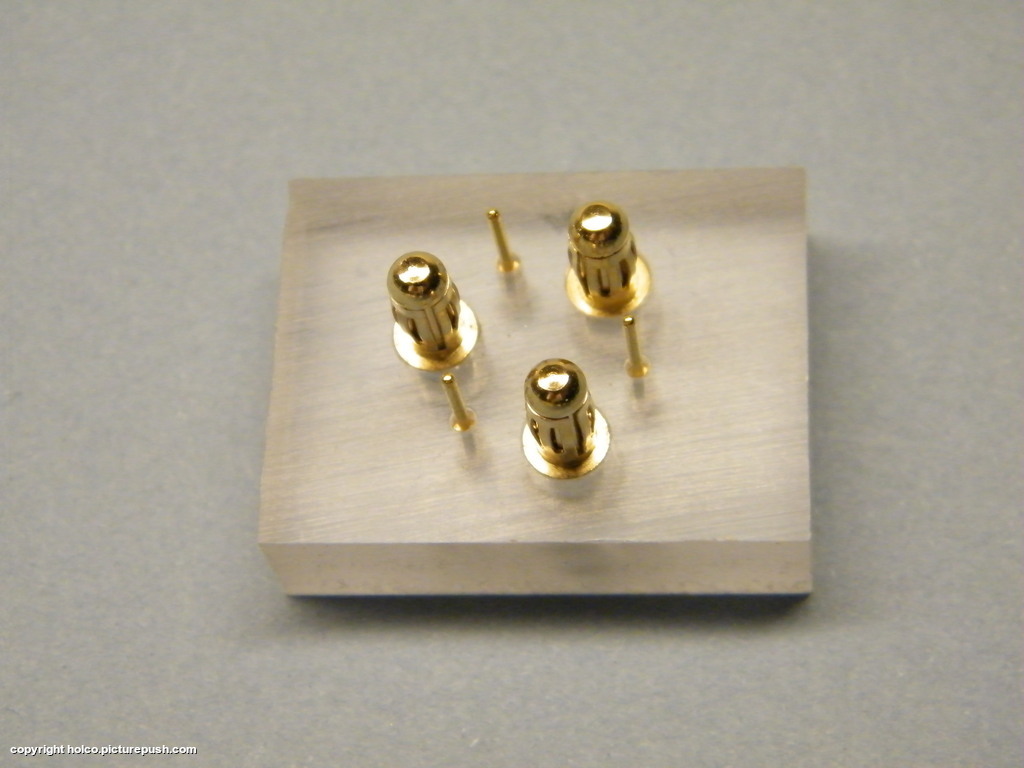
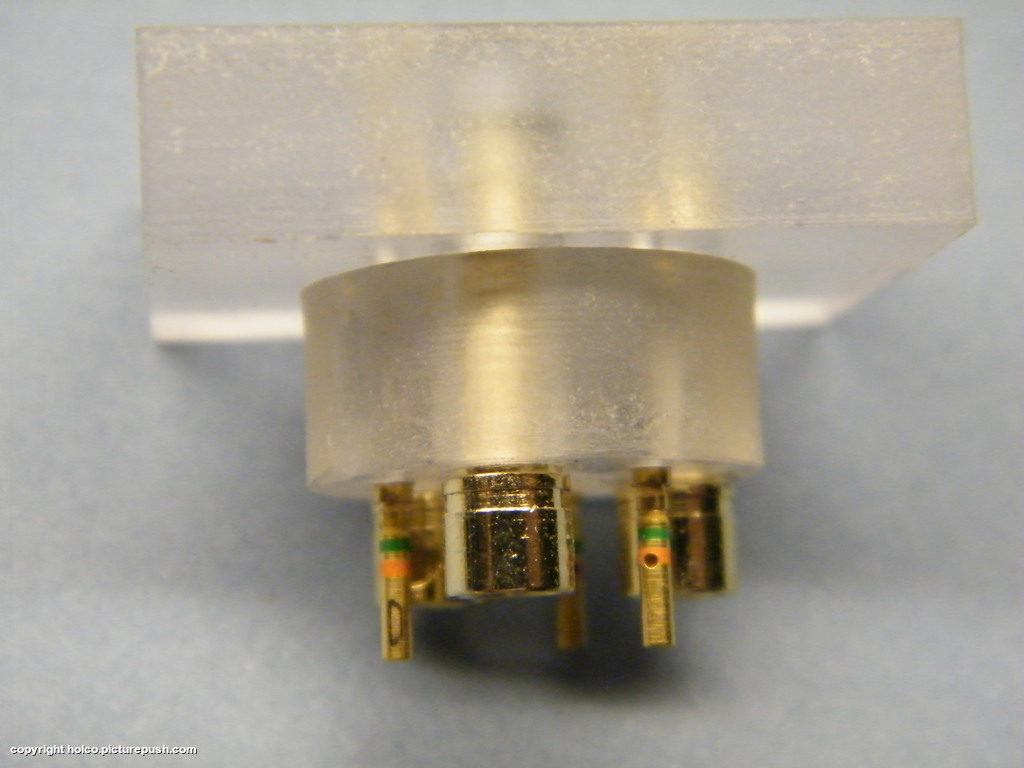
Final wirde dampers.
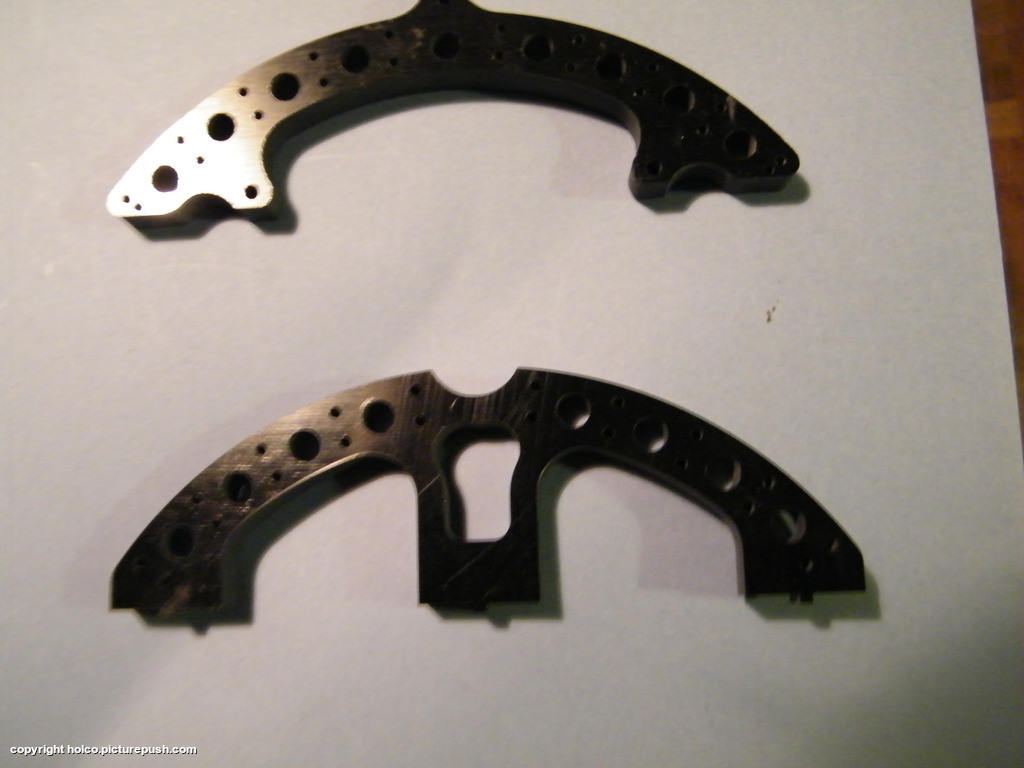
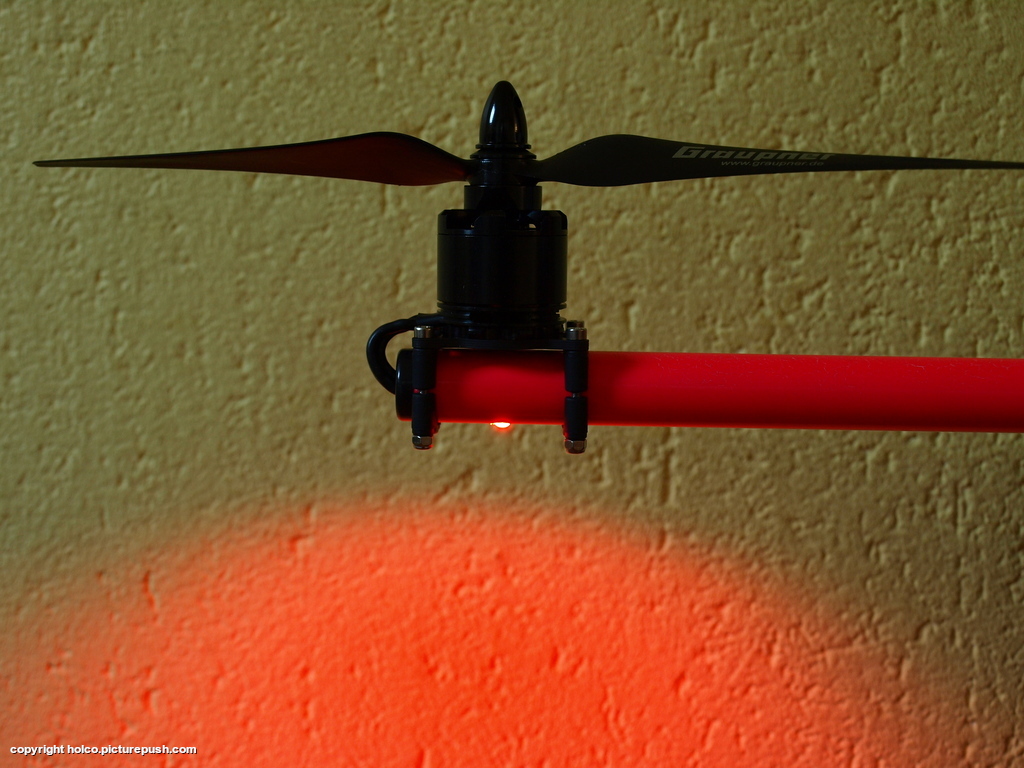
Buildin LED's
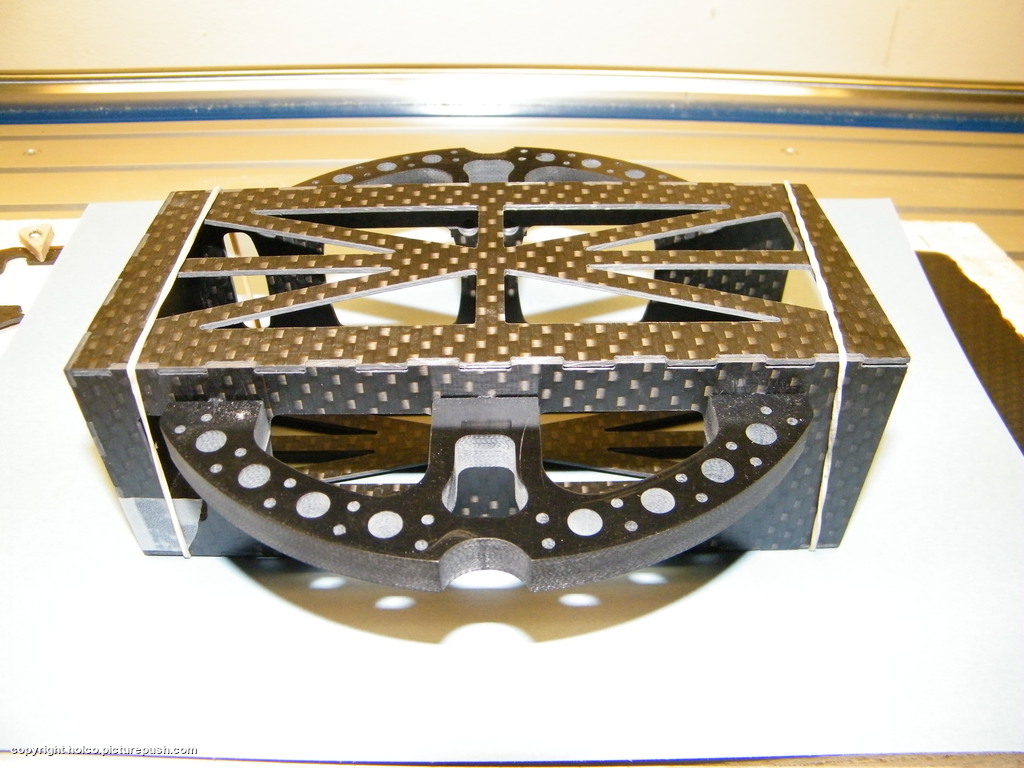
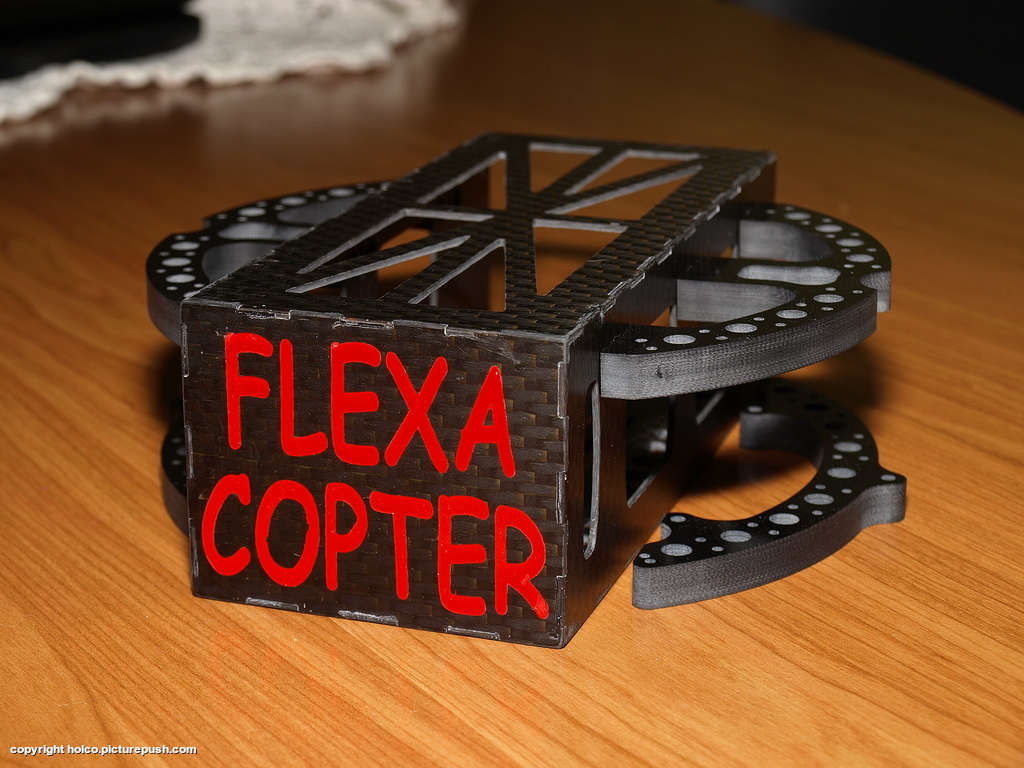
Batterybox with integrated damper.
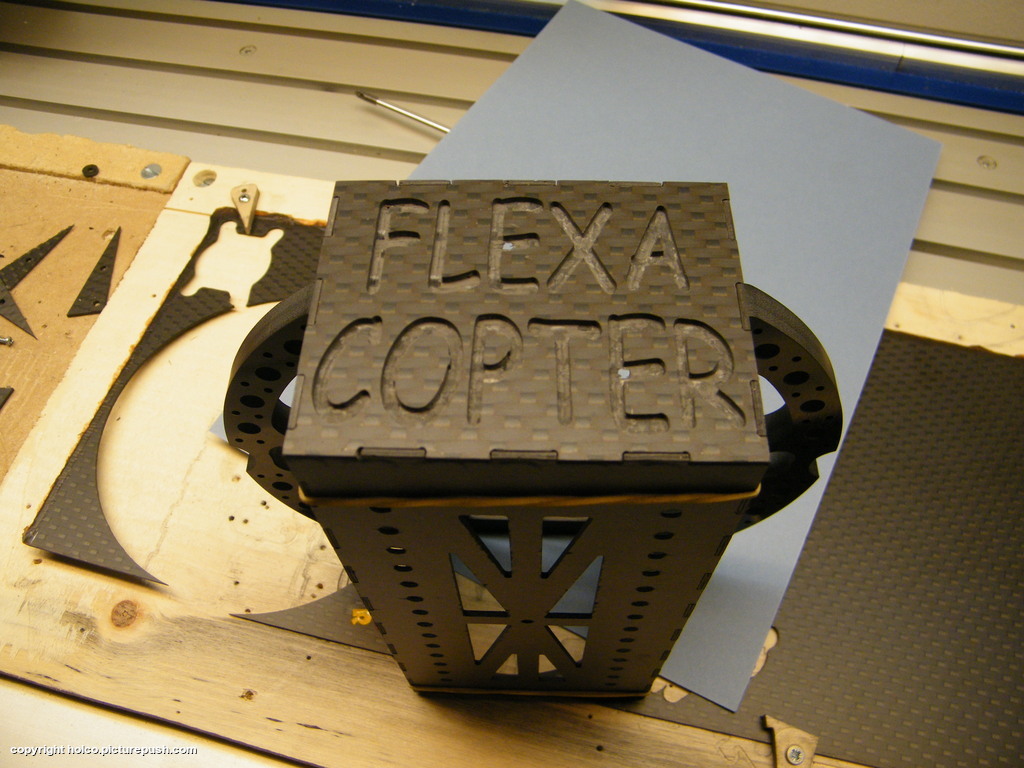
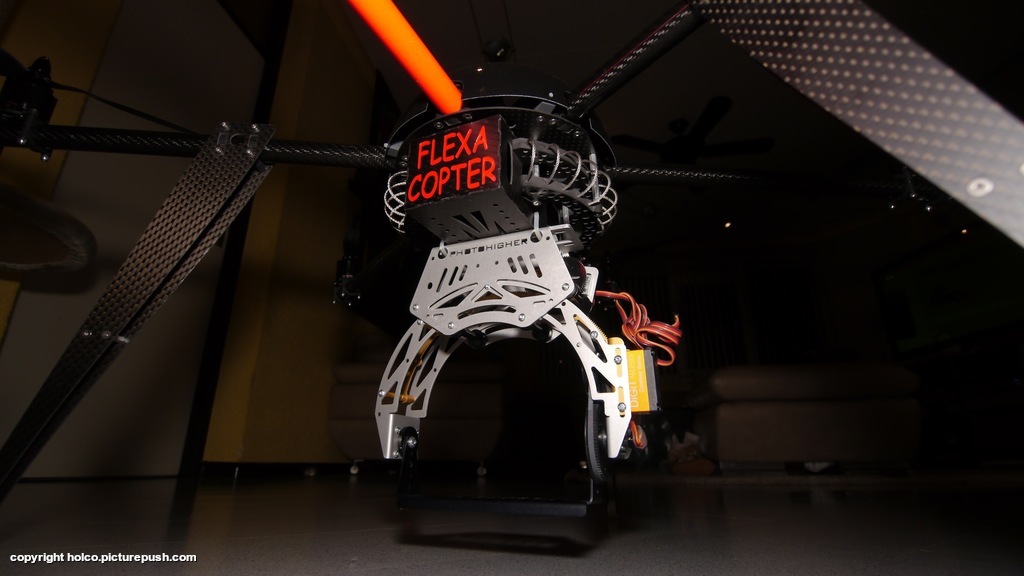
Flexacopter is born.
I love red.
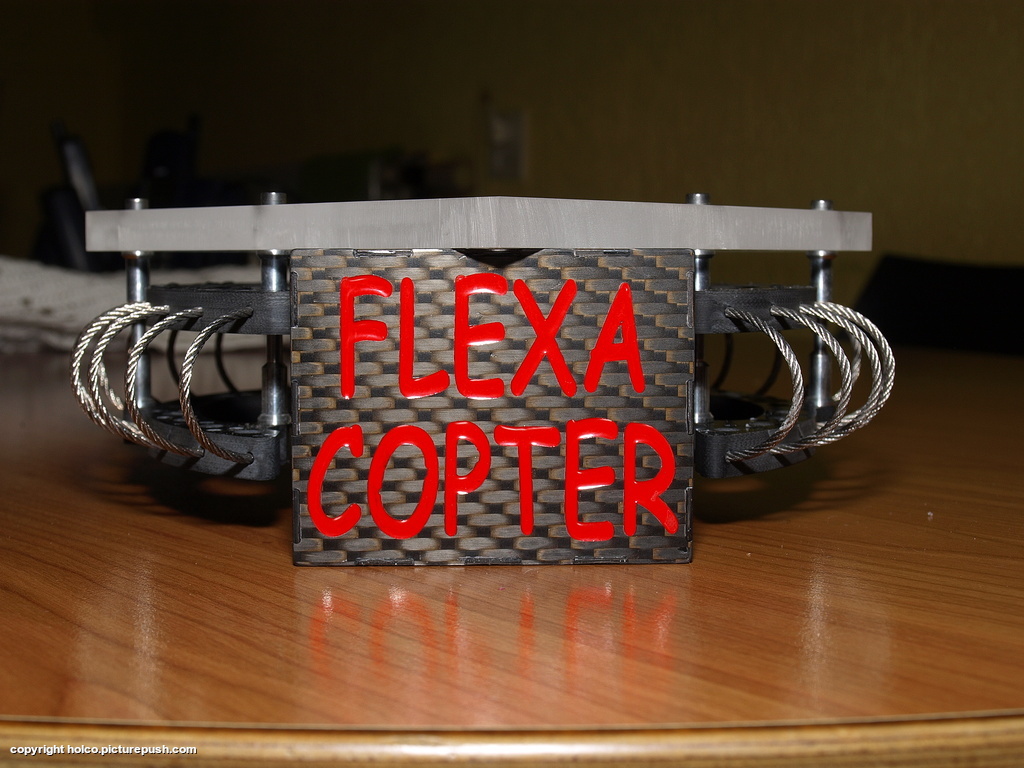
Mounting the wires.
Me.
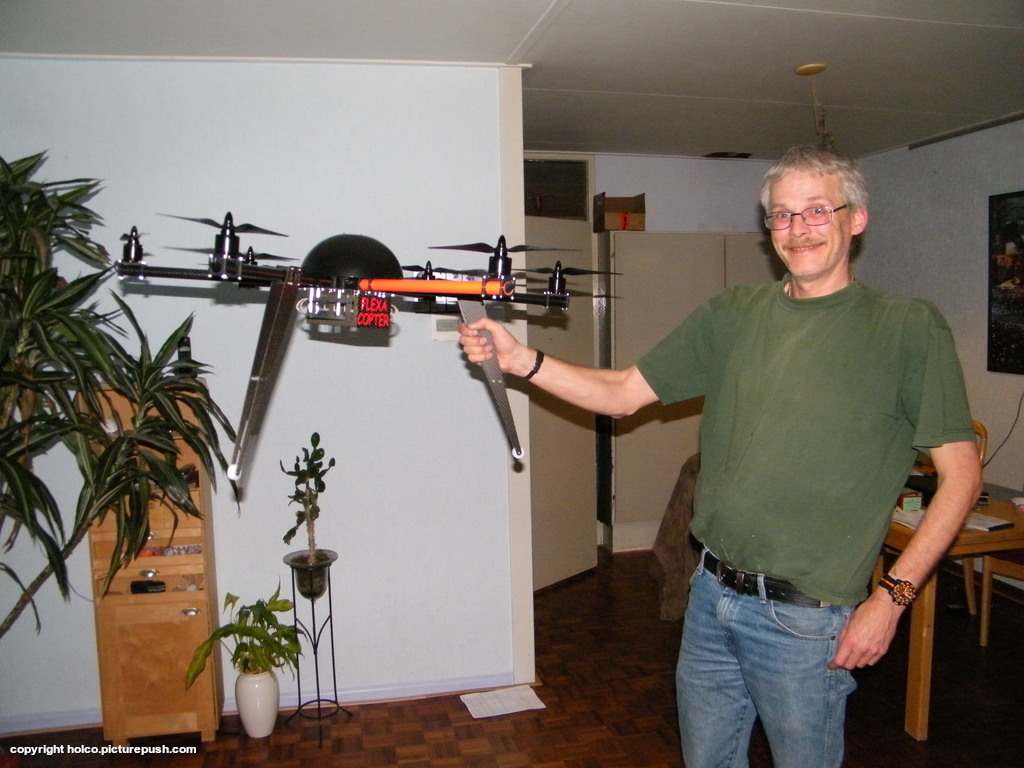
Mario.
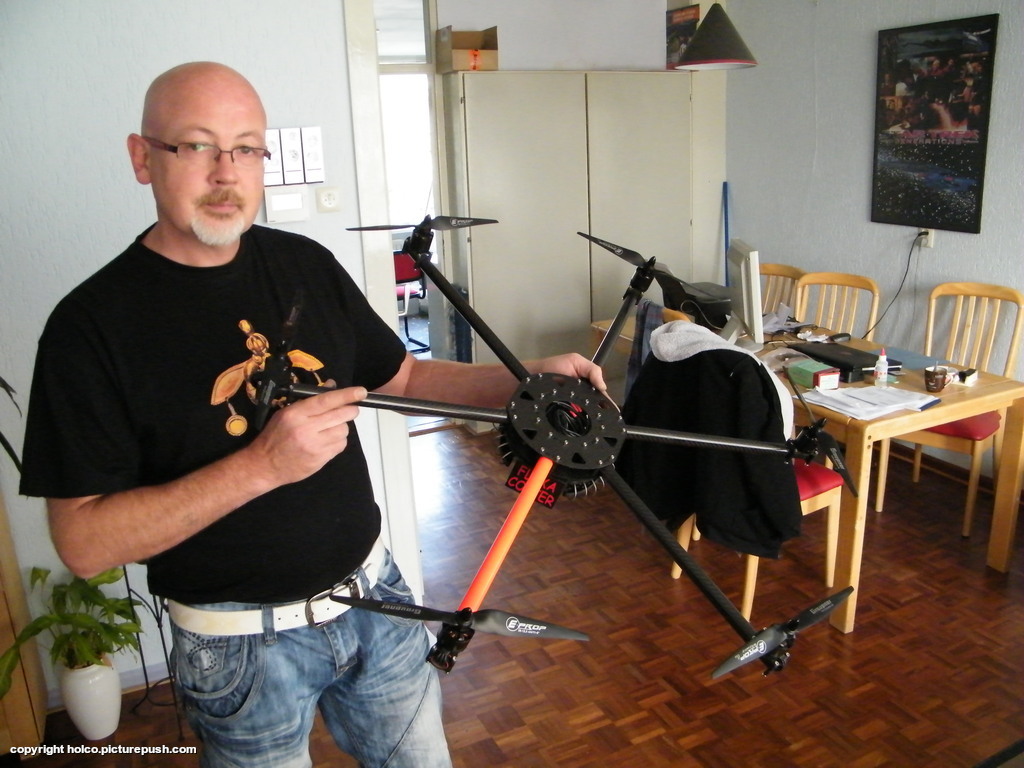
Nice picture.
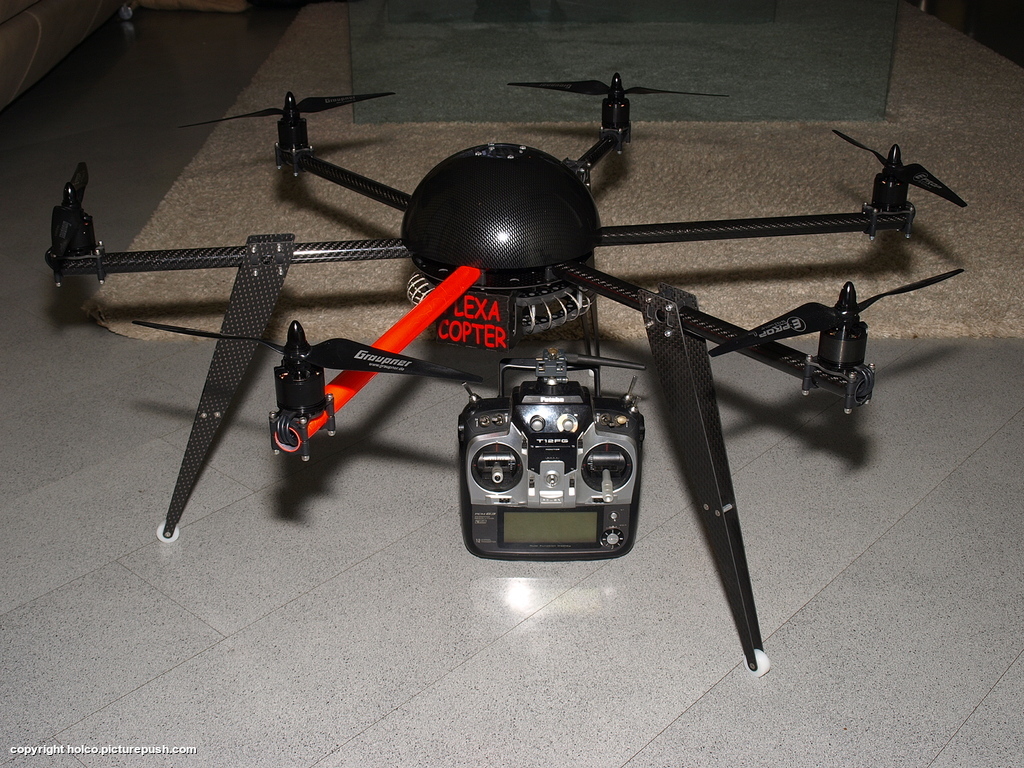
Up close.
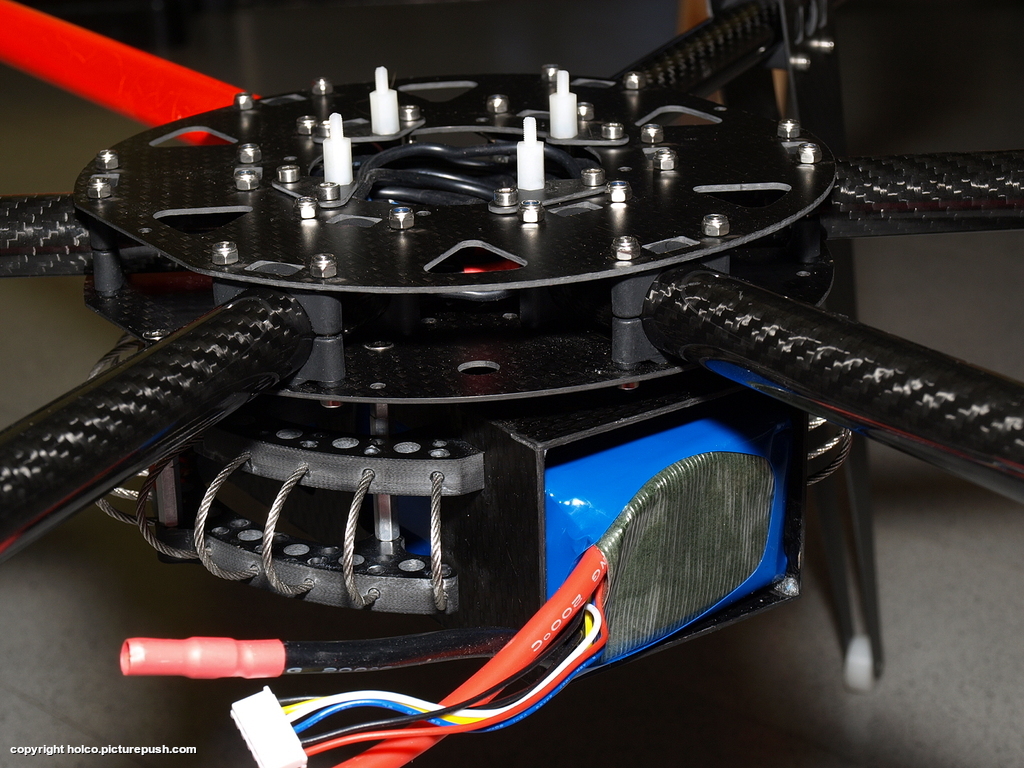
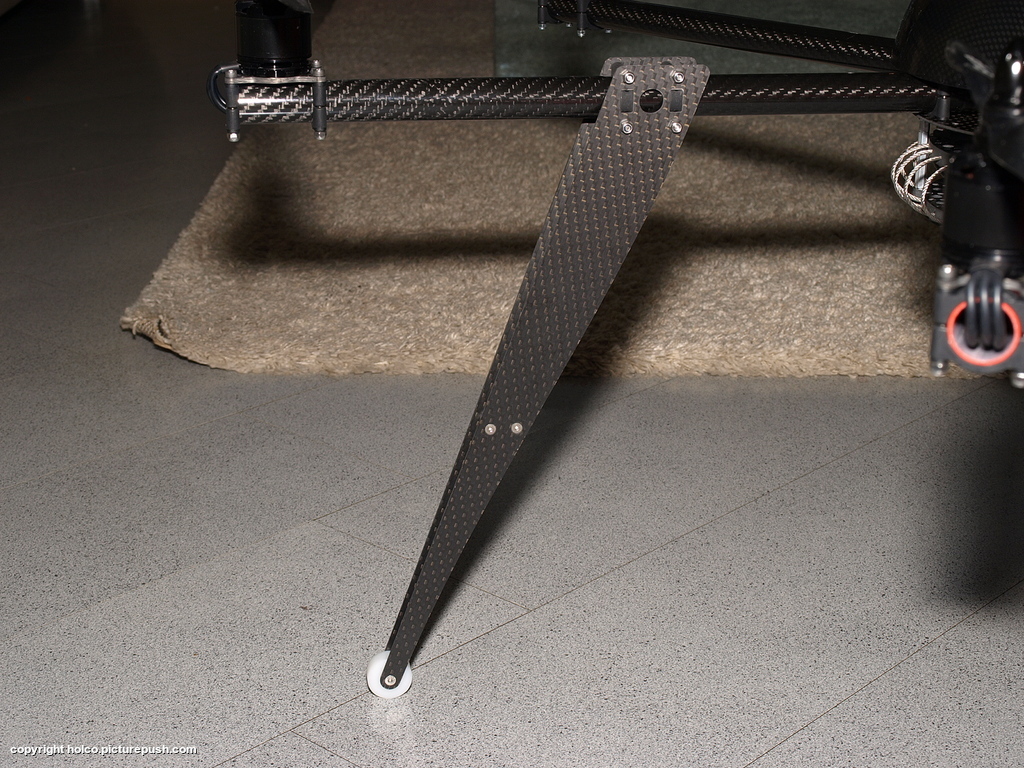
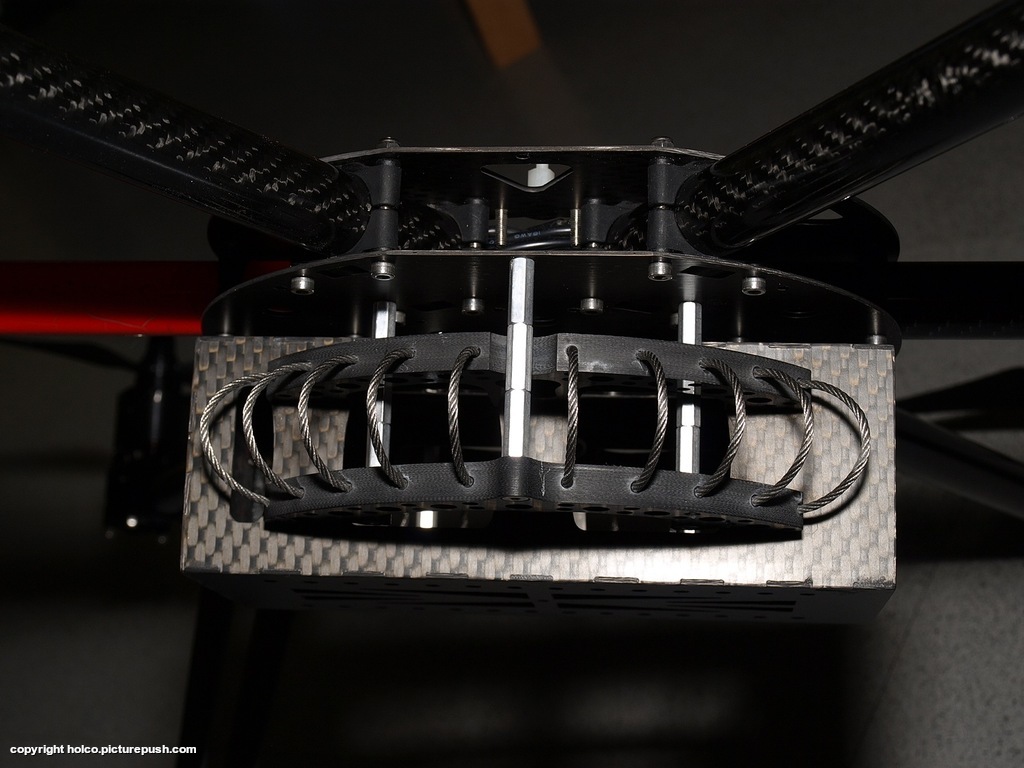
The easy on - off's
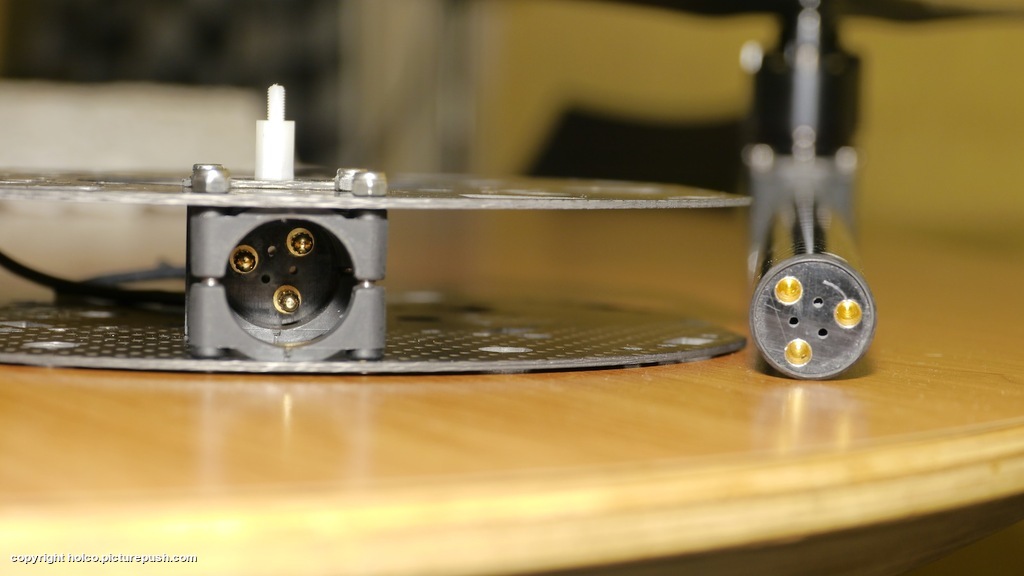
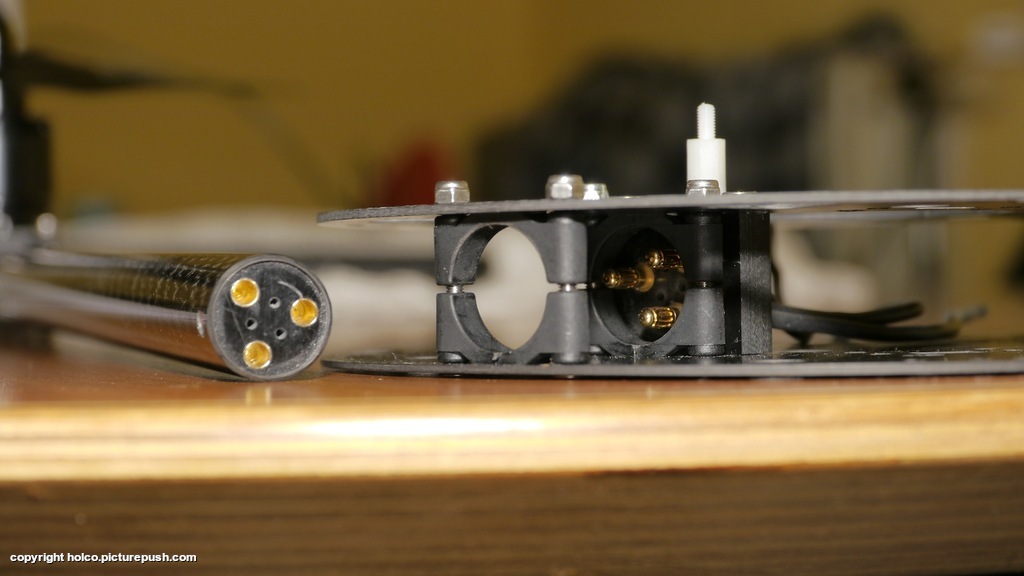
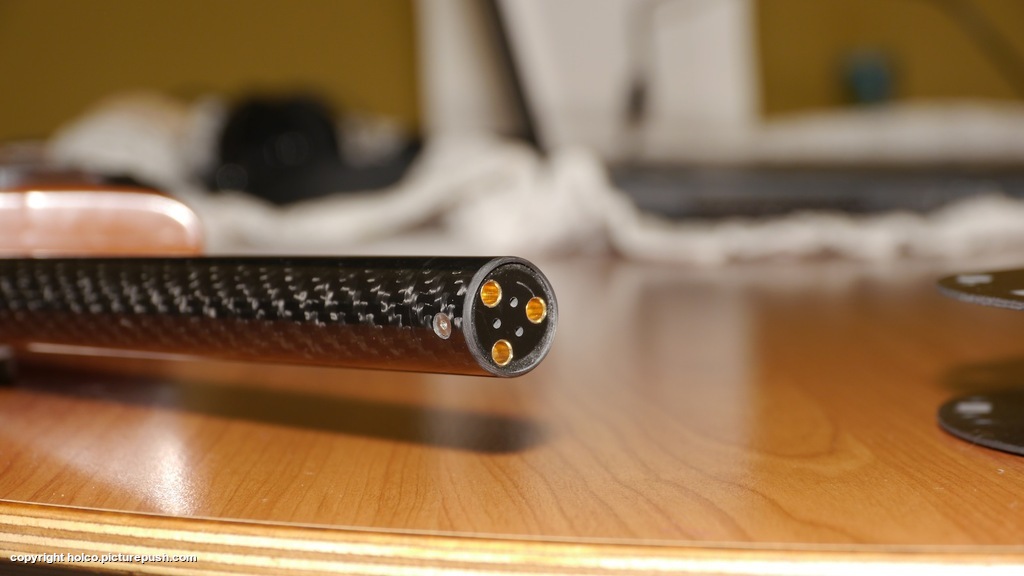
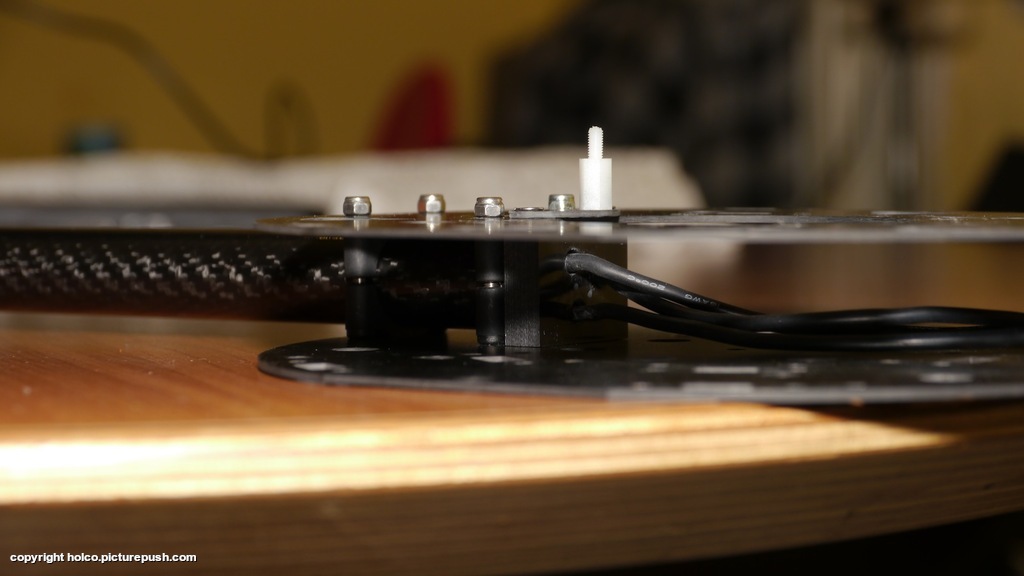
Assembly.
The dampers.
What a set.
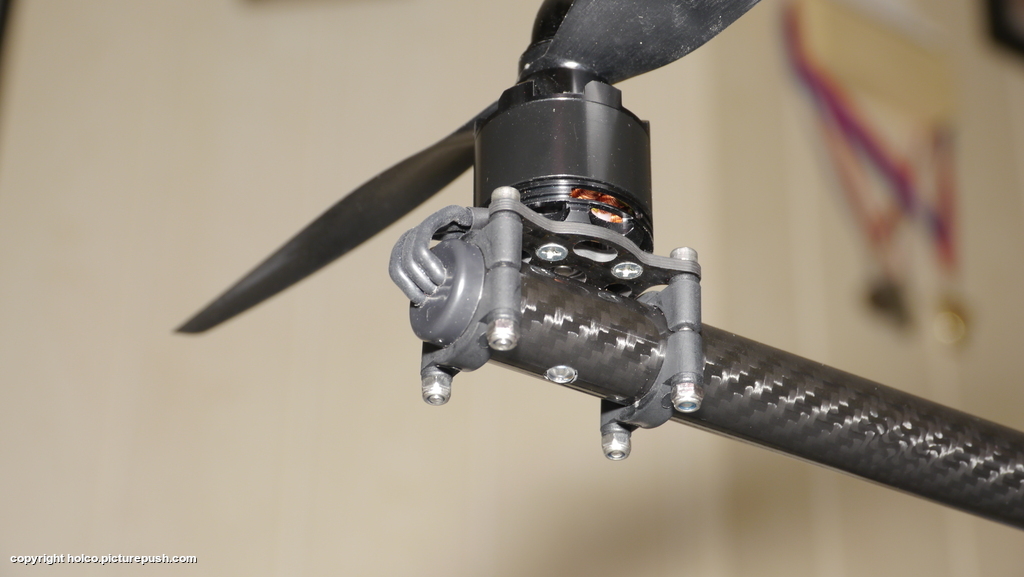
Detail.
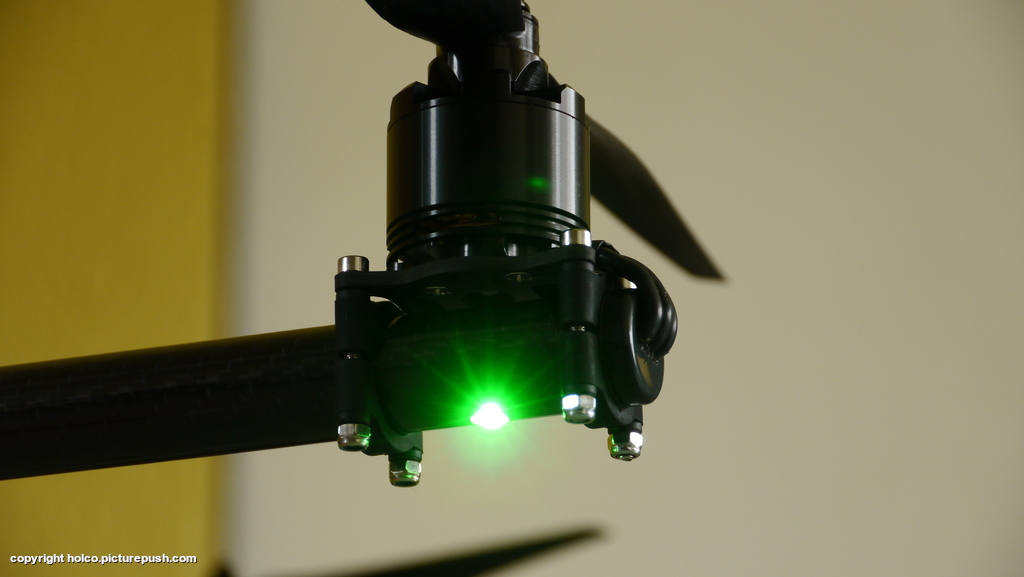
Green.
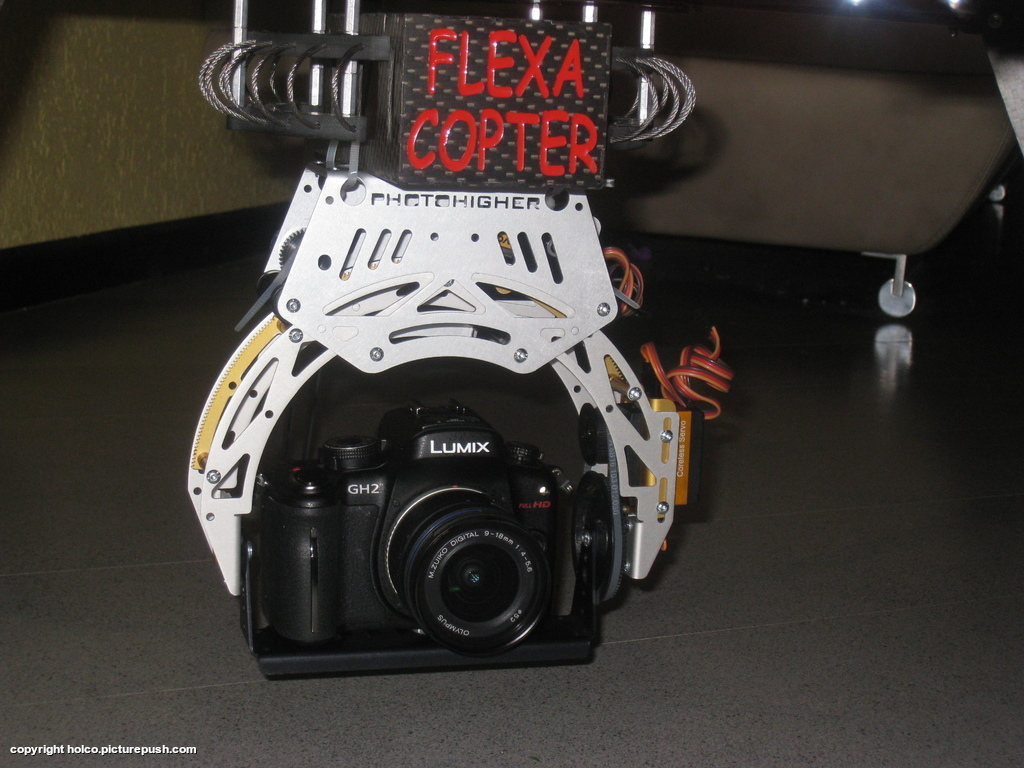
Testfit.
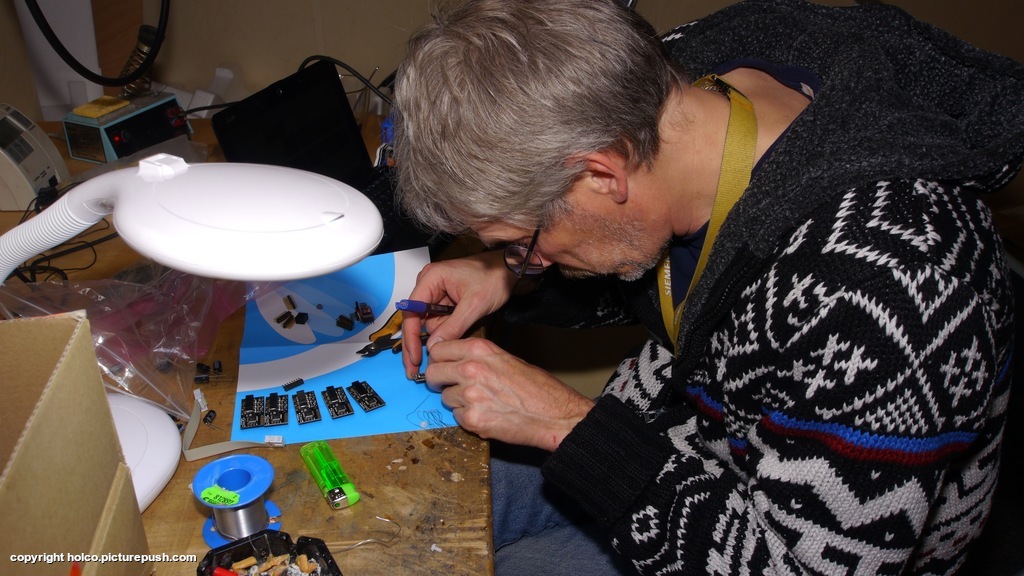
If you build a hex you got to do 6 controllers .....
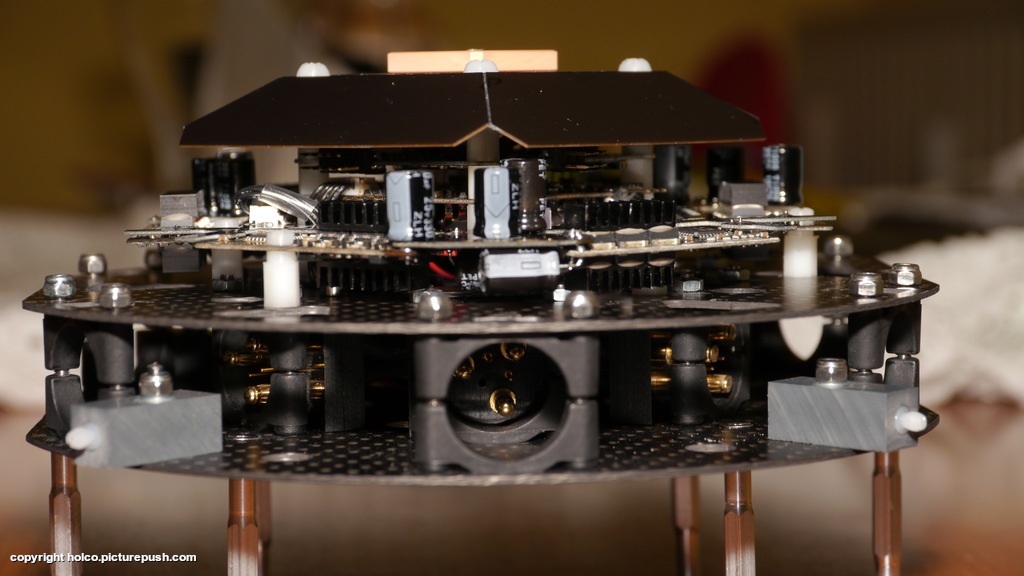
The whole MK setup.
Even before maiden people believe in our design. MASS PRODUCTION

First customer frame ready for shipment.


and now? .....Tomorrow we will complete the Flexacopter build. And if all is ok saturday will be maiden day.

Comments
Can you also PM me wen you have kit prices please.
Keep following this discussion, I'll post it once I have my centre hub design finished.
@ mikefedak. Thanx for your comments. Right now i am in the process of finishing the first alpha kits. As we did use some verry expensive and time consuming components im looking into more convenient production methodes and suppliers. I will PM you as soon as i have kit prices.
Pieter Jan
Yes, that ring one is intended to be a universal bracket for mounting motors on the top and bottom, as well as the booms to a centre plate. But I got sidetracked a bit, since I'm working on a centre hub that automatically mounts all the booms square. Booms good for adjusting motors angle on the arm. It allows for fine tuning that a square arm does not afford. If your square arms are off centre, or your centre plate is a little warped, your motors won't be square. Also, if you look at the prop configuration page in the wiki, Q8 configuration needs to have a slight angle to the motors, which is not achievable with square arms.
With a DSLR hanging of the bottom I think the wire dampening would be spot on. The strength of the dampening really depends on the amount of mass you hang off it. You would probably have the battery pack(s) attached to the underside as well. The more mass distributed to the movable structure at the bottom the more dampening you will get (up to the weight that the wire can handle). If you were talking about putting a GoPro on then you probably would not get enough dampening, but if you are going to get a rig like this then you are more likely to be using a DSLR anyhow.
Really like those connectors for the arms. Only trade off with that is the extra expense of replacing the CF arms if all the wiring and connectors are fixed in place within the tube.
@Lino, if you want to try out TREX 450 tail booms, which are 12mm. Have a look at mine too. I've already made some samples, and they work out fine. Unless you're building a heavy lift quad like Pieter, the 12mm is more than enough. You can also use my mounts on both ends of the tube for mounting to a centre plate on one end and motor on the other. I've made packs of 4,8,16, and 32 to save money.
Check it out:
This week my testplate will arrive form Shapeways. So i can inspect the tolerances.
So Brackets are still WIP until i have had a look.
@ Lino: Thanx and you are right. I am working on custom clamps for the next batch of Flexacopters. The tubeclamps for the CF tubes inside the fram will have the connectors integrated :) this will reduce weight :) 12 bolts, 12 nuts and 6 GFK blocks to hold the connectors. Oops we might hit the 14Kg lifting cabability :)
Here you can see where the mount adapter plate will be fixed on the battery container, the 3mm holes in the battery box are mutually staggered by 10mm and the adapter plate has slotted holes that gif a fine adjustment of + / - 5mm so that the gimbal can be mounted perfectly In the center of gravity on the longitudinal axis, the adapter plate also has a fixt offset of 9mm on the transverse axis so that the whole can be fitted perfectly balanced under the Flexacopter.
-
1
-
2
-
3
-
4
-
5
of 5 Next