Development Update, V4.0 Autopilot from Dean Goedde on Vimeo.
This system sounds promising!
Development Update, V4.0 Autopilot from Dean Goedde on Vimeo.
This system sounds promising!
Using EC3 connections on my quad was a good idea...except when it applied to the AttoPilot 90A sensor from SparkFun. The goal for adding this sensor to the system was to be able to remove it cleanly if needed. The sensor pcb design was changed (from earlier pics in the Wiki) to provide a clean installation of Dean's connectors. What to do? Adapt and Overcome! Behold my solution!
And from the back of the audience I hear "Yeah? So what?" Well the 'what' is the constant challenge we as hobbyists face to take parts and components from different maunfacturers and adapt them to our uses. Have you read the thread on adding this small part? To save you the trouble of looking for it, HERE. Imagine the confusion on the part of the hobbyist who asked if the sensor should be getting hot enough to melt the solder! Wow. The first task I performed after getting a successful adaptation to EC3 was checking for a direct short of the battery connection - none was found. (whew!!) The second task was to insulate the power connections to ensure a short was not added accidently while in use (or crashed).
The solution? Hot Glue! The low temp variety of hot glue guns is cheap and cheap to use. Both sides were sealed off and then tested for mechanical strength. Next was to integrate it into the quad and set it up via Mission Planner. The above linked instructions worked flawlessly to set up the sensor. There is some confusion if you should subtract the 0.3V from the actual measured output from the PDB to the APM. I subtracted it anyway - the MP prompts said I should even if it is contradicted in the Wiki instructions.
The actual function of the sensor can be seen after the APM is reset. It can also be tested with the CLI under the 'tests -> battery ' command string. NOTE: The CLI prompts you with a "Careful" mesage. THIS MEANS THE MOTORS WILL BEGIN RUNNING! ALL THE MOTORS! I did have my propellors removed prior to making the mod but if you, dear reader, decide to add this and perform the CLI tests.. REMOVE YOUR PROPS.
What you see above is the output of the CLI while the battery test is running. Note that 'Careful' actually blends into the 'Hit Enter to exit' string. When I hit Enter, the screen stopped updating but THE MOTORS CONTINUED TO RUN! I tried various commands from 'exit' to 'Cntr-C' to 'stop battery' all to no avail. The motors stopped spinning when I clicked on the 'Flight Data' icon at the top of the screen. I suspect the command string that is sent to the APM to shift from CLI to Flight Data mode flushed the command registers of the battery test states.
The last part of this tale will be a photo of the AttoPilot sensor as installed on the quad. It is installed prior to the PDB on my system but after the arming plug harness (covered in a previous blog post HERE). Thank you for reading this far and I wish you success should you choose to add this neat device to your system.
Doug Weibel writes:
I just got the most recent issue of IEEE Robotics and Automation magazine, which has a theme of quadcopters as robotics research platforms. There is a large article describing the various attitude estimation and control algorithms used in Arducopter, OpenPilot, Paparazzi, Pikhawk, Mirokopter, KK muticopter, Multiwii, and Aeroquad. If you want to know what the difference between what we are doing vs one of the others, this looks like a great resource.
There is also a great article by Robert Mahoney (of DCM fame), Vijay Kumar (from U Penn), and Peter Corke (Queensland U) titled "Modeling, Estimation and Control of Quadrotor". If you want to review first principles and the math basis for quad rotor control, this will interest you.
Several other interesting articles including one on the interface between autonomous and human control, and another on optical 6Dof Pose estimation.
http://online.qmags.com/RAM0912?pg=21&mode=2#pg3&mode2
It's free and the open source flight controller comparison article starts on page 34. Sample below:
I just want to give a shout about a Kickstarter project that I think deserve some attention.
Basically a well established hardware chip design firm, want's to make a $99 parallel "super" computer and needs help financing mass production to lower the cost of chip production. In return for our support they promise full disclosure for all hardware and dedicated open source development tools.
So for a $99 Kickstarter pledge you get:
The reason I am so excited about this, is that this thing is more or less made for next generation autopilots.
- Full blown extended Kalman filter with all the bells and whistles? Would not even break a sweat doing that.
- Real-time visual navigation and object detection? You bet!
- Generate aerial maps on the fly. Be my guest!
You get the idea, and all this would be possible using a 86x54mm board consuming 5W on average. Needless to say I am a bit excited. :)
The $99 pledge is for a 16 core version, but there is talk about a $199 64-core version if they get enough to ramp up the production.
For more information visit the kickstarter here:
http://www.kickstarter.com/projects/adapteva/parallella-a-supercomputer-for-everyone
(More construction photos in link below)
I was flying with an APM2 equipped X525 quad frame but there were a couple of thing I didn't like, namely:
if using a GoPro or other wide angle camera the props would show in the far corners of the video.
Also, orientation at a distance was difficult even with two bright neon-orange legs.
Thirdly, it didn't fold as compactly as I would like for transportation.
Lastly, it looked like all the other X525 framed quads.
So after seeing an H-frame quad on the 'net somewhere I set out to build my own. The first frame was from 3mm ply and balsa using the aluminium arms and feet from the X525 but stiffness was a major issue with motors 1 & 2 sitting higher and at a slight angle while in flight. This caused some strange yaw problems... well, there wasn't any at times, the motor angles cancelling out their yaw effect. I tried covering the ply with very light carbon tissue and epoxy and even some carbon tow braces but could never get rid of the twist between the front and rear arms. A fumbled toggle switch at the wrong moment caused a crash and showed another reason why ply is a bad idea, it breaks very easily!
So...
Next was to find something really stiff and strong, either fiberglass sheeting or carbon, prices were a bit unreal both locally and online, while some suppliers showed no interest at all in selling me any (I'm still waiting for some replies).
I eventually found some 1.5mm woven carbon sheet at Hobbyking but it was only 300mm x 100mm.
The 100mm was fine but I needed 600mm (23") long. This is when an engineering friend came to the rescue (HUGE thanks again, Wladek!), he said I could join 2 sheets mechanically with fiberglass sheet and rivets! So 4 carbon sheets were ordered and some plans drawn up in CAD.
Wladek has some nice machines at his work so we were able to do some very accurate drilling, milling and cutting. 12mm aluminium square tube was sourced locally and milled into a C-channel, saving 1/4 of the weight. Two 0.5mm plastic strips were used to make up the extra 1mm thickness (the X525 arms are 13mm). The carbon is riveted with 3208 rivets to the c-channel.
At first we used the carbon in it's original rectangular shape but we have since cut down the sheet to its present form saving 1/3rd of the weight. If I had to do it again I'd use 1.0mm sheet rather than the 1.5mm saving another 1/3rd. Also initially the ESC's were inside the frame but after many unexplained "ins" and other problems in which I started to suspect an overheating ESC, I have now moved them out into the airflow under the props and all seems well.
Anyway, it flies really well, looks great in the air and fulfils all my requirements, especially no props in the video! (See here). Final weight is 1279g (45oz) dry, with a 3 cell 5000mAh LiPo adding 353g (12oz) totalling 1632g (57oz), about 250g (8oz) heavier than the X525 with the same hardware. Flight time is about 13 minutes. Motors are 20-22L's, ESC's are Super Simple 20A, batts are Zippy Compacts (3S 5000mAh), props are 11x4.7 APC SF.
More construction photos here: Picasa Album
Cheers
link to CAD file>H-Frame2.dwg
HefnyCopter Firmware works in KKv2.1 as in the demo
https://www.youtube.com/watch?v=55Ab4BfcQss&feature=relmfu
can switch between X-Mode & Plus-Mode.
there is also HefnyCopter2 that works on KK2 it has more new features:
1- BuddyMode where u can train ur friend using another 2 TX at a time.
2- XBEE connection where u can connect your quad to PC.
HefnyCopter is released wheile HefnyCopter is still in final developing phase :)
I made up these hi tech shock absorber legs for my grandsons quad we are building. Considering the hours I often spend to find a better design for making copter legs that don't disintegrate on every hard landing, It took me about 10 min to stop laughing from the simplicity of the brilliance of this light bulb moment..
T-Rex 450 Test flight -- Loiter / Guided / RTL and Alt Hold
APM 2.0 firmware 2.7.3
MediaTek MT3329 and barometer
After replacing the hidden Torque Tube Bearing in my T-Rex 450 the shifts in attitude are gone.
Everything changed to the best.
I found a great new flying field, so I went to test Loiter, Guided and RTL, Alt Hold worked always great. I planned a mission too, but the wind became too strong after a while so I will try this another day.
As you can see in the video (thanks to my lovely wife) everything worked very well.
This are the PID I used. The Nav speed is low 2m/sec which is relaxing to watch and you have no overshoots.
Thanks a lot DIY Team.
We sent out an email today to all our distributors, if you did not receive it please contact sales@3drobotics.com . We are trying to make sure we have all of you in our distributor mailing list.
thanks
-3DR
Foam Tail Pusher
Range check is always a god idea, especially when using an new rx!
Do not think there will be any more flight test this week due to bad whether, plans are to scale up the frame to host APM.
My Hitec minima range is horrible 15 m at Aurora 9 Tx at full power I tested whit rx, battery and one servo.
Anyone any ideas?
Project objectives
1. Easy build 2 hour + CNC cutting
2. Dead cheep
3. FPV APM
Anyone else interested in testing the frame let me now.
New video from ETH Zurich’s Flying Machine Arena, you can read more on Robohub:
http://robohub.org/video-watch-flying-robots-cooperate-throw-and-catch-balls/
PS. Robohub.org is an online platform that brings together leading communicators in robotics research, start-ups, business, and education from around the world. We just launch the beta version, take a look! http://robohub.org/
We've covered this before, but Hackaday has a good update on the latest ground-based power techniques:
Lasers can no be used to keep a UAV in the air indefinitely. The trick is to add an array of photovoltaic cells specifically tuned to an IR laser’s wavelength. A ground system then directs a high-intensity laser beam onto the aircraft’s cell array to transfer energy while in flight.
After the break you can catch a video from a trade show where a Lockheed Martin employee describes the successful testing of such a system. But there’s a lot more information available in the white paper (PDF) which Laser Motive has released. They’re the folks behind the technology who have teamed up with LM to implement the system. The laser unit on the ground can track a UAV visually, but there is also a method of using GPS coordinates to do so in the case of overcast skies.

The Google Earth blog reports:
Over the years we've seen quite a few games that use Google Earth as their platform including gems such as Ships, Google Earth War and the GE Flight Simulator. Now a new game is in development and it appears to have a ton of potential: Geoception.
Here's a brief description of the game from the developer, Satyen Sarhad:
In a nutshell, you command and control a fleet of combat drones to provide local and regional security, eventually taking over the whole world. My aim is to make the game readily skinnable so arbitrary models from 3DWarehouse can be dropped into the game to replace the existing model assets. I have great hopes for this gaming platform, although (as you know), there are technical issues with achieving a decent frame rate in newer, out-of-process-plugin browsers. Nonetheless, I stuck with development and put together a limited game demo (that plays best in Firefox 3.6) that lets you fly UAVs around any city in the world, and shoot at various targets to earn XP:They've produced a trailer for the game, and it looks quite impressive:

Green doesn't mean that this version is lower power consumition, it is the board color in that series of clones of our ArduPilot
I have a question: Do you think it's safe to buy one of this versions?
Best regards,
Miguel.
Most of the pro multicopter set-ups have feedback from the ESCs so the controller knows the status of the motors. This is useful for all kinds of reason including:
1. debugging the causes of crashes - the controller could log when a motor has stopped running.
2. allows faster and better reaction to a motor failure perhaps saving you from a crash at least for hexas and octas.
3. automatic generation of a linear thrust curve which makes life easier for the attitude controllers.
As a first step towards trying to make that functionality available for the hobby/diy market I've managed to hack a hobbyking RedBrick50Amp and load it with a modified SimonK firmware so that it sends back timing information using the SPI bus to an APM2. This modified SimonK firmware is in my clone in the spi_feedback2 branch and the changes were pretty minor as you can see here.
Here's a picture of the set-up:
Now, it's really a first step, there are a few issues:
- It only works on the RedBrick50Amp because that's one of the few ESCs that is not using the SPI bus's slave select pin to control one of the FETs also you can see I needed to do some careful soldering to attach a pin directly onto the Atmega8. To make it available to all we'd need specially manufactured ESCs.
- Using the SPI bus would mean a lot of wires to the APM2. 5 wires from each ESC (mosi, miso, reset, slave select, clock) and 4 wires + 1 wire per esc on the APM2 side. I might look into trying to use I2C instead which would be just 2 wires per ESC.
- the feedback is the timing (in nanoseconds?) from when the ESC last switched the polarity of power to one of the wires. So the feedback is non-linear..you get very accurate feedback when it's moving slowly, but lose accuracy as it gets to the high end of it's range.
Still, a step in the right direction I think. All feedback and advice welcome!
For the month my father-in-law and I have been working on a Power Wheels conversion to RC+Rover+Drive by wire. I have an 18 month old son and we wanted to build something he could enjoy before he can physically control the vehicle by himself. So far we have been focusing on the mechanical+drivetrain aspects of the build, but last night I finally got it to a point where we are ready to use the APM2.5 with ardurover code.
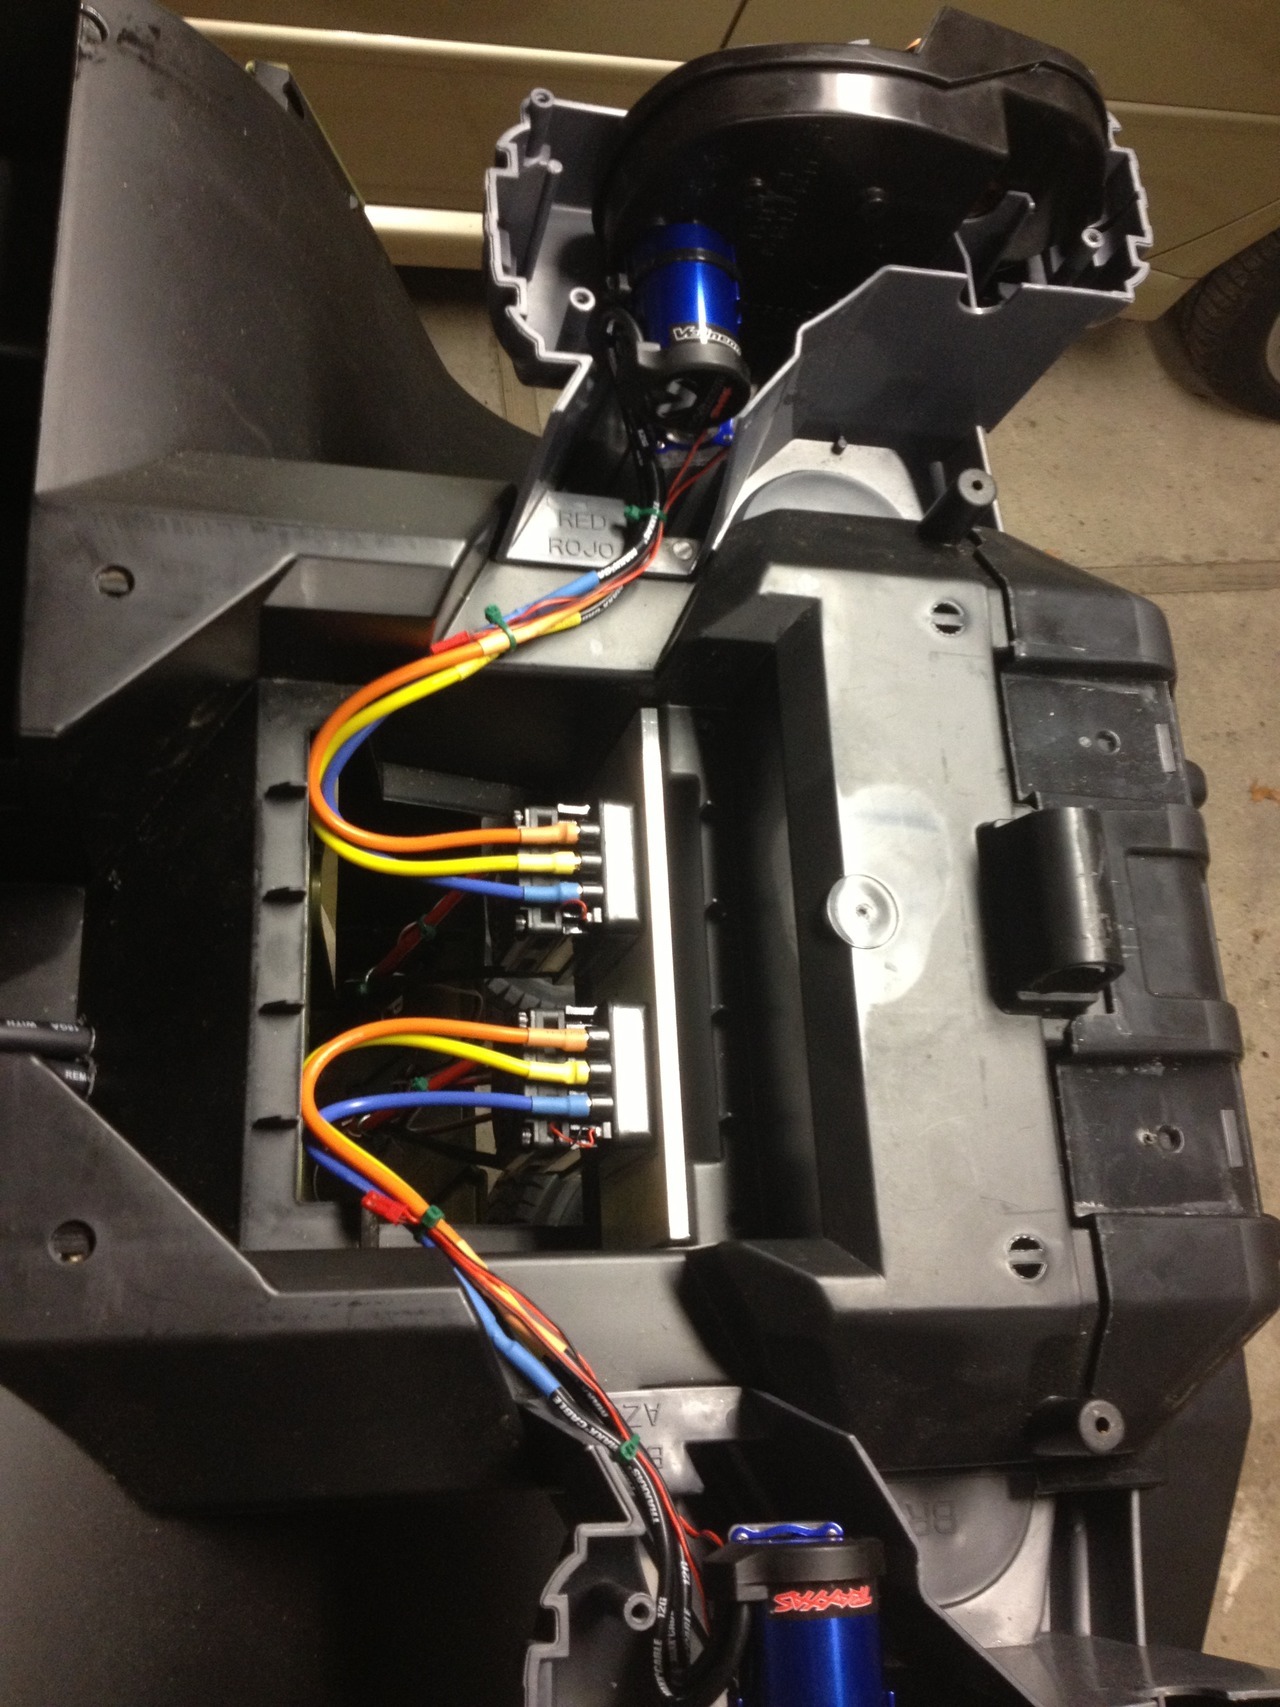
I am going to be heavily modifying the ardurover code to support local "drive by wire" via analog inputs. The steering wheel assembly now drives a 10k ETI pot, and the throttle controls a linear motion 10k pot (pictures will be posted on the blog shortly). I would really like to hear some suggestions as to where I should implement the output channel insertion code. I have a few ideas after reading over the current codebase, but would obviously like to implement this in a way that a) can be reused by other people, b) fits within the code guidelines as defined by primary ardupilot developers.
My project blog is here at: http://projectable.me I would love to hear some feedback on this.
Here is a fresh news from Italy, a drone startup called ItalDron, located in Ravenna (Italy), helped police forces to unveil a undercovered marijuana farm near the town. It's the same company which provided AP coverage during last May' central Italy earthquake. Now It's going viral through social networks and blogs!
here's some news coverage:
http://www.tmnews.it/web/sezioni/video/20120926_video_10173979.shtml
http://it.euronews.com/flashnews/1670068-droni-antisisma-scovano-vivaio-cannabis/
here's their FB page:

I got hold of a Arduino Mega ADK clone , which has a MAX 3421E USB host interface hardwired on the board. Due to some recent code changes, I can now use it with the USB Host Shield library. I have been successful in interfacing Logitech joystick to it and am getting readings on the joystick axes :)
With the arrival of ardustation-ii and ardustation-mega, integration of joystick control using the Mavlink R/C override function could be easily accomplished and easy control like a R/C controller could be achieved without lugging a laptop around.
Presently, the example HID joystick code that comes with the USB Host shield library gives hexadecimal numbers with changes to the joystick axes. I'd like to combine this with Ardustation and a 3DR radio for a small GCS with joystick control.
I am not that good a coder, so I need some developers like Tridge to help me out. I have all the hardware, and just need help in coding. I could help in troubleshooting all code on my side with the H/W. Alternatively you can just buy a USB host shield(cumbersome) and attach it to a Arduino. I checked out Mavlink page and the Mission Planner development wiki, but not much info on the R/C override.
I only need a Xbee 'air' adapter and a 12x6 LCD (not available in India)or a GLCD for the full ardustation setup for testing. If anybody has any old/extra, please PM me.
If you want to help/support this project and think you would be benefited by it, just leave a comment below with your opinion :)
Kabir

As part of a plan of action to launch a non profit club, the Amateur Autonomous Vehicles Association (AAVA), I am putting together a short (20-30 minute) lecture on what is going on in the amateur autonomous vehicles world to be given at the University of Texas at Arlington campus (UTA) next week. AAVA will ultimately sponsor autonomous vehicle competitions in the Dallas/Fort Worth area to include college students and individuals.
UTA has an AV lab that annually funds aerial and ground based unmanned vehicles and has master degrees in AV so I offered to give this short lecture to the local interest group there.
I wanted to take this opportunity to reach out to the largest AV community I know of to ask for suggestions on topics as well as pictures, statistics, opinions and any other information this community feels is important to give to young college students looking for something fun to do with their lives. Any ideas would be most appreciated and I will post the final lecture in case anyone else wishes to use it in the same manner.
I wish to cover, briefly, laws as they currently stand, types of vehicles we decide to build, cost, dangers, what equipment is available, who does this kind of thing as well as any other topic you guys can come up with.
As an aside, if anyone is willing to bring their UAV, multicoptor, submarine, blimp etc to let students see and talk about it with them (show and tell!), please send me a message and I'll help that happen.
