All Posts (11086)

Sort by
3D Robotics

Tutorial explains the fundamentals of an IMU

3689479405?profile=original

From Hackaday:

An Inertial Measurement Unit is most often found in self-balancing robots and quadcopters, providing enough high-speed sensor data to keep up with the effects of gravity.  He previously used some all-in-one IMU devices in school which did most of the work for him. But he wanted to grind down and look at what each sensor spits out and how those measurements are used. The first installment deals with the accelerometer, using its data to calculate pitch and roll. For these demonstrations [Anilm3] is using this ADXL345 sensor board, an Arduino, and some processing sketches for testing.

Whenever working with sensors you need to take noise into consideration. The post shows how to implement a low-pass filter in the code which will help smooth out the readings. The filtered data is then fed to a couple of mostly-painless formulas which calculate the movement of the accelerometer in degrees. The demonstration sketch is mapped to a 3D cube to give you an idea of how accurate the accelerometer is. There’s a little bit of lag which would let a self-balancing robot have a nasty fall. The solution to this issue will be discussed in upcoming parts of the series. The next installment tackles the gyroscope sensor.

Read more…

3689479390?profile=originalWe are glad to announce the release of a micro navigation and control module to serve as an autopilot for UAVs/MAVs. NavStik is one of the smallest and most powerful such platforms available with open-source RTOS based software/drivers that can be used for a variety of applications related to mobile robotics.

This module is intended for use by researchers and hobbyists. All the firmware and drivers are available in open-source to help users start building their applications, quickly.

Key features of this module are:

  • 3-axis Accelerometer
  • 3-axis Gyroscope
  • 3-axis Magnetometer
  • Barometer (Static Pressure Sensor)
  • GPS
  • Temperature Sensors for Temperature Compensation of Sensor Data
  • Cortex M4 Based Microcontroller (STM32F4: 32 bit, 168 MHz)
  • Onboard SPI Flash with 16 Mb Memory
  • Connectors for Interface Board (required for power and interface to external world)
  • Connectors for Gumstix Overo® (optional - available from Gumstix; for power intensive applications)
  • Connector for GPS Antenna (optional; required for GPS applications)
  • Differential Pressure Sensor (optional; for air-speed estimation)
  • Power Regulators and Switches (for programatically controlling power to subsections)

Interface board (IvyPRO) provides following additional features:

  • 12 PWM channels: In/Out Reconfigurable
  • Micro-SD Card Support
  • Telemetry Port (UART)
  • 2 Full-Speed USB Ports (one can be used for firmware upload)
  • Port for Spektrum Receiver (UART)
  • Gumstix Overo® UART and USB (2 nos) ports
  • Debug Port (for connection to IvyGS for JTAG debugging and console)
  • Onboard current measurement
  • Battery voltage monitor
  • Efficient DC-DC converter for wide input voltage range (4.5 V - 14 V)
  • Automatic power switching between USB and Battery
  • ESD and short-circuit protection

The ground-station board (IvyGS) connects to the interface board using the debug cable, and provides these functions:

  • JTAG debugging
  • NavStik console
  • Overo® console
  • Telemetry port for GCS (UART)

A suitable interface board may be selected based on the application. A debugging (JTAG) and ground-control-station board (with telemetry interface and console) is also available. For more details please checkout the community portal: http://www.navstik.org. Limited boards are now available and can be ordered from the NavStik store: http://www.navstik.com.

We look forward to feedback from the research and hobbyist community on NavStik and how would they want it to evolve. Please do leave your comments below or write to us at info@navstik.org.

Read more…
Developer

3689479322?profile=original

[ Update at the end ]

You bought a brand new FRSky with 8 channel and a promise of a helpful PPM Sum output.

Be warned that you cannot use this with 8 channels. Only 6 channels could be used with some risks (only 5 for real safety). [Note #1 at the end] It's really disappointing.

Yes. FRSky's CPPM signal has a BIG problem: It has a period of only 18 milliseconds. What does that means? Here we go:

A PPM Sum signal usually has a period of 20ms. As each channel uses up to 2ms so you need 16ms to fully accommodate the data from 8 channels (8 * 2 = 16ms).

Now comes an important element: the Sync Pulse. It needs to be wider than all other ones  to indicate the start of a new PPM train. Any 8 channels system based on a 20ms has room for a 4ms pulse (16 + 4 = 20ms). Even with all the channels at 100% a system like that still gives you a perfect sync pulse.


3689479069?profile=original

That's the BIG problem with FRSKy CPPM. If you start using some switches and knobs you are pretty much risking to lose the sync on your autopilot. Because the sync pulse is squeezed until having the same size of any channel.


3689479378?profile=original

I hope they can fix that with a firmware update sooner, because I believe it's not acceptable.

Until that, you cannot use it on your autopilot without risks. [Note #1 below]

[ NOTE #1 ]

This is far away from the ideal, but there is a cheat to eliminate the risks when using just 6 channels by suppressing CH7 and CH8 from CPPM.

At least on a ER9X or ERSky9X radios there is this way:
By changing your model's setup to use a Proto PPM 6CH it will not output CH7 and CH8.
(The frame space (300uSec) though is just ignored. I did not see any changes.)
3689479086?profile=originalI've verified on Oscope. It works!!! The CPPM was outputed from RX without CH7 and CH8.
Is still a shame and disappointing using just 6 from 8 channels. But that seems to eliminate the risk.

[ NOTE #2 ]

Jani, from jDrones took this issue to FRSky's GM/CEO and got a response from them. They are now baking a solution to release a new firmware. Probably the new CPPM frame period would be 27ms (the next available number dictated by the hardware's clock division).

[ UPDATE ]

Yesterday (28th September)  Jani came up with a beta firmware from FRSky. It does output CPPM frames at 27ms. So far we have some positive feedback from DIYDrones dev team's tests. I'll not update this post anymore. A new post instead will show some results followed by a mini updating tutorial for those CPPM capable receivers. Stay tuned! ;)

[ UPDATE ]

This post shows how to fix it.

--Sandro

Read more…
100KM

Twinstar fpv lost and found by girls.

Ever wondered what happens to your lost drone or plane while you are searching for it ?

Had to make an emergency landing with my fpv twinstar because it lost a propeller.  While I was searching for it, 2 girls found the plane, and their conversation was recorded by the still operational HD camera.  I was quite amazed by their technical insight and conclusions !

Enjoy !

Read more…
Moderator

Autonomous Vision-based Flight through a Forest

From the description of the youtube movie,
"An AR Drone flies autonomously through a forest using only its camera to avoid trees. The Drone is first flown by a human pilot and subsequently learns to imitate the pilot and avoid obstacles on its own.
Research done at the Robotics Institute of Carnegie Mellon University. Funded by ONR through BIRD MURI."

Read more…

Aeromapper UAV + APM 2.5 + Geotagging now available

3689478951?profile=original

A couple months ago we announced the Aeromapper UAV: a versatile all-composite, low cost UAV mainly aimed for mapping applications, but also being used as a multipurpose UAV platform for its great versatility, performance and great internal volume for different payloads.

It is offered in 3 different options: as a kit, as a RTF with all the basic electronics and components installed, and now as a RTF UAV (autopilot and camera   installed). You can customize each option as well.

The Aeromapper RTF UAV (Option "C") comes with ArduPilot Mega 2.5 installed and ready, and a great mapping camera: the Casio Exilim H20G with   Hybrid GPS.

It's probably one of the best camera options for UAV mapping since it has a GPS   that even works when it loses link with satellites. Motion sensors inside the camera calculates the position even if there`s not a clear view of the sky (three-way   accelerometer and a three-way direction sensor). So it know its position even inside buildings.   Additionally, it features a 14 Megapixel sensor, amazingly long lasting battery, 10x zoom lens, 360 degree panorama feature and many more excellent functions.  

The camera is included with the Aeromapper UAV, installed and ready to use with an interface to shoot images automatically every X seconds (depending on the Option you choose on our website), but it is also sold separately HERE in case you  want just the camera. So if you already have a UAV that is made of composites or doesn't allow a clear view of the sky and you want to tag your images with great precision, go ahead and order the camera from our website.

The Aeromapper UAV is also unique in that it offers a simple and effective   solution that protects the camera and electronics from dirt coming into the payload bay during landing, with a servo activated door on the camera opening (See video HERE).   It is amazing to see how many expensive UAVs are offered in the market and   lack such a basic and important feature. The Aeromapper solves that, still   having a very attractive price (under $4,5K including everything, ready to fly!). As a airframe kit is available for under $1K. It`s probably the best value UAV among composite - high performance UAVs.

We have the goal to  make of the Aeromapper UAV   the best-selling UAV for mapping and No.1 UAV platform for multipurpose applications. We`ll keep improving it, adapting it, adding accesories and payloads and one of our priorities is to offer you the best combination of product and customer support after sale.


More information at our website www.aeromao.com, or email us at info@aeromao.com.

Email us at info@aeromao.com to receive updates!

Read more…
3D Robotics

Robotboat on Kickstarter

3689479034?profile=originalYou can't buy one, but you can back what seems like a very interesting project: to help build a vehcile that could set an autonomous sailing world record. Eighteen days to go and they're at $30,000 towards a $80,000 goal.

From the Kickstarter listing. 

Our boats have completed hundreds of hours of fully autonomous navigation and traversed hundreds of kilometers on the water.

We've proved a robust sailing algorithm.  In the GPS trace below you can see the boat complete upwind tacking maneuvers without human control.

We've completed the Robotboat Mark VI design.  We're going to build it like a surfboard; it will be incredibly strong and be capable of being rolled in waves indefinitely.

Read more…
Moderator

YS-series for multirotor

Lets have a look closer to the YS series multicopter system from Zero UAV.


3689478606?profile=original

3689478557?profile=original

W:63mm L:93,5mm H:19mm (Pretty large for a FC)

3689478382?profile=original

Back of the PCB

3689478583?profile=originalFront PCB

3689478395?profile=original

IMU / pressure sensor L: 50mm W: 42mm H:23,5mm

3689478627?profile=original

Plastic case is spraypainted with cobberpaint inside. IMU PCB is mounted on a massive iron plate on a soft foam. See video.


3689478659?profile=original

Wifi module L: 42mm H: 62mm W: 15mm for comunication with Groundstation

 3689478720?profile=original

 Inside Wifi module


3689478681?profile=original

GPS - Compas module Ø 50mm

3689478642?profile=original

Backside GPS module


Functions:

1 Auto (Takeoff/ Go Home/Landing)
2 Handfeel Control (Phone Attitude Control *NEW function*)
3 Target Lock & Fly encircle
4 Click/Touch & Fly To Point
5 Realtime Flight status (Google Earth Map)
6 Follow Me (Auto-tracking)
7 Auto-Navigation (Waypoints)
8 Flyfree (Joystick Control)
9 Fail/Safe (auto hover--go home--landing)
10 Realtime Power Display Information
11 Low Voltage Alert (By Phone Vibration)
12 RTH Switch from Transmitter directly
13 Built-in Gimbal Stabilization
14 Flight Control Mode(GPS Atittude Mode/ Atittude Mode/ Manual Mode)
15 Support Quad/Hexa/Octo (type I/type V/type Y & A customize motor mixer)
16 Support receiver {S-BUS/Normal Mode/Self-adaptive(PPM *COMING soon*)}
17 Built-in Damper in IMU
18 Accurate Position & Altitude Hold (Hover Precision is within±1.5m horizital and ±0.5m Vertical)
19 Support Steadycam structure, need to add the second customized IMU (*NEW function*, need to customize)
20 Support Bluetooth module(*NEW function*)


At the moment I havn't had the time to test it my self, but I think it will have a big future and it should be in the same catergori as DJI system.


The New Steadi470 From ZeroUAV looks pretty nice.


The YS series autopilot system is available here


Read more…

3689478238?profile=original

In my case Alt Hold worked always really nice, within 1 m in calm conditions, and still does.

But one incident scared me a bit. A few sec after switching to Alt Hold in about 5m, the heli dropped to the ground.  My first thought was a glitch caused by emf from the ESC. After I calmed down, I went for two other trials and like clockwork the same glitch again. But after the dropdowns I resumed flight with Alt Hold and it worked fine as always.

After a bit of analyzing the logs I came to the conclusion the glitch is caused by a kind of   ‘Alt error reset’ after the GPS status goes high. 

If you are in Alt Hold without GPS log  ( Alt Hold  needs no GPS log ) then as soon you get GPS log, the GPS status goes high, and the Alt error drops the same amount as your altitude to hold. If you in 5m the Alt error drops to -5 if you in 2m it drops to -2.


1. scare

3689478238?profile=original1.test

3689478405?profile=original2.test

3689478420?profile=original

So everything works fine as long as you have GPS log before switching to Alt Hold.

I think there needs to be looked in to this issue, to reduce the further scares :-))

Read more…
3D Robotics

3689478222?profile=original

Sounds like somebody neglected to research FAA rules before getting excited about putting an eye in the sky.

From BoingBoing

Above, "The Bravo 300," a tactical drone man­u­fac­tured in New Or­leans by Cres­cent Un­manned Sys­tems. Weeks after New Orleans local investigative paper The Lens began digging into city of­fi­cials’ plans to use a U.S. Home­land Se­cu­rity De­part­ment aer­ial drone to mon­i­tor crowds at the upcoming Super Bowl, a spokesman for Mayor Mitch Lan­drieu announced that the city is no longer pursuing those plans.

Spokesman Ryan Berni of­fered no rea­son for drop­ping the eye-in-the-sky tech­nol­ogy, telling a re­porter to sub­mit a pub­lic-records re­quest. In a brief phone in­ter­view, he would say only that the de­ci­sion to ditch the drone was made “over the past sev­eral days.” In a fol­low-up email, Berni said Home­land Se­cu­rity would be pro­vid­ing a manned he­li­copter, equipped with a cam­era, and that “the City learned by phone in the last few weeks” about the switch.

Read more: City cancels plans for Super Bowl drone despite enthusiasm and interest from NOPD, others (TheLensNola.org).

Read more…
Developer

Bullets in the sky?

3689478215?profile=original

"Can U.S. Citizen Shot Domestic Spy Drones?"

I've just read this post here on DailyTech.

First of all calling it as "Domestic Spy Drones" sounds tendentiously like a bad approach. [Edited] A friend of mine(Otávio Moraes) said that the word "domestic" is referring to native drones. Though it could also be translated as "homemade" which is why I said it sounds to be tendentious and/or ambiguous. Probably, that's due to the fact of the english language not being my native one.[/Edited]

Anyway, thinking about ballistics I'm wondering how dangerous would be shooting against "the sky" upon urban areas. Much probably a slug could eventually cause a biggest damage by "hard landing" on someone's head. Don't you think?

I could be wrong but it would be a classic situation when a problem is treated by another even bigger. You kill the cockroaches with poison and so you have a plague of scorpions. Not bad...

Read more…

Burning Man From Above

Here's a little video I've put together from the recent Burning Man, which is a week long ~50,000 person arts festival held in the Black Rock Desert in Nevada.


I shot it using my small homemade tricopter with a hard mounted gopro using FPV.


Read more…
100KM

Hey everyone,

3689478341?profile=originalI'm sure most of you  have heard about the techpod and the kickstarter campaign I just want to give one more shout out here for help. Its been a long journey getting to this day. I lot of you have been following and supporting the development of the techpod for years. The countless hours of designing, building and flying seem compressed into just a few moments. I know this will be a success heck I just got a $10,000 backer on Saturday. I think bigger things are on the way. I am going to have a very large amount of airplanes soon and I am going to need some help getting Techpods into peoples hands.I just want to take a moment and thank everyone who has supported the project .thanks to all the people who encouraged me through out the years. Thanks to everyone who help to get the word out. Thanks to all me friends and family who have surrounded me and made me strong. Thanks to Chris Anderson and the rest of the diydrones community for giving me a place to express myself and to learn and grow beyond what I thought was possible. Thanks to my wife for putting up with all my crazy ideas. And most of all Thanks to my mom the hardest working person I have ever met.

love you all!

wayne

Read more…

3689478149?profile=originalHi Guys,

As you know, we are working on OpenLRS project since few years and It is an Open Source RC control system with telemetry, I2C and others. Few days before i designed this new boards. It is based on OpenLRS system but there is no 3.3v regulator, PPM or Servo outputs. It is an open Source Telemetry Module with XBee footprint.   And today prototype boards arrived and i populated it for test and passed. Now we are waiting for quality PCB production (15 days).

Features:

  • No more buffering problem of Xbee modules. Real time telemetry or control is possible.(10ms latency)
  • Longer Range, lower frequency
  • No networking stack. Everything in the code. You can write a mesh or point to point, everything is possible.
  • Arduino ProMini based boot and Open Source design
  • No Programmers or FTDI cable require. Just put it to USB to XBee adapter and load the firmware over Arduino. 
  • XBee footprint. (Serial pins only)
  • 100mW 400-470mhz RF Module with FHSS and other functions (RFM22B)
  • up to 3 miles range. (The record is 12KM with Nagoya antenna in England)
  • 3.3v design.

3689478314?profile=original


My Job List:

  • Open google code page for OpenBee in a few days (http://code.google.com/p/openbee/) 
  • Isolate the OpenLRS code's telemetry part.
  • Test it at the field.
  • Add an option for  MAVLink packages (need help!!!)
  • Find project members.
  • Add the code for simulating OpenLRS Transmitter modules. Computer based RC control is possible with OpenLRS Receivers. Joysticks or something like that.  


What are you thinking about OpenBee project?  Is it good or bad idea? 

Thanks for your comments
Melih

Read more…

Sonar ALT_Hold Issue

3689478046?profile=original

Hello there,

Yesterday, i added a new senor onto my quad, MaxSonar MB1260 XL for better altitude hold. Before attaching and re-uploading the ArduCopter 2.7.3 onto the APM 2. I erased and reset the board. And then attached sonar as described in the wiki manual. And uploaded the code and followed all initial steps (Of course i enabled the sonar). Everything went smooth. 

Next step, time for test fly. It flew great in Stable mode. However, as soon as i toggled the ALT_Hold switch ON. Quad started acting strange. It kept climbing higher n higher and suddenly dropped out of nowhere. Luckily i managed to control by toggling the switch back to stable mode.

I have checked everything couple of times now. All connection looks good. Mission Planner looks ok. I don't know what the problem. Your help would be so much helpful. I have attached couple of videos below. Please take a look at them. If you need any other information let me know. Thank you.

Quad Setup:

  • DJI F450 Frame
  • HackerStyle 20-22L Motors
  • Turnigy TY-P1 25Amps ESC (Flashed with SimonK firmware)
  • ArduCopter 2.7.3
  • MB1260 XL - Sonar 
  • 4000mah 20C 3Cell Battery
  • DX7 with AR7000 
  • Using one of four ESCs to provide power to the APM 2. 

3689478046?profile=original

3689477939?profile=original

3689478154?profile=original

3689478123?profile=original


Cheers,

-Keyur

Read more…
Developer

3689478184?profile=originalI lost this post so I have attempted to reconstruct what I can of everybody’s replies. I think I did ok in the end. I continued my discussion of the topic here:

http://diydrones.com/profiles/blogs/stability-patch-for-motor-max-and-min-and-yaw-curve

Hi all,

I wanted to do a post on this for a while now but it is hard to separate the Yaw issues I want to talk about from a number of other issues regarding the interaction between Roll, Pitch, Yaw, and Throttle.

I will attempt to focus on a couple of issues I would like to point out:

  1. Default Yaw PID’s parameters and/or Yaw PID loop design could be improved.
  2. ESC linearization can only be partially implemented and doesn’t necessarily fix the altitude variation problem. This is because we always have the non-linearity below 0% and above 100%. And Yaw is very capable of pushing the outputs into these areas.
  3. Maximum motor limits in the MotorMatrix library are only effective for the HEX configuration. Quad’s and Octo’s experience a Yaw when the maximum outputs are limited because “opposite” motors are spinning in  the same direction.
  4. Maybe we can improve the way we handle Maximum and Minimum motor outputs. This is a complex problem and I am only starting to get it clear in my head.

In this Blog Post I will focus on point 1 because I have run out of time.

A quick summary of what everybody knows

Roll and Pitch are controlled by using the lifting force generated by each propeller to create a toque on the airframe and rotate the airframe in a given direction. Yaw on the other hand uses the drag of each propeller to rotate the airframe about its vertical axis. To rotate clockwise, the counter clockwise propellers are speed up, increasing the drag, while the clockwise propellers are slowed, decreasing the drag. The difference between the clockwise and counter clockwise drag, and therefore toques, on the propellers causes the rotation of the airframe. So basically, Roll and Pitch are controlled using the force that propellers are designed to do well while Yaw is controlled by the toque that the propellers are designed to minimise. This is why multi-rotors have poor yaw authority.

Sudden Full Yaw Input

If a sudden yaw input is applied to the PID’s using the default PID parameters results in 4500 x 7 x 0.25 = 7875. This is 1.75 times the maximum Yaw Rate Output. This is particularly significant because an output of 4500 is enough change the ESC output by 100%. (Correct me if I am wrong there). So basically Yaw input has much stronger control over the propeller RPM than any other control with the exception of manual Throttle… Maybe (There is a Max Throttle variable).

My impression is that the default YAW PID parameters and PID loops have been chosen to compensate for the lack of yaw authority at the expense of Roll, Pitch, and Throttle/Altitude control. I believe that this is a problem since Yaw is the least important control. In fact we have modes setup to control the copter while it is spinning in the Yaw axes.

My Suggestions

This is difficult because there is a real compromise between Yaw control and control in Pitch, Roll, and Altitude/Throttle. How we juggle these issues depends on our priorities. If our priority is an easy to fly and tune system then I would suggest a number of things we could do to potentially improve things:

  1. Reduce default STB_YAW_P parameter.
  2. Multiply the Stick input by ACRO_P instead of STB_YAW_P to calculate the desired rate. Keep STB_YAW_P for its named purpose, stabilising the yaw heading.
  3. Reduce the Rate output limit to something like 2250.
  4. If the user wishes to increase Yaw authority they could be encouraged to increase the angle of the propellers up to 10 degrees. It is suggested that up to 3 degrees should be included in large Octo’s.

Here the link to the starship enterprise copter with the angled props.

http://www.rcgroups.com/forums/showthread.php?t=1692582

http://safeflightcopters.com/

https://www.youtube.com/watch?v=pVZpGO3Ft-E&feature=player_embedded

Thanks for taking the time to read this.

Replies:

Nick Mann:


Thanks for that. Interesting thoughts. 

=========================================================================================

Randy:

    Leonard,


        Great post and very timely as I'm looking at a couple of these area.  Suggestions #1 and #2 look fairly straight forward to implement so no problems there.


        I'm very interested in your thoughts on a better "stability patch".  Jason and I were discussing this a few weeks ago about how to improve it.  As you say, simply reducing the opposite motor is probably not the optimal soluiton.  I was thinking that in the AP_MotorsMatrix library when we're doing the mixing we should remember the roll, pitch yaw and throttle contribution for each motor..then when it comes to doing the stability patch we review those motors that have gone over 100% (or under 0%) and then look at the make-up of what caused them to go over.  So say it's got a big +ve yaw component to the number..well, we can remove that surplus and then go around to the other motors and take away an equivalent -ve yaw.  That might all come from one motor or it might be from a few different motors.


         Generally I think we all agree that we should prioritise control so that #1 maintain altitude, #2 roll+pitch, #3 yaw.  So yaw is the first to be sacrificed if necessary.  That's perhaps not quite true though if you're talking about maintaining a roll/pitch of 45deg at the expense of yaw..in those cases you'd probably prefer to give up some roll/pitch.  So maybe there's some minimum stability which must be maintained and then beyond that it's a luxury and is open to be sacrificed.

=========================================================================================

leonardthall:

Hi Randy,


    I agree, 1 and 2 are the easiest and most sensible way to address most of this problem.I should have put them in the opposite order though. I think we should multiply the stick input by ACRO_P because that is what ACRO_P was intended to be used for (Ok, I am guessing here). This would then leave STB_YAW_P to be tuned for best PID performance (We don't even have to change that then).


    In the current setup, full stick movement, from a stationary level copter, requests 315 degrees per second from the Yaw rate PID. Using ACRO_P will reduce that to 202.5 degrees per second. To put this in perspective, the maximum rate that the stabilised Rate PID's request from a level position is is 202.5 degrees per second, (default acro mode is 180 or 202.5 degrees per second depending if AXIS_ENABLE is set or not).


    Now to translate these figures to the peek commanded to the motors in a + configuration. Max Yaw will command plus or minus 100% (limited from 175% out of the Rate PID) from the motors. Considering that many copters will hover between 30% and 50% throttle, this is massive.


    In comparison the roll or pitch will request a maximum of 78% is Stabilise and 70% in Acro mode with AXIS_ENABLE set. These numbers drop to 55% and 50% for a copter in the x configuration because of the 1/root(2) factor. On top of this, because roll and pitch are so directly effected by the lifting force of the propellers, the rate will increase very quickly reducing these numbers substantially.


    So while it will be very difficult to make roll and pitch reach the output rate limit (and if it does it will be very brief), Yaw can increase to almost double the output limit quiet easily (and because the input into this limiter can easily reach double, it can last for a relatively long time).

=========================================================================================

Randy:

Ok, a lot to digest here and I haven't done that completely but a few bits from me in any case..


Propeller lifting force is approximately proportional to the RPM squared. So if a copter will hover at 50% throttle then it will have approximately 4 times it's lifting capacity in reserve, so lets say that in the real world we have 2 times in reserve.


I didn't know this so thanks for the info.  Although we don't get to control the RPM of the motors but rather just provide a PWM...I've plotted the pwm vs thrust curves for a number of motor + esc combinations and although the curve does get steeper as the throttle goes up I'm not seeing quite as much variation as I'd expect from the above...maybe there's some scaling going on inside the ESC, or maybe the rpm between min throttle and max throttle is actually not that different and so I'm only seeing a small part of the curve so the thrust = rpm^2 bit is not obvious.  I'll get a tachometer.


Ok, fair enough on prioritising the axis as: #1/#2 roll+pitch, #3 throttle, #4 yaw.


What Leonard wrote below is similar to the solution I like best but I don't think that roll/pitch should always overwhelm yaw control in all situations. For example, I think it's much better to abandon a request from an autopilot for a 45 degree pitch forward in favour of maintaining yaw.


Other solutions do away with opposite motors all together and instead reduce multiple motors that combine to create an opposite. The idea is to minimise the amount that any motor has to be reduced and therefore keep a motors in a similar part of their throttle curve. (minimise the impact of throttle curve on PID gain being different from motor to motor). However this approach will still reduce all motors equally on a quad since this is the only solution to the problem without inducing a yaw, pitch or roll.


Anyway, sounds like we're at the point where we need to try out some of these ideas...

=========================================================================================

R_Lefebvre:

Leonard, good analysis.  As Randy said, we were talking about this recently.


An overpowered quad is the worst case scenario.  This is because they hover at 20-30% throttle which means they have less control room before one of the motors hits 0%.  The more overpowered you are, the worse it is.  This was demonstrated by the disagreement between Jason and I about my yaw control changes that were in 2.7.1-ish.  My quad flew well with them, but he found it was causing pitch/roll problems.  This is because if he input a yaw command, even a gentle one, it was shutting down one of the motors causing loss of attitude control.


However on my quad which is moderately powered, hovers around 50-60%, I had no problem, because I had much more room to move before hitting a limit.


Quads without tilted motors makes the situation that much worse, and of course the 3DR Quad kit has no tilt because it's a flat boom design.


You say that Octos have a problem as well, but I think less so.  Reason is, an octo should be able to shut down all the CW or CCW rotating motors and still have attitude control because the remaining CCW or CW rotating motors are still layed out in an X configuration.


But your point about the hexas being the best case is probably true.  It's also a better arrangement for motor redundancy because the opposite motor turns in the reverse direction, simply shutting down two opposite motors causes no loss of control.  (This is why I've also thought about building a decacopter).


Now, did you notice in the motors library, some part of code called "Tridge's Stability Patch"?  This does look at which motors are "clipping" on the high side, and reducing negative control on the opposite motor to match.  The problem is it does not work on the low side clipping.


Anyway, I'm going to cut and paste in here something I wrote on the devlist about this issue.

So what we discussed is the possibility of

Sorry I don't have any more.

=========================================================================================

R_Lefebvre:

Coming out of the discussion about the yaw contribution patch, and how it affected the performance of "overpowered" quads, I'd like to put some collaborative effort into rethinking how this is done.  Currently, this is done in the function AP_MotorsMatrix::output_armed() in AP_MotorsMatrix.cpe.  It's a large function, and is pretty much the last step in calculating the actual motor output.  I'll step through it piece by piece:


This part here constrains the throttle controller output obviously, keeping it between 0 and whatever the _max_throttle parameter is.  This is to avoid having the throttle controller overpower the yaw, pitch and roll controllers, allowing them some headroom to work.  This is based on the fact that _max_throttle is typically 80 or 90%, leaving 10-20% headroom where the attitude controllers can do their job.

// Throttle is 0 to 1000 only

_rc_throttle->servo_out = constrain(_rc_throttle->servo_out, 0, _max_throttle);


This part set the minimum throttle output to _min_throttle whenever the throttle is above the bottom. 

if(_rc_throttle->servo_out > 0)

out_min = _rc_throttle->radio_min + _min_throttle;


I haven't back-checked this part, but I assume it is causing all of the controller objects to calculate PWM ranges between 1000-2000.  I think the comment should read: "capture desired roll, pitch, yaw and throttle from attitude controllers" since these values obviously don't come from the Rx directly, but from the attitude controller.

// capture desired roll, pitch, yaw and throttle from receiver

_rc_roll->calc_pwm();

_rc_pitch->calc_pwm();

_rc_throttle->calc_pwm();

_rc_yaw->calc_pwm();


This part here has the remnants of the yaw_contribution patch.  The idea was that in order to stop copter rising during yaw, we should slow down some motors more than we speed up the others.  The problem in case you missed the other email about this, is that the effect of this can cause the output of this bit to hit min_throttle, which "clips" the output of the controller.  Basically the yaw_contribution can clobber the ability of the pitch and roll controllers to do anything.  This isn't much of a problem on "underpowered" quads (50-60% throttle to hover) since they operate well above throttle_min. But overpowered quads which only require 20-30% throttle to hover, it doesn't take much yaw_contribution before you start hitting throttle_min.  Once one or more of the motors are on throttle_min, you start to lose stability.

// mix roll, pitch, yaw, throttle into output for each motor

for( i=0; i<AP_MOTORS_MAX_NUM_MOTORS; i++ ) {

if( motor_enabled[i] ) {

/*yaw_contribution = _rc_yaw->pwm_out*_yaw_factor[i];

if (yaw_contribution > 0 ){

yaw_contribution *= 0.7;

}else{

yaw_contribution *= 1.42;

}*/

motor_out[i] = _rc_throttle->radio_out +

_rc_roll->pwm_out * _roll_factor[i] +

_rc_pitch->pwm_out * _pitch_factor[i] +

_rc_yaw->pwm_out*_yaw_factor[i];

}

}


The stability patch is doing something similar to what I want to do, but it operates on the high side rather than the low throttle settings.  If any given motor has an output greater than out_max, it sets that output to out_max, and then subtracts the amount that it is "clipping" from the opposite motor. 

// stability patch

for( i=0; i<AP_MOTORS_MAX_NUM_MOTORS; i++ ) {

if( motor_enabled[i] && motor_out[i] > out_max ) {

if( opposite_motor[i] != AP_MOTORS_MATRIX_MOTOR_UNDEFINED ) {

motor_out[opposite_motor[i]] -= motor_out[i] - out_max;

}

motor_out[i] = out_max;

}

}


Then we have this part, which simply makes sure all the motors are above min.  This is where the trouble occurs with the yaw_contribution, or really any yaw control.  If any given motor is below out_min (aka: min_throttle) then set it to out_min.  So the problem is, if you have a strong yaw control, it can reduce one motor of a quad below out_min, which is then clipped and set to out_min.  But the opposite motor does not suffer this.  The result is the quad will have a pitch/roll movement about the axis perpendicular to the affected axis.  ie: if the yawcontroller output causes motor 1 to go below out_min, then the quad will wobble about the 2-4 axis. 

// ensure motors are not below the minimum

for( i=0; i<AP_MOTORS_MAX_NUM_MOTORS; i++ ) {

if( motor_enabled[i] ) {

motor_out[i] = max(motor_out[i], out_min);

}

}


This is the part that needs to be fixed.

=========================================================================================

R_Lefebvre:

So now to discuss what to do about this.


The first thing that must be decided is: Do we want to completely throw out Yaw stabilization if that yaw stabilization causes an instability in pitch/roll? I think the answer is yes. But I'm afraid if we do that, we'll have more complaints about lack of yaw authority. The problem is, I think, simply a case that people with powerful motors are operating too close to the out_min. One solution to that is to lower out_min, and give more room for the stability controllers to work. I think throttle_min might be something like 10-20% by default? Is there a reason we don't recommend going lower, like 5%, or maybe even less? I would think we could go almost as low as possible without having the ESC's actually shut-down?


I bet all of this also has a lot to do with the instability in the quads during descent.


Anyway, so what I'm thinking is something like this. Basically, I'm moving all the yaw controller stuff below the pitch/roll stuff. And I'm constraining the yaw controller PWM to a range which is constrained by how far above the min_throttle we are. If the throttle is low, we cut the yaw controller output to preserve the pitch/roll stability.


// output_armed - sends commands to the motors

void AP_MotorsMatrix::output_armed()

{

int8_t i;

int16_t out_min = _rc_throttle->radio_min;

int16_t out_max = _rc_throttle->radio_max;

int16_t yaw_contribution = 0;

int16_t lowest_output = 2000;


// Throttle is 0 to 1000 only

_rc_throttle->servo_out = constrain(_rc_throttle->servo_out, 0, _max_throttle);


if(_rc_throttle->servo_out > 0)

out_min = _rc_throttle->radio_min + _min_throttle;


// capture desired roll, pitch, yaw and throttle from receiver

_rc_roll->calc_pwm();

_rc_pitch->calc_pwm();

_rc_throttle->calc_pwm();

_rc_yaw->calc_pwm();


// mix roll, pitch, yaw, throttle into output for each motor

for( i=0; i<AP_MOTORS_MAX_NUM_MOTORS; i++ ) {

if( motor_enabled[i] ) {

motor_out[i] = _rc_throttle->radio_out +

_rc_roll->pwm_out * _roll_factor[i] +

_rc_pitch->pwm_out * _pitch_factor[i];

}

}


// stability patch

for( i=0; i<AP_MOTORS_MAX_NUM_MOTORS; i++ ) {

if( motor_enabled[i] && motor_out[i] > out_max ) {

if( opposite_motor[i] != AP_MOTORS_MATRIX_MOTOR_UNDEFINED ) {

motor_out[opposite_motor[i]] -= motor_out[i] - out_max;

}

motor_out[i] = out_max;

}

}


// ensure motors are not below the minimum

for( i=0; i<AP_MOTORS_MAX_NUM_MOTORS; i++ ) {

if( motor_enabled[i] ) {

motor_out[i] = max(motor_out[i], out_min);

}


if( motor_out[i] < lowest_motor ){

lowest_motor = motor_out[i];

}

}


// constrain yaw controller output to priorities roll/pitch control

_rc_yaw->pwm_out = constrain(_rc_yaw->pwm_out, 1500 - lowest_motor, 1500 + lowest_motor);


// add yaw controller contribution

for( i=0; i<AP_MOTORS_MAX_NUM_MOTORS; i++ ) {

if( motor_enabled[i] ) {

yaw_contribution = _rc_yaw->pwm_out*_yaw_factor[i];

if (yaw_contribution > 0 ){

yaw_contribution *= 0.7;

}else{

yaw_contribution *= 1.42;

}

motor_out[i] += _rc_yaw->pwm_out * _yaw_factor[i];

}

}


#if CUT_MOTORS == ENABLED

// if we are not sending a throttle output, we cut the motors

if(_rc_throttle->servo_out == 0){

for( i=0; i<AP_MOTORS_MAX_NUM_MOTORS; i++ ) {

if( motor_enabled[i] ) {

motor_out[i] = _rc_throttle->radio_min;

}

}

}

#endif


// send output to each motor

for( i=0; i<AP_MOTORS_MAX_NUM_MOTORS; i++ ) {

if( motor_enabled[i] ) {

_rc->OutputCh(_motor_to_channel_map[i], motor_out[i]);

}

}


// InstantPWM

if( _speed_hz == AP_MOTORS_SPEED_INSTANT_PWM ) {

if( instant_pwm_force01 )

_rc->Force_Out0_Out1();

if( instant_pwm_force23 )

_rc->Force_Out2_Out3();

if( instant_pwm_force67 )

_rc->Force_Out6_Out7();

}

}

R_Lefebvre:


Sorry the formatting didn't come through, hopefully you can understand what I'm saying.


Also note this isn't finished working code, just kind of a back-of-the-envelope sketch.

=========================================================================================

R_Lefebvre:


I haven't read through everything thoroughly, but I think you're right Randy.  I would be better to sacrifice a high attitude request (45° pitch) if you have to to keep the copter yawed properly.  But if the request is to hold the quad level, then that should get priority over yaw.

=========================================================================================

Marooned:

Huge amount of knowledge here. Still analyzing in my head what I've just read.

This all match to my observations with my quad of having "random" yaws when playing with pitch/roll or trying to avoid the ground with max throttle stick for a while. And because of having GoPro attached to my quad and that unpredictable yaw heading it's almost impossible to know where camera is looking at the moment and record what I want. Also, when flying away when I'm unable to recognize white vs red arms to determine front of the quad, only "simple" mode is usable.

I was watching great movies of copters flights and always was curious "what did I wrong" to not be able to fly various paths and head properly.
I'm still learning about all those PIDs in ArduCopter and not ready to add my 3 cents on that subject.
Fingers crossed for some great conclusions.

=========================================================================================

leonardthall:

Hi all, Thanks for taking the time to read all this.

When I look at throttle curves what I see is a general RPM^2 characteristic with a fall off or saturation at the high end. I think that this is probably a combination of efficiency going down and the ESC running out of legs at the top end. It may also have something to do with the drag characteristics of the antenna as well.

But basically my understanding is that ESC's basically control the average voltage being applied to the motor (for the purposes of RPM calculation), using pulse width modulation of the driving fets. RPM is approximately proportional to voltage input. Then we should get an approximate propeller force = (ESC input pwm)^2. At least below the peak efficiency of the motor (assuming the ESC is up to the task).

But then all the real life effects start messing with us........

But lets just assume that the pwm to force is X^2 relationship around hover at least.

We get a curve like this:

3689477900?profile=original

This graph is computer by comparing the upper and lower Yaw commands we need to give to maintain hover. The Blue line is the ratio that you are suggesting, 0.7/1.42, while the purple is the ratio required to maintain hover or constant vertical force. So based on this idealised model, the ratio you have currently is about right when we are reducing half the motors to near zero.

Sorry, I have to go to a doctors appointment but I will be back to give the equations for the above curves and add the excel sheet.

=========================================================================================

leonardthall:

Ok, the maths.

x = throttle RPM at hover with no control input

y = the reduction in RPM in the slowing motors

z = the increase in RPM of the increasing motors.

Total Lift = 4*x^2 (for a quad without the lift multiplier)

When yawing Total lift is = 2*(x-y)^2 + 2*(x+z)^2

if we want to maintain the same total lift force during yaw
4*x^2 = 2*(x-y)^2 + 2*(x+z)^2
4*x^2 =2*x^2 + 2*y^2 - 4*x*y + 2*x^2 + 2*z^2 + 4*x*z
2*x^2 =x^2 + y^2 - 2*x*y + x^2 + z^2 + 2*x*z
2*x^2 =2*x^2 + y^2 - 2*x*y + z^2 + 2*x*z
0 = y^2 - 2*x*y + z^2 + 2*x*z

Ok, so we have this equation

z^2 + 2*x*z + y^2 - 2*x*y = 0

and we want to calculate what z needs to be.

z = (-2x + sqrt(4*x^2 - 4*(y^2 + 2*x*y)))/2 (we only need the positive root)

z = -x + sqrt(x^2 - y^2 +2*x*y)


So the long and the short of this is that when making small yaw inputs we need a 1 to 1 ratio of increasing and decreasing throttle. When we are applying the maximum possible yaw toque y = x (half the motors are stopped)

z = -x + sqrt(x^2 - x^2 +2*x*x)

z = -x + sqrt(2*x^2)

z = -x + x*sqrt(2)

z = x*(sqrt(2)-1)

z ~ x*0.414

=========================================================================================

leonardthall:

Ok,


Is it better (or even possible) to to sacrifice a high attitude request (45° pitch) if you have to to keep the copter yawed properly?


First up, I agree with the sentiment, I just aren't sure if this is what we want to try to do......


If we are ascending or descending (motors near a limit) with no requested attitude change then the PID loops are simply attempting to maintain the current attitude. Therefore Roll, Pitch, and Yaw inputs will be relatively small.

A number of things could disturb this state:

1. Roll, Pitch, or Yaw input. PID's translate this to the equivalent Rate request.

2. Turbulence or some other force cause a rotation in a number of axis. Attitude error feedback is translated again to the equivalent Rate request.


I think both are important but 1 will happen more often and with larger deviations.

My opinions follow, not facts:

1. If a yaw input is applied then I believe it shouldn't be allowed to impact the roll and pitch loops in any way. This is not too bad because the strong control of the copter in the roll and pitch axis means that the motor RPM deviations from average should be small. Ok, that is easy to say but what about the other way round.

2. If a roll or pitch input is applied I want to see that Yaw still has enough authority to maintain a heading but only just. This is because Yaw will very quickly increase the average lifting force of the motors if we want the same authority of a helicopter or tricopter. So this means we need to allow a certain throttle increase if Yaw needs it, but we want to keep it small because we want to come down.

3. What if we are manoeuvring in all axis. Ok, any strong input in Roll, Pitch or Yaw will reduce our rate of decent because of the RPM^2 tendency. However if we are using the above approach then we will get quick solid response from roll and pitch and a mushy yaw response. The important point is to make sure that we allow Yaw access enough pwm output to keep a heading and weakly adjust heading.

4. As soon as the throttle setting is increased to give a bit of room between the throttle setting and the minimum output then Yaw authority will return (at lease return as much as it can in a quad).


Ok so what happens if we are descending with near minimum throttle in Stabilise mode and we want to go from horizontal to a 45 degree pitch forward. Using the rational described above the pitch will change very quickly (less than a second in my quad), we will momentarily increase the total lifting force being applied to the copter de-accelerating the decent during the manurer. During this... lets say second, the output that yaw is allowed to exert is at it's minimum limit. This means that the copter will have very limited ability to accelerate in Yaw during this second but enough to maintain it's current state. Ok, I am happy with the performance the way I describe it so far. What happens after this maneuver though? The copter now has angle boost plus minimum throttle, increasing the headroom that Yaw can use (a 45 degree angle increased the throttle (g.throttle_cruise + 80) / 0.75).

Code Here:

http://code.google.com/p/ardupilot-mega/source/browse/ArduCopter/Attitude.pde#501

So while a maneuver in roll or pitch away from flat hover, will reduce Yaw control to the minimum needed to maintain a heading for the short period of time, after the maneuver the Yaw authority will be increased (and I don't think people will even notice). However, if the roll or pitch maneuver is back to level there will be less Yaw authority afterwards but who cares, if I let go of the sticks in Stabilise mode I want my copter to go back to level, I don't care if I can't Yaw for a second.


Ok as for point 2.

We are descending and clip a branch. The copter tumbles, we crap ourselves, we don't increase throttle because we don't want to see it accelerate into the ground. Please PID's save me!!!!!

This is a simple one. Get me level then worry about Yaw. We probably have some angle boost helping us for most of the time as the copter attempts to right it's self so that will help but Yaw just isn't on the priority list in this situation at all.


Ok so to answer the question, No I don't think we should reduce roll or pitch authority to get better yaw when near throttle minimum (although I would allow more headroom for Yaw near Throttle maximum). In Stabilise the increased roll and pitch angle will actually increase Yaw authority due to angle boost.

=========================================================================================

leonardthall:

Just a quick note. I hope these replies don't come across as condescending or "know it all" in any way. I am simply trying to put as much detail into my replies as I can to ensure that my thoughts are coming across clearly.

I am also making a real effort to make the most out of the feedback of the DEV team because I realise that you all have been playing with this stuff for a long time now and have a wealth of practical experience with the APM2 on a variety of airframes that I don't have.

As for the post above, I didn't address the (or even possible) part of the question. I was wondering how we would do this quickly (processor clock cycles) without strongly disrupting the roll and pitch PID's. I don't really have an answer to that part of the question......

I will see if I can find some references for where I got the RPM^2 thing.

Read more…

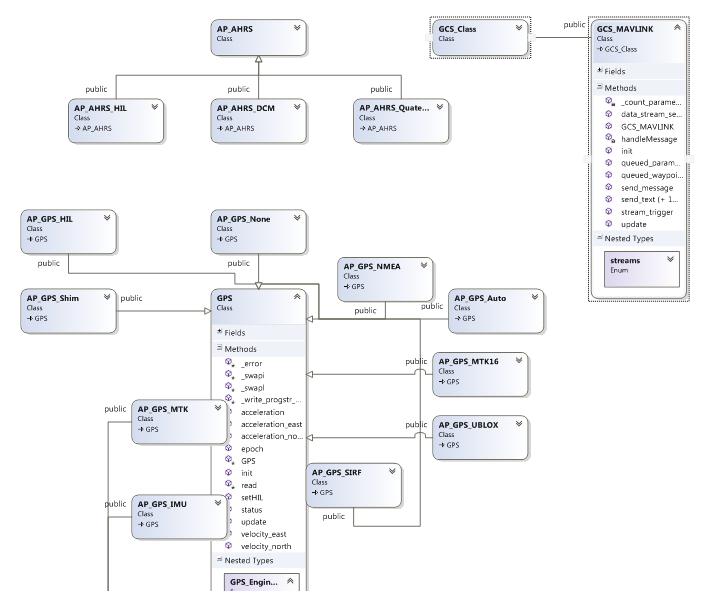
Graphical Display of APM Program Structure

The Class Diagram features of Microsoft Visual Studio provide the facility to show graphically any area of an Apm program. This is an ideal way for new users to understand how ArduPilot and ArduCopter code is designed. 

VisualStudioClassDiagramsCompressedExampleAPM.png

Reference

Microsoft Visual Studio provides a 100% compatible development environment for Arduino and Apm. It is also used to create the diydrones GCS. The Arduino plugin for Visual Studio is free and available from here, Visual Studio can be downloaded for free via here

Read more…
3D Robotics

Etching a power distribution PCB

3689478021?profile=original

If you're buying a premade quadcopter kit like ArduCopter, it will come with a PCB-based Power Distribution Board. But what if you're making your own? You either have to wire together your own harness or, like xnaron did here, make your own PCB. He did a great job of it, but this may be a bit beyond most people's reach: he has both a CNC laser engraver and PCB acid etching materials. But worth reading for tips, even if you don't have the gear. 

(via Hackaday)

Read more…
3D Robotics

3DR ArduCopter Kits Updated

3689477548?profile=original

3DR ArduCopter kits are back in stock at the 3D Robotics store. The kits have gone through a slight redesign both in mechanical design and documentation. Our new facility in Tijuana, Mexico as well as better suppliers for parts have allowed us to greatly improve the quality of these kits as well as offering them for lower prices. The new frames also look stunning!


The main change to both of the kits is the new arms, the arms are now 40mm shorter which translates to about 10 grams lighter per arm. This allows for the motor cables to be shorter and reduce the weight of the vehicle overall. The motors are no longer mounted through the entire cross section of the arm which caused the old 3DR arms to sink, the motors are not mounted to the top face of the arm providing a better mounting surface. The two frames are significantly smaller and will allow for easier transportation. The arms now come in two colors, blue and black. Each kit will contain 2 blue arms and a spare black arm (3 black arms for the Quad kit and 5 black arms for the hexa kit), this will allow you to build your vehicle in either + or x configuration with the front indicated by a blue arm(s).The center plates on the Hexa-B have been redesigned to accommodate for the shorter arms and large props. 


The manuals for both of the kits have been re-written, we took all your feedback and produced a better set of assembly and set-up instructions. 3DR will also be providing a parameter file for these specific frames and keep it current as the code evolves to provide the best possible performance with these frames. The first iteration of this param file should be available shortly.


The full flight electronics quad and hexa kit have been upgraded to APM2.5 .


3DR ArduCopter Quad-C

3689477599?profile=original

Manual

3DR ArduCopter Quad-C Frame Kit     $99.99

3DR ArduCopter Quad-C Frame + Motors Kit     $249.99

3DR ArduCopter Quad-C Frame + Motors + Full Flight Electronics Kit     $449.99

3DR ArduCopter Hexa-B

3689477762?profile=original

Manual


3DR ArduCopter Hexa-B Frame Kit     $129.99

3DR ArduCopter Hexa-B Frame + Motors Kit     $349.99

3DR ArduCopter Hexa-B Frame + Motors + Full Flight Electronics Kit     $549.99


3DR ArduCopter kits will begin shipping today!

Read more…
Developer

3689477900?profile=original

Hi all, it appears that my blog post “Yaw Control, ESC Linearization, and Hover” has been lost. I hope that it will be saveable but I am not holding my breath. If it can’t be saved I will attempt to reconstruct it but while I have most people’s replies on my emails but I don’t have my own. If anybody has a copy of my replies I would be very grateful if you could send them to me.

The discussion that followed that blog post focused on the "stability patch" in AP_MotorsMatrix.cpp.

Both myself and R_Lefebvre attempted to explain this in detail in the blog post above so I won’t do it again now in a hope that we will get that work back (fingers crossed). But I will attempt to summarise the issues that we would like to address.

  1. Near maximum and minimum throttle the control is compromised because we can’t decrease propeller lift much further at minimum throttle or increase it much further maximum throttle.
  2. When multiple Roll, Pitch, and Yaw manoeuvres are happening, how do we combine these with the requested Throttle setting to maintain stability.
  3. Yaw control is very limited in most of the multi rotor geometries and therefore results in large RPM variation in motors compared to Roll and Pitch to create an equivalent Yaw response. The lift force generated tends to be non-linear creating an increase in lifting force when Yaw is applied. How can we correct this behaviour?

While addressing these points we need to ensure that:

  1. We maintain stability and preferably good control over Roll, Pitch, and Yaw.
  2. Throttle response and altitude control is not compromised any more than absolutely necessary.
  3. That we don’t do anything that can prevent an overpowered multi rotor from coming down!


Yaw Curve

Ok, easy bit first.

Yaw is achieved by increasing the RPM of half the motors and decreasing it in the other half of the motors. However, because the lift of a given propeller tends to increase by the square of the change in RPM, this results in an increased total lifting force.

Reference is page 16 here: http://dc-rc.org/pdf/Model%20Propellers%20Article.pdf

So what we want to do is increase the RPM of half the motors less than we decrease the RPM of the other half and keep it the same as when all motors are at the same RPM.

Ok, some maths.

x = RPM of all motors at stationary hover.

y = RPM reduction of half the motors during Yaw.

z = RPM increase of half the motors during Yaw.

Total lifting force at hover for a quad is:

Total Force = 4*x^2

When inducing a Yaw it is:

Total Force = 2*(x - y)^2 + 2*(x + z)^2

We want these two equations to be equal if we don’t want the quad to start accelerating vertically therefore:

4*x^2 = 2*(x - y)^2 + 2*(x + z)^2

2*x^2 = (x - y)^2 + (x + z)^2

2*x^2 = x^2 + y^2 -2*x*y + x^2 + z^2 + 2*x*z

2*x^2 = 2*x^2 + y^2 -2*x*y + z^2 + 2*x*z

0 = y^2 -2*x*y + z^2 + 2*x*z

0 = z^2 + 2*x*z + y^2 -2*x*y

if we solve this for z we get:

z = -x + sqrt(x^2 – y^2 + 2*x*y)

If we plot this we get:

3689477900?profile=original

 The excel file I used is here if you would like to play with it.

YawScaling.xls

The current ratio line is the ratio we are currently considering using, ie 0.7 up and 1.42 down. As you can see, the ratio starts off 1:1 then reduces to sqrt(2)-1 or 0.414. We could get pretty close to the ideal line using a straight line approximation:

z = 1 - (2-SQRT(2)) * x/y

This will give us a small increase in lift half way along but it is pretty close. Looking at the added complexity with this approach I think it is probably better to go with the constant ratio approach that is currently commented out in the code. This makes all calculations much quicker and easier.

Stability Patch

Ok, now the difficult bit.

The approach I suggested in the lost blog was

  1. calculate all motor settings for Roll, Pitch and Throttle.
  2. calculate the remaining headroom between these throttle settings and the max_throttle and min_throttle.
  3. if the headroom is not enough to contain the requested Yaw input the we reduce the requested Yaw to fit the available headroom or the minimum reserved yaw headroom.
  4. We then go through and add the Yaw request to each motor output with the throttle offset to ensure the outputs remain between the max_throttle setting and the min_throttle setting.

We do need to be very careful that Pitch or Yaw oscillations can’t make a high powered quad fly away though. I have some ideas on this but it may not be needed.


In the lost post the question was raised by Randy. “For example, I think it's much better to abandon a request from an autopilot for a 45 degree pitch forward in favour of maintaining yaw.” We could do this by:

  1.  reducing the stick input travel at low or high throttle,
  2. reducing the limit on roll and pitch rate outputs at low or high throttle,
  3. or scaling the rate outputs in the MotorMatix function.

I don’t like any of these options because they either directly interfere with the users inputs or change the ability of the Rate_I (or Stab_I) term to do it job and correct for CG and motor output offsets.

The good news is that I don’t think this is a problem if we leave the Roll and Pitch components un touched. At near minimum throttle we are descending and we can get a large Roll or Pitch output from the Rate PID’s from two things:

  1. a large stick input from the user,
  2. a large exterior force.

Point 1. If the user enters a command to change attitude from horizontal to 45 degree pitch for example. With full Pitch control this will happen in less than a second (for my quad anyway). For this short time we may lose almost all our Yaw authority leaving just a little more than is required to maintain a heading. However, as the Pitch angle increases the throttle boost kicks in. This will dramatically increase the throttle setting restoring Yaw authority.

On the other hand, If the airframe is at 45 degrees and I let go of the sticks in stabilise mode. I want to see my copter go level as fast as possible. I don’t care if I lose all Yaw authority for a second provided my copter is level afterwards. Then with the small amount of Yaw authority that we keep in reserve the copter can change the heading as requested.

Point 2. If the copter experiences a large outside force… say clips a branch while descending to land, all I care about is that it gets up the right way again. As before, Throttle boost will help us here for a portion of the rotation, but Yaw is my absolute lowest priority.

Remember I am not advocating removing all Yaw authority, I am suggesting reserving only enough to maintain a heading and apply small Yaw accelerations.

Code Example

To quote R_Lefebvre from the lost blog post, “this isn't finished working code, just kind of a back-of-the-envelope sketch”


    // capture desired roll, pitch, yaw and throttle from receiver

    _rc_roll->calc_pwm();

    _rc_pitch->calc_pwm();

    _rc_throttle->calc_pwm();

    _rc_yaw->calc_pwm();


    // mix roll, pitch, throttle into output for each motor

    for( i=0; i<AP_MOTORS_MAX_NUM_MOTORS; i++ ) {

        if( motor_enabled[i] ) {

            motor_out[i] = _rc_throttle->radio_out +

                           _rc_roll->pwm_out * _roll_factor[i] +

                           _rc_pitch->pwm_out * _pitch_factor[i];

        }

    }


    // calulate the minium headroom left for Yaw.

    high_yaw_pos = 1000;

    high_yaw_neg = 1000;

    low_yaw_pos = 1000;

    low_yaw_neg = 1000;

    high_throttle = 0;

    low_throttle = 2000;


    // the signs I have used might be wrong

    for( i=0; i<AP_MOTORS_MAX_NUM_MOTORS; i++ ) {

        if( motor_enabled[i]) {

             if( _yaw_factor[i] > 0 ) {

            if( high_yaw_pos > (out_max - motor_out[i])/ ) {

                    high_yaw_pos = out_max - motor_out[i];

                }

            if( low_yaw_neg > motor_out[i] - out_min ) {

                    low_yaw_neg = motor_out[i] - out_min;

                }

                    } else if( _yaw_factor[i] < 0 ) {

            if( high_yaw_neg > out_max - motor_out[i] ) {

                    high_yaw_neg = out_max - motor_out[i];

            }

            if( low_yaw_pos > motor_out[i] - out_min ) {

                    low_yaw_pos = motor_out[i] - out_min;

                }

             }

            if( high_throttle < motor_out[i] ) {

            high_throttle = motor_out[i];

            }

            if( low_throttle > motor_out[i] ) {

            low_throttle = motor_out[i];

            }

       }

       }


    yaw_ratio = 0.7/1.42;


    high_yaw_pos = max(high_yaw_pos, min_yaw_headroom);

    high_yaw_neg = max(high_yaw_neg, min_yaw_headroom);

    low_yaw_pos = max(low_yaw_pos, min_yaw_headroom);

    low_yaw_neg = max(low_yaw_neg, min_yaw_headroom);


    yaw_pos = min(high_yaw_pos/yaw_ratio, low_yaw_pos);

    yaw_neg = min(high_yaw_neg/yaw_ratio, low_yaw_neg);


       rc_yaw_pwm_out = constrain(_rc_yaw->pwm_out, -yaw_neg, yaw_pos);


       min_required_yaw_headroom = min(reserved_yaw_headroom, rc_yaw->pwm_out);


       if( (out_max-high_throttle)/yaw_ratio < (low_throttle - out_min) ) {

             throttle_change = min((out_max-high_throttle) - min_yaw_headroom*yaw_ratio,0);

       }else{

             throttle_change = max((out_min-low_throttle) + min_yaw_headroom,0);

       }


    for( i=0; i<AP_MOTORS_MAX_NUM_MOTORS; i++ ) {

        if( motor_enabled[i] ) {

             yaw_contribution = rc_yaw_pwm_out*_yaw_factor[i];

                    if (yaw_contribution > 0 ){

                           yaw_contribution *= yaw_ratio;

                    }

            motor_out[i] = motor_out[i] +

                                 throttle_change +

                                 yaw_contribution;

        }

    }


    // ensure motors are not outside alowable region

    for( i=0; i<AP_MOTORS_MAX_NUM_MOTORS; i++ ) {

        if( motor_enabled[i] ) {

            motor_out[i] = constrain(motor_out[i], out_min, out_max);

        }

    }


Read more…