You may have seen this fun Audi vs Audi paintball duel. The above hexa is how they captured the aerial shots in a field too dangerous for a boom:
(via Core77)
You may have seen this fun Audi vs Audi paintball duel. The above hexa is how they captured the aerial shots in a field too dangerous for a boom:
(via Core77)
Thanks to everyone that passed us at the Model Expo Italy Verona ... today 'was a good day ... in the evening we were destroyed ... are now in a hotel near the fair, tomorrow it starts again ... from 9.00
Today I met many friends VirtualRobotix, Diydrones and BaroneRosso and not only that we have gone to find, Rino, who was here at the stand of FIAM, Michael is' doing acrobatic flights with its quad here in the aviary Pad 7, Ale with Joseph, Marco Robustini that I always see with pleasure, Rfale, and many others. My "MEMBERS" today are given in thousands of presentations, Emile, Flavio and Marco Masiero, we flew in the aviary in pair with their drones based VRBrain and Mikrokopter.
Tomorrow it's up to Drones "Professional" for video applications and civil protection, etc. etc. etc. ... So who wants to see them live and not just in our video finds us at our stand and also during the day with presentations in the aviary of the main stand.
Greetings to all and see you tomorrow in the meantime a video made by Daniele with our drones that tomorrow you will see the truth in action.
Grazie a tutti di essere passati a trovarci a Verona al Model Expo Italy ... oggi e' stata una bella giornata ... a sera eravamo distrutti ... ora sono in albergo vicino alla fiera , domani si ricomincia ... dalle 9.00
Oggi ho conosciuto tanti amici di VirtualRobotix , DIYDrones e del BaroneRosso e non solo che ci sono passati a trovare , Rino che era qui allo stand della FIAM , Michele che sta' facendo voli acrobatici con i suoi quad qui nella voliera del Pad 7 , Ale con Giuseppe ,Marco Robustini che vedo sempre molto voleniteri , Rfale , e tanti altri  I miei "SOCI" oggi si sono dati in mille presentazioni , Emile , Flavio e Marco Masiero , abbiamo volato nella voliera anche in coppia con i loro droni basati su VRBrain e su Mikrokopter .
Domani tocca ai Droni "Professionali" per riprese video e applicazioni di protezione civile ,ecc ecc ecc ... Quindi chi vuole vederli live e non solo nei nostri video ci trova al nostro stand e anche durante la giornata con presentazioni nella voliera principale dello stand.
Un saluto a tutti e a domani nel frattempo un video fatto da Daniele con i nostri droni che domani potrete vedere dal vero in azione
Original Blog post : http://www.virtualrobotix.com/profiles/blogs/virtualrobotix-al-modelexpoitaly
( Sorry for the crappy photo ) It's time to retire the Radian pro after logging over 100 flights in the past year The wings are pretty well mush from flexing so much. Spring is just around the corner and I am going to
"Morph the Radian pro into a Multiplex easy star I live and fly near a significant body of water and there is always a breeze here you get a on shore breeze in the morning and a off shore breeze
in the afternoon The radian pro doesn't penetrate the wind very well unless you keep the air speed up in a shallow dive then you risk ripping the wings off when you pull out. The wing tips flex
up over a foot or more .If you get into turbulance and a wing drops you push the opposite rudder to bring it back up and the whole fusalage bends and nothing happens. When the breeze is blowing
you have to "nurse it around carefully with the rudder and airlerons and try not to pull to many "g's". In less than 5 mph wind is when it flies best when there is a light breeze blowing against
the cliff and the seagulls are soaring 150 feet up I have soared right beside them with the engine off just giving it short bursts when needed for up to an hour I only crashed twice. Once I
stayed up to long and the battery went dead and all I could do was watch as the off shore breeze pushed it towards the edge of the cliff and the lake. It landed in a bush 3 feet from going over
the edge. The other time it flew into the bright sun light the next time I seen it The tail was sticking up in the center of the bean field . I dinged the prop and replaced it 3 times (once it
tried to eat the coffee table) I used 2 batteries at around 47 flights the original battery swelled up round and wouldn't charge. I stripped the elevator servo the Very first flight and replaced
it with a standard size hightec servo I modified the fusulage for.I put balsa skids on the wings along side the aileron and flap servo horns for protection for landing .The left wing was
heavier than the right wing right out of the box and I had to put 6 thumb tacks in the right wing 3/4 of the way out to get it to balance level side to side I had "crow programmed in
but I never used it The flaps were adequate , with no wind ( which was rare) it would float in ground effect . I had mine given to me by my boys . It is not a "first plane," down wind or in a
dive it accellerates quickly. A Newbie would end up with a lot of broken foam on the plus the hobby shop can get parts readily. I wouldn't go out and buy another one .
For the Easy star it is going to have an alunimum spine down the center stretch the fuslage 2 3/4 inches, larger rudder and elevaror , either airlerons, flaperons or ailerons and flaps.and I
am going to reinforce the wing "right out of the box change the radian motor from a Tractor to a pusher machine a prop hub so I can use the radian folding prop
MyF4 Phantom I am going to leave it stock maby a bright led on the front.There is a abandoned WW2 air strip about an hour north of here shaped like a triangle the farmer utilizes 2 ofthe
runways the other is left open it is not marked on the charts any more but pilots know it is there and use it as a" Emergency strip" .I know the farmer, back in the day I would land there and
bring him a coffee from 'Timmys' I am going to fly the F4 there. When I take it out I am bringing along a bunch of guys that want to see it fly and 4 fire extinguishers From what I have seen of
Vidieos of the F4 you have to keep the airspeed up it has a long takeoff and rool out on landing it glides like a brick and you have to "Fly" it onto the runway . http://youtu.be/WBHCnjXLbrk
and http://youtu.be/7K_sQ8gR3d0
` I just have to repower my alunimum scratch build and it is ready to go! A jet cat gas turbine would fit right in where the 32 EDF was without a'majour modification . Or I go with a piston engine
put the engine in the middle near the center of gravity and run a shaft out the back with a thrust bearing and a folding prop? Or I could mount the engine on a pilon and make it into a "flying
boat and use my dive boat as a "Chase vehicle'!. You Guys have a Great Day!
Hi
following on from this post by Chris A. http://www.diydrones.com/profiles/blogs/connecting-to-apm-2-5-via-bluetooth?xg_source=activity
I have been using the WiFly RN-XV module from Roving Networks as a telemetry link to the APM 2.5. I have been using the XtremeBee adapter from 3DR to connect it to the APM.
I have to say this unit is amazing at it can be configured in so many different ways. It's a mini, no micro-router. It's great. (I know it's short range, but if you fly within a small area as many do it's not an issue, long range FPV enthusiasts look away now ;-) )
Due to it's flexibility the WiFly can be somewhat daunting to configure. I am going to list out some standard configs to help people get started.
This is the simplest configuration and is great at home when you have an available WiFi network. Good for testing, and leaves your computer able to connect to the internet.
To configure the WiFly connect it using an FTDI cable to your computer. (I'm using a Mac so this will be Unix flavour, for windows you can use, mmm been along time, is Hyperterminal still there?)
The default baud is 9600, to connect i run Terminal and the command
screen /dev/cu.usbserial-AM01RMWT 9600
type $$$ to enter setup mode.
Option: Infrastructure TCP
Now you should be able to connect using Mission Planner TCP option to assigned IP address port 2000
Option: Soft AP
You can also set the Wi-Fly up as a micro-router In this mode device connect to the device
You can simply connect to the APMNetwork to 10.0.0.1:2000 to connect to the APM
There are other modes as well, like UDP, ADHOC etc... I haven't used them yet, but I can post configurations as needed.
Hope this helps :-)
From the Robot Operating System mailing list:
ardrone_autonomy" is a ROS driver for Parrot AR-Drone quadrocopter. This driver is based on official AR-Drone SDK version 2.0 and supports both AR-Drone 1.0 and 2.0. "ardrone_autonomy" is a fork of AR-Drone Brown driver. This package has been developed in Autonomy Lab of Simon Fraser University by Mani Monajjemi.
Read more here.
Hi all
We have had the privilege here in having the Avalon airshow every second year, this year, we had a few highlights that are of importance to this group.
1. which has been mentioned, CASA, (our FAA) have made lots of noise on helping us get Airborne, and
2. Bask industries had a stand, with the APM2.5 at Center stage. People were crowding around the stand, amazed at the product, able to play with the Mission Planner, and in general see how good Ardupilot is.
I was amazed at the fact that there were a lot of UAV platforms at the Airshow, including multiple Multirotors. Yet Bask had the most people at their stand.
EDIT March 4th, 2013: Thank you very much for your feedback and patience! We've got a good to-do list now, and rather than keep two stores up and running, we're going to take the beta site down until we're ready with all of the great feedback you provided. It will be back again soon, but if you'd like to place an order now, please visit our current site at: http://store.diydrones.com
In conjunction with updates to the documentation, we are also rolling out a new store! It's now in beta, so we're rewarding the brave folks who are willing to help us wring out the bugs. Only a small number of product categories are currently enabled; if what you want isn't among them, please use the regular store, which will continue to be the main way to buy gear until we take the new store out of beta.
From now through the rest of this weekend, you can order a select set of 3D Robotics hardware at an incredible 25% discount!
You can get to the new store at: http://store.3drobotics.com
While you're taking advantage of this offer, please be sure to take some notes on the experience and send us some feedback at: feedback@3drobotics.com
We appreciate your business and look forward to seeing what the community does with even more cutting-edge products in 2013!
Thank you!
Great hack here (via Hackaday)
As a tie in to my No ‘Air Ambulance Challenge, a sponsored body wax for the local Air Ambulance charity, I’ve decided to upgrade my old project by swapping the RC car out for a Syma S107G. If you enjoyed this post, please donate a few quid or whatever you can here. It’s for a very good cause and as it’ll put me through a *lot* of pain you can be sure I’m not asking for my health!
I tried to implement the IR protocol in C# using the .NET Micro Framework for the Netduino but it proved more than a little tricky to get the timing right. As there are a few implementation out there for the Arduino I decided to stand on the shoulders of giants and build on top of existing code, two in particular.
http://www.kerrywong.com/2012/08/27/reverse-engineering-the-syma-s107g-ir-protocol/
http://abarry.org/s107g-helicopter-control-via-arduino/One thing worth of note is that my helicopter uses Channel B, as you can see in the comments in my code (heavily based on Kerry Wong’s) it is easy to switch between the two channels. For the serial control aspect I implemented a similar method as with my Netduino project and in Andrew Barry’s implementation. For the Xbox 360 Controller interface, I updated my previous application to listen for the trigger for the throttle and the right analogue stick for pitch and yaw. I had some fun when I got the values backwards and I slammed the copter into a wall. Thankfully they are built tough to survive kids and geeks alike…
The IR emitter is a 500Ohm resistor inline with a pair of IR LEDs, connected to Pin3 on the Arduino. Video demo below;
We are in the process of making some significant changes to our site layout and content to improve the overall ease-of-use experience here at DIY Drones.
As part of that effort, we wanted to put out the first section of the site that is ready for community-wide peer review. You can see the updates at:
We need to add the footer, and a few other small things, but we want your input!
Please take a look through the site and the wiki, and submit your feedback to:
feedback@3drobotics.com
We'll do our best to keep up with the comments here, but using the address above will definitely get noticed.
Thank you!
From Kottke:
One of the most intriguing demos I've seen, if the footage in the video is to be believed, is the Myo gesture control armband.
It's an eye-popping demo. The copy on the site reads "unleash your inner Jedi" and you pretty much do look like Obi-Wan using the thing. Which is to say, like a crazy person cosplaying Star Wars in the middle of the street. Adam Lisagor calledGoogle Glass a "Segway for your face" back in April. The Segway was another great idea on paper that failed in part because of human vanity. Segways weren't cool...you looked like a dork riding one. You're gonna look like a dork wearing Google Glass. You're gonna look like a dork unlocking your car with a swipe of your Myo-enabled arm.
But the uncool factor can be overridden in various ways. Nike can make anyone wear anything, especially if it's packaged like a watch with superpowers. A few years ago, you looked like a dork wearing headphones in public but Apple made it cool. Beats By Dre made wearing huge over-the-ear headphones in public cool a few years later. You look like a dork wearing a Bluetooth headset and talking to yourself, but they are cheap and useful enough that it doesn't matter. Mobile phone usage in public used to appear very strange...for awhile it was difficult to tell the brokers-in-a-hurry from the mentally unstable homeless folks muttering to themselves.
That's the challenge for Google Glass and Myo: are these things useful enough and cheap enough to overcome that dork factor or can they somehow be made cool? Because if they aren't and you can't, no one wants to be seen using a Nintendo Power Glove in public and no amount of extreme sports dubstep transitions can save you.
This is the third iteration of my Ardupilot Mega to Hitec telemetry adapter. Adapter no longer requires modifications to APM itself, but instead connects to telemetry port of APM and it has a pass through connector for telemetry transmitter. I made PCB this time using SMD parts for smaller size:
It's possible to have the device automatically display different information based on airframe type. Currently shown vario and airspeed readings are not that useful for hexa, but for example heading might be. I just got my hexa so I've yet to decide what to show. Unfortunately compared to previous versions, it's not anymore possible to show "mAh used" reading since to my understanding that information is not sent in any mavlink message. When using different types of batteries, that information would be more useful than percentage remaining reading. Should we add mavlink message for it?
For more information about the device and sources, see http://antibore.wordpress.com/2013/02/28/showing-apm-telemetry-data-on-hitec-auroras-screen-3rd-edition/
Now if I only could get my hands on some different telemetry capable systems, I could try to make this adapter universal one...
From IEEE Spectrum:
A lot of UAV research is focused on making flying robots that can navigate by themselves using sophisticated sensor systems, intelligently avoiding crashing into things. This is a fantastic goal to have, but it's not easy. EPFL is doing away with just about all of that with a new version of AirBurr, a robot that's specifically designed to run into everything and crash all the time, building maps as it does so.
As we saw last June, AirBurr has undergone a remarkable evolution since 2009. And even in 2012, they were only on version 8, while the current version is up to 11. AirBurr is a coaxial UAV that is totally comfortable with collisions, thanks to its shock absorbing roll cage and self-righting mechanism:
Its rigid central core is surrounded by specially-designed tetrahedral-shaped springs that buckle to efficiently absorb impact energy. The springs protect the AirBurr from impacts with obstacles and can be used to physically interact with objects while in flight. If a collision results in a fall to the ground, the robot's Active Recovery System, comprised of a system of spring-loaded carbon fibre legs, allow it to return to an upright position and take off again.
Here it is in action:
Obviously, having just four sensors makes AirBurr kinda terrible at obstacle avoidance, but the simple fact is that it just doesn't matter: it may not be efficient at finding its way down a hallway, but it does so with an absolute bare minimum of sensors, and it wouldn't care if the hallway was pitch black or full of smoke or otherwise a place in which conventional vision would be out of luck. This vastly increases the number of environments in which AirBurr can be used.
The mapping behavior is especially cool, and if the resulting light paintings remind you of anything, it's because AirBurr employs a random direction algorithm that's similar to the one used by some robotic vacuum cleaners.
This sort of behavior is based in no small part on insects, which also have very primitive sensing systems combined with body structures that allow them to survive numerous collisions. Bugs may not be particularly smart, but as it turns out, big brains and complex sensors aren't always necessary for robust flight and navigation.
We'll see more of this research at ICRA in May from the EPFL team (which includes Briod Adrien, Adam Klaptocz, Kornatowski Przemyslaw Mariusz, and Zufferey Jean-Christophe), but there's a hint on EPFL's website as to where the researchers are taking this: they'll be presenting a paper entitled "A Perching Mechanism for Flying Robots Using a Fibre-Based Adhesive." Cool!
[ AirBurr ]
On Sparkfun's Google Plus page, they've announced the new location of the annual Autonomous Vehicle Competition, which will be held on Saturday, June 8th in Boulder, Colorado. This year, in addition to cars and planes, they're readmitting copters, so the event has moved to a much larger area: the Boulder Reservoir.
Also, for the first time, 3DR and DIY Drones will be organizing a day of drone education and hacking, called DroneCon, which will be held at the Sparkfun headquarters on Friday, June 7th. More details coming soon, but many of the DIY Drones developers and 3DR staff will be there, giving a day of tutorials on everything from drone control theory to communications and operations. For those who can't make it, it will be videoed to create the begninnings of a Drone Academy education program that we''ll be launching.
More details on both AVC and DroneCon coming soon, but save the dates!
HefnyCopter2 implements full PID terms that is P, I & D. It uses the following approach.
My vision is to keep math as simple as possible and use superposition to accumulate different behaviors together based on my suggested framework.
Gyro values for balancing are in purple.
Accelerometer and accumulated Gyro are used together as a virtual angle device to get estimated Angle and implements the restoring function using a PID and are shown in green.
AccZ implements Positioning-Balancing and is shown in orange.
Sonar implements Positioning-Restoring and is shown in Red.
Please let me know how do you find this approach.
Uff...All dirty jobs are done. Trial fit, nearly 9 meters.
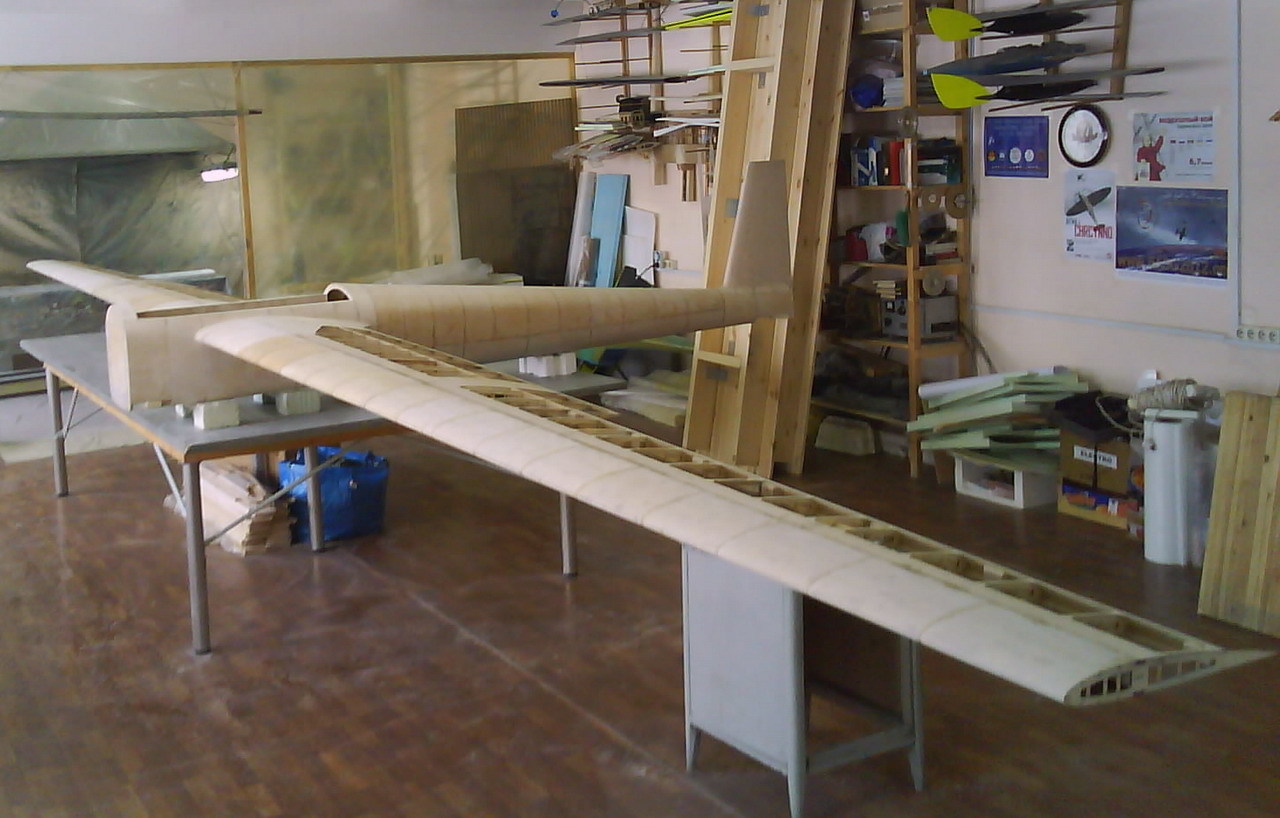
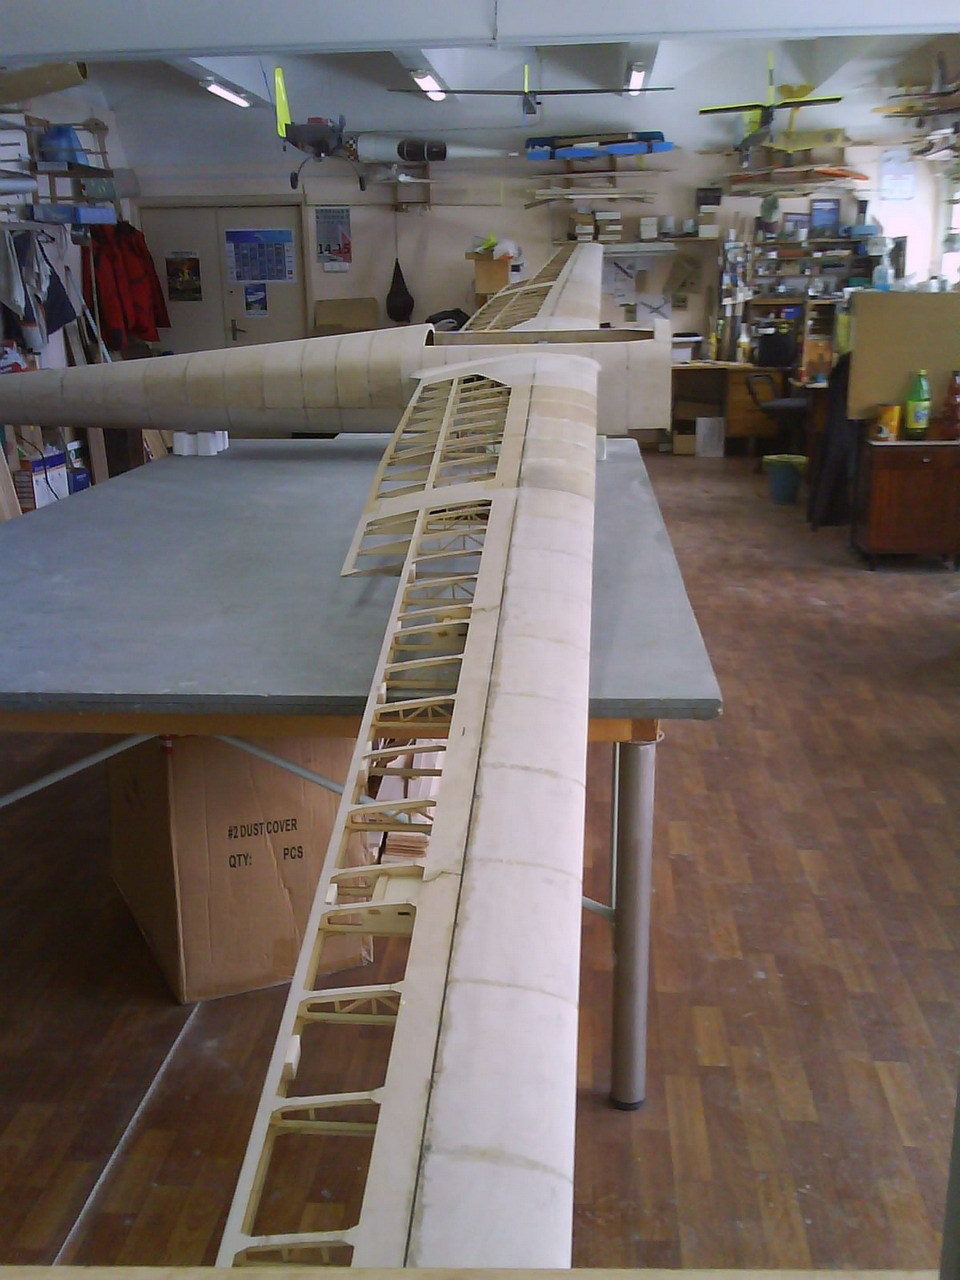
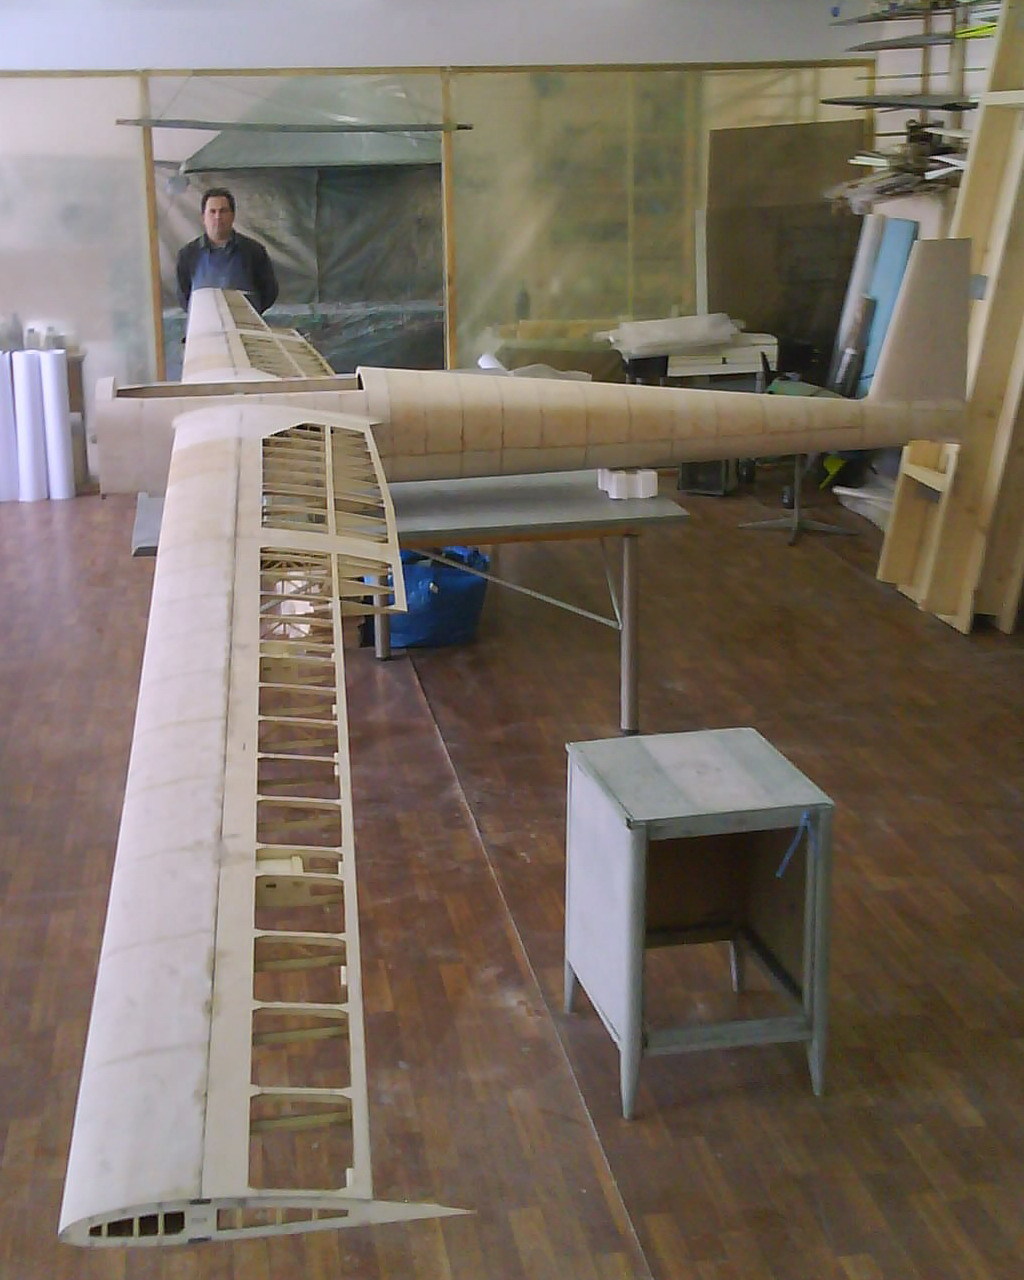
Now - clean, sand, spackle, prepear for covering...

Good evening to all,
today is an historic day for us, after 3 years from the birth of the Virtualrobotix.com community we finally founded the company VirtualRobotix Italia s.c.a.r.l. formed as a spin off of MpxLab Scarl a private research organization based at Kilometro Rosso of Bergamo (Italy).
Here is a photo of the toast ... Unfortunately, some of the members were not present but we expect in the next picture to be all.
We are 15 founding members (quite a number...) and others will join shortly and we are all driven by the will to transform their passion into a work.
Our mission is to facilitate the development of air, terrestrial and marine robotic technologies for the recreational, research and professional use.
We will take care of many things
inventing and developing new technologies made in Italy and offering them to the world
training of pilots for professional applications
develop and certificate drones
Offer specific services as Aerial Video and Photography
…And many other bound only by our imagination
The first public event of VRI will be at the “ModelExpoItaly” of Verona (2-3 March 2013) , where we will have a 36sqm booth!
If you need more info on how to join our initiative or need to know more details about our mission you can contact us at info@virtualrobotix.com
Greetings to all
Roberto Navoni
-----------------------------------------------------------------------------------
Buonasera a tutti,
oggi e' stata una giornata storica , dopo 3 anni dalla nascita della community Virtualrobotix.com oggi è nata la società cooperativa VirtualRobotix Italia Scarl , startup tecnologica ... costituita come spin off di MpxLab Scarl un organismo di ricerca privato con sede al Kilometro Rosso di Bergamo.
Ecco la foto del brindisi ... purtroppo alcuni dei soci sono dovuti scappar via subito dopo l'atto dal notaio .. contiamo nelle prossime foto di esserci proprio tutti
I soci fondatori sono 15 un bel numero ... a breve se ne aggiungeranno ... mission della struttura agevolare lo sviluppo di tecnologie robotiche volanti terresti e marine sia nel settore ludico , della ricerca ed innovazione che nel settore professionale.
Il primo evento pubblico di VRI sarà il ModelExpoItaly di Verona dove avremo uno stand !!!
Ci occuperemo di tante cose , dall'inventare e sviluppare nuove tecnologie made in italy e proporle al mondo , alla formazione di piloti per applicazioni professionali ,sviluppare droni certificati ecc ecc .
Da oggi esiste una realtà creata da tanti appassionati che hanno voluto fare della loro passione il loro lavoro
se qualcuno vuole avere info per aderire alla nostra iniziativa o per conoscerne i dettagli ci puo' contattare ainfo@virtualrobotix.com
Un saluto a tutti
Roberto Navoni
Original : http://www.virtualrobotix.com/profiles/blogs/oggi-e-un-grande-giorno-nasce-virtual-robotix-italia
The PX4 is here and soon it will have a fully supported version of ArduCopter:
From what I have been able to glean, Chris and Company are now in the process of revising this controller for better use by our group including an enclosure.
I Do not know for sure if they are planning on modifying the board itself but indications are that they are.
Now this is completely unsolicited by DIYDrones and may even be an annoyance to them, but there are some things I would like to see in there and I'll bet some of you would as well, so now is your chance to sound off before it becomes a fete acompli.
Whether it will do any good or not I haven't got a clue.
An enclosure is good, but a internally vibration damped enclosure that was truly effective for reducing Accel vibrations to a fully tolerable level would be great.
Also, the existing PX4 pretty much requires that you use a PPM-Sum receiver with it.
PPM-Sum receivers are great, but only a few are available (Futaba and FR-Sky) not counting Graupner for obvious $$$$ reasons.
Personally I would like to use my plain old vanilla Hitec Aurora 9 and I think a lot of people would be a bit put off by having to upgrade their whole radio system because they didn't want to include a few extra RC inputs.
That's the 2 biggies I can think of, this is the place to put in your thoughts and we can see if anyone is listening.
This feedback is certainly unsolicited, I hope it is not also unwelcome.
Hi everybody,
The project "ArdUFO : un drone au service de tous" was selected during the December holidays for being presented at the "Palais de la découverte" at Paris, on February 9th 2013, as part of the "Olympiades de Physique France" contest.
The UAV was created thanks to Roberto Navoni and his magnificent card : VR BRain !
The day ended with the awards ceremony. After some speeches of the selection board, the awards were finally released, and we finished with a second price !
We now decided to continue with the C.Génial contest, to perform our project.
You can follow us on our website : http://ardufo.funpic.org
Best
The ArdUFO project
original blog post by Chydra : http://www.virtualrobotix.com/profiles/blogs/vr-brain-at-the-palais-de-la-d-couverte


I prepared a Word document to insert or paste here, but I cannot figure out how to do it without losing images and formatting. I will attempt to attach it as a Word file. Wish me luck...Arducopter%20vibes.docx