All Posts (11086)

Sort by
3D Robotics

Another DIY PCB quadcopter

3689460044?profile=original

From Hackaday:

Like most people out there, we’re fascinated by these little buzzing and hovering quadrotors. We’ve really enjoyed the recent trend of miniaturizing them and using PCBs as the frame itself. As [scolton] points out in his instructible, his isn’t the first, the smallest, or the lightest, but he does have some great information and a few tricks up his sleeve that make this a fun project to check out. The 4pcb measures 6.5 inches from motor shaft to motor shaft diagonally. It weighs 138 grams and, with its current batteries,can fly for roughly 8 minutes.

A nice thing about the 4pcb is that it includes brushless motor drivers into the design. Apparently that isn’t very common. What we really like though is the massive amount of reference material [scolton] provides. Not only could you download everything necessary to recreate his work, he links to so many other projects and resources you could probably expand in any direction your heart desires. If you’re considering a quadcopter build in the near future, you might want to bookmark this one.

Read more…

Home made ESC ideas

marcy2_44.jpg


Bodge work continues, in the pursuit of supplying the required current in the smallest possible space.  The LM1117 was the only thing available locally.  It makes 3.25V at 800mA with a 1.3V dropout & no other components.  A single one wasn't enough.

The double stack still got hot enough to burn a human.  Meeting the size & weight requirements makes for some bleeding edge temperatures.

marcy2_45.jpg


That ended up failing after a few minutes, leading back to the old TO-220.

marcy2_46.jpg


It would be a lot cheaper to calculate the required current, voltage drop, thermal dissipation of the board, & get the exact right part.

marcy2_47.jpg


Once you start pouring out heat to get the required power in the required space, the hot glue starts melting.  This has become disastrous in sunlight.  A hotter hot glue is required.

Anyways, after some time chasing after the lack of motor pulsing on Marcy 2, found the Castle Creations 6 is giving different results than the Castle Creations 9.  1 of the mane reasons people design their own ESC's is these inconsistencies.  Response rate, maximum duty cycle, different deglitching algorithms are the mane problems. They all accept 200Hz.  The deglitching may slow down the response rate.

Every ESC over 6A gave instant response, including Castle Creations & Hobbyking.  The leading theory is overloading, causing it to pull back when the throttle change is too big.  The 6A hesitates during throttle increases while the 9A instantly spins up.  Castle Creations are too expensive to buy another 9A & the 10A from Hobbyking takes 1 month to deliver. 

Was surprised to find 3drobotics does not sell an open source ESC as rumored.  They sell a 20A m2mpower ESC.

The mikrokopter ESC is the only complete source code & very specific about not being licensed for commercial use.

There is an SIlabs reference design.  It's quite simple.

The fact is you can't undercut hobbyking, which makes any home made ESC fruitless. 


The lack of an ESC & no desire to break down Marcy 1 for her ESC led to implementing things which make Marcy 2 a product more than a science project, manely a full router stack.  ARP, ICMP, DHCP, & DNS were the big ones.  The mane dictator over all this is the high USB error rate, causing many packets to be lost.
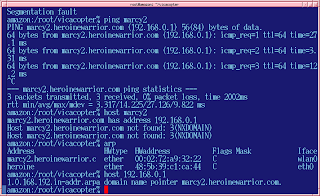
ip01.png

DNS was a real painful implementation of a luxury.  It destroys the realtime performance.  It's too slow to ever be used, but a host name looks neater in a ping command than an address.

Marcy 2 takes your computer off the internet & puts you on her own isolated network in domain heroinewarrior.com.

The access point now supports 8 stations, with flight control possible from any IP address.  In the battle of the router, DNS was voted off the stack.  It worked, but was the only protocol which had response packet length determined by the user.  Some packet lengths caused yet another USB crash.  So DNS now sends a fixed size response.  If the domain name is too big, it's truncated.

Even without that crash, the URB_ERRORs make all the protocols unbearably slow.  ASSOC, DHCP, & ARP are pretty bad but only happen once.  The only way to make the experience fast enough is to limit communication to the flight protocol.  There's no way to have a web page for configuration.

The URB_ERRORs on the STM32F4 drop when the pipeline is kept busy.  In full operation, streaming 2 megabit video, there are almost no errors & the IP stack always works.  Another method is to poll the interrupt endpoint graciously provided by the RTL8192.  This always returns immediately.  The interrupts are absolutely useless, but they keep the pipeline busy enough to reduce the errors.

Sort of disappointing to go through all the trouble of supporting a USB dongle only to have it be incapable of basic IP protocols.  Since the USB core on the STM32F4 is a stock core from Synopsis, there's always hope it really works, but so far it still seems intended for a mass storage device, where the reads are always guaranteed to happen right after a write.


The money for a smartphone is still too far off.  All roads are now leading to iOS & then porting to Android when iOS usage falls off.  It's unavoidable, since iOS is the only thing which is guaranteed to work.  Android has zillions of incompatible pieces of hardware.

The real problem is how iOS is only supported on 2 gadgets: 1 phone & 1 tablet, each updated only once a year.

Read more…
Moderator


Chris needed to do some prep for the upcoming SparkFun Challenge, so he asked if anybody wanted to get together for a Memorial Day fly-in.  I drove up with Andreas and Charlie Burtoff; there were about 15-20(?) people all together, although I didn't actually count.

Here's a shakycam of Andreas flying the Zii, a hex, some of the flyers, and Andreas with his fine-looking FPV mask.

http://eastbay-rc.blogspot.com/2012/06/short-clip-of-recent-diy-drones-fly-in.html

Read more…
T3

EagleTree FDR file format

Hi all,3689459959?profile=original

many of us are using EagleTree data recorder. Sometimes I have several logs that I need to merge between the autopilots and EagleTree. The manual states that you can contact them about file format and they will respond. Unfortunately this is not the case. Therefore maybe somebody has a clue about what the file content means:

TESTPLANE
0 0 0 255 1 0 0 0 255 1 254 0 0 1 0 0 0 255 0 0 0 1 100 74 1536 10.04 8205 1 1073758292
All Sessions
0 19456
Session 1
0 19456
Milliseconds IsEvent EventError EventData Altitude Airspeed ServoCurrent*100 Throttle PackVolt*100 Amps*100 GForceX*100  GForceY*100 GForceZ*100 Temp1*10 Temp2*10 Temp3*10 RPM RPM2 GPSLat GPSLon GPSAlt GPSSpeed GPSCourse GPSDist GPSUTC NumSats GPSFlags SpektrumHolds SpektrumLostFrames SpektrumAFades SpektrumBFades SpektrumLeftFades SpektrumRightFades GPSUTC-ASCII HDOP*10
0 1 9 14 0 0 0 0 1265 48 0 0 0 0 0 0 0 0 0.000000000000 0.000000000000 0.0 0.0 0.0 0.0 0.0000 0 0 0 0 0 0 0 0 04/06/2012,01:00:00.89 0
100 0 0 0 0 0 0 0 1265 48 0 0 0 0 0 0 0 0 0.000000000000 0.000000000000 0.0 0.0 0.0 0.0 0.0000 0 0 0 0 0 0 0 0 04/06/2012,01:00:00.89 0
200 0 0 0 0 0 0 0 1265 48 0 0 0 0 0 0 0 0 0.000000000000 0.000000000000 0.0 0.0 0.0 0.0 0.0000 0 0 0 0 0 0 0 0 04/06/2012,01:00:00.89 0
300 0 0 0 0 0 0 0 1265 48 0 0 0 0 0 0 0 0 0.000000000000 0.000000000000 0.0 0.0 0.0 0.0 0.0000 0 0 0 0 0 0 0 0 04/06/2012,01:00:00.89 0
400 0 0 0 0 0 0 0 1265 48 0 0 0 0 0 0 0 0 0.000000000000 0.000000000000 0.0 0.0 0.0 0.0 0.0000 0 0 0 0 0 0 0 0 04/06/2012,01:00:00.89 0
Obviously 19456 is just the number of samples, the rest are easily decoded ASCII data, but the line in BOLD contains some magic flags and options, one of them is related to time step. Any ideas?

EDIT: The field in red is milliseconds timestep size, it accepts .6 format also, and Milliseconds from the first column are ignored.

Not sure if the application can plot precisely timesteps like 333.333333 or will just truncate to 333.

Other fields remain a mystery.

BTW somebody mentioned

http://www.heliguru.ru/download/-manual/eagletree/597-pro-glide-flight-and-boat-seagull-and-data-recorder-instruction-manual/download.html

but it doesn't explain beyond:

Second Line: Data about your model’s setup, in an internal.

This line is needed to allow sharing of your data files with others.

Oh yes, for sure.

It also adds

Email us if you need more information on the file format.

Without promise of answering to that mail.

PLEASE POST HERE YOUR RECORDINGS *.FDR SO I CAN PICK DIFFERENCES COMING FROM DIFFERENT SOFTWARE VERSIONS - IT WILL BE EASIER TO REVERSE-ENGINEER THIS WAY.

Read more…
Moderator

aerosonde1.jpg

I have long admired the Australian UAS system and I might be getting this completely wrong.

A training scheme might get approved soon, and if you are planning on making some money with sUAS in Australia you might want to kick up a bit.

These bits made me smile

AVIO2004A Conduct frisk search of persons
AVIO2005A Conduct screening using Explosive
Trace Detection (ETD)
AVIO2006A Control access to and exit from an airside security zone or lands


Along with the need to 


Requirement for emergency evacuation of aircraft is identified


There will be pots and pots of money to be made with UAS training around the world and bandwagons will be jumped on. 


http://www.suasnews.com/2012/06/16329/australia-prepare-to-evacuate-your-unmanned-aircraft/


Read more…
Moderator


3689459710?profile=originalDear Friends,

our lab continue to work and improve our platform , we are working on next generation RTF and OEM platform.

The new brand will be VR BRAIN 4.0 the revision of produvt will be MP32FX V4. Put a BRAIN in your DRONE :)


The new design will be based on experience doing with MP32FX V3 and NAVY 2012 . Same great sensor MPU6000 , HMC5883 , MS barometer and STM32F1 or F4 as micro controller and Data Flash onboard for save realtime data logging .


The design will be more compact , only all in one board with put a gps on it or connected by a cable

There are also interesting news about new exclusive ST MEMS sensor supported by VR Brain but will be more news available in the future :)


For special low consuption application will be available also L1 revision of micro.

So with this new board will be available also the new VR IDE PRO .

The main adavantages of this new ide is the direct support of .PDE file so will be more simple mantain the aligment of arducopter project and support of relative path so will be more simple de zip and use enviroment without need to redefine the path ecc ecc in the eclipse.

The last revision of firmware available is ACopter32 2.5.5 updated with last revision of Arducopter 2.5.5 and fully compatible with mission planner.

The firmware that use VRBRAIN is the result of Great Work of Arducopter Dev Team that continue to improve the main code add function and quality of flight . Work of FoxTeam that continue to develop great library for STM32FX hardware and implement same revision of class and library for this great ARM micro controller, and Beta testing group that check in fly the new revision of code. LaserLab Team that every day continue to improve Hardware , Firmware and Tools for develop great open and closed source project on Multipilot platform.

Thank guys for your hard work :)

This is the link of new VRIDE is 4 part download all then dezip it.


http://code.google.com/p/multipilot32/downloads/detail?name=vrobotix-ide-pro-0.0.5.7.0-WIP-Angerl%20Loiter-F1-F4.part1.rar&can=2&q=#makechanges


See last video doing with the hardware that will be used also in VR BRAIN


The precision of loiter is around 2 meter


3689459731?profile=originalOriginal Post here , detail and discussion here:

http://www.virtualrobotix.com/profiles/blogs/new-multipilot-for-rtf-or-oem-application-is-coming

here a thread of Getting Started with MP32F4 + NAVY 2012 precursor of VR BRAIN 

http://www.virtualrobotix.com/group/armcopterdevgroup/forum/topics/mp32f4-getting-started-experience?xg_source=activity

New developer and user are welcome , this will be ideal platform also for oem developer : Autopilot and Gimbal Control systems :) The performance of VRBRAIN with ST F4 micro controller could be until 30x resource available respect at standard AVR micro controller (arduino)

Best

Roberto

Read more…

artefato-voador-transportando-celulares-e-encontrado-pela-policia-em-presidente-venceslau-sp-1338393063558_615x300.jpg

http://noticias.uol.com.br/cotidiano/ultimas-noticias/2012/05/30/mini-helicoptero-com-celulares-a-bordo-e-encontrado-perto-de-rodovia-no-interior-de-sp.htm

Says that roadside cleaning workers found a abandoned hexa-copter near a penitentiary (in  Presidente Venceslau, São Paulo state, Brazil), loaded with 3 cell phones with chargers and 3 saw blades (amateurs!). Probably was an attempt to deliver the cell phones to inmates (cell phones are very forbidden in Brazilian penitentiaries). Previous attempts involved pigeons with small backpacks, bows, arrows, and more.

No good news. I can already hear our precious politicians discoursing against hexacopters (and pigeons, and bows, and arrows,...).

Read more…
3D Robotics

Kids robot racing at Sparkfun's AVC

3689459572?profile=original

Good news for those joining us at Sparkfun's Autonomous Vehicle Competition: if you're bringing your kids, they'll have something fun to do:

Sparkfun announcement:

At this year's competition, we will have an 8-by-8 foot maze, as well as a racetrack, where you can compete and play with robots. You can build with LEGO, VEX, Arduino, BASIC STAMP, PIC, Gears ... whatever you want! Bring your robot to AVC and we'll help you run the courses. 

Kids will run their races between the adult heats, and each kid will have three runs (time permitting, we hope to also get a few practice runs in). If the maze is a bit challenging, we will weigh it against the plain speed track to form the judging rubric.

A couple of technical points:

  • Your robot should be less than 8 inches wide to fit through the maze.
  • The course walls will be approximately 3 inches tall, and painted white for calibration.
  • You can run any platform you bring, as long as it does not harm the other robot. Good sportsmanship please!
  • We will break out three age groups -- 8 and under, 8-12, and 12 and up -- but we may run you all together.

What if you don't have a robot? Don't despair! We will be providing a limited number of ProtoSnap MiniBots and computers, so kids can play with them and get to run a bot even if they don't have one of their own. There will be SparkFun volunteers to help get everyone straightened out on programming the MiniBot. Unfortunately, we won't be able to help with programming other platforms.

We are scheduling this event on the AVC EventBrite sign up, so if you want a good seat, please register as soon as possible, and let us know how many kids you'll be bringing.  If your entrant(s) will need access to a robot, please email us at education@sparkfun.com; that way we can do our best to make sure we are prepared and no one is disappointed. If you are using one of our robots, we may schedule you around the demand for MiniBot.

Read more…

3689459533?profile=original

As you might have heard, a few days ago a strong earthquake hit the North of Italy, destroyed lots of industrial buildings and caused several deaths. On an Italian news portal there is a video of a RC quad (cannot recognize the model, but maybe someone else can) used to survey collapsed buildings, trying to spot survivors and assess damage.

Unfortunately the embed code from the news site doesn't work here, so if you want to see the video you have to go to the site (from second 42 to 57): http://video.repubblica.it/dossier/terremoto-emilia-20-maggio/il-capannone-a-san-giacomo-roncole-macerie-e-droni-in-azione/96803

Read more…
3D Robotics

Housekeeping note: Kevin Finisterre

In the five years that we've been running this site, the Moderators have banned thousands of spammers, but only three or four members for violations of our Terms of Service, which make clear that civil discourse is paramount and personal attacks will not be tolerated.

This is not something we do lightly. It happens only after repeated violations and warnings, and we do it with a heavy heart and for the good of the greater community, who deserve a place for civil discourse and mutual support. We also try to be as transparent as possible about the process when it has to happen. 

I'm sorry to report that we have come to the point of having to do this again. We have suspended Kevin Finisterre for repeated violations of our TOS, including multiple personal attacks and the publication (via Twitter) of the contents of a private message communication with another member, which is a gross violation of that member's trust. This is the final straw in a long track record of abusive behavior to other members here, and he has been warned several times that he was at risk of banning for this. He has hurt many people here and otherwise made this a less happy place. That's bad for everyone.

This is a shame, because despite Kevin's mistreatment of other people, he made some good points and otherwise could have been a valuable contributor to the community. That's why I want to make it clear that we are not deleting any of his content, which will remain on the site, despite its tone and violations of our TOS. Also note that it is a suspension, not outright banning. I hope we can find some agreement with Kevin that will bring him back on more civil terms.

I must also report that he has threatened to create aliases and attempt to cause chaos here if he is banned, so if this happens the Moderators will attempt to be as vigilant in tamping this down as possible. But we would appreciate the community's help us in spotting and helping stop any behavior that seeks to undermine the civil and mutually supportive atmosphere that we have tried so hard to maintain here.


Thank you for your understanding and help in preserving DIY Drones as a friendly place for civil discourse and sharing. And my special thanks to the 50+ Moderators, who work so hard every day to help maintain a high signal-to-noise ratio here. If you'd like to join them and have a track record here, please PM me. We'd love to have you join us!


--Chris


Read more…

A new 9 axes inertial sensor from ST

3689459558?profile=originalST extends it's gyro line with a new 9 axes IC - LSM333D.

Features:

1. 3 axes gyroscope with ±250 to ±2000dps selectable rotational acceleration full-scale range;

2. 3 axes accelerometer with ±2g to ±16g selectable linear acceleration full-scale range;

3. 3 axes compass with ±2 to ±12gauss selectable magnetic full-scale range;

4. LSM333D includes a built-in temperature sensor and smart power management for longer handset battery life;

5. The module allows the choice of either I2C or SPI connection to the main system controller.

6. The LSM333D is available in a 3.5 x 6 x 1mm package, and will soon enter volume production in the 4 x 4 x 1mm package.

Here's the datasheet of the LSM333D in a 3.5x6x1mm. package - http://www.st.com/internet/com/TECHNICAL_RESOURCES/TECHNICAL_LITERATURE/DATASHEET/DM00050102.pdf

Waiting impatiently for the first samples for testing.

Best regards

Nick

Read more…

Add a backup battery on the MTK GPS module.

Hello Everyone, we all know our GPS board (the one that comes with the APM1) has no battery to backup data.

2011_0415%2003%20%20GPS%20backup%20battery.JPG?width=500

This has the disadvantage to make the GPS not very precise in the first minutes after power up and that every startup is a cold startup (at least one minute to get a 3D fix).

This is because the GPS needs find the satellites without a previous almanac (that is information on position of the satellites visible in that location at a specific time).

As you understand almanac is VERY important. Also considrer that the almanac is sent by every satellite and requires 12.5 minutes to transmit (or so).

From Wikipedia:

 "Finally, the almanac allows a single-frequency receiver to correct for ionospheric error by using a global ionospheric model. The corrections are not as accurate as augmentation systems like WAAS or dual-frequency receivers. However, it is often better than no correction, since ionospheric error is the largest error source for a single-frequency GPS receiver. Each satellite transmits not only its own ephemeris, but transmits an almanac for all satellites"

Of course this is not sufficient to have a perfect position: sky visibility, surrounding objects and number of satellites are the key factors. 

This is why after a FIX (fixed blue led) number of satellites is very low (5 to 8) and this get higher (10 or 12) after some time of flying.

So, because of this, I decided to bring up an old hack made by Dcaspi, an old friend who worked also on the former Ardurpirates code.

The hack requires some soldering skills, so I suggest you to do it only if you are confident with it.

Beware if you fry the board or GPS unit, I cannot (nor Dcaspi) be responsible for it...

This mod works and has been used for a while.

This is the original location:

http://code.google.com/p/ardupirates/wiki/MTK_GPS_backup_battery?ts=1303127560&updated=MTK_GPS_backup_battery

Have fun!

Emile

Introduction

If you use the DIYDrones MediaTek? GPS, you're probably aware of the fact that, on each activation, it make take a very long time to get proper satellite lock. The reason is that it always starts from scratch; it is not aware of it approximate geographic location, not of the time.

The reason for this is lack of backup battery. Data is completely erased once you disconnect the main battery.

The GPS module itself has a backup battery input. Here we show how to connect an external battery to that input.

What You Need

You will need a a battery holder and a small, 3V, coin-shaped lithium battery. These can be purchased at any DIY electronics store.

I also used a piece of perforated prototyping board, but this is for convenience and not a must.

How It's Done

Below, you can see the GPS module board layout. Cut one trace as shown, and connect the two leads from the battery holder to the marked places.

2011_0415%2005%20GPS%20backup%20battery.png?width=650

Here is how the setup looks:

2011_0415%2002%20%20GPS%20backup%20battery.JPG?width=650

2011_0415%2003%20%20GPS%20backup%20battery.JPG?width=650

This is how it looks from below. Note the place where the trace is cut:

2011_0415%2004%20%20GPS%20backup%20battery.JPG?width=650

Read more…
3D Robotics

UAVs for wireless sensor charging

3689459379?profile=original

New research by the NIMBUS lab at the University of Nebraska-Lincoln has demonstrated how a UAV could hover over electronics on the ground and charge them. This might be useful for distributed sensor networks that can't use solar energy to recharge batteries. 

From IEEE Spectrum:

The type of wireless power that these quadrotors are beaming out is based on what's called "strongly coupled magnetic resonances." Basically, you've got two coils of wire: one on the quadrotor, and one on whatever you want to power or charge (we'll call this the receiver). The quadrotor drives a current in its coil, which generates an oscillating magnetic field. When the quadrotor gets close enough to the receiver, the receiver's coil starts to resonate with the magnetic field transmitted by the quadrotor. That resonance induces a voltage in the coil, which the receiver can use to power its electronics or charge its battery.

As far as applications go, the researchers suggest that this kind of system would be great for "highway messaging systems, ecological sensors located in forests, or sensors shallowly embedded underground or in concrete." UAVs would act as mobile power stations, zipping around and delivering power to sensors when necessary. 


Read more…

Hi all,


We have been selling our AeroMapper UAV as a kit so far, and we are glad to announce our new Ready To Fly version is available now.  Basically this is our second option which includes installed servos, motor and ESC, batteries, RC transmitter, and even battery charger.3689459421?profile=original

We have our first batch in stock. Please note that availability status change very fast for now, as this is on a first come first serve basis. Anyway within the next month our plan is to keep units in stock always ready to ship!

We are very excited to announce also that our third option will be available pretty soon, which will include ArduPilot Mega 2,0 installed and basically ready to fly!   This make the AeroMapper UAV a very hard to beat combination for a high-end fully-composites UAV for remote sensing and photomapping. This option (Option C on our website) will be priced at less than $4K !! (Including electronics, batteries, RC Transmitter, chargers, etc., camera and autopilot).


Also, in about two months our parachute recovery module will be available and can be easily installed in any of the AeroMapper UAV options, which share the same airframe.


Features:

A cool feature on our design is that all the parts are completely modular. For example, if you need to repair or change the fuselage, just easily detach the Payload Bay Module which contains almost all the electronics. This way you don’t have to uninstall or reinstall things like the autopilot, camera, ESC…. Just add the motor, elevator and rudder servos to the new fuselage, reattach the Payload Bay Module and you are back into the air in no time. This is especially helpful when you are in the field mapping or doing jobs and when time is key.  Spare parts always available in stock, at very reasonable prices.

Additional features:


- 2 piece wing for easy transport.

- Full composites (carbon fiber and fiberglass).

- Very durable and strong.

- Totally modular

- 1 hr of flight endurance with the set of batteries included (Options B and C).

- Hand-launch

- Payload bay module has a servo activated cover to protect camera lens and   electronics during landing.

- Excellent wind penetration and wide range of speeds.

- Full flaps for low speed landings.


For more information and orders: http://www.aeromao.com/the_aeromapper_uav


Videos coming soon....!!


3689459456?profile=original

Read more…

I've been thinking include OpticalFlow whit laser sensor point.
all came into my mind after seeing this post.

I've been thinking include OpticalFlow whit laser sensor point.
all came into my mind after seeing this post. or I I think it would very accurate. What do you think?.
but as this in the arducopter?3689459335?profile=original


http://ashishrd.blogspot.com/2006/11/obstacle-detector-using-webcam-and.html

Hi everyone! I’m back with another webcam project, as usual. :) I’ve been having a lot of fun making cool things using my webcam over the last couple of months. This time, I’ve created an obstacle detector which uses a cheap laser pointer and a webcam to determine how far an object is from the camera. I worked with my cousins, Anuj Karpatne and Prateek Raj on this project.

There are all sorts of range finding devices available in the market like ultrasonic and infrared range finders. All these devices work well, but where portability and cost are of primary concern, this technique could be more desirable.
3689459365?profile=original

So, here’s how it works. A laser pointer is fixed below the camera at a known distance (as you can see in the picture above). The pointer is kept parallel to the optical axis of the camera. Then, a laser-beam is projected on an obstacle which is supposedly in the camera’s field of vision. The scene, along with laser dot is captured by the camera. Then, the image is scanned for the brightest pixels (we are assuming that the laser dot is the brightest point in the scene). Then, we calculate how far along the y-axis the laser dot is from the center of the image. The farther from the center, the closer we are to the obstacle. So, the distance from the object (D) is inversely proportional to the number of pixels from the center of the image (y):

D = hY/2y * cot (A/2)
Where the constants used are:
h = the actual distance between the laser pointer and the optical axis of the camera.
Y = total number of pixels along the y-axis
A = angle of view of the camera

As these values are constants, we obtain,
D α 1/y
Or, D = k/y (where k is the proportionality constant for all the constants used above)

We used an experimental approach to determine the value of k. We wrote a simple program in C# to do the entire image processing work and for finding the position of the laser dot in the scene. We calibrated the apparatus by placing an obstacle at known distances from the center of the camera and noting down the number of pixels the laser dot is from the center of the image along the y-axis. After taking several readings, we obtained the value of k. By using this value, we were actually able to determine how far an obstacle is, from the camera.
Well, we had a lot of fun working on this project! I hope you find it interesting. I’d love to hear your comments and ideas. :)


Read more…

3689459066?profile=original

On 5/20/12 North Texas Near Space (NTNS) and Project Soar collaborated on a dual launch during the annular eclipse. Albuquerque was directly in path of the eclipse. The NTNS payload had most of the electronics that I had intended for a guided flight. That airframe is no more, but I have some data that I'd like to share with the group as a result. The dual launch was a great target of opportunity for looking at APM data at altitude. Most of the flight objectives were met.

KML:

NTNS-1 at Altitude.

3689459118?profile=original

Project Soar Payload at Altitude:

3689459162?profile=original

The NTNS-1 payload captured the Soar payload during descent.  I don't know if this has been done before.

3689459144?profile=original

I'm glossing over the APM data because most of the setup, objectives, data plots, lessons learned, future activity are documented below.  The APM data was converted to CSV so that it's fairly easy to read.  I really brute forced this and should have written a script.  SW V2.28 was somewhat modified to reduce the data frequency to a constant 0.5 Hz.  It turned out that the flight time from turn on to recovery was just under 3 hours and produced only an 805 kb log file.  Obviously I needed to gather more variables or choose a higher rate. I was lucky enough to be able to walk up to the payload and turn it off.  APM operated through the landing.  There is another thread that we did pre-launch discussing tailoring of the data stream.  Unfortunately I didn't get to far mainly due to time.  I was done with SW the day before the launch.

Postflight Data and Reconstructions: Postflight

Data Spreadsheet and Plots: Analysis Spreadsheet

Log Files and other data: TM

Preliminary Video Rendering: Best in 1080p setting

If you poke around in the site you can find 1920X1080 frame captures for most events.

We're getting collectively closer to making some guided flights. Now we have 2 data sets.  Best of luck to all.


Regards,

Larry D. Grater


Read more…