All Posts (11086)

Sort by
3D Robotics

LEGO NXT-based quad!

3689459055?profile=original

Long time readers here will know of my love for LEGO Mindstorms NXT, and my first NXT autopilot many years ago. So I was delighted to see this project, which uses an Arduino IMU plus NXT and the official First Robotics League TETRIX parts to create a LEGO quadcopter!

The NXT reads orientation information from the Arduino, calculates the motor speeds required to maintain stable flight, and sends these motor commands back to the Arduino, which spins the motors via the speed controllers.

So does it fly?  Yep.  Is it graceful?  Nope.  Check out the video of its first (and only) flight.

Read more…
3D Robotics

OpenROV in the New York Times

3689458947?profile=originalFrom Boing Boing:

"In the New York Times today, Brian Lam (formerly of Gizmodo, now the creator of Scuttlefish and Wirecutter) writes about OpenROV, a low-cost submarine designed to be an affordable tool for "curious students and amateurs, as well as provide a highly valuable shallow water tool for explorers and scientists."

This month, NASA engineer Eric Stackpole hiked to a spot in Trinity County, east of California’s rough Bigfoot country. Nestled at the base of a hill of loose rock, peppered by red and purple wildflowers, is Hall City Cave. For part of the winter the cave is infested with large spiders, but is mostly flooded year-round. Locals whisper the cave’s deep pools hold a cache of stolen gold, but Mr. Stackpole isn’t here to look for treasure.

He had, under his arm, what might appear to be a clunky toy blue submarine about the size of a lunchbox. The machine is the latest prototype of the OpenROV–an open-source, remotely operated vehicle that could map the cave in 3D using software from Autodesk and collect water in places too tight for a diver to go. It could change the future of ocean exploration. For now, it is exploring caves because it can only go down 100 meters. But it holds promise because it is cheap, links to a laptop, and is available to a large number of researchers for experimentation. Indeed, the OpenROV team hopes to start taking orders for OpenROV kits on the crowd sourced project site, Kickstarter. Going for $750, the kits include laser cut plastic parts and all the electronics necessary to build an OpenROV. (Users will have to bring their own laptops to view the onboard video feed and control the machine. They’ll also have to supply their own C-cell batteries which power the sub.) The subs are expected to be available by the end of summer.

Read the full story here, and check out the awesome video Brian shot, here."

Read more…

Australian miners send drones to work

3689458843?profile=original

A Slashdot user aesoteric writes "Australia's top miners have opened a new front in their march to automation, flying unmanned aerial vehicles in increasing numbers at remote sites across the country. They've been used to inspect a fire-damaged oil rig, perform aerial photography and stockpile surveys.

There is also a trend towards non U.S.-built UAVs, due to the lag in receiving export approvals for the aircraft and spare parts."

http://www.itnews.com.au/News/302240,australian-miners-send-drones-to-work.aspx

http://tech.slashdot.org/story/12/05/29/003205/autralian-mining-companies-increasing-use-of-uavs

Read more…
Moderator

mza_7829643152360638697.480x480-75.jpg

“Fly a UAV. Learn about robotics. Explore the universe. LM Tomorrow is a science and engineering app that provides insight into some of Lockheed Martin’s most innovative technologies and how they work. From flying a micro-scale Unmanned Aerial Vehicle (UAV) and human exoskeleton design to some of the company’s more well-known products such as air and spacecraft, you’ll learn how sciences such as aerodynamics, electromagnetism and kinetics are translated into a variety of technologies.


http://www.suasnews.com/2012/05/16173/lockheed-martins-tomorrow-for-ipad-fly-a-drone/

Read more…
Moderator

APM-eye's view of News Interview

Here's an interesting bit from a recent news interview with me and Andreas... for my segment, I had parked the quad so that it would be visible in the background over my shoulder as I talked to the interviewer.  While he was recording the quad, the quad was recording him!

If I would have planned ahead a bit I would have framed the shot better, but I was happy with how it turned out. The wind was coming over the hill at about a 45 degree angle which explains the lateral motion.

http://eastbay-rc.blogspot.com/2012/05/aerial-view-of-kgo-interview.html

Read more…

APM2 conversion to Naza

Morning everyone!

So i decided to try the whole Dji thing. It took all of about 20mins to swop the APM2 with the Naza.

The setup is as simple as it gets. That took no more than 10 mins.

After installing the hardware and software I took it outside and attempted the first flight.

All I have to say is wow! A truly awesome piece of engineering! Dont get me wrong, I love my ardupilot!

But the Naza is just amazing! Im not a very experienced pilot so im still a little wobbly flying the APM2.

The real reason behind buying the Naza, is for videography. I cant fly the APM2 stable enough for videography, obviously its perfectly suited for that, Im just not experience enough to fly it well enough. Duran DeV flies all his copters on APM and his videos are mind blowing. So its not the FC, its the pilot!

For a not so fresh noob, the Naza makes the whole experience a dream. I did a direct swop out of the FC on the standard jDrones Arducopter and it worked like a charm, no tuning or anything.

I only flew it in atti mode. Which I think is awesome for videography, the alt hold is accurate to within a few centimeters.

And when I put my gopro on it, which threw out the COG, the flight dynamics remained exactly the same!

I hope the Ardu boys dont get upset with me for posting this, but one has to have an open mind to all new tech :)

G:)

P.S. I bought a ST Discovery high wing foamy trainer for my APM2 for photogrammetry, so Ill post some vids and or crashes of that soon!

Read more…
100KM

techpod prototype

I finally have a prototype of the molded epo Techpod ! i will have it in my hands in a couple weeks .

3689458773?profile=original

3689458671?profile=original

when i receive it I will test fly it and if everything goes well I will launch my  kickstarter campaign . I need $40,000 for the first run and molds . I have pored my heart and sole into this design for more then 3 years . I did it because I believe the UAV community and society deserves a high performance  no compromise airframe that does not come with a $10,000 price tag . it will go for ~ $225 $180 for the kit including everything in the top picture .please keep me in mind and consider supporting this project . I also have a new home on the web http://hobbyuav.com/featured/uav-kit/

here are some links with more info and background on the project

http://diydrones.com/video/techpod-alfa

http://diydrones.com/video/techpod10-remzibi-osd

http://diydrones.com/video/705844:Video:46848

http://diydrones.com/profiles/blogs/techpod-epo-foam

http://diydrones.com/profiles/blogs/techpod11-1

http://diydrones.com/profiles/blogs/techpod10-ready-to-ship

3689458582?profile=original

3689458796?profile=original

3689458692?profile=original

thank you for your support

Read more…

3689458537?profile=original

Hi pilots,

I'd like to introduce some products comming soon, developed by Nick Arsov with the invaluable assistance of Bill Premerlani, Robert Dickenson, Ben levitt, Peter Hollands, Riccardo Kuebler, Mark Whitehorn and Matthew Coleman.

The new AUAV2 (TINY UDB5) will be ready soon for testing. It has dsPIC33FJxxx MCU, SPI, I2C, UART, CAN,analog inputs, digital I/Os, MPU6000 gyro-accelero, HMC5883 compass, LPS331 altitude sensor, 5V 500mA, 3.3V 500mA LDOs and many many new features.

Here's the schematics - AUAV2_dsPIC33FJ_80pin_R2.pdf

Here are some additional pictures of the IMU board. Please note it holds it's sensors on a separate ultra small daughter boards. I used this approach for easy replacement with newer IC when available.

3689458549?profile=original3689458559?profile=original3689458724?profile=originalThe IMU board has MicroSD card reader, 2x GPS connectors, super cap for GPS and holds 3 micro sensor boards.

Here's the schematics - AUAV2_IMU_MICROMODULES_R1.pdf

Also I'm preparing a new OSD microboard...see the picture attached. This board was developed with the great help of Ben Levitt !

3689458737?profile=originalMore info about the future products you can read on www.arsovtech.com .


Also new lower summer prices are promoted!!!!!!


Have fun !

Read more…

Downward facing camera

marcy2_37.jpg

marcy2_38.jpg

marcy2_39.jpg

marcy2_40.jpg

marcy2_41.jpg


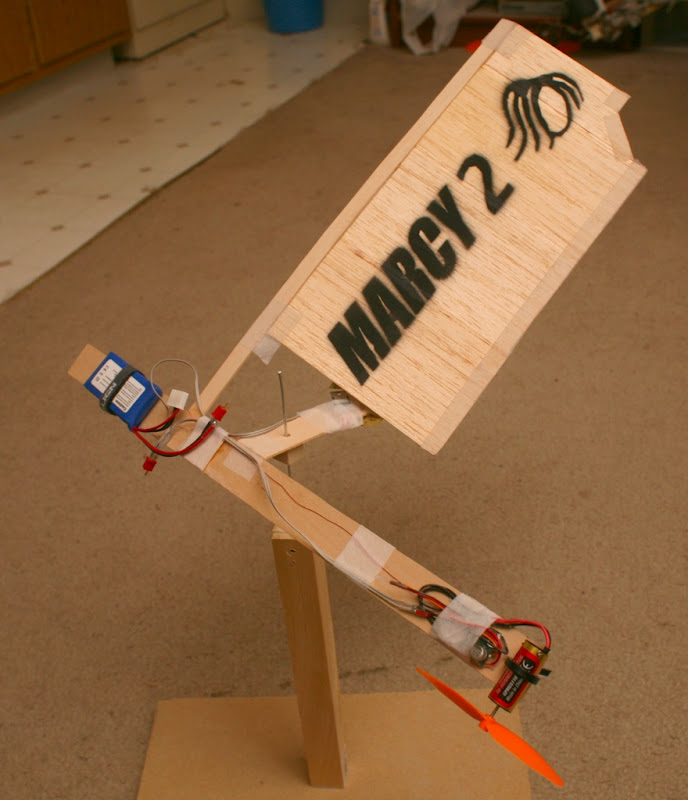
The 1st attempts to point the camera straight down were failures.  It can be pointed straight down & it gets the same target in every frame, but these arrangements screwed up either the starting pin or the center of gravity.

It became obvious that the propeller had to thrust on the plane of the center of gravity for the most stability, so all the electronics had to be in the same plane.


Having the wing below the plane hindered all the Marcy class.  Part of the coning angle would be the center of gravity in the wing lifting into the plane of motor thrust.  At  least this showed a winglet should add more stability than a dead weight, by having more mass in the motor plane.

images09


So that was the axial pointing camera revealing new rolling shutter distortion.  Instead of uniform vertical squishing, the top right had stretching & the bottom left had squishing, in both directions.  That is correctable, by knowing the rotation rate & scan rate.

marcy2_42.jpg

marcy2_43.jpg


This was the best arrangement.  Moving it from the wing to the balance beam got the Y axis on the camera to always be parallel with the spin axis.  If the camera was on the opposite side of the spin axis from the wing & on the balance beam, its field of view in its X axis would cover the spin axis instead of looking away from it & its Y axis would always be straight down.

cam85.png


So the camera could look straight down the spin axis just by repositioning it on the plane of rotation instead of building a diagonal harness. 

images10.jpg


Also noticed there was a good chance the attitude could be determined by looking at the takeoff stand's position in the frame.


Anyways, object recognition with SURF was worthless on the 160x240 video.  There seems to be a minimum complexity before SURF detects a feature point.  The resolution isn't high enough to hit that minimum complexity.

images11.jpg

images12.jpg


At flight altitude, the marker is gone.  The AR Drone required much higher resolution just for detecting velocity.

With the camera pointing at the floor, there might be a future in chroma keying.  The floor is more uniform than the ceiling.


Marcy 2 would require covering a large area of the floor in markers.  The field of view is too narrow for a single marker.  A simple grid with different codes in each square would do it.  A flashing laser projected from the aircraft, off axis from the spin axis, might give altitude.  Sonar altitude is too expensive.

 With the camera limitations & frame rates now well known, any kind of object recognition was ruled out.  The only real option was what it was on Marcy 1: color based blob detection.


chroma


Setting the camera to only record chroma reveals it detects RGB.  Yellow doesn't show up at all.  Some fluorescent pink posterboard showed up nicely. 

chroma02.jpg


Even with it pointing down at a featureless floor, chroma keying was still a problem.

chroma03.jpg

chroma04.jpg

The onboard camera didn't work as well as the DSLR.  It was in chroma-only mode to get enough information to do chroma keying at 25fps.  The color resolution was 160x240 & the hardware saturation was at maximum, which still allowed a lot of saturation changes.

Surprising how well the blue came out.  Humans must not see it as well as cameras.  Yet it detected pink better than red.


Saturation & hue were still being captured.  Maybe it would go faster if just the hue was captured.

chroma05.jpg


Plotting all the possible chroma values, a 256x256 lookup table emerged, in which chroma was converted to hue.

chroma06.jpg


The result was such a noisy image, it actually increased the bitrate & sent the framerate down to 15.  Not the intended result.

What looks like more differentiation between green & background, the computer actually didn't notice. It still detected the least differentiation with green & the most differentiation with pink.


Anyways, some tests with OpenCV blob detection didn't work.  That requires some training data, which they don't give an example of.  Camshift showed pretty good results.  Red, yellow, & blue showed good separation from the background.  The camshift algorithm has a good detection step for getting the size of the object.

The mane problem is it takes lots of tweeking.  Manual white balance was a must.  Also, it did best with the full RGB data instead of just the chroma.

Full RGB limits you to 80x120 for the chroma & 160x240 for the luminance.  160x240 with full frames buffered, full chroma resolution, & dropped frames started looking pretty tempting.

Read more…
3D Robotics

3689458630?profile=originalMicroFly, an open source nanoquad, hit its Kickstarter funder target of $5,000 and will be funded. From the project page:

I've been inspired by the crew at bitcraze.se, where they are building a simple quadcopter at a tiny scale; every component is carefully selected to be mounted on the circuit board. The circuit board itself acts as a chassis for the quadcopter, and custom 3D printed components are used to mount the motors. The reason? To make it as small as possible, without redefining the quadcopter. I would like to do the same, but with some important differences.

So what makes my design different than other open source quadcopters?

In my design, I plan on using embedded WiFi, so the quadcopter can be controlled from a computer on a standard wireless network you might have at home. As a result, the quadcopter can go as far as your wifi signal stretches. This quadcopter is small, which inherently makes it excellent for indoor use.

The quadcopter will have redundant IMUs (Inertial Measurement Unit) to ensure a stable flight for the entire battery life. The Microfly will also run on a small lithium-ion battery that can be recharged from the USB port on your computer.

Does anyone understand the appeal of two parallel ("redundant") IMUs? I've never heard of that and don't really get why it's necessary. 

Read more…

Mould Plug CNC Machining for HDwing4

Since the topic of CNC mills has raised its head here, I thought I'd share this with the DIYDrones community.

One of the things those who are considering this need to be aware of is that the toolpathing of complex shapes isn't a trivial exercise.  I would be interested to know if anyone has experience with any open-source surfacing toolpathing packages - please comment below! 

I am fortunate to have access to MasterCAM V9 - old-fashioned as it is - but only in a 2.5D package.  I then butcher my SolidWorks models into such a form that I can generate an IGES wireframe which represents the basis of a toolpath.  I then import this into MasterCAM and labouriously reconstruct it into a contiguous chain which the 2.5D recognises as a contour path.  This generates an absolute monster long .NC file which I drip-feed into the Siemens Sinumerik 820D controller that runs the mill I'm using.

The other critical point to this type of work is the machine envelope is everything.  Once you start using multiple setups to accomodate an oversize workpiece, you are adding hours and hours to the project, not to mention a bunch of risk and the inevitable mis-match of complex surfaces which will need filling and hand finishing.

As far as MDF goes, it's absolutely not a bad material to machine and is an easily hand-worked end-product which can produce a perfect finish but I do worry about the health risks and it does make an unholy mess.  I'd consider using PVC or, if you can afford it, alumnium billet.  At approximately AUD10/kg, it's not cheap though...

So, after going of half-cocked with the making of this plug, I have since revised the design pretty significantly, so now it's only a learning exercise and a lovely desk ornament!  C'est la vie!

Anyway, I hope this is helpful and interesting.

Read more…

My Ardupilot(legacy) Platform

3689458463?profile=originalHere's the plane I will install my Arduimu and Ardupilot(legacy) into.  I still need to build a motor mount and wind the motor.  It should be stable as it is based on a previous version which was very stable.  I'm aiming for 10-12 ounces AUW and around 50W.

Read more…

Good Hobby CNC Machine

CIMG0038-1.jpg

I'm thinking seriously about getting a CNC.  Been browsing on Ebay.  Mostly these China made 3020 cnc machines are popping up, and they all seem to  be relatively well priced.  Just thought I'd get some opinions from members on any actual experience on these.  Also any recommendations on getting a hobby CNC machine in general would be greatly appreciated.  I'm planning on using the machine to make hub plates, motor mounts, etc.  I'd probably be milling aluminium and/or carbon fibre.

LIST OF EQUIPMENT UNDER CONSIDERATION:

Motors/Controllers:

  1. cadcamcadcam.com (servo motors and controller)
  2. 3-axis Stepper Motor System based on DQ542MA, on Ebay
  3. 6-axis Stepper Motor System based on DQ542MA, on Ebay
  4. DC1 Servo Motor Controller, from Makerbot
  5. Servo Motor Encoder

05/26/2012:  After some discussion.  This blog is starting to look into building a CNC machine of our own.  Keep following to stay informed.  We're in the brainstorming stage at this point any input from users is welcomed.

05/27/2012: DIYDrones CNC Project group is created.  Let's move our activity to that group.

Read more…

Flaperon Trial

With much excitement I found some time to give my dual setting flaperon system a test run. In the video, it's used during the low altitude and climb out at the beginning, the landing, and a couple other points along the way. It does feel a bit better for landings and launches, but I think I might increase the 'flap' angle to the full throw of the servo to get the maximum effect possible.

For those wondering, this uses the Turnigy 9x transmitter with er9x firmware. I have two switches which each supply additive signal to both of the differential aileron channels.

I'm moving in a couple days so I've packed up the plane and quad for now, and this'll be the last testing at this location for a while. I can't wait to see if ArduPlane can handle the tx-based flaperons (fingers crossed).

Read more…

Members of DIY Drones using optical flow sensors, such as the ADNS3080 that is available in the DIYDrones store, or the Centeye vision sensors might be interested in the work I presented last week at ICRA.


The method, described in the video above, allows to calibrate the viewing direction of optic-flow sensors thanks to a very simple calibration process as long as you have a 3-axis rate gyroscope. It is particularly useful when one needs a correct orientation for de-rotation (removing the component induced by rotation from an optic-flow vector), but it is generally useful for all types of applications, from obstacle avoidance to ego-motion estimation.


The paper can be downloaded here and the code for off-line calibration here.

Read more…
Developer

jDrones Report: Beijing Hobby Expo 2012

3689458380?profile=original

Beijing Model / Hobby Expo May-2012


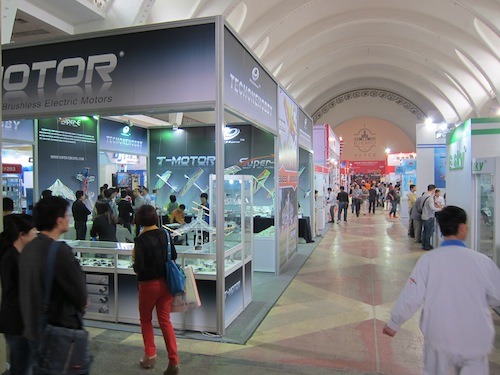
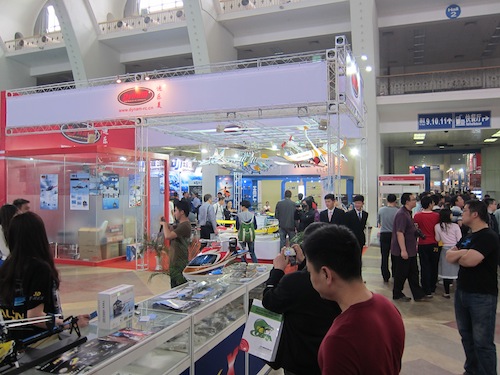
jDrones visited on Beijing Hobby Expo this May-2012. Beijing model expo is one of the biggest in mainland China. There are hundreds and hundreds of people around the world visiting on expos every year. This year was not exception. We saw and talked with lot of people from various countries around the world.


It was really pleasant to visit there and to see many of our friends on their exhibition booths. Almost every 5th exhibitor already knew us and greeted us warmly. We also make some new friends on expo area, some will be our members on our global partner network and some will be more closer contacts.


P2_2444_BJ_jDrones_Overall_sml.JPG?width=500


P2_2490_BJ_jDrones_OverAll2_sml.JPG?width=500


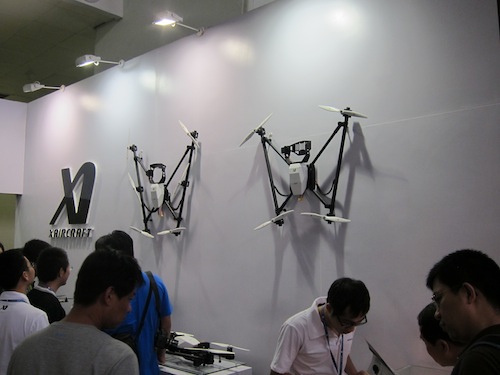
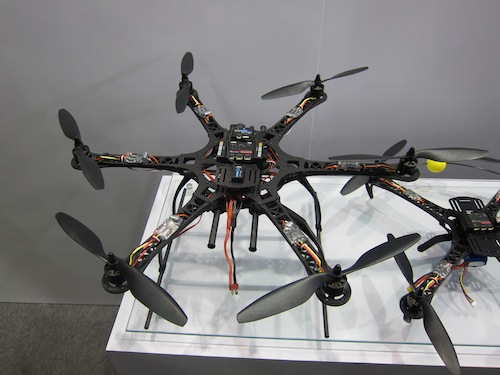
Whole expo area was spread around 3 big halls on Beijing EXPO center. There we not any really big surprise on area. Maybe biggest change on overall was exposure of multicopters and similar devices, almost every 4rd manufacturer had some type of multicopter on their booth.


But in generally whole expo was build around all those traditional areas like:

- Airplanes, Helicopters

- Motors & Servos

- Boats

- Cars


Another thing was battery and motor providers. Those has really big part on this years expo.


So let's first take a look at some of the multicopters over there. 

P3_2451_Bj_jDrones_XAirCraft_sml.JPG?width=500


More traditional looking hexa copters..

P3_2453_BJ_jDrones_XairHexa_sml.JPG?width=500


Generic folding frames was also present. Frame was made mainly from Kite parts
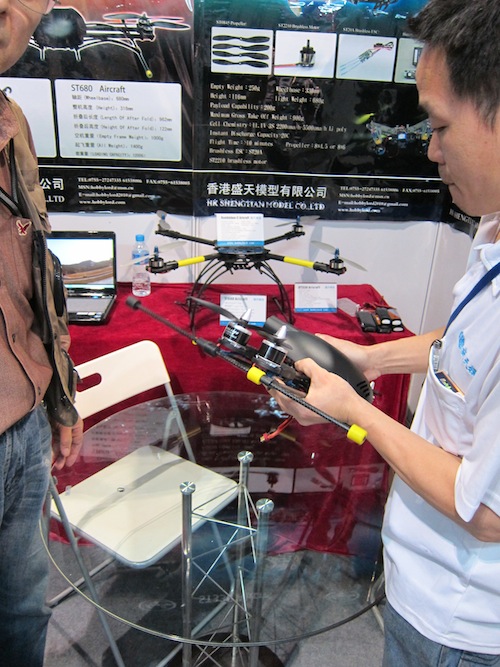
 

P3_2552_BJ_jDrones_Frames.JPG


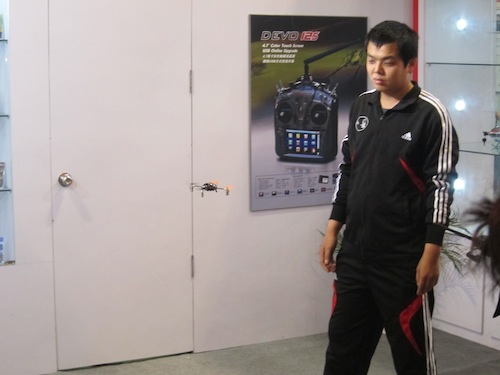
Also there were really small quad copters on Walkera booth. I mean really small :)

P3_2554_BJ_jDrones_MiniQuad.JPG?width=500


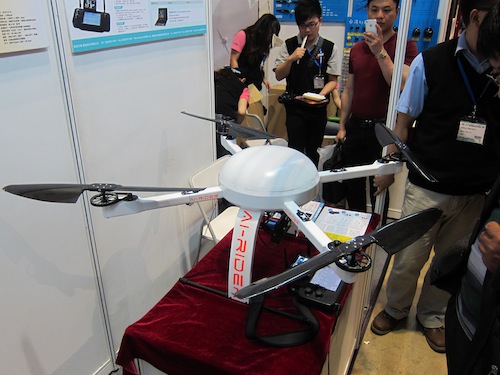
And also one really big monster quad. This quad did weight almost 3kg and it had huge 18" propellers, foldable arms and belt-driven power system. All features were integrated their custom made radio. 

P3_2478_BJ_jDrones_BigQuad_sml.JPG?width=500


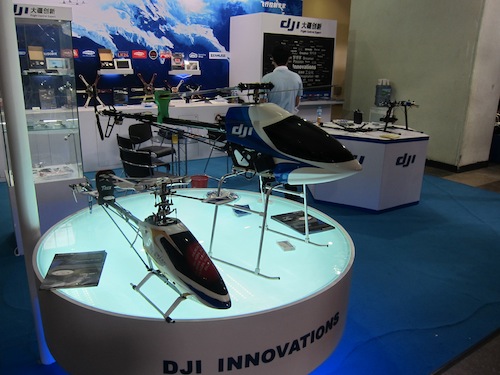
DJI has their big booth too with all their nice frames and helicopters but we never saw many people on their booth which was a bit of surprise for us. 

P4_2537_BJ_jDrones_DJ_.JPG?width=500


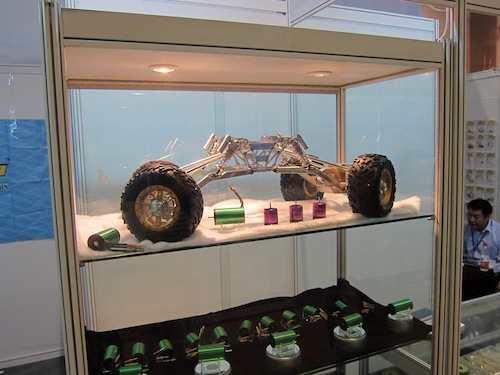
We also found one possible frame for our new ArduRover line. Let's see what future brings for us. At least this rock crawler looks really great and it's strong. It was size 1/6 full aluminum frame.

P5_2462_BJ_jDrones_Rover_sml.JPG?width=500


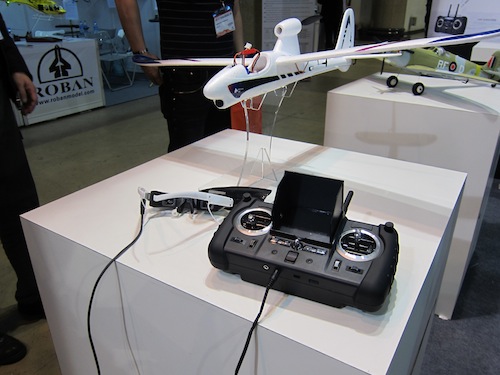
Along all those traditional and UAV airplane frames one full RTF Airplane was clearly on top of others. It was just great looking FPV plane. Elegance to the maximum...

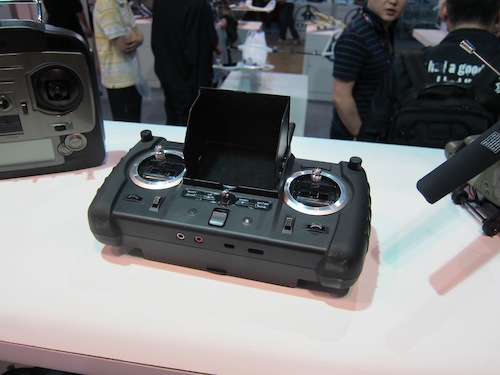
This plane had everything what you need to start your FPV career. IT had front camera, flightstabilization, RC controller, OSD. Best of all was the radio, it had it's own video display and possibility to connect even video goggles. 

P6_2583_BJ-jDrones_SpyPlane2.JPG?width=500


Radio on closeup... This radio and it's camera systems can be easily mounted on helicopters, airplanes and other devices. It works on 2.4Ghz frequency and manufacturer gives range of 1-2km for it.

P6_2585_Bj_jDrones_TVReceiver_sml.JPG?width=500


Other really interesting thing on whole expo was all those great looking nice toys that growing boy just cannot live without. And by toys I mean all great tools what they had. 

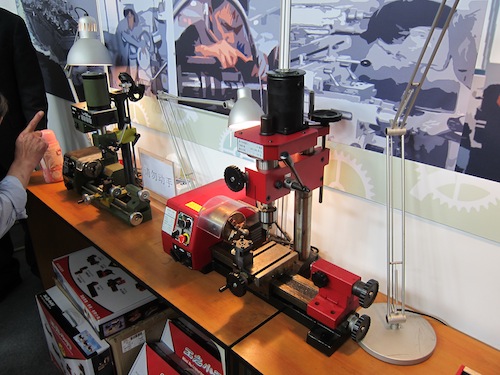
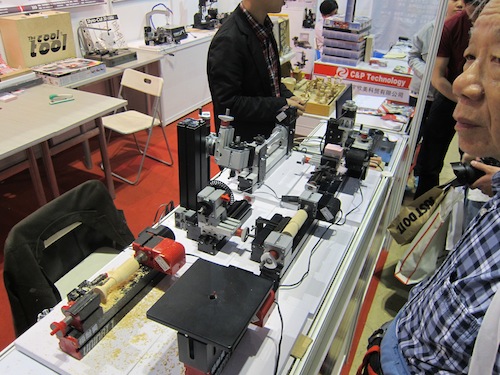
There were several companies selling Milling machines, Millin/Lathe machines and also small hobby 6-in-1 modular machine sets.

P7_2455_BJ_jDrones_MillingMachine.JPG?width=500


One of my favorite was this miniset that can be easily modified from small lathe to milling machine or even tablesaw. It was looking absolutely amazing piece of work. Every home hobbyist should have at least one set. Even thou we here at jDrones have big CNCs/Laser cutters/Milling machines I personally thing that I need to have one of these sets too (when I get it, I will make detailed review of it).

P7_2480_BJ_jDrones_MiniTools_sml.JPG?width=500


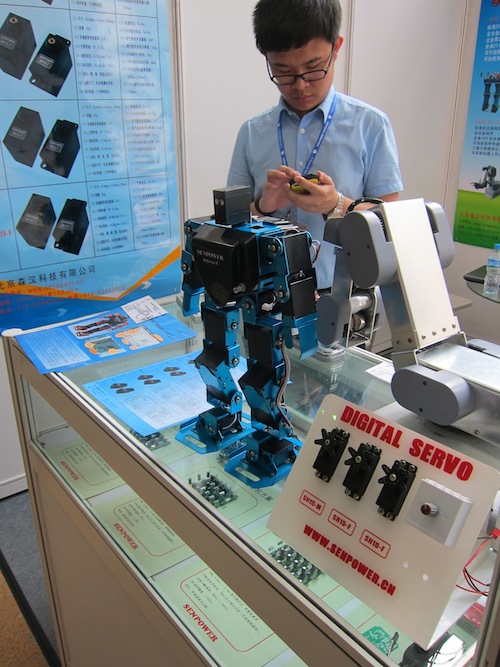
One nice MUST thing is to have your own personal mini robot. It was even dancing some Shakiras football theme.

Robot had 14 servos, ARM cpu and it did rock while doing pushups/dancing and stretching like old Arnold ;)

P8_2565_BJ-jDrones_Robot.JPG?width=500


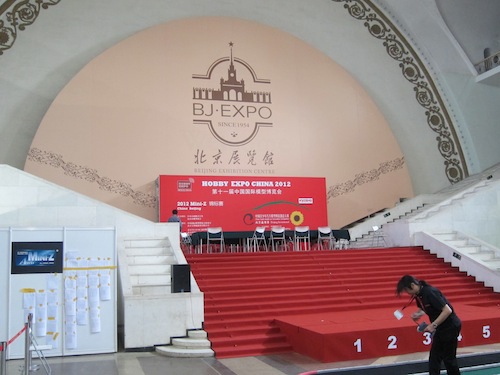
That's about it for this year Hobby Expo. Thank you Beijing and see you next year. 

P10_2562_BJ_jDrones_MainStage_sml.JPG?width=500

Read more…