All Posts (11086)

Sort by
3D Robotics

3689458366?profile=original

Good news: Arduino has released a new version of its IDE (1.0.1) and it now supports ArduCopter/ArduPlane right out of the box. (The previous versions of Arduino required a patched version that we supplied to handle the size of the ArduCopter/ArduPlane codebase, which is considered the most complex Arduino program ever made!)

Here are the release notes:

* The IDE has been internationalized and translated into multiple languages.
Thanks to Shigeru Kanemoto for the internationalization and Japanese
translation and many others for the other translations. For more
information, see: http://arduino.cc/playground/Main/LanguagesIDE

* Added preference for selecting the language in which to display the
Arduino software. Defaults to the operating system locale.

* New upload process for the Arduino Leonardo (ATmega32U4).

* The editor font size preference now applies to the serial monitor and
error / message console as well as the editor. (Paul Stoffregen)
http://code.google.com/p/arduino/issues/detail?id=550

* Compilation has been speeded up by only compiling changed files. (All
files are recompiled when a new board is selected.) (Paul Stoffregen)
http://code.google.com/p/arduino/issues/detail?id=638

* Console log files (stdout.txt and stderr.txt) are now removed when the
Arduino software exits. (Paul Stoffregen)

* The minimum size for the Arduino software window has been reduced.
http://code.google.com/p/arduino/issues/detail?id=52

* Improvements to the Find / Replace dialog. (Peter Lewis)
http://code.google.com/p/arduino/issues/detail?id=825

* Support for selecting words (on double-click) and lines (triple-click)
in the Arduino software. (Peter Lewis)
http://code.google.com/p/arduino/issues/detail?id=824

* Don't insert newline when using serial monitor keyboard
shortcut. (Lars J. Nielsen)
http://code.google.com/p/arduino/issues/detail?id=279

* Added a preference for disabling verification on upload (for increased
speed). (Nathan Seidle)
http://code.google.com/p/arduino/issues/detail?id=842

* Added the gcc toolchain to the Linux distribution. (To use the
toolchain already installed on your system, simply delete the one
that comes with the Arduino software.) (Paul Stoffregen)
http://code.google.com/p/arduino/issues/detail?id=300

* Updating Arduino Mini upload protocol to 'arduino' from 'stk500' (should
fix problems with auto-reset not working).

[core / libraries]

* Updated (and official) support for the Arduino Leonardo (ATmega32U4).
Includes new bootloader and various fixes to the core.

* Adding overloads to Wire.write() (for Wire.write(0)). (Paul Stoffregen)
http://code.google.com/p/arduino/issues/detail?id=527

* Fixing delayMicroseconds() for 20 MHz clocks (Erdem U. Altinyurt)
http://code.google.com/p/arduino/issues/detail?id=306

* Support third external interrupt on ATmega1284P. (maniacbug)
http://code.google.com/p/arduino/issues/detail?id=728

* Update reference voltage constants for ATmega1284P. (maniacbug)
http://code.google.com/p/arduino/issues/detail?id=728

* Adding --relax linker flag for ATmega2560. (arducopter)
http://code.google.com/p/arduino/issues/detail?id=729

* Fixing Ethernet library bug on avr-gcc 4.5.1 (SurferTim)
http://code.google.com/p/arduino/issues/detail?id=605

* Fixed DHCP hostname generation. (peter)

* Simplifying microseconds to clock cycles conversions (Rob Tillaart)
http://code.google.com/p/arduino/issues/detail?id=675

* Fixed various warnings. (maniacbug)
http://code.google.com/p/arduino/issues/detail?id=688

* Fixed bug w/ repeated initial characters in findUntil(). (Jeffery.zksun)
http://code.google.com/p/arduino/issues/detail?id=768

* Added INPUT_PULLUP option for pinMode(). The INPUT mode now explicitly
disables the pullup resistors. (Paul Stoffregen)
http://code.google.com/p/arduino/issues/detail?id=246

* Fixing bug in the receiving of multiple UDP packets. (dylan and peter)
http://code.google.com/p/arduino/issues/detail?id=669

* Added ability to generate repeated starts in the Wire library (in
master mode). Extra boolean parameters to endTransmission() and
requestFrom() control whether or not to send a stop (or a repeated
start instead). (Todd Krein)
http://code.google.com/p/arduino/issues/detail?id=663

* Added Ethernet.maintain() to renew DHCP leases. (Peter Magnusson)
http://code.google.com/p/arduino/issues/detail?id=716

* Fix for CLOSE_WAIT bug that could cause Ethernet sketches to crash
over time. (mr-russ and Johann Richard)

* Fix to servo pulse timing calculation. (jwatte)
http://code.google.com/p/arduino/issues/detail?id=908

* Added readString() and readStringUntil() functions. (Adrian McEwen)
http://code.google.com/p/arduino/issues/detail?id=454

[examples]

* Updated to latest ArduinoISP sketch. (rsbohn)
http://code.google.com/p/arduino/issues/detail?id=378

* Fixed ArduinoISP sketch by lowering delay() in heartbeat.

* Other updates.

Read more…

100_5206.JPG?width=750

If you consider yourself to be one of the following, then read on:

1) Those with extremely fast airframes, such as jets or hotliners or the like.

2) Those that have more than the average dollar invested in their electronic packages.

3) Those that are just nerdy enough to just want to know if this could work.

4) Those that believe they have a vibration problem and are slightly or totally desperate.

No one likes to have to order another UAV part because something went wrong and now its a pile of little and big pieces in some unwanted location.  It is even worse still to lose your electronics on top of this.  I have two ideas for a system to reduce G-Force loading on the APM2 during a crash and indeed it could be carried over to other electronics as well.  So far as I know this has not been done before.

It occurred to me that nature has two very good examples of mechanical dampening meant to protect a valuable cargo.  I mean to use that as a guide.  Our cargo here being the APM2 board. 

Mother nature did it first in your skull.  Your brain has fluid surrounding it that has multiple purposes including mechanical isolation from forceful blows to the head that might cause brain damage.  The second example would be a developing fetus in the womb.  The amniotic fluid provides a very nice ride for the developing and delicate fetus to float around in.  I'm thinking replace that fetus with the APM2 in a box.  Oh jeez, that just sounds bad, sorry.

It should be easy....RIGHT....

Lots of things to mitigate here.  The first being what liquid could you use?  If you search the internet you can find really neat electronic submersions in a non conductive liquid such as Mineral Oil.  See it here.

Various properties need to be considered should you want to choose another liquid, but here is my take on mineral oil.

1) It would need to be thermally conductive to help dissipate the small amount of heat the APM2 would generate.  If you were to perhaps want to send an APM2 into orbit (but no one wants to do that:) you could deliberately choose a liquid with low thermal conductivity to act as a perfect blanket that would not freeze until at about -22F.

2) It would need to be non conductive right from the get go.  I think this goes without saying.  There are a lot of products out there that fit this bill but Mineral Oil is both transparent and non conductive so you could still see your APM2.

3) It would need to allow the GPS to pass an un-attinuated signal, big fancy word to mean that the liquid must not change the frequency or power of the incoming satellite signals. I've got no clue on this and I could not measure it even if I did for I lack the equipment.

4) It would also need to not interfere with the magnetometer.  Since mineral oil's origin is that it is a derivative of petroleum I doubt it will have anything ferrous and would probably fit this bill.

5) Not be heavy, typical mineral oil is about 0.8 g/cm3  so I think we are safe here.

6) Since this liquid could be released into the environment it needs to be non toxic.  Mineral Oil fits that bill too.

7) Since we are usually on a tight budget it should be CHEAP and low and behold, it really is around 10 bucks a gallon.

8) It's also a mild laxative...just thought I'd throw in that icing on the cake since we are in awe of mineral oil at the moment.

Ok, so maybe now you buy in just a little to the mineral oil idea.  Now what?

Two ways to use this, one is very simple and clean and will most likely do the job well.  To picture this think of those water filled barrels you see on some dangerous exits on the highway.  When a car (or APM2 board) hits them the dispersion of the water being thrown into the air acts as a siphon of energy in the collision.  It is quite effective and saving lives because the force felt by the passengers (or components on the APM2 board) is otherwise reduced to a safe level.

What this safe level is I don't know.  That is going to be the crux of this experiment.  So lemme get to the mechanics of it.

The first thing you could do is use some sort of plastic bag that is filled with this mineral oil.  You take a custom made box and line the entire inside with these bags.  Place your APM2 board inside this box and you have the basic idea.  The box does NOT need to be stout, it just needs to hold everything in place to let the mineral oil do its job.  In fact, if the box itself was to explode on impact that too would dissipate energy.  To provide much better protection you would need bags under and over the APM2 as well.  It seems that in theory, you could run the cables out of the top of the box without serious degradation to impact resistances.  That is idea one at the most simple implementation.

The second idea is a bit harder to pull off but could have better results.  You take a box, put the APM2 inside of it, loosely mount it, as in the mounting mechanisms would "easily" break upon impact.  Fill the entire box with mineral oil and put a lid on it.  The lid must be water tight.  All electrical connections would need a water tight exit as well.  The US Navy has a lot of methods to accomplish these connections so while it may not be practical for our purposes it is at least a possibility.  This works because once the mounts are broken the APM2 board must "swim" to the wall of your box in a thick viscous fluid which takes a lot of energy to get there. 

I can foresee testing this second idea by giving the completed box (minus the external wires) to a minor league baseball pitcher and letting him have at it with a brick wall...or you can just drop it from your roof whichever tickles your fancy.  

This is a weak outlining for a solution to crash-proofing valuable electronics.  I have no idea how many would even be interested in such an item or if anyone is willing to give this a try.  I personally don't have APM2's lying around to throw at brick walls, but some of you might!

As a side note, I can also see how this MIGHT reduce vibration issues.  Since vibration in the typical aircraft/copter/whatever for the RC world is due to mechanical oscillation from various sources (motors and airframes for example) then it stands to reason that those forces would propagate to this housing.  These boxes could have plenty of room for custom rubber mounts that you may not have room for with traditional mounting methods (whatever those are for you).  The cool thing is, if you want to reduce vibration overall then you need to have dissimilar materials used in construction.  The mineral oil will act as a very different type of material for the mechanical energy passing into the box to be mitigated before it reaches the IMU on your APM2 board.  I don't know by what degree, but it seems logical that it will indeed have an effect.

I will install SolidWorks on my main desktop at a later date and design some example boxes that are in my head to help those that can do this to get started.  Could be fun!

Read more…

Impressive new camera gimbal

I'm a big fan and supporter of open source multirotors but this is just too impressive to pass. Too bad it is super expensive and out of reach for most hobbyists. Just wanted to share this with the community and see what they have to say about the the frame, gimbal and about DJI in general. 

Read more…

New Align APS ( Auto Pilot System )


Align Helicopter APS system features:


1.Semi-autonomous take off / Landing (Activate system, semi-autonomous takeoff into position and altitude hold, hovers in attitude hold with strong holding ability to prevent drifting, suitable for hover and flight training)
2.Failsafe (Activate system, automatic return home during loss of signal situation)
3.Auto flight (Activate system, transmitter can execute multiple waypoint settings, enabling point to point automatic flights.)
4.Emergency bailout stabilization (loss of orientation, activate system, aircraft flips right side up, goes into position and altitude hold hover, and wait for further command).
5.Autonomous return home (Completion of mission, activate return home command)
6.Simple logical setting through transmitter (APS system does not require complex PC setups)
7.Supports software upgrades

Read more…

A Break from the Quad - Fixed-Wing FPV!

In the spirit of finally getting around to things, I got the HobbyKing EPP FPV plane in the air, FPV style!

The video is of my 3rd FPV flight, so pardon the less-than-ideal flying skills. I've done a handfull of flights non-FPV, but quite frankly I'm rubbish at flying that way. I suppose that's to be expected since this is the first RC plane I've ever flown, so hopefully I'll improve in the future.

As mentioned, the frame is the HK EPP FPV. I haven't put the APM in it yet, since I don't really want to switch the board between the quad and this thing each time. I've made a few modifications, among which include better wing mounting and modularity. At some point I'll post some pictures of the setup.

My current goal is to add flaperon capability for easier landings and shorter runways, as well as better photography characteristics. Of course, I'll be diving into the ArduPlane stuff when I have some time...

Does anyone have any suggestions on where to start (PIDs, mounting location/method, etc) for adding the APM? Does the current code support flaperons in some manner (whether enabled in the code, or solely on the tx)?

Cheers,

Eric

Read more…

dragon_preparing_to_berth.jpg

UPDATE: They did it!!

For those of you awake right now, Spacex's Falcon 9 rocket with Dragon capsule will be launching from Cape Canaveral, Florida in less than an hour. If successful, this mission will see the first private spacecraft docking at the ISS. Check out the webcast and live text/video updates from SpaceFlightNow:

http://www.spacex.com/webcast/

http://spaceflightnow.com/falcon9/003/status.html

Dragon won't be docking with the ISS until Friday so don't wait up for it tonight. You'll see the Falcon 9 launch, taking just under 10 minutes to reach orbit at which point Dragon will separate from the second stage of the rocket. Depending on video Tx range, we may also get to see the solar arrays deploying (even the big guys have trouble with FPV!) After the video cuts out there should be a press conference discussing what happened and explaining any anomalies.

As a former SpaceX engineer, I'd be glad to answer any questions (on publicly available info) people have about the launch. Wish them luck!

Read more…
3D Robotics

Pictures from 3D Robotics at Maker Faire

3689458032?profile=originalWe had a great time at Maker Faire, which was absolutely packed (100,000+ people). Above is a panorama shot of the 3D Robotics talk on Quadcopter UAVs, which was standing room only! (Thanks to Alan Sanchez and Sam Kelly for the ArduCopter flying and panorama photo taking).

 
3689458160?profile=original

Me (left), Massimo Banzi from the Arduino project and Sam Kelly (3D Robotics), along with 2/5ths of my kids. 

 
3689458107?profile=original

Guess what was at the NASA Ames booth? (See next photo)

 
3689458208?profile=originalAPM 1 in a balloon-dropped glider!


Here's the video promo. Check out the autolanding on a boat!


3689458191?profile=originalThe balloon payload is driven by APM 1, too!

Read more…

Lipo battery calculator

3689458013?profile=original

Introduction

A LiPo battery consists of multipe cells. These cells deliver approx. 3.7 Volts. A 4S LiPo would therefore supply 14.8V.

Apart from the cells, a discharge rate is defined by the letter 'C'. Most batteries cases say something like "25C to 40C" discharge rate. This means that 25C is the nominal discharge rate and 40C is the maximum burst discharge rate. It's advisable to stay on or below nominal discharge level to preserve battery future life. Not all brands say something about the peak discharge rate on the battery itself. For more on that, I suggest to read the manual or ask your supplier.

The battery's capacity is defined in mAh. mAh means milli-Ampere per hour. A battery with a 1000mAh capacity can deliver 1 Ampere (1000mA/1000) for 1 hour. Or 1mA for 1000 hours. The battery capacity, together with the LiPo battery's discharge rate will define its maximum current output (Ampère, A). This fact is very important to keep in mind, when choosing a LiPo battery. The combination of capacity and discharge rate is what you will need. It's important to know that the battery cells don't count up for maximum current draw. The amount of cells only determine the voltage (V) of your LiPo, as needed for your equipment.

Example calculation of discharge rate:

A 3S 2200maH 40C LiPo pack will get you this: 2200mAh x 40C = 88.000 mAh discharge rate 88.000 mAh / 1000 = 88 Ampere constant discharge rate.

So, a 2200mAh / 40C LiPo can only handle an Ampère draw of 88A at max. So that's why the combination capacity/discharge rate is of such importance for selecting the right LiPo for you project.

Example calculation of max. flying time:

A constant current draw of 20A from a 2200mAh LiPo will get you:( 2200mAh /1000) / 20A = 0.11 x 60 = 6.6 minutes flying time.

Please notice that current draw depends on your way of flying and external factors such as resistance, weight and wind. Preferably, always use a LiPo low battery warner on your RC device. This will warn you when the battery is drained before it's fully empty (20%). Don't push the LiPo. They don't like to get discharged to the bottom. And you won't like your multicopter falling down from the sky suddenly either.

Charge rate

Most LiPo vendors will tell you what the maximum charge rate of the battery is. If not, keep in mind a maximum charge rate of 1C. So, a 4000mAh LiPo can be charged at a maximum rate of 4000mAh / 1000 = 4A. Please use a special build LiPo battery charger and NO OTHER! Overcharging can cause your LiPo to catch fire and burn your belongings to Kingdom Come.

http://multicopter.forestblue.nl/lipo_need_calculator.html


Read more…

The-Reciever.jpg

Motors:

Motors come in two variants: Brushed motors, which have small brushes that switch the power through the coils, and brushless motors, which need an external controller to do the switching for them.

Brushless motors are usually more efficient, can handle higher speeds and torques, can handle huge amounts of power, and are longer lasting because they do not have brushes to wear out. they usually come in out-runner or in-runner styles. Outrunners have the permanent magnets on the outside, and their housing spins with the axle. Inrunners have the permanent magnets on the inside and have a non-rotating housing. Outrunners have more torque, but less speed, and are usually used with larger propellers. Inrunners have less torque, but can reach very high speed, and are therefore used in geared applications, such as RC cars, or with small propellers.

Motors in the RC world often have an interesting rating called Kv. Although one would expect this to mean Kilovolts, it actually means rotations per minute per volt. A 300Kv motor would, in theory, rotate at 900rpm at 3 volts. the lower the Kv rating, the more torque but the less speed a motor has, and the higher, the more speed but less torque a motor would have.


When looking for a suitable propeller, the prospective buyer may be confronted with such things as "1247" or "12x4.7". These define the propeller's size and pitch. in this instance, one would be looking at a 12 inch diameter, 4.7 inch pitch propeller. Pitch is defined as the distance a propeller would move in the air under ideal conditions in one full rotation. Propellers are also often classified into "slow fly" and normal propellers. Slow fly propellers are usually for geared applications or low speed applications, and have a curved leading edge for more efficiency. Normal Propellers have a straight leading edge for better efficiency, and are usually used with faster motors.

Gears in the RC world are usually only sold as a replacement for RC car gearboxes. they are never sold by diameter, but only by the pitch (spacing of the teeth) and the number of the teeth. A Spur gear is usually a large gear, that is turned by the pinion, a smaller gear directly attached to the motor. 

ESC:

Motor controllers, also known as ESC's (Electronic Speed Controller) are very simple to use. Their purpose is to take a low power input signal in the form of ppm, and the battery voltage, and convert it into something useful for the motor. They also have a voltage output through the signal wire, and are often used to power the receiver.

There are essentially two types of motor controllers: brushless and brushed controllers. Brushed motor controllers only work with brushed motors, and send them a PWM, a Pulse Width Modulated (not PPM, Pulse Position Modulated) power input. These are simple and cheap, and can also be used to control lights and anything else that requires DC power. Brushless motor controllers are quite different. They switch power between the three combinations of two of the three poles of a brushless motor, and modulate the speed of this according to the PPM signal.

The difference between Car ESC's and Airplane ESC's is that car ESC's usually come with a power switch, heat sink and a reversing ability, while airplane ESC's have no reversing capability (Switch any two of the motor wires to reverse spin of the motor), no power switch and usually only a minimal heat sink.

ESC's are also programmable, usually through a programming card or through the reciever and transmitter. This will vary depending on the ESC, but usually they have programmable braking, starting, and battery voltage cutoff settings.

Batteries:

Batteries come in many different Shapes and sizes, chemistries, and ratings.

The two most common chemistries for RC applications are NiMH or NiCd and Lithium polymer batteries.

NiMH (Nickel metal hydride) and NiCd  (Nickel-Cadmium) batteries are heavy, weak and outdated. the only benefit is that they may be marginally cheaper, and less sensitive to shock, vibration, overcharging, and deep discharge.

Lithium Polymer Batteries are lighter, smaller, can deliver huge currents, and have a very large capacity for their size. A 5000mAh Lipo battery is about as big and heavy as 2500mah worth of NiMH batteries. however, if pierced, discharged too far, or charged too far, they will "puff", or expand. This means that the battery is close to exploding. do not use this battery anymore, and dispose of it safely. If you keep going, it will most likely erupt in a large ball of flame and launch chemicals and burning things everywhere. Never short these batteries, they will most likely explode.

Charging: get yourself a good charger, I can recommend the Turnigy Accucell-6. Most chargers do not come with a built in power supply, so make sure you have an adequate power supply for your charger. Follow all the charging instructions that come with the charger, and place your battery in a fireproof container or bag. Never leave it unattended while charging.

Batteries have a number of different ratings:

mAh or Ah:  Stand for milliamp hour or Amp hour. this is the capacity of the battery. 1Ah=1000mAh, which means a battery can supply one amp for one hour (or 1000milliamps for an hour)
S and P:       Stand for number of Series cells and number of parallel cells. the number of cells in series determines voltage, parallel determines capacity.
C ratings:     This is how much current the battery can give you. Multiply the battery's capacity in amp hours by this rating to get the current in amps.  There are usually two specified. the lower one is the continuous rating, and the higher one is the pulse discharge rating.

http://multicopter.forestblue.nl/lipo_need_calculator.html

http://ecalc.ch/xcoptercalc_e.htm?ecalc

I usually use one standardized connector for all of my batteries, so that I can use any battery with any device, and can interchange them easily. It doesn't matter what you use, I use the XT60 connectors, just make sure that you have one type of connector for all of your batteries.

Get some silicone wire for your power connections, because it is a flexible, multi-stranded wire that will in general make your life many times easier.

Also often abbreviated as Tx, this is the thing that actually takes your commands and sends your receiver the commands for the servos and the motors.

There are many Transmitters available on the market nowadays, and the low-cost ones start around $30. However, remotes for RC airplane or helicopter pilots, with programmable features, model memory, and computer simulators can start around $150 and go to nearly $3000.

All RC Remotes have a certain frequency that they operate on. Older, analog remotes operate on lower frequencies, which were determined by a crystal. Modern, digital, remotes usually operate in the Gigahertz Range, often at 2.4GHZ.

RC airplane and helicopter remotes have control sticks, which are mostly self explanatory. Usually, one of the two control sticks on an airplane remote is the throttle control stick, and is not spring loaded in the vertical direction, which means it will not spring back when you let go. Remotes are usually available with this stick on either the left or the right side, and are sold as mode 1 or mode 2. RC car remotes have a trigger and a knob to control different things.

Most RC remotes have something next to the Control sticks called the trim. this basically slightly alters the position of your control sticks, and is useful for finely altering the position of the servos, or the starting point of a motor controller. Transmitters also often have reversing, which reverses the output signal of the control sticks. this is usually controlled by a series of switches at the bottom of the transmitter.

The number of channels a remote has shows how many things it can control. For example a three channel remote could control three things, such as three servos, three motors, or a combination of any of those. Motor controllers and servos receive the same type of signal.

Expo, Telemetry, Limited travel and Model memory are all things seen on better, more expensive transmitters, but are not necessary for the average project. Expo stands for exponential rates, so that linear movement of your control sticks will result in an exponential output signal curve. Telemetry transmits information from the vehicle (such as battery voltage, altitude, motor temperature, etc.) back to the transmitter and displays these on the transmitter. Limited travel means that by moving your control sticks to their maximum will only send out a 30% signal, or whatever you set it to. both of these features are beneficial to sensitive mechanisms and airplanes, so that one can maintain better control over them. Model memory simply allows you to store your trim settings in the transmitter, so that you can recall them for later use, or eliminate the need of having to readjust with every time if you have multiple devices. RC car remotes are often equipped with dual rates, expo, memory, and even telemetry.

Most Transmitters need to bind to your Receiver to ensure proper communications. How to do this depends on your Transmitter/receiver.

Many transmitters need 12v to operate, usually supplied by 8AA batteries. this is 8 batteries too many for me, so i got a small, 0.8Ah battery and hooked it up to my remote, so that i only have one battery to worry about, instead of 8 small ones.

A cheap, beginner-level Transmitter that i can recommend from personal experience is the HobbyKing 6S.

The receiver, abbreviated as Rx, receives the signals of the transmitter, and sends them out to the individual channels through PPM, or Pulse Position Modulation commands.

The Receiver must operate on the same frequency as the transmitter, and the two will usually be sold together.  Replacement or extra receivers are commonly available, so that they do not need to be switched out if one has more than one devices requiring a receiver.

The receiver usually receives power from a motor controller, simply by plugging it into one of the signal ports. Servos receive power from the receiver.

The Polarity of the plugs is usually found out by trial and error, in one way it will work, and the other way it probably will show a flashing light or something similar. Make sure to never connect one wire one way and another with opposite polarity to that wire, because depending on what those two things are, they will most likely be damaged, because one is going to be reverse polarity.

Some servo or motor controller connectors have a small plastic tab on them, and can therefore only be used with RC car receivers that can easily be removed with wire cutters.

Be careful with the antennae of digital receivers, because they are rather difficult to reattach.

Read more…

Higher and Faster

More good weather to test the FPV on my quad. I'm quite happy with the GoPro as both the recording and FPV camera. I just need to invest in a better mount with added roll stabilization. Also, as always the copter needs tuning. It has spontaneous wobbles that I need to figure out. I always dread the tuning process since some things seem to have no effect until they do. :P I have logs from the 4 flights I made in the video if anyone has some spare time and would like to look at them. Otherwise, enjoy.

Read more…
3D Robotics

3689457908?profile=originalOnce again, the 3D Robotics team is going to have a big DIY Drones area at Maker Faire in San Mateo this weekend (picture from last year shown--we've got brand new banners this year ;-)). Come meet the team and Arduino leader Massimo Banzi (speaking at 3:00 on Saturday) and me (speaking about multicopter UAVs at 1:00 on Sunday)

We'll all be in the Expo Hall. All the new 3D Robotics goodies will be there and you can chat with the designers. We might even put some birds in the air, space permitting. It's the highlight of the year, so if you're in the Bay Area, don't miss it!

Here's part of the booth, with the new logo/banners:

3689457793?profile=original

Read more…

1st spinning camera footage

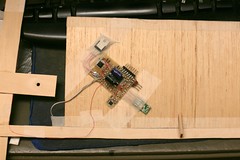
motor17.jpg

motor18.jpg

esc02.jpg


Marcy 2's power plant is overpriced junk from Tower Hobbies.  They didn't send the $1.50 of Dean connectors ordered.

The Castle Creations 6 is really badly soldered.  The 12-30-4110kV Electrifly has incredibly flimsy wires.  It's obviously high flex cable & I should have left the bullet connectors on, but they looked heavier than they were & they easily broke off.

marcy2_34.jpg

marcy2_33.jpg

marcy2_32.jpg

marcy2_35.jpg


She does indeed fly.  Video points nearly sideways.
images01.jpg


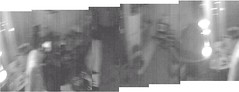
 The 1st images at flight RPM were pretty bad.  A refrigerator & chair are visible.

Instead of hitting head on, the camera scanned diagonally, causing sheering in addition to vertical compression.  At the highest shutter speed, it was still pretty blurry.  Each revolution has 6 frames, so forget about lining up a frame on the same spot.

The test harness was pretty unstable.  A stable attitude would give better results.


marcy2_36

  
images02

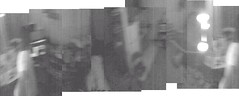
 Camera rotation improved matters.


images03


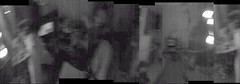
Increasing the camera to 30fps, letting it drop 1/2 the frames, & letting it drop magnetometer samples got more overlap.  If there was a way to automatically align everything, this might work.  Slow scan 640x480 was useless.  The trend is towards lower resolution & higher clockspeed.
images04
images05

Next, we have 160x240 with every frame sent twice to reduce dropped frames & full magnetometer data.  A lion is clearly visible.

images06

Finally, a shot in color 160x240 at 24fps, with 1/2 the frames dropped.  More detail is recognizable to a human, but probably not to a computer.


It's hardly the sharp daylight footage envisioned, but this is a matter of the size of the lens & the sensor quality, not available technology.


Ride on a monocopter

Since the camera is going to point diagonally, it's hard to envision a target it could use for navigation.
mane_attack.jpg

Trying to spin up Marcy 2 outside resulted in the wind taking her off & the mane immediately being attacked.  Untangling required destroying the propeller, since press-on propellers can't be removed.


images07

At least it showed daylight improved the picture quality & a monocopter could be very useful for imaging outside.

 Automatic placement didn't go so well.


images08

 Rotating manually matched a little better, but since the camera was pointing diagonally, it only needed 90 degrees of rotation.  If it pointed straight down, it would rotate 360 deg.
Playing with the Marcy 2 cam showed the realtime 360 deg panorama isn't going to happen.  There's no way to align all the frames fast enough & the information is too noisy to convert to an altitude & position.
Next comes shooting 1 frame per rotation at the highest framerate possible, so the 1 frame can be as close to the same position as possible & capture the highest resolution in the direction of rotation. 

There's no way to trigger the camera at any random time. The nearest frame jumps around a lot more as the framerate decreases.  The extra processing for color slows it down by nearly 1/2.
A slower framerate to increase the span of each frame by widening the line spacing was disastrous.  It really needs the tightest line spacing possible.
It can probably go higher than 42fps if only 1 frame per rotation is captured & the frame buffer is diabolically hacked.  40Mhz is the maximum that any home made solder traces ever did.  It's currently doing 42Mhz to get 42fps.
If there was any advantage to using a custom board instead of http://www.8devices.com/product/3/carambola/specs it was the ability to get very high framerates from the camera interface.  A USB webcam on the Carambola would be real slow. 

  The coning angle is a lot steeper than expected, making pointing straight down hard.

Now some useful commands for accessing Marcy 2 without compiling a wireless network driver on every computer.

iptables -t nat -A POSTROUTING -j MASQUERADE
echo "1" > /proc/sys/net/ipv4/ip_forward

on the computer with the network driver.

route add 192.168.0.1 gw amazon

on the computer with the ground station.
marcy2_31.jpg
That there is a board so badly designed, it's nothing but rework.  The mane shock was a TO-252 had the lowest current capacity of all the LM317 packages & this board uses a lot of current.  If money was infinite, a low dropout regulator would be used. 
mag27.jpg
marcy2_28.jpg
After many experiments, it turned out the STM32F4 I2C core sux.  Software I2C solved the timeouts & it may be ignoring the ACK was the key to RF robustness.  Software also went a lot faster.  The hardware I2C may have added delays somewhere, to comply with the spec.

No matter how high the clockspeed, hardware I2C never could get over 64 samples/sec.  Software could do 120 samples/sec.  Video framerate had to drop & the DCT needed a lot of I2C polling between those raster lines.  10k pullup resistors were necessary.  The STM32F4 has 50k pullups.
screenshot01.png

  There's something you never thought would happen.  Full telemetry & video over wifi.  Depending on the video detail, it'll go up to 4 megabits.  It's not as much telemetry as a quad copter, but the 2.4Ghz bitrate is slightly higher.

Read more…
3D Robotics

3689457883?profile=original

From New Scientist (via SAUSNews), a report on the fatal UAV accident in South Korea last week:

In a statement supplied to New Scientist, Schiebel says its Camcopter S-100 drone, a 150-kilogram rotorcraft capable of 220 km/h flight, should have coped in any case because GPS can be lost for many reasons, such as an inability to access the positioning satellites due to obstruction by high buildings. The Camcopter has multiple inertial measurement units that “allow safe operation and recovery in the absence of GPS signals” the firm says.

“All information recovered to date indicates that after a loss of GPS signals to the aircraft’s receivers incorrect handling and omissions over a time period of a number of minutes, resulted in an unfortunate chain of events that ultimately led to the crash,” the statement says. Emergency procedures “to ensure a safe recovery in such a situation” do not appear to have been “correctly and adequately followed” it alleges.

The Schiebel aviation engineer who died – a 50-year-old Slovakian with much experience of the technology – was assisting two remote pilots working for one of Schiebel’s South Korean partners. He was not in control of the aircraft, the firm says. It’s thought the Camcopter was being tested for new duties in border operations.

The accident aircraft had been used by the South Korean authorities since 2008 to police major events – such as the 2010 G20 summit in Seoul, says a Schiebel spokesperson.

Read more…

FPV Blessing in Rio


I don't usually post my FPV videos here, but I think this one is special and worth sharing.


I think I've been dreaming about flying around Cristo Redentor since I started FPV. Based on the comments I got, I was not the only one... But I began to plan it seriously when I moved back to Rio a few months ago.

The plan and wait was worth it: this was one of the most exciting flights I have ever done! The weather was great and I was lucky enough to find the right amount of clouds to make it more mystic without compromising the light.

About air traffic:
- I was authorized to take off by the helipad operator, after confirming by radio that no other aircraft was in the area. 

- The flight was very early in the morning, before air traffic begins. So the absence of aircrafts in the area was not by chance.

- I flew within 500 feet of the ground/mountain at all times, where manned helis and airplanes are not allowed to get;


The airplane is an electric foam Skywalker with GoPro Hero Camera, Eagle Tree OSD Pro with Artificial Horizon Indicator and emergency Return to Launch, Futaba PCM RC on 72Mhz, video link on 1.280Mhz and Fatshark video Goggles. I had over 200 successfull flights with this gear, before daring to go there.


Cheers! 

Read more…

Tricopter made by dummies [Part 1]

Prelude :

3689457648?profile=original

Hi folks

This is the short version of a very long story about how to create a Tricopter from almost nothing. A story of trial and error, frustration and hard time. Maybe this story will allow future people to make less mistake than I have done myself (with some help by a friend).

Before the Tricopter Project

Before the tricopter project, I have tried to create an RC Airplane from scratch by using Pine Wood and plywood. All my « flight  hours» were made by using an RC flight simulator, it's difficult to find other RC pilot where you live far away from civilisation, so it make that easy to find desert place to do RC safely. Sometime we need to learn how to run before knowing how to walk.

This Twin Motor was an epic fail, it flew almost 10 seconds so that was funny the time it flew. Also I cut myself seriously with the propeller (meaning 1:30h of road + wait 4h at the hospital at 10 P.M (tip : ensure the motor is correctly fixed before playing with throttle ;)    ))

3689457710?profile=original

Tricopter, the genesis

After this fail, it remain all material from the first project so because of my extraordinary manual handcrafting skill I decided to make something that need almost no skill.

  1. ¾ inch square wood bar

  2. A strange plastic (from a friend)

  3. Arduino Mega (not bought for this project)

  4. A 6DOF IMU3000+AD345 IMU Fusion I2C

  5. 15 kg/cm Servo Motor (a little bit overkill I agree)
  6. 3S 5A LiPo
  7. 3x Tower Pro 180 Watt Motor
  8. 3 x Tower Pro 25A (no I2C modification)

LED strip (yes, I love that)

Tricopter, the frame Mark 1

3689457548?profile=original

Second ugliest thing you have ever seen in your life

3689457726?profile=original

Third type encounter (this photo is also a strange piece of luck)

Tricopter, the onboard electronic


That's the first time I'm using an I2C board, I hope it will work the first time ..... I was fool, after an impossible quantity of trial and connection test it worked but I don't know why so it work since this time. I also lose hour trying to get data before I have realized the sample code was buggy (char instead of byte, I feel so stupid).

The hard part is done, the easiest part begin, write a stabilization software (evil laugh from the hell .... ;)  ).

Okay, the only way to get PPM from receiver is by using interrupt, according to the Arduino Mega documentation there are only 6 interrupt pin on almost 54 pins (yes that's before discovering ISM work on every pin, arduino documentation was written by evil people :)    unfortunately, I'm not an electrical engineer (far far farrrr)).

Generate PPM pulse, I'm using Servo.h modified for 100 HZ update rate. I have discovered we can use Timer to generate PPM so what I have tried didn't work so I have another idea to make it work better. I still use servo.h for Mark 1.

Stabilization software

After reading many thread on the Internet, I have discoved PID controller, easy to code but less to tune. According to the IMU documentation, it is 65 RAW/deg/s so .... that's not true. I have tried hour and hour to find why my code do not work before discovering a lost text somewhere that explain MEMS documentation represent perfect value that may change between two identical IMU chip because of manufacturing process. Okay .... a good thing to know.

I'm using an homemade filter (variable trust complementary filter) for IMU values. I tested it by using a C# program that simulate data with noise, at high noise value stay acceptable so I conclude the algorithm is probably good.

Test phase :

We have a little problem, no one of me or my friend has ever pilot an RC helicopter or see someone in real so like I have already said, sometime we need to learn how to run before learning how to walk ;) (Tony Stark told something like that too about Mark 2). So we need to find a way to test PID without killing ourself (IMAO it's better to keep our structural integrity, but it's just my opinion ;)    ).

Those test happened before I have discover problem with gyroscope

First test :

The power is supplied by 12 volt battery for motors and USB for arduino (still not plugged directly to the battery) It is also attached to avoid killing someone by mistake. (video is down here)

http://youtu.be/DmtETvjz3Z0

Another test :

Having no experience with PID, we have decided to test it by holding the Y using 2 hands and one who control the throttle, we expect to get the tricopter auto sustaining itself in air. Only one motor is running during the test (others are simply not powered)

https://www.youtube.com/watch?v=l3Rvnr1ZQ08&feature=relmfu

Another test :

Roll over, arduino connection were smashed but still functional. We discovers that vibration were too high (very high) motor even with no propeller create hard vibration. Motor do not become hot while running so the motor base become very hot, also one motor suddently stop (no matter the ESC) when it is stressed (fast high/low throttle). I suppose that those motors are not good quality and maybe bearing are bad ?

Conclusion  :

 - Frame is fat (1.45 kg including 3S 5A battery)

 - Motor are bad (very bad quality, just check how they were build)

 - IMU vibration isolation is ........ not good

 - As beginner, we need more protection for propeller

How to fix those problems ?

We have destroyed this frame and we have made a new frame :

 - Using 1cm pine wood 60 cm long arm (9 inch remain to protect propeller in case there is too much tilt)

 - 3 new motors (http://www.hobbyking.com/hobbyking/store/uh_viewItem.asp?idProduct=18229)

 - Improved IMU filter

 - IMU is isolated by using a sponge

 - A real tilt mecanism (inspired from RC Explorer), I was previouly glued directly on the servo motor.

To be continued .... same bat-time, same bat-channel

Preview :

3689457763?profile=original

We can rebuild him...we have the technology

It will be better, faster, stronger

3689457823?profile=original

This is what happen if you crash tricopter very hard on a tree

PS : Thanks to Robert Sinclair for his support ;)

Read more…