All Posts (11086)

Sort by

2012-11-24 MV to All:

I've only just joined the ArduPilot-Mega Opensource Project, and am only just beginning to dig into the codebase.

My goal is to implement a host of enhancements to our beloved APM Mission Planner application.

My cloned repository is named "markevogt-pcl-experimenting".

My first enhancements have now been coded, tested and pushed up to my repo:

1. Flight Data Panel: each of the (6) quickView panels now has black text on a colored background - far easier to see when outside than thin, colored text against a black background;

2. Flight Data Panel: each of teh (6) quickView panels now has UNITS dynamically queried from the MainV2.config[] array, which in turn is dynamicall populated from the APM > Configuration screen. This too is handy when you wish to switch from feet to meters, or from fps to mph !...

Again, this is just a newbie way to start contributing swiftly - work on simple stuff to learn the overall codebase, then progressively tackle more complex enhancements.


Next up: adding the Mission Planner Screen's lovely (large) Zoom Slider control to the Flight Data Screen, so the act of zooming is consistent across The Application...


Feedback is welcome!

Cheers,

-MV

Read more…

Taking the New Bird Out for Turkey Day

Hiking Sweeney Ridge on Thanksgiving morning was a perfect time for testing out my newly completed quadcopter.

This spot in the mountains, 1200 feet over SFO and the Pacific ocean, seemed like a perfect place to test out my newly completed quadcopter and my newly acquired piloting skills. I've been spending hours and hours flying collective pitch helis in a simulator using a PPM-to-USB joystick adapter I built – trying to get past the heading-aligned flying I've done for years now. It's also the first outdoor flight of my new custom quadcopter and my first time with the KK2.0 flight controller too.

3689487895?profile=original


Parts list:

The frame is all carbon fiber: about 1.5 meters of 6mm square tube and two 60x60mm 0.5mm sheets epoxied together. The motors are mounted directly to the motors using zip ties (with hot-glue holding them from sliding off). 

The battery mounts via velcro underneath (with an extra strap just to be safe). I built a modular camera attachment with some spare plastic pieces I had lying around from some cheap ikea curtain mounts. That's right.

3689487948?profile=original3689488023?profile=original3689487822?profile=original

Built / Design process

I picked out these motors for their weight/size/power and figured I could work around their idiotic peculiar design. I sketched out the design, computer modeled the specific dimensions I wanted, then measured everything out to a piece of cardboard (an insert from a new pack of t-shirts). Using foam tape to hold the carbon beams in place I used plastic weld epoxy to sandwich the plates on the top then the bottom. 

3689487972?profile=original 3689488043?profile=original3689487999?profile=original

I'm running with my 3 year old 10A plush ESCs that I reflashed to run tgy firmware. I built a friction-contact programmer out of some wire, a clamp, hot glue, and a servo horn.  I wouldn't actually recommend doing this anymore, hobbyking sells these now (480Hz update rate out of the box) although I haven't tried them. 

20121112222518.jpg

Read more…
3D Robotics

Drone Olympics in San Francisco on Dec 1

3689487881?profile=originalI'm really looking forward to the Drone Olympics, which will be held on Dec 1st at Groupon's offices in San Francisco. I'll be one of the judges. 

Here's the description of the event:

Drone Olympics is a NodeCopter-Style programming competition powered by drones and JavaScript. Hackers will receive one Parrot AR Drone 2.0 so they can work on their project. Here is one of the drones in action. The day of the event hackers will get a chance to present their work to other attendees and judges. Judges will select the winner(s).


Looking forward to meeting many of you there!

Read more…
T3

global waypoint range for MatrixPilot

3689488154?profile=original

UAVDevBoard users:


MatrixPilot trunk, r1817 now has global waypoint range, provided that:

1. You use absolute waypoints. Specify longitude, latitude, and altitude for each waypoint.
2. Each pair of points in the sequence, including first and last, should be no farther apart than 20 miles.
3. When you engage waypoint control mode, the aircraft must be within 20 miles of the first waypoint.

A couple of things to be careful with:
1. RTL will not work if the aircraft is beyond 20 miles of the RTL point.
2. Be aware of how your Rx failsafe works.
3. It is highly recommended that you do ground testing with HILSIM before any long mission.

Also, please be aware of, and comply with rules and restrictions that apply to you. If it is not possible for you to actually conduct a long mission, you still might want to conduct simulated flights.

Regarding failsafe, for a long mission you should set your Rx failsafe up to simply maintain waypoint mode, with trim values for all control surfaces, and maximum throttle.

Also, when you plot your flight log, ignore the IMU path, plot GPS only, because the IMU path will wrap.

The above flight track is for a 40 minute HILSIM test flight of a Boeing 747 which took off from Schenectady County Airport in autonomous mode, flew around Saratoga lake, then flew south toward New York City at about 400 miles per hour, west over the Catskill Mountains toward Binghamton NY, then back to Saratoga Lake, NY.

Keep in mind that versions of MP prior to r1817 will not work properly if any of the waypoints are farther than 20 miles from the origin. I have verified that to be the case with HILSIM.

I would eventually like to relax all waypoint range restrictions. I am not sure when that might be, but I will make an announcement when I do that. It does not look like it will be very hard to do, It will simply require several 32 bit integers in places where we are now using 16 bit integers, and a few 64 bit integers instead of 32 bit.

Best regards,
Bill Premerlani
Read more…

UDrones Holiday Sale!

3689488132?profile=original

We've got some new cool discounts on Multicopters, starting today through the end of the year!


                                                                                                              LIST PRICE                  SALE PRICE

ArduCopter 3DR Hexa RTF + *FREE Replacement Kit (Crash Kit)                 $899.99                          $765.00

ArduCopter 3DR Quad  RTF +*FREE Replacement Kit (Crash Kit)                 $799.99                          $599.99

Crash Kit Pics


ALSO JUST FOR THE WEEKEND!


                       PLUS! Save $50 OFF on Hexacopter          Valid 11/22/2012 - 11/28/2012


3689488095?profile=original


Have a safe flight!

Read more…
3D Robotics

3689487904?profile=original

We're delighted to announce the new APM 2.5+, which is the same APM 2.5 board you know and love but surrounded by lots of new goodness!  Now, for a new lower price of $179, it comes with all this, right out of the box:

  • 3689487855?profile=originalThe new APM 2.5 enclosure, available in both top pin (above) and side pin (right) styles. It's designed to keep your electronics safe while looking great at the same time! The enclosure is made of black translucent ABS plastic so you can see the board's LEDs. It protects your electronics while allowing access to all pins and connectors. The inside of the enclosure is lined with ESD safe open cell foam to ensure the barometric pressure sensor is surrounded by static air and prevent unwanted readings due to airflow over the sensor. And the screws that secure the enclosure have been moved to the top for ease of use. It's also available as a stand-alone product for $4.99. (customers who already have an APM 2.5 are eligible for a coupon code to get a free enclosure with their next order. Email sales@3drobotics.com if you don't already have one)
  • 3689487915?profile=originalThe new APM Power Module, available with either XT60 (shown) or Deans connectors. It's a simple way of providing your APM 2.5 with clean power from a LiPo battery as well as monitoring current consumption and battery voltage measurements, all through a 6-pos cable that plugs in neatly. The board is also shrink-wrapped to protect it (the bare board is shown here so you can see the innards). Been wondering what that "mystery connector" was on APM 2.5? Now you know! This will ensure that you have no brown-outs due to insufficient BEC power from your ESCs, and makes current and voltage monitoring easy! It's also available as a stand-alone product for $24.99
  • 3689487864?profile=originalOur new Version 2 of the Mediatek GPS module. This takes all the learning we've had with the Mediatek over the past two years and wraps it up in one vastly improved product. New big ground plane antenna to improve reception! On-board battery for fast lock! New firmware for better performance and datalogging! Also available as a stand-alone product for $37.95.

Oh, and did I mention that we also lowered the price of APM 2.5 by $20 at the same time?? This is all thanks to our new production facilities in Tijuana, which allow us to make an increased volume of products at higher quality and lower prices. We're even adding a new Manncorp four-head pick-and-place machine there to handle even higher volume!

Read more…

APM - Open Source Examples

It is possible to explore and use the APM hardware without having to adopt the ArduPilot or ArduCopter code.

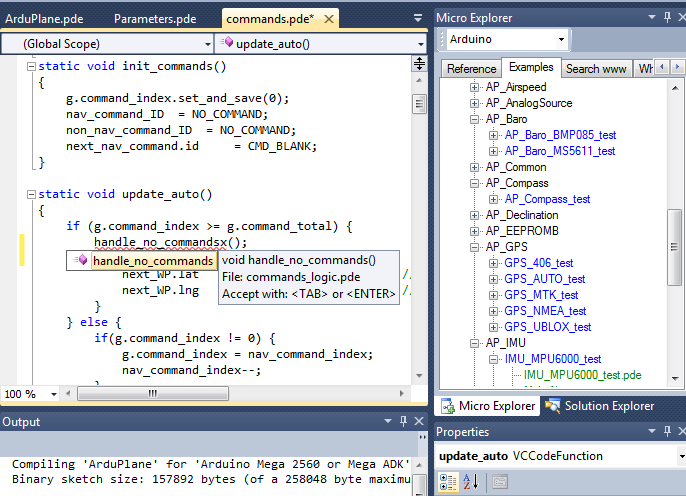
ArduPilotMicroExplorerExamplesAndIntellisenseCodeCorrection.png

The DIYd open source community has provided a full set of examples which enable us to easily see how each hardware element works.

These examples will be found on the "File" menu in the Arduino IDE, or in the "Micro Explorer" in Microsoft Visual Studio.

There are a few additional benefits of the Visual Studio system compared with the Arduino IDE such as the ability to explore examples without the need to create a new project. This becomes very useful if we are writing or extending drone software and a quick reference guide.

Arduino for Visual Studio Professional is free

Read more…
3D Robotics

$1250 RTF UAV for autonomous GoPro filming

3689487729?profile=originalI can't understand how a foam wing with a simple RTL autopilot (not including GoPro) costs $1,250, but that's what Lehmann Aviation from France is now offering. What am I missing?

From Gizmag:

Like the Swinglet CAM UAV, the LA100 follows a pre-programmed flight path, but unlike the Swinglet, the LA100's flight path can't be customized or overridden by remote control. This is because the aircraft is targeted specifically at users with no piloting background. After a few minutes of capturing footage from a height of 80 to 100 meters (262 – 328 ft) with no input from the user on the ground, the hand-launched LA100 returns to the launch site for a horizontal landing.

The LA100 is a hand-launched UAV

With the ability to fly at speeds of 20 to 80 km/h (12 – 50 mph) for periods of up to five minutes, the LA100 has a range of up to 0.5 km (0.3 miles). It can also fly in winds of up to 45 km/h (28 mph) and in temperatures from -25° C to 60° C (-13° F to 140° F). The UAV has a wingspan of 92 cm (36 in) and length of 45 cm (18 in). Made mostly of foam and carbon fiber, the LA100 weighs around 850 g (30 oz), including a mounted GoPro camera.

A camera can be mounted on top of the wing to capture oblique images or at the bottom of the wing for vertical images. It can also fly with two GoPros on board at the same time. However, buyers will have to supply their GoPros as they aren't included in the purchase price.

The LA100 is priced at €990 (US$1,275) and will come ready to fly from December, 2012. Lehmann Aviation says it plans to roll out hardware and software upgrades for the LA100 on a regular basis.

The video below shows the LA100 and some of the aerial images captured with it.

LA100 UAV from Lehmann Aviation on Vimeo.

Read more…
3D Robotics

3689487742?profile=original

I like the sound of this, from the Kickstarter project we covered earlier: "The development team has promised to release the source code for the Linux/Mac/PC software and mobile apps, all protocols, and available hardware schematics under open-source licenses."

From Gizmag:

The actual helicopter being sold as part of the Puzzlebox Orbit package may look somewhat familiar to Gizmag regulars. The protective outer sphere that prevents the rotor blades from impacting with walls, furniture, floor and ceiling is very similar in design to the Kyosho Space Ball we covered last month. It's not the same craft though, and the ability to control it with the mind is not the only difference.

"There's a ring around the top and bottom of the Space Ball which isn't present on the Puzzlebox Orbit," Castellotti told us. "The casing around their server motor looks quite different, too. The horizontal ring at-mid level is more rounded on the Orbit, and vertically it is more squat. We're also selling the Puzzlebox Orbit in the U.S. for US$89 (including shipping), versus their $117 (plus shipping)."

Two versions of the Puzzlebox Orbit system are being offered to the public. The first is designed for use with mobile devices like tablets and smartphones. A NeuroSky MindWave Mobile EEG headset communicates with the device via Bluetooth. Proprietary software then analyzes the brainwave data in real time and translates the input as command signals, which are sent to the helicopter via an IR adapter plugged into the device's audio jack.

This system isn't quite ready for all mobile operating platforms, though. The team is "happy on Android but don't have access to a wide variety of hardware for testing," confirmed Castellotti, adding "Some tuning after release is expected. We'll have open source code available to iOS developers and will have initiated the App Store evaluation process if it's not already been approved."

An EEG headset communicates with the mobile device via Bluetooth, software analyzes the in...

The second offering comes with a Puzzlebox Pyramid, which was developed completely in-house and has a dual role as a home base for the Orbit helicopter and a remote control unit. At its heart is a programmable micro-controller that's compatible with Arduino boards. On one face of the pyramid there's a broken circle of multi-colored LED lights in a clock face configuration. These are used to indicate levels of concentration, mental relaxation, and the quality of the EEG signal from a NeuroSky MindWave EEG headset (which wirelessly communicates with a USB dongle plugged into the rear of the pyramid).

Twelve infrared LEDs to the top of each face actually control the Orbit helicopter, and with some inventive tweaking, these can also be used to control other IR toys and devices (including TVs).

In either case, a targeted mental state can be assigned to a helicopter control or flight path (such as hover in place or fly in a straight line) and actioned whenever that state is detected and maintained. Estimated Orbit flight time is around eight minutes (or more), after which the user will need to recharge the unit for 30 minutes before the next take-off.

At the time of writing, a crowd-funding campaign on Kickstarter to take the prototype system into mass production has attracted almost three times its target. The Puzzlebox team has already secured enough hardware and materials to start shipping the first wave of Orbits next month. International backers will get their hands on the system early next year.

The brain-controlled helicopter is only a part of the package, however. The development team has promised to release the source code for the Linux/Mac/PC software and mobile apps, all protocols, and available hardware schematics under open-source licenses. Step-by-step how-to guides are also in the pipeline (like the one already on the Instructableswebsite), together with educational aids detailing how everything works.

"We have prepared contributor tools for Orbit, including a wiki, source code browser, and ticket tracking system," said Castellotti. "We are already using these tools internally to build the project. Access to these will be granted when the Kickstarter campaign closes."

The Puzzlebox Pyramid has a dual role as a home base for the Orbit helicopter and a remote...

"We would really like to underline that we are producing more than just a brain-controlled helicopter," he stressed. "The toy and concept is fun and certainly the main draw, but the true purpose lies in the open code and hacking guides. We don't want to be the holiday toy that gets played with for ten minutes then sits forever in the corner or on a shelf. We want owners to be able to use the Orbit to experiment with biofeedback – practicing how to concentrate better or to unwind and relax with this physical and visual aid."

"And when curiosity kicks in and they start to wonder how it actually works, all of the information is published freely. That's how we hope to share knowledge and foster a community. For example, a motivated experimenter should be able to start with the hardware we provide, and using our tools and guides learn how to hack support for driving a remote controlled car or causing a television to change channels when attention levels are measured as being low for too long a period of time. Such advancements could then be contributed back to the rest of our users."

The Kickstarter campaign will close on December 8, after which the team will concentrate its efforts on getting Orbit systems delivered to backers and ensure that all the background and support documentation is in place. If all goes according to plan, a retail launch could follow as soon as Q1 2013.

It is hoped that the consumer Puzzlebox Orbit mobile/tablet edition with the NeuroSky headset will remain under US$200, followed by the Pyramid version at an as-yet undisclosed price.

Read more…
M1-D-thermal-camera-ptz-3-channel-looking-up_002.jpg

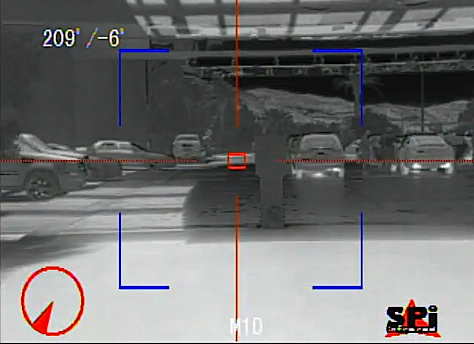
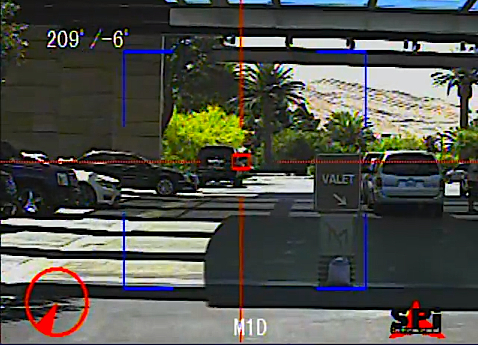
   After arriving in Texas, I've talked to several land owners who complain about feral hogs damaging their property.  I had a solution that would incorporate thermal imaging with a sUAS platform to track hog movement and patterns during the day and at night.  While doing research I came across this little baby, the M1D Micro PTZ Gimbal. 


  I was very surprised at the size, weight, and resolution of this camera.  It uses a FLIR thermal imaging camera that are available in three resolutions, 120x140 being the lowest @ $3900 and 640x480 being the highest at $9500.  I was definitely expecting this to being in the upper teens or low 20's!


It has a very nice CCD camera, Hi-res thermal camera, and focusable laser incorporated in a weatherproof housing.  Being 6" tall, 4.5" in diameter and weighing in around .9 kg, it seems to be a very good solution for a UAS system such as the X8 or similar platform.


The only issue that I have seen along with most PTZ systems in the RS-485 communication.  I'm not a comms expert so I do not know if it is possible to do a P&P setup with the APM 2.5.  I did come across a couple of Xtend 900 RS-485 1W modems that would allow control from a joystick or PTZ control board from the ground.

m1d_PTZ_FLIR_Thermal.jpgm1d_VISUAL_PTZ_FLIR.jpg

Read more…
3D Robotics

3689487768?profile=original

We've got some awesome new products coming out on Friday, along with great discounts as part of our annual DIY Drones store Black Friday Sale. It will start at midnight EST on Thurs (9:00 PM PST) and go through the weekend.


Get ready for a new version of the APM 2.5 kit, with a sleek enclosure, a new improved MTK GPS with a larger antenna, firmware and battery backup. Plus a cool new accessory: a power supply + current/voltage power sensor, all in a tiny board. And all these are now included in the new APM 2.5+, at a new, lower price! (The APM 2.5 itself is unchanged; it just now comes in a cooler, cheaper package).


Also, look for new PX4 kits, including everything you need for this exciting new autopilot. 


Here's a glimpse of just some of the products that will be on sale:


Product List Price Sale Price
XtreamBee XBee adapter board $24.95 $9.99
XtreamBee USB XBee adapter $24.95 $14.99
3DR GPS uBlox LEA-6 $75.99 $49.99
Ardupilot Mega MinimOSD Rev. 1.1 $65.99 $44.99
Dronecell $120.00 $79.99
HMC5883L - Triple Axis Magnetometer $34.90 $23.99
3DR ArduCopter Quad-C Frame Kit $99.99 $49.99
3DR ArduCopter Quad-C Frame + Motors Kit $249.99 $199.99
3DR ArduCopter Quad-C Frame + Motors + Full Flight Electronics Kit $449.99 $399.99
3DR ArduCopter Hexa-B Frame Kit $129.99 $79.99
3DR ArduCopter Hexa-B Frame + Motors Kit $349.99 $299.99
3DR ArduCopter Hexa-B Frame + Motors + Full Flight Electronics Kit $549.99 $499.99
ArduIMU+ V3 $78.90 $49.99
3DR Radio Telemetry Kit - 433 Mhz $85.99 $65.99
3DR Radio Telemetry Kit - 915 Mhz $74.99 $54.99
MediaTek MT3329 GPS V2. $37.95 $27.99


Read more…

Futaba T8J Transmitter Mode Selection

3689487472?profile=original

Just thought I would share my Arducopter mode setup on my new Futaba T8J, as this can be a bit of a headache for newcomers.  The new T8J radio is my new favorite transmitter.  It offers a lot of features that was only offered on the 8FG, but at a fraction of the price.  It doesn't utilize FASST, rather S-FHSS.  With the settings pictured you can get all six flight modes on two toggles.  

First I set my three position toggle to switch C and the two position toggle to switch D, which is changed in the AUX-CHAN menu.  Next I changed my end points on channel five to those pictured below.  Lastly I setup the program mix (under P.MIX1-6 in the 8J menu).  Just dial in the values pictured below.  Maybe this will be of use.  


 3689487668?profile=original

Read more…

Big thanks to the Team!

Just wanted to say thanks to the developers bringing this product out. I love it.

 Today I felt lucky and went to the field for my second ever flight with ardupilot wired to a custom made fixed wing platform for some testing. Since the first flight I connected the pitot and the Xbee at 2.4 GHz for telemetry.

 I was feeling that lucky that decided to try the auto take off, On my previous only flight I only tried manual, circle mode and RTL which seemed to work reasonably well, sure lots of potenital for PID improvement.

So I planed some waypoints inlcuding take off and landing, Set the mode to auto and ...it is a miracle the plane took off (it is a trike setup) run fairly straight on the grass took off and gradually climbed ( I should remember to increase the maximum pitch angle as currently set to 14 degrees only- but better be safe). It was climbing slowly straight away from me going past the first two waypoints but that was due to having to reach the alt at which take off is complete, I had to hold my nerve for a bit cause it flew at least 1km away. Then turned back and completed a circuit of 8 waypoints. It only missed one of them and had to bank steeply to re-get it ( a bit of adrenaline rush there). but other than that pretty spot on especially for a first time circuit.

For some reason it didn't want to land and I couldn't understand what it wanted to do after getting the last turnpoint before landing. I couldn't understand looking at my laptop which was the current waypoint target either, so I  switched to manual and brought it down.

Marvellous stuff guys and thanks so much for getting this out to the masses.

 The next thing I want to do is try to get the plane to take a picture when it reaches a waypoint, ideally I would like to use the IR control camera shutter library for this too, as the goal is to use the setup for aerial photography.

Great 

Read more…
Developer

ArduStation Mega v1.0b arrived

jDrones_ArduStation_Mega_v1.0b_0147_sml.JPG?width=500

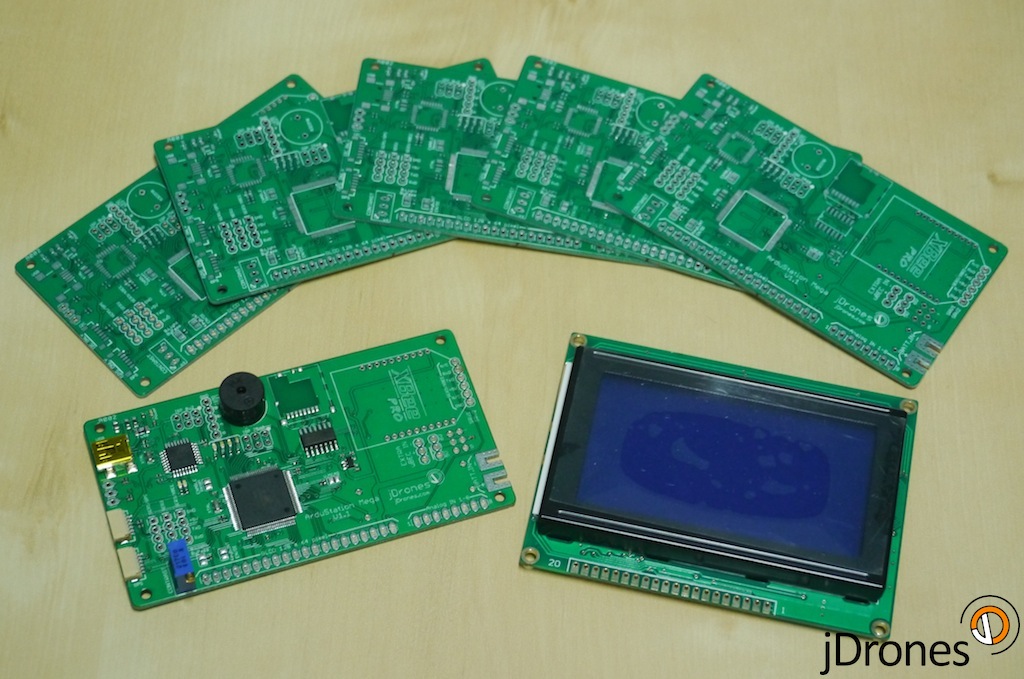
Our ArduStation MEGA boards arrived today and I am truly excited to see how they work. Now starts small assembly job for them and then we can start doing testing for those. 

Big thanks for Colin for his original ASM work, it's great to see what great minds can create. 

New boards looks just awesome. Few connectors are missing but those are quickly soldered. These boards are from the first batch and we have them now small qty in stock. If there are any changes that needs to be made, we will do it and then first production batch will come.

Technical specs:

  • MCU: Atmel 2560 with Atmel 8u2 USB "adapter"
  • XBee footprint for telemetry with external pins
  • IO: Buzzer, Analog, I2C, GPS
  • SDCard holder for storage needs
  • 128 x 64 pixel Graphics LCD
  • 3 x TTL Serial output pins
  • 2 x Servo outputs with internal/external power feed
  • Encoder port for menus etc use
  • Connection for I2C Keyboard 
  • 4 x LEDs for showing different statues

Jani / jDrones

Read more…
3D Robotics

3689487604?profile=original

This sounds very cool. Basically you set up a network of these transmitters in a space, such as a sports field, and multiple multicopters can triangulate off them. Better accuracy than GPS and works indoors and outside.  Found by SUAS News:

The core of this environment is the lpm (local position measurement) of inmotiotec , a radio-basedpositioning system, which can be used both indoor as well as outdoor used. Until now, the Quadrocopter were so dependent on their positioning in GPS receiver and thus operate only under the open sky, with the new tracking system is a thing of the past this limitation.

The new tracking system is a quantum leap in terms of navigation of the aircraft: the positioning improves by a significant order of magnitude compared to the pure use of GPS. Instead of 5 to 6 meters accuracy to get to 5 – 15 cm. If we now also charged that a Quadrocopter has about 30 centimeters in diameter, it quickly becomes clear how accurate it can be flown from now – in other words, the creative department can now play safely.

Today, technology in sports, in the entertainment industry and, indeed, for Spaxels is used. The operation is relatively simple: At least 12 receivers are set up to provide a space and a calibrated reference transponder which must be visible from all 12 recipients. Per second to 1000 position signals are detected, you can fly as in the case of Future Labs with 50 quadrocopters, the position of each aircraft is determined by triangulation 20 times per second, enough data to allow precise trajectories. And in order to save weight divides the transponder’s battery with the respective Quadrocopter on which he sits, energy verso insurance technically is not a problem.

Read more…
3D Robotics

Robo-sailboat competition

3689487341?profile=originalFrom Wired Design (lots more photos here):

Every summer for the past six years, teams of engineering students from around the world have converged on an unsuspecting body of water to hold the SailBot International Robotic Sailing Regatta. The goal of the event is to create an unmanned, wind-driven vessel that navigates through a variety of challenges with limited, if any, human control. In other words, sailing drones. In 2012, Olin College‘s team entered the SailBot regatta as rookies and managed to secure second place. On Friday, the organizers announced that Olin will be hosting the 2013 event.

Why would we want sailing robots? Aside from the beneficial learning experience for everyone involved, there are applications for real-world use. The oceans are vast and it takes a lot of fuel to motor around them, plus life at sea is incredibly harsh. An autonomous vehicle could allow scientists — or spies — to monitor much larger swaths of the seascape, and a sail-powered drone could operate for much longer than a vehicle that needs to carry fuel. On top of that, all the benefits of sending machines instead of people into dangerous environments apply.

Read more…
3D Robotics

3689487451?profile=originalRoberto Navoni's cool ARM CortexM4 board that runs the latest ArduCopter code is now on IndieGoGo. The first 50 will be available for $240. From the listing

The VR Brain autopilot is an all in one board the main hardware features are:

  • 168Mhz ARM CortexM4F microcontroller with DSP and floating-point hardware acceleration.
  • 1024 KB of flash memory, 192 KB of RAM.
  • MEMS accelerometer and gyro, magnetometer and barometric pressure sensor.
  • 6 RC Input standard PPM , PPMSUM , SBUS
  • 8 RC Output at 490 hz
  • 1 integrated high speed data flash for logging data
  • 1 Can bus 2 i2c Bus
  • 3 Serial port available  one for GPS 1 for serial option 1 for serial telemetry.
  • 3 digital switch (ULN2003).
  • Jtag support for onboard realtime debugger.
  • 1 Buzzer output.
  • 1 Input to control lipo voltage
  • Included in the  VR Brain Package there is the GPS module , the module support MTEK 3329 gps .
  • Physical Dimension 60x40x15 mm
  • Will be available a plastic enclosure.
Read more…
Moderator

3689487528?profile=original

By Matthew Schroyer sUAS News

“As soon as I hit the go home mode, because the GPS and compasses were damaged, it went crazy,” Hindi said. “I flipped off the ‘come home’ mode and went into manual control. It wasn’t working right, but we were able to bring it in for a crash landing anyway.”

“I had more control than I anticipated,” he said. “I couldn’t believe it didn’t just drop out of the sky.”

Read More

http://www.suasnews.com/2012/11/19719/activists-drone-shot-out-of-the-sky-for-fourth-time/

Read more…

Hexacopter Project


Hi guys, i want to share my Hexacopter Project.

I designed all the frame parts and cut them out of 2mm carbon fiber in a cnc machine, this is still a prototype, I need to fix a lot of mistakes in a second revision of the frame.


1024.jpg?md=1353372304000&width=545

1024.jpg?md=1353372257000&width=545

1024.jpg?md=1353372286000&width=545

1024.jpg?md=1353372271000&width=545

1024.jpg?md=1353372182000&width=545

1024.jpg?md=1353372232000&width=545


Read more…