All Posts (11086)

Sort by

3689701148?profile=originalExperts agree that best practice is a process known as open-sourcing – a form of crowd-sourcing that brings together software development leaders, external developers and stakeholders in an open and democratic process.

When managed well, open-sourcing results in a product everybody wants to use - perhaps more importantly, it results in a community that is able to constantly update the product as processes change and technologies advance.

But the open-sourcing process doesn't always work out. Sometimes the main software developer becomes too heavy-handed. Or the client company is overly protective. Sometimes there is simply too little interest in the project from the community. So how is this process best managed? What are its ingredients for success?

A recently published paper discusses these issues and is worth a read: http://journal.acs.org.au/index.php/ajis/article/view/1221/667

Read more…
3D Robotics

I was one of the backers of the Pozyx ultrawideband positioning system Kickstarter campaign, and after a pretty bumpy start (although they shipped the product, the software and tech support was pretty terrible for six months), they've finally started delivering on their promise with new firmware and active support and it's now worth considering for indoor (no GPS) drone or rover use. 

From the video above:

In the demo, the Pozyx developers kit is used to accurately track the position of the tag with 6 fixed anchors, with an update rate of 40Hz. The resulting positioning data is directly used by the Unity Engine to move the ball (by reading data through the serial port).

Read more…
3D Robotics

Lego kit makes DIY drones easier for kids

3689701135?profile=originalWhat's interesting about the new Flybrix kit ($149) is that it has an original Arduino-based flight controller. Pretty hard core code (Kalman filters and such) so that might be a little gnarly for younger kids, but the frame looks fun to put together. 

Flybrix Kits come complete with all the components you need to make and fly rebuildable, crash-friendly quadcopters, hexacopters and octocopters from one kit. Flybrix is designed for anyone who is interested in building and flying their own creations.  There's nothing like the thrill of seeing what you made, take to the skies.  The included Flybrix Flight Control App for Android and iOs is easy as 1, 2, 3 to get your designs airborne!

So much more than a toy.

Highly capable hardware and open-source software make for a building, flying, crashing and rebuilding experience that’s not only fun, but also highly flexible; no matter your level of expertise. That’s what makes Flybrix different from typical ready-to-fly drone toys.  It's the ability to experiment, create, customize, and learn in a hands-on way.

Friendly for non-technical makers and new pilots. 

The basic snap-and-go experience has deep play-value.  Simply building and flying stays fresh and engaging time after time, especially as a project that parents can do with kids.  The more you play the more you learn about engineering, physics, design, and geometry. You'll be airborne in a snap!

Tech savvy builders and amateur aviators can get creative - quickly.

Intermediates can dive deeper into the creative experience by designing new airframes and tuning them for flight. The Flybrix Chrome Extension Configuration Software makes adjusting settings and motor tuning easy.  It opens the path of creative problem solving, deeper tuning, flight logic, and control theory.

For true techies and pro pilots, the sky is the limit.

The Flybrix brain is a 96Mhz ARM® Cortex®-M4 processor that's Arduino compatible.  Our custom PCB includes a barometer, a magnetometer, several indicator LEDs, ADC converters, SD card slot and bluetooth.  It's also possible to add Wi-Fi and GPS modules.

The Flybrix code is all open-source, so it’s infinitely tweakable. Add a GPS module, experiment with LQR control theory and alternative state estimation, or wire up some extra LEDs and do some flight-path light painting.  It's fair to say, the sky is the limit. Check out our code on Github.

Flybrix is for the young and young at heart!

Flybrix is designed for pilots 14 years and older.  As with using any drone, adult supervision, following general safety guidelines such as eye protection, safe battery handling, and using common sense is advised.  

Parents often ask if kids younger than 14 can play with Flybrix.  The answer is it's up to the parent to decide.  With younger kids one-on-one parent participation, not just supervision, is required. Flybrix is a fantastic "together time" project where everyone has fun and everyone learns together.   

Read more…

Sense and Avoid for Drones is No Easy Feat

3689701100?profile=original

But development is vibrant, and you’ll see it work first in prosumer drones

THE FACTS:  

“Sense and avoid” for drones is a popular topic in the press right now, but the phrase can mean different things in different contexts and for different people. To clarify, there is a difference between solving the problem of “sense” and solving the problem of “avoid.”  Also, there is a difference between “airborne collision avoidance” (which is what most concerns the FAA) and “obstacle avoidance” (which is the problem that most manufacturers are trying to solve right now). With that in mind, this post looks at what a few manufacturers and software providers are doing to solve obstacle avoidance.

WHAT’S COOL AND WHAT’S NOT: 

DJI – DJI was one of the first to release a drone that could sense and avoid obstacles. In June 2015, they announced Guidance, a combination of ultrasonic sensors and stereo cameras that allow the drone to detect objects up to 65 feet (20 meters) away and stay away from objects at a preconfigured distance. The kit was immediately available for the Matrice 100 drone development platform.  They subsequently incorporated that technology into their flagship Phantom 4 prosumer drone but not their new professional drone, the Matrice 600.  

The Phantom 4 has front obstacle sensors combined with advanced computer vision and processing that allow it to react to and avoid obstacles in its path. The secret sauce for the Phantom 4’s ability to sense and avoid obstacles in real time and hover in a fixed position without a GPS signal is a set of specialized software algorithms for spatial computing and 3D depth sensing. These algorithms are coupled with an onboard Movidius vision processing unit (VPU) that gives the Phantom 4 drone the ability to sense and avoid obstacles in real time. In the “TapFly Mode” of the flight control program, the Phantom 4 obstacle sensing systems are supposed to enable you to fly a path with the drone automatically moving around objects as it flies. But you can find several real-world tests like this one that show it’s not a perfect system.

Intel – Intel is all over sense and avoid, and they accomplish it with active sensors...

Read more here: http://droneanalyst.com/2016/09/22/sense-and-avoid-for-drones-is-no-easy-feat/

Read more…

Fold-up GCS with Android Telemetry

A flexible mission control kit

Thanks to the abundant comments from our friends and the ever growing requirements of our clients, we've been double busy working on some new GCS models for small series and batch production. One of the new models – or rather new versions – is this little kit, which caters for a long list of customer demands collected during the earlier production cycles and in this design phase. The primary goal of this exercise was to create a new station framework that has all the following basic features without unacceptable trade-offs:

  • Man portable system with an absolute total maximum package weight of 12kg
  • Full ground control functions with complete direct RC, live AV and modem telemetry
  • Removable Android based fast and user friendly IT hardware
  • Both wearable "belly box" and seated desk mounted operation
  • External RF box option for pole, tripod, tracker or vehicle mount
  • Belly box no more than 2.5kg, individual transport cases no more than 6kg
  • Easily adaptable control systems for the most popular FCs, primarily APM/Pixhawk/PX4, but also DJI, MicroPilot, etc.
  • Fully customisable controls with dual joysticks, trims, 6+3+3 modular switch and pot locations
  • Single operator basic scenario with the option for additional operators with linked control trays
  • Extremely fast field set-up and disassembly
  • Self contained packages, all antennas, cables and other accessories must fit within the transport cases
  • Self contained field charger option
  • Flexible RF link set-up, 1-3 band operation including COFDM or MIMO links
  • Scalable levels of water and ingress protection, from simple dust proof to full IP (54-67)

3689700845?profile=original

Our previous fold-up type station had a PC tablet installed, which performed pretty well, but we weren't too happy about the Windows GUI or in fact with Mission Planner in this small 8" format. The Android based GCS software packages have come a long way since then, so the time has come to update this wearable belly box framework with a much lighter and friendlier Android tablet.


3689701008?profile=original

Because the Bluetooth telemetry link has also become a de facto standard, there was no need to mount the tablet permanently in its frame for a constant USB connection any more. Neither was it important to charge the tablet from the control tray, especially if we were to use a tablet with one of the longest battery endurances available. Besides, some of our customers noted the need for being able to remove the tablet during waypoint programming, settings tuning and other purposes. However, they still wanted the tablet to be an organic part of the station with its own hood and well secured in place, rather than the flimsy clip-on phone or tablet mounts of other systems. Hence the current slide-in "letterbox" frame, which holds the tablet firmly even when you are just hanging the station all the way down from its handle.


3689700989?profile=original

As this is a fairly long range kit, we used an external RF box to be able to separate the operator from the best antenna location, but for short ranges we can fit all the RF modules in the control tray itself. In that particular case the entire station fits into a single transport enclosure. The downside is that we still need to link the fold-up telemetry frame with the base for the antenna leads, but it's still workable through an energy chain.

The ideal RF link combination with built-in RF modules is just a TBS Crossfire and any old 5.8GHz AV. As the Crossfire will satisfy both direct RC and telemetry modem functions, we can get away with only two antennas on top of the tablet frame in the corners.


3689701030?profile=original

You'll notice the single system cable that links the RF box to the control tray, which is an engineering treat in itself. While it is pretty simple to link these two units when the single RF link is an IP based fully digital high-end system, we do quite a lot of signal conditioning for mixed signal versions at both ends of the cable to eliminate crosstalk. While this unit only needed 5 meters of autonomy from the RF box, we can easily go over 100m of cable without issues using the same technology.

3689700901?profile=original

The noble wood frame is not a flashy detail here, because we have tried and tested at least a dozen different materials for this very purpose. While we have quite the tooling and experience in composite and aluminium CNC end milling, this type of structure was a bit out of our comfort zone. We weren't too happy with the 3D printed versions, with neither their finish, nor their rigidity, and we certainly didn't want to put a boat anchor around anyone's neck by using aluminium as the body of a wearable tray. Our series production batch sizes don't warrant injection moulded parts in this format, either, so my favourite material remained the only option.


3689701074?profile=original

As a personal note, I was a cabinet maker/joiner apprentice before I went to college and later uni, so wood is very close to my heart as a material for anything. As with most other wooden objects or pieces of furniture I've ever made, the surface of the frame is not varnished or lacquered, but treated half a dozen times with tung oil and hard wax. We've found these frames to be lighter and stronger than ABS when made of okoumé, but walnut will be even better.


3689701114?profile=original
P.S.

Some readers of these log entries noted earlier that I only show rather expensive and high-end builds which are unattainable to the average DIYdroner. We started our journey at very much the same level as everybody else, with maybe even less funds living on the other side of the old iron curtain, but we've built a strong team over the years. We still don't shape our gear to fashionable forms as any self-respecting industrial designer would do. We just put the technical substance in ergonomic and practical packages while keeping basic proportions and rules of symmetry, that's all.  

While this kit is still not so much of a consumer grade piece, we are slowly moving towards numbers and new methods of production, so this wouldn't be the case for very long. Next time I'll also be discussing some very simple and practical builds that everyone can replicate or develop, but they still make a big difference in UAV operations.

Read more…
3D Robotics

From NewAtlas:

We have seen a few different takes on Vertical TakeOff and Landing (VTOL) drones over the last few years. The idea behind such approaches is to harness the typically longer range and greater payload capacity of fixed-wing drones and mix it with the superior agility of multicopters, allowing them to take off and land in tight spaces.

Some of these have been developed for military purposes, such as the HQ UAV and the Batwing-like AirMule, but others, like the VTOL Kestrel and SkyProwler are aimed more at hobbyists. In developing the delftAcopter, the researchers have set out to build a drone that can be used to carry medical supplies to tough-to-reach areas.

The electric drone takes the form of a miniature biplane, an aircraft design that uses two wings stacked on top of one another which became popular in the early years of aviation following its success at the hands of the Wright brothers. While some VTOL drones use tilting propellors to switch from vertical to horizontal movement, the delftAcopter itself changes orientation as it makes that transition.

Prior to takeoff, it sits upright with the propellor spinning horizontally, just like a helicopter. Then as it reaches the desired height, it shifts its position by 90 degrees so that the propellor is facing forward and it is thrust in that direction, allowing it to zip along at up to 107 km/h (66 mph). With a 10,000 mAh battery onboard, the aircraft can fly for up to 60 minutes on a single charge.

The delftAcopter is capable of entirely autonomous flight, including takeoff, forward flight transition and landing. It can travel beyond the operator's line of sight and maintain a connection through an Iridium satellite connection, which the researchers actually claim allows it to be controlled from anywhere on the planet.

It uses Parrot's S.L.A.M.dunk developer kit along with a fish-eye stereo camera to gather video, and uses an inertial measurement unit (IMU) and GPS to track its position during flight. The craft weighs 4 kg (8.8 lb) and also features obstacle avoidance and the ability to pick out safe landing zones.

The team is set to put the delftAcopter through its paces at the upcoming 2016 Outback Medical Challenge. The event takes place in Australia and tasks competitors with building an autonomous aircraft capable of retrieving a blood sample from a stranded person located at an inaccessible site around 30 km (18 mi) away.

Drones have emerged as tools with great potential when it comes to search, rescue and disaster relief situations. Various drones have been tested for these purposes in the US, the Swiss Alps and across Africa, a particularly suitable candidate due to rough terrain and the lack of paved roads and infrastructure to move cargo by land. The delftAcopter will have its chance to demonstrate its wherewithal at the Outback Medical Challenge between September 27 to 29.

Read more…

Our company GET (Global Energy Transmission) has built and successfully tested the world’s first prototype hardware that can wirelessly power heavy drones over long distances. The prototype shows, that we can build a cell-tower like power network for drones, so that drones can safely grab enough energy in seconds to fly payloads across the charging network to stay aloft indefinitely or reach delivery destinations. 

The key feature of the technology is a long length flexible transmission cord, which forms area of energy reception with a distance of up to 20 meters from the cord. Separately, each drone should be supplied with special receiving hardware.

The transmission cord concept allows us to offer unique solution for industrial applications since such cord can be placed around the building, construction, or any other object, providing wireless power for drones, which can operate in a 24x7 mode in the dedicated area without recharging. This can be used for monitoring, security and other applications. 

Additionally, using such transmission cord, we aim to deploy charging spots for drones, making wireless power network for them. How it works:

•           Charging spots can be located on the top of the roofs/in dedicated areas

•           Drones can be charged on the fly (over the charging spot and in 10-20 meters from it)

•           During several seconds, drone can grab amount of energy which is enough to jump to another spot in a several miles distance

Key competitive advantages compare with other solutions:

•           Waterproof, works at any weather

•           No necessary of precious positioning

•           Charging multiple drones simultaneously without limitation (up to maximum output power of the transmitter)

•           Preliminary research shows lower costs for manufacturing, installation and usage

We are sure this solution will fully disrupt commercial drone-enabled services, especially for commercial delivery and monitoring.

Check more http://getcorp.com/wirelessly-powered-drone/

Read more…


FFfnpJfPs_wIGKSiFjYvtUcp52yZjocIsr5AyvSZSF1yqSNVEclnwhmUojOsYQvhw-r6VoYVxIVUzFvZKtaT866v75mpZ_uaQb2pIQzuaBgCEwTzfRn_qrXIPm4PxRrxbu7v5Xrx

u-blox NEO-M8P is the smallest high precision RTK GNSS (Real Time Kinematics) module available on the market and TINY RTK is the first global solution for u-blox NEO-M8P. The RTK algorithms are pre-integrated into the module. As a result, size and weight are significantly reduced, and power consumption is five times lower than existing solutions, thus cutting costs and improving usability dramatically.

Following a high demand for an integrated solution for UAV users, we jointly achieved with u-blox and PX4 a version specially designed for this purpose : TinyRTK Drone Edition. The boards include patch antennas and a battery-powered base. Base can stream differential data to ground control station through a BLE module.

KEY FEATURES :

  • Centimeter‑level GNSS positioning for mass market, based on U-Blox M8P

  • Integrated Real Time Kinematics (RTK) for fast time‑to‑market

  • Smallest, lightest, and best energy‑efficient RTK module

  • Receiver type: 72-channel GPS L1 , GLONASS L1, BeiDou B1, GALILEO E1

  • Nav. update rate: up to 8 Hz

  • Position accuracy: 2.5 cm

  • MAVLink protocol encapsulation through u-blox NINA-B1 Bluetooth Low Energy module

  • Connectors: USB, JST-GH

  • Compass : HMC5983

  • Power : LiPo 1S compatible / USB with integrated charger

  • Size: 50 x 50 mm

  • Weight : 24g


3689700944?profile=original

Why this architecture?

  • it is small and consumes little energy

  • base can be standalone, wireless, rechargeable and located on a good sky view spot regardless of ground control station's position

  • base is compatible with 1S LiPos, rechargeable by USB with integrated charger

  • rover module is supported by Pixhawk

  • base module : encapsulation within MAVLink protocol is under development (some developers have already got our boards, we will keep sending them to all)

  • rover includes a compass (HMC5983)

  • patch antenna included to avoid additional integration costs


Support us in our Indiegogo campaign and do not hesitate to ask any question !


Drotek Team


Read more…

The Good Drone: New book out

3689702148?profile=originalA new volume, The Good Drone, has just been published with Routledge, edited by Kristin Bergtora Sandvik (Research Professor in Humanitarian Studies at PRIO and Associate Professor at the Department of Criminology and Sociology of Law at the University of Oslo) and Maria Gabrielsen Jumbert (Director, Norwegian Centre for Humanitarian Studies and Research Director at PRIO).

In addition to contributions by Sandvik and Jumbert, it includes chapters by Susanne Krasmann (University of Hamburg); John Karlsrud (NUPI) and Fredrik Rosén (Danish Institute for International Studies); Kristoffer Lidén (PRIO); Brad Bolman (Harvard University); Serge Wich (Liverpool John Moores University), Lian Pin Koh (University of Adelaide) and Lorna Scott (freelancer); and Mareile Kaufmann (UiO/PRIO).

While the military use of drones has been the subject of much scrutiny, the use of drones for humanitarian and other "good"
 purposes has so far received little attention. This innovative new volume aims to explore that gap.
The many possibilities for the use of drones are recognized and taken seriously by the contributors to this volume through their critical examination of the difference that the functionalities of drones can make, but also what difference the presence of drones themselves – as unmarked flying objects – makes. The implications for the drone industry, user communities, and the areas of crisis where drones are deployed are discussed and analyzed.

Read more…

Creating a Mesh Network With Drones

3689700813?profile=original
Operating in remote areas can present challenges in communications. In areas with weak or non-existing communication networks, large changes in elevation or obstacles, one must look for other purposes of establishing communications. Where there are no towers, drones can be used to set up temporary communication networks.


However, the limited flight time of drones can cause problems in these cases. For this purpose, a tethered drone system can be used. The tethered drone system uses an intelligent winch system that powers the drone from the ground, allowing the drone to stay up in the air for extended periods of time due to the system no longer being reliant on a battery.


Below you can find a video demonstrating the capabilities of UgCS ground control software working together with Rajant BreadCrumb® modules to create a mesh network. This setup can be used to quickly and easily establish a multi-node network using drones. It allows sending flight data as well as video stream to a ground control station operator from multiple drone operators in the field.


For more information and inquiries on the system please contact ugcs@ugcs.com

The newest version of UgCS ground control software can be downloaded here: www.ugcs.com

Safe flights,
UgCS Team

Read more…

3689700590?profile=original

A climb-glide routine can potentially yield a useful increase in range compared with the same airframe/propeller/motor combination operating straight-and-level at best range speed point or best endurance point respectively.

Let me explain briefly with graphs of the results how I have come to that conclusion, at least theoretically so far, hopefully including some useful detail on the method of my calculations and models.  I intend to experimentally validate this concept at some point with my APM-powered Skyfun, so I have tailored this example with measured and guestimate data as best I can for this style and size of UAV.  The propeller is oversized compared with what is normally run on the Skyfun (8" vs 5-6") due to the non availability of data at the smaller sizes.

Best Endurance Steady-state Flight

Firstly, we look at the airframe drag power curves as a function of airspeed. For this model a simple Prandtl model of an aircraft is used. The form drag power and induced drag power combine to form a "U"-shaped total drag power curve with a minima representing the best endurance point (lowest power consumption). The point where a tangent line to this drag power curve passing through the origin touches the curve, (or, in the case of head or tailwind components, with the origin point offset in the speed axis by the appropriate offset) yields the minimum energy consumption per unit distance - i.e. best range speed. This is all valid for steady-state, straight-and-level operation and is only considering aerodynamic power absorbed.

70939574?profile=RESIZE_1024x1024Adding in the propeller and electric motor models to the calculation, we can estimate the shaft power and electrical power consumed to overcome this aerodynamic drag.  The propeller model is a regressed 4th order polynomial surface model based on UIUC propeller data The efficiency curve for an 8x6" APC-E propeller shown here shows how the polynomial model compares with the UUIC data.  This model is actually two models -  one for thrust coefficient and one for power coefficient.  It isn't a perfect model by any stretch, but it allows an analytical solution for the overall modelling process.

3689700531?profile=original

The electric motor is modelled as a first-order model as described by Mark Drela

The motor Kv was estimated to give a voltage requirement for a 25% climb gradient at 28.5m/s of approximately 14.8V (4S battery pack assumption). This is somewhat arbitrary and the assumption does influence the motor efficiency somewhat, but it also gives a realistically useful top speed estimate of 33-34m/s. It is possible to optimise the motor efficiency in cruise a fraction further by manipulating the Kv value, but only by choosing to compromise climb and max speed performance. The motor model used yields a peak efficiency of a realistic 81%

3689700605?profile=originalHaving modeled the propeller and the motor, these two power curves sit respectively above the aero drag curve by an amount representing the successive inefficiency of each of these processes.  The minima of the electric power curve now yields the best electrical endurance speed and, likewise, the tangent point for best electrical range speed. Note that both points are at somewhat increased airspeeds - something to bear in mind even for straight and level operations!

3689700544?profile=originalJust for interest, here below are the propeller and motor efficiency curves for steady-state flight.  It shows clearly some of the compromises of steady-state operation where the efficiency points of the electric motor and propeller are obviously not co-located. Notice too that increasing speed increases the total propulsion efficiency, excepting that the gain here is subsequently lost in airframe drag.

3689700661?profile=original

System Efficiency during Climb

If we now add a climb (vertical) velocity, then knowing the airframe mass (in this example specified at 1kg), we can quite easily calculate the additional power required to climb and add this to the net thrust power. Not forgetting to correct for the increased hypotenuse speed of the climb gradient, this generates a new thrust value the propeller needs to generate, hence a higher propeller speed, more shaft power and therefore more electrical power. This is shown in the following graph, where the best range climb point (curve minima) is clearly visible. A key point to understand is that much of the extra power expended is being stored in a potential energy "battery". (PEB). There are some subtleties here that I have not modeled, since increasing climb angle transfers some of the airframe lift duties to the propeller thrust. I initially attempted to do the vector math, but quickly threw it in the too-hard-for-now basket, however I may revisit this. I do suspect the effects are small and potentially favourable.

3689700708?profile=originalNote how the best range speed during climb is faster than at straight-and-level.  This is useful because it compensates for the climb angle reducing the horizontal speed and also helps offset the slower best L/D speed during the glide period.  In this example, as we will see in the calculations below, the net horizontal speed (but not necessarily ground speed) is within a bull's roar of the best range speed when straight and level.

3689700626?profile=original

Glide Performance

For this modelling exercise, I have assumed, reasonably enough, that the glide mode will be at best glide ratio, which in this case is about 8.5:1. The second graph above shows the peak L/D to be coincident with the best range speed from the airframe drag power curve - no voodoo in that, really.

It's worth noting that optimal glide performance will only be achieved with a stopped propeller (or, ideally a folded propeller!). With a fixed propeller this will probably require the continuous use of the ESC brake function which may consume some power. Such are the differences between theory and practice.

Combining Climb and Glide Modes

For the horizontal speed calculations, we need to correct the airspeed to consider only the horizontal component to make valid comparisons with straight-and-level flight. Using the example of this study, this takes the best range climb speed of 18m/s at 15% gradient down to 17.46m/s horizontal speed and for the 8.5:1 glide, 15m/s to 14.89m/s. To compare directly with straight-and-level operation, if we take a climb-glide cycle, the average speed is 15.7m/s - fractionally slower than the 16m/s straight-and-level cruise. The electrical energy consumption is assumed to only occur during the climb phase, so factoring this over the whole climb-glide cycle (working in energy units/unit distance or J/m) gives an average energy consumption of 2.18J/km compared with 2.50J/km when travelling straight-and-level - a 12.7% decrease in energy consumption or a 14.6% increase in range.

This isn't actually the optimal case as calculated by this model. The 25% climb gradient yields a slightly better 15.2% increase in range, but since this model doesn't include the battery discharge efficiency, we can't be sure this really is optimal.

Note that it is now possible to trade this range gain off in the glide phase to recover or even increase the average speed over the straight-and-level condition. The choice is yours!

Where do the Efficiency Gains come from?

If we plot efficiency curves for propeller and motor together it becomes immediately clear that the vast majority of the efficiency gain is found in operating the electric motor closer to its peak efficiency. It must be emphasised that this is for this case only! Other airframe, motor and propeller combinations will move this around.

Indeed it opens the possibility of re-sizing the motor in lieu of climb-glide operation, however this will most likely limit the maximum power output of the motor, limiting climb rate and making take-off difficult without applying additional measures.

3689700713?profile=original

Summary

This was prepared for my own curiosity, but I hope that it can shed some light on the possibilities that relatively simple modelling can offer in helping to optimize a fixed-wing UAV. All this was done using MS Excel, including the regression analysis of the propeller model.

I am in no way claiming that climb-glide is the best solution for everyone's application. Merely that it is a way to improve the energy efficiency of the relatively simple hardware set that most people adopt for their UAV's.

Read more…

RTK on Arducopter in Loiter Mode

Watch how Tersus GPS RTK works on Arducopter in Loiter Mode.

Great work from Michael Oborne and his Ardupilot Dev Team and thanks for the sharing.

Stay tuned. The latest Precis-BX316 RTK board which supports GPS L1L2/BDS B1B2/GLONASS G1G2 and with GPS L1L2 heading mode is coming soon. One of the spotlights is camera shuttle synchronization feature. Want to get more? Drop us a line to info@tersus-gnss.com. 
Read more…
3D Robotics

Wirelessly powered quadcopter

There have been a lot of quadcopters that get power wirelessly with lasers, but this is the first one I've seen at small scale that uses radio. From Hackaday:

[Sam M] wrote in with a quick proof-of-concept demo that blows our socks off: transferring enough power wirelessly to make a small quadcopter take flight. Wireless power transfer over any real distance still seems like magic to us. Check out the videos embedded below and you’ll see what we mean.

What’s noteworthy about this demo is that neither the transmitter nor the receiver are particularly difficult to make. The transmitting loop is etched into a PCB, and the receiver is made of copper foil tape. Going to a higher frequency facilitates this; [Sam M] is using 13.56 MHz instead of the kilohertz that most power-transfer projects use. This means that all the parts can be smaller and lighter, which is obviously important on a miniature quadrotor.

wirelessly-powered-quadrotor-uylhy8abhiqmp4-shot0009High-frequency power switching puts real demands on the transistors, though, and the one [Sam M] is using is cutting-edge and specifically designed for this application. You’re not going to get far with junk-bin parts at high frequencies. In fact, the whole inverter that drives the coil is a custom design, and is extremely well detailed in [Sam]’s research paper, available here. (PDF)

High-power and high-frequency can still benefit from having a wire to run along, but transmitting a few watts across thin air like this is a sweet demo. Thanks for sharing, [Sam]!

Read more…
3D Robotics

Training autonomous cars with Grand Theft Auto

This is super cool -- training with scaleable simulations is the future of robotic AI.  From Hackaday:

For all the complexity involved in driving, it becomes second nature to respond to pedestrians, environmental conditions, even the basic rules of the road. When it comes to AI, teaching machine learning algorithms how to drive in a virtual world makes sense when the real one is packed full of squishy humans and other potential catastrophes. So, why not use the wildly successful virtual world of Grand Theft Auto V to teach machine learning programs to operate a vehicle?

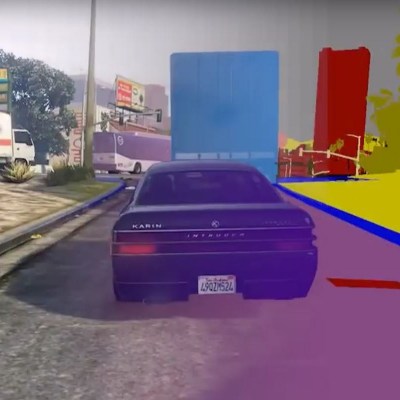
Half and Half GTAV Annotation Thumb

The hard problem with this approach is getting a large enough sample for the machine learning to be viable. The idea is this: the virtual world provides a far more efficient solution to supplying enough data to these programs compared to the time-consuming task of annotating object data from real-world images. In addition to scaling up the amount of data, researchers can manipulate weather, traffic, pedestrians and more to create complex conditions with which to train AI.

It’s pretty easy to teach the “rules of the road” — we do with 16-year-olds all the time. But those earliest drivers have already spent a lifetime observing the real world and watching parents drive. The virtual world inside GTA V is fantastically realistic. Humans are great pattern recognizers and fickle gamers would cry foul at anything that doesn’t analog real life. What we’re left with is a near-perfect source of test cases for machine learning to be applied to the hard part of self-drive: understanding the vastly variable world every vehicle encounters.

A team of researchers from Intel Labs and Darmstadt University in Germany created a program that automatically indexes the virtual world (as seen above), creating useful data for a machine learning program to consume. This isn’t a complete substitute for real-world experience mind you, but the freedom to make a few mistakes before putting an AI behind the wheel of a vehicle has the potential to speed up development of autonomous vehicles. Read the paper the team published Playing for Data: Ground Truth from Video Games.

Before you think this could go horribly wrong, check out this mini-rally truck that taught itself how to powerslide and realize that this method of teaching AI how to drive could actually be totally awesome. Also realize that this research is just characterizing still-images at about 7 seconds per image. This is more than a couple orders of magnitude faster than real-world images — great for learning but we’re still very far away from real-time and real-world implementation.

We really hope that a team of research assistants were paid to play a lot of GTA V in a serious scientific effort to harvest this data set. That brings to mind one serious speed-bump. This game is copyrighted and you can’t just do anything you want with recordings of gameplay, and the researchers do mention that gameplay footage is allowed under certain non-commercial circumstances. That means that Uber, Google, Apple, Tesla, every major auto company, and anyone else developing autonomous vehicles as a business model will be locked out of this data source unless Rockstar Games comes up with a licensing model. Maybe your next car will have a “Powered by GTA” sticker on it.

[MIT Technology Review via Popular Science]

Read more…

3689700479?profile=original

Yesterday Was the first successful transition flight of my Nano Quadplane.  After limited success a few years ago with two separate pixhawks on the VTOL Anaconda, I decided it wasn't feasible to use multiple Pixhawks/Pilots for anything other than a tech demo.  

Now with all of the work done by the Devs for creating the quadplane code (awesome work gents!), I was inspired once again to make something that worked as seamlessly as imagined back then.  I knew there would be challenges and a large margin for failure, so I chose a small EPP plane to minimize damage and rebuilding. Turns out I don't think I've ever seen a quadplane that uses Arduplane/pixhawk this small, so I thought I would share this with everyone.  It took about a week to make and probably took it apart and back together no less than 10 times...seriously there is so much crammed in the fuselage I don't think there is room for air. 

In this flight I was running Arduplane 3.7, and have yet to test some of the advanced features like weathervaning and pusher motor position hold assist. Using old batteries so I can only hover for about one minute, so no time for autotune.  All gains were done manually the old fashioned way, though they still aren't perfect. Now that I am confident and familiar with the code, I will try again on a much larger model (2 meter+ wingspan) with decent flight time and payload carrying ability. 

Nano VTOL Full Specifications-

AUW: 610g

Endurance with VTOL Takeoff/Landing: 12 Minutes

Autopilot: Pixhawk 1 with GPS, 900mhz Telemetry, & Power Module

Firmware: Arduplane 3.7.0 

Airframe: RMRC Skyhunter Nano RTF 

Battery: Turnigy Nano-tech 4s 850mah 45C

Pusher Motor: Multistar 2206-2150kv

Pusher ESC: 3DR 20A w BEC

Pusher Prop: 5x5 Tri-Blade

Lift Motors: Emax 1306 4000kv

Lift ESCs: DYS 20A 

Lift Props: 3x3 Quad Blade

FPV: RMRC 25mw 5.8ghz all in one Tx + Camera

Also if anyone would like the file to 3D print the booms send me an email: Joseph@suavx.com

Thanks again to the Devs and Testers who made this possible-

Read more…
3D Robotics

Great piece from NPR about the use of Pixhawk-powered fixed-wing drones to deliver drugs and medical samples. Last year the blood transport was tested and deemed safe. Now the microbial transport has also been tested and passed. 

Three years ago, Geoff Baird bought a drone. The Seattle dad and hobby plane enthusiast used the 2.5-pound quadcopter to photograph the Hawaiian coastline and film his son's soccer and baseball games.

But his big hope is that drones will soon fly tubes of blood and other specimens to Harborview Medical Center, where he works as a clinical pathologist running the hospital's chemistry and toxicology labs. In the near future, Baird and others say, drones could transform health care — not only in rural areas by bringing critical supplies into hard-to-reach places, but also in crowded cities where hospitals pay hefty fees to get medical samples across town during rush hour. By providing a faster, cheaper way to move test specimens, drones could speed diagnoses and save lives. "It's super exciting to me," Baird says.

The technology seems to be there. Drones are delivering pizza in New Zealand and taking condoms to parts of Ghana that lack reliable roads or access to birth control. Tech giants and big retailers, including Amazon and Wal-Mart, are testing drones fordeliveries and pickups.

However, "blood specimens are not like a book or a shoe," Timothy Amukele, an assistant professor of pathology at Johns Hopkins School of Medicine, said in a TED talk earlier this year. No one knew whether bumpy flights would hurt cells or otherwise make biological samples unsuitable for lab tests.

Drones In Flight

3689700448?profile=original

Amukele and his colleagues transport donated blood samples by drone in this video. The drones climbed to over 328 feet above ground and circled the field for six to 38 minutes.

So Amukele and co-workers conducted several experiments to find out. In their firststudy, published in PLOS ONE last July, the team collected several hundred blood samples from healthy volunteers. They drove the samples to a flight field an hour northwest of Baltimore, packed half of them into foam containers and flew them around in a drone for up to 40 minutes. The other samples sat. All specimens went back to the lab for 33 routine tests. The results were the same for each group, suggesting samples stay intact during drone flights.

In follow-up analyses, drone transport also seemed safe for samples containing microbes and for donated blood. The microbial study was published in August in theJournal of Clinical Microbiology; a manuscript on the blood products study is under review. (Videos of each experiment can be found here.)

"The results don't surprise me," says Bill Remillard, chief technical officer at TriCore Reference Laboratories in Albuquerque, N.M. "But until you do the science, you just don't know."

TriCore handles nearly three-quarters of New Mexico's clinical lab testing. And in a sparsely populated state, moving samples over large distances is expensive. TriCore spends $3.5 million per year. So after Remillard heard the results of Amukele's first drone experiment at a meeting last summer, the two started discussing a possible pilot study using drones to transport lab samples in New Mexico.

While Amukele's experiments show it's feasible to move lab specimens with drones, pilot studies in real clinical settings are still needed to work out logistics. Questions include how to request a drone, where it would land, who would pick up the samples and how often a drone would need new batteries.

Safety is another concern. Some drones drop cargo with parachutes or other release mechanisms, making it harder for people to tamper with the vehicles. But as far as how safe drones are, "those data don't yet exist," Amukele says. Though millions of drones have been sold worldwide, "we don't know how many crashes happen and how many are due to operator error," he says. The Federal Aviation Administration is starting to collect this data.

It's a promising development for an industry where legislation has lagged behind the fast-advancing technology. For years, the FAA had imposed a near-ban on commercial drones, only allowing them to fly if businesses applied for an exemption. But in June the agency announced a set of rules for companies to operate drones in the United States, and on Aug. 29 those regulations took effect. The FAA expects the number of registered commercial drones to jump 30-fold, from 20,000 to 600,000, within months.

"The rules had not been well defined. This is an attempt to define them," says Lawrence Williams, who heads business development at Zipline, a Silicon Valley startup making drones for medical applications. Zipline is focusing much of its effort in Rwanda, where less crowded skies, relative to the U.S., make it easier to negotiate drone delivery of blood samples.

Another drone startup, Vayu, whose CEO is a co-author on the PLOS ONE drone study, is also dipping into the international arena. In July, the Michigan-based company did a demo flight in Madagascar, carrying specimens from a remote village to a lab for testing. Vayu makes a quadricopter plane capable of vertical takeoff — an appealing feature for hospitals with limited landing space.

While it's easy to see how drones could improve health care in poor countries, Amukele thinks medical drone delivery could make a bigger splash in the U.S. Compared to Africa and developing countries, the U.S. does much more testing per person, he says, and many of the country's 200,000 medical labs are collection-only sites that rely on central labs for testing. So "there are likely to be more [medical drone users] in the U.S. than anywhere else," Amukele says.

As Zipline prepares to launch blood delivery drones in Rwanda, the company is also seeking regulatory approval for three projects using drones to bring medical supplies to underserved communities in the U.S.

One project would integrate drone delivery of medications with telemedicine appointments at a small clinic in rural Maryland. Another would use Zipline drones to link a large health care distribution center to hospitals and tribal clinics around Reno, Nev. And for the third project, the company would partner with a regional blood bank in Washington state, creating a plan to distribute blood to various hospitals and clinics in the event of earthquakes and other natural disasters.

Johns Hopkins was initially skeptical of Amukele's experiments — the review board thought his first proposal was a joke — but now the university is giving the pathologist space and funds to hire a drone engineer and continue researching medical delivery drones.

In Seattle, Baird is working with Amukele and aeronautical engineers at the University of Washington on their own drone proposal. Ideally their test flights would take samples from Seattle Children's to Harborview, a bustling facility that runs thousands of tests each day. However, that flight path would violate the FAA rule requiring drones to stay within the pilot's line of sight. So the initial plan is to run 2-mile line-of-sight flights between the children's hospital and UW Medical Center, Baird says.

Drones could be a huge help in poison emergencies, Baird says. In a typical scenario, a child gets rushed to the emergency room after accidentally swallowing some pills. Though routine tests can rule out some things, clinics often send samples to a centralized toxicology lab for confirmation and further testing. This can take hours. A drone could zip samples downtown in five to 10 minutes, Baird says, helping a child get diagnosed and receive medications more quickly.

He also envisions drones collecting samples from patients' homes and taking them to the hospital. You could prick your finger and rub the blood onto a card that a drone could fly back to the lab for testing, Baird says.

In the meantime, though, Zipline's U.S. projects remain on hold, awaiting the regulatory go-ahead, and the Seattle team continues studying maps and sketching flight routes for the small drone test it hopes to launch. The team has presented the plan to grant agencies and gotten positive responses — but no funding yet.

Like other technological advances, Baird suspects drones for medicine will "wait, wait, wait and then go very quickly."

Esther Landhuis is a freelance science journalist in the San Francisco Bay Area. Follow her at @elandhuis.

Read more…

3689700409?profile=original

How often do you need to make repeatable flights in areas for which Google or other map provider data is outdated? It’s a typical scenario for flying a drone in rapidly changing areas such as construction sites, quarries, mines, disaster areas etc.

If this is the case for you, then you probably are familiar with how hard it is to plan missions when there are no visual identifiers on the map. This is especially true if you need to build a 3D reconstruction from the images taken during the flight.

Here we will show you how easy it is to make a map and import it in UgCS ground control software. After this is done you will be able to plan your drone flights with more precision and confidence.

The steps are as follows:

1. Plan a Photogrammetry mission which covers the area of your interest. Because you will only use this map to plan future missions you don’t need a very good GSD - 5 cm per pixel will be more than enough and it will give you short flight and image processing time. Here is an instructional video on how to plan a photogrammetry mission in UgCS - https://youtu.be/Ykf0x0B-QoE

3689700096?profile=original

2. Fly your route and take images. If the camera on your drone does not automatically geotag the images, you can geotag them in UgCS Telemetry Player.


3. Next step is to stitch the images together using your favorite software or service. By using the right tools - in fifteen minutes you will get a geotagged GIF or TIF file like this:


3689700350?profile=original

The image for this sample was created using a free account on Dronedeploy.com


4. Use some “black magic” to import the geotagged map file back into UgCS


In UgCS go to Menu / Configuration / Geoserver. Then select “Local Geographic Server”, press “Edit”, click “Manage map sources”, “New source” and you will see this window:

3689700516?profile=original

Give your new map a name, for example - “Fresh map”, and click Create. Then click “Upload” and select your geotagged image file.

The upload process can take anywhere from 2 to 10 minutes depending on your hard drive speed and the size of the file. When image is imported you can close this window and click “Save”.


Click Back and you will be taken back to the main window of UgCS.


5. Click on “Layers” menu located in the upper right corner of UgCS. Select your newly created map in the list of map overlays:


3689700429?profile=original

Bingo! Here you have it:

3689700465?profile=original

Now you can plan your next mission in a safe and confident manner by using the map you just created!


Best,

UgCS Team


Get the newest version of UgCS here: www.ugcs.com

Read more…
3D Robotics

Lidar Lite back with V3 after Garmin aquisition

3689700337?profile=original[Updated with more info] Glad to see that the Pulsed Light team, which joined Garmin earlier this year, are back with a new version of the Lidar Light range finder. Not many details yet, but it's now listed for $150 at Sparkfun:

  • Description: It’s back! This is the LIDAR-Lite v3, a compact, high-performance optical distance measurement sensor from Garmin™. When space and weight requirements are tight, the LIDAR-Lite v3 soars. The LIDAR-Lite v3 is the ideal solution for drone, robot or unmanned vehicle applications.

    This easy-to-use 40-meter laser-based optical ranging sensor has all the core features that made the LIDAR-Lite v2 so popular. Small in form and light in weight with low power consumption of less than 130mA during an acquisition. And it’s user-configurable so you can adjust between accuracy, operating range and measurement time.

    Each LIDAR-Lite v3 features an edge-emitting, 905nm (1.3 watts), single-stripe laser transmitter, 4m Radian x 2m Radian beam divergence, and an optical aperture of 12.5mm. The third version of the LIDAR-Lite still operates at 5V DC with a current consumption rate of <100mA at continuous operation. On top of everything else, the LIDAR-Lite is user-configurable, allowing adjustment between accuracy, operating range and measurement time. It can be interfaced via I2C or PWM.

    Note: The LIDAR-Lite v3 is available for pre-order. We expect to have these in stock and shipping by early to mid-October. Adding a pre-order product to an order may cause a delay. Be sure to uncheck “ship complete order” in your cart to avoid delays in shipping in-stock items.

    Dimensions: 20 x 48 x 40 mm (0.8 x 1.9 x 1.6 inches)

    Features:

    • Range: 0-40m Laser Emitter
    • Accuracy: +/- 2.5cm at distances greater than 1m
    • Power: 4.75–5V DC; 6V Max
    • Current Consumption: 105ma idle; 130ma continuous
    • Rep Rate: 1–500Hz
    • Laser Wave Length/Peak Power: 905nm/1.3 watts
    • Beam Divergence: 4m Radian x 2m Radian
    • Optical Aperture: 12.5mm
    • Interface: I2C or PWM

Read more…
3D Robotics

3689700389?profile=original

The Open Source Robotics Foundation (a member of Dronecode) is getting investment from Toyota Research to expand the development of both open source and proprietary applications of ROS. From IEEE Spectrum. 

Today, the Open Source Robotics Foundation announced a whole bunch of stuff, including a big pile of money from Toyota Research, what is probably an even bigger pile of money from Toyota Research, and the formation of the for-profit Open Source Robotics Corporation. That last thing might sound a little worrisome, since corporation-ness and open source-itude are often at odds, but we checked in with OSRF CEO Brian Gerkey, who explained how it’s all going to work.

The most straightforward bit of news is that the Toyota Research Institute (TRI) is making a charitable donation of US $1 million to the Open Source Robotics Foundation to “advance the development and adoption of open source robotics software.” In other words, TRI thinks that OSRF has been doing pretty good work with ROS and Gazebo over the last couple years, and they’re supporting that vision financially. Since it’s a donation, OSRF can use that money however it wants, meaning that it’s going to benefit the development of ROS and Gazebo for everyone.

From the beginning, OSRF has been a non-profit corporation, which is why it’s subsisted mostly on government contracts and donations from companies. As a non-profit, OSRF isn’t allowed to get paid directly for doing substantial amounts of work for specific companies. This causes two problems: First, it means that OSRF isn’t as effective at making improvements to ROS that are targeted at robots doing commercial and industrial stuff, which are areas where ROS has a lot of potential to expand. And that leads to the second problem, which is that OSRF can’t get financial support from partnerships with companies that (presumably) want to invest some of those aforementioned piles of money into making ROS better for themselves, and by extension, for the rest of us.

“OSRF will continue to create and distribute open source and free-of-charge applications for the robotics community, including ROS and Gazebo.”—OSRF

The brand new Open Source Robotics Corporation (OSRC) is a for-profit subsidiary of the Open Source Robotics Foundation. Basically, OSRC exists so that other companies can pay money for core ROS development, new features, or custom projects, without jeopardizing the non-profit status of its parent company, OSRF. As the press release very specifically and deliberately says, “OSRF will continue to create and distribute open source and free-of- charge applications for the robotics community, including ROS and Gazebo.” This is just going to make sure they have the resources they need to keep on doing so.

Speaking of resources, the final part of the announcement is that the Toyota Research Institute has “joined forces” with OSRC “to expand the development of both open source and proprietary tools for Toyota’s fast-growing robotics and automated vehicle research initiatives.” Specifically, or as specific as the press releases are willing to be:

“TRI signed a consulting agreement with the newly-formed Open Source Robotics Corporation. As part of the two-year agreement, TRI will leverage the expertise of OSRC’s engineering team, engaging them in a variety of initiatives.”

We’re hoping to hear back from TRI about what “a variety of initiatives” are, but we did manage to speak with Brian Gerkey, OSRF’s CEO, about what’s going on on their end:

IEEE Spectrum: What’s the Open Source Robotics Corporation, and why does it exist all of a sudden?

Brian Gerkey: What has changed over the last couple years is that we’re getting more interest from industry to financially support our work. This is a good thing, it’s showing that there’s commercial interest out there for using ROS and Gazebo in products. There are certain constraints associated with having a [non-profit] status that make it difficult to really do business in a serious way with industry. Our goal here is to simultaneously continue the mission of the foundation and continue to develop the open source work and support our community, but at the same time, have the ability to partner with industry, where they’re interested in contributing to that open source platform and perhaps, in some cases, applying it to their particular problems.

What we want to do is essentially continue doing the same work, but do it in a way that’s supporting this emerging industrial user base that we have, and be able to get their financial support without endangering the [non-profit] status of the foundation. We want to keep that as it is, but really start primarily operating day-to-day out of the corporation. What we’re doing now, we knew quite a while ago that we were going to do this, and this arrangement with TRI is causing us to execute this plan we had on the shelf.

Will most ROS users notice that anything is different going forward?

They should notice no difference at all. 

What should we expect from the partnerships between OSRF, OSRC, and TRI?

TRI is making a $1 million charitable contribution to OSRF. It will be at the discretion of OSRF to spend those funds in support of its mission. In addition, as part of a separate arrangement, TRI is entering into a substantial, multi-year research and development contract with OSRC for services related to ROS and Gazebo. 

Cars and robotics are two domains in which we expect that TRI’s efforts will rely in some non-trivial way on ROS and Gazebo. The role we’ll play is making sure that ROS and Gazebo are improved, extended, modified, and supported in a way that will help them achieve their research goals on those two broad domains. 

Will the work that OSRC does for TRI be contributed back into the ROS community?

What the OSRF and OSRC team is very good at doing is building open source software and contributing it back to the community. It’s that specialty that TRI has come to us to leverage. We anticipate that we will be making substantial contributions back to the open source community.


In addition to TRI, there are plenty of other companies that have already contributed to the health and future of ROS, like Qualcomm, NVIDIA, and Bosch. But, as Gerkey explained, OSRF has had to place significant limits on that kind of thing because of their non-profit status. OSRC, on the other hand, will be able to accept a much more substantial amount of support, while also providing industry with all of the help that it needs in a much more direct way.

As far as we can tell, this is good news for everyone, whether you’re a casual ROS user or an enormous multinational conglomerate. And if you’re the latter, hey, have you considered sponsoring a robotics blog lately?

Also, don’t forget that ROSCon 2016 is happening next month in Seoul, South Korea. There’s going to be some cool stuff announced there that we can’t tell you about yet, but it’s going to be awesome. Check out the program here.

[ OSRF ]

Read more…