All Posts (11086)

Sort by
3D Robotics

3689536822?profile=originalFrom Engineering.com

Created by Dr. Paul Pounds at the University of Queensland, Australia, the drones are designed to be so cheaply manufactured that they can be single-use, disposable robots.

The first design, modeled after a paper plane, is created from a cellulose sheet that has electronic circuits ink-jet printed directly onto its body.  Once the circuits have been laid on the plane’s frame, the craft is exposed to a UV curing process, turning the planes body into a flexible circuit board.  These circuits are then connected to the planes “avionics system”, two elevons attached to the rear of the craft, which give the UAV the ability to steer itself to its destination.

The second design from Dr. Pounds’ lab is named the Samara.  It’s an odd looking UAV designed to mimic a maple seed. The Samara is built from a rigid circuit board with sensors housed on a tiny round PCB at its leading end.

The proposed use for the Samara is to drop a huge number of them from a larger vehicle to survey a vast swath of land. Because of its unique design the Samara would fall gently to the ground, rotating like a helicopter’s blades, collecting valuable environmental information on its way back to Earth.

Whether Dr. Pounds’ designs ever see full scale production is still to be seen. However, as more researchers, corporations and militaries look to big data for ways to understand complex systems, UAVs like these could be in high demand.

(via MakerBlock)

Read more…

And now you know...the rest of the story...

3689536748?profile=original

This shot  was taken about half an hour before a storm moved in, using my inexpensive aerial stitched photo technique I wrote about HERE.

This is a video taken during a storm (not the same one though).

I put my cheap standard def camera on, because I still baby my $40 keychain cam a bit, and the 20mph winds made me nervous. The quad on the other hand is a tank. I have flown it full speed into a tree without a scratch.

So, now you know why I call myself HeliStorm! 

Also, I know some people have been enjoying my videos, and pictures, done on the cheap. I am thinking of starting a site for low cost drone tips, tricks, etc. 

Thanks for all the views of my blog posts, my videos, and my pictures! This is a great community, of which I am proud to be a part.

Read more…

Ahhhh, 'Merica

3689536687?profile=original

Saw this today: http://news.yahoo.com/blogs/sideshow/drone-hunting-colorado-172357477.html

It's interesting that the article leads with a photo of a hexacopter, calls it an octocopter, and the drone bounty being discussed would reward people for turning in "identifiable parts of an unmanned aerial vehicle whose markings and configuration are consistent with those used on any similar craft known to be owned or operated by the United States federal government".  So, presumably it's nothing to do with multi-rotors or hobbyist craft, but that's what they include a photo of?  Sigh.

Read more…

I took my new Pulsar H-8 Octocopter for a test flight tonight.  I'm getting ready for more flights with the Nex5 camera, so I wanted to give it a bit of a shakedown run. For this flight it has a Contour camera mounted just for fun.  Previous to this flight, some of the bearings sounded and felt a little iffy...  and now we know why!

One of the motors failed and came apart in flight.  It appears that when it came off, it actually hit another propeller, stopping it.  The H-8 now had two adjacent props stopped which isn't good.  It does a flip, but then miraculously recovers after the second motor re-starts.  I've never seen a better example of Arducopter stability and fault tolerance.  In the past, I've disabled motors by removing the props to test the performance, but it's just not the same as the real thing.

Read more…

GEMiNi tiny FPV racing hexrotor

A video of the Shrediquette GEMiNi:

Hi everyone! I just posted this already in the internet somewhere else, but I think it might be worth a blog-post on DIYdrones as well, as it contains some information on motors / propellers / aerodynamics that might be interesting to you guys...:

I spent some time during holidays to design a new FPV hexacopter based on my latest flight controller (see details here: click) and a canopy which was designed using CAD.

_MG_9617.jpg?width=200Cheap hobbyking motors were shown to have the same performance as the more expensive Roxxy ones (see details here: click). I found propellers that I did not know before (see details here: click) and that are more efficient than the AirAce propellers. The props are tilted 10° forward in order to decrease the angle of attack of the copters body in forward flight, which, together with the canopy, decreases the net aerodynamic drag in fast translational flight by about 30% (see details here: click). This copter flies even faster than the BOLT (see here: click) and it seems more maneuvrable. The GEMïNï is however slightly larger, the max. dimension is 315 mm from propeller tip to propeller tip (diagonally). I use the CCD-Killer camera, and a 25 mW Airwave module for video transmission. The CCD-Killer is still my favorite camera in terms of image quality and exposure control vs. weight and size.

Ever since I built my first tricopter, I wanted to build a canopy that somehow resembles the Limulus, an impressive animal that seems to have survived from the primeval times (see details here: click)... I like the design of the Limulus ("Horseshoe crab") a lot. Now I had the opportunity to print the model in 3D and to cast it using thermoformed flat film (Polystyrol).
The GEMïNï is extremely fun to fly, it seems to be very fast and agile - better than any copter I built before. For one full FPV flight of the GEMïNï, see this video:

I am very much interested in FPV multirotorracing, anyone that likes to have a fun competition, please tell me!

All the best,

William (Bremen / Germany)

Read more…

My Tilt-Tricopter on Gears

I built a Tricopter that front motors can tilt forward to gain speed.

I also added gears so that It can take-off and land like a plane !!!

Motors also can tilt-backward so it looks like a Scorpion with high tails and can move backward on gears .


Read more…
Moderator

EastBay RC to Present at U.C. Davis

asdfa
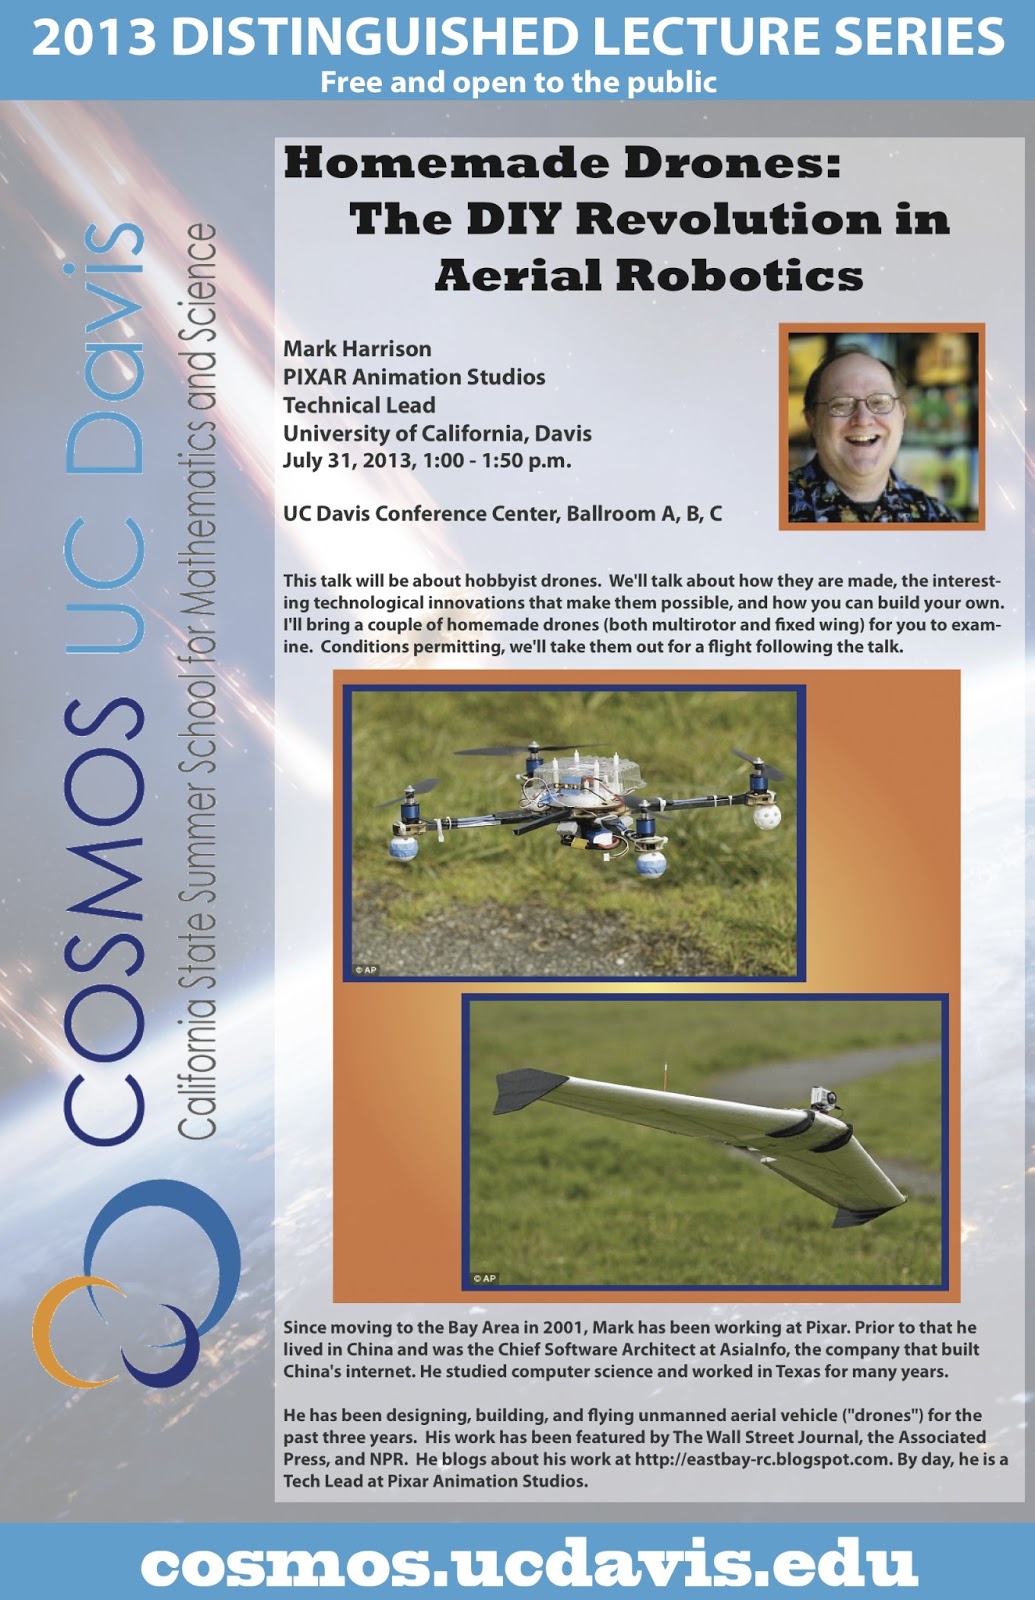
DLS+Poster+2013+Markfinal-5.png?width=300I'll be presenting in the COSMOS Distinguished Leture Series on the campus of U.C. Davis on Wednesday.

Synopsis: "This talk will be about hobbyist drones. We'll talk about how they are made, the interesting technological innovations that make them possible, and how you can build your own. I'll bring a couple of homemade drones (both multirotor and fixed wing) for you to examine. Conditions permitting, we'll take them out for a flight following the talk."

July 31, 2013, 1:00 - 1:50 p.m.
UC Davis Conference Center, Ballroom A, B, C

If you happen to be in the area stop by and say hello!

Read more…

CAMERA 10X ZOOM, STABILIZED BY APM 2.5

After a year of having purchased the camera FH 10 with 10x zoom, the first experiences were poor due to the lack of a system of stabilization.

then decided dusting the camera again and stabilize with AMP 2.5. using the PAN and TIL my RVJET, to install it sideways. in my skywalker 1900. the camera has stabilization in the ROLL axis, the flight height is 300 meters and the loiter radius is 200 meters.

https://www.youtube.com/watch?v=UrPrqO9uFew&feature=c4-overview&list=UUVoTd1B5K8AEVzY4R0vIqJQ

Read more…
Distributor

3689536422?profile=original

Mississauga, Ont., businessman Dany Thivierge, right, has established himself as a go-to man for hobbyists in need of drone parts and know-how. (Evan Mitsui/CBC)

Hi guys, pretty happy about that one! 

Last week we filmed with CBC Evan Mitsui to get a good view of how the UAV hobby side was doing. 

We spend a good half day showing off technologie that here we now take for granted but that the vast majority of the the non initiate people have a hard time grasping.  We went flying (couldn't get the Hexa to work... I swear this thing has severe stage fright syndrome, when it's time to shopw off it refuses!) but we had fun with a Quad and recorded everything on the entry level DJI Phantom. 

Was a very nice day and we had a blast.  

Check the second part of the interview to see me with Yuri a friend/customer with a very DIY setup. 

http://www.cbc.ca/news/canada/story/2013/07/10/f-canadas-commcerial-uav-drones-laws.html

Read more…
3D Robotics

New 2m Bixler-style plane from Hobbyking

3689536319?profile=originalLike a Bixler, but bigger and with a cool nose dome for a forward-facing camera. $120, now available from HobbyKing. 

Details:

The Sky Eye is a large plug and fly glider designed for the FPV pilot who is looking for all the benefits of a larger model that is also fast to get into the air and won't break the bank!
 
Make no mistake, the Sky Eye is a biggie! That said, it is also really practical and features a 2pc plug in wing and huge magnetic canopy for easy camera and Lipo access. Being a plug and fly model, the Sky Eye is really quick to assemble, the heavy duty mini servo's are all pre-installed, as is the powerful 35mm brushless out-runner motor and ESC, in fact setting up your camera in the supplied transparent camera dome is going to be the longest job of the build!
 
As the old saying goes, the bigger they are, the better they fly and with a 2 metre span, the Sky Eye provides a high lift, stable and virtually un-stallable camera & FPV platform thanks to it's generous wing area and effective pre-installed flaps. The powerful brushless outrunner and 8" prop combo offer an excellent climb rate while the effectively sized four channel control surfaces offer absolute control at all speeds. This fantastic model offers a fun and easy to fly glider and FPV/Camera platform in a simple & fast to build format that is totally affordable and perfect for pilots of every ability, the Sky Eye offers something unique and familiar rolled into one great priced package!
 
Features:
• Tough EPO Construction
• Plug and Fly Format, Simply add Battery and Reciever!
• Large Size Ideal for a Stable Flying in a Variety of Weather Conditions
• Unique Nose Mounted Transparent Camera Dome
• Pre-Installed Landing Wheel
• Pre-Installed Flaps
• Large Magnetic Canopy
• Plug In 2pc Wing for Easy Transport
• Powerful 35mm Brushless Outrunner
• Large Payload Capability
• Large CF wing Tube
 
Specs:
Wingspan: 2000mm
Length: 1100mm
Weight: 1350g
Wing Area: 46.3dm2
Wing Loading: 29.2g/dm2
Servo: 6 x Mini 17g
ESC: 30A w/BEC
Motor: 3536 Brushless Outrunner 900kv
Prop: 8x6

Read more…

3689535850?profile=original

...but there's a snag. Right at the end of the build too - extremely annoying. More on that later.

First, apologies for the photo's my main light is bust, and I'm only using an iphone!

This post is a look at what I did with *NO* external compass.

1. Reversed the screws and bolts. Supposedly, the end of the screw causes more interference than the head. This could all be complete rubbish, but since it was in bits, I did it anyway. Now the heads are what's closest to APM.

2. Replaced the 8mm anti-vibe stand offs with a 1cm metal one. Doesn't sound like much, but it's all I had lying around that came with the kit. The good news is, I recon you can get 2cm stand off in there, while preserving the cage. and dome.

3. Twisted the power wired for the ESC's once. That's all I could do given the short cable lengths.

4. Re-did the PDB. It's bigger, and the soldering is much improved. I also took the opportunity to wire in an extra JST.

And that's it for now. Was hoping to run the compassmot in this base config...BUT THE DAMNED ESC'S ARE REFUSING TO SET THEIR END POINTS!!!! Ultra annoying, given the rebuld is complete, the motors are all running and in the correct CW/CCW fashion, everything...but fails to set the end points. Last time I had to take the whole thing apart, and only then did they spring back into life. Sequence after boot up is:

- two beeps

- the calibration scale

- one beep

(throttle down)

- one beep (throttle up....nothing....throttle to max...error tones)

Doesn't matter if you wait for two beeps or one - it still errors out. These are t-motor 30A OPTO PRO's and appear to be running normally apart from this. Dodgy motor maybe? One is making some low vibrations at mid stick with no props.

Anyway -  I was request to post details about the rig. Well, here it is:

3689536022?profile=original

3689535964?profile=originalThat's an RCtimer gimbal but with an alexmos. The flight battery is a 10900mAh from maxamps.

3689536047?profile=originalSpektrum RC mounted on port side. Includes telemetry. And APM obviously, mounted on double moongel corners.

3689535980?profile=originalFatshark 5.8 tx + bluebeam. Also in shot is 0.1 minimOSD from jdrones. It's not working right though (see forum post) with gopro as the source. Smearas white behind the text (text is clear and sharp, as is image)

3689536072?profile=originalWhere the fun will take place. A DJI style riser has been fitted - just waiting for my 30cm cable now for the external mag. GPS will also be replace by GPS/compass combo from 3DR, but the old one stays in place for now. The port and starboard pylons have been extended outward to their maximum as well. I should have huge distance between the compass and APM after this is complete!

3689536105?profile=originalUnderneath is a Turnigy 4-in-1 BEC and the battery for the FPV. Will probably power the FPV camera (have decided to avoid the GoPro, after the current problems). Once I find a suitable Y cable for the balancer port, I can ditch this battery and save 100g.

3689536097?profile=originalThe Braincube flightlights controller v5 and the electronics battery (on a 3DR PM). It's chunky and heavy, but the power the lights give out is incredible. No orientation issues, even in bright sunlight, so it's worth the weight penalty.

So...almost ready to test. Just gotta work out if I can solve my ESC problem without resorting to a complete disassemble again!

Read more…

3689535925?profile=original

Currently a GoPro 3 is static mounted to my Neo 660 Hex Copter and it takes pretty nice video, but the video is pretty wild and jerky due to the maneuverability of the copter.  So a brushless camera gimbal is in the works.  The SimpleBGC Controller for the gimbal just arrived from Aerial Pixels and had it's first light today.

The board version from Aerial Pixels include both the FTDI and a USB interface for programming the controller.  The USB fired right up without loading any additional drivers when plugged into my Windows 8 box probably since it was already loaded from another project, but the driver is available from the Aerial Pixels support page as well.

The SimpleBGC GUI did not connect to the controller at first because the GUI has newer than the firmware on the controller.  That was easily fixed with the instructions from the Aerial Pixels support page, including the very helpful note that the flash loader XLoader displays a failure message on loading the new firmware even though it succeeds.

Just waiting on the gimbal mount now.

Read more…

We got recently some nice shots that we would like to share while flying multi-rotors at high altitude (approx 3000 meters) in the amazing natural theater given by the Alps. The video shows the preliminary steps of our new SHERPA Project (www.sherpa-project.eu) which is focusing on the application of robotics technology (including of course aerial robotics) in the Alpine rescue scenario.

I really believe that we will get some really interesting results to share with the UAV amateur community.

To this end, I would like also to show you some results obtained with our former project, AIRobots (www.airobots.eu), which was focusing on designing and controlling innovative aerial robots able to physically interact with the surrounding environment.

The ideal goal was to design a sort of "flying-hand", and as you can see from some of our videos we got really some nice toys :-)


See you all very soon and thanks to all of you for the many inspiring ideas that are driving our research!

Roberto
(member of the SHERPA and AIRobots project)

Read more…