All Posts (11086)

Sort by

An APM2 for the South Carolina Arducopter

3689462234?profile=original

On second thought, maybe ordering the APM2 assembled would have been a good idea.

Nah, why let someone else have all the fun? The board is wonderfully small and has convinced me that SMD components require learning new tricks if I plan to roll my own in the future. Over 35 years of through-hole work only qualifies me to solder in the header pins.. barely. You see a very vintage grounded Ungar iron and the ESD packing on my bench acting as my base ground ("Where's my anti-static mat?")

 I could not locate an order of assembly for the 'kit' version of the on-board GPS (the APM1 has one) so...

Here is what I did:

  • Drop the single pins into the main board first (short pins through the mainboard)
  • Then use the GPS module to hold them somewhat down and in place (plastic 'block' between main and GPS).
  • Solder the pins on the bare (back) side of the mainboard first.
  • Then solder the 4 pins in the purple section of the GPS board from the top. These are the Vcc and Gnd connections to the GPS module. I left the two pins at the GPS 'chip' end unsoldered. They look that way in the 3DR pictures.

The GPS header connector was not marked with Vcc or Gnd. This implies the power and return (earth, ground) are delivered through the single pins. If I missed the markings, at least the board is mechanically intact if/when an uncontrolled impact should occur. Besides, the pictures of the pre-assembled APM2 seem to show those pins soldered from the top.

Why did I go with the kit? I wanted the 90 degree connectors for the inputs/outputs rather then the stock units. I think cable management will be neater this way. When I get APM2 in the Quad stack up, this will be confirmed or recanted.

My plan is to do bench testing of the APM2, Mission Planner, etc before even thinking about trying to get off the ground.

Last week I purchased a Hitec X1 AC Plus Multicharger and an Eflite 3S 3200mAh LiPo from my local hobby shop (previously mentioned in the first blog post). More to do is matching up connectors from the battery to the PBD on the quad. Also to make up are the stack up plates for the APM2 and RC Rcv section. Writing the Gcode for these can be time consuming but it will allow me to create spares if they are broken while learning to fly. I think I will buy interconnect cables from 3DR. We've got to keep folks employed afterall.

Read more…
Moderator

Specter 360 CS UAV gimbal system

Hi All

I am glad to tell you that we have started with first air test of our small gimbal. This is under 600g, affordable, 2 axis control and stabilization system with 10x zoom great quality camera.

After analyzing global gimbal market we have decided to make a step forward and do a low cost, high-tech, reliable gimbal system all of us could use.

If this hits a good response we will put the system in production at the end of the summer.

We still have a lot of work to do. Stabilization is still not dead locked, integration with ardupilot, testing of different mechanical components, optical tests, endurance tests....

here is the link  https://www.youtube.com/watch?v=uX-ZIX6Ot8I

Read more…
3D Robotics

3689461991?profile=original

Drivers in Washington DC freaked out by sight of an X-47b being towed on a flatbed truck; think it's a UFO. Washington Post story here, including the amusing Twitter response I quoted in the headline, which came once citizens were informed that it was just a military drone. 

Read more…
3D Robotics

3689462173?profile=original

IEEE Spectrum writes:

In October of 2009, we wrote about the very first version of EPFL's AirBurr micro air vehicle, called HoverMouse. It was an innovative design: a roll cage protected the MAV's engine and flight surfaces, enabling it to crash into walls and floors without damage and then take off again, provided it had enough room to get airborne. Seven iterations later, the AirBurr V8 Samurai includes an active self-righting mechanism that allows it to crash and take off again even in rugged and cluttered environments.

AirBurr's latest trick involves first crashing into something and falling to the ground, which I imagine was a pretty easy thing to get it to do. Second, the MAV rolls over onto its side thanks to a clever arrangement of carbon fiber caging plus a carefully designed center of gravity. Third, AirBurr activates an "Active Recovery System" consisting of carbon fiber legs that deploy out from the body, pushing the body of the MAV into a vertical position from which it can lift off straight up. Watch:

Read the whole IEEE Spectrum piece for lots of pictures of previous versions and background on the research.

Read more…

Hello

wr703n.jpg?width=750

I found that lot of people discovered this new feature of the wr703n flashed under openwrt : It is able to stream an USB webcam (soon a Gopro using an easycap) and also to make a bridge between a serial interface (USB according to CDC driver or 3.3V TTL).

see : http://www.diydrones.com/profiles/blogs/hacking-a-rc-helicopter-for-wifi-router-control

Here is the tutorial (3 parts + 1 part unbricking ;) ) on Openpilot Forum : http://forums.openpilot.org/blog/52-fertitos-blog/

So I started a TUTORIAL to help those that would like to add this feature on theyre drone and start developping new sensors :

I'ld like to work on a laser line avoidance system using the webcam :

scan.JPG

If you have question... ;)

Read more…

I know there are instructions for setting up a DX7 and a DX8 to get 6 modes out of channel 5, but the DX7s is a bit different from each of those other transmitters.  Here are screen shots of the 3 sets of changes you need to make to use the 2-way Gear and 3-way Flap switches to send 6 different modes down channel 5.

3689462056?profile=original

3689462038?profile=original

3689462077?profile=original

I hope those are legible, My screen is pretty scratched, and of course for the millionth time I wish the display was backlit.   

Read more…

APM1 > APM2?

3689462019?profile=original

To avoid confusion, I ought to preface this post by mentioning that I began tests quite some time ago with the APM2 purple board. Since then I've gotten my hands on it's older brother the APM1 (hey, they're cheap now and then!). I have the APM2 in my heli now, so I decided to throw the APM1 on my quad in place of the APM2 to see how things compare...

So that might be a bit of an excessive title, but if I didn't know the differences between the two boards, I would claim that the APM1 is superior to the APM2!

A lofty claim, you might suppose, but let me explain why.

Firstly, the yaw issue I had with my APM2 is completely gone after installing the APM1. I'm using the same quad frame I had my APM2 on. Perhaps shuffling the ESC's around a bit helped. I moved them a bit farther away from the center and they now reside near the motors themselves. I've heard that to be a good thing, and I've heard it to be a negative thing having long + and - wires, so who knows.

The most surprising observation I made was with regard to loiter. This is the first time I've gotten anything to loiter. I can't claim to have even once gotten my APM2 to loiter, but right off the bat with default parameters, the APM1 on my quad loitered amazingly well (both using 2.5.5). Why? I have no idea. I didn't run a long test, but take a look at the results in the picture. The longest distance traveled was about 7 meters. There was a slight breeze. I suppose this warrants some careful comparisons of mounting, wiring, etc. for me in the future.

Anyway, that was my surprise for the day. I know the APM2 board is quite an improvement upon its predecessor, and I'm really not claiming otherwise. I suppose all I'm doing is pointing out the causes for my sudden onset of confusion and hope. Either way I'm happy. I have an APM1 in my plane, APM1 on my quad, and APM2 on my heli. No complaints here (except crashing the plane repeatedly, but that's another story...)

Cheers!

Read more…
3D Robotics

Dealing with GPS blocking/jamming

3689461845?profile=original

The sad truth is the GPS system is a fragile one, easily blocked and interfered with, as the tragic fatal crash of a drone in South Korea last month (shown above) showed. 

Now DARPA is sponsoring new research to help drones navigate without GPS. Called "All Source Positioning and Navigation (ASPN),” it’s trying to “enable low-cost, robust and seamless navigation solutions … with or without GPS.”

Wired writes:

Right now, the agency notes, the military’s navigation systems primarily rely on a pairing of two devices: GPS, which uses satellite data, and what’s known as an Inertial Navigation System (INS), which relies on “dead reckoning” (using estimates of speed and direction, without external references) to provide locational intel.

It’s a tactic that’s accompanied by several problems. For one, INS — because it uses internal, ongoing estimates — is notoriously error-prone without a GPS system to back it up, so it can’t be relied upon exclusively. And INS systems often obtain their starting position and velocity from a GPS device. Which means if the GPS is under attack, the INS risks leading military personnel (or the drone or weapon they’re navigating) astray.

These navigational systems are also extremely inflexible. Typically, Darpa notes, they’re programmed to accommodate, maybe, one additional sensor (say, a magnetometer) and unable to plug into any others. As a result, personnel can’t respond to “new threats or mission challenges” in real time. Not to mention that, even as consumer navigation tech becomes more sophisticated (Apple Maps, anyone?) the military can’t take advantage of the most cutting-edge products.

Of course, there are already plenty of GPS alternatives available. Radio beacons, which transmit signals from static locations to receiving devices, allow the calculation of location based on proximity to various beacons. Ground feature navigation extracts the positions of tracked objects and then uses them as points of reference to gauge a vessel’s locale. And stellar navigation systems use the coordinates of celestial bodies to assist in a vehicle’s navigation.

Darpa’s dream navigational system would go beyond those kinds of discreet systems — by incorporating pretty much all of them. The ASPN system, according to Darpa’s announcement, should be able to accomodate any available sensor, and be versatile enough to incorporate new sensors “as they become available in the marketplace.” The key benefit to such adaptability would be the mitigation of GPS-dependency. Personnel would instead have myriad sensors at their disposal, and be able to toggle between them as necessary. In other words, a suite of backup tools to work, in conjunction, as a safety net in case of GPS failure. Among the ton of gadgets that Darpa wants the system to utilize: 3-D imagers, LiDAR, temperature sensors … and good old compasses.

Read more…

UAV Inspired by Maple Seed.

Those of us in the North Country, are very familiar with the shape and mess that we have to clean up every year.  Yes the venerable maple seed.  Lockheed has found a way to turn this into a military drone.  Way to go, Lockheed!

This design seems familiar, very much like Jack Crossfire's Marcy mono-wing.

http://diydrones.com/profiles/blog/list?user=JackCrossfire

Read more…
Distributor

3689461949?profile=original

Mark your calendars for August 25-26 in beautiful Montreal City!

Canada Drones is proud to let you know that we will be sponsoring the Montreal Maker Faire 2012. 

We will have a booth there with the 3DRobotics and jDrones products on display.  People will be able to interact with the gear in a safe way (no Lipo connected on display items). 

We are still trying to figure out if there will be a way to do some flight demo but safety is paramount and we will only do so if the organisation is giving us the green light. 

People interested to come I will have some free tickets, let me know! 

Also if you are interested to come show your setup that would be great, I will have a spot for you! 

This will be fun!


Read more…

I found this in one of my rss feeds:


The MPU-9150™ is the world’s first 9-axis motion tracking device designed for the low power, low cost, and high performance requirements of consumer electronics equipment including smartphones, tablets and wearable sensors.

The MPU-9150™ is actually two chips in one package: the MPU-6050 ( 3-axis gyro / 3-axis accelerometer ), and an AK8975 ( 3-axis digital compass ). They’ve also included what they call a Digital Motion Processor™ (DMP™) which is used to precisely process and ship sensor data over I2C.

It’s pretty small- 4x4x1mm with a 2.4 to 3.34V operating range. So… probably not something you can hook-up directly to a microcontroller. [Via]


Link: http://invensense.com/mems/gyro/mpu9150.html

Read more…

3689461956?profile=original

Hey all I got my 3DR package today, it was like opening a present in christmas

APM2

3DR Quad Frame Kit with motors and ESC's

MinimOSD

CCD Camera

3DR 900mhz radio

LV-EZ0 Sonar and mount

2 hoodies (It is winter here in South Africa so it is NICE)

I waited 6 weeks before it was at my door but it is all worth it, thank you 3DR.


Read more…
3D Robotics

3689461919?profile=original

Over the five years we've been running the site, Apple OSs have been consistently rising and Linux consistently falling. Today iOS of various flavors add up to nearly 6% of total traffic of 1.4m page views/month, which brings the Apple total (mobile +  Mac) to around 20%. Five years ago, Linux was around 8%; now it's 5%. FWIW, Chrome is the most popular browser, closely followed by Firefox.  

Read more…
Developer

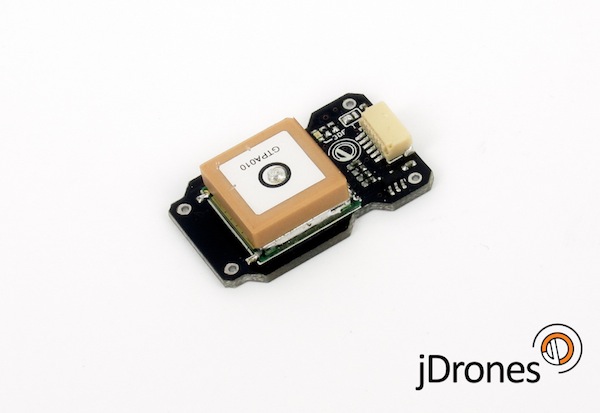
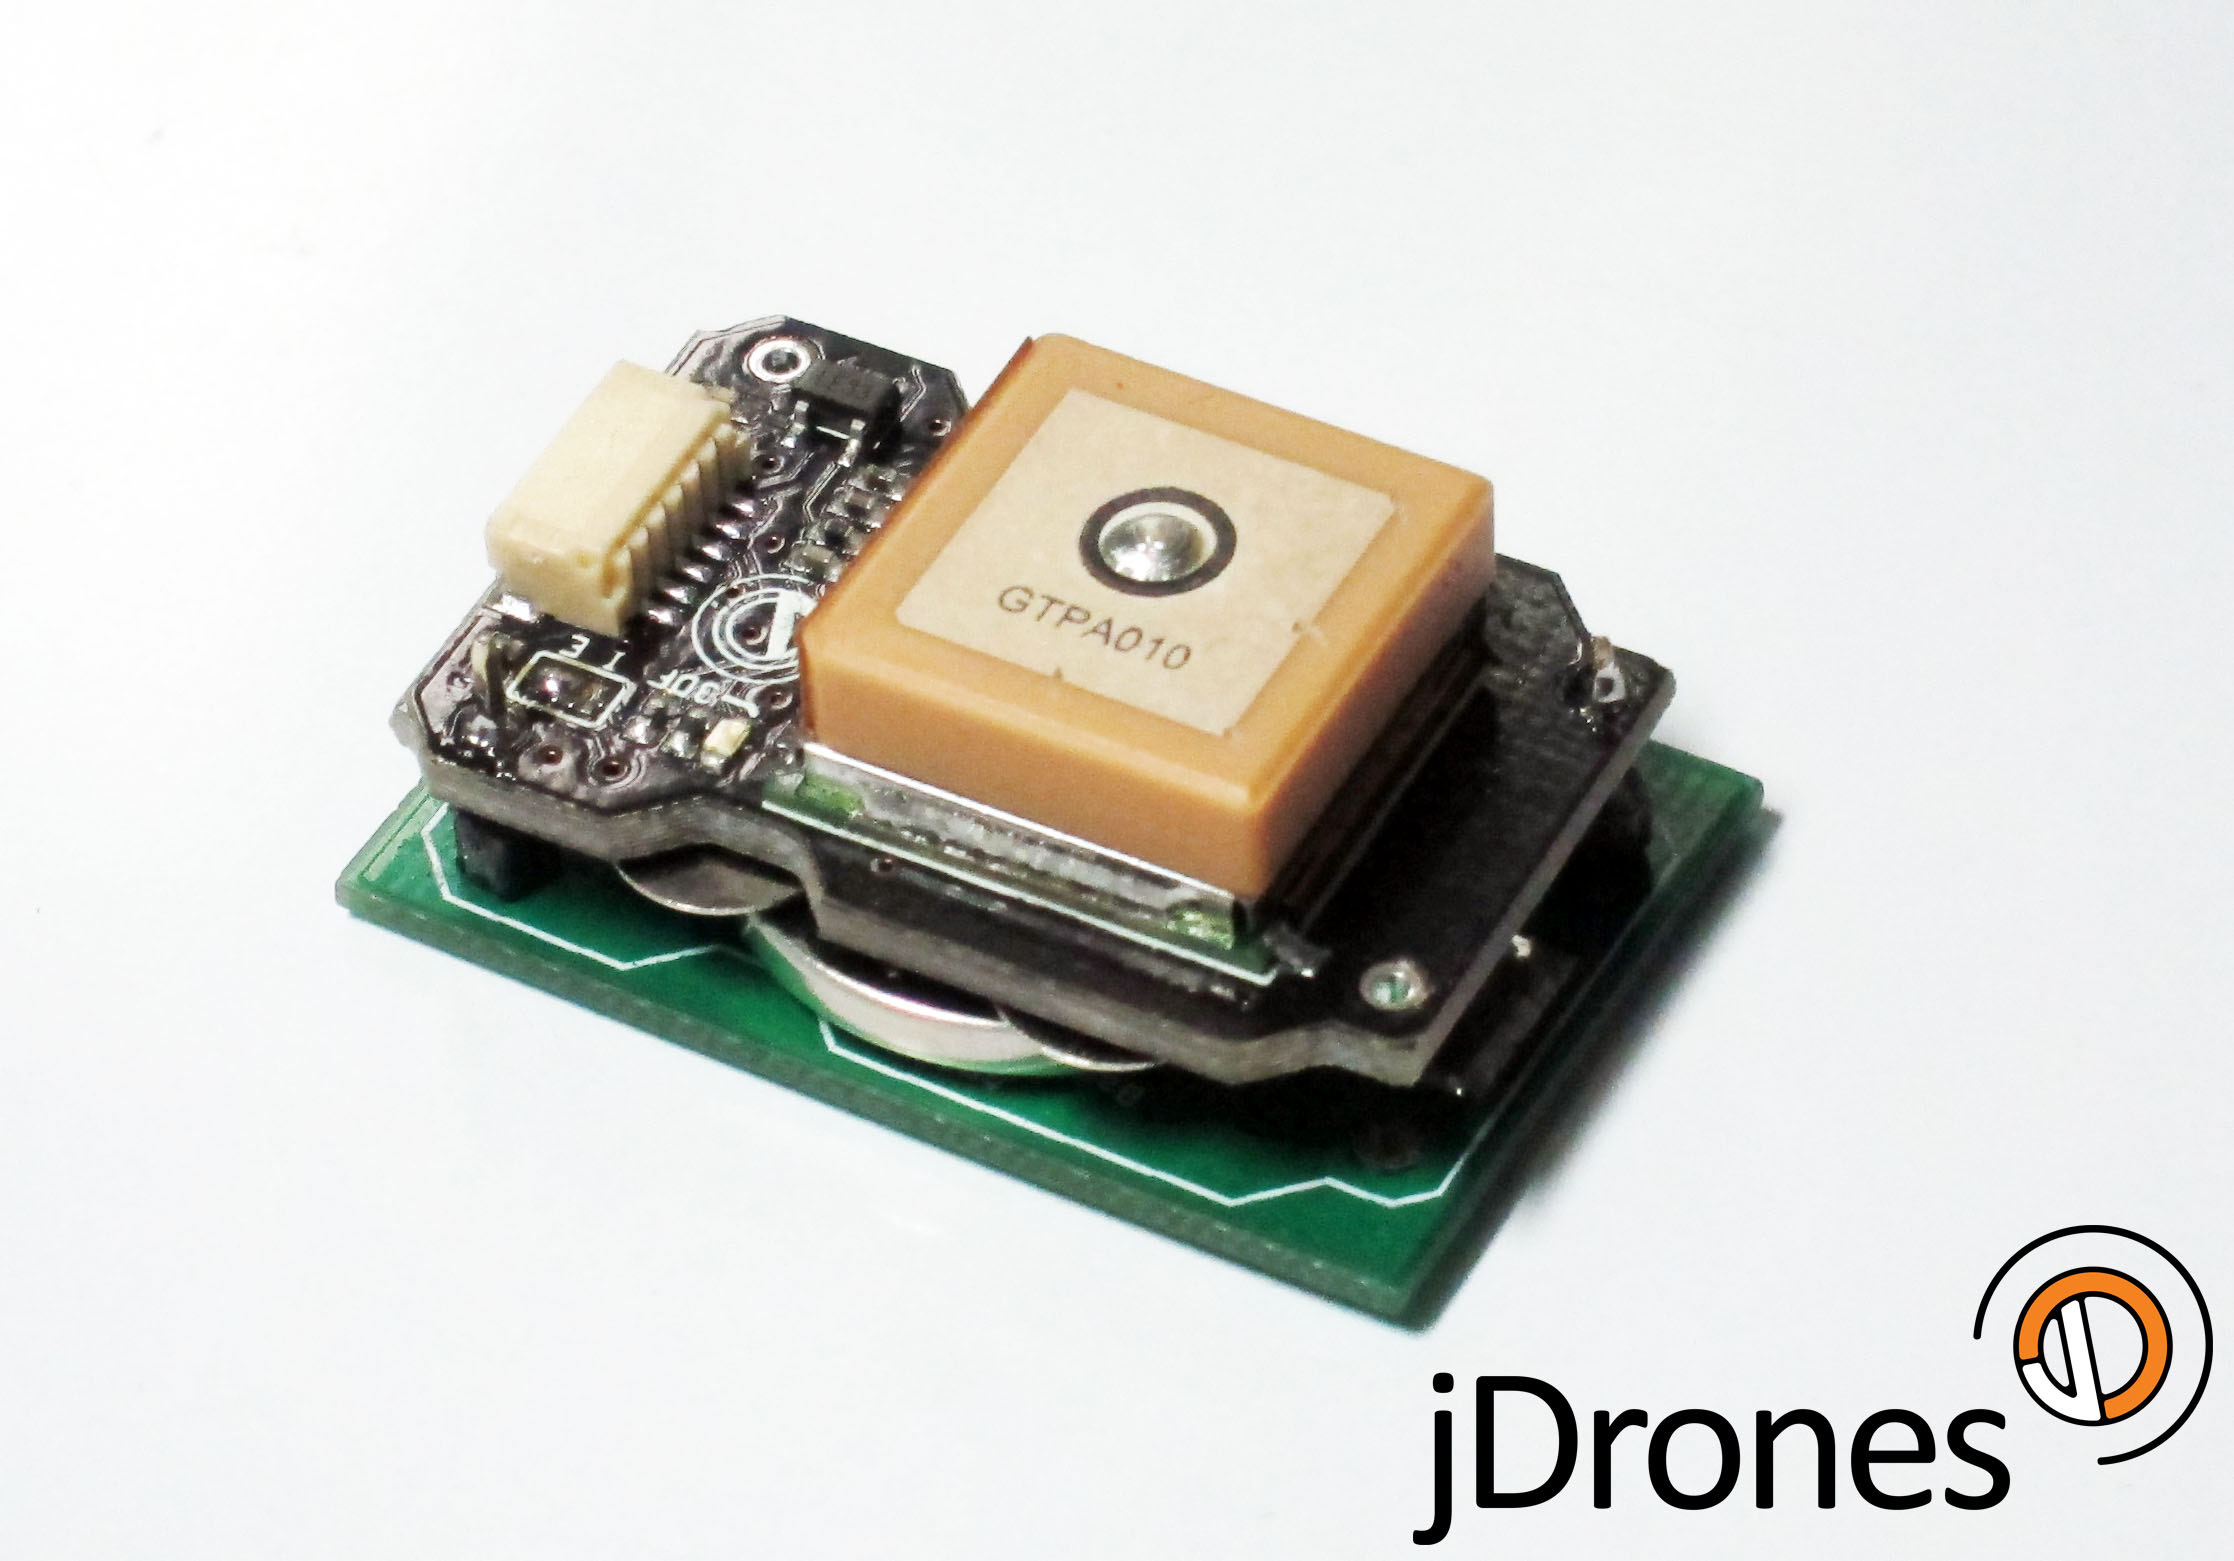
jDrones News: Upgraded MediaTEK GPS

jDrones_MediaTEK_3329_GPS.jpg?width=500

jDrones News: Upgraded MediaTEK 3329 GPS

Another exciting product update from us. Some people already have seen this new jDrones MediaTEK GPS. GPS is based on same GPS module as original DIYDrones GPS but it has some enhancements. Enhancements such as better groundplanes and optional backup battery board. Better groundplane enhances greatly to get 3D lock and also accuracy of GPS position. 

If you need even more, groundplane can be easily expanded around board. Shape of the PCB allows you fasten it easier with for example cableties. 

GPS is fully compatible with ArduPilot Mega and other boards. 

With optional backup battery board, tested 3D lock times are average of 1-5 seconds. Without battery board, initial lock times on our tests have been around 20-50 seconds. 

Get your GPS from jDrones store MediaTEK

Main board info

  • Size: 21 x 33mm
  • Weight: 7.9gr  (+5.5 gr with battery adapter and battery)
  • Internal / External jumper for selecting backup source
  • Engine: MediaTEK 3329 with patch antenna
  • Fully compatible with earlier MediaTEK GPS boards.

Backup battery board (optional)

  • Size: 21 x 33mm
  • Weight: 2.9gr (5.5gr with battery) 
  • Backup battery CR2032 3V
  • low current charging circuitry on board
  • Side load for battery

Picture below is battery board connected to main GPS board (production board is black and same shape as main board). Battery that fits on holder is normal CR2032 3V battery and you can find them from every 7-11 and other shops around the world.

Estimate lifespan for battery is 1-2 years. jDrones_MediaTEK_3329_Battery_GPS.jpg?width=300

Read more…

SmartAP Successful Flights

A week ago we made several successful flights with our own flight control system - SmartAP autopilot. At the moment Manual and Stabilize flight modes are ready. Below you can find a couple of videos. Both flight were made only in Stabilize Mode, no Altitude Hold or Position Hold activated. In the first one we checked hovering, in the second stability while ascending / descending fast. If you have any questions - feel free to ask them. More info you can find on our website http://sky-drones.com


Read more…
3D Robotics

3689461780?profile=original

FromHackaday: 

Last Christmas, [bonafide] received a WiFi enabled remote control helicopter from his employer. The heli is an interesting bit of kit, able to be controlled with an Android or iDevice. Being the good tinkerer he is, [bonafide] took a screwdriver to his Wi-Fli Bladerunner Helicopter and reengineered the toy to use an off-the-shelf wireless router.

The protocol used by the Wi-Fli helicopter is closed source, but a few people have had their hand at reverse engineering this cool toy. Instead of simply controlling the helicopter over WiFi, [bonafide] wanted to add a few unsupported features like sending images from a webcam. This isn’t supported in the toy’s firmware, so after a valiant attempt at flashing new firmware, [bonafide] decided to replace the electronics with a WiFi router.

In the stock configuration, the helicopter receives commands from an RT5350F-based WiFi module. This module communicates to the servos and motors with a serial connection. [bonafide] replaced the WiFi module with a very small router capable of running OpenWRT. The new router was easily configured to send commands to the motors, and allowed [bonafide] to add a small keychain webcam to stream video back to his desktop.

Interestingly, the makers of the WiFli helicopter, Interactive Toy Concepts, are putting out a streaming-video version of this toy next fall. The current version of the WiFli helicopter may hit the Toys ‘r Us clearance bin before that, so if you’d like your own unmanned aerial drone [bonafide]‘s may be worth looking over.

Read more…
100KM

Maplepilot : beginnings

3689461856?profile=originaljust wanted to show off a project of mine I've been working on . It uses arduino compatible 32bit development system from the very smart guys at leaflabs .I currently have a 9DOF DCM running 200Hz based on the arduIMU code .when I started this project I had a few important requirements for a reliable and responsive system.

  • An external mux/fail safe – Anytime you rely upon your CPU for RC pass through you are asking for trouble.
  • Watchdog timer – The Mars rovers have it ,why not your $900+ investment.
  • RTOS -This gives the ability to have real time responsiveness. Multiple concurrent prioritized processes and Interrupts.

as the title of the blog states this is just the beginning of what I think will be a very exciting project .

you can read more about it and get the code @ maplepilot .More then happy to help people get involved . if you want drop me a line . I have a the layout done for everything on a single board .The first prototypes will be here in about 2 weeks . I will have a few prototypes that i may be interested in passing out if anyone wants to get involved . 

also check out my techpod while your there.

Read more…

"Explorer" New twin from the makers of the Maja

3689461643?profile=original


Info from their website:
EXPLORER is the development of MAJA for a bigger UAV with more payload and shorter runway. The both motors are very powerful and quiet and gives EXPLORER many application possibilities. The used materials EPP and Coroplast exhibit a small weight and are extremely durable.

EXPLORER can be used for the following areas:

- Aerial photography
- Surveying
- Air observation
- Environmental protection

Wingspan: 220 cm
Length:     140 cm

Weight without LiPo: 2,5 kg

Wing loading: ~ 40 g / dm ²

Payload: 2,5 kg

Time of flight: ~ 1/2 h


-MADE IN GERMANY-

Basic Kit Price $374.99   

Read more…