All Posts (11086)

Sort by

Downward facing camera busted

marcy2_64.jpg


So the 1st flight with some vision hits happened.


 vision27.jpg


Blue becomes visible 1st.

vision28.jpg


Frame is missed, for no reason.

vision29.jpg


vision30.png


The few position data points seemed where they should be, but position sensing wasn't fast enough & she flew right into the ceiling.  Not until the last 4 data points did the autopilot detect a finished takeoff climb.

The general idea is the camera needs a complete view of the axis of rotation, so it can have continuous coverage of the red blob during takeoff.  If it can't do that, it needs to get position from a partially obscured red blob, so it can have more data points.  But if it points straight down, it can't detect tilt during takeoff.

marcy2_51.jpg


marcy2_52.jpg


Then came more attempts to get the camera to point down more & withstand crashes.  The wifi dongle seems well protected.  It needs to be as far from the wood as possible, for any reception.

The idea of sonar for altitude & a horizontal camera for position continues to haunt. Exactly how to derive position from the horizontal camera is still unknown.  Feature detection is impossible on it.


Ground based vision gave Marcy 1 pretty much 10Hz updates.  She spun around at 4Hz, but the incomplete revolutions still seemed to have extra data.

A few more crashes have painted a picture where 1 update per revolution, with many updates glitched out & therefore velocity data based on changing time bases, isn't enough.  Marcy 1 needed many high quality updates to work.  A fisheye lens pointed straight down seems the only way.

marcy2_53.jpg


marcy2_54.jpg


marcy2_55.jpg


marcy2_56.jpg


marcy2_57.jpg


marcy2_58.jpg


marcy2_59.jpg


The downward facing camera is slowly rebuilt.  A fisheye lens would solve everything.  Fish eye lenses can physically be produced, but aren't made in enough quantities to be affordable.  So because of a manufacturing technicality, more exotic measures must be tried.

marcy2_60.jpg


marcy2_61.jpg


marcy2_62.jpg


marcy2_63.jpg


Downward facing attempts continue.  This 1 had more in view, but the camera has a small field of view.

This is quite a heavy attachment, but any payload on it is going to be relatively level for any coning angle.  The options are stuffing it to give it the last angle change, moving mass below it to force it up, or making it rigid.  All this with a field of view which is too narrow.

marcy2_64.jpg


marcy2_65.jpg


Then there's going back to ground based vision, probably feasible with the latest blob detection, but not for any product.  Requiring a target on the floor isn't sellable either, but it was a step towards an all in one system.

A horizontal firing camera of higher resolution & downward firing sonar for altitude might do it, with this horizontal platform.  The camera would have to detect optical flow of vertical objects.


marcy2_66.jpg


marcy2_67.jpg


vision31.jpg


That was as close as anything can be expected to get.  At 2 meters in altitude, there are only 2 target widths of horizontal range.  It's either this & 25Hz position data or diagonally facing & 4Hz position data.

Any vision system that tracks a single object is going to need a gimballed camera.  That's why, even with modern object detecting algorithms, aircraft still only use optical flow.


So aircraft video over wifi was heroic, but only showed it's impractical for navigation.  Pointing sideways, the detail isn't enough to detect motion.  Pointing down, either the field of view is too small or the update rate is too slow.  Even though the rotation rate always created an update rate of 4hz, there was more information in the incomplete rotations.

Marcy 2 needs a takeoff platform, so all roads lead to a vertical facing camera pointing up from the takeoff platform.  It's connected by hard USB.  A 2nd camera on the aircraft points sideways & sends video by wifi.  As a simple 4fps video downlink, it would be better done over bluetooth.

It's a lot of wires to connect.  It's not an all in one system, but having both cameras on the aircraft still required a ground target which was bulkier than a ground camera.  Altitude information pointing straight up is not as accurate as pointing sideways.

  1. Thumbnail6:43

    GoPro Digital Hero 3 Disassembly


There's exactly 1 teardown of a gopro hero 3, revealing the wide angle lens

gopro.jpg


is a box screwed down over the sensor, like a webcam.

 Another teardown of this thing
cam07.jpg


revealed a compound lens, like the TCM8230MD.

cam08.jpg


No part number.

cam09.jpg
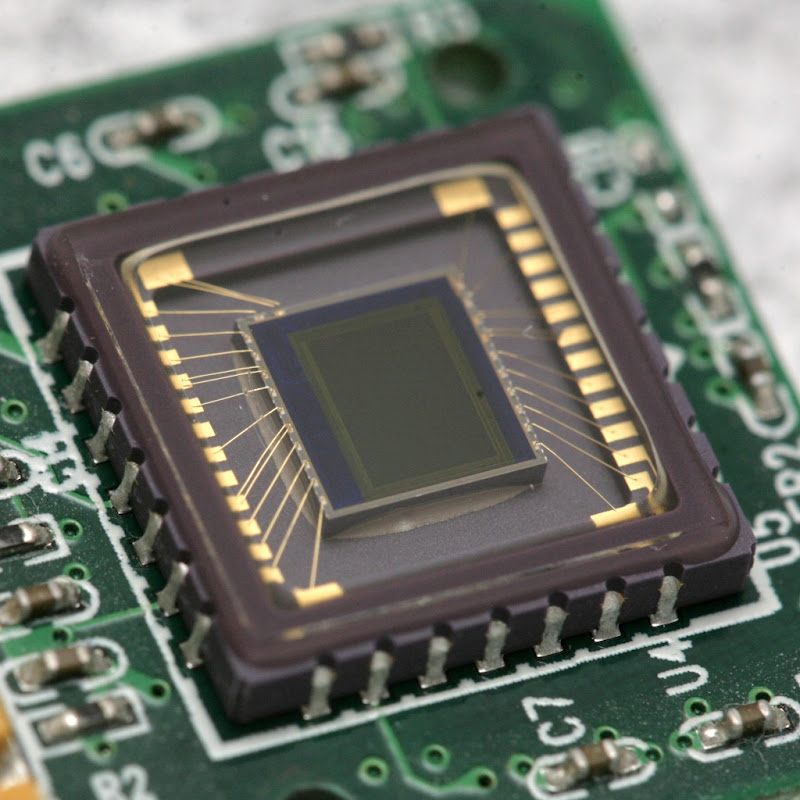
  Another look at the omnivision sensor.


So the keyword that gets lenses to show up is "board camera lens".  Wide angles don't become possible until the sensor is 1/3".

http://www.vitekcctv.com

is the only supplier.  The keyword used to look up cheap, zoomless, fixed focus cams like the gopro is "board camera."

cam10.jpg


A $30 wide angle adapter gets it wider.


peephole03.jpg


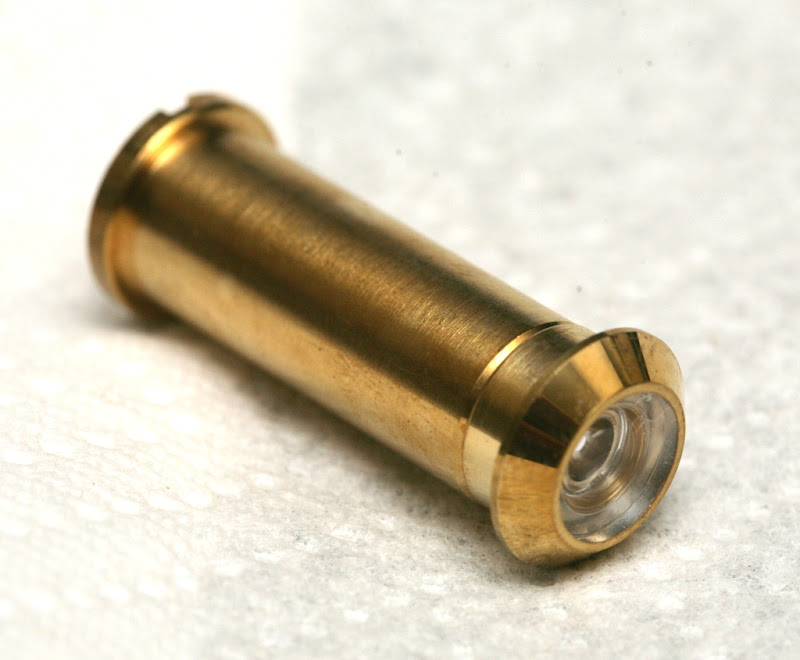
Finally, from goo tube wide angle lens lore, we have the peephole.


peephole04.jpg


It has 2 lens elements.  It splits in 2.

peephole01.jpg


 revealing a useless image.

peephole07.jpg


peephole06.jpg


peephole05.jpg


The front element can be ground off.

peephole02.jpg


Revealing no image.


Forget about extracting the 2 lens elements & making a custom tube.  Even when you're done grinding, they're glued in there.


Position sensing from the launch pad is the new ideal.  Attitude leveling for takeoff would be done by a side firing, onboard camera.  The problem of 2 onboard cameras goes away.

Then the problem of position sensing in daylight returns.  Should a cable connect to the launch pad?  Should the launch pad & aircraft both be on wifi?  Should the aircraft use proprietary radio to talk to the launch pad & the launch pad use a cable or wifi?  Should the launch pad use a stock webcam with a USB multiplexer or a custom cam?  What kind of servos should it use?

There's docking a phone to the launch pad to control it & having another remote control, like the Swivl.  There's doing all the navigation processing on the launch pad, having a proprietary radio from the launch pad to the aircraft & wifi from the aircraft to the phone.


marcy2_68.jpg


A few hours reinstalling LED markers returned the reality of colored LEDs saturating the sensor to white.  Then came the realization that Vicon uses reflective markers to keep the sensor from saturating white.  To illuminate the markers, it has a very expensive & labor intensive ring of IR LEDs.

An attempt to light the markers with camera LEDs failed.  Obviously the Vicon cameras can't sense anything too close.  A dreaded infrared camera with ring of LEDs draws nearer.


The LED rearranging yielded this.

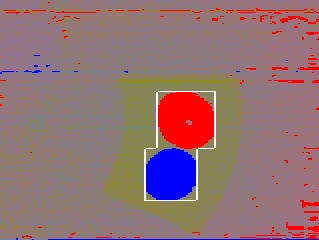
vision32.jpg


Which the computer sees as

vision33.jpg


or

vision34.jpg


depending on camera exposure.  It's hard to see a future in the webcam business.

vision35.jpg


With minimum gain on the webcam & some chroma keying, an algorithm starts to emerge, where the intersections of red, white, & blue are plotted & averaged to give a very accurate location of the marker.


Let's get clear that I did dream about trying to get into Aerovironment.  It turned into the hippy colony from Martha Marcy May Marlene.  The creepy skinny guy was the boss.  He seemed normal, then turned into a crazy preacher of some kind, conjuring up super powers. A crazy dog came out from a wall.  Then there were crazy zombies which mutated into other forms of life.  I didn't care & still wanted the job, hoping the craziness didn't happen during business hours.
3689464139?profile=original
Anyways, the point is 1 of the mane drivers of open source work is the saying "If I can't have a job, no-one can."  You may not realize it, but the simplest answer is always right.
3689464139?profile=original
You think a college student in Finland, a country like US, with total unemployment in 1990, wasn't at least partly driven by vengence because he once sent a resume to work on Minix & got rejected?  I say vengence over denied opportunities has always been 99% of the motivation behind free software, even more than fame or learning.
3689464139?profile=original
It has always been the case that the most valuable work is not what anyone is hiring for.  In 2000, the most valuable work was in video software, yet all the jobs were in e-commerce software.  They specifically wanted to see e-commerce on the resume or you were out.
3689464139?profile=original


A lot of college students then wrote free video editors.  Our motto was if we couldn't get jobs doing it, we'd put everyone out of business who did.  Write the software we did & out of business the corporations went.
3689464139?profile=original
It feels the same way, today.  All the money seems to be in physical computing that combines software & hardware.  It's obvious that you can't make money selling pure software, yet all the companies are still in this 20 year old model of dividing jobs into specifically software or specifically hardware.  If you're not specifically doing 1 thing, you're out.
3689464139?profile=original

So the mission has been if we can't make money because we don't fit the cookie cutter model of pure software engineers with exactly the right 8 year degree in reverse polish turkey notation, produce all the stuff for free until no-one can make money.
3689464139?profile=original

The job market today isn't just bad, the people who are getting jobs are clueless.  It's 1 of those times when it's so bad, people with jobs are more afraid of getting pushed out than increasing production, so they're only hiring lower levels of talent.  The incompetent workforce is begetting greater incompetence.

3689464139?profile=original


If you've got 100 million people whose cost of producing anything is $0 & who are being denied opportunities not because of talent but simply because of fear, 0 is going to be the fair market value for anything produced.  No business will be left standing.


Read more…

40-150960_tcm51-166329.png

Information taked from the webpage of dutch ministry of defense.

It basically says that only aircrafts that carry people (regular air traffic), people inside are allowed to make pictures,
and also military aircrafts are excepted from the rule. Any other type of aircraft  (including a drone) needs to have
permit to be able to make pictures or record videos over Dutch territories from the sky.

Read more…
Moderator

2007-bugtop.jpg

Who is this person?

At last year’s Paris Air Show, some of the hottest aircraft were the autonomous unmanned helicopters—a few of them small enough to carry in one hand—that would allow military buyers to put a camera in the sky anywhere, anytime. Manufactured by major defense contractors, and ranging in design from a single-bladed camcopter to four-bladed multicopters, these drones were being sold as the future of warfare at prices in the tens to hundreds of thousands of dollars.


In May, at a different trade show, similar aircraft were once again the most buzzed-about items on display. But this wasn’t another exhibition of military hardware; instead, it was the Hobby Expo China in Beijing, where Chinese manufacturers demo their newest and coolest toys. Companies like Shenzhen-based DJI Innovations are selling drones with the same capability as the military ones, sometimes for less than $1,000. These Chinese firms, in turn, are competing with even cheaper drones created by amateurs around the world, who share their designs for free in communities online. It’s safe to say that drones are the first technology in history where the toy industry and hobbyists are beating the military-industrial complex at its own game.


http://www.wired.com/dangerroom/2012/06/ff_drones/all/

Read more…
Moderator

Illegal UAV Operators More Exposed

Today the Australian Civil Aviation Safety Authority (CASA) published for the first time a list of certified UAV operators.  According to Brad Mason of Australian Certified UAV Operators Inc, this was a result of 2 years of lobbying.

3689464120?profile=originalhttp://www.casa.gov.au/scripts/nc.dll?WCMS:STANDARD::pc=PC_100959

There are many cases of uncertified operators operating UAVs without the required UAV Operator Certificate.  In some cases, customers were misled into believing that these uncertified operators did possess an operator certificate. 

Until now it was difficult for consumers to determine which operators were operating legally or illegally.  This public register leaves illegal operators much more exposed and easily identifiable.

Read more…

More Bixler Mods

3689464168?profile=original

A couple of technical and personal delays are going to push out my Bixler's first flight, but I thought I'd share a couple of pictures.

Mike Pursifull suggested increasing rudder area, which seems like a reasonable thing to do.  I used a cardboard photo mailer and glued the edge together with white glue, and used silicone calk to glue it to the rudder.  The result is light and super stiff and about doubles the rudder area.  I used calk hoping it'd be easier to undo if I want to try something else.


Here are the two halves with a notch for the control horn:

3689464036?profile=original

Here's the extension while it's installed:

3689464168?profile=original

I also implemented the rubber band and Command hook idea:

3689464196?profile=originalI'm not very satisfied with this solution.  It was too fiddly to install and I'm not sure I have enough tension.


Feedback is welcome.

I also had a minor disaster; one of the crummy aileron clevises broke when I was adjusting it.  I'd like to replace it with something better.  Does anyone have a good option to replace these?  My local hobby store only has larger ones.

Read more…

3689464265?profile=original

I find the tab-delimited waypoint list files used in mavlink to be hard to read, so I added Protocol Buffer text format to the formats that mavwp.py can read and write.

I still think it can be improved to be even easier to read, but here's my current version of the mission defined in ardupilot-mega/Tools/autotest/mission2.txt:

QGC WPL PB 110
defaults {
  # Default coordinate frame for this mission.
  frame: FRAME_GLOBAL_RELATIVE_ALT
}
waypoint {
  command: CMD_NAV_WAYPOINT
  x: -35.362881
  y: 149.165222
  z: 582.0
}
waypoint {
  command: CMD_NAV_TAKEOFF
  x: -35.362881
  y: 149.165222
  z: 20.0
}
waypoint {
  command: CMD_NAV_WAYPOINT
  param2: 3.0
  x: -35.363949
  y: 149.164151
  z: 20.0
}
waypoint {
  command: CMD_CONDITION_YAW
  param1: 640.0
  param2: 20.0
  param3: 1.0
  param4: 1.0
}
waypoint {
  command: CMD_NAV_LOITER_TIME
  param1: 35.0
  param4: 1.0
  x: 0.0
  y: 0.0
  z: 20.0
}
waypoint {
  command: CMD_NAV_WAYPOINT
  param2: 3.0
  x: -35.363287
  y: 149.164958
  z: 20.0
}
waypoint {
  command: CMD_NAV_WAYPOINT
  param2: 3.0
  x: -35.364865
  y: 149.164952
  z: 20.0
}
waypoint {
  command: CMD_CONDITION_DISTANCE
  param1: 100.0
}
waypoint {
  command: CMD_CONDITION_CHANGE_ALT
  z: 40.0
}
waypoint {
  command: CMD_NAV_WAYPOINT
  param2: 3.0
  x: -35.363165
  y: 149.163905
  z: 20.0
}
waypoint {
  command: CMD_NAV_WAYPOINT
  param2: 3.0
  x: -35.363611
  y: 149.163583
  z: 20.0
}
waypoint {
  command: CMD_DO_JUMP 
  param1: 11.0
  param2: 3.0
}
waypoint {
  command: CMD_NAV_RETURN_TO_LAUNCH
}
waypoint {
  command: CMD_NAV_LAND
}

Read more…
Developer

Arducopter Sim Update

3689460971?profile=original


I just wanted to let everyone know I've pushed an update to the SIM. What's new:

Upped iteration limit so it will run indefinitely. 

Stand alone executables for Mac and Windows.

A new "lead" filter to remove GPS latency leading to improved accuracy in AUTO modes and loiter.(coming to main code soon.)

Inertia nav - you must up the rate_P gains by 3x to 4x to see a difference.

Added Sonar.

Lot's of under the hood enhancements.

Arducopter Sim still lives at http://www.jasonshort.com/


Read more…

Bot Thoughts / Data Bus - Sparkfun AVC 2012

2012_sf_avc_094.jpg

I had a heck of a time pulling it together in the final days before the competition with a nerve-wrecking mix of failure and triumph. Ah good times! :D

Summary is... I kept running into troubles with heading estimation and heading control in the days prior and things were looking mighty grim. I implemented a few changes and Thursday night went down to SFE for covert, cover-of-darkness testing. To my elation, the fixes worked beautifully and the robot consistently held to its path at faster and faster speeds. I quit while I was ahead with a top speed of 9m/s and time around the building of about 36 seconds.


On Saturday I was feeling pretty good about things, but nervous as all get-out. To my horror, on the first run, the robot did an exact repeat of its embarrasing 2011 performance: it veered right and crashed into the SFE building! I implemented a "fix" for heat 2, discovered a problem with one of the wheel encoders, hammered the front bumper back into shape, and... the robot took off, turned left and headed for the crowd! What a disappointment after the towering success I had Thursday night. I undid my "fix", took the advice of a wiser soul than me (Team Daisy Chain, Ted), and ran the robot slow off the ramp and put the hammer down after a second... I sacrificed myself to save my robot...

2012_sf_avc_089.jpg

And was overjoyed to witness the little bus shoot out from the 4th turn, head for the finish line at top speed and ...

2012_sf_avc_103.jpg

I was just happy the thing finally made it around like it did before. Then in addition to proffering of medical supplies for my ankle, I was informed Data Bus time put it ... in 3rd place! I would've danced up and down... but for the ankle :D  Very very happy. 


Congrats to team 0x27 for 1st, team Minuteman for 2nd not to mention brilliant MacGuyver style repair action! And congrats to all who competed: no small feat, whether your robot started up, crashed, finished, whatever. And humongo kudos to Sparkfun for a truly awesome event, best every by far!


Results

TeamRaw(s)Official
0x2732.022.02
Minuteman39.469.46
Data Bus37.1637.16
Read more…

3689464007?profile=originalI have written a small Android-Widget to easily have an eye on the current solar activity to be aware of possible GPS-Problems when there is a sun-storm. You can get it on Google-Play for free:

- https://play.google.com/store/apps/details?id=org.ligi.solar_activity_monitor

3689463882?profile=original

the code is on github:
- https://github.com/ligi/Solar-Activity-Monitor

Enjoy and have a safe flight!


3689464015?profile=original

3689463995?profile=original

Read more…

24723.jpgRolf Bakke, designer of the widely used KK multi copter boards, has done it again. An improvement in many ways to the original KK board is the V2 version that is available now from Hobbyking.

The original KK gyro system has had had an update to an incredibly sensitive dual chip 3-axis gyro and an additional 3 axis accelerometer system. These two items must make your quad more stable than ever. Other changes are an Atmel Mega324PA 8-bit AVR RISC-based microcontroller with 32k of memory, two extra motor channels and a piezo buzzer for audio warnings.


The software that is already loaded on the processors includes a menu which makes it easy to configure the controller for your type of multi rotor. The following models are already configured:

Dualcopter
Tricopter
Y6
Quadcopter +
Quadcopter X
Hexcopter +
Hexcopter X
Octocopter +
Octocopter X
X8 +
X8 X
H8
H6
V8
V6
Aero 1S Aileron
Aero 2S Aileron
Flying Wing
Singlecopter 2M 2S
Singlecopter 1M 4S


The menu is displayed on the LCD and you can navigate through the menu with the buttons below it. This allows you to select your aircraft type, change motor layout/direction, calibrate the esc's and more.

For more information check the Hobbyking product page here: http://www.hobbyking.com/hobbyking/store/uh_viewitem.asp?idproduct=24723&aff=5361

Read more…

Minuteman AVC 2012

3689463395?profile=original
Minuteman
This is another write-up of my Sparkfun AVC experience. This year I worked closely with Roadrunner, who ran a similar vehicle and the same code. We collaborated using google code and SVN, which made us feel like "real" programmers.
3689463417?profile=original
Minuteman's twin, Roadrunner.
Minuteman intro
Minuteman uses a dead reckoning navigation system with a gyro for direction, and an optical encoder for distance. The car starts at a known position and direction which is designated as coordinates (0,0) and angle 0. As the car moves, the direction and distance are used to compute the new position approximately every inch. This process is all interrupt-driven, so the position is computed, even when the car is under manual control.

Programming the car is done by manually driving it around a course and recording waypoints (4 waypoints for a square course, for example). To re-run the course, it is set back at the original starting position (and angle), and set to auto-mode.  The car uses a proportional steering algorithm to steer to the waypoints with open-loop throttle control. If the car doesn’t hit the waypoints exactly as programmed, the waypoints may be edited on a spreadsheet for fine-tuning. Generally, if allowed to temperature-stabilize, it is very repeatable from run to run.

Ardupilot
I chose an ardupilot (original) for this project. It’s basically an arduino with a multiplexer and attiny chip for switching between manual and auto modes. It is powered directly from the ESC and has worked like a real champ throughout much testing and countless crashes.
3689463506?profile=original
Ardupilot--the brains

Gyro
The gyro is an Analog Devices ADXRS613, single axis, analog output,  from Sparkfun. It is sampled at 19.4 kHz by a free-running ADC on the ardupilot. My testing has shown that the null value shifts linearly with temperature, so letting the car temperature-stabilize for 5 or 10 minutes before running is important. Once stabilized, the drift over 1 minute is negligible. The gyro rate is very stable over the temperature range of interest, and is assumed to be linear over all rates (within specification).

Encoder
The encoder is attached to the transmission input shaft. It’s made with parts from an old computer mouse, and has 8 divisions per revolution. The signal is very clean, and is able to drive an interrupt on the ardupilot with no signal conditioning. With the light shield in place, I believe it’s completely immune to noise.
3689463477?profile=original3689463437?profile=original Optical encoder, on transmission
Pricetag
Losi XXX roller: $60
brushless ESC and motor: $60
Gyro: $25
Ardupilot: $25
Total: $170

AVC 2012
On Friday I went with RR to the sparkfun building for testing. There were probably 10 other teams there doing the same. Testing went well, and I was able to establish some waypoints for the corners and some possible barrel locations. My best lap times were around 40 sec.The car can go much faster, but goes out of sight quickly and would be destroyed by a curb--so I didn't want to take any chances. 

On the day of the race we got to sparkfun at about 7:45 and started testing. My first problem was that a food truck had parked in front of the electric pole I had been sighting the car to (have to set the initial angle for dead reckoning). I re-sighted on a tree, which was later covered by another food truck. I tried not to take it personally :)
3689463490?profile=original
I use a scope for setting the initial angle

First Heat
After setting up my waypoints for the hoop, I did a bit more testing, and ran an entire loop. Then I had to put together a complete course and adjust some waypoint locations, however the testing period was over. I made the adjustments in the spreadsheet and uploaded it to the car. I had not tested the full programmed course, so I crossed my fingers, sighted-in the initial angle, calibrated the gyro, and sent it off at the starting "gun".  To my surprise and relief, all the adjustments were right on, and the car navigated perfectly. My time was about 50 seconds - 30 = 20 seconds (I think). This was faster than any previous official time, so just like last year I held the course record, at least for a brief time. I maintained my first place throughout the heat, until round 8 when team 0x27 clocked a very fast time by plowing straight through barrels and through the hoop. It was a huge 1:5 scale car and had no problem swatting the barrels aside. I believe their time, with hoop deduction, was 6 seconds. 
3689463523?profile=original Start of heat 1
Second Heat
The second round, I was feeling good. I would have to turn the speed up very high to beat 0x27,  and I wasn’t ready to do that yet. So, instead I cranked it up to 40% (1700 us) which is still pretty fast. I changed nothing else, including the waypoints. I lined it up, and it took off. As it rounded the first turn and headed to the hoop, I could tell something was a little off. It was a tad to the right and headed very close to a barrel. As it went by, the front right tire nicked the barrel, breaking the steering linkage. My initial reaction was that the run was over, and I was about to hit the kill switch. I let it go, though, just out of curiosity. The bump had steered the car a bit to the left, and it went directly through the hoop. As it continued to the second turn I had a glimmer of hope that it may somehow still be able to steer. All the turns were right-hand, which favored the left (and unbroken) wheel. As it shakily rounded the turn I started to smile. It rounded the third turn a bit off course, but close enough to keep going. With dead reckoning, any small course errors near the beginning can mean total failure the further you go. It headed down the straightaway, going wide left, and nearing the boundary poles. It stayed in, though and headed around the final turn. By this point it was far ahead of me, and I didn’t get to see it go for the finish line. I counted off a few seconds, trying to estimate when it would cross the finish line, then hit the kill switch. I could tell from the announcements and applause that it must have made it! I jogged around the corner to see it lying about ten feet past the finish line, one wheel folded up. This point hadn’t gone unnoticed, by the announcer, who was graciously pointing it out to the crowd. As my time came back, I had even more reason to smile. It had completed the course, with a broken steering linkage, in 9.4 seconds (including bonus). I was now only 5 seconds outside of first!

Stepping it up
Now my attention was turned to fixing the steering. I didn't have a replacement for the part that had broken, but only the mounting hole had broken. Fortunately, there were other mounting holes available, so the fix was quick. Now, I waited for Team 0x27. I need to see just how fast I might have to go in the final round. As it turns out, they bested their previous time, and were now at 2 seconds. So, this meant that it was time to pull out all the stops. Go for broke. I felt my second place was pretty secure (only to find out later that it wasn’t). My car, with its Velineon brushless motor and lipo battery is capable of some insanely fast speeds. So I decided to crank it up to 100% throttle. I had never tested it at anything close to this speed. If it made it around without crashing, it would probably be well under 30 seconds--remember, it had just done 40 seconds (unadjusted) at 40% throttle and a broken wheel. So, I made the changes, and decided to do a bit of testing.

Disaster strikes!
As no testing is allowed on the course, I went to a neighboring parking lot to test it. There wasn’t as much space there, but I really wanted to see how it would do in a straight line, and around a single turn. I pointed the car straight down a corridor, and let her rip. It took off like a banshee, the slipper clutch screaming wildly to keep the front wheels on the ground. Instantly, it veers at about a 20 degree angle (doh my first waypoint was at an angle!) It’s screaming along, headed perpendicular to a curb, and still picking up speed. I panick, fumbling for the kill switch, but it’s too late. The car slams into the curb with such force that the entire steering assembly is severed. I see the main chassis fly in one direction, and the steering assembly in another. I know immediately that my day is over. I’m happy that I did well for two rounds, but frustrated at my stupidity. This is exactly why I never tested it at these speeds. Failures are catastrophic.

Assessing the damage 
Cursing myself, I go pick up the pieces. The brushless controller, with its huge heat sink has separated in 3 parts. The LCD has broken from its mounting and separated from the cable. The car is lifeless. The chassis is sheared in two. I take it back to the pit to more closely assess the condition. I plug everything back together and flip the switch. It turns on. I pull the trigger, and the wheels spin. The steering servo is OK also. Hmmm. I put the two pieces of the chassis together--it’s a pretty clean break.
3689463554?profile=originalSpeed control in bad shape

MacGyver time
It’s announced that the next heat will start in about 45 min. A crazy idea starts to form. I need some epoxy, and some kind of stiff strut. I raid Roadrunner’s tool kit for some hex wrenches. I go in search of some epoxy, and one of the aero guys lends me a bit. Meanwhile sparkfun goes looking for some as well. I apply some of the epoxy to the hex keys and hold them in place on the bottom of the chassis. My son, Eric helps with the application, while I hold it together. Sparkfun comes to the rescue with a larger tube, and we start liberally applying the epoxy. Within about about 20 minutes it’s firm enough to stay together on its own weight, but still feels much too soft to run on. On the suggestion of a fellow competitor, I borrow a head gun, hoping to accelerate the curing process. It’s 5 min. epoxy, but that seems awfully optimistic.
3689463541?profile=original
Epoxy patch, hex keys and all

Heat 3
The first round of heat 3 starts, and I’m done with the heat gun. The epoxy still isn’t hard to the touch, but it’s starting to feel pretty strong. I put it on the ground a run it around a bit. Seems OK. I can’t believe I’m about to race after what I had just witnessed 45 minutes ago. I get everything set for the run. My heat comes up, and I line up next to the monster truck (a stampede). The race starts, and my car jogs off the line for a few feet. See, with the speed dialed up so high, I didn’t want it to jump the start line too much, so I had it go out slowly for the first few feet before accelerating. This is a deviation from the other two runs, where the car immediately jumped out to the lead and stayed there. This time, though, the monster truck gets a few feet out in front, and when my car finally decides to take off, it angles to the first waypoint and slams aggressively into the back of the monster truck, flipping them both over. My run is over, and I have unfortunately ruined the other car’s run as well. Surprisingly, the epoxy holds, and the chassis is fine.
3689463567?profile=original
Pile-up on starting line

Data Bus
Now, I wait for the other heats, feeling confident that I’ve got 2nd place in the bag. My most probable competitor, Roadrunner, has an amazing heat which involves weaving around multiple barrels, through the hoop, breaking a wheel, and ultimately crashing out on the 3rd turn. He was on pace to beat me. The last heat features team 0x27 which inexplicably has a glitch at the starting line, and doesn’t make it to the first turn. GPS jamming, they thought (?) I see data bus head out around the first turn, not thinking much of it. When it flies around the last turn about 30 seconds later, and catches some major air crossing the finish line, I have flashbacks to the previous year when I had been beaten in the very last heat. Fortunately for me, data bus missed the hoop--his 37 second lap time would have torpedoed me. I’m lucky for once, I guess.
3689463658?profile=original
Data Bus, catching air

Mano a Mano
As a final competition, just for fun, I am asked if I want to go head to head with team 0x27, and I accept. We both go to line-up, but realize that we want the same starting position. We separate the cars by about a foot, my sleek and sporty Losi XXX next to the 1:5 scale behemoth. I’m assured that the proximity won’t be a problem, since team 0x27’s car will be gone before minuteman has a chance to get in the way. The race starts, and I smile when minuteman gets out to the first corner well ahead of the other car. Unfortunately, that’s where the fun ends.

I have never tested minuteman to go all-out. It’s just too fast. Under manual control I have briefly taken it to full throttle, and any small twitches of the steering usually result in a heinous roll that makes me wonder what I’ve destroyed. My code is a little better than that, though and knows to apply brakes when approaching a waypoint. The braking level has been set to not cause skidding, but that may not apply at really high speeds. As the car approaches the first turn, it applies brakes, fishtails a bit, and swerves, causing a rollover. When the steering null point is off, minuteman tends to swerve at the last moment to hit a waypoint. The previous crash and re-attachment of the front end had resulted in a change in the steering null, as well as the hard braking at high speed was a recipe for failure.
3689463616?profile=originalGoliath 1 - David 0

The Winners
Team 0x27 finished the course in an (unofficial) record time of 27 seconds, Their car did amazingly well, and was easily the most robust. The huge 1:5 scale size allowed it to plow through barrels and glide over potholes with relative impunity. They had worked on obstacle avoidance software, but it was apparently un-needed and not used. They benefitted from good programmers, financial support from sponsors, and top notch navigation equipment not available to most hobby enthusiasts. Their GPS unit was an industrial-grade Hemisphere, the kind of equipment that isn’t listed with a price, just a “contact us”. It has a 20Hz update rate, and didn’t seem to have any trouble navigating on the side of the building where most GPS’s get lost. In chatting with their lead programmer, it sounds like their algorithms were very robust, and they apparently had about 3000 lines of code. It was an impressive project all around.

Next year
It appears now that vehicles will be going fast enough that an average “basher” has no chance of winning. Stampede? Grasshopper? Emaxx? electric wheelchair?  All of these will likely be too ponderous to navigate turns at 20+ mph. I think you will need a well-tuned race car to take the top spot. Fortunately for me, my Losi XXX already fits that bill. It would be nice to have a 1:5 scale brushless monster, but that’s not in my budget. Maybe it’s time to start looking for a sponsor.

Minuteman is set-up for a dirt track with jumps and washboards. This means the suspension is plush, and tends to roll when cornering at high speed. To counter this, I’ll lower the suspension, using shock spacers, and stiffen it up with different springs and more viscous oil. I’ll play with the toe and camber and hopefully end up with a car that zips through the turns on pavement. I considered going with a road-specific car, maybe AWD. With the rough conditions of the sparkfun parking lot, though, I guess I’ll stick with the Losi.

On the software side, there isn’t much to do. I’ll probably add in some cross-track correction, and smarter speed management (closed loop). Maybe at some point I’ll play around with object detection. I’m thinking opencv on an android or something. I’d also like to be able to edit waypoints over bluetooth, using my android. It’s hard to plan too much without knowing if Sparkfun will decide to drastically change the rules. We’ll just have to wait and see.

Thanks
And finally, I’d like to thank Sparkfun for making it all happen. From the organizers, to the volunteers, the guy who found some epoxy for me, and the nice lady trying to interview socially-awkward engineers about their nerdy projects. The cool announcer, the race director, all the guys that loaded and unloaded heavy equipment. You’re all awesome!
Read more…

"T Drone "Power Plant

3689463707?profile=original

Hi guys I decided to make the "T Drone an EDF and if it doesn't fly? well ? I will suck it up and maby try a glow engine on a pylon .I got a 80 mm  Delta 32 EDF out of a Habu  The brochure says  in a static lab test it puts out 5.4 pounds of thrust and a lab test in a Habu 4.8 pounds of thrust . I don't plan on zipping all over the sky like the guys with the jets do even though I will be the same weight . My plane has a very efficient high lift high aspect ratio air foil it carrys the cord right to the wing tip with no taper and with the wind shear coming over the bank here once I get to altitude I can pretty well shut the motor off and glide he whole time l like I do with the radian pro now that I "committed "on a power plant the only decision I have to make is should I put it in a streamlined pod on top of the wing? Or mount it in the fuselage? It willonly take up 12" with the thrust tube and the interior volume I have to work with is 36" by 5" by 3 3/4 " Have a great day".3689463683?profile=original3689463767?profile=original

Read more…

Bad news for 2.4GHz

cellular-tower-center.jpg

It looks like AT&T is looking to use 2.3GHz bands reserved for Sirius radio.  Those in the WiFi space know that Terrestrial repeaters of Sirius radio signals are a major source of outdoor interference - but those repeaters only existed in dense cities.  Now with that spectrum moving to 4G Basestations we will see much more interference in on open areas (like those we like to fly in). This will likely raise the noise floor and reduce the range and reliability of communications in 2.4 GHz.  72 MHz anyone? 

source engadget

Read more…
3D Robotics

ROS Java interface for the AR.Drone

3689463343?profile=original

Pablo writes: 

I'm a student at UT Dallas, and we have a ROS driver for the AR.Drone. It is an early version, and it has almost the same functionality as the ardrone_brown package. The main difference and advantage is that it is written using rosjava and javadrone.

This means that no matter how broken the official SDK is on current or future versions of Linux, we could always have a ROS driver as long as a Java Virtual Machine is present. Moreover, if somebody has the skills this could be ported to Windows or Android, since it does not use native code at all.

You can find this package at https://github.com/jpiramirez/ardrone_utd

There are a couple of Wiki entries explaining how to install and use it.

Suggestions and bug fixes are very welcome!

Read more…

3689462974?profile=originalSo I have some vacations coming up and already have some quads and a hex I figured I needed a fixed wing to round out my aerial camera fleet. (for now) heh. So I took the plunge and picked myself up an X8 to fill up with electronics. 

3689463094?profile=original

I'm running an ArduPilot Purple, with a Castle 75 esc waiting for Hobbyking to drop of my new Scorpion motor until then I have a 700W max 50Amp local hobby store motor to power the bird. I'm running 1.2 video feeding through MinimOSD with a Sony 720 line mini cam. I have a roll and tilt GoPro mount in the works that I'll post up some pics when I can get some play time on the  router this weekend. Communication is done through a Futaba 10C 72Mhz and some 900Mhz XBees.

3689463151?profile=original

I've only made a few mods for now like adding a second motor mount plate that bolt through the foam to the outer plate.

3689462999?profile=original

I made some electronics trays and filled in the lower camera cut out with some foam and Gorilla glue.

3689463160?profile=original

3689463274?profile=original

I ended up bringing the control linkage up through the wing, leaving it on the bottom seemed like a bad idea for a belly lander. I have never flown a or built a fixed wing, but I said the same about the multirotors and DIYDrone's gear and community made it simple, awesome and enjoyable. Only crashes were ah-hem user error. So I'm hoping for the same luck with this bird. I do have tons of hours now on RealFlight sim just to make sure I feel comfortable with the controls. That being said any input from from you guys will be greatly appreciated. I'll update this blog as things progress and as I get the camera mount going. But for now heres some more eye candy. Be happy and safe all!

3689463229?profile=original3689463317?profile=original3689463299?profile=original3689463186?profile=original 3689463358?profile=original

Read more…