All Posts (11086)

Sort by

CubeStormer II solves the Rubik's Cube puzzle faster than the human world record.

This ARM Powered robot was designed, built and programmed by Mike Dobson and David Gilday, creators respectively of CubeStormer

and Android Speedcuber


The mechanics are constructed entirely from LEGO, including four MINDSTORMS NXT kits, with the addition of a Samsung Galaxy S II smartphone running a custom Android app as the robot's brain. Both the MINDSTORMS NXT kits and the Samsung Galaxy SII use a variety of ARM --based processors.

The app uses the phone's camera to capture images of each face of the Rubik's Cube which it processes to determine the scrambled colours. The solution is found using an advanced two-phase algorithm, originally developed for Speedcuber, enhanced to be multi-threaded to make effective use of the smartphone's dual-core ARM Cortex-A9 1.2GHz processor. The software finds an efficient solution to the puzzle which is optimised specifically for the capabilities of the four-grip mechanism. The app communicates via Bluetooth with software running on the ARM microprocessors in the LEGO NXT Intelligent Bricks which controls the motors driving the robot. During the physical solve, the app uses OpenGL ES on the phone's ARM Mali-400 MP GPU to display a graphical version of the cube being solved in real time.

Human speedcubers' solve times only include the physical manipulation of the cube and don't include some time which is allowed to "inspect" the cube beforehand. Times recorded by CubeStormer II are for the total solve including: image capture, software solution calculation and physical solve.

Read more…

[OFF-topic] Meanwhile in Brazil...

3689441524?profile=original

don't forget to watch the video in the linked site :D

This guy was arrested by the police for piloting his R/C plane on a busy highway, while on a bike driven by his girlfriend.

According to the reporter the news crew spotted the couple trying to trick the police by flying the airplane at a higher altitude while crossing border patrol.

http://g1.globo.com/parana/noticia/2012/01/rapaz-e-detido-no-parana-apos-pilotar-aeromodelo-na-garupa-de-moto.html

It's kind of funny... but dangerous and unfortunately giving R/C flying a bad reputation.

Read more…

Birth of Octocopter :)

3689441582?profile=original3689441607?profile=original3689441582?profile=original3689441652?profile=original

Almost there!
After countless hours of fitting and soldering, the thing is starting to look like something that will
actually fly! I had to make custom 3 degree mounts for the motors as they are too big for the frame.

Amazingly enough, the whole build was without any serious issues. Just niggly little gremlins that
were thwarted quickly.

Setup the APM1 board and all the esc & RC connections.
Loaded the latest firmware using MP.
At first it wouldnt arm, so I re-did the radio calibration and all worked flawlessly.
Im quite surprised as I had ENDLESS trouble with my arducopter but then again those were the
fresh n00b days. Im definitely on the road to not-so-fresh n00b :)

Thanks everyone who helped!

One thing I did notice is with the copter powered up, when I connect the USB to the PC. The
one motors spun up for like 100ms. Shouldnt be a problem. Havent connected via the xbee yet.

Today I plan to loctite all the motor screws and CAREFULLY give it a little test flight this
afternoon, as long as the wind dies down.

Hoping im not going to have too much stability issues.

One last point on vibration. The motors vibrate a little, and in turn vibrate the frame.
The electronics bed (clear polycarbonate) is mounted on 4 anti-vibration mounts.
They work alright, halving the vibration. The APM is mounted with 3 layers of foam double
sided tape. Im happy to report theres virtually NO vibration on it! W00t!

Will post some videos later!

G:)

Read more…

Well this took me a while, I've been too busy travelling to complete in time.

Some of You may remember my earlier post:

http://www.diydrones.com/profiles/blogs/all-in-one-uav-controller


Well I must say it is done! And it came out pretty nice! This is an all in one UAV controller:3689441363?profile=original

As mentioned - it's all in one board that contains the following:

- 3 axis gyro

- 3 axis accelerometer

- 3 axis magnetic sensor

- orientation sensor for calibration and in flight corrections

- 2 pressure sensor (one for altitud and the other for air speed measurement)

- moisture and temperature sensor

- 10 Hz GPS

- contactless current sensor

- optically isolated PWM inputs and outputs (5 inputs and 8 outputs), with additional one non-isolated input and 4 non isoated outputs

- 10 16bit analog or digital inputs outputs

- I2C, SPI and CAN communication ports

- miro SD card for data logging

- SEPIC power supply that will maintain device operation down to 1 V remaining on the battery


All of it is controlled by TI's 32 bit DSP (TMS320F28335) with float support. This is a real power engine capabe of 150 MMACS!

I've been sucessfully working on programing it directly from Matlab / Simulink - this has dramatically improved code development eliminating hard coding of all routines.

All comes in a neat  2.2 by 2 inch package with weight of just under 0.4 oz (12 grams with no servo headers)!


There are two other version being currently build and tested as well - one intended for quad copters (no headers just I2C ad CAN) and the other with an integrated GSM module (Telit's GE865 module).


If some of You would like to contribute to the development of this module You are welcome - it turns out working on a project of that scale alone is just beyond my abilities and time commitment, so I would welcome some of You to contribute! Please feel free to contact me!

By the way I will be making other posts very shortly about other exciting projects I've been working on so keep watching!

3689441535?profile=original

Read more…

3689441507?profile=original

Video of my BlimpDuino at Melbourne Mini Makers Faire

http://www.flickr.com/photos/74286203@N05/6704426813/in/pool-1874758@N22

More about the event:

and

Richard
Read more…

Death of a Feigao

feigao01.jpg

feigao02.jpg


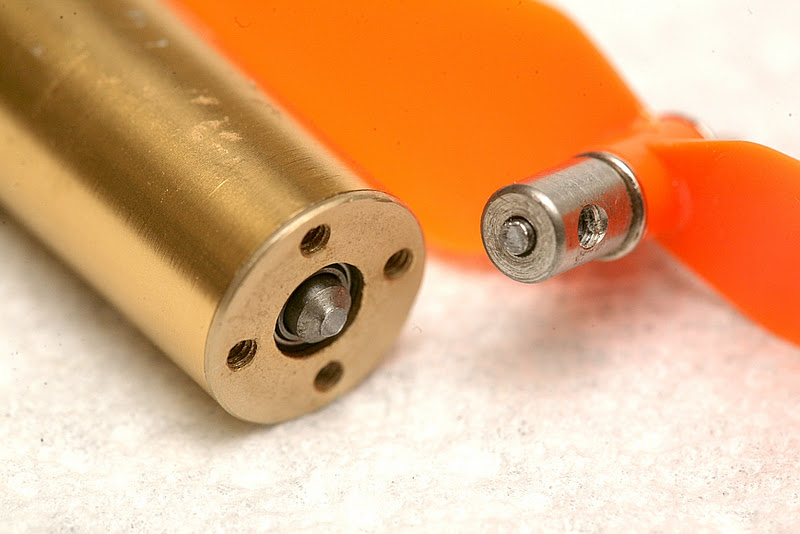
The $30 Feigao motor we got in May 2009 finally dies when hitting a piece of wood, after already being on the ground. It was a FeiGao 5300kV 17g 141g thrust. Today, it's $34. Obviously, it's going to cost a lot of money to fly such a large aircraft in such a small space.

Really thought that motor would last forever & the very existence of the project seemed just to make use of it.

We did find the horizontal velocity wasn't being calculated in the previous flights. After fixing velocity, the vehicle showed signs of being able to stabilize horizontal motion, though not return to the target point. Altitude hold was still nowhere close.

There are 3 options:

1) Build a smaller aircraft, using a recycled toy motor.  It would use a smaller battery & new circuit board.  It would have a shorter flight time, not support lifting a POV attachment, & would be more expensive in the long term.  The 1st copy would be free & it would be easier to fly, indoors.  Replacing the motor & propeller would require buying complete toys, since those power systems are insanely expensive from plantraco.com.

2) Get an EDF for the current airframe.  It would potentially be crash proof & have faster throttle changes.  It would have shorter flight time & its resistance to crashes is unknown.

3) Get another Feigao & make it a pusher instead of a puller.  A pusher alone should eliminate shaft breakage, but have an unknown effect on propeller breakage.  Flying indoors would definitely continue to be virtually impossible.

Read more…
Moderator

RCAPA petitions the FAA, now its time to act.

bio_peggy.jpg

Let the battle commence, people will be getting bored of me pushing this issue. But if you ever want to turn a dime with a UAS in the USA or have sensible rules for flight you had better start making a noise.

Patrick Egan starts his article in sUAS News like this

RCAPA cites incongruities in the UAS ARC charter and what is transpiring as part of an alleged “public process”. The charter and membership roster FOIA requested by sUAS News is applicable and of concern to the small business, end-user and academic community stakeholders. This egregious oversight is yet another example of what many in the global airspace integration community view as subpar leadership and questionable administrative actions taken by the UAPO (Unmanned Aircraft Program Office.) These and other purported irregular practices have been highlighted and are not going unnoticed by elected officials. It begs the question, at what point do we as taxpayers say, enough.

A letter to the FAA which is so far unanswered is also there.

This is just the first step, the NPRM process is ever closer and louder noise will be needed then.

RCAPA is free to join find them here and perhaps consider a tweet if you do such things.

Here is a copy and paste tweet.

HEY FAA UAS in the NAS today the RCAPA way suasnews.com/2012/01/11217/… #FAA #UAS #UAV #diydrones #suasnews #AUVSI 

Join the Facebook page here http://www.facebook.com/groups/317984811558233/ and add support

Finally LinkedIN http://www.linkedin.com/groups/RCAPA-4230773

Lets try and make this Friday the 13th an interesting one in Washington.

Read more…

Getting six fly modes on Futaba T10CAG transmitter

We use for example CH5,switch C-3positions and switch D-2positions.

Settings:

1. Transmitter END POINT menu-GEAR -100%3689440774?profile=original

2.SUB-TRIM menu-GEAR -0

3689440674?profile=original

3.AUX-CH SELECT menu –CH5-Ls1(Logical switch)

3689440712?profile=original

4.LOGIC SW menu.Settings as shown on left.

3689440791?profile=original

 5.PROG.MIX1-8 menu choose mix 5

3689440685?profile=original

 6.P.MIX5  page 2/2 settings as shown

3689440808?profile=original

7.GYRO SENSE menu settings-CH5 and switch C as shown.

3689440728?profile=original

 8.GYRO SENSE  menu position 2 to ON.

DSCF9571.jpg?width=500

 9.C switch up,D switch up and set 68%.Pulse with in this set is 1166µs.

DSCF9573a.jpg?width=500

 10.C switch middle position,D switch up and set 48%.PW-1264µs.

DSCF9574a.jpg?width=500

 11.C switch down,D switch up and set 16%.PW-1423µs.

DSCF9575a.jpg?width=500

 12.P.MIX5 menu tab2/2 turn MIX ON.

DSCF9593.jpg?width=500

 13.P.MIX5 tab1/2 C switch down,D switch down and set -(minus)71% at poin5.PW-1554µs.

DSCF9582a.jpg?width=500

 14.C switch middle,D switch down,set -(minus)76% at point1.PW-1683µs.

DSCF9583a.jpg?width=500

 15.C switch up,D switch down and set -(minus)71% at point5.PW-1814µs

DSCF9585a.jpg?width=500

 16.Now P.MIX tab2/2

DSCF9586.jpg?width=500

That's all.There are other ways to do it,no doubt.

Read more…

Its now been a whole year since I got addicted to the crazy hobby of Autopilots.

What a wild ride!!!

There has been some fantastic moments and some of total frustration, but it has been an exciting and rewarding journey.
There are a lot of people who ask about getting into the hobby and have somewhat ambitious ideas about building a drone to do X and Y before they have even completed their first flight.
This is a short video compiled from some of my mishaps over the last year that hopefully helps show those considering getting into the hobby why it is an extremely good idea to start small and cheap and gradually work your way up to more ambitious goals.

When I started, I was a relatively competent RC pilot. All of the crashes and incidents in this footage have arisen from me making stupid mistakes on the Autopilot side.

By setting the wrong waypoints and RTL'ing straight into a tree, by setting my altitude wrong, by trying to do PID tuning while in the Air, by putting too much weight on a plane and it not getting off the ground and hitting a tree etc etc.


All in all, the crashes when compared to the number of great flights have been relatively few, looking back at the log I've kept, I've flown 165 individual flights in the last year, with a combined total of 95 hours in the air.

These have primarily been logged on one of the 3 SkyFuns I have built and destroyed in that time.

The first one only lasted 5 flights, the next one I got 36 flights out of and the last one is still going strong.

I've now progressed onto a composite FPV168 and also a Hugin (which you can see being destroyed in the last clip with too much weight to get off the ground).


Over the next year, I'm planning to get the new Skywalker X8 and perfect Telemetry and video over a cellular link which I have been experimenting with more recently.

Best of luck to you all, and hopefully this video serves as a lesson in what to avoid doing and saves you the time / expense yourself.


Read more…
An Aeryon Scout, a four-propeller unmanned aerial vehicle, returns to Nome on Monday, Jan. 9, 2012, after surveying the sea ice near the town s harbor. University of Alaska Fairbanks researchers from the Geophysical Institute arrived in Nome to prepare for the arrival of the Russian fuel tanker, Renda. Jessica Cherry photo
An Aeryon Scout, a four-propeller unmanned aerial vehicle, returns to Nome on Monday, Jan. 9, 2012, after surveying the sea ice near the town's harbor. University of Alaska Fairbanks researchers from the Geophysical Institute arrived in Nome to prepare for the arrival of the Russian fuel tanker, Renda. Jessica Cherry photo

Read more: Fairbanks Daily News-Miner 

http://newsminer.com/bookmark/17062606

Read more…

SparkFun Free Day!

When/where: 9:00 am MST Sparkfun.com

What: Win $100 of a total $200,000 giveaway

"Well the time is near - tomorrow at 9 AM Mountain Time, SparkFun is hosting the third edition of Free Day. This year we are giving away $200,000 worth of $100 credits to the SparkFun website. Show up here at 9 AM Mountain Time on January 11th, 2012 to try your hand at winning! Want to know more? Watch the video below:

Here's a little more information:

The Rules: The give away starts at 9AM MST and is limited to $100 per person. Each winner will get a gift code that can be used at SparkFun within 60 days.

Stipulations: In order to participate, you must register an account on sparkfun.com, and use a modern browser with JavaScript and cookies enabled. (Sorry, Lynx!)

The System: We're doing away with the quiz system of 2011 and trying to return to a give-away system that is as simple as possible, but can handle the load of the Free Day crowd. The system will randomly give away the 2,000 gift codes (2000 * $100 = $200,000) throughout the day. For example, if we set up a 7 hour giveaway window, we should see a gift given away about every 12 seconds. We will allow people to try for the prize as many times as they'd like, but we will have a basic system to prove you're not a script.

Free Day is always an intense and interesting time! We wish all of you the best of luck in getting your share of the prize! See you tomorrow!"


Read more…

Turnigy G10 Outrunner - Hair Dryer & Thrust test


Motor: Turnigy G10 810kv
(http://www.hobbyking.com/hobbyking/store/uh_viewItem.asp?idProduct=19020)

ESC: Turnigy dlux 55A SBEC
(http://www.hobbyking.com/hobbyking/store/__16365__Turnigy_dlux_55A_SBEC_Brushless_Speed_Controller.html)

Battery: Turnigy Nano-tech 5000mah 4S1P
(http://www.hobbyking.com/hobbyking/store/__17254__Turnigy_nano_tech_5000mah_4S_35_70C_Lipo_Pack.html)

Prop: EPP1245 CF SF
(http://mikrokopter.altigator.com/propeller-pair-epp1245-cf-p-89.html)


I was expecting around 1.6kg of thrust per motor. My platform weighs about 5-6kg.
1.6 x 8 = 12.8kg for a 6kg platform is fine. With a 12x45 prop, im getting 2.4kg per motor.
I think I might have to add some weaponry or perhaps build a small cockpit for my cat!


Thanks to Karla for allowing me to test the "blow your hair back" factor.


G:)

Read more…

Backup system for BEC

So after much reading and research into the whole "backup" BEC saga. I think I've found a solution!

My first idea was just to run a 5.5v backup lipo in parallel with the 5v UBEC output.
This idea has been vitoed by most. Too many unknowns apparently.
The other was to parallel all the BECs up, but this would cause harmonics due to all the square wave interaction.

So I figured we cant mix power supplies. Other than using a microproccessor controlled mosfet to switch
power supplies when and if the bec dies.

We use a relay :) Bear with me.

The main power supply powers the relay. With the relay closed (NO) power is routed via the bec to the apm.
If the bec fails, the power to the relay fails and is switched to the auxillary power supply (battery or another bec)

This completely seperates the two power sources.

Will the relay be able to switch fast enough to the auxillary power source without the APM losing power?
If not, im sure a power capacitor will keep the APM alive long enough for the bi-pass surgery to take effect?

Above is a recording of the ciruit just in case my explaining skills are dodgy :)

Read more…
Moderator

If by "Stormy" you mean "Somewhat Cloudy", and by "Sea" you mean "San Francisco Bay"...

Radio contact lost, Zephyr II with APM flies to points unknown, rescued with APM and most other electronics functioning.

shot003-2.jpg?width=512

Full story and pics:

http://eastbay-rc.blogspot.com/2012/01/zii-in-east-bay.html

We're pulling some information from the log to see if there's anything interesting.

Read more…

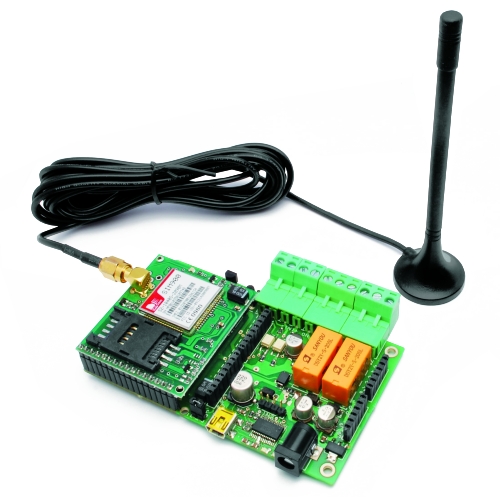
Universal GSM Remote Control module

TiDiGino_3.jpg

TiDiGino is a new open source Arduino-based (ATmega2560) GSM remote control module.  From open-electronics via dangerous prototypes

"The remote can be operated by commands sent by SMS, but you can also control it via the serial port (connected to USB converter).
Each command is followed by a response (via SMS) directly to the sender, but the answer may be disabled. In addition there is an alarm function, as the automatic sending of SMS or voice calls, based on conditions on each of the two inputs.
The circuit can also be used as a gate control, calling the SIM in the TiDiGino: the system recognize the calling number and if this number is stored the relay will switch on. In the DTMF mode, the remote control can be controlled by a multi-frequency telephone tone.
In addition, the circuit can operate as a thermostat, running an air conditioning system."

Read more…

Reliable takeoffs

marcy1_46.jpg


This continues to move forward.  Decided attitude sensing is required for what we need.

After some complicated math problems, finally derived an empirical method for determining attitude from video.  It most definitely isn't accurate enough for our needs.  There's going to be a lot of horizontal drift.  The tilt of the camera has a big effect on it.

The takeoff is still problematic.  Attitude really needs to be level before it lifts off.  It's most definitely not passively stable.

PID tuning for attitude control with the altitude control nailed down.  It's most definitely not passively stable.


The great problem with Marcy 1 is devising a stabilized takeoff.  It needs to start tracking position at some point before it can actually track position.


The 1st algorithm was to apply fixed throttle that was known to go fast enough to control attitude but not take off.  Once the RPM was certain to be fast enough to return a valid position & attitude, apply cyclic to level the attitude without increasing throttle.  

This has been killing us, since attitude oscillates at low throttle.  For now, it just ramps up at the point in the oscillation when it's level enough & hopes there's enough control to keep it level. 


The moment it starts ramping up, it starts tracking position.  Since it can't move, the integrals build up.


Making it ignore position until reaching a minimum altitude has been tried.  The takeoff attitude is never level because the camera is never level, so it would fly away without active control.


 Resetting the integrals before reaching a minimum altitude, but having proportional feedback is yet to be tried.  Trying to stabilize the oscillation at low RPM, with derivatives is yet to be tried.


Loosening the steel wire to give it some horizontal range has shown whether or not feedback was going in the right direction.  Another idea is using fishing line instead of steel & tightening it if it gets out of control.

Marcy 1 does 4 autonomous flights without the tether. It's pretty bad. Throttle is a lot more unstable. Position tracking is erratic. The last crash might have been an unknown air current. Put a lot of work into making the takeoffs exactly level. Honestly thought that would never happen, but we got level takeoffs. Now, the XY camera movement seems to confuse it.

  Began by running the takeoff sequence up to the stabilized attitude stage to show machine vision could keep it level. Then switched to manual mode with cyclic at neutral to show how it doesn't naturally stay level. Then ran down the battery with the stabilized attitude on, to show the algorithm could keep it level for all battery voltages.

Perfectly level attitude is required for takeoff. Deglitching the video & getting such a slowly rotating blade level was a buster.

Reasonably pleased with new progress in leveling the aircraft on the test stand.  Maintaining a perfectly level aircraft during the takeoff is key to everything else.

Key to leveling the aircraft was using much higher gains than we used before.  A manual test showed the D gain was capable of an amazing job stabilizing the aircraft.

Also, application of the deglitching algorithm formerly used in sonar to the vision system greatly improved matters without causing a delay.  Finally, the trig had some more corner case tests.

Currently, the next flight test is programmed to feed position directly to cyclic, because vision isn't seen as accurate enough to give useful attitude information on a moving object.  All these changes still may get it to work with attitude hold.

Need to find more propellers 1st.  All suppliers are moving to China.  It takes several months to get anything from China. We've actually haven't gotten anything from the last 2 hobbyking orders.


More stable takeoff algorithm, deglitching, & direct position to cyclic feedback, but still no luck.  It's taking 1 propeller for every 4 test flights. 


We got the takeoffs very reliable.  It doesn't fly off the stand in a random direction unless the propeller breaks.  The only algorithm left is going back to the attitude feedback.

Read more…