All Posts (11086)

Sort by

UgCS 2.0 public Beta is out!

3689624670?profile=original

Hi,

I wanted to let you know what UgCS 2.0 Beta is now available for download at our site www.ugcs.com !

UgCS 2.0 now supports Ardupilot, Mikrokopter, Microdrones, ARDrone and DJI (Naza-m, wookong-m, A2) autopilots.

As shown in our teaser, UgCS 2.0 has now real 3D globe map engine and capability to search for locations for quick navigation.


Please feel free to download it and see the beauty with your own eyes :)

As always your feedback is greatly appreciated, as together we can build really one of the kind ground control software!

Thank you!

UgCS Team

Read more…

PilotViper300-1080.png?width=702

-Pilot Viper 300-

Digi-DNA-300-PilotViper.gif?width=600

Shown without the landing gear and 3d camera array.

3D FPV, dynamic driven landing gear.

Dual purpose Tail assembly, aerial/gear parts in process...

The landing gear assembly inspiration was the trap jaw of the South Carolina "Cottonmouth"

As this will be a active post with frequent updates. pictures of the linkages.

Interior Dimensions allow for Pixhawk, VR Brain, VR Brain Micro without any modification.

digi-dna.net 

(the props are on the wrong way, had been in virtual model land long enough)

snapjaw-300-HD.gif?width=702A quick crop of a semi deconstructed view, helping picture it as a H4 setup 

Read more…

3689624595?profile=originalTransport Canada makes it easier to fly small UAVs for work and pleasure

November 5, 2014, 2014 – Montréal, Quebec – Transport Canada

Transport Canada today announced, at the Unmanned Systems Canada conference in Montréal, two exemptions that simplify small unmanned air vehicle (UAV) operations and safely integrate UAVs into Canadian airspace.

Under the new exemptions, a Special Flight Operations Certificate will not be required for UAVs under 2 kilograms and certain operations involving UAVs under 25 kilograms. The new approach will apply to commercial operations and contribute to a strong safety regime for those on the ground and in the skies.

Once the changes come into effect later this month, operators must check on Transport Canada’s website if the exemptions apply to them and respect specific safety conditions, including requirements to operate within visual line-of-sight, maximum altitudes and away from built-up areas and aerodromes. In addition, Transport Canada is simplifying the application process and reducing the time it takes to issue Special Flight Operations Certificates for larger UAV operators.

In October, Minister Raitt launched the Government of Canada’s national safety awareness campaign for UAVs, which aims to help Canadians better understand the risks and responsibilities of flying UAVs. For more information, please visit www.tc.gc.ca/SafetyFirst.

Quick Facts

  • Transport Canada regulates the use of all aircraft, manned and unmanned, to keep the public and our airspace safe.

  • Canada has had safety regulations in place that govern the use of UAVs since 1996.

  • Operators must still apply for a Special Flight Operations Certificate for UAVs weighing more than 25 kg.

  • If a UAV is operated without a Special Flight Operations Certificate and should be, Transport Canada can issue fines of up to $5,000 for an individual and $25,000 for a company.

  • If an operator does not follow the requirements of their Special Flight Operations Certificate, Transport Canada can issue fines of up to $3,000 for an individual and $15,000 for a business.

Quotes

“Transport Canada has requirements in place for aircraft of all sizes. For businesses, these changes will make it easier for their small UAVs to take flight sooner, while maintaining the safety of those on the ground and in the skies”
The Honourable Lisa Raitt
Minister of Transport

“This approach will dramatically improve the ability for Canadian businesses to safely make use of this extremely capable technology while substantially reducing the time it takes to get authorization for more complex operations. Coupled with the safety awareness campaign announced two weeks ago, I believe that Canada now has one of the most effective and progressive UAV regulatory frameworks in the world.”
Stewart Baillie
Chairman, Unmanned Systems Canada

Contacts

Ashley Kelahear
Director of Communications
Office of the Honourable Lisa Raitt
Minister of Transport, Ottawa
613-991-0700

Media Relations
Transport Canada, Ottawa
613-993-0055

Read more…

Podcast Interview With Tad McGeer

3689624561?profile=originalTad McGeer has 25 years of experience in the unmanned aircraft world. He is responsible for Aerosonde and the Scan Eagle as well as the first unmanned transatlantic flight (1998). If you want to hear the history of drones hear it from a guy who lived (and helped invent) it.

sUAS News Podcast

BTW - I've started using Cheer laundry detergent! ;-)

Read more…

3689624585?profile=original

This blog is a continuation of my previous post.

How to build a High-Definition FPV UAV using a Rasperry PI with HD camera, using a high speed WiFi link

This post will discuss how to use GStreamer and Mission Planner together to display the HD video with a HUD (Head-Up-Display).

Note: I have only tested this feature on Windows so the instructions given here are for Windows only. 

To give proper credit, the HUD created here was borrowed from APM Planner, a Qt-Based app similar to Mission Planner. The HUD part was created from the Qt codebase QML HUD created by Bill Bonney who is on the APM Planner development team. To make the HUD work with the background video, I used a GStreamer library called "QtGStreamer" which integrates GStreamer plugins with painting on a Qt widget.  This library is available on the GStreamer website.

The end-result is dynamically added to Mission Planner using the plug-in architecture. 

In the previous posts I discussed used a Raspberry PI and a High-speed WiFi link using GStreamer on the PI and the ground station PC.  To get the HUD to work, you need to already have a successful link with the video on your ground station. 

Here are the steps to follow to install the plugin:

1) Install Mission Planner.

2) Download and install GStreamer from this link.  Use the x86 version, the x86_64 version will NOT work. (Use the default path 'C:\GStreamer' when installing). When installing GStreamer, select 'Custom' install and select ALL plugins to be installed.

3) Follow the steps in the previous blog noted above to get your video stream working.

4) Download and the MSI installer from this link. and run the installer.

If all went well, you should have the plugin installed.

Open Mission Planner and navigate to the "Flight Data" page and right-click on the map. You should see a menu item called "GStreamer HUD" as shown below:

3689624376?profile=original

Select this menu item and the following screen should appear:

3689624624?profile=original

In the upper-left corner is a context menu. Here is where you enter your GStreamer Pipeline string. If you had the video displaying without the HUD using a valid pipeline, enter it here.

Note: The GStreamer Pipeline string should be exactly the same as the string you used before, but WITHOUT the final video sink element. The video sink is the QtGStreamer element which will be added automatically by the plugin. The GStreamer pipe should therefore be the same, except remove the last element for the video sink.

Here is an example string I used on my setup:

udpsrc port=9000  buffer-size=60000 ! application/x-rtp,encoding-name=H264,payload=96 ! rtph264depay ! h264parse ! queue ! avdec_h264

If all is well, you can connect to your UAV and see the HUD elements moving.  To change the HUD, right click on the display and select which elements you want to display. The default is to display everything shown here. 

If anybody has problems, please post back and I'll update the blog in case I missed something, and you cannot get it to work.

Happy Flying!

Read more…
3D Robotics

Nice post over at sUAS News:

The rain has finally subsided so I went out to the RC field for some quadcopter fiddling and testing.

The below video shows a quick demonstration of the Region Of Interest (ROI) function of Arducopter (running firmware v3.1.5). I demonstrate the function on the Steadidrone 2014 QU4D with 3DR Pixhawk and GoPro 3 Silver. The function allows the nose (and camera) of the quad to keep pointing at a designated point while flying an autonomous flight plan. In the video there is an explanation of how to set up the the ROI flight plan in Mission Planner as well as a demonstration flight with telemetry data provided by the 3DR 433Mhz Telemetry system.

These technologies still amaze me every day.

Read more…

Another simple camera plane

MiratuFrame3%2528rzd%2529.jpg

The Miratu as design by a RC buddy of mine with a much higher specs but still had that open frame design exhibited on the smaller  PX34-A plane . the interesting fact His design this a few years before I have interest in FPV and AP

camera of choice Sony Cybershot. and the frame is made of wood his main advantage is the entire gear fits in a backpack and comes with landing gear. great for those flyby shootings

http://3.bp.blogspot.com/-eO0rhucbLhg/VBeOijNiOoI/AAAAAAAADqw/K4BmNk1oim4/s1600/MiratuOnTheGo(rzd)A.jpg

PX-34A in comparison

One would ask why forward facing motor for camera planes. the real reason is to fly slow. and still have that extra control. over the common pusher prop setup.

Read more…
3D Robotics

Neruromorphic chip "learns" how to fly

3689624364?profile=originalFrom Technology Review:

There isn’t much space between your ears, but what’s in there can do many things that a computer of the same size never could. Your brain is also vastly more energy efficient at interpreting the world visually or understanding speech than any computer system.

That’s why academic and corporate labs have been experimenting with “neuromorphic” chips modeled on features seen in brains. These chips have networks of “neurons” that communicate in spikes of electricity (see “Thinking in Silicon”). They can be significantly more energy-efficient than conventional chips, and some can even automatically reprogram themselves to learn new skills.

Now a neuromorphic chip has been untethered from the lab bench, and tested in a tiny drone aircraft that weighs less than 100 grams.

In the experiment, the prototype chip, with 576 silicon neurons, took in data from the aircraft’s optical, ultrasound, and infrared sensors as it flew between three different rooms.

The first time the drone was flown into each room, the unique pattern of incoming sensor data from the walls, furniture, and other objects caused a pattern of electrical activity in the neurons that the chip had never experienced before. That triggered it to report that it was in a new space, and also caused the ways its neurons connected to one another to change, in a crude mimic of learning in a real brain. Those changes meant that next time the craft entered the same room, it recognized it and signaled as such.

The chip involved is far from ready for practical deployment, but the test offers empirical support for the ideas that have motivated research into neuromorphic chips, says Narayan Srinivasa, who leads HRL’s Center for Neural and Emergent Systems. “This shows it is possible to do learning literally on the fly, while under very strict size, weight, and power constraints,” he says.

The drone, custom built for the test by drone-maker company Aerovironment, based in Monrovia, California, is six inches square, 1.5 inches high, and weighs only 93 grams, including the battery. HRL’s chip made up just 18 grams of the craft’s weight, and used only 50 milliwatts of power. That wouldn’t be nearly enough for a conventional computer to run software that could learn to recognize rooms, says Srinivasa.

The flight test was a challenge set by the Pentagon research agency DARPA as part of a project under which it has funded HRL, IBM, and others to work on neuromorphic chips. One motivation is the hope that neuromorphic chips might make it possible for military drones to make sense of video and sensor data for themselves, instead of always having to beam it down to earth for analysis by computers or humans.

Prototypes made under DARPA’s program—like HRL’s—have delivered promising results, but much work remains before such technology can perform useful work, says Vishal Saxena, an assistant professor working on neuromorphic chips at Boise State University. “The biggest challenge is identifying what the applications will be and developing robust algorithms,” he says.

Researchers also face a chicken-and-egg scenario, with chips being developed without much idea of what algorithms they will run and algorithms being written without a firm idea of what chip designs will become established. At the same time, neuroscientists are still discovering new things about how networks of real brain cells work on information. “There’s a lot of work to be done collectively between circuit and algorithm experts and the neuroscience community,” says Saxena.

Read more…
Moderator

It support all the standard and advanced functionality that require GPS and magnetometer, too

This is the repo mantained by Stefan : 

In this branch is available the firmware and software that support standard micro brain .

https://github.com/scenkov/TauLabs/tree/VRuBrain_InternalFlash

Here is available the code that support the waypoint ,too but need to add data flash to VR micro Brain .

https://github.com/scenkov/TauLabs/tree/VRuBrain


For enviroment Setup :

Setting Linux Enviroment:

https://github.com/TauLabs/TauLabs/wiki/Development-Linux-setup

Setting  Windows Enviroment :

https://github.com/TauLabs/TauLabs/wiki/Development-Windows-setup


I succesfully build the code in the Stefan’s Git , today i did my first fly with micro brain and Taulabs code , in this code you can find the binary for VR micro Brain and CGS for linux OS.

https://drive.google.com/a/virtualrobotix.com/file/d/0BwTncyahsmkiZFZyTDRYYm9zc3M/view?usp=sharing

bl_vrbrain.dfu is the bootloader upload it with DFUDemostrator by usb cable .

fw_vrubrain.tlfw this is the last available TauLabs firmware for VR micro Brain . It’s a early revision of code so keep atention to use it.

Enjoy with this new great toy :)

the official wiki page is here : 

http://vrbrain.wordpress.com/quick-start-guide/quickstart-open-pilot-taulab-firmware-for-vr-ubrain-5/

For more info on vr micro brain this is the link:

http://www.virtualrobotix.it/index.php/en/shop/autopilot/vrbrainmicro51-detail

Best

Roberto

Read more…

b0x88jzcmaa1fnu.jpg?w=610&width=300

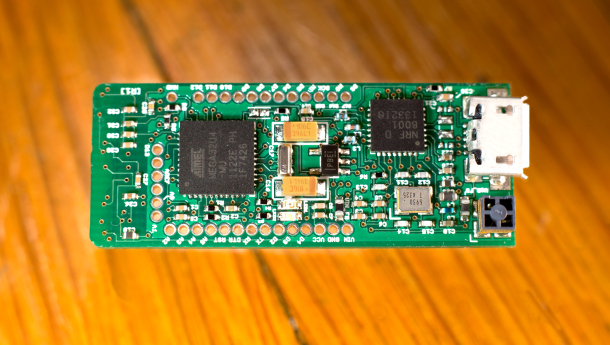
IMUdino on Kickstarter -- a really tiny 10DOF IMU with Bluetooth. It was covered by Atmel blog.

The Kickstarter has 3 days left.

Surely there are UAV / Rover applications in addition to Minority Report style UI and Wearable applications, right?

Generally speaking it looks like a pretty neat product. Enough that I backed it so I could get one for myself. :)

I have been in touch with the guy behind all this over the last couple of years as a fellow seller on Tindie.com. He seems to be a good guy. He's been making these by hand to date, but it's quite a task for this unit, so he's hoping to start outsourcing assembly now, hence the Kickstarter.

Read more…

Aeromapper Talon mapping drone

It's been already a while ago since we started selling one of our newest drones based on the Talon UAV airframe: the Aeromapper Talon.

In this occasion we wanted to use a large foam aircraft, something that was compact and yet large to offer 60 minutes endurance carrying a Sony Nex 5 with wide angle lens (as standard sensor, but more sensors are available). We chose the Talon, since structuraly and aerodynamically is a better compromise than other designs.

This UAV is very easy to launch, cruises at a low speed (40-45 km/h), has a small turning radius and has a parachute landing system. This makes it ideal for medium to small survey areas with very tight launch and landing spaces.

The V tail is quickly removable for easy transport.

Includes long range control and data link system (20+ kms).

And as usual, comes ready to fly and each unit we manufacture is completely flight tested. Includes a  fully detailed User Manual with step by step instructions to get the user airborne in no time and with no training, although training is also available. Of course, it has APM and soon we’ll be transitioning to Pixhawk when we verify the maturity of this autopilot for fixed wing.

The Aeromapper Talon can already accommodate many different payloads with automatic triggering, including many variations of the Sony Nex 5 (converted camera bodies).

For more information on available payloads for this UAV please visit http://www.aeromao.com/uav_payloads

For more information on the Aeromapper Talon please visit http://www.aeromao.com/aeromapper_talon_uav

www.aeromao.com

Read more…

UN Experts Meeting on Humanitarian UAV/Drones

The Humanitarian UAV Network (UAViators) and the United Nations Office for the Coordination of Humanitarian Affairs (OCHA) are co-organizing the first ever “Experts Meeting on Humanitarian UAVs” on November 6th at UN Head-quarters in New York. This full-day strategy meeting, which is co-sponsored by the ICT for Peace Foundation (ICT4Peace) and QCRI, will bring together leading UAV experts (including several members of the UAV Network’s Advisory Board, such as DJI) with seasoned humanitarian 
professionals fro
m OCHA, WFP, UNICEF, UNHCR, UNDAC, IOM, American Red Cross, European Commission and several other groups that are also starting to use civilian UAVs or have a strong interest in leveraging this technology.

The strategy session, which I’ll be running with my colleague Dan Gilman from OCHA (who authored this Policy Brief on Humanitarian UAVs), will provide an important opportunity for information sharing between UAV experts and humanitarian professionals with the explicit goal of catalyzing direct collabo-ration on the operational use of UAVs in humanitarian settings. UAV experts seek to better understand humanitarian information needs (e.g. UNDAC needs) while humanitarians seek to better understand the challenges and opportunities regarding the rapid deployment of UAVs. In sum, this workshop will bring together 30 experts from different disciplines to pave the way forward for the safe and effective use of humanitarian UAVs.

Screen Shot 2014-06-24 at 2.22.05 PM

The Experts Meeting will include presentations from select participants such as Gene Robinson (leading expert in the use of UAVs for Search & Rescue), Kate Chapman (director of Humanitarian OpenStreetMap), Peter Spruyt (European Commission’s Joint Research Center), Jacob Petersen (Anthea Technologies), Charles Devaney (University of Hawaii), Adam Klaptocz (Drone Adventures & senseFly) and several others. Both Matternet and Google’s Project Wing have been formally invited to present on the latest in UAV payload transportation. (Representatives from the Small UAV Coalition have also been invited to attend).

In addition to the above, the strategy meeting will include dedicated sessions on Ethics, Legislation and Regulation facilitated by Brendan Schulman (leading UAV lawyer) and Kristin Sandvik (Norwegian Center for Humanitarian Studies). Other sessions are expected to focus on Community Engagement, Imagery Analysis as well as Training and Certification. The final session of the day will be dedicated to identifying potential joint pilot projects between UAV pro’s and humanitarian organizations as well as the Humanitarian UAV Network.

UAViators Logo

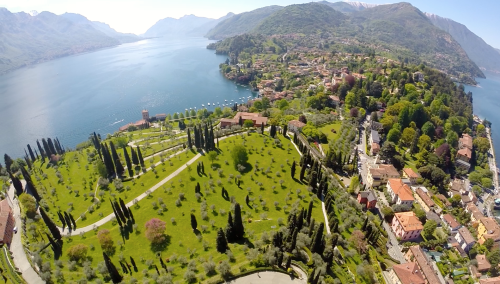
We will be writing up a summary of the Experts Meeting and making this report publicly available via the Humanitarian UAV Network website. In addition, we plan to post videos of select talks given during the strategy meeting along with accompanying slides. This first meeting at UN Headquarters serves as a spring board for 2 future strategy meetings scheduled for 2015. One of these will be a 3-day high-level & policy-focused international workshop on Humanitarian UAVs, which will be held at the Rockefeller Foundation’s Center in Bellagio, Italy (pictured below in an UAV/aerial image I took earlier this year). This workshop will be run by myself, Dan Gilman and Kristin Sandvik (both of whom are on the Advisory Board of the Humanitarian UAV Network).

ProPic35

Kristin and I are also looking to co-organize another workshop in 2015 to focus specifically on the use of non-lethal UAVs in conflict zones. We are currently talking to prospective donors to make this happen. So stay tuned for more information on all three Humanitarian UAV meetings as one of our key goals at the Humanitarian UAV Network is to raise awareness about humanitarian UAVs by publicly disseminating results & findings from key policy discussions and UAV missions. In the meantime, big thanks to UN/OCHA, ICT4Peace and the Rockefeller Foundation for their crucial and most timely support.

See also:

  • Humanitarians in the Sky: Using UAVs for Disaster Response [link]
  • Low-Cost UAV Applications for Post-Disaster Damage Assessments: A Streamlined Workflow [Link]
  • Humanitarian UAVs Fly in China After Earthquake [link]
  • Humanitarian UAV Missions During Balkan Floods [link]
  • Humanitarian UAVs in the Solomon Islands [link]
  • UAVs, Community Mapping & Disaster Risk Reduction in Haiti [link]

Read more…

3689623614?profile=originalLinus Penzlien and Andrew Tridgell have been picking over the log files from the recent stratospheric test flight of our Vulture 2 spaceplane's avionics, and the verdict is largely positive.3689623593?profile=original

3689623442?profile=original

Our US allies at Edge Research Lab sent up a Pixhawk, GPS/compass unit, digital airspeed sensor, servos and the two battery packs which power the whole rig (see pic at top).

The Pixhawk was in "servo wiggle" mode - a custom LOHAN ArduPilot AUTO mode command (MAV_CMD_NAV_ASCEND_WAIT) which operates the servos every 15 seconds to prevent them freezing as the Vulture 2 ascends to launch altitude. There's more on the Low Orbit Helium Assisted Navigator (LOHAN) custom programming here.

While the external temperature dropped to a teeth-chattering -50°C, it was comparatively tropical 0°C inside the payload box, in line with what we'd expect.

3689624498?profile=original

Linus and Tridge have identified some spikes on the servo rail voltage, which may require deployment of a zener diode, and we had the servo rail voltage a tad high at 5.6V:

3689624417?profile=original

The data from the airspeed sensor proved entertaining:

3689624438?profile=original

Tridge notes: 

"The blue line is the actual airspeed reading, which is apparent airspeed. It was very noisy over a small range. The green line is the true airspeed calculated by TECS during the flight by using the EAS2TAS ratio. The red line is the GPS vertical velocity, which ideally should match the true airspeed.

"The GPS vertical speed and true airspeed do follow the same curve, but are offset by a factor of around 1.5. It would be nice to work out why that is."

Suffice it to say, we're on the case and are planning a second test flight to check out any necessary mods to the system. There's more on the above data and analysis right here.

Read more…
3D Robotics

3689624465?profile=originalFrom Wired:

Scientists who study wild animals want to get as close as possible to their subjects without stressing them out or disrupting their natural behaviors. One possible solution: remote-controlled rovers.

In a new study, Yvon Le Maho of the University of Strasbourg in France and colleagues equipped 34 king penguins with an external heart rate monitor that could be read with an RFID antenna (the same technology lets you into your office or onto the subway with the swipe of a card). A day later, they sent an unadorned 4-wheeled rover into the colony. Not only did the penguins let the rover get close enough to read their monitors, the birds’ heart rates increased less and returned to normal more quickly than when the same task was done by a human with a hand-held reader.

In another experiment, the researchers disguised the rover as a penguin chick and sent it into a colony of notoriously shy emperor penguins. The birds allowed it to approach (see above) and in one case even infiltrate a creche of chicks (see below). Finally, they tried the undisguised rover on southern elephant seals, massive animals that can weigh more than 7,000 pounds. The seals hardly seemed to notice. As the researchers write—with typical academic understatement—in a paperpublished today in Nature Methods: “This is notable as elephant seals generally react strongly when humans approach their tails (data not shown).”

Le Maho is already using the rovers to study how climate change is affecting the breeding success and survival of king penguins. But he and his colleagues say there are many other possibilities. The rovers could be modified, for example, to record vocalizations of animals or to gather data from sensors mounted inside their territory without disturbing them.

lemaho-s1

gallery-cam@2x.png Frederique Olivier/John Downer Productions, Le Maho et al., Nature Methods

Read more…
3D Robotics

3689624140?profile=originalInteresting new job listing at the New American Foundation:

New America’s International Security Program (ISP) is looking for a Project Manager to join our team in Washington, D.C. to support our efforts to create a primer on the development potential of unmanned aerial vehicles (UAVs). This booklet will serve as the definitive point of reference for this information and as a handbook for NGOs interested in using drones for their work in development, anchored in property rights. The primer will also draw out regulatory and policy concerns around the issues, such as risks in using UAVs, privacy concerns, and competition in certain markets with established businesses, such as aerial photographers, who might have an interest in introducing laws to limit UAV use.

In addition to editing and/ or writing the primer, the project manager will work with expert contributors who will furnish case studies and chapters for inclusion in the primer and also convene a group of experts in the field who will lay out the industry’s best practices for using UAVs across a broad range of activities in varied geographic contexts. The project manager will also work with a team of researchers to develop an online, interactive database of known instances of UAV use for development and property right uses globally that will accompany the primer.

Responsibilities

  • The project manager will work closely with New America’s International Security Program (ISP) and Open Technology Institute (OTI) to look at both the benefits and potential downsides involved with using UAVs in a development setting.
  • The project manager will be responsible for ensuring all project deliverables are completed in a timely manner, as well as writing sections of the primer, as well as editing and compiling the primer. This individual will also review and edit shorter articles, based on the book’s chapters, for placement in a variety of media outlets.

Qualifications

  • Experience as a project manager for similar projects, ideally in a policy research or NGO environment. The role requires someone who is persistent, resourceful, imaginative, able to work well under pressure. The ideal candidate will be able to coordinate and interact well with numerous experts in the field in order to solicit their input into the project.
  • Demonstrated interest in and knowledge of development processes, regulations, and concerns, particularly with regard to property rights, as well as the non-military uses of UAVs.
  • Excellent writing and communications skills.

This position will be a one-year contract, with the potential for renewal. Salary will be commensurate with experience.

Application Process

Please submit your resume, a cover letter depicting your experience and interest and three (3) professional references.  

New America is an equal opportunity employer committed to hiring a diverse work force at all levels of the organization thereby creating a culture that allows us to better serve our clientele, our employees and our communities. We value and encourage the contributions of our employees and strive to create an environment where everyone can reach their full potential and drive outstanding results.

All qualified applicants will receive consideration for employment without regard to race, national origin, age, sex, religion, disability, sexual orientation, marital status, veteran status, gender identity or expression, or any other basis protected by local, state, or federal law. This policy applies with regard to all aspects of one’s employment, including hiring, transfer, promotion, compensation, eligibility for benefits, and termination.

Read more…

SmartAP 3.0 Pro

3689624277?profile=original

The next generation of SmartAP Autopilot - SmartAP 3.0 Pro has been released for public recently. This is the state of the art flight control system for multirotor UAVs capable of fully autonomous flight. It has a powerful MCU STM32F4, 9-axis IMU, integrated telemetry module and the latest GPS receiver from UBlox (UBlox NEO 8) already integrated onboard. SmartAP 3.0 was developed using the latest electronic components available at the moment, which allowed us to achieve amazing results in navigation and control precision.


The list of SmartAP 3.0 features:
- Powerful microcontroller 32 bit 168 MHz STM32F4 ARM Cortex M4
- Compact board size of 8x8 cm (3.15"x3.15"), weight 60g, 6 layers PCB design
- Power supply from main LiPO battery (3S - 8S) support, up to 36 Volts
- Power supply from BEC 5V support
- 12V, 5V, 3.3V generated onboard
- Integrated GPS receiver (UBlox NEO8, GPS/GLONASS, up to 24 sats, 10 Hz) active antenna, exnternal module is supported as well
- Integrated telemetry module (100 mW), external module is supported as well (up to 5V@1A powered)
- Up to 24 PWM I/O support (5V out, high-power), SBUS support
- USB interface for configuration / firmware update
- 6-pin JTAG port for programming / debugging
- Various communication lines (UART/USART, RS232, I2C, SPI)
- MicroSD card driven by 4-bit SDIO interface for data-logging / parameters
- Backup battery for real-time clock and GPS receiver
- Integrated main LiPo battery voltage monitoring
- 4 ADC inputs, battery voltage / current monitoring
- Electromagnetic sound audio indicator
- 4-channels bright LED support (up to 100mA/ch)
- Sound voice speaker support
- RBG LED Indicator
- 2-channels solid state relay

Sensors:
IMU: InvenSense MPU-9150, STMicroelectronics LIS3DSH
Magnetometer: Honeywell HMC5883L
Pressure sensors: MS5611

Firmware capabilities:
- Extremely stable flight in stabilize (user control), position hold (semi-autonomous control) and auto (fully autonomos navigation and control) modes.
- MAVLink compatible Ground Control Station protocol
- Accurate GPS Position hold (up to 40cm with good GPS reception quality)
- Accurate Altitude hold (up to 10 cm), manual altitude override
- Fully autonomous waypoints flight, return to home mode
- Low battery detection and event triggering

Here is the demo video showing Altitude and Position Hold mode:

More info about the project can be found at http://sky-drones.com/

Read more…

APM X8 redundancy is brilliant

Just a post as a compliment to the Devs. Today, I was able to test a full flight with my X8 with a payload and a motor out. Only a 3kg load instead of the maximum 4.5kg, but that's a design fault of my own in the target bracket, not of the magnets or of the X8.

It flew as if nothing was wrong. Start to finish, I had full control, and it behaved almost as if the motor was actually working. Only the tiniest bias on roll to one side, but you probably wouldn't actually notice. Some hot motors when I landed (perfectly, and with absolute control I might add).

So all I can say to the Devs - top notch stuff guys. Really top notch.

Can't wait to try it again with a full payload (4.5kg)...

Read more…

Sony camera controlled with RC transmitter

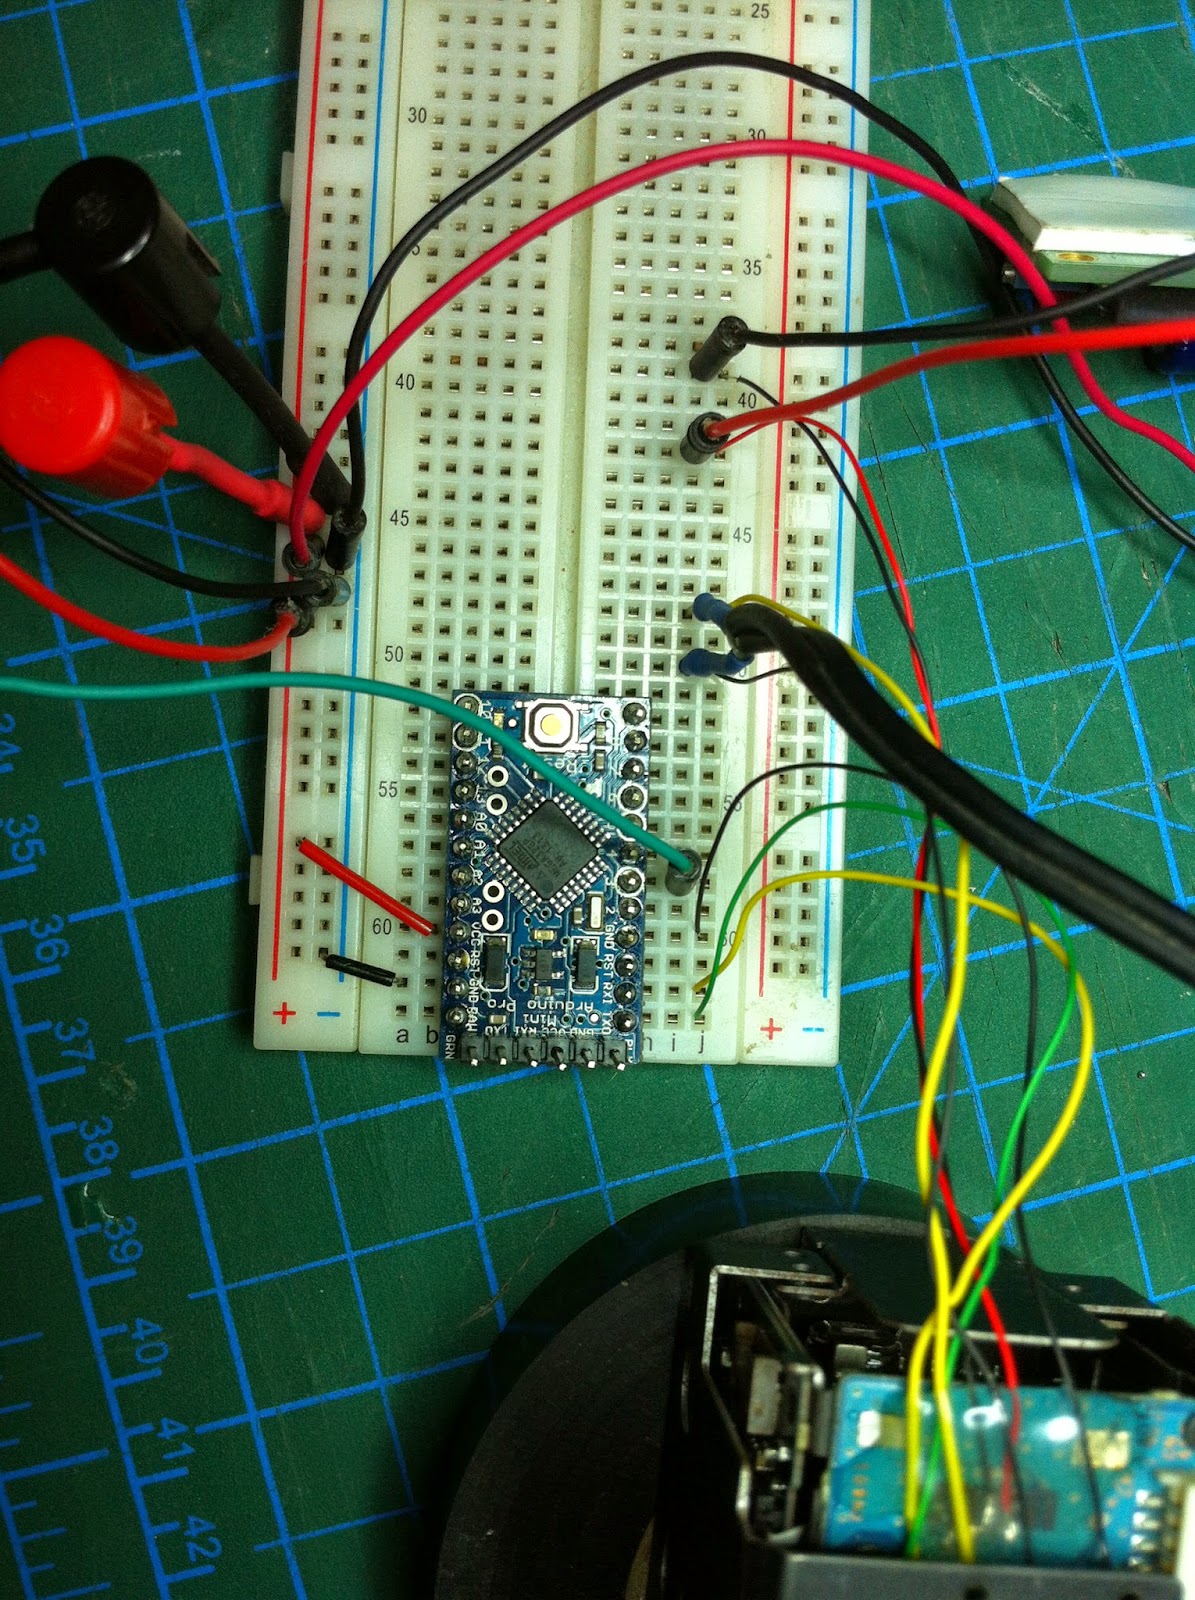
proxy?url=http%3A%2F%2F2.bp.blogspot.com%2F-GuyfBo2dEGo%2FVFZE4UkC6sI%2FAAAAAAAAAJo%2FbVkSWvEyeKs%2Fs1600%2FIMG_1774.JPG&container=blogger&gadget=a&rewriteMime=image%2F*&width=350for this demo I used 3.3v as power source for the receiver but in real life it will probably be a 5v power source so you'll need to figure a way how to do it (resistors, level converter...) 
 
so let's start 
what you need:
sony block camera (visca)
arduino (3.3v)
rc transmitter
rc receiver
monitor with av
 
fcb-ex11d
 
arduino mini 3.3v

proxy?url=http%3A%2F%2F3.bp.blogspot.com%2F-oWvvP1604Zk%2FVFZPMQ2lr1I%2FAAAAAAAAAJ4%2FlzkHQYpbMEE%2Fs1600%2FIMG_1783.JPG&container=blogger&gadget=a&rewriteMime=image%2F*

 
rc transmitter - spektrum dx6i

proxy?url=http%3A%2F%2F2.bp.blogspot.com%2F-RLpI2rdz3fo%2FVFZPkTL4nAI%2FAAAAAAAAAKA%2FRX-0ULUHuH4%2Fs1600%2FIMG_1772.JPG&container=blogger&gadget=a&rewriteMime=image%2F*

 
ar6200

proxy?url=http%3A%2F%2F1.bp.blogspot.com%2F-r-CTWmjzRZM%2FVFZPmyFs15I%2FAAAAAAAAAKI%2FewwSnEBLiXU%2Fs1600%2FIMG_1777.JPG&container=blogger&gadget=a&rewriteMime=image%2F*

then you'll need to hook up the wires as so
camera rx to arduino tx
camera tx to arduino rx
camera gnd to arduino gnd
arduino digital pin 3 to reciever elev channel

proxy?url=http%3A%2F%2F3.bp.blogspot.com%2F-kgRUB4V93yM%2FVFZPr0LaL-I%2FAAAAAAAAAKQ%2Ffh_DBgBXPAo%2Fs1600%2FIMG_1779.JPG&container=blogger&gadget=a&rewriteMime=image%2F*

 
then you left with video and power
 
power specs says 9v plus or minus 3v
and video is ntsc so any suitable 
monitor will do the job

and of course the code :)


/* build and tested using
sony camera block fcb-ex11d and
rc transmitter spektrum dx6i with
ar6200 reciever and connected to the elev channel */
byte address_set[4]= {0x88, 0x30, 0x01, 0xFF};
byte if_clear[5]= {0x88, 0x01, 0x00, 0x01, 0xFF};
byte command_cancel[3]= {0x81,0x21,0xFF};
byte zoom_teleVar[6]= {0x81, 0x01, 0x04, 0x07, 0x23, 0xFF}; //zoom in 81 01 04 07 2p FF - p=0 (low) to 7 (high)
byte zoom_wideVar[6]= {0x81, 0x01, 0x04, 0x07, 0x33, 0xFF}; //zoom out 81 01 04 07 3p FF - p=0 (low) to 7 (high)
byte zoom_stop[6]= {0x81, 0x01, 0x04, 0x07, 0x00, 0xFF}; //stop zoom
byte auto_focus[6]= {0x81, 0x01, 0x04, 0x38, 0x02, 0xFF}; //auto focus

const int thisdelay= 250; //time between sets
const int zoom_out=3; //Zoom 

void setup() {
pinMode(zoom_in, INPUT);
pinMode(zoom_out, INPUT);
// initialize both serial ports:
Serial.begin(9600);
//send Address set
for (int i=0; i<4; i++){
Serial.write(address_set[i]);
}
delay(thisdelay);
//send IF_clear set
for (int i=0; i<5; i++){
Serial.write(if_clear[i]);
delay(thisdelay);
}
}


//zoom in
void loop() {
int zoom_inState=pulseIn(3, HIGH, 25000);
if(zoom_inState>1550 )
{
delay(thisdelay);
//Send zoom tele set
for (int i=0; i<6; i++){
Serial.write(zoom_teleVar[i]);
}
}

//zoom out
int zoom_outState=pulseIn(3, HIGH, 25000);
if(zoom_outState < 1400 )
{
delay(thisdelay);
for (int i=0; i<6; i++){
Serial.write(zoom_wideVar[i]);
}
}
//zoom stop
if(zoom_outState < 1500 && zoom_inState > 1400 ){
//send auto focus cmd
for (int i=0; i<6; i++){
Serial.write(auto_focus[i]);
}
//send zoom stop
for (int i=0; i<6; i++){
Serial.write(zoom_stop[i]);
}
}
}


void sendcommand_cancel(){
for (int i=0; i<3; i++){
Serial.write(command_cancel[i]);
}
}

next thing will be to import it to attiny85

will release the code later tonight

**got really cool board that im using called attami (google it :) )

i was told that it will cost 1euro (not assembled)

and will be available at c31c (chaos communication congress #31)

3689624257?profile=original
code for attiny85 or attami :)

/* build and tested using
sony camera block fcb-ex11d and
rc transmitter spektrum dx6i with
ar6200 reciever and connected to the elev channel */

#include <SoftwareSerial.h>

#define zoom PB0 // zoom
#define rxPin PB1 // rx
#define txPin PB2 // tx

SoftwareSerial mySerial(rxPin, txPin);

byte address_set[4]= {0x88, 0x30, 0x01, 0xFF};
byte if_clear[5]= {0x88, 0x01, 0x00, 0x01, 0xFF};
byte command_cancel[3]= {0x81,0x21,0xFF};
byte zoom_teleVar[6]= {0x81, 0x01, 0x04, 0x07, 0x23, 0xFF}; //zoom in 81 01 04 07 2p FF - p=0 (low) to 7 (high)
byte zoom_wideVar[6]= {0x81, 0x01, 0x04, 0x07, 0x33, 0xFF}; //zoom out 81 01 04 07 3p FF - p=0 (low) to 7 (high)
byte zoom_stop[6]= {0x81, 0x01, 0x04, 0x07, 0x00, 0xFF}; //stop zoom
byte auto_focus[6]= {0x81, 0x01, 0x04, 0x38, 0x02, 0xFF}; //auto focus

const int thisdelay= 250; //time between sets

void setup() {
pinMode(rxPin, INPUT);
pinMode(txPin, OUTPUT);
pinMode(zoom, INPUT);
// initialize both serial ports:
mySerial.begin(9600);
//send Address set
for (int i=0; i<4; i++){
mySerial.write(address_set[i]);
}
delay(thisdelay);
//send IF_clear set
for (int i=0; i<5; i++){
mySerial.write(if_clear[i]);
delay(thisdelay);
}
}


//zoom in
void loop() {
int zoom_inState=pulseIn(zoom, HIGH, 25000);
if(zoom_inState>1550 )
{
delay(thisdelay);
//Send zoom tele set
for (int i=0; i<6; i++){
mySerial.write(zoom_teleVar[i]);
}
}

//zoom out
int zoom_outState=pulseIn(zoom, HIGH, 25000);
if(zoom_outState < 1400 )
{
delay(thisdelay);
for (int i=0; i<6; i++){
mySerial.write(zoom_wideVar[i]);
}
}
//zoom stop
if(zoom_outState < 1500 && zoom_inState > 1400 ){
//send auto focus cmd
for (int i=0; i<6; i++){
mySerial.write(auto_focus[i]);
}
//send zoom stop
for (int i=0; i<6; i++){
mySerial.write(zoom_stop[i]);
}
}
}


void sendcommand_cancel(){
for (int i=0; i<3; i++){
mySerial.write(command_cancel[i]);
}
}

 
Read more…

CanberraUAV's Future Plans

3689624112?profile=original

After our win at the 2014 UAV Outback Challenge and the many subsequent team discussions, CanberraUAV has developed a detailed set of goals for the next couple of years (see below).

The general theme is that we want to build up a capability to run real-life Search and Rescue scenarios in concert with the emergency services. We also want to collaborate with other like-minded organisations to do the same.

And as always, we remain committed to publishing our documentation and source code and remaining an “open” organisation dedicated to advancing the field of civilian UAV technology.

We always welcome new members. So if you see something on the list of goals that you’re interested in contributing to, let us know.

Finally, it’s been an amazing 4 years since the beginning of CanberraUAV and we can’t wait for what the next 4 years will being!

The following goals we aim to complete in the 2015-2016 timeframe.

Imaging

Lead: Tridge

  • Researching new cameras that are able to detect a shoe sized object at 100m altitude
  • Imaging software improvement to detect the aforementioned shoe
  • Record a reference set of images of an area with items strewn in it, to be used for development of imaging software
  • Support use of common cameras (ie Gopro), and document shortfalls
  • Provide comparison images between cameras (multi-camera flights)
  • Start using thermal cameras (if not too expensive) in the future

Airframe development

Lead: Jack, James, Greg, Darrell

  • Development of a rugged airframe (Bushmaster mk II) that can carry an imaging payload for a 1 hour flight and does not require a prepared runway for takeoff and landing
  • Investigate use of petrol helicopters and high efficiency multicopters as option
  • Development of a simple small foam airframe (Techpod, etc) fitted out with CanberraUAV electronics. Test and develop range, duration stats

Ground Equipment

Lead: Chris, Matt

  • Develop a compact catapult/launch system capable of rapid deployment in remote locations as a possible solution to absence of runway. Suitable for 4-10kg airframes
  • Develop capture mechanism/procedure for recovering airframe in remote locations to minimise damage to airframe e.g. chutes, net etc
  • Improve transportability and readiness of our equipment to allow for short notice deployments when interesting opportunities arise. Know the capabilities and limits of our airframes and suitability for the particular scenario
  • Fitting out the Ground Control Van in a better way, based on our OBC 2014 experiences
  • Develop a ruggedised mini Ground Control Station (pelican case) to enable small footprint operations

Running a mini-OBC

  • Research the feasibility of running a small scale competition/challenge with the objective of finding multiple large and small objects in a given area
  • Running a “Drone Day Out” in conjunction with mini-OBC, to showcase technologies and provide information to the interested public

Radio data link R&D

Lead: Tridge, Stephen

  • Look at using 915-928 MHz ISM radios for high-datarate datalinks, as they give better range
  • Antenna Tracker improvements (depends on radio used)
  • Develop a 3G/4G solution for situations where it is appropriate
  • Look at the feasibility of a satellite data link
  • Enhanced link aggregation and failover
  • Investigate 2.4 GHz Ubqiuti radios if the 900 MHz radios don’t work out
  • Main goal is a long range / “high” bandwidth radio that can fit on small aircraft (ie. Skywalker)

Safety Management System

Lead: Chris, Jono, James

  • Develop and implement a mature safety system for CanberraUAV’s operations
  • Create checklists, procedures for each position. Includes abort modes and airframe/engine hours/battery cycle tracking
  • Create an occurrence form to track and identify hazards, incidents and accident
  • Try to continuously improve CanberraUAV’s safety by performing ad-hoc safety management activities.
  • Develop a safety management system for CanberraUAV
  • After 12 months, the goal would be to transition to the SMS, which would be ongoing and more mature way to continuously improve safety (compared to ad-hoc safety management)

Documentation and Admin

Lead: Stephen

  • Update documentation for the cuav and MAVProxy software packages
  • Investigate more effective ways to manage and publish documentation
  • General updates of the CanberraUAV website and “admin” github repository
  • Collating documentation into a “how to” guide for S&R organisations to quickly replicate our setup. Include data on different systems (ie. compare cameras)
  • Gain UAV Operators Certificate to enable non-hobbyist operations
  • Document a “how to” guide to enable prospective users to build our system step by step (suggest video/series of videos on youtube). This would include ground station setup, telemetry links, MAVProxy.

Collaboration

  • More work with universities, high schools and SAR organisations
  • Work with landcare or similar groups for environment monitoring type tasks
  • Build relationships with emergency services/SAR organisations (ie SES)
Read more…