All Posts (11086)

Sort by

PV-300-SS-AR.JPG?width=700

Today I officially shifted gears, now one year later after proposing it to the rest of my business colleagues, on how I was focusing our pet brand Digi-DNA, created from the evolution and adaptation of technology specific for aerospace manufacturing locally here in Charleston, South Carolina. This began over 4 years ago. Boeing placed a dreamliner plant in my backyard so to speak and changed the environment to say the least. Prior Project partners Verizon and LG we hope to engage now in the RPV markets as well. Finally following some ambitious dreams of aviation to which I could feasibly have full control of raw materials such as prepreg carbon fiber to full manufacturing and assembly of finished RTF products. All within a 15 min reach of my main office location, and for this I am quite excited. 


Edwin Link

175px-Edwin_Link.jpg


The Rosetta lander inspired me, more to really commit, I feel I am harnessing some of the ingenious nature maybe inferred from this man, Edwin Link, I feel it was no coincidence that shared the same bedroom for the same adolescent year almost exactly 70 years later. I guess it just has taken me a while to start really chasing my dreams.  I a former nationally ranked alpine skier have a significant competitive nature and which my siblings being very successful in there own fields, one in childrens toys and the other in automotive, I have felt it necessary to step up my efforts and finally figure out what my intrinsic purpose is on this planet.


Recently I decided to challenge myself to a personal goal to deign and develop and produce at volume a completely new design RPV, in the same time it would take DJI to with the Inspire, (they were successful, they inspired me) from when I heard about the pending announcement at the beginning of the month to the time that stock levels at their listed dealer list are reached. I really have no hard way to gauge this however I have a personal goal of 30 days start to finish, all at price points better than DJI and available before the holidays. I look at it as my own personal X type prize challenge, and so far I can say I have already been rewarded, or at least promised significant reward for pulling off that feat, then again if I hit anywhere close to my target the reward may then turn exponential. More on this project can be monitored at this thread but announced on diydrones.com as the pilot viper, with limited information.  It is all me so only so many hours in the day and I need to make this better than a inspire with the same specs or documented exceed in capabilities while roughly half the price, it is time for some american engineering and production speed akin to the space race under Kenedy, (or at least it is in my own head, I tend to have quite a imagination).So my name may be the Pilot Viper but I hope that I can say one day that maybe this is the DIY we did it better kind of thing. Many of the plans I will be pushing back to the community once complete with opensource steams if you will, so I can try not and fracture my core product, too much then at the same time focusing on. I also recently reached out to Randy about a few comments I want to provide to team of Jedi that mange the source code and do a majority of development.  


snapjaw-300-HD.gif?width=702

repeat picture the frame, from a week ago

I am ready for new pictures also;


ETTS LLC, stand for Extra Terrestrial Technology Systems LLC. and the brand and registered trademark or Digi-DNA is a personal project that has found reemergence through the help and direction of the DIYdrones.com community, 3drobotics and all of the individuals that I have delt with to date. Early on they operated at a level of business acumen I felt I could only see benefit. This foray has been done DIY style with a shoestring budget and I have nothing but gratitude for all that I have engage in the multi-rotor community at large.The cooperation I have experienced to date has truly been remarkable and glad I have found many like minds so far that see the opportunity is of abundance especially when the opensource community teams to create an overload of technology and innovation! I then have had the grace of working with Roberto Navoni at VR robotics and between him and John at 3dr I could not ask for better contact or partner for my OEM relationships. This was also resonated when finding Lucien at Innov8tive, and I feel lucky to have met each and every one to date. 

courtyard-flying-simulated.JPG?width=700

To mark the new commitment and focus, I have reached out to my close friend and business partner for many years Ron Bush shown here is a very touch and cheek segment, much like the name of our company, spoofing the very well known movie scarface.  


31e2fffd43d03605de8aacd298fc82c7_original.?width=700Photo Credit - Powder Your Nose

To now help me try and turn this up to 11 (spinal tap) glad to have the help on this now as up till now this has been pretty much a solo gig with just a few helping hands, glad to see the growth, and excited about the challenge or personaly X prize I have set for my self, thank you DJI Inspire, Thank you 3d Robotics, Thank you DIYdrones.com I have set my marching orders, now hopefully I can catch some of that comet dust of sucess now falling from the Rosetta lander.

I welcome all that wish to collaborate with us to reach out, and I may even reach out to you as I only see partnership with innovation as truly the method for success.  The Rosetta lander shows this well and could only hope to capture a thread of that type of unbridled collaboration crossing the globe.  Below is an example of Ron Bush's work who is now writing a few in a series of Drone or UAV shorts aimed at hopefully debunking myths about the technology (maybe Mythbusters reference yesterday at the DJI Inspire launch?) and helping to pave the road for hopefully our technology and continued success while also helping the community at large.

Hooker turf wars - watch more funny videos trans.gif

11, 12, 13, 14... we have lift off...

Above is another short Ron and Jenea did called Turf Wars, I am excited to see how they attack some of the drone hot button issues.. This was kinda a core dump based on the wave of excitement from the lander yesterday, if I made error let me know I am not all that proud and make lots of mistakes and look forward to in and all valuable comments.
Read more…

Maiden flight of world's largest 3d printed plane

3689625240?profile=original

I know posting about 3D printed planes on here usually results in 50 comments of people saying "give me some cardboard and packing tape and i could build something better in an hour..." so I would like to preface this with saying that this was an academic exercise and the vision for the future is that you could upload your mission requirements to an interface, some software would design an airplane optimized for your mission, and then a printer would print it, all without a human in the loop. So, yes, I understand the practicality implications, but I think this is a very interesting exercise.

That being said... we finally got our plane to fly! The aircraft was designed by a group of students from Purdue University, Brigham-Young University, and Georgia Tech during the last academic year but it was never flown before the students graduated. An attempt was made but the motor ingested some gravel and blew neodymium chunks everywhere. I upgraded the propulsion system, modified the control surfaces (they used to be printed but they were very delicate) and that's about it. For this flight, I took out the ardupilot and just flew it manually.

Video of the flight here

All up weight with batteries was 12.000 lbs. Span is 8', and I can dig up area and wing loading and all that stuff. Flew it off 2 5S 5000mAh batteries ganged together to make 10S. 16x12 prop.'

Aircraft is almost entirely FDM, made on a fortus machine. There is a carbon fiber spar running down the wing and the control surfaces are foam. Other than that, everything you see is ABS.

Very wiggly in yaw, which was surprising as the scale model we flew last year was fine. Could be the fancy winglet design.

As you can see from the video, the landing was on the hot side, but the structure held up impeccably. There are sacrificial landing skids that did their job and broke on impact and we can just pop new ones in to fly again.

All in all, I'm overjoyed it finally flew! It's been quite a few months since the last attempt.

3689625362?profile=original3689625515?profile=original3689625383?profile=original

Read more…

An Autopilot in the clouds - part 5

An Autopilot in the clouds - part 5

3689625272?profile=original

This article is part five in a series, describing some of the inner workings of an autopilot system - even though the description is specific for this particular system, a lot of principles are generic and can be used to describe a variety of auto pilot systems.

Today we’ll look at building the electronics for the new UAV (the UTV-1) incorporating some lessons learned from the smaller UTV-3.


Intro

If you’ve read the previous posts you’ll know that I’ve been working on an Autopilot with an architecture that allows the platform to run several instances of the autopilot and separate the autopilot from the airframe. This allows rapid testing and the potential to have central computer system that coordinates several drones in a join effort to solve a task.

So far the tests have been conducted on a relative small airframe, which only allowed the basic hardware and the autopilot computer to be ground based. This allowed a lot of concepts to be tested and paved the way for the next test vehicle.

The airframe will be the Zeta Science Phantom 61 - It’s very familiar with the z-84 which was used for the small test vehicle. Now we need to figure out what to stuff in the airframe and how.


Requirements

The current test vehicle was build only to test the basic concepts and software. The new vehicle will host some sensors and a computer that can analyse the collected data in real time. To experiment with this aspect, the airframe will be fitted with two downward facing cameras - one regular and one with the filter removed (a simple NIR camera) and two gas sensors. The place I do testing is close to some waste dumps etc, so it would be interesting to analyse the surroundings and map gas concentration to a map.


Lessons learned from UTV-3

Flying up here can be a wet experience and even the most gentle landing will get your plane wet. I had a few incidents that was probably caused by electronics meeting water. In this vehicle we want to bring a computing platform (an adapteva parallella or a raspberry pi), and other delicate equipment that should be protected from the elements. That means that some electronics will be fitted inside an enclosure, that can shield it somewhat from the elements. The “somewhat” implies that we don’t want 100% water tight shielding since some sensors need to be exposed to the outside pressure and temperature - namely the IMU with the barometer sensor and the two gas sensors used to analyse the air quality.


HW Sensory

Computer platform - Raspberry Pi B+ or Adapteva Parallella

Cameras - Raspberry PI Camera and Public Labs Infragram camera

Gas sensors - Methane and Carbon Monoxide sensors MQ7 & MQ4

Arduino nano 32u for analog input and processing

2x UBEC - 3 amps for power to the systems

IMU Crius SE 2.5


Layout

Even though we work with two enclosures, we still want the modularity of the complete package, which allows us to test most of the setup outside the actual airframe. Since there are some links between the two enclosures, both are mounted on the same base plate which allows easy interconnection and testing (a test rig)

Each enclosure has it’s own UBEC that supplies power.


The IMU/Sensors platform

One enclosure houses all sensors (not counting the two cameras) including the two gas sensors. It is seen to that the enclosure is naturally ventilated, to make sure the outside air can get in.

3689625170?profile=original

Everything inside is marked with labels, and fastened with vibration dampening pads.

3689625297?profile=original

The two gas sensors have built in heaters that needs to be on for at least 60 seconds before good measurements can be made. Sensors is connected to a 32u based Arduino with 10 bit resolution.

3689625185?profile=originalThe final enclosure will also host an analog accelerometer that will measure the vibration of the enclosure and the craft, which can be monitored from the ground. The watchdog system will also monitor for large vibrations through this sensor and will warn if the ride starts getting bumpy. 

A little field test

So test out the enclosure with the sensors, I attached the enclosure to my car and drove out to the dirt-processing plant close to the place I conduct my testing. It was very pleasing to see some quite big “peaks” while passing a certain place. Below we see the two peaks (a bit left from the middle) as a result as passing a certain location, turn around and drive past it again.

3689625323?profile=original

Without calibrating the sensors we can’t say exactly how much Monoxide and Methane we measure, just that we see more some places than others. For now thats okay, it proves that the gas sensing unit works and is able to measure differences in gas levels with a strong airflow going through the enclosure.


Next time

Next post will be about the complete test rig, that in the end will be fitted in the craft. With all the features of the electronics some extensive testing is needed. Also, power measurements, stability and so forth is essential to uncover before placing the electronics on the airframe. 


Read more…

Parrot Bebop paparazzi integration

Hi UAV community,

3689625429?profile=original
As you know paparazzi is very modular platform. To show the world how modular we are, we work hard on implementing paparazzi into the Parrot Bebop. At the Micro Aerial Vehicle Laboratory MAVLab of Delft University of Technology faculty Aerospace engineering TU Delft we received a pre-production model of the Bebop. We do our best to have paparazzi integrated before the launch of the Bebop. If you want to follow the progress check our youtube channel

after 4 hours after reception of the Bebop

8 hours later after hacking the ESC check-sum First Flight!!!!

kind regards,
Read more…
Moderator

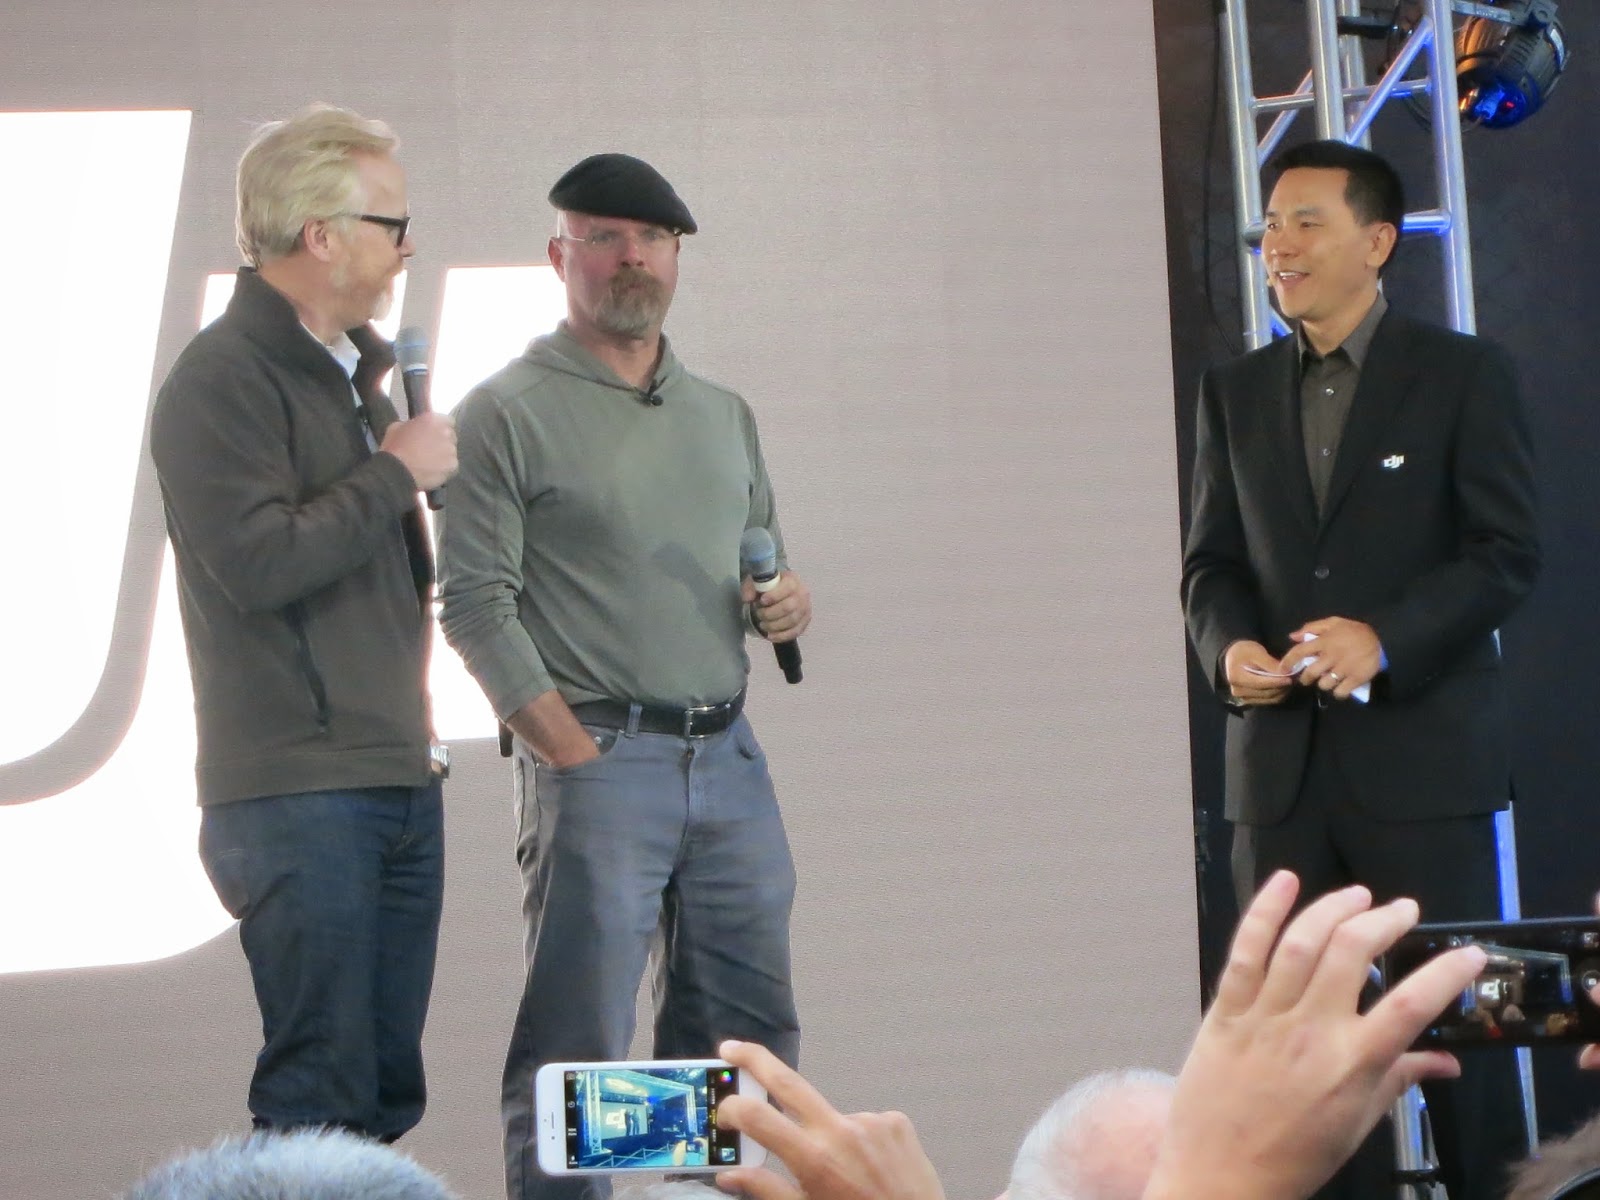
EastBay RC Attends the DJI Inspire Launch

Drone Photographer Extraordinare Eric Cheng has been a long-time friend of EastBay RC, and he kindly invited me to the DJI Inspire product launch.

It's an impressive unit and looks to be competitive in the "prosumer" aerial photography market.

I shot the video above, and have collected some notes over on EastBay RC.

http://eastbay-rc.blogspot.com/2014/11/eastbay-rc-attends-dji-inspire-launch.html

With a special appearance by celebrity drone enthusiasts!

IMG_5149.JPG?width=400

Read more…

DJI INSPIRE 1 in Action

DJI's New Inspire 1 - Reviewed by Octofilms

H style frame

Be able to fold each side of the H frame around the body for an easier transportation mode

Larger than the DJI Phantom 2 and looks almost larger than the Flamewheel 550

Possible 4K camera

3 axis gimbal

Possible built in FPV monitor in the remote control of the quadcopter utilizing DJI’s high definition Lightbridge system

Read more…

3689625145?profile=original

ICAO address is used as unique airframe identifier for so called Mode-S transponders - http://en.wikipedia.org/wiki/Aviation_transponder_interrogation_modes#ICAO_24-bit_address.


It is likely at least in Europe that beyond line of sight UAV operations in future will require equipping UAVs with such transponder.


So we decided to start working on ADS-B OUT transponders integration with popular autopilots and adding these features to our ground control software UgCS (www.ugcs.com).


As first carrier we have selected 3DR Quad with Pixhawk.


Why Pixhawk? -  This line of autopilots have matured and we expect lot of  commercial applications will be using it. We will be ready for that with our solution for Pixhawk- ADS-B transponder integration.


We selected 3D Robotics Quad because we have lot of them and they are symbolic for getting quads and UAV technology to the masses. :-)


We will use Sagetech XPS-TR transponder because of its small size and weight, which allows equipping even lightest UAVs with it. 


4 months ago we approached Latvian Civil Aviation Agency with request to provide us ICAO 24-bit address for our quad, and now it has happened! 


Latvian Civil Aviation Agency (FAA analogue for us) has issued ICAO address 502С08 for our little bird - 3DR Quad with "tail number" 6 (see picture).


In a month or two it should appear on flightradar24.com.


UgCS Team

Read more…
3D Robotics

3689625118?profile=original

This is good news for Bay Area drone research! From Business Week:

Google Inc. has agreed to a $1.2 billion lease of NASA’s Moffett Field airfield in California for 60 years, as the company invests in new technologies such as robotics and aviation.

As part of the deal, Google subsidiary Planetary Ventures LLC will invest more than $200 million in improvements at the site, which is near the company’s headquarters in Mountain View, according to a NASA statement. The facility is slated for research, assembly and testing in the areas of robotics, space exploration, aviation and other technologies, it said.

Google is committing more resources to cutting-edge technologies as it looks for new ventures beyond its core online search services. The Internet search provider has acquired several companies in a robotics effort that was led by Android co-founder Andy Rubin. Last month, Google said Rubin was stepping down and that James Kuffner, a research scientist, would take his position. Other research efforts have included wind power, driverless cars, drones and computerized eyewear.

Read more…

GPS Kalman Filtering in PyQuadSim

This video shows recent work by Washington and Lee undergraduate student Shannon Nollet: a simple Kalman filter being applied to the a simulated noisy GPS signal in PyQuadSim (http://home.wlu.edu/~levys/software/pyquadsim/), a Python quadrotor simulator.  The yellow plot is the original, noisy simulated GPS signal (latitude / longitude), and the green plot is the GPS signal filtered using the Kalman filter in OpenCV.  Despite our use of a linear filter (as opposed to the Extended Kalman Filter used in actual vehicles), and despite the filter having only two state variables (latitude, longitude), the filtered GPS signal is good enough to support hover-in-place in the absence of stick input.  I am hoping that students, researchers, and hobbyists can use these kinds of simulations to help  learn about the Kalman Filtering that is essential to the firmware of Autopilot systems like Pixhawk, OpenPilot, and others.

Read more…

01-DSC_2230.jpg

I know there have already been a few posts regarding the 2014 UAV Challenge however the official photographer "Stefan Hrabar" has just published his photos of the event and they are certainly worth seeing.

Brings back many happy memories of my week in Kingaroy as a member of Team Thunder.

The link to the 2014 gallery is

http://www.uavchallenge.csiro.au/galleries/2014/index.html

Read more…
Moderator

The Solution Has Got To Be In Here Somewhere

3689624925?profile=original

By Patrick Egan who is currently on a plane to Norway

(The go-forward plan for the rest of us.)

The FAA has long since left the academic, amateur and small business end-user and the public in the dust as actual participating stakeholders. The only “full-spectrum” of stakeholders invited are the DOD vendors with lobbyists and political friends. (Maybe if I wrote Buck McKeon a six-figure check I’d get two slots on the UAS ARC??) You’d think that shame or sentimental ideas of participatory democracy might come into play with something so important. The only place you see or hear that is in old movies, and or stories from old-timers who remember a way of life where people were good for their word. Unfortunately, it would appear that Mr. Smith left Washington D.C. many years ago.

Those who have followed the sUAS News writings might well understand the old shell game. For the newcomers, three card Monty or the pea and the shells is the U.S. UAS airspace integration game.

Yes, some of the stories may be obscure, but I’ve had to utilize allegory and aphorisms as a courtesy and not come right out and to expose the source. Don’t want to ruin someone’s career, backroom deal, or whatever angle they may have going. No shortage of that over the years and from folks in this effort that all purportedly say, “we all want the same thing.” They will straight up blackball people (some possibly their own kin) without any reservations totally devoid of either scruple or moral compunction. You’ve got Federal employees banning or reassigning other federal employees for not going along with the program. Then there’s the one way ticket to Pariahville (formally Palookaville) for any stakeholder who’s script they (or the DOD folks) don’t dig.

For those of you that think it too fantastic to be true… I wish. Heck, I was almost kicked off of the current FAA BVLOS committee before I even accepted. (It would appear that those not well practiced in the art of bootlicking are not really welcome??) A couple of choice quotes for educational purposes.

“The ARC debated your inclusion on this working group for some time. However, the FAA wanted your organization involved, so feel free to delegate to someone else at RCAPA.”

And most of you thought the FAA was the only group sandbagging the process.

“We all hope you are constructive and keep the bomb throwing to a minimum. This is not a seat on the ARC, but a working group, and it can be revoked at any time.”

“Bomb throwing!” Does this sound like “we all want the same thing?” It lacks a certain inclusive tone, but I don’t want to be accused of nitpicking.

On the other side of the coin, you go quietly along with the program, and there is more than likely a nice golden off ramp in your future. Maybe a DOD vendor or some other cushy spot where you can go play the do nothing game till your interests become vested. Funny (ironic) part is… it takes a few years for a new employer to realize what type of “we all want the same thing” they got.

Read the rest of Patricks article here http://www.suasnews.com/2014/11/32584/the-solution-has-got-to-be-in-here-somewhere/

Read more…

Ambulance Drone' ... a flying defibrillator!

3689625019?profile=original


JUST AMAZING! A Dutch-based engineering student has revealed a prototype 'Ambulance Drone' ... a flying defibrillator! 

It can fly at speeds up to 100 kms per hour and tracks emergency mobile calls using GPS to navigate.

If an ambulance took 10 minutes to reach a cardiac arrest patient, the chance of survival is only 8%. But the drone can get a defibrillator to a patient inside a 12 km sq zone within a minute, increasing the chance of survival to 80%.

Once at the scene, an operator, like a paramedic, can watch, talk and instruct those helping the victim by using an on-board camera connected to a control room.

Visit alecmomont.com for more information.

Ambulance Drone

Read more…

Exmaps: Online Flight Logbook for Ardupilot Update #2

3689624981?profile=original

First of all thanks for all the feedback .We have been busy improving the system and today I am pleased to announce the following:

- Support for Tlog, Log and Bin. We also unify the upload boxes into 1 but to do this we had to drop support for logs without GPS Week. 
- Flight modes for Tlogs.

- Able to process logs without account. We felt that there are people who just want to process 1 log or try out the system without signing up. So we have implemented a public log upload ability at the front page.
3689624904?profile=original

- Auto scaling of data points according to flight time hence short flights will produce sensible graphs and long flights will have data trimmed. 

- Battery information such as mAh, Average current with ability to summarised by modes. 
3689625003?profile=original
Total mAh is important because actual flight time is not dependent on how much mAh that is stated on your battery pack but rather how much useable mAh there is. There are many reasons why useable mAh is way below rated mAh.
i) Your battery manufacturer lied on the rating
ii) You are drawing high Amps. Ratings are measured using discharge 1C. 
iii) Battery is old
iv) Your personal rule for cut off voltage per cell is above 3.0v. 
Looking at average Amps drawn together with Total Amps also allow you to quantify the improvement if you upgraded the battery. 
We also introduce mAh/km information. We think this is important if you are planning to do straight line flights like drone delivery, mapping. What is important is how efficient your platform is. Ideally if you upgrade your motor/propeller/battery etc, your goal is to minimise mAh/km for the same payload. This is also similar to cars which use km/litres. It offers a baseline understanding of fuel efficiency between car models 

- Flight details such as average speed, distance travelled summarised by flight modes. Most UAVs are switched on (manual mode) but not flying hence data for all modes might not be relevant. Filter to the mode that you want to understand. 

- Error messages are now plotted on map and shown on log list page.

3689624916?profile=original

(Map shows throttle failsafe error, later deduced to be 2.4Ghz jamming in the area) 

- Ability to download uploaded logs

- Ability to sort flights by date

- Improved UI and backend

Thats all for this update. The service is free at www.exmaps.com . I hope you give it a try and let us know how to improve. Meanwhile, fly safe!
Read more…

3689624853?profile=original

The 2nd app - RPAS Logger Plus - in our RPAS Logger Enterprise suite now enables you to export your logs to create reports as you wish. It is also ready to sync your data with the RPAS Logger Enterprise website. The RPAS Logger Plus app is US$9.99 and the RPAS Logger Lite is Free.

We have developed a suite of mobile and cloud / desktop applications on Android, iOS app and RPAS / sUAS / UAV / Drone Job Management website that integrates with your mobile devices called RPAS Logger (Remotely Piloted Aircraft System = RPAS )

Our iOS app is submitted to Apple and will be available next week. Once the iOS app is available we will officially launch the Enterprise website which is a breakthrough in managing all potential government compliance issues. It is designed to streamline your official Australian CASA application and built according to the latest ICAO requirement which is the standard that the FAA and most Civil Aviation Authorities world wide are aligning their drone laws too.

RPAS Logger EnterpriseThis is the flagship version of RPAS Logger. Unlike the Lite and Pro version, RPAS Logger Enterprise is a cloud-based solution. All Data is kept in the web application and your mobile devices will now become access points that you will be able to use on and off line to collect and log data. You can use the Android / iOS apps when you don't have internet access and sync it up when you connect again. 

The apps include a bar code scanning feature for battery / maintenance management and our latest (most requested feature) allows you to use your GPS location on your mobile device to show you the nearest airport / helipad etc to your current location which will help in completing your Risk Assessment for each job or flight. www.rpaslogger.com 

It is oriented towards a commercial operation or hobby clubs. It will allow you to create jobs for customers, assign equipment and personnel to different jobs, manage area approvals and risk assessments, manage maintenance requirements and inventory.

Modules include:
Basic Module – everything required to create jobs, manage airframes, batteries and role equipment usage, manage pilots (including type endorsements and certifications) and produce comprehensive reports.

  • Maintenance Module – Keep maintenance logs for all equipment and manage your inventory - including shelf life and minimum quantity reporting.
  • UOC Manuals – online management of your flight, operations and maintenance manuals. Easily update your entire documentation suite with any changes that you make to your fleet, role equipment or operational parameters.

We will appreciate any feedback or request for new features. Rest assured, we have a long list of upcoming features but use your comments to help prioritise our updates. 

Read more…
Developer

ArduCopter 3.2 ready for wider use

After months of testing, ArduCopter 3.2 (aka APM:Copter) is ready for widespread use and we invite all users to give it a try.  In order to manage the support load at first it will be available only through the Mission Planner and APM Planner2's Beta Firmwares link.  This link is visible from the regular "Install Firmware" page if you check the "Advanced View" on the Config/Tuning >> Planner page.  On APM Planner2 the "Advanced View" it is under the File menu.

In about two weeks we plan to replace AC3.1.5 with AC3.2 as the default version dispensed by the ground stations.

The full list of changes can be found in the ReleaseNotes but here are the highlights:
Flight Mode Enhancements:

  • PosHold flight mode: similar to Loiter but with direct response to pilot input during repositioning
  • ACRO mode handling improvement EXPO (for faster rotations)
  • Drift mode uses "throttle assist" (similar to AltHold)
  • Smoother transitions between flight modes (i..e when entering Loiter or RTL from high speeds)

Mission Enhancements/Fixes:

New Sensors/Devices:

Safety Features:

  • EKF/DCM check will switch to LAND mode if heading error > 60deg for 1 second
  • Baro glitch detection
  • Pre-arm check for Gyro calibration success
  • Pre-arm check that internal & external sensors (gyros, accels and compass) are consistent (Pixhawk only)
  • Parachute support (Pixhawk only)
  • Feedback to Pilot when taking off in AltHold, Loiter, PosHold (i.e. motors spin up a little as throttle is raised)
  • EKF (new attitude and position estimate system only used for reference in this release)

Bug Fixes:

  • Pixhawk GPS driver buffer overflow that could lead to missed GPS messages
  • Pixhawk I2C bug that could lead freeze up if I2C bus is noisy


Known issues/Warnings:

  • Pixhawk users will need to recalibrate their compasses
  • PosHold won't show up as option on FlightMode screen if you have an old version of mission planner.  Please select Help > Check for Updates
  • Landing detector is more strict meaning it may take longer to disarm after RTL, AUTO
  • Set THR_MID parameter especially if you have a very powerful copter because "Feedback to Pilot" raises throttle to 1/2 of THR_MID
  • Spline twitches slightly as it passes a waypoint especially if WPNAV_SPEED is set > 500.
  • Dropped support for NMEA and SIRF GPS on APM boards (ran out of Flash space)
  • Dropped ssupport for sonar for MultiCopters on APM1 and TradHeli on APM1 & APM2 (ran out of Flash space)

If you hit issues, please post them in the APM Forum and include a dataflash log file if possible.

Special thanks the Marco and the Beta Testing team from the AC3.2 beta testing thread who put their copters at risk in the pursuit of a smooth, safe release.  Here are links to some of their videos: Marco's DJIs900, Holger's Water Tower, Josh's Acro, Ray's TradHeli2&FPV, Raph's Hawaii, PhillS's CommandYaw,  Thor's Zombie Run&FollowMe, Phanivyas's Test, Rob's TradHeli, Christian's Test1&Test2, Balloon's Spline, JimJ's FPV, Ultrojo's ROI & Spline&FollowMe1&FollowMe2, Troy's Mission

Thanks also to the code contributors to this release including Tridge, Jonathan, Leonard, RobL, Paul Riseborough, MichaelO, Julien Dubois, David Dewey, Andrew Chapman, Emile, Allyson and many more.  If you want to get involved check-out our dev wiki.

Read more…

sensefly_big-1415247389211.jpgSenseFly's eXom Drone Uses Vision and Ultrasound to Fly Precisely, Safely

Since Parrot acquired senseFly back in 2012, we’ve been looking forward to seeing what the EPFL-LIS spinoff would come up with next. If you were paying close attention a few weeks ago, you noticed a little teaser for a new drone called eXom. It looked awesome. Turns out, it is awesome, and here are details.

First, let’s have a look at the eXom drone in (admittedly quite limited) action:

Several things are being demonstrated here:

In this clip eXom is flying 100% autonomously, without being remotely controlled and without the use of GPS. It is using its onboard vision and ultrasonic proximity sensors to stabilise, hold and correct its position, while the artificial intelligence built into its autopilot enables it to execute pre-programmed movements in sync with the music.

So the demo is of the fact that the drone can “dance” around while maintaining its position in the air, without the aid of external tracking or GPS. This is where you can see some of Parrot’s influence, because this software and sensor-driven inherently stable behavior is one of the things that makes the AR Drone so easy to fly.

The eXom drone is fusing inputs from multiple sensors for position holding, but just like the AR Drone, it’s depending primarily on two: downward-facing sonar to maintain altitude, and a downward-facing camera that’s doing optic flow tracking on ground features to maintain x/y position. This, incidentally, is likely why the surface underneath the drone has that tile pattern: more unique features means better tracking, and it’s possible (even probable) that the drone would drift a bit above a featureless surface like solid carpeting.

While Parrot’s drones (including the new Bebop) have just one of these modules that fuse vision and ultrasonic sensing, eXom has five, for optimal coverage in 360 degrees, not just downward: sensor module locations include left side, right side, underbelly, rear, and built inside its forward/upward facing camera head.

SenseFly had two goals with eXom. The first was to “create an autonomous quadcopter that is highly stable in the air,” and the second was to “produce the safest system on the market by giving the user full situational awareness.” With the comprehensive coverage from these vision and ultrasonic sensors, eXom can detect obstacles just about anywhere around it.

The company says that the user will have several options on how to leverage this with different flight modes of various levels of autonomy:

  • Interactive ScreenFly mode – click or tap the on-screen video feed to define an object of interest. eXom’s intelligent autopilot moves the drone into position and directs its TripleView head automatically.
  • Autonomous mode – define the area to map using the drone’s eMotion software. The software automatically generates the drone’s flight plan, then eXom takes off, flies, acquires imagery and lands itself (similar to senseFly’s fixed-wing eBee drones).

These capabilities are very cool, especially if they can compensate for bad piloting when in manual mode. Some drones can do this with GPS to a limited extent (like, you set up a safety box of GPS points somewhere in midair), but I’d absolutely love a drone that could use onboard sensors to prevent me (one of those aforementioned bad pilots) from running into any obstacles or the ground. And also, you know, the whole delivery drones thing: any reliably safe urban delivery drone would probably need a sensor package a lot like this.

Now, let’s talk about that crazy looking camera head. While Parrot’s Bebop drone relies on software to provide active stabilization while simulating a pan/tilt camera, eXom does it the old-fashioned (if you want to call it that) way, with a camera system that is hardware stabilized and can physically move to look around. The camera head itself has a 270 degree vertical field of view, meaning that it can look both straight up and straight down and even slightly behind.

In terms of actual cameras, you’ve got two: a HD video camera that can also capture ultra-high resolution still images, and a thermal camera. You can record all of these data at once, meaning no landings to switch sensors. With a drone that can safely get very close to objects and take high resolution images of them, we’re probably looking at a drone that’s optimized for civil infrastructure inspection.

In other words, this drone is more like a tool than a toy, and as such it will not be an inexpensive piece of hardware. Were we to guess wildly, we’d put the cost of eXom somewhere in the very low five figures, partially because as with senseFly’s other drones, you’re not just paying for the hardware, you’re also paying for the spectacular control software and the reliable out-of-the-box workingness. And from the look of things, it’ll be worth every penny.

[ senseFly eXom ]

Read more…