All Posts (11086)

Sort by

Let the projects begin!!!

And now the Fun Begins

It's time, the planing is complete, the mission has been established, and the electronics platform for the HK1, is on order. I have taken easy route, and decided to order a plane that I will customize for my project, I think that this will be fairly successful and as my first UAV I think that's saying alot! I will take the wing set and install them into a redesigned fuse, that will house the electronics and powerplant. This plane is unique and blends the hobbies, that I love! Robotics, R/C planes and Rockets, just to name and few! And if you think that is a type then you are nistaken! that is correct, this UAV is desiged the be a Quick Response Vehicle, what's the use in working on a electronics Prototype if you don't have a goal for it? This particular plane will be rocket powered on take off allowing it to be dispached to a locatation that we may not be able to get to quickly and then transistion into a slow flight, currently I am working on a time on station of like three - five hours, but to start, lets just work on getting her home! .... Pictures on and schematics to come shortly so stay tuned the build will be awesome!On a side note, anyone out there have any guidance for vision tracking? and help on one of those awesome little camera ball units?

Read more…

Communication keeps getting cheaper

Module_Transparent_sm.jpg

These are basically 300ft XBee's for $10. They have no UART, only SPI. They don't have the GPIO functions of XBee's. They're the same size as XBee's. The idea is to bring the data processing of a really powerful computer on the ground to ever smaller, cheaper aircraft with these high speed radios.MicrochipHopefully Microchip is following the Sparkfun model of selling prototyped versions of its chips & not running short batches for reference designs.
Read more…

I'm still confuzed on the power for the board

Hey guys I've fried 2 boards already, first one dunno why. The second time was a stupid impatient error of judgment. Anyways, unlike most of you I have a Nitro engine so no ESC. I'm tired of shorting my board so I want to make sure I understand 100% where my power can come from. I got my board in the mail yesterday, but the back is stamped 1-12-09. It looks like the new ones. I'm not a newbie to electronics, I'm just paranoid now. Thanks
Read more…
3D Robotics

Fred Smith: FedEx wants UAVs

FedEx founder Fred Smith came by the Wired offices yesterday for a chat on a range of things, but I'll focus here on the bit relevant to this site. He says that they'd like to switch their fleet to UAVs as soon as possible but that this will have to wait for the FAA, which has a tough road ahead in figuring out the rules of NAS integration. Unmanned cargo freighters have lots of advantages for FedEx: safer, cheaper, and much larger capacity. The ideal form is the "blended wing" (example shown). That design doesn't make a clear a distinction between wings and body, so almost all the interior of both can be used for cargo. The result is that the price premium for air over sea would fall from 10x to 2X (with all the speed advantages of air). As he notes, a modern 777 is already capable of being an unmanned vehicle. "They let the pilots touch the controls for about 20 seconds, to advance the throttles, and then the plane takes over," he said, only half-kidding. The truth is that the plane can take off, fly and land itself. Today pilots drive the planes on the ground, but there's no reason why the computer can't do that, too. Sully's a hero, but Smith's perspective is that humans in the cockpit make the airways more dangerous, not less. Because the FAA rules are not in place, nobody's built that perfect blended wing UAV for FedEx yet. But Smith believes it's only a matter of time. As he notes, the key thing is having NO people on board, not even as backup. A single person in the craft requires a completely different design, along with radically different economics and logistics. The efficiencies come with 100% robotic operation.
Read more…
3D Robotics

Tiny 5MP camera coming out

Autofocus, image stabalization, etc. Seems perfect for UAV use. From robots.net "Advasense has announced what they claim is the world's smallest 5MP autofocus camera module. The module, which was developed with the help of Creative Sensor Inc., uses a technology called Feedback Controlled Pixels (FCP) to reduce image lag and noise within the tiny sensor. The new moduled, the ASIO 5, is designed for mobile phones but looks ideal for robotics use."
Read more…
I thought the DIY community here would find this pretty interesting:http://www.satnews.com/cgi-bin/story.cgi?number=1312146799Take some pretty low-tech French helicopter designs, add some microUAV command/control, sprinkle some magic video transmission fairy dust, and...This is "allegedly" unmanned, but I'm sure it's "man-assisted"...Now, this brings up a question -- in you folks' opinion, how much experimentation in the amateur community has been done with video-linked RF remote control (digital or analog)?
Read more…
I have just recently gotten one of these from http://thesiliconhorizon.com/

And I was basically planning on using it as the hardware platform for my own integrated UAV controller.The specs TechFX Motion OSD IMU:* small 2"x2.5" size* fast dsPIC 40 MIPS 80 Mhz MCU* 3 axis accelerometer MMA7260Q with G selectable* 3 axis Gyroscope of IDG300's* MAX 7456 On screen display video overlay NTSC and PAL formats which overlays the data sent to it from the dsPIC over the Video input* (2) RCA jacks for Video in and Video out supporting NTSC and PAL formats* GPS port for 32 channel Sannav FV-M8 (Etek EB-85A) GPS module MAX 2 HZ update rate* DGPS port for optional RTCM DGPS updates* Xbee connectors (XSC gives maximum range of 15 miles!)* 256K I2C serial eeprom for storing settings, waypoints and GPS logger data* USB fullspeed 2.0 communications via FTDI chip* SPI, I2C and UART ports for using optional modules* (8) 3.3 volt IO configurable* (8) 5 volt Output configurable as PWM (servo) or TTL* 10 bit a2d* ICSP port for ICD2 or Pickit2 programmers* 5 volt 800 mA LDO voltage regulator* 3.3 volt 800 mA LDO voltage regulator* Full power and ground planes with quality 6 layer board design minimizes noise* Power ports including 3.3, 5 volt, and ground connections* Optional 0.100 “ headers* Voltage input of 6-9 volts DCI have been thinking of a setup like this:TechFX OSD/IMU with custom programming for Kalman, as well as waypoint and return home navigation, using an XBee 868 modem for control and telemetry plus a video TX for live feed with the OSD overlay.The TechFX has 8 PWM out, and I2C, and I have a I2C 8 servo controller board so there should be enough channels for flight, camera pan tilt and zoom, plus a few other tricks.On the ground I was planning on using a laptop with a custom app in C# to communicate with the UAV, and to be able to also control it manually when needed using normal USB flight sim controllers. The laptop would be showing the video stream, or moving map, or attitude/flight data or a mix of them all.I would use software to select autonomous, manual or a mixed mode on the TechFX but would most likely include a RC rx with a hardware mux as a backup in case of software failure.The airframe will be my ~40" trainer (see my bad pic) with a hefty noname brushless motor, 70amp ESC, and 22.2V Li-Po batteries (big) plus a 7A BEC for 5V and a 3A 9V DC-DC.Will have at least one belly mounted camera with pan and tilt to begin with and then add zoom and another down facing camera later probably.This will take quite some time as it is being built on a very small budget and will move slowly, plus there is a ton of programming to do which may also move slowly since I already do it for 8 hours a day at work.Any comments welcome :-)Ps in case anyone wonders, No I am not affiliated in any way to the silicon horizon.
Read more…
3D Robotics
Some people have had questions about ArduPilot's FTDI port. Basically, it's a standard FTDI port but we don't use the power pin. That means that you can't power the board from the FTDI cable, and every time you're using the FTDI cable it must be powered by another source, such as your ESC, battery or whatever else you'd normally use. The reason we don't use the FTDI's power is to avoid power conflict with the board when you're using the FTDI cable as a serial monitor during regular ArduPilot operations. [FTDI is 3.3v and the board is 5v] The pinouts on the Sparkfun FTDI board are as follows: GND CTS 3.3v TXO RXI DTR ArduPilot's FTDI pins are: GND [not used] [not used] RXI [matches FTDI's TXO] TXO [matches FTDI RXI] DTR
Read more…

My UAV

Hey all I finally took some pictures, nothing really different about my UAV. It will have a police scanner in it though....here is whats in it.Video Tx (25 miles)....slight overkill for the momentO.S LA 40 Engine12v Battery Pack4.8v Battery PackArduPilot (on the way first board went toast)XBee (On the way)Ground SideEndurance RC Tx (Computer joystick to Radio TX)Video ReceiverGE Telemetry (On the way)Internet Video Stream (On the way)Still Image Geo-Referencer (Home grown and proud of it :-D )

Read more…
Hello everyone, I've been visiting the website for a while and have enjoyed reading the discussions here, but this is my first official post. I am working on hovering my co-axial helicopter and decided to do this using the Propeller chip, and specifically using the Sparkfun 5 DOF IMU and Jason Wood's code which we all appreciate. To make a long story short, I downloaded the code successfully to the development board with the IMU and ADC soldered according to the circuit in the code, but I am having trouble checking whether the IMU gives me correct angle, rate, and q bias. I am using the modified FullDuplexSerial object to display the readings from the KF on the screen using the serial terminal, but I am getting various different errors. Is this the correct way to do this? I was wondering if someone who has done this before could offer any advice or procedure to check whether the IMU and Kalman Filter work. Any help will be greatly appreciated! I look forward to advancing my knowledge to keep up with you guys! -Victor
Read more…
3D Robotics

Arduino v13 is out!

The new version of Arduino is now out. Improvements included fixing PulseIn() to wait for a transition to start timing (i.e. ignoring any pulse that had already started when the function was called) and, importantly, supporting the ATMega328 natively! That last one is a biggie, since the 328 has twice as much memory as the 168 we're currently using (32KB of flash, 2KB of RAM, and 1KB of EEPROM). Eventually, we'll migrate ArduPilot to that, which will allow us to load waypoints more gracefully (and a lot more of them) and other cool stuff that may include datalogging.
Read more…
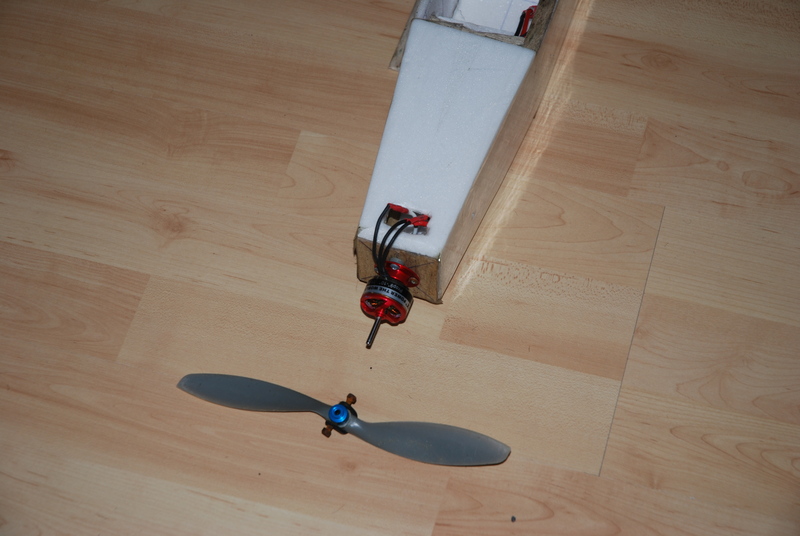
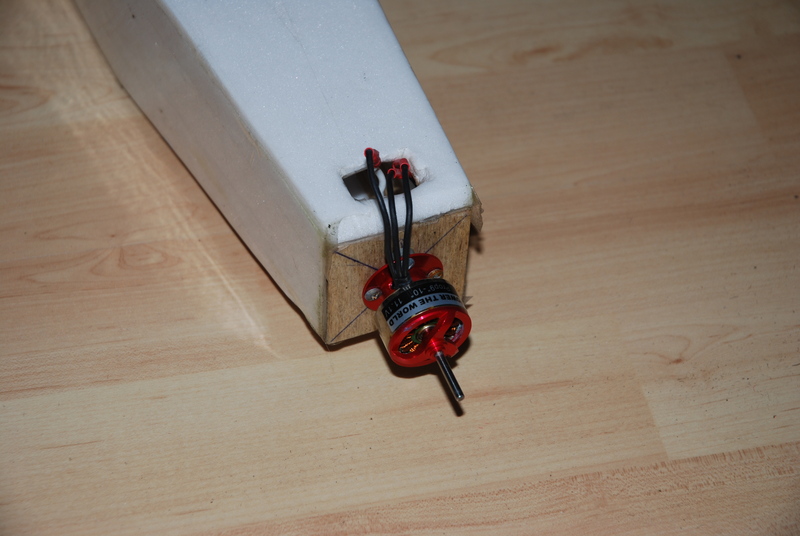
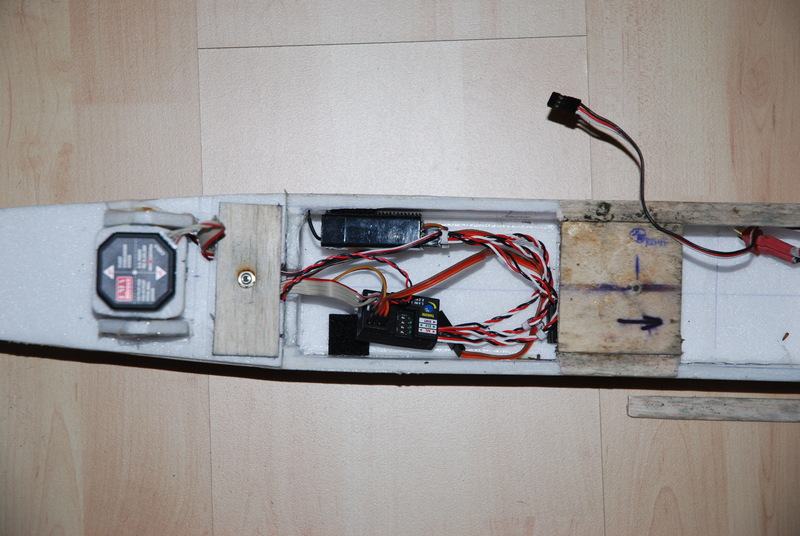
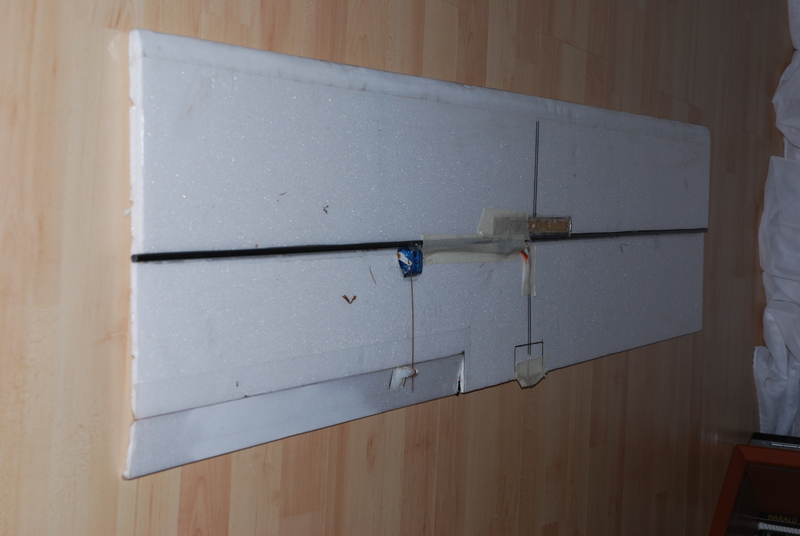
As i postet here, i lost my UAV_Eins (one) due to "environmental effects".As i christmas wonder, i got a message that it has be spotet in a bush a couple of kilometers away from the airfield it was lost...Today (about 5months later!) i got it back!!The fuselage and wing is in 99% perfekt condition!!! No structural damage... :)Only the balsa wood is gone, due to the rain and weather. (its pretty wet in norther germany at the end of the year)Here are some pictures of this long-time-traveller...

3264604174_dfbd6155f5_o.jpg

3264599462_869689447b_o.jpg

3264249692_032b25abb2_o.jpg

3264239466_a554b20b95_o.jpg

Edit: Seems that 2 servos are scrap, the rest works just fine.....receiver, esc, motor, fma baord and sensor, the other two servos....everything is working... :)i think it will fly this week
Read more…