All Posts (11086)

Sort by

Awash in GPS autopilots

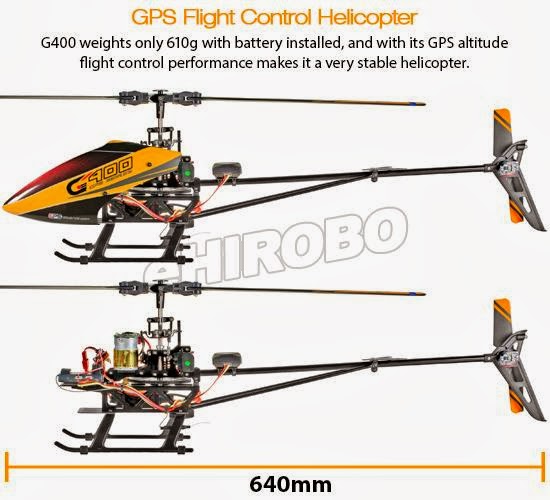
WALKERA-G400-ARTF_02.jpg
Clicking through some ads reveals there's now a flood of banging good GPS autopilots out there, being marketed towards RC pilots.  They're a lot more stable than anything I could afford, owing to the latest GPS module, barometers, & the arducopter source code, which they all undoubtedly copy.


http://www.banggood.com/Walkera-G400-GPS-Serles-6CH-RC-Helicopter-With-DEVO-7-p-89151.html


Gone are the days when someone would tear them open & study the part numbers.  The new customers are RC pilots with no idea what's inside. It wouldn't be surprising to find uBlox-7 & MS5611 in all of them.


BLH7880_b0.jpg

http://helipartsdirect.com/blade-350-qx-bnf-quadcopter-with-safe-technology-model-blh7880.html


Even the mighty Horizon Hobby finally caved in & started selling a GPS autopilot, though marketing it exclusively as a return to home feature.


The trick with autopilots is once you have one, now what?  They're good at making timelapse movies.  They can fly to places that were impossible for a human to reach manually, but the newest FPV systems make those places accessible for a human.

They're supposed to be good at returning to home when contact is lost, but there's very little evidence of that being used.  It's still a lot of trouble to wait for GPS to lock on, make sure everything is calibrated correctly, just for that 1 feature. 

There was some energy behind the following camera concept, but they probably weren't accurate enough to do a good job.  Now there's hope for massive agricultural demand. 

Autopilot for an RC pilot can get pretty boring, once the novelty of seeing it hover wears off.  Hobbyists who design robot algorithms still seem to be the mane customers.
It was suprising that the mane media avenues: tested, flite test, rcmodelreviews were completely devoid of the GPS autopilot boom, emphasizing indoor quads instead.  Even the mighty black sheep became famous not because of an autopilot but manual control.


Read more…

DIY FPGA Reflow Oven

fpgareflow.jpg?w=568&h=426

Cool Xmas Day project uses Papilio FPGA control

From HackADay:

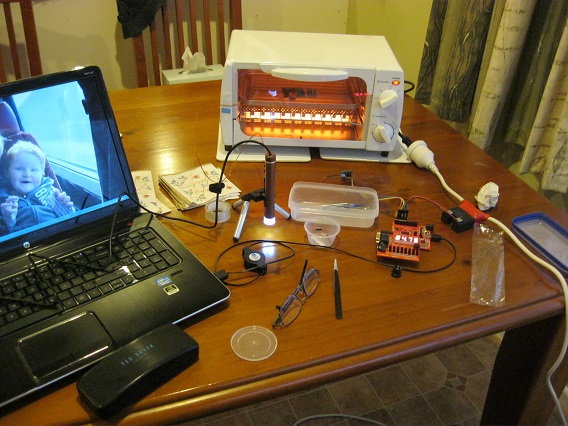
"For Christmas, [Hamster]‘s wife gave him a mini-oven. Later that day, he tore it apart and built this FPGA controlled reflow oven.

We’ve seen plenty of reflow oven builds in the past. Most of those projects use a microcontroller to do closed loop control, sensing the temperature and toggling the heating element to hit a set point. This build uses the Papilio One FPGA development board as a controller. It implements a state machine that meets the reflow profile of the solder paste, ensuring SMD components are soldered properly.

The oven uses a MAX31855 to read temperature from a thermocouple. This device provides amplification, cold junction compensation, and analog to digital conversion which spits out the temperature over SPI. To control the heater, a 40A solid state relay is used.

The VHDL code that drives this oven is linked in the writeup, and has some interesting bits for those looking to experiment with FPGAs. It includes an SPI interface, display driver, and the temperature state machine logic."

Read more…
Developer

3689564749?profile=original

I would like to announce the first RC1 release of APM Planner 2.0. This is a cross platform Ground Control Station to accompany the consumer release of Pixhawk and Iris for APM:Plane, APM:Copter & APM:Rover. More information can be found here on the APM Forums

Please post support requests to http://ardupilot.com/forum/viewforum.php?f=82

Happy Holidays, hope everybody is enjoying some flying :)

APM Planner 2.0 Team


Read more…

Parachute dropping!

Earlier this year I was testing some parachute designs to drop payloads.

VIDEO

Feel free to ask any questions!


As always, happy Droning!

Aaron


The building Log (sorry for the bad photos)


First I chopped off a little from my servo horn (be careful, to much gone won't hold the rubber band and to much wont relese it!) then glue your servo some where on you flying thing so that the horn is pointing away from where you will attach the rubber band. (I mounted mine where my finger is in the pic below)


Then I made a Weird knot with a rubber band onto my batter strap close to the frame.


I got a Garbage bag and cut it about 2/3 from the bottom (if you have a real, small parachute go ahead and use it) then tape 4ft of thread in all 4 corners of the bag


Then tigh all the 4 corvers and make sure they are all the same length and then tigh them to a paper clip (two knots)


Then I got something that would carry my payload and took the top off and glued a bent paper clip onto it with some hot glue

Now that your finished you have a parachute and a payload that can clip onto each other.

Thanks for reading my How-To Article!

- See more at: http://www.flitetest.com/articles/flightreel-multirotor-parachute-drop#sthash.JTvu8Ggi.dpuf

Read more…

Click Here to sign up for the Beta or go to CADDrones.com!

Hello my Fellow Diy Drones Members.  I am currently opening up CADDrones.com to anyone who wants to join in on the Beta Testing and eventfual full release of CADDrones.com!! The Ning Basic Plan caps me at 1,000 members so the beta limit is going to be set at 1k.

What are We looking for?!:

1-2 Admins, 10-20 Moderators, CAD Beginners, CAD Experts, HTML Geniuses, Website Techies, phpBB Experts, etc.  Basically anyone who feels that this is website will serve an amazing purpose for the Drone Community and wants to help assist or be a part of it.

What are we trying to do with CADDrones.com?!:

We are trying to build the worlds largest open source CAD Community that is 100% Focused on open source Hobby and commercial CAD Drones collaboration between experts around the world.  If the beta goes good then we are going to get on a specialized Ning plan that will allow us to turn this into the worlds largest CAD Database for Drone Part Printing, Designing, and the sharing of files amongst community members.

Who is in Charge of CADDrones.com?! Who makes the decisions?!:

The community of course!  During the Beta Process and beyond the full release of the website the members of CAD Drones will be able to vote in polls and voice their opinions on which way the website goes on this great journey.  The polls will be the deciding factor on major decisions like whether to go with the Ning Forum Platform or use an embedded 3rd Party forum system and also the beta members will ultimately decide the Website rules and such.

Come check out CADDrones.com and be a part of the beginnging of something amazing!


All the advice I can get right now would be great!!

Joshua Johnson

Read more…

Bluetooth Telemetry Bridge - Last Chance

3689561495?profile=original

Just a friendly reminder, now is the last chance to grab a Bluetooth Telemetry Bridge before the Kickstarter ends tonight at 10:30PM EST. We've already had an overwhelming response and reached our goal in less than 24 hours! After tonight, there will be a bit of delay before we can take any more orders because we'll prioritize Kickstarter pre-orders.

Here is a link to the Kickstarter Page and some more information from my original post here on DIY Drones.

If you're not familiar with the Bluetooth Bridge, it's a simple device that allows you to connect to your 3DR Radio or RFD900 telemetry stream to any Android phone or tablet supporting a ground station. The most popular ground station for Android is the DroidPlanner. The device is very easy to use, just power it on using the internal rechargeable battery (recharge with a USB cable). The battery lasts for over 5 hours of continuous operation. Right now, the Bluetooth Bridge does not support iOS devices because Apple requires a special type of Bluetooth hardware to integrate properly.

The Bluetooth Bridge can also help for normal laptop groundstation work since it allows you to place the telemetry antenna in any location where it might have better reception.

Let me know if you have any questions or suggestions about the project in the comments below. Thanks again for your support!

Read more…

Let me just state that  I respect Daren his work and contribution to hack and IT community and that this comment isn't directed in any way against him or his work.

Just a month ago while watching one of the Daren's videos I noticed DJI Phantom sitting on his desk and I couldn't wait to see how its going to be used. Than last week I got a chance to see what was cooking in his kitchen.

While drone hacking was mentioned few times here I founded Daren's approach very simplistic and easy to understand. Like always his lingo is easy to follow and his proof of concepts are easy to replicate. He is using WiFi device from his own sore but it can be achieved with almost any  WiFi enabled smart phone and telnet app. People at Parrot didn't bother protecting WiFi link and they made it easy to access flight computer on board their parrot drone. As this can inspire some comments and ideas about security I would like to point out to two moments on his videos, first at 07:25 on his first video and second one at 15:17 on second video. While WiFi hijacking and hacking on board computer is quite interesting I founded amazing that nobody didn't get hurt during filming this episode. They could just simply cut "embarrassing" parts in post production but they decided to keep it and in video comments Daren stated "I was flying irresponsibly for fun and hit a wall. No damage. Not recommended." It seems that we are learning from our mistakes but unfortunately this is after the fact that we damage something or hurt someone.

I think that we as community, and as responsible drone operators have obligation to point out to all potential hazards that can arise from operating such remote controlled vehicles. I strongly believe that showing graphic images in warning section is the way to go. As we have more and more ready to fly drones available we will have more and more people using them and we will most likely have more and more accidents. Usually people see nice online videos made by seasoned pro's and think I'll get one and do the same thing. Little they know that its not that easy and most important that isn't that safe. Best case scenario they crash in to the wall or drop from 12 stories high on to the pavement brake their new toy and loose interest.

But if they have to see pictures of potential danger and injuries before they can make a purchase instead of just reading (flying thru) safety warnings they would take it more seriously?

      Some of the pictures that by my opinion should be included in every safety warning, printed or online. Look at it as warning on pack of cigarettes just more graphic. Would that cut into sales? probably, would that help us as community in long run? most definitely yes. It all comes to personal perception of safety and responsibility but we are just making a little extra effort to explain to the future users to take safety more serious.

Read more…


Here is footage from software showing our software capability to simultaneously plan and execute mission with 3 different drones. Arducopter, Microdrone MD4-200 and Mikrokopter were used.

As we support at this moment Arducopter, Mikrocopter, ArDrone, Microdrone this demo can be interesting at least for professional users of Arducopters.

Software specs are here - http://www.ugcs.com/index.php/products

We have only private beta today, but if you want to be a beta-tester, you can write request to ugcs@ugcs.com and we will provide a path to obtain preview copy of our software.


Read more…

Arduino based virtual horizon

https://www.youtube.com/watch?v=1JbAVCclQcY&feature=youtu.be

Merry Christmas and happy new year DIYdrones! It is been long since my first blog post about my time in jDrones. Sorry guys I haven’t posted since then, even I said I would. Been busy finishing my degree and with my projects.


I recently recorded a video of one of our projects here. We’re doing some research on how we could build stand alone virtual horizon/attitude detector to use in gliders and other flying vehicles. This very early version is running on Ardustation Mega. This screen is way too rough to draw nice graphics, but good enough to determine algorithms to draw the horizon lines, speedmeter and variometer of the aircraft.


Final version will have built in GPS, gyro/accelerometer, barometer and other necessary stuff for fully stand alone operation to support flying.

What kind of a information do you think this kind of a display should provide?


Have a peaceful holidays DIYdrones.


Marko

Read more…

Merry Christmas and a Happy New ACRO!

3.1 was released just in time for the holidays, but I felt the new Acro Mode we have developed has not been adequately demonstrated.  So I shot this video to show that Arducopter now has a competent Acro mode to go along with all the other functions.  This is kind of a big deal to me, as I am interested in learning acrobatic flying, but I really appreciate having a system which can "bail out" if I lose control.  Throughout this video I was flipping between Acro and Stabilize, with Arducopter generally doing a good job of saving the copter after I lost orientation.

This is also one of the few demonstrations of a new Pixhawk controller on something other than an Iris.  But don't be fooled, Acro works just as well on an APM2.5.  :)

While developing and testing this code, I have also done quite a bit of high speed acro flying, on both the quad and my helicopters, but it was simply too cold to bother hearing out to the flying field.  So this video is just some basic flips in one place.  I will try to get out for some better video in a few days.  If it warms up. :)

Read more…

Happy Holidays DiyDrones.com!!  This is Joshua Johnson with what's going to be new in 2014 with my Drone Internet Show. Below is a picture of how my show will be structured in 2014.  The websites inside the pyramid represent the various sources I'm going to use to gather information on Drones, Model Vehicles,autopilots, etc.  This information will be used to create engaging Blog's for DiyDrones+RCGroups, and Live Youtube Broadcasts on the 3 Websites that I own on the outside of the pyramid.

3689564806?profile=original

HobbyKingNews.com (Should being finished being built by the end of JAN):

Im working closely with Hobby King employees to bring the DiyDrones Community R/C & Model Aviation News coming out of Hobby King.  My website and Hobby King News segment of my show is a 3rd Party website that has no official ties with Hobby King and my views and opinions are not associated with Hobby Kings. They have given me exclusive access to early release of all News coming out of HobbyKing.com related to various things such as new products before the public gets this information.  Also I was told if the interest in "Hobby King News" is large enough they will allow me to interview key staff members involved in the operation of Hobby Kings.  I'm trying to work out a deal in which Hobby Kings supports my show by providing me with the Models/Vehicles/and Electronics to use for various Episode Series. 

sUAS News:

In the year 2014 I'm going to try my very hardest to strengthen my ties and bond with sUAS News and the folks affiliated with it.  In the past I have found myself neglecting sUAS News because I felt as if it was a News source I had to compete with.  With the new year coming along I am leaving that mentality behind and hoping that I can help create a mutually beneficial bond between my News Show/Websites and sUASNews.com!  They share various stories that I can't find anywhere else but sUAS News which shows me they are leading the way in Drone Based News Media. 

Contest Giveaways!:

If I get to the point where I ever get an over abundance of products and the supporting companies allow me to.  I will run various contests in which I'll give away excess products I receive from companies that were used on the show as prizes.  The prize packs for these contests will include anything from autopilots, R/C Planes, R/C Boats, Quad Frames, Motors, and much more.

Take it Easy Diy Drones and enjoy the holidays, 

Joshua Johnson

Read more…
3D Robotics

LIDAR for your smartphone

3689564864?profile=original

Not sure how I missed this successful Kickstarter campaign from October, but here's more from Gizmag: 

Virginia-based IkeGPS wants to bring this functionality to the mainstream. And what better way to do it than sticking it on the back of a smartphone?

Spike builds on the company's established GIS (geographic information systems) tools, which were used by the UN in the wake of natural disasters such as Hurricane Katrina and the 2010 earthquake in Haiti. The device attaches to the back of a smartphone and combines a built-in laser range finder, 3D compass and Bluetooth chip with the phone's camera and GPS.

Users take a photo of the object they wish to measure through the Spike companion app on their smartphone (the team has nearly completed an Android app and has an iOS app in development). The hardware then measures key metrics, such as distance, direction and volume and communicates this data to the smartphone via Bluetooth, displaying the augmented results on the screen. Users can then share this data, or use it to produce 3D models with what the company says is laser accuracy.

According to it's successful Kickstarter campaign page, the company will allow third party app developers access to an API (application programming interface), enabling the embedding of specialist ikeTools into applications in anticipation of augmented reality and location based services apps.

Spike is also compatible with 3D modeling software SketchUp meaning that users can take an...

Spike is also compatible with 3D modeling software SketchUp. This means that rather than importing measurements manually, users can take an image with Spike to reproduce a scalable model of the object or building and 3D-print it as required.

The entire device weighs approximately 100 g (3.5 oz) and measures 90 x 50 x 20 mm (3.5 x 2 x .8 in). The 905 nm, Class 1 Eyesafe laser has a range of 2 to 200 m (6 to 600 ft) with a resolution of ±0.2 m (8 in). Spike is powered by an internal Li-ion cell battery recharged via a Micro USB connector, with each charge lasting two days of typical use, according to the company.

Spike can be pre-ordered via IkeGPS's website for US$559 with shipping (included) estimated for May 2014.

Read more…

Bay area drone startup #3

air.jpg

In the beginning, there was spyplanes.com.  Then there was 3drobotics.com.  What a surprise when my recuiter spam feed came up with another one in San Francisco called Airware.  They showed a location in Newport Beach, but like so many others, probably had to expand North to save on real estate costs & be closer to the cloud/dot com boom.


It's yet another agriculture quad copter play.  Besides tacitly luring photography hobbyists by branding the quad copter as a professional product for agriculture, there's no logic behind all these startups pitching quad copters for agriculture.  They can't efficiently image thousands of acres.  Sensefly probably had the best model with flying wings, but not the money or the resources to build up a community movement.

Despite not getting any interest, I did manage to get the recruiter to return a phone call, a huge breakthrough.  The UAV business has just exploded to the point of not being the domain of makers & self starters anymore.  They just want formal masters degrees.
Did the maker movement make the engineering degree mandatory?

In the old days, there was a novelty to someone picking up electronics on his own. It showed the ability to learn without being told what to do & the ability to be motivated without the threat of failing a class. While there were always places like Lockheed which would never touch someone without a formal engineering degree, it was not uncommon to get in elsewhere with a biology degree & a lot of design experience.

Nowadays, with the maker movement & the rise of the goo tube hacker, that doesn't work anymore.  Everybody knows how to design a robot.  It may be that they're now getting inundated with self taught engineers to the point that the degree is now the rarity.
Read more…
Developer
3689564588?profile=original
One of the widely ignored (in open source projects, not in industry) sources of error in attitude and inertial estimation are temperature dependent offsets and scaling changes (some open source systems do, and we would love to hear about how you are doing it - the purpose of this post is to gather the community knowledge). Some systems estimate them online with a bias state. However, not all of them can be easily and reliably estimated online, and bias estimation always poses the risk that the designer makes too strong assumptions about observability. Consequently the quality of the estimate then depends on the flight pattern (straight line vs. circling) and GPS accuracy.
It is therefore always a good idea to estimate temperature effects upfront (if we reliably can) and remove all known effects from the measurement before estimating the remaining offsets online.
Please find below the link to a 1500 seconds (25 minutes) dataset showing the MPU6K warming from 5 deg to 40 deg Celsius.
3689564768?profile=original
The temperature drift is obvious. The link contains a ZIP file with a complete Matlab dataset and scripts to plot the data. You will find that tempdrift.m does all the plotting and is already set up with all convenience logic - you just need to insert your compensation function.
The dataset is however not perfect: It might very well turn out that we need multiple (e.g. six) orientations to differentiate between accel offsets and accel scaling changes, and we might need constant rates (e.g. from a record player) for the same differentiation between offset and scaling for the gyroscopes. Please get in touch via the mailing list to request additional data and describe what you want to have.
Note that we already know that there are two different offsets / scalings: The per-boot offset of the sensor, which only varies mildly. That’s why 10 reference boots at different temperatures are attached for validation. And the temperature-induced general offset (this might be per-device or per instance, we’ll see).
Please get in touch if you have questions. To make this more fun and give it a personal touch: I’m offering a three-course dinner at a local restaurant if we ever manage to meet (I’m traveling a lot). I will offer this to the best solution once I end the competition :).
The benchmark is clear: Show that you can measure the Earths rotation rate of 15 deg/hour. I know its not impossible with today’s MEMS sensors - I have no baseline on the MPU6K though, from which this dataset originates (the MAG is the LSM303D's internal mag).
(photograph CC-by-SA Wikipedia)
Read more…

Landing a Quad on a moving car via FPV

I tried to do something different this time: land a quad on a moving car.

After 2 unsuccessful attempts (crashes), the quadcopter finally did a smooth landing on the roof of the moving car.


The RC quad was controlled from the inside of the car using a 7" monitor (480x234 pixels) for FPV. Video was transmitted directly from the onboard GoPro2. A GoPro3 was mounted on the top of the car.


The quadcopter used a simple Multiwii controller board with acc + gyro. The PIDs weren´t tuned so the flight wasn´t very stable.


WARNING: this was recorded on a closed course without other vehicles or pedestrians.

Read more…