All Posts (11086)

Sort by
3D Robotics

New drone model at HobbyKing

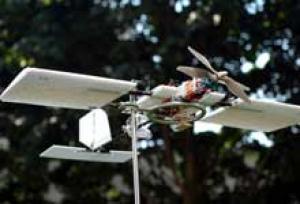
3689470622?profile=originalLooks cool and costs just $72. From the Hobby King product listing:

The Target Drone is a great little FPV platform that has been specifically designed for the job and not only is the kit cheap to buy, this great little model is also cheap to get in the air.

The Target Drone features an FG fuselage that is open at the front for camera mounting, there is also a built in anti-glare cover. The model is designed for a pusher motor as you would expect and it also features a mid mounted, large hatch for battery and equipment access, the large and open fuselage area not only has plenty of room for your FPV equipment and lipoly, it also provides plenty of battery and ESC cooling from the open front fuselage. The under carriage is robust, featuring screw in alloy leg's at the rear and a steerable nose wheel up front.

The Target Drone is a pretty quick build, servo extension leads are pre-installed into the balsa wing, which is mounted on a CF rod and epoxied into place. The supplied hardware is comprensive and the overall parts count low, meaning you will be experiencing FPV in double quick time. The Target Drone, with it's tailess, swept wing is one of the most unusual and interesting EP FPV models in it's class yet and is sure to get people's attention wherever it flies!

Features:
Robust FG Fuselage
Open Front Camera Mount with Anti-Glare Cover
Large Mid-Mounted Access Hatch
Balsa Constructed Wing & Winglets
Sturdy Under Carriage
Steerable Nose-Wheel
Low Parts Count
All Hardware Included
Pusher Configuration

Read more…
Moderator

Chris Anderson, Commercial Drone Disruptor!

chris-anderson.jpg?width=400

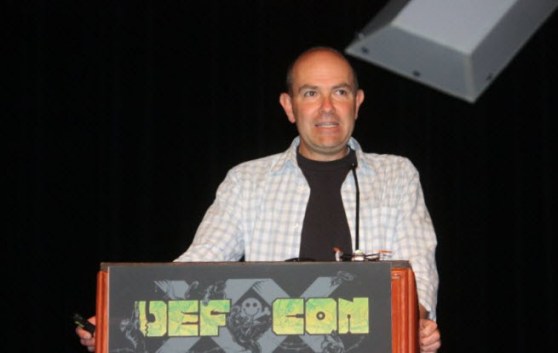
Chris speaks DEFCON...

"The do-it-yourself (DIY), open-source drone movement is turning into a real business that could disrupt the commercial and military drone industry. It’s another case of how exploiting the curiosity of hackers can turn into a commercial opportunity.

"That’s the view of Chris Anderson (pictured), editor of Wired magazine and a drone hobbyist and businessman on the side. He spoke about this DIY trend and his own efforts to lead it in a talk at the Defcon hacker conference in Las Vegas today."

[...]

Venture Beat

via sUAS News

Read more…
Developer

Last week we implemented a fancy ticketing system that will enable us to properly track issues among customers and be able to supervise the time response of our representatives but at the same time give them access to a set of tools that will help them be a lot more efficient.

Unfortunately the systems blow up last Friday (the 20th) so we were receiving emails from customers but any of our responses made it out, they were probably sent to the limbo.net.

The system has been shut down today, so we can catch up as quickly as possible. We are deeply sorry about this incident.

We are aiming to answer everybody between today and tomorrow (Yes Saturday).

Read more…

Bixler. The sad story of my maiden RC flight.

I've spent last couple of days preparing my Bixler. I did some mods listed here like reinforcing wing spar and fuselage with additional carbon fiber rods and changing prop to 6x4. Even my tail was detachable using similar trick.

Today was a nice weather to go and check what have I've learned in the simulator...It didn't go well (see video).

Stock servos were cheapo. One of them were buzzing from start with no stick movement. After first crash one of them worked only in one direction. Probably one tooth of the gear broke.

Servo rod's endings that hold horns were one-time. After opening (for changing the rods for better) both broke a bit leaving horizontal bolt going through the horn too short.

I'll have to find a way to fix that wing. Maybe a few small carbon fiber rods going through the wing? Also, polymer glue that was suggested on many Polish forums doesn't look for me good - it's very flexible and does not create a strong bond.

If you have any suggestion on how to fix that wing (and fuselage) to be strong and survive my future landing let me know.

Read more…
3D Robotics

3689470548?profile=originalGood news: Invensense has finally released a licence that allows open source projects such as ArduCopter/Plane to use the built-in sensor fusion processor in the MPU-6000 gyro/accel chip used in APM 2.x!

This processor, called the Digital Motion Processor (DMP), has been in the APM 2.x sensors from the beginning, but we weren't using it because Invensense had not specifically allowed their driver to be distributed with open source software. However, after much discussion, they have now written a licence that allows this. 

You can get it on the Invensense Developers Corner here. (You'll have to register first). I'm not a lawyer, so I won't attempt to analyze the language to see if there are any holes in it, but the Invensense developer relations managers and their legal team wrote it with projects like ArduPlane/Copter in mind, and they've assured me that we now have the green light to use the DMP code. (The agreement specifies the MPU-6050, which is the I2C version of the chip, but that includes the MPU-6000, which is the SPI version that we use). 

The Ardu* dev team is hard at work at implementing the DMP code in the ArduCopter/Plane code and we hope to have that ready for the next release. It will probably give you a choice of using the current DCM, running on the main processor, or the DMP running on the MPU-6000, freeing up a good bit of processing power for other functions. 

We have not done a rigorous test of the DMP vs the DCM, so we can't yet say that one is better than the other. But this licence now allows us give people the option of trying it, and if it perorms better than the DCM, or just as well but freeing up computational power, we can switch to it going forward. 

Read more…
Developer

Announcing APM 2.5!

3689470507?profile=original

I’m pleased to announce the new APM 2.0 revision, better known as APM2.5!

But before you start screaming that you just got an APM 2.0, let me explain that there’s NO difference in performance at all between the two, the board is still the same in terms of functionally and it runs exactly the same code as APM 2.0. We just took the liberty of throwing in a few new universal connectors in there (so accessories can be cross compatible with the new PX4 and protect the user from connecting the cable in the wrong direction), some production improvements that will allows to manufacture it faster and finally we added some protection features to protect it from those reverse polarity/short circuit lovers.

Here goes the full list of changes (you already know all its features):

  • No more shield/daughterboard: magnetometer and dataflash were moved to the main board, making it easier to assemble, repair and hack. 
  • No more on-board GPS, but we added a new 6-pins DF13 connector for our new GPS cable standard (PX4) and kept the old but reliable Molex (EM-406) connector for old GPS compatibility. 
  • The old radio-modem connector is gone and now is being replaced by our new 6-pins DF13 connector (like the GPS, because both are UART’s. Got it?), this will make it compatible with PX4 and prevents users from blowing up the UART mux. 
  • We added a second protection fuse and diode (you are no longer required to solder it yourself) for extra reverse polarity and short circuit protection. 
  • The old I2C connector is gone and has been replaced by our new 4-pins DF13 connector (yeah PX4 compatible. Oh wait correction… None of both (PX4 & APM2.5) are compatible with each other, we created this standard together as a team, but I have to give the average of the credits to PX4). 
  • Added a “mystery” 6-pin DF13 Connector that will be used later. I know you like surprises so please stay tuned. No big deal but is really cool and will save you some soldering here and there. 
  • Added “Magnetometer Jumper” that allows you to disable the on-board magnetometer, so you can attach an external one. 
  • Added extra LED attached to the PPM encoder (Atmega32-U2) on pin PC7. This will allows us later to use it as PPM status indication and leave those poor TX/RX LED’s do their intended job.

3689470433?profile=original

Those who ordered the APM2.0 and are still waiting for it (only if is not shipped yet) will have the option to upgrade to the new APM2.5, but you will be required to wait an extra couple of weeks for production to begin. For upgrades please send us an email to sales@3drobotics.com. 

If you want to order one now you can get the assembled version here and the unassembled version here (for those who want their choice of RC connector: straight or right-angled). They will begin shipping in a week or so, but if there is a huge flood of orders, the backlog for any individual order may grow to 2-4 weeks. We're making them at the new Tijuana facility, so we hope that we'll be able to keep up with demand much better than we have in the past. We're committed to shrinking all delays, and our investment in the Tijuana facility is just one sign of this.

The APM 2.0 enclosures will not fit this new board, so new enclosures are on their way. If you buy an APM 2.5 now, you will get a $4.99 credit for a free enclosure with your next order (the enclosures should be in in about a month).  Also, APM 2.5 will ship with an adapter cable for the 3DR/Xbee radios, converting from the APM 2.5 DF13 connector to the radios' conventional 6-pin connectors.  Eagle files for the boards will be posted in the next few days.

Read more…
3D Robotics

Visit to new 3D Robotics Tijuana plant

3689470468?profile=originalI've given a quick tour of the big 3D Robotics factory and R&D center in San Diego before (here), but as some of you may know, we've recently opened a second manufacturing facility 30 minutes across the border, in Tijuana, Mexico. The management team and I were down there this week reviewing operations, so here are some quickie photos so you can see what it looks like.

uDrones is now a subsidiary of 3D Robotics, so one thing the new facility does is the original uDrones function: assemble, test and ship complete UAVs (quads, hexas and planes). Above is the copter assembly line. At left is Lorenzo Lopez, Operations Manager of 3D Robotics, and Jordi Munoz, CEO.

3689470530?profile=originalAbove: The administration area. Behind it is the PCB assembly line, with the pick-and-place machine and reflow oven at left, and the QA and hand-finishing line at right. This is the new function of the factory, and most of the APM boards are now made there. I forgot to take a picture of it, but it's identical to the pick-and-place line in San Diego, which looks like this:

3689470493?profile=original 

 3689470569?profile=originalThe CNC room. This is where the 3DR ArduCopter frames are made. 

We'll probably keep the uDrones name, but the website is being revamped, as are all the products. All the pre-made drones will now come with APM 2.x, with the copters defaulting to the uBlox GPS and the planes having a choice between uBlox and MTK. We might have some cool exclusive color schemes, too. Better instructions and support is coming too, as part of the ramping up of the facility. 

The good news for everyone is that now that this facility is up and running, backlogs on boards should be much reduced if not eliminated. We have two full-time pick-and-place lines and we can add shifts in Tijuana as demand requires. 

Read more…
Moderator


3689470390?profile=original


3689470140?profile=original

3689470326?profile=original


Dear Friends,

after 2 month of test I'm happy to inform you that the VBrain is ready to fly.

The platform is a result of 4 years of work on ARM autopilot platform. It's last evolution of Multipilot32 platform. I'm very happy that this is the year of ARM and we are here to present our last creation : Simple , Smaller and Ready to Use.

VBrain is a good choose for OEM ready to use hardware platform.

The VBrainautopilot features include:

  • 168Mhz ARM CortexM4F microcontroller with DSP and floating-point hardware acceleration.
  • 1024KiB of flash memory, 192KiB of RAM.
  • MEMS accelerometer and gyro, magnetometer and barometric pressure sensor.
  • 8 RC Input standard PPM , PPMSUM , SBUS
  • 8 RC Output at 490 hz
  • 1 integrated high speed data flash for logging data
  • 1 Can bus 2 i2c Bus
  • 3 Serial port available one for GPS 1 for serial option 1 for serial telemetry.
  • 3 digital switch (ULN2003).
  • Jtag support for onboard realtime debugger.
  • 1 Buzzer output.
  • 1 Input for control lipo voltage
  • Include in the standard Vbrain Package there is VBrain GPS module , the module support MTEK 3329 gps , Ublox module , Fastrak IT600. On the module is available optional magnetometer. You can disconnect the board and put it far from brushless motoros to solve the problem of noise on mag signal.
  • Physical Dimension 6x4 cm
  • Will be available a case


It's first Universal Arm hardware platform . On it is available different kind of firmware : Open or Closed source . The main firmware available is Arducopter32 , last revision is 2.7 In the next day will be available a full fly test.
This platform is fully compatible with different kind of RTOS : FreeRtos , ChibiOS , Nuttx , CooxOS .

Our first target when start to develop our hardware platform 2 years ago was to develop a simple and powerfull ide.

We develop VRIDE PRO that is a special distribution customize by FoxTeam and LaserLab guys. The Ide use Eclipse as Editor, GCC as compiler , GDB and OpenOcd as Debugger.

This is the link of ready to use Ide:

http://code.google.com/p/multipilot32/downloads/detail?name=vrobotix-ide-pro-0.0.5.7.0-WIP-Angerl%20Loiter-F1-F4.part1.rar&can=2&q=#makechanges

The ide support different kind of workspace and library. Our first target was porting all arduino and APM api to ARM platform.


The supported firmware are Arducopter32the last revision available is 2.7 the status of firmware is ready to fly .

The Workspace with last revision of code is available here :

http://code.google.com/p/multipilot32/downloads/detail?name=ACopter32_2.7_Beta1_VRBRAIN.rar&can=2&q=#makechanges

Our Team are working also on PX4 enviroment , first target was to port Arducopter32 on PX4 and PX4 enviroment to Vbrain and MP32Fx platform.


The hardware is compatible also with other opensource firmware as AutoQuad AeroQuad and OpenPilot. A lot of work are doing on IDE and firmware to share it on our platform.
We try to work to a new Opensource Standard based on high performances STM32F4 micro controller.


The price for VBRAIN with GPS Board (MTEK 3329 rev) developer revision is 199 euro.

It's also available a ready to use board with 3 days of support by team viewer at 270 euro.

There is also available a oem version of product.

We are Ready for pre order the first batch of production will be available in 3 weeks some sample is yet available.

For more info about VBrain : http://www.virtualrobotix.com/profiles/blogs/vbrain-coming

or contact virtualrobotix@gmail.com

Best

Roberto

Read more…

PX4 Flight and Features Video (Introduction post #2)

This platform overview video shows quadrotors in flight, fixed wing hardware in the loop simulation and a novel experimental aircraft. It also introduces all PX4 hardware modules (available from 3D Robotics).

This is the second of a series of PX4 introduction posts. The first is here. We will continue our coverage in the next days with an introduction to first-time setup and calibration and installation of the programming environment (Eclipse or plain shell, arm compiler, USB flashing and/or JTAG debugging).

Read more…

pix4d-epfl.jpgInteresting development. The company behind the Parrot AR drone is investing in Sensefly and Pix4D. What can we expect? When will our kids be making ortho's with their smartphones?

From Engadget:

Switzerland's EPFL has managed to catch our attention with its various UAV-related activities, and it looks like it's also been the radar of Parrot, maker of the AR.Drones. EPFL announced today that the French company is investing 7.4 million Swiss Francs (or about $7.5 million) in two companies that have been spun out of the institution: senseFly and Pix4D. As you may recall, those two have collaborated in the past, with senseFly providing the camera-equipped UAVs necessary for Pix4D's 3D mapping software. Broken down, the investment works out to 2.4 million Francs put into Pix4D and five million invested in senseFly, the latter of which is enough for Parrot to claim a majority stake company. As for the future, senseFly's CEO says that the deal will give Parrot "access to the expertise and the technology for specialized drones," while Pix4D's CEO says that the investment "reinforces our position as a leader in software for professional drones" and opens up new business opportunities. It also makes it clear, if it wasn't already, that Parrot is getting pretty serious about drones. You can find the official announcement after the break, along with a video from EPFL explaining the deal.

Read more…

Introducing the USAV.

3689470086?profile=original

(Disclaimer - I'm not an english speaking person from birth, but thru endless re-runs of predator, Total Recall and Terminator - I have perfected my english skills.... not)

On the outer skin it's a standard 450 Quadcopter - but the brains is a new approach to the standard UAV.

Most amateur-UAV today either use a remote controlling system, an ardu-pilot or a combination of the two.

While the ardurino platform is very well made and has the most impressive features, I wanted to create a different approach. 

Being a software designer I decided to let the brains of my UAV to be based on the well known Android platform - in other words program a smartphone to fly the UAV and utilize all the nifty features and gadgetry these phones are born with (GPS, accelerometers, compass, camera, gprs radio etc..).

3689470122?profile=original

You may argue that it's an expensive solution, but obtaining an old Sony Ericsson X10 mini was easy and very affordable (around 25$).

So having turned my back to the wonderful world of Ardurino, I instead turned to Sparkfun's IOIO Board. 

3689470261?profile=original

The particular upsides of this board are amongst others;

* Works with android 1.5 and up

* Has adjustable charging for the phone

* Does not require any USB shield, can talk directly to a connected phone

* Phone connects through standard USB or bluetooth

* A very simple to use API makes it easy for a JAVA guy (like me) to talk to the IOIO board

The IOIO board can talk and recieve digital/analog/pwm etc., thus making it relatively easy to "fake" an RC receiver.

I've installed my homebrew app/autopilot on the android phone, just like a regular android app.

Granted - this is my very first QUAD, UAV and even hobby vehicle - although I make it sound easy, I actually had to go through all the tragedies, let downs and broken props as everyone else in here. Also, this particular craft is not built for beauty, and I've probably made a lot of rookie mistakes when using heavy plexi glass plates, 4 mm nuts etc..

So the navigation system of my UAV consists of an Android phone, the IOIO board and a KK controlboard.

3689470266?profile=original

As of now, the android utilizes the GPS for location, compass for heading and GPRS for communication and accelerometers for figuring out if a catastrophe is near (ie. if the phone is flipped, then we are likely to crash and the engines are cut off). All data is logged to the sdcard in the phone. The balancing of the quad is handled by the HK KK board.

SO! What makes the S of the USAV I hear you ask - well - my approach to flying might be somewhat different than other people flying UAV's - My vision goes toward the extreme of autonomous. I like systems that are able to make their own choises and who interact with the outside world through "normal" channels like everyone else. 

Enter the S for social - this quad can fly to various predefined waypoints just like the ardupilot, but it is also more autonomous in that you are able to give it a task, and the Quad will find a way to solve it by itself (do the dishes is NOT an option - I tried it and the wife haven't forgiven me for breaking the 14 century Ming Vases we dine and drink from). More on this subject will come....

Moreover - instead of fiddling with code and editors to tell the quad what you want - you simply use a chat client (GTalk) when you want something done or you need a status - in other words, the quad is my new best chat buddy! I will uncover more of this in an upcoming post.

The merits of the Quad is twitted by the Quad instantaneously during flight, so every masochist can follow the Quad's doings in realtime.

I believe this is the very first UAV with social skills!

So where are we currently at? (we being me and my new best flying friend). Well, we are still learning basic maneuvers - lift off, landing, turning etc.. Last flight really revealed that I have to look into adjusting the pots on the KK board to decrease a heavy oscillation that in the end rattled the KK board off it's platform resulting in a nasty crash and broken props - last chat message from the QUAD was a simple "ouch!" 

There's also problems with the compass being disturbed by the engines and finally a downward pointing sonar would be nice to make the landings more smooth.

Following the nature of blogs I will post updates and comments are very welcome :-)

Thank you for tuning in on this very first post, from a new user of this awsome site.

Fly with whatever force you believe in

-jesper

instantaneously
Read more…
T3

Hi,

I was able to obtain certain number of XBEE PRO modules at 50mW with wire antenna, no chance to get them with SMA antenna. However I would like to solder a specific connector. Unfortunately, the PCB layout is different:

Type A is for SMA, uFL and WIRE     3689470293?profile=original

Type B is for Small PCB patch antenna, uFL and WIRE

3689470356?profile=original

the second one is more popular. I was trying to figure out what is connected to what when trying to mount SMA connector, but given the fact that the SMA in xbee is sometimes mentioned to be 'Reverse Polarised SMA' I am lost about which part of the connector should be soldered to what. ohmmeter of course reveals nothing, all appears to be connected together on type B board. What the...?

Read more…

Introducing the PX4 autopilot system

The PX4 team is pleased to announce early availability of the PX4 autopilot platform, with hardware available immediately from 3D Robotics. 

px4fmuv1.6_top.png?width=400

The platform is a low cost, modular, open hardware and software design targeting high-end research, hobby and industrial autopilot applications.

PX4 is an expandable, modular system comprising the PX4FMU Flight Management Unit (autopilot) and a number of optional interface modules.

The PX4FMU autopilot features include:

  • 168Mhz ARM CortexM4F microcontroller with DSP and floating-point hardware acceleration.
  • 1024KiB of flash memory, 192KiB of RAM.
  • MEMS accelerometer and gyro, magnetometer and barometric pressure sensor.
  • Flexible expansion bus and onboard power options.

Expansion modules available at release include:

  • PX4IOAR This module interfaces PX4 to the AR.Drone motor controllers, allowing a complete quadrotor to be assembled using an AR.Drone frame and motors.
  • PX4IO A flexible interface module with support for eight PWM servo outputs, relays, switched power and more.

As an open hardware design, third-party and DIY expansion modules can be easily developed for specific applications, and more PX4 modules are in development.

In addition to the versatile hardware platform, PX4 introduces a sophisticated, modular software environment built on top of a POSIX-like realtime operating system. The modular architecture and operating system support greatly simplify the process of experimenting with specific components of the system, as well as reducing the barriers to entry for new developers.

Adding support for new sensors, peripherals and expansion modules is straightforward due to standardized interface protocols between software components. Onboard microSD storage permits high-rate logging and data storage for custom applications. MAVLink protocol support provides direct integration with existing ground control systems including QGroundControl and the APM Mission Planner.

Pricing of the PX4 components reflects more than a year of careful development and a strong commitment from our manufacturing partner.

This release is targeted at early adopters and developers looking for a more capable platform than existing low-cost autopilots. With more than an order of magnitude more processing power and memory compared to popular 8-bit autopilot platforms, PX4 is exceptional value for money and provides substantial room for future growth.

For more information about the PX4 autopilot platform, visit the project website at http://pixhawk.ethz.ch/px4/

PX4 modules can be purchased from our manufacturing partner, 3DRobotics.

Read more…
Moderator

Fancy twisting wing from MIT

120725120642.jpg

“We want to build small-scale UAVs that can fly quickly through indoor and/or cluttered environments, but controlling these UAVs is very different than controlling a fighter jet flying up above the clouds,” said Dr. Russ Tedrake, X Consortium associate professor of electrical engineering and computer science and aeronautics and astronautics at MIT and the MURI lead. “To be successful, we have to solve a number of incredibly hard problems in computer vision and nonlinear control. This long-term project lets us focus on the basic research questions that will lead to fundamental results and, ultimately, dramatic new capabilities for UAVs.”

Full press release

http://www.suasnews.com/2012/07/17753/birds-perceptual-and-maneuvering-abilities-inspire-small-unmanned-aerial-vehicles/

Read more…
Developer

Head first into the deep end :)

3689469893?profile=originalHi all,

I wanted to ask some questions about my quad implementation but I thought that it would be polite to introduce myself and my quad first.

I started my first quad design because my wife and I (and two kids under 2) were planning a 2 week four wheel drive trip across the Simpson Desert in central Australia. For those not familiar with the Simpson Desert it is 550 km of desert, 1100 sand dunes to cross, and 3000 km round trip. The quad seemed like the perfect way to get a different perspective on the landscape.

I have been following DIY Drones for a while because I supervised a couple of Electrical and Electronic Engineering final year projects to develop an IMU for a basic auto pilot application. So I ordered an ARM 2 and a bunch of parts from Hobby King.

I started with a cheap frame but quickly realised that it wasn’t going to be easy to mount the ARM 2 so I decided to design and build my own, keeping the aluminium arms and motor mounts. I wasn’t overly happy with my first design but it did serve to introduce me to some of the basic tuning and setup required. It also made me realise how much electronics I was going to have to cram into the quad to do what I intended.

I quickly realised that my first frame was going to be very difficult to carry in a fully loaded 4WD so I redesigned the frame to fold up and be stored against the cargo barrier above the rear seats. I also added some room for a pitch gimbal on the GoPro I intended to use.

The final assembly looks like this:

3689470045?profile=original

Folded for travel:

3689469893?profile=original

And the pitch gimbal and GoPro:

3689470170?profile=original

The basic parameters for the quad are:

1.6 kg with GoPro

NTM Prop Drive Series 28-26A 1200kv / 250w

APC 12x3.8 Propellers

Hobbyking X550 Aluminum Spare Booms ( 2pcs red/2pcs black)

ZIPPY Flightmax 4000mAh 3S1P 20C

Fat Shark Predator RTF FPV Headset System w/Camera and 5.8G TX

I broke quiet a few prop’s so I am now using:

Slow Fly Electric Prop 1045 SF

In the end it took four full days from start to finish before I left on the trip so I had very little time to learn to fly a quad and optimise the tuning. I have flown RC gliders since I was 14 so I had some basics but this was the first time I had flown anything with a motor. The most challenging part of the process was the tuning. I have a good understanding of control theory as make use of it from time to time in my day job but the Wiki control loop diagrams don’t seem to be up to date. This made it difficult to understand how some of the parameters interact.

I didn’t get to develop my flying skills too much before I left and I only started to get comfortable flying FPV near my last flight of the trip. Unfortunately I missed one of my ESC connectors worked its way out and I crashed the quad after approximately 10 flights. I some good footage though. I will post a video when I get one cut together.

I would like to thank the DIY Drones community and everybody who contributed to the ARM 2 board!

Read more…
3D Robotics

Review of new EasyStar II for UAV use

3689469849?profile=originalWe were huge fans of the original EasyStar back in the day: it was tough, flew well and had loads of room for electronics. But it was slow to evolve (terrible brushed motor, no ailerons, rudder too small) and our favorite beginners platform shifted to the Bixler, which came almost ready to fly and was much cheaper than the EasyStar. Last year, however, Multiplex released an EasyStar II in Europe, but it's only just now arrived in the US. So I bought one and put it together and flew it for a review here. 

First, the good news: 

  • Built-in ailerons
  • Excellent power pod allows for easy access to the motor. Designed for brushless motors
  • Folding prop
  • Easy-to-remove elevator for easy transport
  • Better ventilation
  • Bigger rudder

3689470062?profile=original

Now the bad news:

  • Expensive. $95 without motor, servos, or ESC (compare that to the Bixler, which is $58 with motor and servos already installed)
  • Hard to assemble: It basically arrives as bags of plastic and foam. Expect at least two evening to assemble. The Bixler, by comparison, goes together in about an hour, in part because the motor and servos are already installed.
  • Although the cockpit is longer than the EasyStar I, it's also narrower (by about 3-5mm), which makes for a tight fit between batteries and electronics. 
  • Nose-heavy, perhaps because of the longer nose. You'll have to push your electronics as far back as possible, and if you use a battery bigger than 2200mah, you'll need to add weight in the tail. 

3689470014?profile=original

Bottom line:

I was not as impressed as I'd hoped. Overall, I still prefer the Bixler for new users. I think the EasyStar II is too expensive and too hard to assemble, and requires ordering motor/esc and servos separately, which will confuse beginners. (Multiplex usually sells an optional power pack, which is a very expensive motor/ESC combo, but has not yet released that in the US. The one for for the old EasyStar, which may work, costs $80!). The EasyStar II flies well, but not noticeably better than the original EasyStar or Bixler in my limited testing. 

Now that I've bought the EasyStar II and set it up, I'm happy with it and it will be my main plane for APM 2 testing. But on balance, it doesn't represent enough of an improvement over the Bixler to justify upgrading. And remember, there's a Bixler 2 coming, too.  If Multiplex were to ship the EasyStar II with motor, ESCs and servos for under $100, I think I could recommend it, but for now I don't think it represents enough value and simplicity for new users.

Read more…
T3

Cheap Drones has a Customer for Life!

3689469867?profile=originalI recently showed an interest in supporting Cheap Drones over Hobby King in this thread, since Cheap Drones is a small company and I'm always glad to support them over big business.  Cheap Drones sent me a freebie gift since I'd shown interest in their products.  Now I was expecting maybe a t shirt or a lanyard, so I was shocked when I got an FPV Raptor kit in the mail!  All I can say is that Cheap Drones has a customer for life; I intend to buy all the FPV and plane equipment I need from them.

Read more…

Fighting with the wind with quadrocopter.

After coming back from my honeymoon I finally found some time to get some real flights. 3 weeks ago I flew my copter for the first time but it was just a few minutes on a very low altitude in front of my block. Today I went to some open space. Unfortunately, the wind was very strong so learning changed into fighting with the wind. Still managed not to crash the copter and even attached GoPro to it :)

Here you have 4 exceprts from those flights.

Comparing http://code.google.com/p/arducopter/wiki/AC2_ModeSwitch with APM Planner need to ask what is the "Toy" mode not described on wiki?

Also, is it possible to make some sound (by using ESC/motors?) when arming/disarming? My LEDs are hard to see under the shield (anyway, are LEDs shows arming state? on wiki couldn't find that info) so some audio notification would be appreciated. Audio info on GPS fix will also help a lot. I'll check for some hack connecting the buzzer. Still a newbie here :)

Except "stabilize" mode I tried to use "loiter" and "alt hold" but probably due to the strong wind I had problems with having proper control over my copter. RTL was also fast drifting with the wind far over home location so had to switch to stabilize to recover the copter.

On next session I'll try "simple" and "super simple" modes. To bad they can't go paraller to check them without connecting to APM Planner to switch "SUPER_SIMPLE" param.

Read more…