It flew ! For 50 feet off ground. Premature rope cut ! Dang....getting closer
Moment of ground release.
Next Friday...8-10-12...same time ...same place...another launch !
Earl
It flew ! For 50 feet off ground. Premature rope cut ! Dang....getting closer
Moment of ground release.
Next Friday...8-10-12...same time ...same place...another launch !
Earl
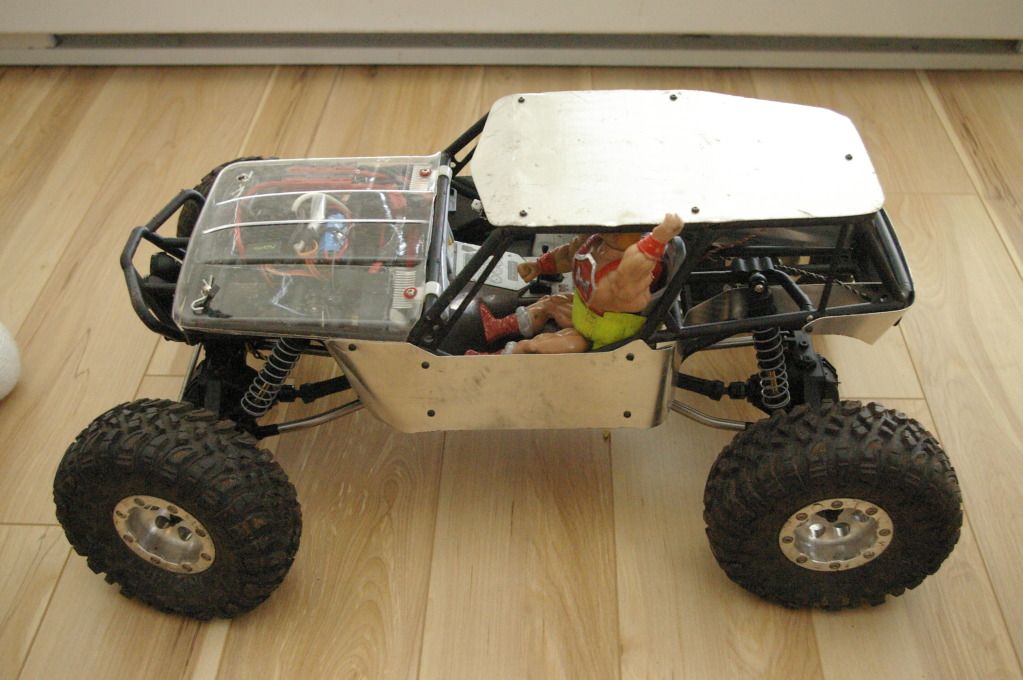
This drone 'stuff' seems to have taken over my brain, with FPV thanks to John Arne Birkeland's "Crawler 1" videos. I like how John's thinking process worked, testing the vehicle's drone capabilities via FPV driving made sense to me, and also FPV just looked cool!
So I've resigned myself decided that I'll be buying an autopilot eventually, but there are things with my vehicle I'd like to do first, and make sure they're compatible down the road. (that makes it sound like it's a bad thing, but it's only bad for my wallet!)
My current 'ride' is an 1/10th RC Truck, the Axial Wraith specifically. I've been playing with it since Feb/March 2012, worked out some of the problems with it, shaken out some of the more-easily-broken parts, and got it to a place where I can compete on the rocks and bash on the trails and have lots of fun in both places (without leaving a trail of parts behind me).
I realise from all the ardurover talk that the Wraith itself probably won't be the Urban Assault Drone of my dreams. Being 1/10th scale it has a problem with stairs and large curbs and other urban-environment things. It is also prone to being top-heavy and rolling over (less so now with my CoG lowering changes), and the environments I drive in can tend towards the muddy/watery, so I'd have to make sure everything's water 'resistant' at the very least. But I think it will be a good vehicle to test the various technological capabilities, so that in the future if I want to upgrade to a 1/8+ size vehicle, I'll have much more experience with a functioning smaller-scale system (as well as some hardware I may just be able to transfer over).
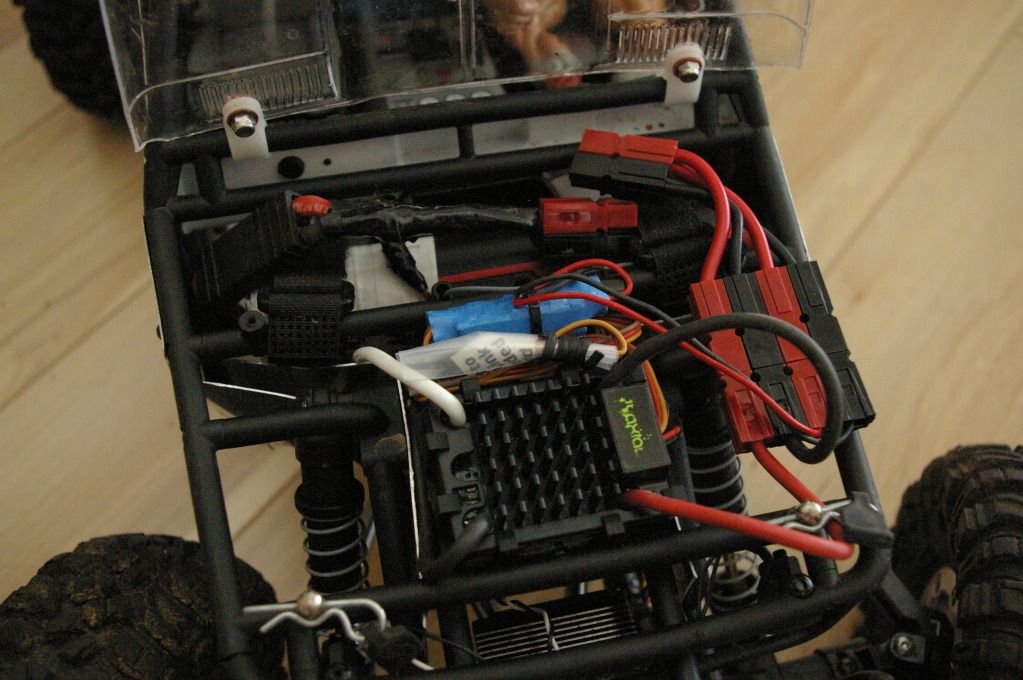 Under the Hood, all basic electronics squeezed to fit!
 Rear View, showing the space I've cleared for future electronics. I think the APM2 will just fit into the space between the shock mounts.
I'd like to be able to film FPV (and eventually drive FPV w/ same camera), with a camera mounted into the cabin of the vehicle. I've been looking at GoPro w/ AV out on a pan/tilt gimbal. Spacing will be tight, I may have to kick He-Man out of the driver's seat, but I think it'll fit inside. To do FPV with OSD I'd need the A/V cable for the GP and to add the various OSD/Tx stuff for that, and that's where the options are starting to get confusing.
I'd also like to be able to 'map' where I've been, even if I don't use any of the RTL/autopilot automatic driving stuff. What made me think of this was the rock-crawling competitions, I could map my own line and use the waypoint setting ability to mark where each gate is on the course.
I know the APM2 can do the auto-mapping (I've seen posts to that effect buried in here somewhere), but it's the various FPV/OSD combinations I'm wondering about. It would seem the 'easiest' way to get what I want, with a minimum of overlapping abilities, is APM2+minimosd, but I wouldn't mind some real-world confirmation and usage pointers for stuff like that. There are OSDs made for FPV that also function as a mini-autopilot, with their own GPS and RTL capabilities, but I'm not sure if there's a single all-in-one unit to rule them all or not.
So please, if you don't mind, I'd love to read opinion on this, how your experiences have worked out for you, pointers to other web-resources I may not have read already over the last few months. I'm sure I'm not the only noob with these questions. ;)
In the end, I'll probably attempt a total-awareness vehicle, driving around tracking everything, mapping wifi, maybe even terrain mapping, but I'm trying to limit myself and start small, instead of jumping into the deep end with both feet and ending up over-my-head and drowning-in-bits!
Also I've been lurking here long enough I thought I should at least introduce myself and my ride: ;)
Hi Everyone,
I'm working over some LANC controllers since few months. LANC is the camera control protocol by Sony and most of Sony, Canon and Panasonic cameras using this protocol to control the camera features by a cable remote.
I'm designing LANC RF links and other LANC products for video production market.
My new product is a RC LANC controller over servo lines and it is currently in production.
It is supporting Zoom(In-Out) and Rec(start-stop) functions.
Please share your idea about this product. It is useful or not? Need extra features? for drones?
Thanks
Melih
The next few posts in our tutorial series cover the setup of the PX4 autopilot for flight. The first step is to set up RC and telemetry. Here is a RC calibration video with Mission Planner showing the interoperability (due to MAVLink 1.0) of PX4 and APM.
The video is very short and basic and should just illustrate the route PX4 is taking towards maximum interoperability with MAVLink 1.0 and existing platforms and tools. If you have further questions about the platform or if you're unboxing it in the next days, please use PX4 Answers to get solid answers from the core developers and real-life tips from other users. We will reward active contributors to the answers and wikis with a community award and hardware.
7-30-12
10:00 am
I wake up get some coffee have some eats and go down to the garage . check the batteries , double check CG and control surfaces . go over everything one last time .
11:30 am
got the car packed and head off to get my friends Ken and Greg . the plan is to have Greg launch and ken video while I fly .
12:30 pm
arrive at the field . It was sunny with clouds and a 5-10 mph wind coming from ssw . I plugged the wings in , did a range check , everything looked good . me and greg walked to the east side of the runway and we launched it . It climbed quickly without any dip . a quick wiggle of the ailerons to check responsiveness and i climbed to ~ 100 ft and cut the throttle a bit . I turned the upwind leg of the pattern . the nose dipped a bit when it transitioned to a tail wind situation . I added throttle and it quickly recovered . defiantly nose heavy but i did that on purpose to help stability. got it through the downwind tun and checked for trim at about a 30mph cruise . It was dead on . no trim needed . I completed a few more laps and brought her in for a landing . I came in low over the east end of the runway with ~1/4 throttle i cut the throttle as it came over the runway . I let it settle in for a nice smooth belly landing . WOOT WOOT !!
here are the videos ken got for me on his phone .
Here a video of a full autonomous test flight of my Easyglider e-Glider piloted by the firmware ArduPlaneNG v2.x R4 and an AIOP (All In One Pro) full IMU board.This is a porting of the official ArduPlane v2 firmware with special addons and improvements for the AIOP board that I have added.
The flight was very stable in spite of the gusty wind conditions, the wind was blowing at 18 km/h gusting 35 km/h..
Below the setup used:
To make getting started with PX4 a bit easier, we've compiled an installation video for the Windows installer. The setup instructions for Eclipse are also valid for Mac OS and Linux.
Note that toolchain means a packaged selection of individual standard software required to develop software for a platform. We do not claim to have developed our own Integrated Development Environment (IDE), we just packaged what we needed into one redistributable file. This also implies that this development environment is not just usable for the PX4 platform, but for almost any other ARM-driven micro controllers.
The video runs through all setup steps, starting with the installation of the toolchain, downloading the PX4 Firmware the first time and finishing with Eclipse setup and board flashing. The toolchain can be used to build firmware for PX4FMU, PX4IO, PX4FLOW and any other ARM7, ARM9, ARM Cortex-M3 or ARM Cortex-M4. Functionality-wise it is similar to YAGARTO or CodeSourcery. Of course the credits for this go to MSYS, ARM and all other people porting the GNU toolchain to Windows, we just wrapped everything into an installer.
It contains:
Developers have the choice to either use the Eclipse IDE and build with double-clicking make targets, or to use plain Makefiles on the console and their preferred text editor. There is a SublimeText 2 project in the Firmware folder, for users preferring SublimeText.
A while back Jose Julio built a simple state machine for doing copter flips. I integrated it into AC 2.x a long time ago but never flew it. Then, once I built the Flash simulator I could finally test it without doing too much damage or loosing my quad to a fly away.
The original code was quick and dirty which lead to a few issues, one of which was a tendency to turn the my quad into an air to ground missile. The new code which is in 2.7 added a few items:
The state machine takes control of the throttle, roll and pitch until the flip is complete. It breaks up the flip into 4 main steps
The mode is enabled by setting the CH 7 option to Flip. Bringing CH 7 high while flying any mode will trigger the flip, but you must be armed and flying to get the flip code to trigger. You must return CH 7 low, then high again to reset the state machine and do another flip.
Jason
Willy the Whale is actually driven by a underwater Falcon remotely-operated-vehicle (ROV) in the fourth remake of the film, says Saab. (There have been four Free Willy movies????)
The biggest challenge, according to Marine Solutions director, Kevin Bey-Leveld, was to make the Orca whale, with its large body, look like it really was swimming along.
The success of the project, says Kevin Bey-Leveld, helped keep down the cost of filming.
“The way the Falcon flies, combined with trained ROV pilots, allowed the director to film the sequences in a relatively short space of time, in terms of normal filming,” he explains.
Although small and compact, the Falcon was powerful enough to manoeuvre in both swimming pool and the open ocean − the trick, explained Kevin Bey-Leveld, was to balance the buoyancy to compensate between sea water and fresh water.
It is not the first time the Falcon has starred in the movies. In the Bollywood film, ‘LUCK’, also filmed in South Africa, it was strapped under a 4.2 metre long latex and polyurethane replica of a tiger shark and used to replicate the realistic swimming motion of the shark and its violent attacks on hapless swimmers.
The Falcon is owned and operated by Cape Town based Marine Solutions. The ROV’s worldwide success across a range of industries, has come from its power to hold steady in strong cross currents, and its distributed intelligence control system that allows up to 128 devices to be connected together on a single RS 485 serial network. This means different equipment can be easily added and changed as needed.
First of all – thank you for the warm welcome into the DIY drone family. I am very grateful that so many people spent some time on reading my first blog post about the USAV.
So the idea of what exactly the USAV is, is starting to form, and while there are a lot of practical stuff to work on (changing frame, gluing nuts and bolts, deciding which configuration to fly), the more abstract thoughts about what the USAV should do has to be developed alongside.
One of its features should be the possibility to give it some kind of task, and let the brains of the USAV solve the task. This may sound very AI, but even AI is in its heart a bunch of formulas and computations.
The USAV could in some regards be seen as an autonomous satellite, with a bunch of sensors on it, which it should utilize to solve the task at hand. We have camera, magnetometer, accelerometers, Wi-Fi radio, GSM/GPRS radio, microphone etc… and could be equipped with even more sensors. Also remember that internet is available during the operation.
As with all life (even Artificial Life), life must have a purpose.
So today I would like to ask this wonderful community for ideas of what kind of tasks the USAV could be asked to perform. Any suggestions are welcome, fun, useful, technically demanding….
To start you off – here are some of my own ideas
Please leave a comment describing
1) The task
2) Special requirements (sensors, setup etc..)

A few weeks ago Hobbyking revealed in a picture on their facebook that a new version of the Bixler was supposed to be coming. Today they listed it an ARF version on their site.
While keeping the features of the first Bixler (the plane is named after one of the Flitetest presenters) Hobbyking has managed to improve flight times by giving it a bigger wing area (wingspan of Bixler 1 was 1400mm, version 2 has a wingspan of 1500mm) and other design improvements. The Bixler 2 in ARF form comes with a lower kV motor that can handle bigger props (7x5 for this version, was 6x4 for the 'old' Bixler. By enlarging the canopy area you are more versatile in the FPV equipment you want to use or use a larger flight battery. Also, the canopy is clear plastic now (was black foam).
Flaps are optional. Although the plane comes with a provision to add flaps, you don't need to use them. If you still want to use them, then you need 2 9 gram servo's and a servo reverser to your cart.
The price for the Bixler 2 ARF is US$ 69.99 while you can still get the old Bixler in ARF form for US$ 49.82. It's unclear what that price difference is coming from, maybe they want to sell out the previous Bixler.
For more information and specifications see: http://www.hobbyking.com/hobbyking/store/uh_viewitem.asp?idproduct=24474&aff=5361
Hi Guys I got the wing covered With Ultra Cote from a roll I bought 25 years ago when I first got into R.C.and added flaps and Ailerons out of solid Balsa. mounted with 1/2 inch nylon hinges with a brass cotter pin I put black markings on the bottom of the wing so I will know if it is right side up or not I am debating putting 1 3/4 inch slats 3/4 of an inch ahead of the leading edge to give it "STOL" performance I think I will leave it the way it is for now and finish the build I still have to iron it a couple of more times to get all the wrinkles out. It is not professional Quality but it is certainly stronger than the wings on my radian pro the wing root is aluminum and the ribs are 1/16 inch balsa and a carbon fiber reinforced leading edge the voids between the ribs are filled with 666 psi high density spray foam it is 78 inches by 9 inches(702 Sq in) and weighs a pound and a half There are 2 metal gear servos for the flaps and ailerons in the middle it will be attached to the fuselage with 4 bolts with a nylon angle of incidence" wedge" in between. Here are some pix of the build. You guys have a great day!
Now that uDrones is a 3DR subsidiary and we've moved half of the electronics production there, uDrones is able to lower prices and provide the latest 3DR electronics. That means that the ready-to-fly ArduCopter Quad now comes with APM 2.5 and the new, awesome 3DR uBlox 6 GPS for $799 (assembled and ready to go; just add your own RC gear and battery)
The RTF ArduCopter Hexa, also with APM 2.5 and the 3DR uBlox 6 is $899.
And ArduPlane, also with the upgrade to APM 2.5, is now $50 cheaper at $599.
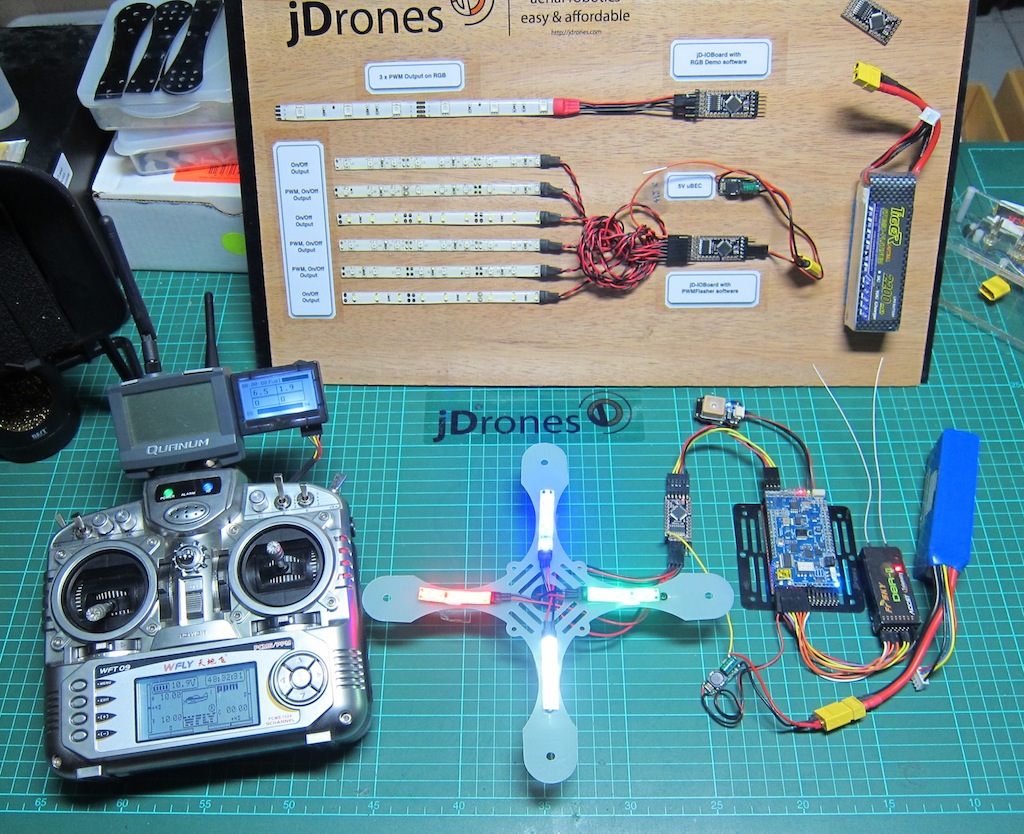
jDrones NEWS: IOBoard goes MAVLink 1.0
Time has come to make another exciting release. New software has been released for our mini IOBoard. With this software you are not anymore depending on static flashes, blinks and other patterns.
We made blog post about basic jD-IOBoard few weeks ago and you can read it in here. Now it just get's better and better.
jD-IOBoard now listens full MAVLink 1.0 protocol and acts depending on flight modes. Currently we are supporting ArduCopter and ArduPlane style flight modes but more has been planned. Basically all MAVLink compatible systems works fine with this.
Big thanks to Michael Oborne for his great jD-IOBoard Confgurator program that allows users easily to configure and test play different patterns. Michael is the man behind Mission Planner and also OSD Configurator.
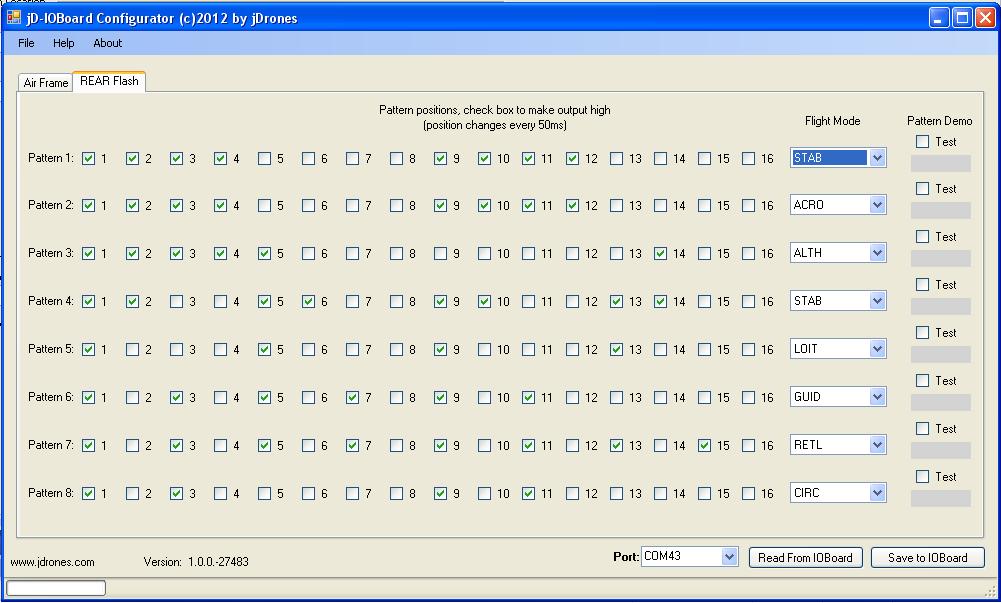
On configurator you can create 16 step patterns and 8 patterns that can be binded on different flight modes. On right hand side of every pattern you have Test box where you can simulate your pattern. Just click Test and then change on/off positions to get your desired outcome.
With Configurator you can also upload our latest HEX files from Arducodes repository.
Here is quick demo video of how it works in real-life with 3 different patterns.
Currently we are only allowing REAR pattern to be changed but in future there will be others coming too.
You can always find latest HEX and other files from our: Arducodes repository (jD-IOBoard 1.4 MAVLink. HEX)
Latest Configurator can always been downloaded from our: Software repository (Setup.EXE). Setup file is available on our Arducodes repository too.
Configurator has builtin update feature installed so it will make sure that you always have latest version of it. Source code is on our repository.
jD-IOBoard can be found from our store at http://store.jdrones.com and also from our distributors around world.
Have fun with your flashing lights. Evenings are getting darker but planes and copter more brighter.
Regards,
Jani / jDrones
It was a productive weekend: MP up and running on my shop PC, aircraft firmware loaded into APM2, radio connections troubleshot and calibrated, Wow! There's my house with a graphic quad hovering over it! (I am not worried about giving away my coordinates. Come on by but call first, please.) After performing the leveling cal I even was able to watch the artificial horizon roll correctly, the compass indications were correct, and all in all it was just plain cool!
The Configuration -> Radio Calibration section of MP is great. Graphically you can see if your transmitter outputs need inverting and also if they are centered well. This is a great benefit if your transmitter does not have this feature but it is more important to the operation of the aircraft.
I hit a wall when it came to calibrating the ESCs. 3 hours of frustration and a day later, the short version of the story is: Triple check your wiring of the *output* of the APM2 if you can run the ESCs one at a time off the receiver throttle output. I messed up and had the ESC output cable on the wrong end of the header. Output 8 - 5 DO NOT drive the ESCs. I now have a gold star on the top of the cable plug and oriented to remind me of how it is supposed to be installed. The picture below shows the cable, on the right, installed incorrectly.
Tonight I succesfully performed the 'all at once' ESC calibration and ran all four motors up under APM control! Then my ESCs decided to inform me that the battery had drained sufficiently to allow them to refuse to operate. The indication was a "1-2-3" (increasing pitch) beep series followed by "1-1-1-1-1-1..." (same pitch at 0.25 sec interval). Low battery. Onto the charger it went while I do this post.
Spektrum DX6i note: Part of the troubleshooting yesterday involved figuring out why Ch 5 was following inverted to the throttle input. This was simultaneous and proportional. Ah yes, the hand in the back.. Mr. Sikorsky? Very good! You must set up your Spektrum DX6i (or what ever DX you have) in ACRO (fixed wing) mode. Somewhere this was not clearly explained to me. I suspect this is true for any of the programmable RC transmitters. If you think about it, there is no such thing as a multirotor RC transmitter mode. I suspect that soon enough the maufacturers will provide multirotor graphics to make those of us who are obsessed about that kind of thing happy. Until then, the airplane graphic will do just fine.
As mentioned in a previous post, we need some form of kill switch to make system power isolation easier than pulling a stiff connector off the battery. My right thumb is nearly raw from all the efforts. Yes I am whining but there must be a better way. A rework of my battery mount is also in order. The sticky foam being employed does not stick to itself very well. The double velcro straps work but if the foam slides, so does the battery. A multi-connector manifold for Deans, EC-60, etc connections would also be cool. That way most any battery I have could be employed. Most have Deans but in the pic above you see the EC-60. The PDB has an XT60. Connector proliferation has struck in spite of my efforts to not allow it!
In short, my soldering job seems to be good and now that the wiring is sorted out and basic functions and calibrations were performed, a maiden flight, though probably short, is very near.
This means more time with FMS and the DX6i.
What is the High Tech Line? Wingsuit base jumpers call the tracks they fly down "lines". The High Tech Line is what you see here ... lines that are flown with high tech equipment. Little lower, little better glide angle ... and a little less dangerous :)
It flew about as well as you'd expect (60-second flight time, no tolerance for wind) but what a cool bit of mechanical design! No idea how that "laser beam" control works. From Engadget
Back in the '70s, the CIA needed some kind of miniature flyer to deliver an audio bug, and after considering (and rejecting) a faux bumblebee, decided that a robotic dragonfly would be the best option. The wee UAV used a "miniature fluidic oscillator" as a motor and was propelled by a small amount of gas. It was somehow guided by a laser beam, which served double-duty as the "datalink for the audio sensor payload," according to the CIA Museum. Unfortunately, the insect-based mech proved too difficult to control, especially with any degree of wind, and was eventually scuppered -- all that's left of the now-declassified project is in the video after the break.
You always have that ONE flight where nothing goes right. 7-27-12
The balloon slipped off the filling neck and got away. We had a backup balloon ! The second helium tank was EMPTY.
Dang..what luck.
Soooo... I will show pictures of the X8 wing we will try to launch Friday 8-3-12.
The Big Wheel antenna on the front is for the 5 WATT ATV TX on 434 mhz. (Yes I am a ham N8TV)
Antenna on wing is the 10 watt APRS antenna on 144 mhz.
Notice the annoyance deterrent ?
5 watt ATV Tx, APRS (under card) and battery.
Nichrome cut down system activated by time or a command from the Mission Planner and APM 2.5
It is released by a command from the Mission Planner at a LOW altitude. (joke)
I hope the Friday 8-3-12 launch goes well.
Earl
Here a video of a test flight of the ArduCopterNG v2.7 with the All In One Pro IMU board (AIOP). The official release of the ArduCopter v2.7 firmware for APM has been ported and tested successfully in flight on a quadcopter with an All In One Pro (AIOP) v1.0 full IMU on board by Jean-Louis Naudin on July 29, 2012.
Avionics:
- Full IMU: All In One Pro v1.0 (AIOP) from CRIUS
- GPS: Mediatek MT3329 (10hz)
Firmware: ArduCopterNG v2.7
- Receiver: Turnigy 9X8C v2
- Transmitter: Turnigy 9X with Er9X firmware update
Lipo: Turnigy NanoTech 2650 mAh 3S
Frame:
- DJI F450 FlameWheel (set to Quadcopter X mode)
- 4 brushless motors RC Timers BC-2836/11
- 2 propellers 10x6 CW
- 2 propellers 10x6 CCW
During the test flight, the wind was 17 km/h gusting 20 km/h
More infos at: http://diydrones.com/profile/JeanLouisNaudin

It may be that the blog reaches more people on RCGroups than DIY Drones. The audience of both tends to be the same RC pilots, not electronics designers, but RC Groups tends to be frequented by more electronics designers while DIY Drones is frequented by more absolute beginners.
Because of the lack of jobs, the Marcy class aircraft have tended to shift more towards a product than an open source hobby. Had a rare opportunity to fly her in a large room, because someone paid to have a pretty difficult autonomous feature put in Marcy 1. For a few days, only 2 people in the world saw a vehicle do what she did, for the cost.
Also got to fly her manually, in a large room. The 1st manual indoor flight in her 3 year history showed exactly how stable she is.
So that difficult autonomous feature is top secret & the brains of Marcy aircraft are becoming more secret, over time. 15 years of doing 1 open source project or another have never yielded any career benefits from the open source aspect of it. They might care about the final product or the experience from developing it, but no-one ever offered a job because the source code was free & no-one who copied my source code to advance their job ever offered a pat on the back.
Part of the problem is it takes a lot more support than development for the open source aspect to gain enough popularity that it enhances your career. You have to be more of an organizer & the development has to be more in line with what the masses look for in other products right now, not a science project. Compromises like a 4Hz update when you'd like 30Hz or a clunky touch screen interface when you'd like a bulletproof tactile interface have to be accepted, because the platform has to be what the masses want right now.
In open source RC projects more than web servers, the developers tend to have jobs other than programming. They're competent enough at programming to make a career out of it, yet they're not offered jobs & they don't seem to seek any.
What seems to be happening is people who work on web servers are interested in software for its own sake. People who work on RC projects are using software as a tool to solve another problem that they're more interested in. The economy is based on very specialized roles, performing exactly 1 task for their entire life. Programmers are supposed to write software for their entire life, without regard to the application.
If technology is allowing 1 person to do the work that required 3, years ago, shouldn't jobs become less specialized? Business leaders are all saying no & continuing to just hire specialists. Programmers are just supposed to program, because the amount of skill required to be competitive requires committing your full attention to just 1 thing.
The maker revolution seems to depend on the opposite, because you don't have the budget to hire a full time, lifetime specialist in Ruby on Rails. Money is made by generalists who fabricate, program, & solder, while the specialized work of perfecting the tools is unpaid.
Exactly which model will be required to survive is unknown. A modern government can impose any model it wants, through flexible currency & credit. We only know that business leaders using the traditional model continue to dominate the economy & the economy hasn't produced more than it has consumed in many years.
Who knew there were once people who spent their entire lives lighting gas street lights.

There were once people who spent their entire lives manually adding transaction amounts in books, before computer spreadsheets.
Hard to believe the reason today's jobs seem ridiculously specialized isn't because the same type of evolution has continued.
