All Posts (11086)

Sort by
3D Robotics

Good Robots Podcast on robot swarming

3689380703?profile=originalThis weeks' Robots Podcast has a great interview with Alan Winfield, co-founder of the Bristol Robotics Lab. Although it's not about UAVs, per se, it is about the challenges in swarming robotics. He makes some excellent points:


--There are no real swarming robotic deployments in the world outside of lab simulations.

--One of the problems with designing swarming strategies is that in the absence of natural evolution and selection pressure, we can't measure how "good" they are.

--My favorite line: "There are no robot ethics. Only ethical roboticists." Like him, I've always thought that Asimov's Three Laws of Robotics were silly. Robots aren't people and can't have ethics. Robticists can.

Read more…
3D Robotics

Nice piece on the Canon Hack Development Kit

"These aerial images of White Sands National Monument [top] and Glen Canyon Dam [left] were taken by a Canon SD30 carried on a radio-controlled model airplane [right], using CHDK to operate the shutter."


IEEE Spectrum magazine on the great CHDK software, which allows you to control Canon cameras remotely. The whole piece is long and interesting, so read it all, but here's a bit about what CHDK is:


"The CHDK firmware resides on the camera's memory card, but the original Canon firmware remains on the camera's internal flash memory. So you're not likely to "brick" your camera by using CHDK inappropriately. Indeed, you can return your camera to its stock configuration merely by restarting it without CHDK on its memory card or by switching the locking tab on the card to its unlocked position. (CHDK loads only if the card is locked, and once this firmware is loaded, the camera can still record images.) The CHDK firmware is described fully on the wiki athttp://www.chdk.wikia.com, which includes a "CHDK for Dummies" section and plenty of pointers for getting up and running."


(via Adafruit)

Read more…

STMicro Cortex-M4 Samples Coming Out!

2010-11-30_crh_STMicroelectronics_CortexMCUs.jpg


STMicro has done it again... this time readying their ARM Cortex-M4 MCU (with hardware floating-point, DSP instructions and compatibility with Cortex-M3) for production in early 2011. In addition, they're also expanding into the F-2 series, which features an adaptive real-time memory accelerator to achieve a performance of 150 Dhrystone MIPS when executing code from flash at 120MHz (the maximum possible for the Cortex core).

All the above devices will remain software and pin-compatible!

Now it will be possible to upgrade the CPU on some existing IMU/AHRS/MARG/INS designs, so that a true Kalman filter can be implemented with floating-point support!

Click here if you want to read the full press release.
Read more…

I2C is delicate, I too see

My first attempt at communications was going to be I2C, with the ArduIMU as a writing master, and the Nano as a reading slave. I had hoped that the 5V nano would be OK with the 3.3V magnetometer, but COMMs were never achieved, and it seems to have damaged the mag.
So, back to serial, while I wait for FedEx to bring my early xmas gift.

On the Nano is the ArduPilot 2.7.1 and COMMS are happening just fine.
Given that the 2.7.1 takes up 24886bytes of the Nano's 30720, the first step is extensive cutting back of any code that I know I won't use for now.
Read more…
3D Robotics

Three Paparazzi-powered UAVs stolen

Martin reports: "Last weekend (27./28.11.2010) someone broke into the University of Bergen, Norway and stole three Paparazzi-equipped autonomous aircrafts/systems for atmospheric research based on the Multiplex Funjet. The break-in was very precisely targeted to only the systems that had been used in many measurement campaigns. Any information about the disposition of this equipment (e.g. suspicious offer for sale) is highly appreciated.

More detailed descriptions at the site of the Norwegian RC club:

http://forum.radiostyrt.no/vb/conten...A5let-fra-UiB?"

Video from one of the UAVs on an arctic mission:

Read more…

Arducopter arrived at home

5217320527_b3305ec5a0_m_d.jpg
Just wanted to share my excitement about the arrival of my Arducopter.

Want to thank and congratulate with Jani for the super fast shipping (despite one month of wait in the pre-order list): the box left the office last Friday and this morning, Monday, 3 days later with a weekend in between, it arrived at my place, in Bruxelles (Belgium)

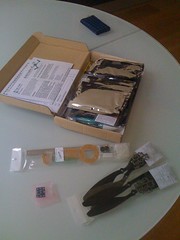
Here is the content of the box:


In main box the full arducopter kit, then 2 sets of spare propellers (you never know what you can hit, and propellers are the first thing to break), the magnetometer and a crash kit (one complete arm).

As a side note, I was not able to close the box after I took the additional items out: the guys that packed it must have insane packaging skills for having assembled this 3D puzzle :)

Here some additional pictures:

5217905034_006c3e5e9d_m_d.jpg5217905666_0a3bf9b975_m_d.jpg


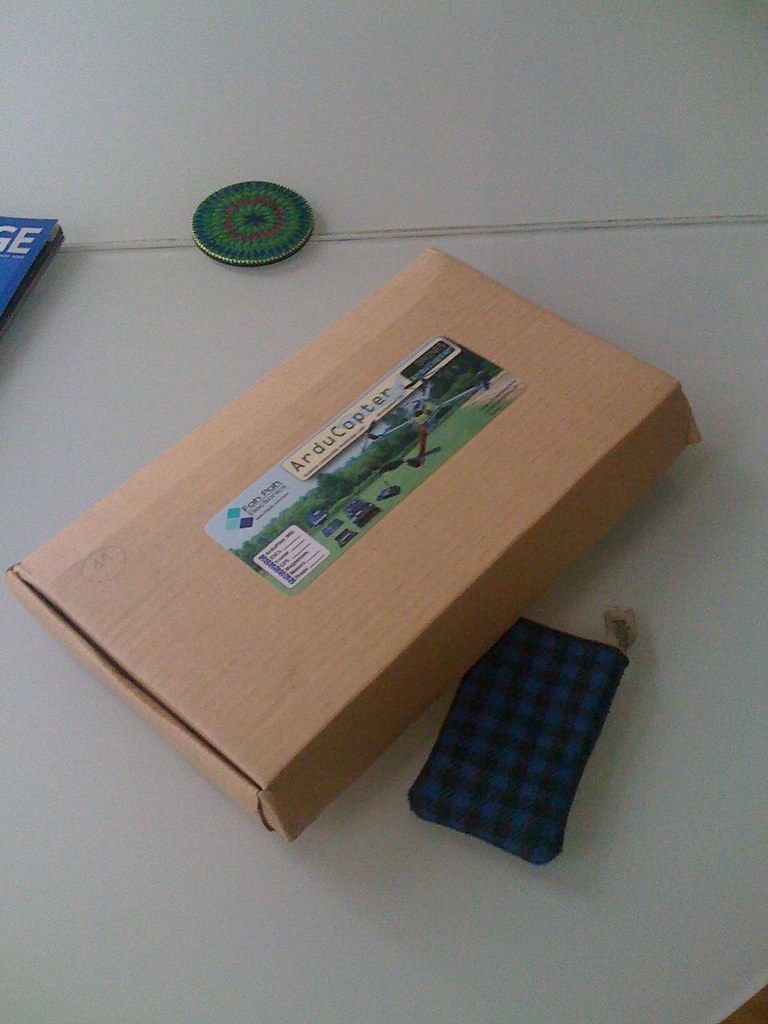
Impressed by the size of the box: I expected it to be bigger, while it is pretty small. Look at the iPhone cover I used as reference. Positively impressed: less problems for storing it away :)


I don't think people will be interested in me posting my building log here in the main page of DIYDrones, so I think I will do it on Flickr: Arducopter Building Log.

If you are interested you can also subscribe to the RSS feed: http://feeds.feedburner.com/ArducopterBuildingLog


Let me know your thought on this.


Hope to be able to start working on it soon :)

Read more…
3D Robotics

I've updated the APM Beta code (zip file version) to roll up our latest bug fixes and tweaks. The most noticeable one is that we've moved back to the excellent circle algorithm that we had in ArduPilot2.7 (we were experimenting with a different approach with APM, but the ArduPilot one turned out to work better in the real world). You can see some results from one of my flights yesterday above (using a SuperStar--moderate wind).


Overall it's flying very well and has been tested on a large and growing number of aircraft. It almost invariably works right out of the box with the default gains. All you should need to do is change the DIP switches to get your servo directions right and use elevon mixing if that what you need.


This is the last beta update. We expect to release the 1.0 code (not beta) this time next week. As always, you can follow the progress here. As you can see from that activity tracker, the APM Dev Team has been busy.

Read more…

Hi, I'm wondering if there's a way to obtain AoA and sideslip angle information from GPS speed data? There is vertical speed and 3d speed so this would probably be able to give me an estimate of the angle of attack, but for sideslip, I would have to have the y-component of the speed. Is there a way to get this from GPS or the IMU unit?

I have also tried it for one whole day but am at a loss of how to get the information to be passed from ArduIMU V2+ to ArduPilot so that I can use XBee to transmit it wirelessly to my GCS. Any clues from any good samaritans out there?

Otherwise, I think I am left with integrating acceleration information from the IMU which will probably be susceptible to a lot of errors, and also since it depends on the 'initial conditions' the errors will accumulate continuously.. :( Any ideas on whether this is a feasible option at all?

Read more…

ArduIMU Crawler

3689380375?profile=original


It's getting cold and I'm limited by space to fly and money to repair crashes, so I'm going to feed all my toy-wants by starting off with an AGV, and using the knowledge and experience to make liftoff next spring smoother than would otherwise be.
I already tried using a Traxxas Rustler, but keeping control at low speeds and preventing motor overheats was an issue, so...browse....browse...browse....ah-ha!

3689380408?profile=original

What better vehicle to accidently go off-roading with at low speeds than a rock-crawler?! :-)

Kit form - No electronics - $150

3689380401?profile=original


Basic crawler ESC and Motor installed: $130-ish


What I had on hand: Arduino Nano V3 and breakout board

Purpose: Main Processing

Servo Control

IR Distance measurement using a Sharp GP2D15 on a pan/tilt


What I bought: ArduIMU+ V2 Flat, and HMC5843 - Triple Axis Magnetometer

Purpose: Rollover warning, impact sensing, heading input, turn-rate input, future GPS


The CreepyAGV V1.0


Read more…

Drive 10 Servos using only 2 Arduino Pins


I've been building both AutoPilots, and QuadraCopters, and I wanted to drive more servos and ESCs, with less jitter, so I used some ideas from the Paparazzi gang and developed a way to drive up to 10 servos with just 2 output pins from an Arduino or ATMega8.

The design uses just one chip, a Johnson style Decade Counter, and requires only two output pins from the Arduino. The Arduino uses one PWM pin (pin9), and one general IO pin (pin8). All the pulse are generated in sequence on the PWM pin, then spread out to the individual servos via the decade counter. The decade counter costs 63 cents.

Now I can build Hexa-Copters without having to use I2C ESCs, and still have servo outputs available for camera controls.


Read more…

Flex 4 GCS Update


This should have come out yesterday but admissions essays got in the way. Anyway, I updated the GCS, and now it supports waypoint-ing by clicking on the map. You can also insert waypoints in between existing ones by using the Add Before/Add After buttons. Delete waypoints by using the shiny red button.

To set up options for takeoff and landing, click "Takeoff / Landing Options". You'll be shown a screen like this:


... where you'll be able to set the takeoff pitch and altitude, as well as add CMD_LAND_OPTIONS entries. Fill in the boxes and click Add Landing Option, and it'll be automatically added to the list. The list is held in sorted order. To delete an option, select it and hit the 'Delete' or 'Backspace' keys on your keyboard.


Finally, You can export your mission to a waypoint writer file. I've only exported to the mission[][5] array, so you'll need to create the file and then copy and paste it in.


If you're using the GPS Simulator with this, and suddenly see the CDI (lowest instrument on the left) needles suddenly jerk around, just ignore it for now. I'll add in functionality so that the CDI will show your deviation from the plotted mission soon.


The updated .AIR file can be found here: http://zhiquanyeo.com/apm-gcs/APM_GCS_ControlStation.air


Have fun and as usual, let me know if there are any bugs, or comments :)
Read more…
3D Robotics

AR.Drone + ROS = Goodnesss


More cool stuff with Willow Garage's Robot Operating System (ROS) from I Love Robotics: "Updates to Brown University's ROS Software Repository should soon include the ardrone_brown driver which improve the AR.Drone's ROS performance with access to the front camera. The video above shows the system in action tracking an AR Marker."
Read more…

JYNX Depron Made Glider


DSCN4355.JPG


JYNX 4.0: This is JYNX glider designed by RCPLANS.nl . Now a days I am working on it and modifying it for electric motor powered. I am attaching whole plans of this glider. Totally made of depron foam and low cost plattform for APM.


The JYNX is a depron flying wing glider, designed for sloping. It's a simple build, which took me a week to finish in the evening hours. The JYNX has a 15% symmetrical airfoil, which is created by folding the wing from the leading edge around a depron spar. there are no carbon fibre reinforcements used, yet the wing is very strong and stiff. This plane is light on the budget too, as it uses just two cheap 5 gram servo's, a 4 channel receiver and a small battery.So far the prototype has flown a few hours, in which I've experimented with the center of gravity, control throws and reflex. You can find the results on the plan. Keep in mind that reaching the indicated center of gravity will mean you have to place the receiver and battery at the back of the fuselage.The JYNX has had a good number of pretty rough landings, but I haven't found a single scratch or crack. This is a very durable plane.Finishing has been done with clear packing tape used for masking, acrylic paint applied with a brush, and a dry paintroller to absorb and spread the paint. The results can be compared with airbrushed paint.The available space in the fuselage is quite limited. I'm still working on a version with a brushless motor, and might release a new plan for a slightly bigger fuselage soon.


Click the file below to download plans

jynx.zip


DSCN4288.JPG


DSCN4292.JPG


DSCN4307.JPG


DSCN4296.JPG


DSCN4297.JPG


DSCN4310.JPG


DSCN4294.JPG


DSCN4311.JPG


DSCN4312.JPG


DSCN4314.JPG


DSCN4351.JPG


DSCN4355.JPG


DSCN4356.JPG


Read more…
3D Robotics

Book recommendation: The World's Worst Aircraft

I noticed this book on the bargain shelf of Barnes and Nobel and picked it up--I haven't been able to put it down since. It's a terrific romp through 150 of the worst aircraft designs in history, but what it really is a catalog of all-too-common engineering errors, such as:

  • Solutions looking for problems (such as jetpacks and the Hillar hovering sniper platform)
  • Engineers designing planes with no sense of what pilots wanted
  • Dependencies on exotic fuels that aren't available
  • The "Gillette problem" of adding more wings than the last guy, including some crazy 8-wing things
  • Delivering so late that the need is gone.
It's beautifully illustrated and very funny, thanks to the sparking writing of Jim Winchester. And the stories are hilarious. Here's my favorite passage, about the ME 163 Komet, an experimental German rocket plane:

"The fuels in the Komet were highly corrosive and would dissolve organic material (such as the pilot). To avoid this, the pilots would wear special asbestos-fiber suits"

Kill you now or kill you later ;-)

Highly recommended!


Read more…