All Posts (11086)

Sort by
3D Robotics

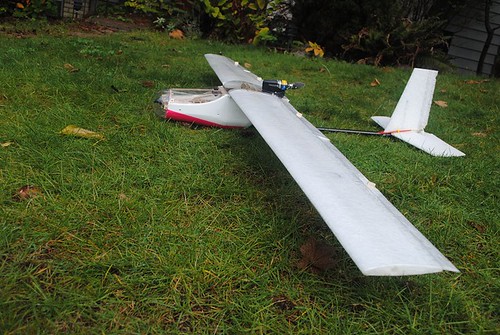
FPV goes very wrong, plane kidnapped, then....


Hilarious. This is why you want live video/telemetry in your planes!

"One of my 1st FPV attempts didn't turn out so well, it was found by some teens whose first thought wasn't to find the rightful owner until they discovered a camera on-board. A couple hours later I recovered the plane with the help of a local garbage collector and here is the edited down version of the video I found recorded after the whole ordeal had ended. "

(from RCG)
Read more…
Developer

The new ArduPilotMega Mavlink branch with the latest QGroundControl development branch enables the operator to dynamically load waypoints and set gains in flight. To test out the communication we setup a small ground based experiment with an RC Car. No gains were changed from the default ArduPilotMega gains. Also the inertial navigation code was used between GPS updates but the GPS reset the position/ velocity when each GPS packet was received. This led to some oscillations that will be corrected in later tests. The autopilot trim throttle/ steering is set at the beginning of the experiment using the autotrim feature of the ArduPilotMega autopilot system. At the end of the experiment the trim throttle was insufficient off-pavement and led to the end of the test. More experiments to come! We will be testing out the data-logging and in flight gain adjustment.


Below we have included a screenshot of the ground trajectory. We were using a ublox gps. Note that there was significant GPS signal degradation due to the surrounding buildings that led to the trajectory deviations from the flight plan.

Read more…
Developer

What's up with original Ardupilot? (not APM)

Hey everyone, I just wanted to catch everyone up with the state of the original Ardupilot (not APM!). I'm the only developer currently working on it and could use some help. I recently had a baby boy and between him, work and a small copter side project I've not been able to keep up with the code.

What needs to get done:
  • Maintain compatibility with the config tool. - don't mess too much with the EEPROM.
  • Move from our old GPS parsers to the newer and well maintained Libraries.
  • Add printf and <avr/pgmspace.h> to move Serial.print strings to ROM from RAM.
  • If possible add in CLI from Mega. (We're running low on ROM!)
  • Do anything to reduce, clean up code to free up ROM.
  • Anything else we can do to align, where possible, with Mega.
In the end these should be minor updates. I just can't get to them and flight test them.
Jason


Read more…
3D Robotics

This isn't quite DIY, since the Skybotix coax platform costs $5,000 (!), but if you want to run Willow Garage's cool Robot Operating System (ROS), you're going to need some serious computational horsepower, such as an onboard Gumstix linux processor board.


We wrote about this before, but I Heart Robotics has an update:


"There seems to be something about Zurich and Micro Air Vechicles, maybe it's the alpine air. This video shows the Skybotix CoaX helicopter being tele-operated through ROS. On the software side of things the CoaX, appears to be running eRos, or something similar, on-board aGumstix processor. It has basic support for running opencv on-board and is capable of transmitting images as a ROS topic. It's not clear how the IMU and optical flow data is made available in ROS, but overall their documentation looks good.

On the hardware side, the CoaX is equipped with both a pressure altimeter, for outdoor use, and a sonar altimeter, for indoor flight. It has two dsPIC microcontrollers, IMU and a Bluetooth or Zigbee radio. Optionally it can be purchased with a Gumstix Overo, WiFi and lateral IR sensors. The 340mm rotor diameter makes it capable of flight through small apertures and it's low center of gravity makes it aerodynamically stable."

Read more…
3D Robotics

Updated version of ArduPilotMega beta code

As we do every week, I've rolled the latest bug fixes into the current public zip file version of the ArduPilotMega code. It's a good idea to download a fresh version if you haven't used the code for a week or so.

These are just bug fixes. The new features and enhancements are happening in the developer trunk of the SVN repository and should not be used, as they're often untested. They'll be release with the next public version of the code, 1.0 (non beta).

If you've had trouble getting your CLI to work, try downloading the code again, as we've fixed that bug. It's best to delete all your APM files INCLUDING THE LIBRARIES, and load them fresh from the zip file.

A few other updates:

  • APM boards will be back in stock at Sparkfun on Monday
  • More magnetometer boards will be in stock at the DIY Drones store early next week.
  • ArduCopter kits started shipping on Friday, and the first 50 are already out the door. If you pre-ordered one, it will probably be shipped in the next few days.
  • We've got tons of new products coming! You're going to be amazed ;-)


Read more…

Instrument panel written in Python.


hey guys,
this might be of use to some of you:
i've scripted a set of basic instruments in Python that might be of use to some of you.
the Youtube clip shows it attached to my UAV project.

for anyone who hasn't used it, Python is a particularly easy to use programming language that is used for all sorts of applications.
there are loads of add on libraries to do much of the hard work for you which makes it particularly useful for this sort of rapid development.

the Python code can be downloaded here under the name "cockpit.zip":
http://sites.google.com/site/mrdunk/Home/downloads

more detail on my UAV work here:
https://sites.google.com/site/mrdunk/Home


dunk.
Read more…
3D Robotics

Demo of new AR.Drone game

I've never been totally sold on the AR.Drone as a gaming platform (you need two drones, two iPhones and, most importantly, the ability to fly the thing via the laggy first-person-view video feed on the phone, which I find really hard), but credit to the company for making it look cool!
Read more…
3D Robotics


Robots Podcast co-host and researcher Sabine Hauert writes to tell us about a new blog:

"I thought you might be interested to know that the journal "Autonomous Robots" which is very well known in robotics now has a blog: http://www.autonomousrobotsblog.com/

The goal of the Autonomous Robots Blog is to present the latest research published in "Autonomous Robots" in a fresh and interactive manner through reader-friendly summaries and videos. All posts are based on material that is newly published and peer-reviewed.

Our latest post is about quadrotors cooperating to transport objects:

A video from that post is above.
Read more…
Moderator

SFAR 107 what you might expect

patrick.jpg

Patrick Egan has some comments about the upcoming SFAR 107.
Highlights include:-
VLOS = 400’ AGL out to 1500’ laterally.

Small UAS handbook

Manufacturers operations and maintenance manuals

Operations only allowed 5 miles from charted airports. The other bins or “types” will find themselves flying further away.

Written permission from airport manager for operations closer than 5 miles (I suppose that there’ll still be no operating in Class B)

Ground School

Pilot certification (Pilot’s license)

Observer certification

Class 2 medicals for both the pilot and observer

Electronic position and altitude reporting (Self certification okay here.)

No autonomous aids (but not here.)

Aircraft certification, PIC (Pilot in Command) will declare

Some sort of automated web-tool to be developed for registration

Data collection/capture (TBD)

SFAR standards still to be developed by ASTM and other standards groups (another story all together)

And for the nonaffiliated RC hobbyists, you will basically be at the mercy of the ATO as they will be writing the regulations for you.

* This list is meant to demonstrate the tone of SFAR as we’ve not had the privilege of laying eyes on the chiseled granite.


His full article here


No doubt as ever fur and handbags will fly now.

Read more…
3D Robotics

My Ten Rules for Maker Businesses


Based in large part on our experience here at DIY Drones, I've written "Ten Rules For Maker Businesses", which has been serialized on the Ponoko blog this week in the lead up to their announcement of adding 3D printing to their service. Here they are (click on each for the full text of each one):


Read more…
Developer

ArduPilotMega integration with QGroundControl is finally finished. All of the basic functionality is there although there are some finishing touches that need to be done. I added the ability to set local/global waypoints and also actions (takeoff/land/etc.) to easily integrate with the existing APM autopilot software. A 3d osgearth view inspired from dronegcs is in the works and we hope to have it together soon.
Read more…
3D Robotics

DIY flight simulator

Nothing to do with UAVs, but boy is this geeky/cool (from MakeZine):"Matt Thomas of Roger Dodger Aviation (and Maker Faire Kansas City fame) designed and built this Moving Axis AirCraft Simulator, which is a flight simulator that tilts and shifts you as you fly a virtual plane. If you've been thinking about building something similar, you are in luck- along with the device itself, he also recorded a series of tutorial videos on the trials and tribulations of constructing such a device. He writes:
The Moving Axis AirCraft Simulator (MAACS) was our first experimental effort in motion flight simulation. We also delved into virtual reality along the way.

The menu on the right is a series of videos that show how MAACS works. It shows how MAACS was developed, and how we tried different configurations.

...and we tried a lot of stuff. We called this rapid prototyping. Basically, you draw up an idea, then buy a bunch of boards and plywood, bang it together and see what works and what doesn't.

It was a lot of trial and error. It was frustrating and fascinating all at the same time. This is the MAACS series.


Read more…
100KM

EPP covering technique " the new stuff "

5184757573_327f0c1748.jpg

Expanded polypropylene is highly desired for fabricating small remote control airplanes and uavs . Its high impact stability low material cost and low weight makes it very good for this role . However the two main ways of manufacturing parts from the raw material have drawbacks . Molded EPP makes a great finished product and can be produced in many shapes including compound curves and can have a smooth finish. the major drawback is the high cost of producing the molds and the production machinery. The other method used is hot wire cutting . the start up cost is much less expensive, however it cannot produce compound curves and the finish is very rough, which can produce unwanted drag in an airplane design.


Wanting the best of both worlds , I came across this blog on what has been termed " the new stuff ". I ordered a couple roles and began playing with it when it arrived. I was very impressed and decided to use it on my next version of the techpod it went on like butter , very smooth , easy to manage wrinkles and adds much structural strength to the EPP. over all this technique is about the same weight per square inch of wing as molded EPP.

I am very please with the outcome and very happy to share this with the hobby uav community at large.

Read more here http://community.evuas.com/pg/blog/EVUAS/read/205/epp-covering-technique-the-new-stuff- and yes i will be offering small quantities at good prices on the EVUAS store soon
Read more…
Developer

Full autonomous flight of the TrIMUpter UAV with automatic landing

Here the video of the 1st full AUTONOMOUS FLIGHT of the UAV TrIMUpter with AUTOMATIC LANDING controlled with a 9 DOF IMU and a GPS...
Electronic setup used:
- ArduIMU+ V2 flat (a 6DOF IMU)
- HMC 5843 triple axis magnetometer
- GPS EM406 SirfIII
- 3 brushless motors Hextronik 1300 Kv, HXM2730-1300
- 3 ESC Hobbyking SS Series 8-10A
- 1 servo Corona 919 MG 1.7kg/ 12.5g/ 0.06sec
- 1 Lipo battery 3S1P 11.1V 1500mAh
- 3 propellers CCW GWS EP0843
Firmware: TriStab v2.3 JLN
More info at: http://diydrones.com/profile/JeanLouisNaudin

Read more…
Developer

ArduCopter factory updates..


ArduCopter Factory Update....

Jordi showed his electronic 3D Robotics facilities some weeks ago and Chris posted some more after he visited there, now It's time to give quick look on how Fah Pah Electornics facilities looks like and where the magic happens for ArduCopter frames and other parts.

Small history about early dates and today: Earlier Beta frames were made in smaller scale and without proper production facilities on my friends office but now that we are doing them in a bigger scale and we want to provide good and reliable service to all DIY Drones customers, we needed to have proper production and storage area. So me and my partner created another division under Fah Pah Elecronics Co., Ltd. (Btw. Fah Pah means Thunder/Lightning in Thai language).

We had a possibility to get another office area from same building where main office is, so we got it and did move all Drone/UAV production/packing/shipping there. Also to make life a lot easier on people on main office where all electronics design and assembly is done, I was driving them crazy running CNC's all day long.

And now finally we can start show how things looks like and where the magic happens. There are another factory that does all fiberglass/polycarbonate parts for us. On this area we make all smaller parts and packing/testing/shipping.


Picture: 3 weeks ago when first furnitures started to arrive:


Because we were in hurry to get production up and running so people can start flying their ArduCopters as soon as possible, we created temporary walls around CNC machines to keep voice down.


Picture: CNC cuting room where all small parts are made. Even tho there are automated machines, a lot of hand work is done to get them ready


There are now 3 table size heavy duty CNC machines running constantly and doing various parts. Covers are still missing around CNC routers so it's rather noisy room when all three are running at full speed.


Material size that we can use on those is 30 x 60 x 7 cm and they cut even 3 cm stainless steel.


(Mr. PIK examining cut quality on motormounts or something else parts)


Other tools that we do have is milling machine, grinding machines and polishing machines. Plans are to have few more tools to help on some production issues. Like belt saw, air compressor etc.


Picture: Preprocessor software for CNC routers, Mach3


Softwares that we are using on production floor are:

  • Mach3 - CNC processing
  • ArtCAM - CAD/CAM drawing and design
  • Cut2D - CAD/CAM drawing and design, mainly for importing simple customer drawings
and few CAD programs to do initial drawings like TurboCAM 5 for Mac, AutoCAD for Mac, Solidworks for Win.


Picture: Storage shelfs are starting to get populated (filling up more every day)


Picture: Closeup for motors and other parts for ArduCopters


Picture: Packing are is used to unpack nuts/screws and propeller shipment that arrived today (16th of Nov)


Picture: People always says that it's hard to find CW & CCW propellers, not anymore.. We have them now and more will come :)


Video: Last but not least... Quick video tour to production floor. (Watchout, loud noises)


There are still many things to do before shipping will start, but it is close only few items are missing and they should arrive this week Thursday.


Many things are still looking their places on this production floor and many issues still needs to be resolved but over all it's looking rather ok.


After shipping has started there will be time again to do experimenting and prototyping for other nice add-on parts for ArduCopter like camera mounts, IR Sensor mounts and all other things that our users would ever need.

If you have a good idea or needs, share it, maybe some one else has similar needs.. Also if you have special needs, just ask and we can look what we can do.

Few more picture will come after packing has started to show how new packets and contents will look. Not any major changes on beta frames but still :)

Happy flying guys & gals...
and remember.. fly safe.


Read more…