I just wanted to let everyone know that early registration is open for the UAS Airspace Operations Challenge. Please take a look at the web site (http://uasaoc.org) to see the deadlines (early registration ends Nov 15), the new Team Agreement, and the revised rules. You can sign up for the competition mailing list there, as well. The first phase of the competition will be next Spring, with a total prize purse of $500,000. Feedback is always welcome!
All Posts (11086)
Sort by
I'm glad to say I'm helping myself to a beer tonight....my first ever design flew tonight!
It was a dark, windy night, and I had to light "home" with my car headlights...but it was enough to get it in the air, hovering and even moving about.
And what can I tell from this short, windy flight?
- Well, it's massively overpowered without the gimbal and nex5 aboard. Tomorrows daylight flight will include this weight to even it out.
- It's stable in the wind. Wow. And some. I'm getting pelted with leaves in the bluster, but it's just slowly moving about, even on stabilise. No histrionics - no mad plummets or bounces. But with 83cm between the front arms, there's a lot of weight and leverage to keep it that way. It's so good I'm calling it "Terrance". Fans of the Angry Bird cartoons will know why.
But the true tests are to come. Will the "very forward of CoT" CoG caused by the gimbal destroy the handling? Will the APM react ok being off centre? How will it handle getting thrown about properly? Should I dump zeal, and go back to moongel (see chart below), based on the worse-than-wanted vibes chart? Can I improve on the 15% Compassmot (yes, I can)?
But most important of all - and the reason it was designed - does it make a good video platform? Time will tell.
Every now and then a new blog post or forum thread pops up something along the lines of "Be careful, I got cut by the propeller ..." with ugly images attached.
UAVs are complex solutions and can be dangerous. The technology itself can help prevent accidents but eventually in most cases it boils down to human errors. I have fond memories sitting in a cockpit while going through checklists. We should learn from the real aviation and adopt checklists to make flying UAVs safer. I am always going through my checklist on paper before a flight. This is a proven approach to keep risks low.
In our situation we could take the idea of paper checklists even one step further: interactive checklists. It would be even nicer if the groundstation software would aid the operator going through the checks. The GCS could help by displaying relevant values which need to be checked and allow user input where needed in a structured ways, step by step.
The Image above shows a mockup of a tablet base UI which could be used as checklist in the field. If such a feature would be implemented in DroidPlanner orAndropilot it could also offer GUI components to switch mode or read settings while going through the checks.
Below is my checklist for an electric plane. It might look different depending on vehicle (even for fixed wing planes). I think it would be important to make such checklists configurable. The user should be able to re-order and add/remove items.
From preparation to launch, during the mission and while landing different checklists are required. The checklists could be organized in tabs.
My checklists:
Preflight check
[ ] Check payload battery
[  ] Check payload on
[  ] Check UAV battery
[  ] Check airspeed sensor clear
[  ] Turn on transmitter
     [  ] Mode manual
     [  ] Power idle
[  ] check prop clear
[  ] Power up UAV
     [  ] block airspeed sensor
     [  ] don't move UAV until elevator flicks 3 times
[  ] Connect telemetry
[  ] Check 3D GPS fix
[  ] Check altitude
[  ] Check airspeed
[  ] Check Home Location
[  ] Check cruise speed
[  ] Set home altitude to realtive alt.
[  ] Check moving surfaces [Manual]
[  ] Check moving surfaces [Stabilize]
Mission planning
[ ] Wind direction and speed?
[ ] Auto take off? Angle ___, Altitude ___
[ ] Check default altitude ___
[ ] Check altitude graph
[ ] Check distance
[ ] Upload mission
[ ] Download mission again and check
Take off
[ ] Check prop thrust?
[ ] Wind direction and speed
[ ] Takeoff flight path clear of obstacles?
[ ] Mode auto
[ ] Check elevator (auto takeoff only)
launch against wind
Landing
[ ] Check home altitude
[ ] Check cruise speed
[ ] Check wind direction and speed
Shutdown
[ ] Power idle
[ ] Mode manual
[ ] Disconnect Telemetry
[ ] Power off
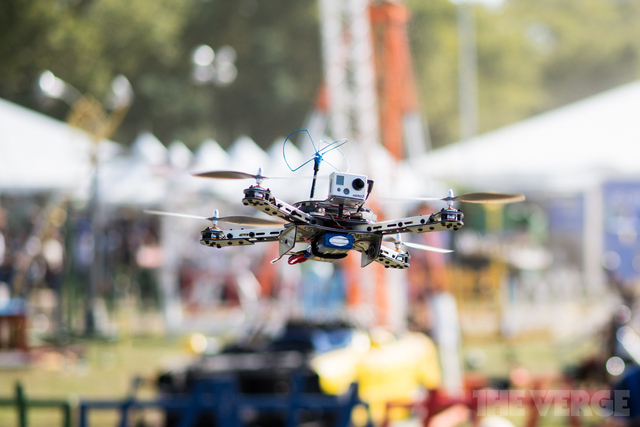
A businessman walking through the East Side of Manhattan Monday was startled when a 3-pound helicopter drone crash landed a few feet from him. The man recovered a memory card from the downed craft and passed it along to a local ABC News station, which broke the story of the accident this afternoon.
The man, concerned that he could have been injured by the falling drone, contacted local police, who told him that no law had been broken and did not pursue the pilot. FAA rules state, however, that hobbyist drones must fly below 400 feet and keep away from airports and heavily populated areas like city streets. The Verge contacted FAA spokesman Les Dorr, but reached the following voicemail message: "I am out of the office due to a lapse in funding. Please call back after news reports advise a resumption of services for all federal agencies."
Chris Anderson, founder of the drone company 3D Robotics and the online community for enthusiasts, DIY Drones, confirmed that this kind of flight was illegal. "The FAA has very clear guidelines on this, and such flying over built-up areas is clearly in violation of those rules (and has been for decades)," said Anderson. "One of the things we created DIY Drones for was to inform people about such regulations and principles of responsible flight. But clearly the message needs to get out better."
The Verge has also reached out to the NYPD for comment.
Click Here to go to the Diy Drones News Center
I added a visitor globe to the Diy Drones News Center page under the Video's tab at the top of the page. I'm curious if you folks think it would be a cool feature to add on the front page of DiyDrones. If you click View Large map you can view all kinds of visitor statistics and lots of different maps to view the global spread of DiyDrones Users.
Joshua Johnson
Diy Drones News
Somehow my previous blog post got removed from this site when I made some minor edits to it last night. Sorry for repost.
In November Intel will release this Quark (IA-32 x86) based development board named "Galileo" targeted for the education and hobbyist markets. Both hardware and software are open source.
Arduino supported and I believe it has the necessary IO for it to be a very nice flight controller.
Links for more marketing details...
http://www.intel.com/support/galileo/
http://www.intel.com/content/www/us/en/do-it-yourself/galileo-maker-quark-board.html
http://arduino.cc/en/ArduinoCertified/IntelGalileo
Best link for programmers to get detailed HW and SW documentation:
https://communities.intel.com/community/makers
Hope to see this community adopt this board and do some great things with it!
Having just completed the new Octa frame with vibration isolation system it was time to design a gimbal for it.
One great advantage of 3D printed parts is variable density. They can be almost hollow where stress is low.
It comes in at 900g including NEX 5n camera with zoom servo and bracket, also 3D printed.
Motors are 4008 -150 size with Alexmos controller.
Camera socket can be adjusted so it goes back exactly on the balance point every time. This base also includes the IMU unit.
Even with the controller mounted as close as possible to the camera base the IMU cable was still too short and had to be cut and extended. Longer cables please guys.
Here is the Octa going through its paces with a 1kg 'dummy' camera hanging below.
Now all the plastic parts are designed it wont take long to produce more of these. Other colours are available.
A Simple idea for a big problem
Rc model safety, Is everyone doing
what they can do to protect out hobby and the public.
(summary: I would like a splash
screen to be implemented on all software that gives safety tips each start up)
Full story
Please don't take the following as me bossing around, this is a suggestion I feel very strongly about and so should everyone as it will effect everyone.
So recently (very recently) Multirotor and other RC model safety has been brought into the spotlight.
there have been deaths, injuries, cuts, bruises and damaged Egos, btu most importantly bad impressions and opinions.
With all this negative attention I foresee this blowing up very soon and being the central gaze of media.
And even though we have all sorts of blog posts with advice in hindsight, nothing has been done, so action needs to be taken, Because the sooner we do something about Rc model safety, the leaner the consequences will be.in the long run.
I would like a splash screen to be implemented that gives safety tips each start up
on all RC related software, not only on Droidplanner, which Arthur supports (the creator or droidplanner) but on software like Missionplaner, Andropilot, open9X etc
anything that is an aid or enabler of RC flight (remember that boats, cars and subs are also classed as drones in the laws
The main message ontop followed by the sub message (they could be comical or upbeat )
eg: (main message)
(example of message below)
Return to launch (RTL) only flies in a straight line,
it wont watch out for that tree
Return to launch (RTL) Do
esn't know when it is going to hit something,
make sure the path is clear!
Return to launch (RTL) Don't fly if you plan on using it.
It Doesn't give you wings!
Return to launch (RTL) Is n
ot capable of flying through objects,
so don't make it try!
Prison or Freedom, only one accident away
are you willing to risk your own life?
Life or Death, Only one crash away!
Is life in prison worth it?
Your life and spectators, Would you let someone new fly close to you?
Don't let the inexperienced fly dangerously
Medical,court and insurance costs, Are you rich enough?
Don't endanger others or their property
Damage, how much is their car worth?
I don't think you want to find out
Good luck to all who recognize the benefits
Another idea from me :) hope you like
Regards Jared Reabow
@MultirotorGuy
Is it time for the DIY Drone community to roll up our sleeves and enter a team into this anti-poaching UAV contest?
http://www.wcuavc.com
$65,000 in prizes and an all expenses paid trip for the winning team to the Kruger Park in South Africa for 10 days to fly the design with the real life anti-poaching teams.
We have to have the expertise in this community to win this competition hands down?
Maybe 3D can use some of this newly raised $30 million to offer the winning UAV design a production contract and 3D Robotics can then offer a line of counter poaching UAV's?
Chris, drop me a note if this is of interest and I can send it onto the contest organizers so you can discuss the idea.
This is the latest creation from Bernie's basement (tm). It is a GoPro based steady cam using a Tarot gimbal for stabilization. It attaches to the carbon core X8 via 2 screws AND can be used as a standalone steadycam device. It is self contained with a NiMh battery, switch, and video transmitter. I hacked together a miniUSB cord for the GoPro to transmit the composite output to the laptop so I can see what I am filming when I fly. The gimbal has a connector to allow a clear view of what is recording while flying. I can also remotely control the pitch of the camera in flight (using channel 6 via the remote control). It isn't the pretty think in the world, but a drill, a soldering iron, a hobby case from radio shack, and a half a day of cobbling makes for a pretty cool toy!
3D-printed quadcopters are now officially hip.(Sheldon via BoingBoing)
 I have recently been quite active regarding the use of Micro UAVs in Search and Rescue here in Finland and I also have been in contact with the EU Commission on this matter.
Here in Finland - as in many European countries - Search and Rescue missions are carried out under the authority of the police but mainly by volunteer organizations, such as the Red Cross, The National Association for Volunteer Rescue Services (VaPePa), Rescue Dog organizations and the Finnish Lifeboat Institution. Recently, inside some of the involved NGOs, the usage of Micro UAVs has been subject of discussion and evaluation, based on the obvious advantages.
While the current EU regulatory drafts contain reasonable exemptions for hobby/recreational use, as of now, NGOs will be classified as professional users. That would mean:
- UAS will have to be certified, just like a fullsize aircraft
- The NGO will need an operator's license, just like an airline
- The pilots will have to have some kind of pilot's license
This directly translates into the following problems:
- Only commercially produced UAS can be used. Commercial UAS are already now very expensive. Once they need to be certified, they will become even more expensive due to increased requirements for the manufacturers and the simple fact that the manufacturers can determine the prices by phantasy as there is no cheaper competition any more.
- Certified UAS will likely also need to be maintained similar to fullsize aviation standards, means mandatory maintenance by authorized facilities - again very expensive.
- Getting an operator's license will produce more costs and includes the need for determining personnel which holds the responsibility. A very tedious, if not impossible, task for an organization based on volunteers.
- Finding volunteers which are willing to spend the time and the money to acquire a pilot's license will be hard. Of course, the NGO could offer to pay the bill but what if the member stops volunteering? People move for new jobs and might stop working as a volunteer because the have less time. Maybe they expect children or start building a house. Also, for volunteer-based work, you always need a broad base of qualified people. The volunteer might be on vacation or on a business trip or in an important project where the employer does not permit the volunteer to respond to an alarm.
These regulatory drafts which classify volunteer-based NGOs as professional users will very likely effectively kill the usage of Micro UAVs by volunteer rescue organizations in Europe.
I already started some work on this matter, but of course, one man alone can hardly move anything.
Therefore, I call on everybody in Europe who
- Is involved in any type of voluntary rescue organization or other volunteer-based NGO
- Or is involved in any way in R/C-, FPV- or hobby UAV activities
- Or simply is a concerned citizen who does not want to see the application of this exiting new technology for saving lives killed by ignorant rulemakers
Get active!
- Bring those topics up in your local organizations!
- Push your local organization heads to bring the topic to the national organizations!
- If you are in the board of a local or national volunteer rescue organization, contact the boards in your neighboring countries!
We urgently need an international European alliance of volunteer rescue organizations and other NGOs to make ourself heard in the regulatory bodies and try to make sure that the same exempts are included for voluntary rescue work as for recreational/hobby use!
"Welcome to Taranis!" And that's exactly what my new $200 radio said to me when I powered it on. Awesome. Over the coming weeks I will post a number of blogs on how to configure the new FrSky Taranis radio for use with your drone.
Audio is a the killer application IMHO. No more sticky tape labels to remember which mode you selected, just configure the radio to tell you on throwing a switch. And it has plenty of those switches. A total of six 3 position switches + the T-CUT and the trainer switch. It has 4 pots, two on the face place, and two "sliders" which using for camera pitch and roll will be great.
For styling, its not any different than the classic JR radio, it even has a compatible JR Module Bay in the back so you can plug in your favourite MHz/UHF or other manufacture module to be compatible with any older kit you may have.
Internally it has a FrSky ACCST 2.4GHz D16 system that supports up to 16 channels. It also backwards compatible with older FrSky receivers.
The power requirements standard is 7.2V 260mA. It's supplied with a NiMH 7.2V 800mAh pack and charger, but can take 2S or 3S LiPo and LiFE packs (I'm using a 1800mAh LiFe pack). If you have an 8 cell AA NiMh pack 2400mAh you can even charge it even in the radio!
If all that isn't great enough, it's completely updateable as the firmware is a custom version of OpenTX
It comes standard with a ratchet on the throttle control, which I am not a fan, but no problem, just remove the six screws from the back and you can disengage that with a few turns of a conveniently placed screw. You can also change from MODE1 to MODE2 config as well, if required.
The build quality is excellent, and I am really happy with this purchase. (Thanks Dany @ candadrones.com)
All in all, I don't think you can go wrong with this budget radio with features found on radios costing in excess of $1000
Look out for the future post on how to make this radio really work for you, and maybe just boss you about a bit "Please land now your battery is flat!" ;-)
Bill
Guys, stop buying and flying quads when you don't know what you are doing. Especially over crowds or populated areas. This should be common sense.
RAW video link - http://abclocal.go.com/wabc/video?id=9270819
Well it's begun and this case will have an impact on all of you in the USA in one way or another. For those that did not hear about it Trappy is facing a $10,000 dollar fine.
The Complaint alleges that on or about October 17, 2011, Mr. Pirker (a Swiss citizen residing overseas) was the “pilot in command” of a “Ritewing Zephyr powered glider aircraft” in Charlottesville, Virginia. Compl. It next asserts that “[t]he aircraft referenced above is an Unmanned Aircraft System (UAS).” As a matter of undisputed public record, a Ritewing Zephyr is in fact a popular type of radio-control model airplane made of a kind of styrofoam and weighs approximately four and a half pounds once equipped with batteries, radio, motor, and other components.
The Administrator alleges that Mr. Pirker’s Zephyr was equipped with a camera, that Mr. Pirker operated the model for the purpose of supplying aerial video and photographs of the University ofVirginia campus to an advertising agency, and that he was compensated by that firm for the video and photographs. 4-6. The Complaint notes that Mr. Pirker does not hold an FAA pilot’s certificate.
The balance of the Complaint sets out a list of allegedly dangerous characteristics of Mr.Pirker’s operation of his model airplane on October 17, 2011. It alleges that he “operated the abovedescribed aircraft at extremely low altitudes over vehicles, buildings, people, streets, and structures.” More specifically, it alleges, inter alia, that he operated the model airplane “through a UVA tunnel containing moving vehicles,” “below tree top level over a tree lined walkway,” “within approximately 15 feet of a UVA statue,” “within approximately 50 feet of railway tracks,” “within approximately 25 feet of
numerous UVA buildings,” and “directly towards a two story UVA building below rooftop level and made an abrupt climb in order to avoid hitting the building.”
Patrick Egan of sUAS News was given access to documents today and he wrote:-
Without a doubt, there is a lot riding on this issue for both the community and FAA. As we have seen in the past, people start to line up on those different sides of those issues with independent views on how the law works, what image the community should portray. Whatever the eventual outcome, we should at the very least have a better understanding and some clarification on how the process is supposed to work, and discern where exactly the U.S. RPAS community stands.
More at http://www.suasnews.com/2013/10/25375/trappys-defence-moves-to-dismiss/
Trappy, along with Chris Anderson is a speaker next week at the Drones and Aerial Robotics Conference
The very low cost ruggedized case MAX 505S (complete series) nicely fits the Iris with props unmounted. This is a custom / personal DIY setup, not a product - although we would guess that 3DR will be offering something along these lines. The case is water-tight and has a pressure valve. It comes with pluckable foam which can be manually brought to shape. The RC transmitter could also be fitted underneath, but in this example we decided to keep it external to have a clean 'all things Iris' box. Iris has a classic (nicely machined, black anozided) prop mount which tightly fits the APC SF props. We're working with 3DR to speed up rotor mounting / unmounting with a simplified 'quick mount'. The larger version of the case, MAX 505, would have plenty of space for additional items, but also has obviously more volume. MAX 505S dimensions should fit cabin luggage requirements of most airlines and Iris + accessories + case should be below 6 kg.
Both Mission Planner and DroidPlanner have recently added features for simplifying aerial survey. These tools help take the guesswork out of mission planning with cameras onboard, taking pictures to be stitched into a mosaic. Rather than manually specifying a grid flight pattern, you can instead specify you camera, desired operational altitude, and triggering method. The survey tool takes care of the rest, and allows you to see the expected coverage as well as estimates of ground resolution, required number of pictures, and other statistics.
Survey is completely airframe independent and works for both copter and plane. By framing the mission planning problem in terms of aircraft operation and desired result, rather than the means to that result, planning is vastly simplified, repeatable, and easy to do in the field.
Fly the camera, not the plane!
The current version of DroidPlanner now supports the following features in Survey:
- Simple user interface
- Multiple supported cameras
- Real-time visualization of the flight plan
- Projected camera footprint visualization
- Calculated statistics, such as coverage area and mission length
The current version of Mission Planner now supports the following features in Survey:
- Both simple and advanced user interfaces
- Multiple supported cameras and custom camera definition
- Automatic camera parameter identification by photo upload
- Real-time visualization of the flight plan
- Projected camera footprint visualization
- Calculated statistics, such as coverage area and mission length
- Trigger type selection and auto population of the distance-based trigger, CAM_TRIGG_DIST
This is the first of a series of posts explaining the end-to-end process of aerial survey, from planning to stitching. The wiki will be updated with tutorials on 1) mission planning, 2) aircraft setup and operation, 3) camera control and 4) post-processing. And new features are always being added, so stay tuned!
Things are slowly moving forward.
The status right now is:
- Boat has done some sea trials. It sails, and it sails better than expected.
- Windvane is integrated with APM using a separate Arduino nano and I2C to the APM
- APM installed in boat with GPS, compass and telemetry. Next step is to start logging data for use in for example simuliations the coming winter months
- Sail Simulator installed on my home PC.
- Created a small processing program to read NMEA from the simulator and to emulate keyborad commands to it to control rudder and sheet.
Next step:
- start writing a simple autopilot for sail simulator so i can develop steering and navigation algorithms this winter
- Continue sea trials to gather as much data as possible before it gets to cold.
That is where i am!
/Magnus
Continued here
DiyDronesNewspaper-Volume1pdf.pdf Option #1 (Recommended)
Link to DiyDronesNewspaper - Volume 1 - Google Docs - Option #2
DiyDronesNewspaper - Volume 1 - Download File Option #3
DiyDronesNewspaper - Volume1 - Download File Option #4
This is some more pictures of what Volume 1 Looks like:
GoPro just announced its new camera, the Hero3+. I am really interested to see how much smaller it really is than the hero3. Longer battery, sharper lens, smaller, 720p at 120fps sounds really good to me. The buttons on the enclosure seem bigger, I hope so, the old ones were a pain to press. Anyone getting one?
Edit:
Here is the video, now gopro has made me want to play with lions.
I found this picture for size comparison:

http://www.theverge.com/2013/10/2/4795488/drone-crash-landing-accident-new-york