Yee haw! Save your money boys and girls. Looks like Iran may be going into the flight controller business soon. Once commercialized, the RQ-170 based flight controller should outperform DJI, and Arducopter. Maybe even give Mikrokopter a run for its money.
All Posts (11086)
Sort by
I did't know how much important is choose the right propellers, but after changing on my multiwii and arducopter (3dr) i get no vibrations and fly very well :)
this is the video:

With the arrival of my 3DR radio, I discovered that I had quite a collection of boxes from open source hardware companies. I think it's safe to say they may be setting the pace in the world of electronics delivery packaging!
details here:
http://eastbay-rc.blogspot.com/2012/04/review-open-source-cardboard-boxes.html

I'm thrilled to report that my radio kit arrived and it works well. Andreas is likewise happy with his kit.
Writeup here:
http://eastbay-rc.blogspot.com/2012/04/review-3dr-900mhz-radio.html
Fixing the air unit network id:
http://eastbay-rc.blogspot.com/2012/04/setting-network-address-on-3dr-air.html
Thanks 3DR, Tridge, and everybody else that worked in producing this unit!
Today I went to a mega store and I found this "broken" car for just 9.99 pounds, so I decided to buy it and replace the crappy car that I mounted all the stuffs.
The next week I will buy 1 ultrasound sensor, extension IO and a compass, them should help the car to drive in a specific direction ( i.e. to the north ) and I am going to avoid the obstacles that the sensor will find on the road.
 If you're like me, you've been asked plenty of times if your RC unit can be controlled by an iPhone. Now you may be able to answer yes!
Hobbyking IOS & Android 4CH WiFi Receiver
Four channel, talks over wifi, app works by pseudo-stick or tilt control, mysterious reference to "video function", failsafe... seems pretty nifty!
It looks like the unit joins a hard-coded network name, and the password is printed on the receiver.
Reference manual here. The Internet believes this to be the app.

Hi Everyone
Today is Friday and after dispatching all orders finally we are idle.
My MQ-202 MicroQuad was on the desk and airsoft guns were on sight.
Please watch all video we have a surprise in the end ;)
Have a nice weekend
Melih & Bora
First! i'm bad in english but i try to explain everything i done and i have many question to help me if you can.
Last year thailand flood, This is my head video camera 9 km. from take off point.
And i have another camera under the plane for aerial photos
When already have raw material aerial photos then i used photosphop Command to make 1 peice situation map like this (20 photos)
after that i used photoshop (Automate->Photomerge) to processed a lot of pieces (1 piece create from 20 original aerial photos) again for only 1 map photo.
and i used global mapper software to make ground control point for geo reference in this map photo.
make .png and export to .kml to display in google earth
it's not perfect but i can use this for my job.
my job is volunteer in disaster in thailand.
when situation come i use this map for meeting with local people and another volunteer or doctor to plan how to help before real help from gov come.
i learn from many people from internet and rc group in thailand
this is my plane
Hand made air frame form stein aircraft (Thailand)
433 MHz Dradon link
Dradon lab autopilot
2 x 5800 mah
---------------------------------------------------------------------------------------------
Next i want to learn about ardu mega and imu to merge pitch roll yaw to each aerial photo.
i have questions
If i buy APM V2 and IMU V3
- i must to buy OSD?
- between Full ArduPilot Mega kit (soldered, code loaded and ready to fly) from Udrones! or APM V2 and IMU V3 i need?
- IMU V2 can trigger camera , IMU V3 can do that?
- after flight what software to merge pitch & Heading log file with photos?
Somebody can help me or teach me to do this?
Thank you
My name is OB
Hi all,
It occurs to me that I never got around to posting my videos flying my ArduCopter, Cindi Lou, on Mt Erebus last December (2011). I'm at around 10700 ft, but the pressure altitude is around 0.65 bar -- the equivalent of closer to 13,000 ft at the equator. This was on a nice, warm (-15C) nearly windless day. I was pleasantly surprised how well the quad performed in stabilize and simple mode (no sonar, and loiter was unreliable).
I got my APM / Oilpan when they first came out, and that's what's flying in this video. Unfortunately I upgraded to 2.0.49 before going to Antarctica and didn't realize that flight log collection was disabled since I had the atmega 1280 version, so no logs.
This is vaguely related to my PhD research in volcanology. My job on Erebus is to map and study some ice caves that form when volcanic gases melt tunnels into the bottom of the snowpack. The BBC came out and filmed us at work and you can see it in the "Life in the freezer" episode of the BBC / Discovery series Frozen Planet if you're interested.
I'm going back to Erebus for the fourth time this November, and this time I intend to do some serious science using multirotors with APM2 onboard. Some of the caves cannot be entered due to dangerous gasses and / or unique microbiology. I'm planning to fly an autonomous quadcopter down into them, doing SLAM or at least wall avoidance, and measuring gas concentrations. Eventually I'd also like to fly a multirotor down into Erebus' crater to sample gas from the bubbling lava lake. NASA's New Mexico Space Grant Consortium has kindly awarded me a graduate research fellowship for this work, and I am considering an application to NASA NIACS.
Please let me know if you have any advice or are interested in collaborating. Major issues I need to overcome:
- Radio transmission through the snowpack: can it be done?
- Cave wall avoidance. I will probably do this with IR distance sensors, although the MIT RANGE quadcopter-mounted lidar or Kinect approach would be better if I can pull it off. RANGE said they are interested in collaborating wants me to email them again in June...
- Propeller / motor design for high altitudes. Should I be changing the blade pitch for lower pressure?
- Keeping a quadrotor running in a cold environment with acidic and corrosive condensing vapor.
Oh, by the way, I'm now flying a 3DR frame with an APM2, and an Xaircraft X650V8 also with an APM2. Thanks to all the developers, the technology has improving by leaps and bounds! As has my own flying ability...
One more question. Does anyone know of other people flying multirotors in Antarctica? Am I the first on the continent? I hope not, because it would be great to start the McMurdo RC flying club!
Cheers,
Aaron
Barometer Issues!?
Ok, here is another problem I've spotted in the mind field of hardware issues and for people who continually bang their heads trying to fix them through PID tuning. .
If you have a housing that is covering over all of your electronics such as a plastic container,.. then when you descend or ascend quickly the pressure inside the container changes and gives your barometer an false reading.
For example if you descend quickly the pressure increases inside the container making the barometer think that you are descending faster than you actually are. So the APM will try to compensate this out and try to increase the throttle and this probably cause a bouncing behavior some people are finding happens .
Some may argue that the barometer cant be this sensitive, but I beg to differ because the pressure variation it can sense for the pressure variances in altitude that it works off is very fine. The pressure change inside the container even for horizontal flight will be enough to for it to sense the changes of pressure in the container.
This also includes pressure zones around the incoming and out going air stream around the props if they are to close to the container or even if you have an open center frame the pressure zone around the props can possibly still affect the barometer
I'm considering some fixes for this such as a tube that has a H tube branch at its end and that sits above or below the center board.
I would be interested to know what others view and ideas are on this. .
http://diydrones.com/forum/topics/barometer-issues-and-pid-tuning
Im in two minds about mounting on rubber rings and particularly if it allows the board to wobble even ever so slightly . Any movement at all of the board relative to the crafts frame I suspect will cause oscillation and probably jitters during quick maneuvers. . I'm more in favor of adding vibration dampening pads to the arms and frame rather than suspending the AMP board. Take for example if the motors are causing a horizontal circular vibration from the motors and this circular rotation is say clockwise, then this is without doubt is going to affect the yaw if the board is moving differently to the frames yaw. So if anything I feel the oring idea is in some cases more counter productive than what its trying to achieve. The APM board in my view must be rock solid fixed to the frame to be able to quickly and accurately read what the aircraft is doing. Any compromise even if only very minute will without doubt affect the stability of the aircraft. We have to realise that if the board can be so easily affected from such small amounts of vibration and it is so sensitive, then the idea of APM board suspension mounts possibly is not a good idea
I feel some of the people having trouble with the PID tuning could be because their boards are moving and are not firmly fixed the the frames.
One method I have used to dampen vibration is to wrap a metal rod in some soft rubber and then slid this into the arm tube just under the motor. The rod floating in the rubber wrap takes quite a bit of the high frequency vibration out of the arms.
Just my thought on this.
Resistance is futile...
John Villasenor, senior fellow at the Center for Technology Innovation, Brookings Institution, was on NPR's Talk of the nation today talking about civilian drones. 3D Robotics gets a mention.
As usual, there is some confusion over terms and definitions:
VILLASENOR: Well, first of all, I think it's very important to emphasize that model aircrafts are not drones. Model aircraft are flown within the line of sight of, and under the control of a pilot at all times. And so whatever definition someone might adopt of drones, that definition should not include model aircraft.
I think the other thing that's important to emphasize is that many of our military pilots, unmanned aircraft pilots, they justifiably aren't particularly thrilled with the term drone because it implies - it can imply sort of a hands-off approach, where in fact these folks are extremely skilled aviators who are no less skilled just because they happen not to be in the cockpit. And so they often prefer designations such as UAV, which is unmanned aerial vehicle, or RPA, which is remotely piloted aircraft.
CONAN: But for good or ill, the word drone has become associated with these, and that's the word that's in common usage. So we're going to continue with it.
You can listen to it or read a transcript here.
Hizook (Travis Deyle and Robert Powers) have found some fascinating research:
We were scanning through the upcoming ICRA2012 program and noticed an interesting paper titled, "Resonant Wireless Power Transfer to Ground Sensors from a UAV." This certainly piqued our interest -- especially for Travis, who happens to work with wirelessly-powered sensors at his day job. Come to find out... the article is by Dr. Carrick Detweiler, PI of the NIMBUS Lab at the University of Nebraska-Lincoln (our undergrad alma mater!). Furthermore, he just provided a preprint of the paper (PDF) and a video on his website. Score! Their quadrotor delivers power via magnetic resonance (ie. WiTricity-style) to a load on the ground. This same type of technology is being actively researched for lots of applications, including: consumer electronics, transportation (eg. electric vehicle recharging), and remote sensing (this application). Adding it to a UAV adds a bit of flexibility to the system. Anyway, be sure to check out the video below... and we'll also give a brief overview of a few different wireless power + robotics projects over the ages.
The paper is titled, "Resonant Wireless Power Transfer to Ground Sensors from a UAV" (PDF) by Brent Griffin and Dr. Carrick Detweiler.
Magnetic resonance can be a good method for wireless power transfer at medium distances (ie. a meter or so). Owing to the resonant fields, it is more efficient that inductive coupling, which would require the UAV to be in close proximity to the load (a few centimeters) to get good mutual coupling. Furthermore, the magnetic fields are less susceptible to occlusions or material composition compared to microwave (electromagnetic) or laser-based wireless power transfer.
However, being at least partially familiar with the underlying technology, we know that alignment and (dynamic) frequency tuning are absolutely critical for efficient power transfer using magnetic resonance. Presumably, the quadrotor itself could supply the necessary flexibility in the system to help align the coils -- heck, we've all seen quadrotors perform impressive feats of acrobatics. So kudos to Carrick and Brent for their insights!
Lots more history on this kind of power transfer at the rest of the post here.
Last week, DARPA announced that the recommended simulation environment for its Robotics Challenge for Disaster Environments would be Gazebo, from the the Open Source Robotics Foundation:
The Open Source Robotics Foundation will develop an open-source robot simulation software system for use by the DARPA Robotics Challenge program. The effort will develop validated models of robots (kinematics, dynamics, and sensors) and field environments (three-dimensional surfaces, solids, and material properties). The effort will develop physics-based models of inertia, actuation, contact, and environment dynamics to simulate the robot's motion. The effort will make the simulation software available on an open-source basis, and will host the simulation so that participants in the DARPA Robotics Challenge program can access it freely.
First, yay! The government is recognizing the power of open source robotics! But what actually is the Open Source Robotics Foundation? It turns out that it's a spin off from Willow Garage's Robot Operating System (ROS) project.
Evan Ackerman from IEEE Spectrum explains:
A few years ago, Willow Garage integrated ROS and the PR2 into Gazebo, a multi-robot simulator project started at the University of Southern California by Andrew Howard and Nate Koenig. Willow Garage now provides financial support for the development of Gazebo. However, DARPA isn't awarding the simulator contract to Willow Garage itself, but instead to the Open Source Robotics Foundation, which nobody has heard of until just now.
From the sound of things, Willow Garage has decided that ROS is now mature enough to go off and fend for itself, and the Open Source Robotics Foundation is the shiny new embodiment of that confidence. And it really is brand new: the OSR Foundation website is, well, minimalist, to say the least. All we really know is that it's a Menlo Park, Calif. nonprofit that's managed by "members of the global robotics community who have demonstrated a commitment to open-source robotics, are visible to the community, and have relevant experience in the field," but who are currently still anonymous.
It's certainly true that Gazebo and ROS have impressive pedigrees, and according to DARPA's announcement, it chose Gazebo on the basis of "an informal market survey" through which the OSR Foundation was "deemed to be the sole viable supplier for providing the necessary open-source simulation software within the specified timeframe." It's interesting to note that as far as we know the OSR Foundation kind of didn't even exist until very recently, so DARPA is putting a lot of faith (and presumably funding) into a foundation without a distinct track record. We'll just have to assume (for now) that both DARPA and the OSR Foundation know what they're doing, and that they've got things under control and ready to go.
The other little niggling question here is whether this means that the OSR Foundation is going to devote the majority of its resources into optimizing Gazebo for the Challenge itself, as opposed to taking an approach that might be better (or at least more productive) for the robotics community and Gazebo users as a whole. I guess this probably depends on how much funding it gets from DARPA as opposed to other sources, but the risk is that Gazebo becomes a project for DARPA rather than a project that DARPA simply benefits from.
Skywalker 1880mm wingspan.
1880 mm FPV/UAS platform - WoodWing + EPO fuselage Skywalker.
Wood + Covering film main wing.
Fuselage and tail wing are EPO material.
Made for long range fpv/uas flying with high payload
Features :
Wingspan : 1880 mm Wood and Covering film main wing (2 flaps)
Lenght : 1150 mm (Fuselage and tail wing are EPO)
Empty airplane weight : 920 grams
WOOD CAMERA MOUNT INCLUDING IN THE PRICE
(free mount)
Requires:
2815-2835 800-1000kv brushless motor
30-40A ESC
3S 2200-5000mah LiPo
9040-9060 propeller
Price: 129 US$
Back in 2004, in the day before ubiquitous smart phones and data networks, Microsoft and some hardware partners such as Fossil and Swatch introduced SPOT (Smart Personal Objects Technology) watches, which used a satellite constallation to send 41-character messages to low-power devices anywhere in the world. The idea is that you would register with a service and you could get weather or sports data on your watch anywhere. They flopped, but the satellite constellation is still operating.
Now you can buy Spot radio hardware and a service that let's you SEND messages, too. So who needs an expensive satellite data service for long-range UAVs? Just lower your data rate and send just what you need as SPOT messages. It's $150 for the hardware, $100 a year for the service, $20 for the breakout board, $0.10 per message.
From Hackaday:
[Nate] over at Sparkfun put up a great tutorial for using the SPOT personal satellite communicator with just about any microcontroller. These personal satellite transmitters were originally intended to pair with the bluetooth module of a smart phone, allowing you to send a short 41-character message from anywhere in the world. Now, you can use these neat little boxes for getting data from remote sensors, or even telemetry from a weather balloon.
[Nate]‘s teardown expands on [natrium4] and [Travis Goodspeed]‘s efforts in reverse-engineering the SPOT satellite communicator. The hardware works with theGlobalstar satellite constellation only for uplink use. That is, you can’t send stuff to a remote device with a SPOT. After poking around the circuitry of the original, first-edition SPOT, [Nate] pulled out a much cheaper SPOT Connect from his bag of tricks. Like the previous hacks, tying into the bluetooth TX/RX lines granted [Nate] full access to broadcast anything he wants to a satellite sitting in orbit.
We’ve seen the SPOT satellite messaging service put to use in a high altitude balloon over the wilds of northern California where it proved to be a very reliable, if expensive, means of data collection. Sometimes, though, XBees and terrestrial radio just aren’t good enough, and you need a satellite solution.
The SPOT satellite service has an enormous coverage area, seen in the title pic of this post. The only major landmasses not covered are eastern and southern Africa, India, and the southern tip of South America. If anyone out there wants to build a transatlantic UAV, SPOT, and [Nate]‘s awesome tutorial, are the tools to use.
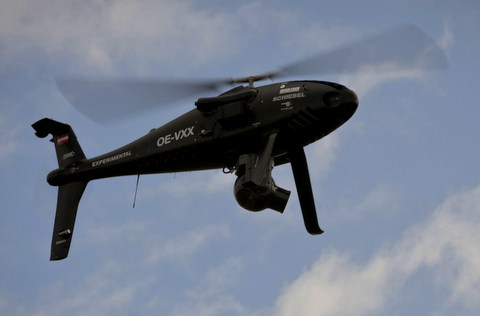
Schiebel kindly sent me this morning a link with this video on it. Its pretty amazing and certainly to my mind points at how Europe really is pulling ahead of the USA. (starting a flame war there) Imagine how difficult it would have been test flying the system in the USA.
I think there will be a rush towards large helicopter based systems now. This will become the minimum expected standard from movie UAS. It will cost a bit that's for sure.
It excited me enough yesterday to add it to our UAS Got Talent tab, if you have an entry then please suggest away.
Its on show in Las Vegas this week.
Article here. Excerpts:
It’s a land rush in the air.
Jordi Munoz Bardales is one of a handful of San Diego entrepreneurs staking out new territory in the rapidly commercializing field of unmanned aviation.
Munoz, 25, is CEO of 3D Robotics Inc. Working out of a Kearny Mesa business park, his enterprise produces and sells components for model-size unmanned aircraft, providing them to hobbyists, college engineering programs and other entrepreneurs.
Its specialty is autopilot electronics.
Early in the venture, Munoz said, he saw that he might be onto something when he assembled 40 autopilots and sold them in a single day. “I realized I had a business here,” Munoz said.
Munoz said his enterprise is a success because it uses open-source software. 3D Robotics operates a website called DIY Drones, which lets tinkerers compare notes.
He said he also tries to make everything he sells as inexpensive as possible.
Cruising Along
It’s a long way from 2007 and 2008, when Munoz disassembled components from a Nintendo Wii and integrated them into a model helicopter, making a drone of his own. He posted updates to the project on the Internet, including the code he wrote. The work attracted notice from Chris Anderson, editor in chief of New York-based Wired Magazine and author of “The Long Tail: Why the Future of Business Is Selling Less of More.” Anderson sent him $100 and a note of encouragement. Today, Anderson and Munoz are 50 percent owners of 3D Robotics.
3D Robotics has left garage and bedroom quarters in favor of 10,000 square feet of industrial space. The firm has 20 employees in San Diego and six in Tijuana, and relies on 20 software developers worldwide. It has three jobs open.
Its building houses specialized machines that churn out ArduPilot autopilots, which fit on purple circuit boards the size of business cards. Munoz said he would like to buy a second pick-and-place machine to mount components to circuit boards, and locate it in Tijuana. Eventually, he said, he would like to put most of his production in Mexico, while keeping the engineering team in the United States.
A few corrections: Wired is based in San Francisco, not New York. 3D Robotics does not operate DIY Drones, I do (personally -- it's not a company). And 3D Robotics already has a second pick-and-place machine for the Tijuana production line.
(article via the 3D Robotics Twitter feed)
Interesting controller and hexa setup.
http://www.engadget.com/2012/04/16/dji-aircraft-live-video-feed-controller/
Extracts:
"Shenzhen-based DJI Innovations was on hand at NAB today to demonstrate its new hex-rotor aircraft, designed to provide photographers (and videographers) with a low-cost tool for capturing aerial images."
"The Spreading Wings S800 is available for pre-order now and is expected to ship next month for roughly $8,500. That clever live video controller will cost you another pretty penny, however, with an estimated $5,000 price tag and a TBD ship date"
