Hey everyone,I haven't been on the site in a while and I am amazed at what is/has come out of this community in the past 8 months.Anyway, I made a blimp last year for a class at RISD taught by Paul Badger. The blimp follows people. Its based around the arduino, a pyroelectric sensor, and an ultrasound sensor. The code is quite simple: it scans for heat (IR at ~ human frequency) and once it finds a maximum above threshold, it moves towards the location of heat and corrects for height.I started out with some mathematically complex programming but soon learned that very simple rules performed satisfactory. I don't plan on adding any more advanced controls or processes: its simple, stupid, and fun.A video of the blimp is here.also on the video is some other stuff I've done including a drawbot that draws in polar coordinates, and a bicycle powered record player (hah, not done).
Read more…
Posted by Robert Drone on April 11, 2009 at 7:18am
What does anyone think of this radio:http://www.nitroplanes.com/72waraco4chf.htmlWalkera Radio Control 4 Channel FM Transmitter Perfect for Helicopter and Airplane4 Channel R/C Set included, complete Left/ Right, Up/ Down Control ( RUDDER, AILERON, ELEVATOR AND THROTTLE. Suitable for Indoor / Outdoor / Backyard / Park ( 500 sqft area )Includes:One 4 Channel FM Transmitter w. Tx Battery holderOne ReceiverOne Crystal SetOne Receiver Battery Box w/ BEC connectorTwo 9 Gram ServosOne Switch HarnessOne Tx AntennaBattery HolderRequires: 8 AA batteriesRegular price: $99.95Sale price: $44.95It looks good to me and very affordable. What does every one else think?Link:http://www.nitroplanes.com/72waraco4chf.htmlRead more…
Posted by yuanzhenzong on April 11, 2009 at 12:59am
as an engineer worked for uav,I need variety of knowledge about the system.It includes composite material Aerodynamics,propultion,avinics,payload(op or ir sensor)and the communication.because the real enrienment of education in my country,I haven't get the valuable material about that,today find this page and find kinds of products and subsystems,thank you.
Read more…
Posted by Kyle Corbitt on April 10, 2009 at 7:30pm
Hey everyone, I would like to take this opportunity to post a screenshot of the groundstation I've just begun work on. I haven't gotten very far in the short time I've been working on it, but my goal is to release it around the same time as the upcoming ArduPilot Pro, which should have the ability to use a two-way digital radio for control. That gives me a good chunk of time for development and tuning.
I've put more time into playing around with different layouts than anything else so far, and I think I've settled on one that seems servicable. I would greatly appreciate it though if other community members (particularly those involved with ArduPilot Pro development) could let me know what you think of the direction I'm going... it would be much better to know sooner than later if I'm barking up the wrong tree!I should also mention that currently the "File" menu is set up as follows:"Load MissionSave Mission-------------Import KMLExport KML-------------Load PlaybackSave Playback-------------Exit"(there is nothing under "Settings" yet)Finally, for anyone interested in the code itself, I've been developing in Python using wxPython for the GUI elements.
Read more…
I've been having some problems intermittently with RF interference when flying my Nexstar EP. I always thought it was just some local interference which kicked on and off for whatever reason and that I needed to just do a range test before each flight.However, just today I decided to try a range test with & without Ardupilot installed. With Ardupilot I could only go about 200 feet away before i started getting pretty significant twitching of the servos. Without Ardupilot everything was still rock solid at 200+ feet. So it looks like the jumble of wires I had inside before won't work... are there any special precautions I can take besides just organizing wires and keeping Ardupilot as far from the receiver as possible? Is it important to keep Ardupilot away from the ESC as well? Does anyone have any home-made RF shield ideas?I also want to thank Chris & Jordi for making Ardupilot - not only a great autopilot but a really great place for beginners to start learning.
Read more…
Posted by Robert Drone on April 10, 2009 at 8:00am
Hi, I'm a bored teen living in south Georgia; so how's that different from any other teen? Well, I'm bored because what they teach us n school here is stuff I've known for a long time for the most part sooo I was looking around at airplanes online thinking about building a UAV and I came across this site after a while I got permission from my parents to use this site and here I am. I just posted some pictures of my custom airframe I am building and some electronics gear I could hack. I am a noob to real rc models (you know brushless motors and servos and stuff) the only real experience I have is the lego robotics system and messing with junked electonics and stuff. I was wondering if any one could answer the following questions:1. Has anyone launched an NXT or RCX using an all electric aircraft?2.Should I use the monster-truck rc unit to save money or buy a new one?(it is old so it is not proportional)3.Do you have to use a brushless and brand new battery?(could I use the one pictured)4.Could I build a magnetic sensor for the rcx or nxt?5. Does anyone have any comments questions or ideas for me?Here is a link to my pictures:
Posted by Brian Hudson on April 8, 2009 at 11:51pm
Tom and I have made a couple of decisions and are moving forward."I would not be just a nothin' my head all full of stuffin'...If I only had a brain."I purchased and have received a standard Arduino Duemilanove board. I strongly considered the ArduPilot, but I wanted to get up an running quickly and I didn't really want to spend the money for an FTDI Serial / USB cable. I've been doing some basic bootstrapping to get a few things up and running.- A simple echo terminal program as my first "hello world" type sketch- A "random" number generator set up to send data to a terminal program on the PC- A C# program to plot the data received from the number generator. Which brings me to my first request for advice / feedback in this post:Does anyone have recommendations for a set of plotting / graphing tools? Tom has a student copy of MatLab / Simulink, so I was thinking about seeing what could be done there, but I want something we can both use without me having to try to find time on his computer. I've considered Processing, but I don't really see a way to interface it easily with other software packages, and while I can't sum up succinctly why, it just doesn't seem like a language I want to invest much in. For now I've just used a free-ware copy of something called PlotLab - http://www.mitov.com/html/plotlab.html. The docs aren't very good, and it doesn't seem all that well suited to my current task, but it lets me get something on the screen quickly in a nice friendly C# .Net rapid development setup. It has some cool zoom features as well.The last thing I've written is a little quick and dirty benchmark sketch for floating point operations. I was just trying to get a ballpark here, but I can't recall where I placed the data. Either way, this wasn't very scientific. If folks have data about the efficiency of the floating point emulation sitting around somewhere, I've done some searching and haven't found much. Otherwise, this could be the topic of its own short post, although I'm by no means an expert in this area.Moving along...Input! More Input!Just today I placed the order for an Atomic IMU 6DOF sensor assembly. This was a relatively big purchase for us, but the combination of sensors set up according to manufacturer recommendation, a great little form factor package, and a programmable AVR core seemed to really fit our needs.Under ConstructionThis brings me to my next planned task - I will be writing a simple software-serial pass-thru sketch so that I can hook up the Atomic IMU 6DOF to a terminal program on the PC, play with it, and chart the output at least as a simple benchmarking / verification setup (remember I was too cheap to buy the FTDI serial / usb cable).Following that, I think my next (larger) task will be designing a serial communication protocol between the main Arduino board and the Arduino on the 6DOF. I don't want to reinvent the wheel here, so once I spec what my requirements are, I'll be hunting around for something I can base my protocol on. Here are some characteristics that come to mind, but I'm definitely not saying these are exhaustive or all necessary - obviously some are mutually exclusive, and I have some decisions to make between them:1) High speed - I want to be able to pull data at as high a frequency as our processing / navigation model needs.2) Low latency - pull model - the main controller requests data, and it gets it fast. If we're sampling very frequently, I don't want latency to indroduce complexity or inconsistency into our control / feedback model. I haven't yet quantified this at all.3) Low encoding overhead cost (the pull model kind of pushes against this goal, as there's more back and forth than perhaps necessary)4) Simple and consistent frequency samples - push model - the IMU pushes data at a consistent interval. I like the simplicity of this, but I don't want to burden the main controller with servicing and throwing away serial data that it's not going to use, wasting precious cycles.5) Flexible and extensible - Right now, I'll be using this to pull raw data straight from the sensors, either with a push or a pull model. If I go with the pull model, in order to achieve low latency I'll want some sort of request batching and transmission mechanism, which I would want to lend itself well to future expansion of the data supported. This may all be overkill, and I might just end up defining a set of metrics on both sides that grows as my needs grow.Once I've got an idea of my data transfer system, another need I'll have is the ability to program the AVR on the 6DOF. I've got a couple important issues here, in priority order:1) Fail-safe, Fail-safe, Fail-safe. I'm a bit nervous about programming an SMD chip on a $125 part. I've never programmed an Atmel before (ok fine, I've programmed my Arduino several times now, but that hardly counts). My previous experience was with the PIC microcontrollers that took minutes to program and 20 minutes in a UV light box to "erase," so my guess is that ICSP is going to be a welcome change - I sure hope so, as I have no desire to screw this baby up and get my first shot at SMD soldering with my nearly non-existent soldering tools, and very limited soldering skills. Words of encouragement and "you can't break it by flashing it, I swear!" are definitely appreciated here.2) I'm cheap :) I'm not about to drop $20+ for an AVR programmer when I've got a 16Mhz amazingly programmable physical computing platform right in front of me! I've seen far more Arduino AVR programmer set ups than I expected to when I came up with this idea and did a search, so I'd love feedback about experience folks have here if any. What sketch program did you use? What software did you use with it? My Duemilanove has the ATMega328, so I'll need something current, I think.I'm hoping Tom will be writing a post similar to this about our progress on our choice of plane. Our ever current theme of getting the most for our money has led to a fairly involved spreadsheet with our candidate airframes, their characteristics, and the cost of all the equipment to get them up and running:
Thanks to Chris for the tip on fixing up this image so you can click it for a larger version. I have links to all the parts in the cells of the spreadsheet, but obviously they're too long to make fully visible, so folks looking at the image don't know what the dollar amounts translate into in terms of parts, but like I said - hopefully Tom will post on this later!
Read more…3D Robotics
Jordi's been doing lots of test flights of ArduPilot 2.1 and 2.2 in preparation for the Sparkfun autonomous vehicle contest. These new versions of ArduPilot include throttle control to help it handle wind better. Today seemed like a good day to test that. Jordi describes what happened:
"Today i went to test my ArduPilor and winds were about 15mph with gusts of 25mph, EasyStar was having a difficult flight due to the high winds, and suddenly the EasyStar climb for about 200 meters and start drifting away from launch pad (maybe at that altitude the currents were a lot more stronger)....
It was cloudy and I lost it in the sky and i was looking on the ground station how ArduPilot was trying to fighting against the wind, but the motor was almost off because the autopilot was trying to go down, but unable to travel forward, was going left and right, against the wind....
I tried to spot it on the sky over and over again to retake control, also looking into the ground station to know the direction but nothing! at that moment it was around 400 meters high!
In a matter of seconds the last position i got was 2500 meters away!! at 50 meters altitude, then i lost signal!! So i quickly took the coordinates and i made the calculation of the crash site (you know, with the last altitude and the heading i can estimate more or less the crash area, the battery was drained so no thrust at all). I've put the coordinates in motionX (iPhone app) and i begun the searching deep into the mountains!
The easystar was suposed to be lost, forever!!! And i was impressed with the range of the modem, normally i lost signal at 500 meters!
Then when i spotted i could't believe it!!
And OMG i still don't know how i find it, that was horrible, hills and canyon... That was for sure luck...
When you use FMA Co-Pilot CPD4 on a plane with 2 servos on wing (one for airelon) usually you must connect an Y cable to use correctly CPD4 stabilization.With this configuration you cant use the flaperon mix (it move the 2 wing servo to the same direction to simulate flap).My idea is to use a V-Tail hardware mixer (it cost under 10$) to use flaperons.This is the connection schema:
The V-Tail mixer output will be connected to servos, the ELEVATOR input is our flap, i suggest to connect to gear channel, the RUDDER input is the airelon input, you must connect to airelon output of CPD4.Check on the trasmitter that on gear switch off all 2 airelon are on neutral posizition, then set the position on the gear switch on.I hope that my explanation is clear.
Read more…
From the description: "MADS (Miniature Aircraft Deployment System) is an Aerospace Engineering senior design project at the University of Colorado at Boulder. The mission of MADS is to deploy flight-capable, autonomous, miniature aircraft (the SuperFly) from a larger unmanned aerial vehicle (the Sig Rascal 110). Visit http://recuv.colorado.edu/MADS/ for more information!"
(Actually the aircraft that are launched aren't really UAVs, since they're not guided or even controlled. And it's not clear why this team took eight months to figure out how to drop something from a plane. But it's a cool concept at least...)Read more…3D Robotics
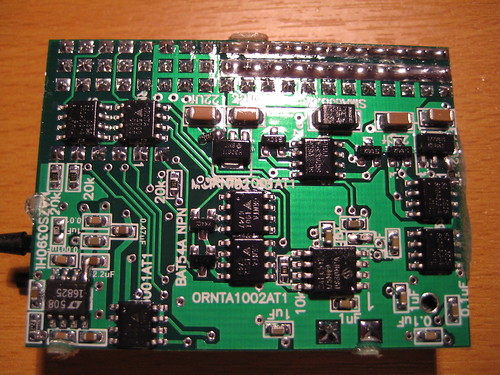
After stripping down AttoPilot, I thought it would be fun to compare it with the last-gen consumer autopilot, the PicoPilot NAT. There's quite a difference!
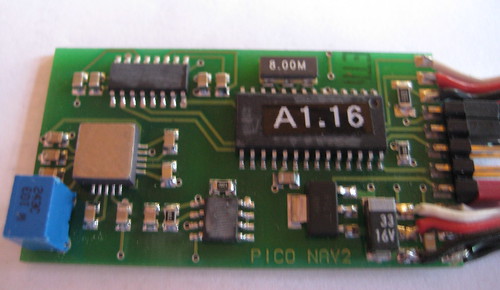
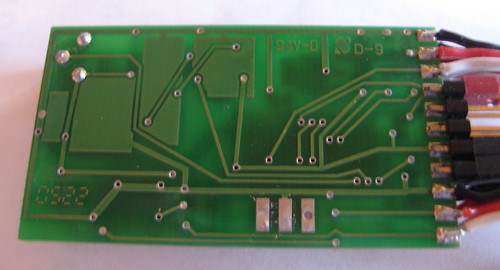
The most obvious contrast is how simple and basic the PicoPilot board is. It doesn't have any of the dataline protection and noise reduction features of AttoPilot, and the PCB layout itself is hobby-grade (no effort to extend the ground planes to fill all available space, which is the trick good designers use to cut down on RF noise). No wonder it tends to need servo signal amplifiers. There's also no provision for expansion (spare pins broken out, etc).
U-Nav ground off all the identifying numbers on the microprocessor and support ICs, but I've identified what I could in these photographs. (click on the pictures of the board tops to go to Flickr, where you can mouse over and see what parts I could identify)
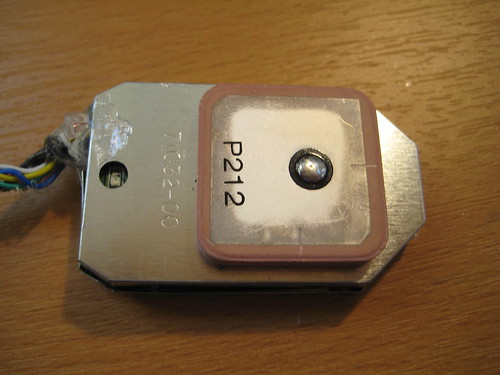
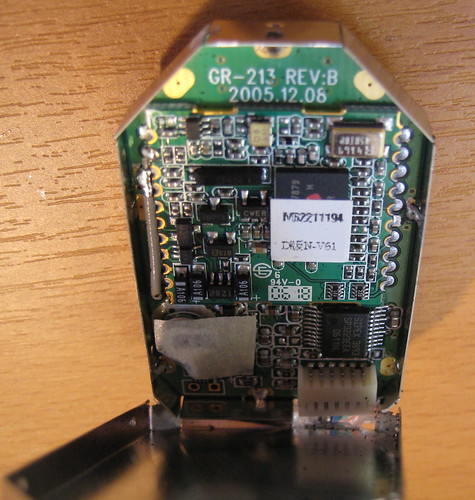
There are two boards + a GPS module. One board is the wing-leveler and GPS navigation (PicoPilot NA); the other is the altitude hold board with a pressure sensor (ALT3E). The GPS module is a stand-alone component (A Holux GR-213 module with a SiRFIII chipset).
PicoPilot NA top:
PicoPilot NA bottom:
ALT3E top:
ALT3E bottom:
GPS module outside (this is just a standard Holux GPS module):
The Holux GPS module inside:
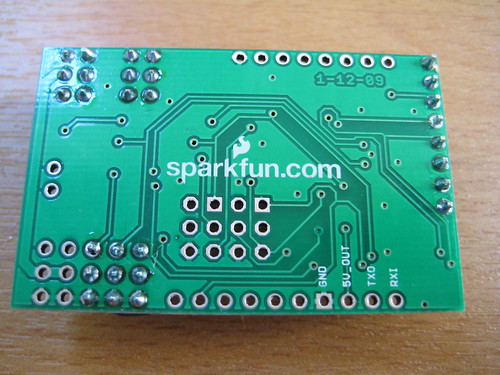
To give you an idea how basic these PCBs are, here's the PicoPilot bottom and the AttoPilot and ArduPilot bottoms side by side, ranked in increasing sophistication. Again, note the careful effort to maximize the ground planes (big light green areas) for noise reduction in ArduPilot and AttoPilot, and the minimal use in PicoPilot.
PicoPilot PCB bottom:
ArduPilot PCB bottom:
AttoPilot PCB bottom:
Read more…3D Robotics
AttoPilot comes with two desktop programs, a full-featured ground station and a basic KML-to-TXT converter.
Before I get into the specifics, I'll give some quick impressions.
The Ground Station is intended to be used while the aircraft is in the air or to replay a saved flight file. It can display real-time telemetry data if you have a radio modem hooked up to AttoPilot, and can send commands back to AttoPilot if that radio modem is 2-way. It's a nicely done professional piece of software and seems to cover all the bases. Two thumbs up.
The KML-to-TXT converter is a bit of a kludge, compensating for the fact that AttoPilot doesn't have a native way to input waypoints. Instead, it recommends using Google Earth Plus to point-and-click waypoints, exporting them as a KML file that the supplied utility can covert into a form that AttoPilot can use. Unfortunately, this process, which is pretty cumbersome at the best of times, is now also impossible, since Google has stopped selling Google Earth Plus. I've asked Dean for advice on what people should do about that, but haven't heard back yet.
[UPDATE: Dean says that the free Google Earth 5 now includes the KML export feature. So ignore the Google Earth Plus reference in AttoPilot instructions, which I assume will soon be updated]
There is also, to my mind, a missing piece of software, which is a setup utility. In the absence of that, the main way you adjust AttoPilot for your plane is by editing a text file that is stored on the on-board SD card. That file is pretty scary looking (and we should know, since we currently make people do something similar with ArduPilot, although we'll be releasing a setup utility that avoids that soon), and consists of hundreds of lines that look like this:
I assume that in later versions of AttoPilot, there will be some program that helps you enter those values. In the meantime, however, it's a relatively daunting process of trial-and-error, reading the manual and tweaking a supplied generic file. I haven't flown a plane with it yet, so I don't know how well the generic file will work for my target platform, an EasyGliderPro, but I'll update this as I learn more.
For the rest of the review,. I'm going to focus mostly on the Ground Station software, which is the most polished part of the package. Here's the main screen, showing the playback of a flight:
The menu items give you the following dialog boxes.
Settings:
When you click "Read from AttoPilot", the following boxes are added to the interface:
If you have a 2-way radio modem, those boxes allow you to send in-flight commands to AttoPilot. These are the available commands:
If you click on "Show PID", you get a new window that creates graphs of key values over time:
The "KML Utilities" launch the aforementioned KML-to-TXT file converter. You can convert both ways:
All in all, an impressive piece of software. My hope is that in the next version of AttoPilot, the waypoint entry and setup process will display an equal level of polish.
Read more…3D Robotics
If you follow the Ardunio world, you will have seen that the standard platform is now based on the Atmega328 chip, not the Atmega168 chip that we were all using last year. The main difference between the 328 and the 168 is that the 328 has twice as much flash and EEPROM memory.
Atmel was only able to provide through-hole versions of the 328 until this month, so the only Arduino boards at the moment that use the 328 are the big development boards with DIP chips, such as the Duemilanove. But now the surface-mount version of the 328 is starting to trickle out, and it's time for the Ardunio boards to make the move to 328, too, to get access to that additional memory, which will allow us to do a lot more with the code.
You'll notice that ArduPilot is now out of stock at SparkFun again. That means two things. First, we've sold nearly 500 ArduPilots! Second, we let it go out of stock so as to not make any more Atmega168 boards, assuming that it's better to not sell any ArduPilots for the next two weeks than to make another batch of boards that will be immediately outmoded.
[UPDATE: We're now back in stock and all board will use the 328 chip from now on.]
The latest info we have from Sparkfun is that the 328 chips will be coming in this week, and we should be among the first boards to get them. We'll need to test one board, and then we can start a full production run of 500 328-based ArduPilots. If you backorder the board, we guarantee that it will be filled with the new 328 version and you'll be the first to get them.
So what does that mean for current ArduPilot owners? As mentioned in the ArduPilot roadmap, version 2.2 will require the new boards with the 328 chip. But all versions before that will continue to be supported and will work fine with the current board.
So if you're happy with anything from ArduPilot 1.0 to the forthcoming ArduPilot 2.1, you're fine with the current board. But if you want the features in ArduPilot 2.2 and above, you'll want to upgrade to the new board. The price will remain the same ($24.95), so this won't cost you a lot. Hardware upgrades don't come much cheaper than that!
Read more…
Build and fly your very own model airplane design. Using clear explanations, you will learn important design trade-offs and how to choose among them. The latest research and techniques are discussed using easy to understand language.You will discover:* The special challenges faced by the smaller models and how to overcome them.* How to choose the right material for each part of the airplane.* Easy rules for selecting the right power system, gas or electric.* When it makes sense to use one of the innovative KFm airfoils.* Pros and cons of canard and multi-wing configurations.* A step-by-step design process that includes goal setting and flight testing.* In-depth discussions of important topics like airfoils and wing design.* The sources of air drag and how to minimize their impact.Not just for beginners! Exhaustively researched, there is something for everyone among the wealth of information it contains.Not just for electric models! The power systems chapter covers gas engines and electric motors. Most of the book applies equally well to gliders.A perfect complement to RCadvisor's online model airplane calculator, this book stands completely on its own. All of the formulas included can be easily used with a hand-held calculator.RCadvisor's easy to use calculator is the leading online tool for model airplane building and design. Numerous ToolTips, interactive tutorials, and real-time graphs make understanding easy.Carlos Reyes founded www.rcadvisor.com in 2007. He's had a life-long love affair with aviation, building and flying model airplanes since childhood. He holds a Private Pilot-Glider license and is the Vice President of his local model airplane club.
Read more…Moderator
Before commiting expensive gear to an anything and in the interests of I wonder.I have been flying this airframe quite hard.Yesterday I load tested it using five of these at 58g each the multipack 5 came to 290gWithout load I have achived flights in the order of one hour obviously that will change.The aircraft has a 40 inch wingspan and easily fits on the back seat of my car. A simple solution for when we go out and get this sort of shotWorking towards an Attopilot being fitted for vertical stitch shots of archaeological stuff.On the drawing board a more efficient wing and larger, probably just shy of 2m easily able to lift 500g for one hour.A platform nose for FPV/Stills cameras and plenty of internal space for vertical/horizontally mounted cameras and gear.Flat wing this time with outboard ailerons. The airframe being roughly double this ones size. Also thinking of having a small or large wing for different tasks or wind speeds.Hopefully some pictures of a rough setup within the month.This bigger airframe will be used for some animal research tasks in Kenya, Tanzania and South Africa. Mostly lifting repeaters for animal tracking collars.For test Airframe 1, I have set up a TwitPerhaps the first UAV airframe with its own Twitter feed??I am hoping to fly 100 hours in the next month or two, so far I am ahead of schedule but weather is coming next week so I'm sure that will get in the way.
Read more…3D Robotics
As you'll see, we're releasing versions of ArduPilot at quite a clip. The difference between them can be a bit confusing, so here's a roadmap:
1.0: Just navigation and altitude hold (released 1/09)
2.0: Adds XY-sensor stabalization, EM406 only (released 3/09)
2.0.1: Adds Z sensor, ground station support (released 4/09)
2.1: Supports XY sensor in diagonal position, desktop setup utility (does not require Arduino IDE), throttle (if airspeed sensor/shield is connected). Due week of April 20th
2.2: Requires ArduPilot 328 board (current board upgraded to the Atmega328 chip; stay tuned for details). Supports any GPS, fully configurable for different airframes, new navigation modes. Due early May
Shields: We will be releasing expansion boards (called "shields" in the Arduino world) that plug into the top of ArduPilot and add additional features and connectors. This first one just adds a differential pressure (airspeed) sensor, 3.3v power regulator, lots of handy ways to add other sensors and GPS modules, and a circuit that allows you to upload code without unplugging the GPS. The first board will be available in May.
Main changes:-Solved compatibility issue with Arduino IDE 14 and 15, (thanks very much Arduino Mega).-Z Sensor support (extremely recommended, otherwise you will fly strange).-An small Ground Station based in Labview to play with ;-)...And can be donwloaded from here.The problem with the Ground Station is that i can't compile it, but you can run it if you have Labview installed. Later i will release the EXE.It includes a better virtual horizon and displays Speed, Altitude, Climb rate, Heading, Bearing and show the aircraft position in real time using Google Earth.What you need:-Any radio modem (XBEE) running at 57600bps.-Labview 8.6 installed.-Run the file "groundtest.vi".-Select the port number, then click open and enjoy!(You can try it with the FTDI cable if you don't have radio modem).Note: This ground station is same I'm using right now to debug the new ArduPilot firmware 2.1.Ground Station download click here.[UPDATE: The Ground Station for Labview 8.5 please Click here]Be ready for the next release of ArduPilot firmware, the version 2.1, that will include:-Diagonal X Sensors.-Throttle Control-AirSpeed Sensor Support[Warning: You need Arduino 0015 or higher in order to use this firmware]
Read more…
 PicoPilot NA bottom:
 ALT3E top:
 ALT3E bottom:
 GPS module outside (this is just a standard Holux GPS module):
 The Holux GPS module inside:
 To give you an idea how basic these PCBs are, here's the PicoPilot bottom and the AttoPilot and ArduPilot bottoms side by side, ranked in increasing sophistication. Again, note the careful effort to maximize the ground planes (big light green areas) for noise reduction in ArduPilot and AttoPilot, and the minimal use in PicoPilot.
PicoPilot PCB bottom:
 AttoPilot PCB bottom: