All Posts (11086)

Sort by

Students build a 3D printed plane

screenshot022.jpg?w=580&h=325From Hackaday: 

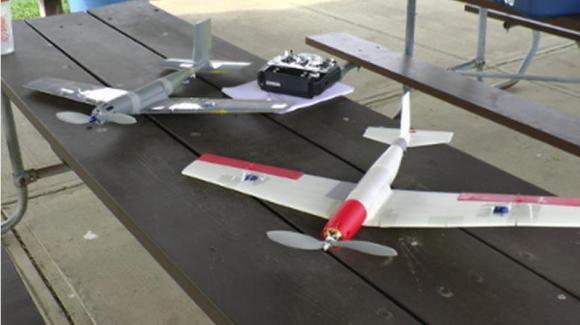
A student team has successfully designed, built, and flown a 3D printed RC plane using only $16 of plastic with a consumer-grade 3D printer (Makerbot), plus the necessary electronics and motor.

The folks over at the Wright Brothers Institute (WBI) have a great program called the AFRL Discovery Lab which brings teams of students, businesses, researchers, and government together to work on a specific challenge or opportunity.


More here: http://hackaday.com/2013/09/13/students-build-a-3d-printed-plane/

Read more…
3D Robotics

Drone-led campus tours!

From IEEE Spectrum:

Skycall is a project from MIT's Senseable City Lab that explores "novel, positive uses of UAV technology in the urban context." It's also a tool to help clueless freshmen find their way around the MIT campus.

The quadcopter itself utilities onboard autopilot and GPS navigation systems with sonar sensors and WiFi connectivity (via a ground station), enabling it to fly autonomously and communicate with the user via the SkyCall app. The UAV also integrates an onboard camera as both an information gathering system (relaying images to a ‘base’ location upon encountering the user), as well as a manually-controlled camera, accessible to the visitor-come-tourist again via the SkyCall app.

Like most conceptual videos, reality is rather far from what's portrayed here, most notably when it comes to the autonomous indoor navigation. But, it might be feasible to have this thing leading students around campus outdoors, as long as they're willing to move at a speed that's compatible with the robot's battery life, and also willing to call campus police when a hapless Frisbee player gets accidentally decapitated.

Also, that is an alarmingly sultry voice for a quadcopter.

Read more…

Thermalling method for Model Glider Autopilots

Hi,

Finally, an update about my project:

I have converted the telemetry log into subtitles, so you can see what's going on. This video explains a "Thermalling method for Model Glider Autopilots" in more detail. Best viewed in HD)

To view the pictures in higher resolution, go to:
http://diydrones.com/photo/photo/listForContributor?screenName=2vx1pcwjwgjgn


My Project page:
   http://diydrones.com/forum/topics/atv-autonomous-thermalling?xg_source=activity

Read more…

X8 3D scanning

3689548130?profile=original

Hi everyone, 

Is time to share something.

Here are some great files of an X8 3D laser scanned. This job was done completely for Free from some cool guys in Australia, for help us to participate to the Outback challenge. Unfortunately we did't make in time the prototype of an modified X8, so we will need to wait until 2014. But I the meantime I want to share with everyone this, so anyone can 

create or modify parts for the X8 having a good reference.  

The total folder size is about 133Mb with all the components of the X8. Here is the Dropbox link https://www.dropbox.com/sh/d0e9xr277754akb/_wb44sqFzp

Also Is worth to have a look at the website of the guys that made this possible, you may find interesting (I'm not affiliated in any way with this company). http://www.3dspatial.com.au   

NOTE:  If dropbox link is't working anymore, please check in the comments for an updated one 

3689548173?profile=original

Read more…

Meet Flip a REALLY Tough little Quadcopter

3689548076?profile=original

Hi All,

Some of you may remember a while back I put in some posts on F3330 and F450 DJI FlameWheel QuadCopters detailing construction and operation.

I really love those little FlameWheels for delivering many hours of fun and resisting my every effort to destroy them.

I thought I'd try and kick it up a notch this time.

Something even more indestructible and maybe even more fun.

The Flip frame kit is $89.00 from Hoverthings and it is billed as being nearly indestructible, and short of direct Nuclear blast effects, they are probably right.

In addition to the standard kit I added an extended tab pair of center frame pieces and some 7/8" extenders.

My intention is to mount the battery on the bottom a four in one 25 amp ESC in the middle and a PX4FMU/PX4IO controller, a receiver and FPV transmitter between the 2 no tab top frame center plates and a UBlox GPS on top.

I have the 4 in 1 ESC and 4 DJI Flamewheel motors on order.

The arms on these Flips are billed as being incredibly stiff and incredibly strong.

They appear to be made of CNC milled very high density 1/4" thick fiberglass and are stiffer than anything that is not carbon fiber and likely a lot better able to withstand punishment without failing.

3689548112?profile=original

The frame centers are also very strong and stiff fiberglass and it is likely all of it is G10.

This is a 380 size frame and will accommodate 10" propellers (Right between the Flamewheel F330 and F450.)

I will be using Gemfan 10" carbon filled propellers that are DJI motor hub compatible. I have had very good luck with these propellers, they are very tough, quite efficient and not as sharp as more expensive carbon fiber propellers.

3689548040?profile=original

I will add details of my build as the parts come in and as I can get it put together, the motors and 4 in 1 ESC are coming from China, so it may take a while, but I have been very happy with my Flamewheels and I expect this to be - Better.
Read more…

Smaller is sometimes better.

So I've built well over a dozen multicopters by now and surprisingly this little 30cm job has turned out to be the most fun out of all of them.  I always heard that 40-50cm sized frames were the magic number, but this lightweight 3cell setup has more pep and handling than anything else I've flown so far.  details here

Read more…
3D Robotics

Stress-testing Y6 fully autonomous missions

Ahead of the Iris launch, we've been testing more and more tough missions in fully autonomous modes. Next to our Berkeley offices we've got a small courtyard with high walls that is a combination of dodgy GPS and gusting wind. So naturally enough the Flight Ops team decided to run full autonomous missions with a 3DR Y6 all afternoon to stress test the tuning. I walked out during one of these and caught it on video, above.

This is a fully autonomous takeoff, three waypoints and autolanding. It did this all afternoon and always landed around one meter from launch point. 

Read more…

$15 external compass for APM 2.5

3689548054?profile=original
As a followup to a conversation in this thread: 
http://www.diydrones.com/profiles/blogs/3dr-gps-mag-back-in-stock

I have successfully used this $15 sparkfun HMC5883L breakout board: https://www.sparkfun.com/products/10530

as an external compass on my APM 2.5.  

Used the instructions here: http://copter.ardupilot.com/wiki/common-external-magnetometer-for-improved-performance/

The process is even simpler than those instructions, since the sparkfun board is already wired for 3.3V.  Just connect four wires and cut a jumper on he APM to disable the onboard compass.

I wasn't able to source the correct cable from sparkfun, but got one that was 1mm OC instead of the 1.25 OC that the APM uses on the i2c port.  A little very minor pin bending and hot glue to hold it in seemed to do the trick.

The HMC583L is the same sensor that's on the APM and on the 3DR external compass/GPS module.

Read more…

DiyDronesNews.com Podcast #1

Hex Kickstarter Project

- 3D Robotics RTF MultiCopter Iris -

Iris Teaser Video

Iris details: #1 The 4-1 ESC/Power Module

Iris Details: #2 Injection molded arms and Legs

Iris Details: #3 The camera attachment

Iris Details: #4 Android Apps Overview

Overview of PX4 and Pixhawk Board Series

- 3D Robotics Pixhawk -

Read more…
3D Robotics

Where drones sit on the Gartner "Hype Cycle"

3689547744?profile=originalGartner has released their annual "hype cycle", which seeks to identify where technologies are in their path to maturity. Gartner thinks that drones (which are a combination of "Autonomous vehicles" and "Mobile robots" above) are 5-10 years to the "Plateau of Productivity", but with the higher "inflated expectations" still to come (followed by the inevitable "trough of disillusionment". Sounds about right to me. 

Fast Company explains the methodology of the Hype Cycle and this year's version:

Gartner, a technology research group that has been producing its hype schematic since 1995, says new technologies tend to follow a trajectory. First there's a Trigger--a breakthrough that "kicks everything off." Then, that technology invariably gets over-exposed, leading to a bubble of expectations. At that point, the whole thing implodes (think of what happened the first time around with "virtual reality"). There's a over-reaction the other way, and everyone says the technology will never make it. And so on. Until, finally, the technology--which was a good idea to start with--takes its place in the "Plateau of Productivity."

Themes this year include "bioacoustic sensing, quantified self, 3-D bioprinting, brain-computer interface, human augmentation, speech-to-speech translation," and so on--which all fall under the category of technology that could help companies produce "more capable workforces."

A second theme involves technologies that are actually replacing humans, like "volumetric and holographic displays, autonomous vehicles, mobile robots and virtual assistants." A third group sees a more equal human-technology relationship, and includes "autonomous vehicles, mobile robots, natural language question and answering, and virtual assistants."

"These three major trends are made possible by three areas that facilitate and support the relationship between human and machine," says Hung LeHong, research vice president at Gartner. "Machines are becoming better at understanding humans and the environment--for example, recognizing the emotion in a person's voice--and humans are becoming better at understanding machines--for example, through the Internet of things."

The Hype Cycle has its holes. Not all technologies get over-hyped, fall into irrelevance, and then make it. Some just make it outright--or don't. And Gartner's theory is highly subjective: we could all place the same technologies in different places along the Hype Cycle. The company is hardly a disinterested observer: it manufactures hype itself, making the Hype Cycle seem quite meta.

But the chart does shed light on something that we often fail to see: technology rises and falls because of our belief in it.

Read more…

3689547811?profile=original

Immediate opening at the Smithsonian Tropical Research Institute (STRI) for an intern / fellow / research assistant to collect high-resolution aerial photos with unmanned aerial vehicles (UAVs).  Responsibilities will include assembly of UAVs, maintenance and repair of UAVs, weekly operation of UAVs to collect images, processing of collected images, collection of auxiliary field data (e.g., linking tagged trees with crowns visible on images), data analysis, and contribution to scientific publications.  Data collection will be focused in the Agua Salud experiment and the Barro Colorado Nature Monument (especially the 50 ha forest dynamics plot on Barro Colorado Island and long-term experimental plots on Gigante peninsula).  The successful candidate will work with staff scientist Helene Muller-Landau and collaborators, including Jonathan Dandois (http://ecosynth.org/), Lian Pin Koh (http://ConservationDrones.org), Stephanie Bohlman, Jeff Hall, S. Joseph Wright, and more.  The Smithsonian Tropical Research Institute is home to a vibrant scientific community of 30 staff scientists, over 100 graduate and postdoctoral fellows, and over 500 scientific visitors per year.

panamatropics.jpg?w=300&width=240

The ideal candidate has experience with UAVs or demonstrated possession of relevant mechanical and electronics skills, interest in and some basic knowledge of forest ecology, past experience in field research or some other outdoorsy job or pastime, experience using GPS, experience with GIS and remote sensing software, basic programming skills (e.g., Python, R, Matlab, or C++), a bachelor’s degree in a relevant field, good English communication skills, at least basic Spanish communication skills, a driver’s license, and ability to drive a vehicle with manual transmission.  The start date is flexible, but would ideally be as soon as possible, and no later than December 1.

This position will be compensated with a modest stipend sufficient to cover living expenses in Panama (minimum $800/month; negotiable).  Initial appointment is for one year (minimum commitment of 9 months is required), and is renewable contingent on satisfactory performance and availability of funds.

To apply, please email a cover letter describing your qualifications and interest in the position, CV, and contact information for 3 references to Helene Muller-Landau at mullerh@si.edu.  Review of applications will commence on September 15, 2013, and continue until the position is filled.


Read more…

Number 3 complete

 3689547593?profile=original


Number 1 was short lived http://diydrones.com/profiles/blog/list?user=3vlhdj1afps2z


Number 2 was much better http://diydrones.com/forum/topics/share-your-drone-info-thread?commentId=705844%3AComment%3A772970&xg_source=activity


Number 3 is perfect..      3DR Y6.

I didn't have enough room to squeeze in the gimbal in the space provided so, I had to make the mount for the gimbal from a piece of aluminum, which was fairly quick. They gimbal is fantastic, after you get it tuned which is a whole ordeal by itself. Lots of new understandings with that thing.. Basically, your expectation should be to keep the camera level in two planes, emphasis on the 'keep'. it won't just move it around itself, it has very little torque..


It's the same gimbal previously posted a month back.

http://www.goodluckbuy.com/dji-phantom-brushless-gimbal-camera-mount-w-motor-and-controller-for-gopro3-fpv-aerial-photography-blalck.html


enough about the gimbal..


Here's the flight. Flight


The wind was about 10-15 up there. the Camera nods when the angle get's to a certain point but it does stabilize. I did hover for a min to get the below air shot..


The Y6 is sooo stable. I have APM 2.6 with telemetry, Turnigy 9x radio. I purchased it as a kit. I wanted to see how much easier it is to buy a kit than build it myself, since that's what I did last time. It was so easy to assemble


Current code is also a great leap from the old Ardupirates code of my last one.. I'm not running a sonar and alt hold is within a few feet..


Putting the kit together was straight forward. Make sure you check the holes on the motor plates for alignment.. Better yet, 3DR, why not just drill a 4th hole? I didn't touch the PIDS one bit. Stock ones were right on the money. Yaw is tight also..  Lastly, I did have to cut off the deans connector that came with the power module. I have tons of the XT deans from Hobby King and the one that came with the module didn't connect securely enough and caused the apm to reboot.. Thank goodness I found this on the bench and not in the air.


What more can I say.. I've had so much fun with it..

3689547548?profile=original3689547439?profile=original3689547674?profile=original

 OH.. the ZEAL/Velcro Band works wonders...

3689547714?profile=original


Read more…

Project Platypus update

3689547463?profile=original

A small update - eventually got round to weighing it, and even with the 2mm plate, it's come in at the top of the designed weight - 1.1kg.This is good news because it means I should be able to hit the designed AUW - with NEX5 and gimbal - of 4.1kg.

3689547489?profile=original

With the recommended pack, that will mean a loiter time of around 19 minutes, and mixed flight time of 9 minutes (according to ecalc), This is just below what I wanted, unfortunately - I was aiming for 20 minutes loiter, and 10 minutes mixed flight time. I have some weight saving changes to make before handing over to 3 guys here for independent testing, so I'm hoping for 1kg, including legs, clamps, bolts, and DJI elevator.

The X/Y8 config might be interesting...yes it can do it easily enough, but I'm not sure how 4 x 4,000mAh 6S in parrallel in the bay (theoretically possible with 4m risers) will affect the CoG or the flight times...<laughs evily>. I can't do X8 for jack, but thankfully one of the testers will have more experience than me here!

Still to do before handing over to the testers - 19 different refinements/corrections, including holes for mounting new pixhawk attachments (led and external USB port).This frame is design from the outset for APM 2.5 & 2.6 at the moment, but just need to see what considerations I need for pixhawk.

Read more…

3D printed tricopter - from CAD to reality!

3689547029?profile=original

Hi,


I'm Adrian from Hungary/Europe. Let me introduce my tricopter project.

My goal was to make something really good-looking copter that have ally features I need.The design process started 1 years ago. My first idea was to make a composite chasis, from glass/carbon fiber.I designed the copter in a 3D modelling software, and also designed the necessary moulds for making each parts, here is the initial design:

3689546905?profile=original


This is a sample of the mould design:

3689547050?profile=originalI also made some FEM calculations, to check the stress dispersion:

3689546928?profile=original

3689547001?profile=originalUnfortunatelly, this type of production would cost too much for me. I tried to find partners in Hungary, without success. So I almost forgot this project. But some months before I read a lot about 3D printing, and finally I found a great partner in Hungary (many thanks to the Ground Zero Team www.groundzero.hu !!!). So I started to redesign my copter according to the requirements of 3D printing:

3689546950?profile=original

3689547165?profile=original

3689547114?profile=original


Then I sent the .stl files for FDM printing. Here is the result:

3689547192?profile=original

3689547127?profile=original

3689547206?profile=original


This is my current configuration:

  • Turnigy SK3-2826-1130 motors
  • 8x4,5 karbon SF props
  • 10A HK ESC (simonK firmware)
  • ArduFlyer 2.5 with ArduCopter 3.0.1 code
  • ULOX NEO6-M GPS
  • 2000mA 3S lipo (2 db 1000mA 3S2P)
  • Flytron 25A ultralight current sensor
  • MKS-DS95 servo
  • RECOM 5V 1A power supply for electronics
  • 3DR 868 MHz telemetry module
  • RCTimer OLED screen
  • Immersion 600mW 5.8 video TX + Coverleaf antenna
  • MinimOSD, with KVTeam code
  • KPC-E700PUB camera
  • FRSKY Futaba FASST-compatible receiver, PPM
  • controlled LED-s and buzzer

All-up weight is 782g, and has 8 minutes of safe flight time with 20-25% of remaining battery.

(Please note that I used Crius AIO Pro at first with MWI code and KV-OSD code. These can be found on the following pictures and in the videos.)

3689547227?profile=original

3689547081?profile=original

3689547253?profile=original

3689547247?profile=original

3689547268?profile=original


LED sripes are controlled by APM:

3689547311?profile=original

3689547354?profile=original


Here are some videos:

Flight test (with Multiwii)

Onboard video (with Multiwii + KV-OSD)

3689547322?profile=original


3689547281?profile=original

For more details please connect me by mail: nhadrian@gmail.com

- UPDATE - 

stl files can be downloaded from here:

http://shpws.me/oGJN
http://shpws.me/oGKc
http://shpws.me/oGKd
http://shpws.me/oGKg
http://shpws.me/oGK7

And these are the additional metal parts for rear arm control:

3689547406?profile=original3689547380?profile=original

I wish you all good luck on reproducing my tri.

Please note that I'll not modify desing according to personal wishes, since my spare time is quite limited and I focus on my personal projects. Thanks for understanding!!!


Best Regards

Adrian

Read more…

Reptile 500 at Shakawe Game reserve

We were invited to Shakawe Game reserve this weekend and the owner allowed me to take aerial videos at his beautiful farm this weekend and allowed us to see his amazing animals from a different angle.


They have from white springbok to black rooibok, as you also can see on the video all of the animals is in such good condition because everything on this farm is controlled to utter perfection, there is not a single area of this 800 hectare farm that is not controlled and managed to deliver the top quality animal walking around on this farm.


Here is their facebook page.


1170678_506269082801025_46286855_n.jpg


971067_506271486134118_1102412547_n.jpg


486387_459899507437983_238718556_n.jpg


559969_417690724992195_47273706_n.jpg


309991_401522976608970_880059322_n.jpg


So enjoy.

Read more…

Iris Details: #4 Android Apps Overview

This is a video showing an overview of operating Iris via an Android tablet. Although we always have an RC transmitter in the mix, as a backup, the Android apps provide a very convenient way to maintain a telemetry and control link with the vehicle.

In the weeks ahead, we will be making some in-depth video tutorials on using all these different functions.

3689546968?profile=original

3689546848?profile=original

3689546993?profile=original

http://diydrones.com/group/andropilot-users-group

http://diydrones.com/profiles/blogs/update-droidplanner-v0-11-4

Read more…