All Posts (11086)
Sort by
Another great post from Robohub. Excerpt:
“The whole is greater than the sum of its parts” — a catch phrase that aptly expresses the Distributed Flight Array: a modular robot consisting of hexagonal-shaped single-rotor units that can take on just about any shape or form. Although each unit is capable of generating enough thrust to lift itself off the ground, on its own it is incapable of flight much like a helicopter cannot fly without its tail rotor. However, when joined together, these units evolve into a sophisticated multi-rotor system capable of coordinated flight and much more.
Read the rest here
I flew my Arducopter IFR-FPV Sunday!
It was pretty cool once I landed safely back at the takeoff point.
For various reasons which I won't go into, my video camera view became unusable 2 or 3 minutes into the FPV flight in my rural neighborhood, and I found that I had no idea where I was.
The last thing I saw was an unfamiliar street and I was probably 100-150 ft high, then I couldn't make out anything.
I realized FPV wasn't going to get me back so I put int into loiter and took off my googles and and tried to see if I could see or hear it. I found that I couldn't hear or see the ArduCopter.
Unfortunately, I hadn't set up the Mission Planner and ground station, I was just going for a quick test flight before it got dark. so i just took the copter and the radio and took off.
Then I remembered!, I could just use the MinimOSD, thats what it's there for!
So I put the googles back on, even though I couldn't make out any camera image, the OSD was overlaying fine. So I checked the direction arrow, and the distance, I was about 600 feet out.
So, i turned until the arrow was pointing straight up and started heading in, In less than a minute, I began to hear the copter and it was a great sound. The meters out were counting down and I got it right within 2 meters of home, and descended to a landing. Whew!, I wiped my brow and retreated to the house with my hardware, and got a beer..
I found that it was a great feeling to know that I could fly IFR, and that I probably could have used RTL instead, using the instruments was much more fun and less nerve racking...
RE
From left: John, Alex, Sam
Our Berkeley office summer interns started work yesterday. Not a bad way to spend the summer!
The VR Gimbal DEV Board #1 is going in germany :)
Ludwig Färber will be the developer that will receive the first VR 3 axis Gimbal is this is our donation for his great work on :
http://code.google.com/p/brushless-gimbal/
What there is in kit :
Hardware :
VR Gimbal :
Micro Controller is STM32F1 at 72 mhz.
3 Axis Brushless Direct Drive gimbal :
- Roll (MOT1)
- Pitch (MOT2)
- Yaw (MOT3)
For each channel we have 3 high power pwm output .
1 USB port.
1 Serial port that support mavlink protocol.
1 Power module that support until 3S battery.
4 Radio RC Input for :
- Control ROLL Setup.
- Control Pitch Setup.
- Control YAW Setup.
- IR control repeater.
4 Analog Input 0-3.3v
VR 9DOF I2C IMU
Inside the VR IMU there are : MPU6000 (6 DOF) + HMC5883 (3 DOF)
I2C IMU that support 3 axis . It is on camera module , so we can know exactly the position of camera and control in realtime the 3 Brushless motors.
Cable for inteconnect the VR Gimbal Board with VR 9DOF I2C IMU
A Jumper for put the VR Gimbal in bootload mode.
Firmware :
The bootloader we use maple bootloader ported on VR Gimbal board.
On board we put first 32 bit release of BruGi 049B r69 (Martinenz board's firmware) . This version of firmware , support only 2 axis gimbal , the 3axis version is coming. All the boards is yet ready and tested for 3 axis managment.
Software :
We develop a VRGimbal Gui .net it's compatible with Windows 32 and 64 bit.
What do you need :
You need to download the Universal ide follow this link :
https://vrbrain.wordpress.com/installing-and-compiling-the-code/
And also need a ttl <-> usb converter
as this one :
https://www.olimex.com/Products/Components/Cables/USB-Serial-Cable/USB-Serial-Cable-F/
We are working on usb serial will be available in the end user product. The hardware will be the same will be only update the serial library.
Today we open pre order for first 20 pcs of board . We'll send a mail to first 75 developer that ask me to reserve the VR Gimbal.
The revision for end user will be available in some weeks a new batch is in production .
Some usefull link :
The code repository here you can find workspace with library and code and also VR Gimbal GUI.
http://code.google.com/p/vrgimbal/source/browse/#svn%2Fbranches
This is official VR Gimbal User Group join us for updates about the project:
http://www.virtualrobotix.com/group/vr-gimbal-user-group
for buy or reserve your VR 3 Axis gimbal send a request here : info@virtualrobotix.com
You will be inform about the status of the stocks .
The price for developer is updated to a promotional price of 95 euro for fist 20 VR Gimbal Dev Kit .
The end user price will be for 2 Axis Gimbal of 120 euro and for 3 Axis Gimbal of 165 euro.
Best
Roberto Navoni
The coverage of drones at TED Global continues over at Robohub with this great post from the Conservation Drones team, who presented today:
TED Global speaker/drone ecologist Lian Pin Koh and fellow researcher Serge Wich share how drones are playing an important role in helping conservationists survey and map ecologically sensitive parts of the globe.
Global land-use changes continue to be a major driver of biodiversity loss and greenhouse gas emissions. Remote sensing technology is increasingly used to assess changes in land use, species distributions and carbon stocks. However, satellite and airborne sensors can be prohibitively costly and inaccessible for researchers, or they may not have the required spatial resolution. Recently UAVs have been used by conservation researchers and practitioners across various parts of the world. These inexpensive UAVs typically cost less than $4000 US, and have been dubbed ‘Conservation Drones’. The drones are equipped with cameras to record videos at up to 1080 pixel resolution (high definition), and acquire aerial photographs of <2 cm pixel resolution. Aerial photographs can be stitched together to produce near real-time geo-referenced land use/cover maps of surveyed areas and 3D models.
This post is part of Robohub’s TED Global 2013 coverage.
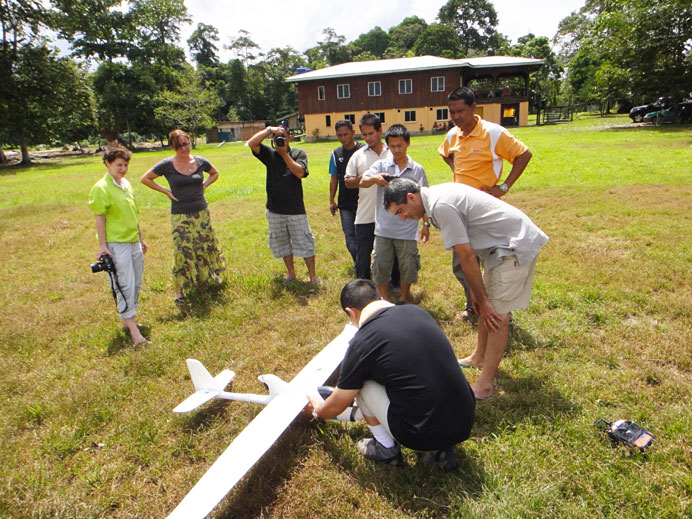
Serge Wich and Lian Pin Koh preparing a Conservation Drone for a demonstration mission for the French conservation group, HUTAN, near the Kinabatangan river in Borneo.Why did we develop Conservation Drones?
Globally, biodiversity continues to decline, and a disproportional amount of this decline occurs in the tropics where the majority of global biodiversity is found. One urgent challenge for conservationists is to be able to accurately assess and monitor changes in forest cover, species distributions and population dynamics. To obtain such data, conservationists currently rely on satellite-based remote sensing for mapping and monitoring land use changes, and on ground surveys to determine and monitor species distribution and population dynamics. Although low-resolution satellite images are freely available at specific time intervals, it is often prohibitively expensive to obtain sub-meter resolution images. Yet, such high-resolution data are often critical for accurately detecting and tracking land use change at the landscape scale. Furthermore, large portions of the humid tropics are often obscured from remote sensing satellites due to persistent cloud cover. As such, cloud-free satellite images for a specific time period/series and location are often not readily available.
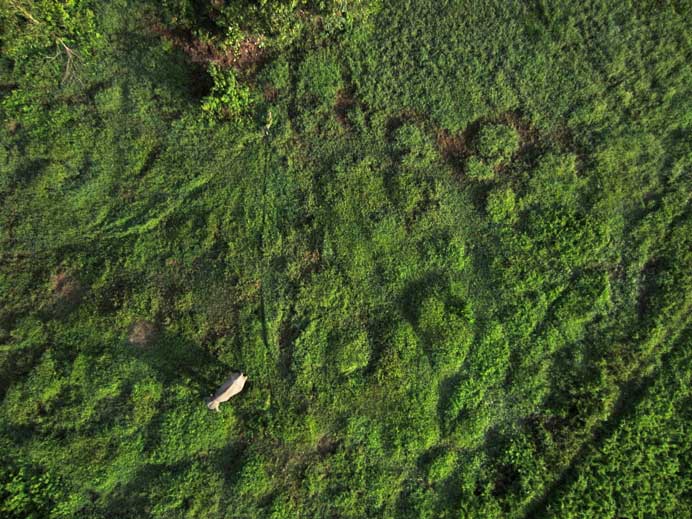
An elephant detected during one of the drone missions in North Sumatra, Indonesia.A second major conservation challenge concerns assessment and monitoring of biodiversity. Currently, this is largely achieved through ground surveys, which are often time-consuming, financially expensive, and logistically challenging in remote areas. As a result, surveys are not conducted at the frequency required to monitor population trends, and some remote tropical forests have never been surveyed for biodiversity due to difficult and inaccessible terrain.
An additional challenge for conservationists is the illegal encroachment into protected areas and illegal hunting of prized animals, such as tiger, rhinos, and elephants. The areas that need to be surveyed in these cases are large, and current ground and manned aircraft surveys do not occur regularly enough to be able to effectively reduce illegal activities.
To address these challenges, we are developing the use of inexpensive, autonomous unmanned aerial vehicles for surveying and mapping forests, biodiversity and potential illegal activities – Conservation Drones.
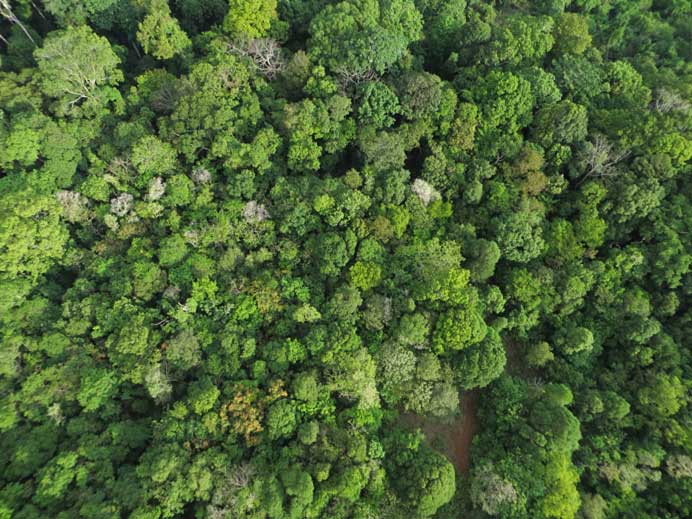
Drone image of a forest in Cambodia.What are Conservation Drones?
Although we have been using several airframes for our drones since we started, the core part of the system has remained the same. The core is an autopilot system (APM) developed by an online community (diydrones.com). By combining the APM with open-source mission planner software (APM Planner), we convert off-the-shelf model airplanes into drones. We use inexpensive airframes so that the technology can be accessible to conservation organizations and researchers, who often do not have the funding to acquire drones and maintain them.The sensors
We have equipped our drones with various camera systems for still-photography and videography. We have been mainly using the Canon SX230 with a build-in GPS so that all photos are geo-tagged. We replace the original firmware of the Canon camera with aCanon Hack Development Kit. This ‘hacked’ firmware allows us to implement a customized intervalometer script to command the camera to take photographs at user-specified time intervals (e.g., every 3 seconds). This script also allows the user to define several other parameters including: i) time-delay before the camera begins taking pictures, ii) focal length of camera lens, and iii) time before camera automatically shuts down and retracts its lens.We also use video cameras such as the GoPro Hero and the ContourGPS. These take high definition videos at 1080 x 720 pixels. We attached these cameras underneath or on the side of the fuselage. Using the APM Planner, we program the flight path of each mission by clicking on waypoints in a Google satellite map interface. The drone can be programmed to take off and land autonomously, and circle over any waypoint for a specified number of turns or duration. Users could also program other flight parameters such as ground speed and altitude of each waypoint.
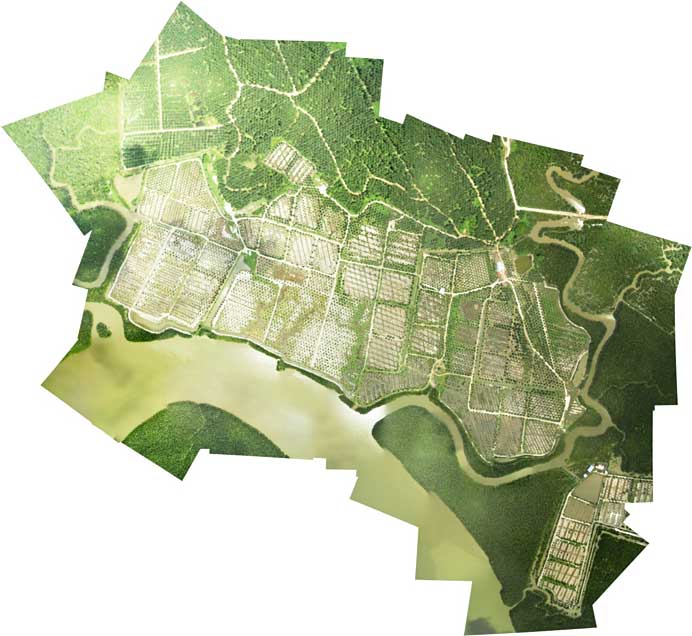
A mosaic of drone images during a mission over an agricultural landscape in Sabah.What have we achieved so far?
Since our start in January of this year we have made over 200 conservation drone flights in several countries including Switzerland, Netherlands, Indonesia, Malaysia and Nepal, Congo, Gabon, Madagascar, United States, and Greenland. These flights have provided us a large amount of photos and videos, which we have examined with respect to our three main initial goals. We describe these below.Mapping land use
So far we have been able to take sets of high-resolution photos of various areas that can be stitched together into a geo-referenced mosaic so that it can be used in geographic information system software. Such mosaics give detailed information on type of land use, agriculture, and settlements. In addition, the images can be used to create three-dimensional models of the areas that were covered during missions due to the overlap between the photos. Such models can potentially be used to calculate a number of characteristics of different land uses such as tree height and tree density.Biodiversity
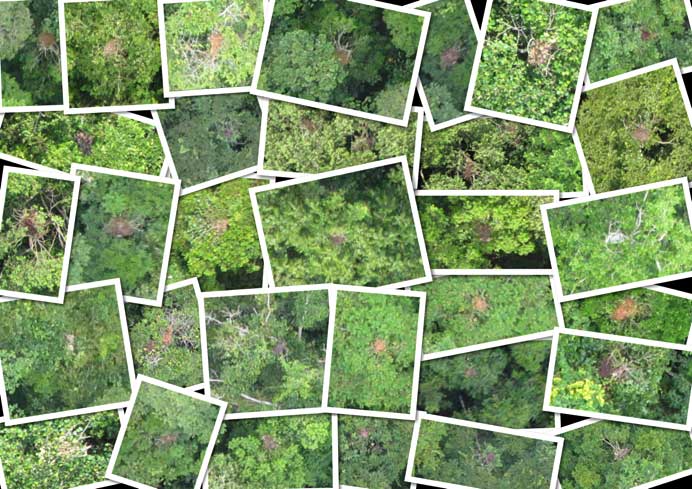
The high-resolution nature of our images have also allowed us to detect various wildlife species on our photos or their signs including orangutans and their nests, elephants, rhinos, forest buffaloes, and even turtle nests. The next important step for our work is to derive the distribution and density of these wildlife species based on drone images so that this technique can become a standard application for conservation workers. To achieve this goal, we are collaborating with colleagues, including Prof. Dr. Andreas Krause at ETH Zurich to automate the detection of orangutan nests.Illegal activities
For conservation workers, having access to up-to-date information on illegal logging in protected areas and poaching are extremely important. The video and photos taken from the drones can be used to detect such these illegal activities. For example, geo-tagged drone images of recently logged areas could help authorities track down illegal loggers and provide evidence for their conviction. When poachers are in a forest, they often create campfires for cooking or smoking the bush-meat from animals they have hunted. The detection of smoke rising above a forest would thus be very useful to locate these poachers. Conservation drones equipped with a high definition video camera could facilitate the detection of smoke many kilometers away. Furthermore, a ‘live’ video link would allow rangers to patrol the forest in real time, and react immediately when needed.
Drone images of orang-utan nests acquired during missions in Southeast Asia.Plans for the future
Conservation Drones is a constant work in progress. We are currently working with other colleagues to explore the use of our drones as a ‘data mule’. For example, drones equipped with a scanning radio receiver might be able to triangulate the location of forest animals that have been tagged with a radio collar. This would be a much more efficient way of locating these radio-collared animals than the traditional method of walking the forest on foot with a cumbersome radio antenna.We are also working with WWF Nepal and India to equip drones with thermal imaging cameras. These camera systems would be able to detect heat emitting objects from the ground, which would help rangers locate both wildlife and poachers at night.
Further Reading
Koh, L. H., Wich, S. A. (2012) Dawn of drone ecology: low-cost autonomous aerial vehicles for conservation. Tropical Conservation Science 5: 121-132.
During my LED-googling, I also ran across the Neopixel light strips. Those are strips made of WS2812 LEDs - RGB LEDs with integrated 2811 controller. Thanks to Adafruit there also is a control library, which makes it reasonably easy to control those things with an Arduino.
Here is an idea of integrated navigation and anti-collision lights for a quad:
4 segments, 1 red, 1 green and 2 white for left, right and rear arms, showing navigation colors and doubling as an anti-collision strobe. Those WS2812 are not immensely bright but hey - nobody said you can only use 3 per arm :).
And they probably work great for a plane too, just put half a meter of strip to every wing. That IS gonna be bright.
US-residents probably best get the strips from Adafruit. If you are in Europe, KT-Electronic's eBay-shop should be the right address.
I’m happy to announce the release of our first multirotor drone at Event 38, the Aphex aerial photography platform. This hexacopter is based on the 3DR Hexa frame. It comes ready to fly with a 2-axis stabilizing camera mount for taking aerial photographs. We modified the camera mount so it can now take images not only at moderate angles but also straight down for super low altitude mapping missions. You can easily make small mosaics with resolution less than 0.5cm/pixel. Aimed straight forward, the Aphex can be used to take amazing oblique aerial shots of houses, landscapes and large structures.
The Platform:
The Aphex is based on the 3DR Hexa-B frame using the larger 880kV motors and 11x4.7 propellers. APM2.5 with uBlox GPS are included. The pre-configured tilt/roll stabilized camera mount keeps your cameras up to 500g shooting straight and level. Adjust the tilt axis any time from your R/C controller. The 3DR battery monitor warns you when the battery is low on charge.
The Possibilities:
- Mapping – Great for small but extremely high quality maps, up to 20 acres per flight
- Inspection – Bridges/Buildings/Rooves
- Photography – Get a vantage point above pole cameras and below helicopters
- Planning – Construction, Mining, Logging, any large scale outdoor operation can benefit from a periodic, "big picture" vantage point.
For those who want really high quality images from an aerial vantage point and don’t like the distorted look and curved horizon you get from GoPro, we’ve sized the Aphex to carry larger traditional cameras. Mount your own or choose one of our Canon Powershot SX260s for medium resolution (12.1MP) and to have your images automatically geotagged. For very high quality images, we offer an automatic trigger system for Samsung mirrorless cameras, the NX1000, NX20 and NX210. These cameras are a great blend of DSLR quality images (20MP APC-C sensor) and lightweight bodies compatible with aerial use.
Check out some of our images below or see more here: http://droneyard.com/aerial-shots/
Click here to read more about the specifications or to order now.
Please leave your questions or comments below and also feel free to message me directly through DIY Drones or by email at Jeff@Event38.com. If there's any interest, I'll make another blog post detailing how to trigger Samsung NX cameras from APM.
Finally I'd like to thank the 3DR and uDrones teams and especially the ArduPlane, ArduCopter and Mission Planner dev teams, thank you!!
In full disclosure I work at a company that builds WiFi Access Points, routers etc for enterprises and I just put a hotspot on a drone for fun
It is hard to imagine now, but Ethernet as we know it today (802.3) was not the obvious choice for wired performant connections in 1996, many competing technologies like ATM, Token Ring, RS485, 802.4 etc seemed like more reliable choices, but because Ethernet was fast and cheap (among other reasons) it won out - since then it is hard to imagine a new technology displacing it.
Like Ethernet, WiFi is in the process of subsuming all adjacent technologies (802.15.4, Bluetooth, etc) and for all connections beyond the WAN (which will likely be LTE) it has the ability to be lower power, have better range (within reason) and perform better. This is not because WiFi is necessarily better spec'd - in fact it is unnecessarily complicated - it is because the R&D dollars are focused on it rather than competing technologies. A modern 3x3:3 802.11n chip has massive DSP resource and with .11ac we are seeing double the compute inside the mac/baseband. In addition we are seeing huge improvements in frame detection, phased antenna arrays and RF front ends which has the consequence of increasing link budget (link budget is roughly analogous to signal strength).
Okay, so where am I going with this: as a community we should be looking to use WiFi to consolidate our communication paths with our drones rather than 900MHz telemetry, 2.4GHz remote, 5.8GHz analog. Only fully integrated products like the Parrot AR drone use WiFi and I think that is a mistake. Here are a few reasons why WiFi makes sense:
- We put a digital RX with -95 db sensitivity inches away from a video transmitter transmitting at 23 dBm (in my case, or if you go illegal 36dBm) - this desensitizes our RX significantly reducing link budget. While this is one example, putting a high power transmitter next to a high sensitivity receiver is a bad idea always and we do it 3 times on drones.
- We need to deal with varying ranges and qualities of TX/RX pairs, complicated antenna and ground station setups.
- Analog video is incredibly susceptible to multi-path, limiting quality and antenna types. Don't we all want HD?
- Wouldn't it be convenient to just have one communication path? with maybe a remote as a backup.
Because there are naysayers (correctly so) out there, I thought I would point out common arguments against WiFi:
- WiFi requires a much higher SNR than 802.15.4 - this is true, but the quality of receivers and transmitters along with techniques MRC overcomes much of this and gives you a link that has a much lower duty cycle making it less susceptible to interference and provides superior error checking. A distance of 2-4km is totally practical with WiFi assuming good radios and modest antennas (we do a lot further at my company without too much issue)
- Using WiFi requires IP - yup… but does anybody think this isn't inevitable for us?
- WiFi is unreliable - okay, this needs a 2 part answer - WiFi is actually extremely reliable… it offers very good error checking (CRC) and will do 9 retries before dropping a frame at which point the higher level protocol will also send retries. On the flip side, we are often used to the crappy WiFi found in an Acer laptop (not picking on Acer, just mentioning a random pc vendor) where the radio is placed poorly, the analog front end is poorly designed and the antennas are in odd positions - remove those limitations and buy a $20 card from a reputable manufacturer and you will find superior performance.
- WiFi is really hard to integrate, especially when you need connections beyond serial speeds - I actually dont have an argument here. Most WiFi cards today use a soft MAC which means that most of the radio runs in software - replicating that in Arduino is infeasible. This is why the Arduino Yun uses a linux and a SoC to deliver WiFi. The obvious fix would be to put Autopilot on a linux based platform like OpenWRT, Android or Raspberry Pi
I don't think that it is a question of whether WiFi will become prevalent on drones, it is only a question of when. In the meantime I am working on my WiFi drone, I have 4G and WiFi on mine, Telemetry and Video are the next pieces to get working. I will update as I progress.
 I was looking for a way to make the ARM and GPS LED signals more visible for quite a while. Ideally, I thought, I could drive high-power LEDs somehow from that outputs. A short question in the comments of my blog post with the LED poles didn't yield any results except the reflex-like pointing to the jDrones JDIO board.
Well, I do have a JDIO board and it's not usable for that purpose at all.
Reasons:
- The JDIO board is not a LED driver. It's basically just a switch with an Arduino attached. Primary function of a LED driver is to supply a constant current, not to switch stuff on and off
- The JDIO board has a current limit of 500mA per channel. That works for 1W LEDs but nor for 3W LEDs.
- The JDIO board does decode MAVlink but the (IMHO) most interesting and important infos, i.e. ARM and GPS status, are not evaluated.
So, I started googling and scanning eBay. On eBay I found an interesting assortment of LED drivers from a German supplier - KT-Electronic. I ordered a few drivers and a bunch of other stuff and sent the seller a question about how the driver likes being dimmed by PWM on the supply side. Within a couple of hours I received an email, pointing me to another driver. The email described the circuitry and included the datasheet for the IC that's used on those driver. Actually, the seller has 2 drivers with this chip, one configured to drive 1-3x 1W LED in series and one configured to drive 1x 3W LED.It turned out, that those ICs have a combined analog/PWM input to control the LED output. Analog/PWM combined? Yeah! You can either apply between 0.2 and 5.0V to the ADJ input, which will result to proportional dimming of the output, or send a PWM signal with 0 and 5V amplitude.
This is the module before the modification:

 The SN3350 is easily accessible (latter photo, bottom right). All that needs to be done is to solder a servo cable to ADJ (bottom right pin) and GND (bottom center pin) and replace the MR16 pins with some cables. Soldering the cables to the IC requires somewhat of a steady hand but it's totally doable.
This is the module after the modification:
 Now you only have to connect the supply line to the battery and the control line to the APM and you have the APM controlling up to (3) 1W high-power LEDs. Don't forget the cooling for the LEDs!
According to the seller, the boards are tested up to 24V supply voltage. The IC can do up to 40 volts but the capacitors are only 25V types. The eBay auction does say 12V for one and 6-16V for the other but that is the normal operating voltage or (in the latter case) the minimum voltage (16V for 3 LEDs). I already tested the modules with a 4S LiPo a couple of hours constant operation and they didn't get noticably hot.
Raffaello D’Andrea, and the ETH Flying Machine Arena will perform a demo on TED Global. Take a look at the preparation behind the scenes exclusively on Robohub:
http://robohub.org/ted-global-raffaello-dandrea-and-his-quadrocopters-machine-athleticism/
There'll be more in-depth coverage, you can find all TED Global 2013 articles on Robohub here: http://robohub.org/tag/tedglobal2013/
Just some very early results, but here we go with our first autonomous onboard video. This is the PX4 native stack flying a stock Bormatec Camflyer Q (estimation and control used in the video contributed by James Goppert). PX4FMU + PX4io fits fine, but we are already working with Bormatec on a wider heavy-duty version (photos of the first prototype). Always keep in mind that the design goal of PX4 is to provide a modular autopilot platform not only for our own purposes, but also to allow others to build on. While working closely with the APM dev team making sure that APM runs fine on it, this allows us to experiment and push the state of the art (certainly on the platform, just starting on flight control), offering a flight control app on the same hardware for every purpose. For those who noted: Yes, QGroundControl has some cool new features coming, the AHRS display was contributed by Soren Kuula, and much more (not shown in the video) is coming from Michael Carpenter, with some really important design guidance by Michael Oborne and Craig Elders experience going in as well.
Joe was able to fit two of the new folding Y6 birds plus RC transmitters in his carry on bag. TSA did ask a few questions, but let them through.
Is it something new or I missed the announcement?
Yes indeed, I put one more year behind, and one less year ahead of me today. For my birthday morning, the family packed up and walked down the street to our lovely park, where I was able to do some trail flying. In short, I keep a line of site on the quad and hike behind as I fly it down the trails. This is the first time I have accomplished this feat with an HD camera attached, and I am quite happy with the results. Stick around to the end, because there is a definite surprise as to what I caught on camera.
John Cherbini and Joshua Ott of 3D Robotics, setting up a thermal imaging camera for infrared shots of a field at the Berkeley Marina. Photo by Aarti Shahani
From a NPR radio program airing tomorrow morning:
It appears that “drones” are here to stay. And Silicon Valley drone makers are going beyond military and spy applications, creating new environmental uses for unmanned aerial vehicles.
On Friday afternoons, you’ll usually find Chris Anderson out by the Berkeley Marina, tinkering with his squadron of drones. Looking up at the sky as one of his creations buzzes about, he can’t help blurting out, "So that’s just freakin’ cool, right?"
For Anderson, this is serious stuff. He quit his job as editor-in-chief of Wired Magazine to build 3D Robotics. The do-it-yourself drone company based in San Diego, won’t do military projects. That's part of a compact it has with about 40 thousand developers in its online community.
A few of them are here today, testing a 2-pound fixed-wing airplane that’s carrying a pocket-sized near-infrared camera, which is nothing more than a regular point-and-shoot model, with the plastic filter popped off.
"Our eyes are like the worst eyes in the animal kingdom,” Anderson says. “The cameras have been sort of crippled, to resemble the human eye. So we ‘un-cripple’ these cameras, to see the world the way an insect would see it."
This mini-airplane with a 2-and-half foot wingspan is different from conventional remote-controlled planes because it’s flying without a human operator. It’s following GPS coordinates plugged in before take-off. Other drones track moving objects on the ground using sensors.
"The more autonomous, the more drone-like they are," Anderson says.
The drone darts back and forth in a lawnmower pattern, 150 feet above the grass. It’s reporting its position to a laptop, and snapping pictures to stitch together a high-resolution map of the marina.
That image may not be something the world desperately needs but Anderson says farmers could use this kind of data gathering and image processing for crop surveys, to figure out what plants need water.
"A healthy plant will absorb the red light, but reflect the infrared,” he explains. “But as chlorophyll is damaged, it'll start to reflect the red as well. So the ratio of the infrared and the red tells you the health of the plant."
Well it's been a few months since my last blog post, so here is an update and some photos.
The ground control trailer is going well. I have finished putting on the steel cladding, and insulated with 10mm foamboard. In my last blog post, I referred to a generator which I was thinking of including.....I have decided to leave it out of the build, as I have decided to use two car batteries, 100W solar panel, and the tow car's alternator as a last resort to run the 2KW inverter. Should be plenty of power. The generator would be very loud if I incorporated it into the build, though it would allow me to have air conditioning, which would be nice!
And a vid never goes astray, subscribe for more :-)
Now the plane is taking shape too. See previous blog for the solidworks drawing. Basically it's an aluminium skeleton made from box section, and hot wire cut foam wings. The wings are 3m tip to tip. and there are two 16mm tubes joining the tail plane to the wings. The fuselage is a work in progress, but it will probably be made from water jet cut 3mm aluminium, then bent into a box.
The wings are cut from "medium density" insulation foam. The local insulation shop had offcuts of a suitable size, which they parted with for $30. Nice!
This is my first build of this size, so I really am not sure if it will be strong enough. Time will tell!
That's a two car garage, so the build is getting bigger and bigger!
That's a CRRCPro 50cc two stroke gas engine. It's a low cost Chinese engine. Reliability? Yet to be proven, but I can only find great reviews online, and only one unhappy review from someone that didn't like the BOX it came in?!?!?!
Landing gear, and motor mount fitted. Servo compartments cut...
Now for the fun part (NOT) ... fiberglassing!
I purchased some fiberglass cloth from ebay. It was the remains of some stock used for building wind turbines. So I thought it would be perfect...... Well, this stuff is strong, but it is VERRRRY heavy... The tail plane alone, after the fiberglass treatment, is 4KG! So the entire aeroplane will weigh around 20Kg before I add a payload, electronics and fuel. Too heavy? Again time will tell!
Starting very shortly, 0900 Mountain AVC 2013.
Chris Anderson and co are there to be covered in glory having flown an autonomous take off then out over water to drop a tennis ball on a spit of land, fly under a hoop and finally land all without the aid of a net.
What could possibly go wrong.
Live stream here http://www.ustream.tv/channel/autonomous-vehicle-competition
I'm hanging out as sUASNews on twitter there.
Everytime i launch my X8 it's never any problems. That was until i mounted a bigger propeller. I went from 13x6 to 14x9.5 and my plane "suddenly" went out of my hand much faster than before! The result is a painful hand and a lot of thinking :) Maybe some of you guys should think twice before you hand launch your new X8 or similar...
Now i'm considering several options:
1. Build a catapult
2. Hand launch engine off and throttle up after the wing has left my hand
3. Build a device where i can take off in a 30 deg. angle just by using the propeller power itself?
4. Any other ideas??
Hi gang :)))
Time to update blog. Story, named "Primus III". Prewiously, I show fuse building process:
I'll go sleep now, because of my injury is less.
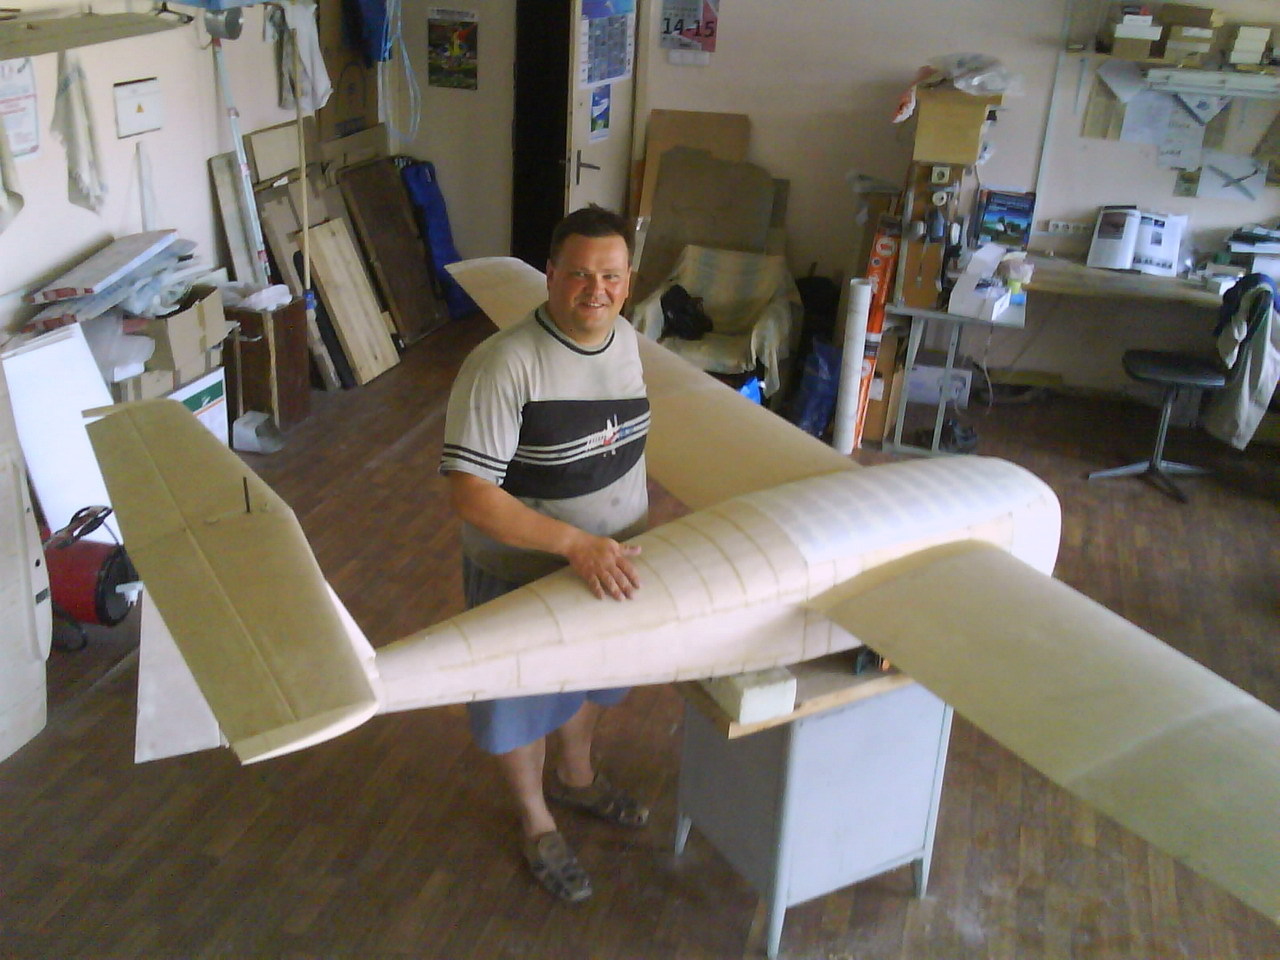
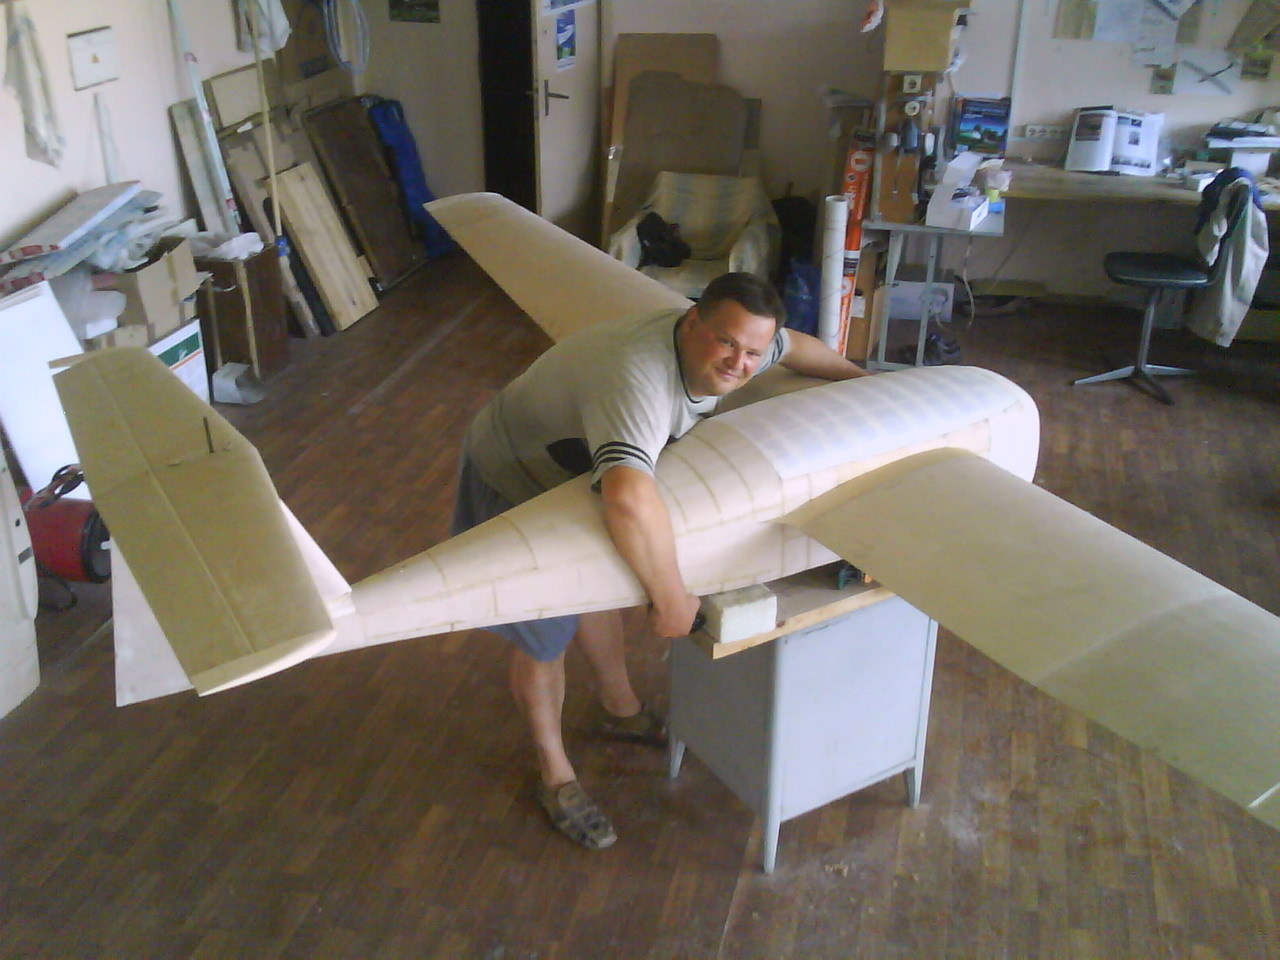
Now, plane look much better. We make a trial fit all elements together.
