All Posts (11086)

Sort by

ArduPilot Mega Telemetry on RC Transmitter Screen

What's the Turnigy TH9x or Eurgle 9x or other 9 channel clones good for ?
Well being a $60 transmitter very good. Add some new FW and holy cow !
Here is my modified $60 Eurgle TX.
v=Vtwh3K0XHP8&feature=player_embedded">https://www.youtube.com/watch?v=Vtwh3K0XHP8&feature=player_embedded

here is a group wanging it out!
http://www.rcgroups.com/forums/showthread.php?t=1266162&page=91
Earl


Read more…

fd4362b3-7173-4854-b242-50c097f2828e.Full.jpg

All patent graphics: USPTO [moderator edit]

Some unusual new design schemes for UAVs were recently granted US patents.

"Designs for morphing and articulating UAVs are among some of the latestest patents approved by the US Patent and Trademark Office. One is a Boeing patent for a lifting-body UAV with telescoping wing.

c022cbbb-c9b7-4ef1-a65c-ec837d74dfd5.Large.jpg

Concentric wing sections extend for a low-speed, high-lift configuration and retract flush with the airframe for high speed and low lift. Russian aircraft designer Ivan Makhonine flew the telescoping-wing MAK-10 in 1931, but Boeing's patent goes a step further and envisions extendable foreplanes, vertical tails - and variable-geometry telescoping wings...

fd4362b3-7173-4854-b242-50c097f2828e.Large.jpg

Another Boeing patent is for a solar-powered UAV capable of continuous operation at northern latitudes and during winter months, when sunlight is in short supply.

703495f5-4b37-4b54-8fc2-bd1fa7df4dae.Large.jpg

The aircraft has a planar "solar sail", with solar cells on one side, mounted so it can rotate around the aircraft's roll axis to track the elevation of the Sun while the vehicle remains horizontal. The X-tail also has solar cells on one side and rotates to track the Sun while providing pitch and yaw control of the vehicle.

1b40fdab-23f9-4b96-ac99-b7cd39c8228c.Large.jpg

One final patent, awarded to Virginia-based Geoffrey Summer, is for a "skybase" system of forming a high-latitude UAV from multiple smaller aircraft. These "modular flyers" would be air-launched individually and would join up, wingtip to wingtip, to form a larger "articluated-wing"vehicle - the more that join the higher it can fly.

6fb6abc0-d81a-43cb-ba36-00b366a89de3.Large.jpg

As illustrated above (right), individual flyers could fail and the skybase would reform and keep flying. Additionally, individual flyers could be detached from the formation and despatched to take a closer look at a target before returning to rejoin the skybase."
Read more…
100KM

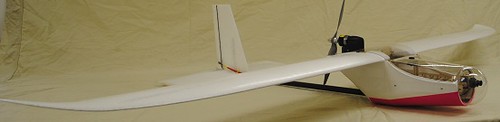
techpod1.0 ready to ship

5015652144_246150382d.jpg


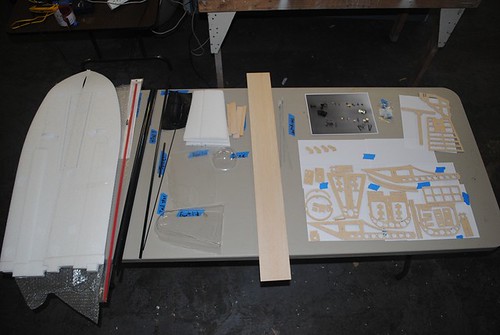
Here is what you get


5015020779_fb0a555fca.jpg


including :

EPP wings and tail , carbon fiber tail boom , CF wing spars , CF joiner , CF tail spars , CNC cut aircraft grade plywood , polycarbonate front and rear lids , 1/4 turn fastener for front lid , acrylic camera dome , ABS molded engine cowl , all push rods , control horns , balsa sheeting and stock , all needed screws and assorted hardware .


Not included but recommended running gear


motor : E-flight power 10 brushless in runner

ESC : castle creation thunderbird-54

Batteries : thunderpower pro light v2 3S 2600 mah x2 wired parallel

servos : 2x hitec HS-81 (elevator,rudder) 2x hitec HS-55(2x ailerons) 2x HS-5055mg (pan,tilt)

TX & RX Spectrum DX-7

Prop : APC E11x7

camera : CCD Killer Camera Micro NTSC Camera

as of this posting there are only 4 left from this run . the material for 20 more is on the way . will be available in approximately 2 weeks


for the latest news check http://evuas.com

Read more…

Modkit


I came across this on sparkfun.com and think this is a great way to get your kids started in micro controllers.


I realize this might not be the best suited for the needs of a UAV but LEGO Logo was where I got my start in something that I could call programming and as long as the price is right I think this would be a great tool to get the local kids into micro controllers.

Home page

http://www.modk.it/

Video

https://www.youtube.com/watch?v=RNqDoniUD9I

Funding

http://www.kickstarter.com/projects/modkit/modkit-electronics-arduino-for-everyone

Read more…

QuadRotor Project, Part 2

3689371147?profile=original
Some weeks ago I posted about my quadrotor proyect and showed a video with the Roll controller on a testbench.

Now I'm working with the yaw controller. I build a simple testbench to test the behaviour of the controller. As I said before, I am implementing a digital PID on the arduino MEGA, and I use Labview just to send the commands and visualize the behaviour of the quad.

Here is a small clip of how the yaw controller is working right now. I still have to improve it, but I think I'm getting there. Please feel free to comment or ask any question.

I will add some pics again for those who didnt see my previous post.


Read more…
3D Robotics


As most of you know, we've been in semi-public alpha with the ArduPilotMega code for the past two 2-3 months, and there has been the usual torrent of bug fixes, feature additions and architecture changes during that period as both the fixed wing and quad/heli teams test fly the board. By the time we release 1.0, this will be the most tested hardware/software configuration in DIY Drones history, which I'm really proud of.


Here are the latest updates:


1) The official public beta (as a zip file) is targeted to be released on September 30th. It will be announced here. It will have full autopilot capability and should be ready for unlimited flight testing. The new GCS may be out at the same time; if not, there is a mode by which APM can use the old GCS, which has all but the in-flight mission upload capability.

2) The APM board is now available at Sparkfun (another 233 are in stock--more than 500 have already been sold).

3) The DIY Drones factory moved to a larger industrial space yesterday with our big new Manncorp 7722-FV pick-and-place machine (our second!). This is to ramp of production of the new APM IMU Rev-H boards, which are much easier for us to produce, and anticipates the huge demand we're seeing for ArduCopter and for fixed wing once the code is out. Limited quantities of the board are available now, and stock should be replenished on a daily basis going forward.

4) Speaking of ArduCopter, Jani says he may start taking pre-orders in two weeks, and shipping full kits within the month.

5) Finally, if you've one of the brave early adopters who has been using the Alpha APM code out of the SVN, you should be aware that there have been some significant architecture and config file changes. We VERY MUCH RECOMMEND that most users wait for the public beta next week--the alpha code in the SVN is changing fast and often unstable, and we will not be able to answer questions on it from non dev-team members. But if you're an SVN expert or already knee-deep in the alpha code, you can download the latest code from the SVN and follow these instructions from code guru Michael Smith:


- After you update your Sketchbook, or ArduPilotMega folder, check that you don't have any local changes or conflicts at the top of ArduPilotMega.pde. Also make sure that you are no longer including a personalised configuration file. You should not have any local changes in this file related to your configuration.

- If you still have a copy of APM_Config.h containing options from the old version of the file, save any specific options you changed and delete the file.

- If you still have a copy of APM_PID_gains.h containing changes from the old version of the file, save any specific changes and delete the file.

- Open APM_Config.h.example in your favorite file viewer. Note that this file isn't included by anything, it's just a reference. DO NOT copy this file as a basis for your new APM_Config.h file.

- Open a new APM_Config.h file. In this file you will be saving *just* your local changes. It will never be overwritten by changes made by the developers, so you will be relatively save from conflicts related to option changes.

- Work through APM_Config.h. Note that only the REQUIRED options are, well, required. Currently that's just GPS_PROTOCOL. Here is my current APM_Config.h file in its entirety:

// Mike's local config
#define GPS_PROTOCOL GPS_PROTOCOL_UBLOX

- Check your old saved APM_Config.h changes (if any). Note that units for many properties have changed to be more friendly (e.g. hundredths of a degree is now degrees), and many configuration options are gone (e.g. radio channel settings, etc). Defaults have not changed significantly, so if you had no changes before, you should need none now.

- Check your old saved APM_PID_gains.h changes (if any) and set options as required. Note that many of the units here have changed, but the default values are the same as before, so if you had no changes you don't need any of these to be set.

If you encounter problems with the transition that need to be fixed, please file an issue.

Read more…

Crash 4 Sure: integrated Autopilot & OSD


A few months earlier, mmormota and I have started to develop a combination of autopilot and OSD. We're made it for FPV purposes mainly, but you may have found it interesting because of the autopilot part. We've just accomplished our first flight tests in this week and the system didn't served it's temporary name: Crash 4 Sure :)
On the picture above you can see as it's going round on a small rectangle course. Here is the video: http://vimeo.com/15128879

Our main goals are:
- Simple installation, we hate the mess of wires.
- Keeping the part count and prices low.
- Make it modular for further expansions, but the basic unit must able to stabilize and bring back the plane safely.

Our unit is most likely a single chip design, based on an STM32 (ARM Cortex M3) controller witch performs all the tasks. This combination of the two systems is quite convenient. For example we can see clearly how the autopilot works, is the orientation correct, because it can display everything on screen real-time.
The sensing of orientation is IMU based, I'm currently using the Razor 6DOF IMU board from Sparkfun and mmormota is using ITG-3200 and BMA-180 breakouts for this task.

The autopilot have the following modes of operation:
-Manual mode
-Stabilized mode (exactly the same as ardupilot's "fly by wire")
-Waypoint mode
-Return to Home

We want to expand it's abilities with automatic takeoff and landing, but first we want to make the current software and features as safe as possible. We were using Raisonance's Ride7 and Rlink for he development, but run into the 32k code limit and have to transfer the project under Eclipse + GDB + OpenOCD + Rlink. Programming and debugging the target still didn't work very well, this environment is terribly complex and hard to configure everything right...
The entire code is in C, using floating point arithmetic everywhere. Now it takes about 10% CPU time to run everything what's related to the autopilot and the OSD consumes about 15% CPU time, so there is still plenty of possibility in the hardware. Ohh, and the core runs on 48MHz instead of the maximal 72MHz.

So this is the whole story in a nutshell, we're want to thank all of YOU who maintain this great community.

Special thanks to William Premerlani for the great papers !

Here are some photos of my equipment:

p1010077ml.jpg


p1010079f.jpg


p1010132b.jpg


p1010122b.jpg


Read more…
3D Robotics

Help wanted: Mac LabVIEW developer

We're looking for a volunteer with a Mac version of the LabVIEW devkit to help compile a version of the new ArduPilotMega Ground Control Station for Macs. No coding required (although if you're interested, we can certainly bring you into the dev process)--just need to be able to create a Mac executable from the existing code and keep it updated as the code evolves.

It's a great way to get into the APM development team process, and shouldn't take much work. Please respond in the comments or PM me if you're interested.
Read more…
T3

landing altitude control

There is a simple control technique to get good altitude control during autonomous landings. Turn off the throttle and follow a glide path defined by 2 waypoints. The first point is the approach point, and should be about 10 meters above the beginning of the runway. The second point defines the glide path, and should have a negative height, and be unreachable.

Whenever the plane is above the desired landing glide path, the pitch altitude control should be programmed to engage. Whenever the plane is below the desired glide path, altitude control should simply maintain level pitch, that will keep the unpowered plane from stalling.

If the plane is landing against the wind, it will land close to the first waypoint. If it is landing with the wind, it will land where the glide path intersects the ground.

The above pair of tracks were recorded during 8 autonomous flights of an EasyStar that I made today. Waypoint7 is the approach point, and waypoint8 defines the glide path. The two landings were within 7 meters of each other, and close to the intended landing point.

Best regards,

Bill Premerlani

Read more…
This might interest some of you.


A hydrogen fuel cell hybrid power-train for 1/10 scale model hobby RC. The H-Cell 2.0 can be connected to almost any RC platform and will provide continuous power to recharge the on-board batteries. Using this hybrid system it is possible to increase the run time of RC vehicles by more than four times!


When the solar panel option is included the HydroFILL and H-Cell 2.0 become a 100% renewable energy system. The solar panel also has the added benefit of making the HydroFILL mobile and HydroSTIKs can be refilled anywhere the sun shines!


Here is the PDF brochure they sent me: H-Cell 2 0 Brochure.pdf


Read more…
Moderator


Hello everyone,
in this video you can see the first pre-flight testing on the new HG3.2 the airplane has the following features:
Created by Joseph D'Angelo
Hardware and firmware development: Roberto Navoni
Electronic Edge: Ardubotix 1.0A (Multipilot)
Wheelbase: 1.65 m
Maximum dimensions: 2.60 x 2.60 m
V2 Version: hybrid
Electric Motor: Hacker A60
Petrol Engine: Zenoah
Blades: SAB Composite
Frame: DIY


Here we can found the video : http://www.virtualrobotix.com/profiles/blogs/hg32-preflight-check

Here you can found the full story : http://www.virtualrobotix.com/profiles/blogs/hg3-the-era-of-quad-variable

Blog of Giuseppe Pipposoft for the friends ;) : http://www.virtualrobotix.com/profile/GiuseppeDAngelo?xg_source=activity

Read more…
Moderator

Synchronised video/stills and position in HD

3689371094?profile=original

I thought this looked like quite a cool concept so I asked them about it. An HD camera / GPS logging solution with some pretty funky software for linking the recorded video and data gathered together afterwards.

This requires us to develop a complete new product family which is based around a HD camera solution which meets the specific requirements for, lets say, an RC helicopter pilot. It should be small, very robust, but most importantly able to take care of vibrations caused by the RC model plane or helicopter. But it should stay affordable and allow easy additional data collection via quick and simple module based add-on’s which can be connected to the main unit quickly and easily without needing to engage in rocket science.


Part of the development plan is an HD downlink.


Read more…
Developer


This ardupilotmega hardware in the loop block for scicoslab marks the completion of an open source, completely free autopilot design and testing tool chain. The jsbsimcomm block communicates with the ardupilotmega hil block to simulate an actual flight. Servos move in response to the autopilot and may also be manually controlled with the radio receiver. This isn't polished yet, but it's working and I'll be cleaning it up this week. I've used the boost asio library for serial communication so the scicoslab blocks should also compile on windows if your lucky. Will probably take some work if anyone wants to volunteer. :-). Source code is on http://hsl.dynalias.com/git/?p=JSBSim;a=summary
Read more…
3D Robotics

Using Arduino with Matlab

Matlab is the gold standard of physical computing simulations used with UAVs, including built-in Kalman filters. Now you can use it with Arduino.


From the Arduino blog: "I found a well and detailed step-by-step guide with codes and pictures on this presentation from Giampiero Campa who lead the webinar “Learning Basic Mechatronics Concepts Using the Arduino Board and MATLAB“:

The webinar introduces the ArduinoIO package, which allows the user to perform Analog and Digital Input and Output, as well as to control DC, Servo and Stepper Motors interactively from the MATLAB command window, without having to write, debug, compile, upload and run C programs.

you can downlaod the Arduino package from here."

Read more…
3D Robotics
I'm a bit late to the party in actually building a beta ArduCopter kit, but I just finished last night, loaded the code and set the motor rotation directions this morn. Then the kids and I took it out to our tiny backyard and just took off. This is the result--amazing. Rock-sold stability (this was in windy conditions, too) and no tuning required--these are the default settings. So much better than the Gaui 330 XS, both in terms of performance and setup!

Ted Carancho's configurator software is the key. Best setup experience I've ever had. It not only tests all your hardware, but really walks you through the process in an intuitive way. It looks great, too:


My only issue was the the rudder channel seemed reversed in the configurator, but worked fine on the quad. I'll dig into that a bit more. But the main point is this: ArduCopter is in great shape, and as far as I can tell, ready for prime time. Really looking forward to the commercial release in a few weeks. Huge congrats to the team!

Read more…
3D Robotics

New PixHawk GCS vid and development roadmap


"The Pixhawk Team at ETH shows off more progress on their QGroundControl, and discusses their development plans here. " From I Heart Robotics.
kbosak: If you want to spare yourself digging through the project website, the groundstation itself has mailing group http://groups.google.com/group/qgroundcontrol and issue reporting + code download site http://github.com/pixhawk/qgroundcontrol
Read more…

Operation Overkill - ArduCopter, input appreciated :)

Let me just start saying that I like overkill on just about every project i do but i also am frugal as hell and need to keep costs down, i know so counter productive to someone who likes overkill HEHE.

Next problem i live in the caribbean, it has some advantages, like i can probably fly my uav just about anywhere and no one will say sh*t, and frequency use ... well... the local "FCC" is a joke, so i dont really need any ham licenses etc for running alternate frequencies are far as i can tell here.

Now the negative of being in the caribbean, their are 0 rc shops on island so everything is ordered from the US, so theirs no real "opps ordered the wrong thing" i have to get it right the first time around or else shipping will kill me.

I havent flown RC in a very very long time, and even then it was my dad's boats which clocked in at 70mph on water which was always impressive... But never really flew a plane, i am however a quick study.

Anyway thats enough intro to who i am, onward to Operation Overkill!

Operation Overkill Mission Plan: To build a "heavy lift" RC QuadCopter utilizing opensource hardware/software.

Operation Overkill Success Goals
1: Ability to manually fly using FPV
2: Ability to autonavigate way points for geophotomapping
3: Capable of 15-20 minutes of sustained flight fully loaded with hardware
4: Able to aim and trigger a high quality camera.
5: Stable flight and video recording for video work.
6. Total flight product under 800$

Operation Overkill Hardware
--- Basic Brains ---
1x ArduPilot-Mega - $60.00
1x ArduPilot-Mega IMU - $160.00
1x MediaTek MT3329 GPS 10Hz + Adapter - $40.00
1x HMC5843 - Triple Axis Magnetometer - $45.00

--- Power Plant ---
1x TrueRC 11.1V 8000mAh Li-polymer Battery 10c = 565grams - $110
4x X2217/08 Outrunner hangit rc 18 amps max http://www.eastrc.org/estoremotorselectric.htm - 32$*4 - $128
4x 3.17mm Prop Saver w/ Adapter & 3 bands http://www.hobbycity.com/hobbycity/store/uh_viewItem.asp?idProduct=3739 4x $2.99 = $12

*** I've read that the TrueRC batteries are awesome and cheap, the hangitrc motor had the highest thrust i could find in such a small package and low price, 32$, 70 gram unit, and 1150grams of thrust with the 10x5 e prop, although i'm having issues finding the APC e prop for CCW or am i missing something? the prop savers, i dont know if they are really designed to work with 10x5 props but as i said i dont wanna be ordering new props every week given where i live any experience with prop savers on quads with bigger rotors?

--- OSD/Telemetry ---
*** I'm still not sure what to do here, i wanted a good OSD but the one i saw that works with ardupilot forces use of a smaller gps module from what i saw and i want high gps reliability for when its on autopilot... The alternative is xbee pro for telemetry and just a standard ccd with broadcaster without an osd... any input here would be great.

--- TX/RX ---
1x Turnigy 9X 9Ch Transmitter w/ Module & 8ch Receiver (Mode 2) (v2 Firmware) - $70

--- Camera Hardware ---
*** I'm still researching how best to integrate/mount/trigger a camera using ardupilot mega, as i'd like to have some form of camera stabilizer mount below that i can rotate and turn that would also hold the osd camera that way i could actively see what i'm aiming the high def camera at, switch on hover, aim the cameras and trigger a nice snap shot fromt he air... Or program waypoints (once thats available) point the cameras straight down and do geophotos, tips and suggestions are welcome.

--- Airframe ---
To start i'm looking to get some metal towel rods for arms, and hopefully will be able to find some teflon/rubber washers so that i can pressure mount the motors onto the rods instead of drilling them... the plates for the electronics, i'm considering trying to find some flat plastic boards and then covering the contact points with the electronics with a little bit of rubber to reduce vibration on the electronics even further.

This setup would primarily be used for just testing and getting the hang of the unit i eventually want to get a unit from Jakub or maybe build out a carbon fiber frame once i'm sure of my hardware that will handle a camera mount

-------------------END OF HARDWARE---------------------

Price wise I'm at 630$ and i'm missing the camera, airframe, telemetry and radio.... wow i don't think im gonna make that 800$ goal.

The way i see it at max thrust the engine and prop combo can put out 4600grams of thrust. I don't really want to be using that much as i'll drain even the 8000mah battery in what, 5-6 minutes so i should be looking to keep the total load at about half that 2300grams, right? That way i can maximize battery availability by not having to run the motors hard ever.

280grams motor + 570 grams battery + 400 grams for the airframe worst case + 200 grams of circuit boards (i have no idea how much the ardu pilot stuff weights along with the radio and telemetry) + 100 grams esc

That would bring me to 1550grams allowing me to lug a camera of up to a 1kg without stressing the engines or battery... i kinda wish i cud get my non-payload weight down some.

Anyone see where i could save some cash? Or alternatives for the above hardware? Holes in my logic etc would all be appreciated greatly.

Wow is it just me or is 40.7oz * 4 - 1450 grams airframe mean i could lift a 7 pound baby? lol Not that i would LOL
Read more…

Who's on Twitter?

3689370110?profile=original

Please comment if you'd like to add or remove an entry.

DIY Drones: @DIYDrones

DIY Drones members
Chris Anderson: @chr1sa
Doug Connell: @dougconnell
Garry Qualls: @garryqualls
Gary Mortimer: @sUASnews
IKE: @erripman
Jaron: @jarontec
kevin kitchin: @kitchin01
Melih Karakelle: @flytron
Scott James: @MelbourneUAV

Sgt Ric: @Sgt_Ric

Read more…