Another great tutorial by Randy.
Here's an example of using it for RTL analysis:
Another great tutorial by Randy.
Here's an example of using it for RTL analysis:
Set up with airspeed sensor and telemetry. A little worried about propwash on the pitot-static probe but we'll have to see!
APM frame is 3D printed and uses nylon standoffs to space everything out. Flight battery is under there but balancing leads exit on the right side of the fuselage so it can be charged and remain inside. Its also wired up to a switch so there's no more fussing with battery connectors. Battery was moved aft to counteract extra weight up front. CG is pretty dead on.
I can post STLs of my frame if anyone is interested. It's stuck onto the fuselage with VHB. Hopefully will get some good video soon!
For those of you who are using Google+, the DIY Drones community there is growing nicely and just broke 1,000 members. It's a good way to get DIYD content in your regular G+ stream, and it's easy to share other relevent G+ posts with the rest of the community. Join here.
This is a quick video of a flight after some fresh snow in Castlewood Canyon State Park south of Denver, which was one of my favorite places to go as a kid. This is the first video I've posted using my new GoPro3 White Edition. It's taken me forever to figure out the right settings for color correction, since the raw video from this camera is normally flat and lacking in contrast. I think I finally got it right, though the flat lighting and the sun shining through the clouds confusing the GoPro's light meter didn't help.
This canyon is a real challenge to fly and get smooth video, since the slightest wind is amplified by the canyon walls producing a lot of turbulence. My Deep Reaper can handle it better than my old Hawk Sky, but it's still a little bumpy. It was also fun to fly as low through the canyon as possible without blocking LOS with an intervening hill.  Enjoy!
Oakland tribute tower from ZM Interactive on Vimeo.
Hey everyone, just wanted to share,
This is part of a video for a featured film we did, it got pretty windy, check the flags later on the video :)
Let me know what u think!
Ziv.
***Footage of how the helicopter flies is in the second half of the video***
Drone Cafe - Episode 8 - Micro Siri Heli - Part 1
***Part 2 I am going to open up the Heli for the first time and make a video about whats inside, how much space is available, and what my options are***
If anyone has any knowledge in voice control, programming, Siri code, or anything useful to this project please help contribute. You can do that by giving me all the information that you think I would find useful in completing my goals for this project.
Useful Links to this Project:
Siri Controlled Arduino using Ruby
I had a blast helping my friend build his hexacopter last weekend. This video includes some tips and tricks. We also had to do some interesting trouble shooting for problem that showed up during ESC calibration that turned out to be a bad soldering job (yep it was my fault!).
Anyway please enjoy a 5 minute condensed version of a fun day building the most excellent 3DR ArduCopter Hexa-B Frame + Motors + Full Flight Electronics Kit.
At first, we tried principle experiment with 1-axis arm robot.
Next, we tried principle experiment with 2-axes arm robot.
This is our latest experiment with humanoid robot.
This Kickstarter project is awesome (I'm a backer). The video above, from the San Jose State team doing this project, is inspiring. And they use APM 2.5!
From the listing:
What is HLQ?
We are designing and building a Heavy Lift Quadcopter (HLQ) which we are calling Incredible HLQ (sounds like "Hulk"). Like the super hero, HLQ will be able to lift and transport a huge amount of weight for it's size and cost. HLQ will be capable autonomously retrieving and delivering 50 pounds of payload.
How are we doing it?
In order to accomplish the 50 pound goal, HLQ will utilize a drive train powered by two gasoline two-stroke engines of about 12.5 HP each. Lift will be achieved using four commercial RC helicopter rotor heads spinning four 435mm blades. Selection of these blades were based of actual lift testing in our test rig which is featured in the video. Control is achieved by using the variable pitch control of the rotor-heads to change the lift output and induces torque of each rotor.
Flight control will utilize DIYDrone's Ardupilot APM2.5+ module. The Ardupilot is a open-source arduino based control board for UAV's. It has been widely utilized for many fixed wing, helicopter and multi-rotor flight platforms and has a proven track record. Best of all, the programming is already done for us.
In addition, we will be utilizing a computer vision system for payload identification and tracking using the OpenCV library on a Roboard RB-110. The RB-110 is a complete computer on a single board. It has a 486 compatible processor running at 1GHz and is capable of running, Windows, Linux or Dos. We will be using OpenCV through it's Python extensions to identify payloads and guide HLQ in for retrieval.
As students of San Jose State, we have a lot of resources available to us for designing and building HLQ. The Engineering department has a computer lab which has design tools such as PTC Creo, Solid Works, and Inventor. We have thus far been utilizing mostly Creo to design and analyze HLQ. We also have access to electronics labs, mechatronics labs, and product testing labs to help build and troubleshoot HLQ.
We are also just two blocks away from the San Jose TechShop which gives us access to lathes, mills, laser cutters, a water-jet machine, electronics equipment and more.
Lastly, but perhaps most importantly, we have made contact with members of the worlds top aerospace and mechanical engineering firms right here in the San Francisco Bay Area. We are designing HLQ with reliance on their knowledge and experience.
As you can see we have all the resources necessary to complete HLQ. But there is one thing keeping us from meeting our goal: funding! That is, of course why we are here on kick-starter, and why we need your help to make HLQ a reality!
Impressive philosophical opinion about the modern world and the role of self-regulating systems in our life.
From ZURICH.MINDS conferences YT reports.
Check YT channel https://www.youtube.com/user/zurichminds for more interesting things and http://zurichminds.com for such another events.
"ZURICH.MINDS is a community of leaders in science, the arts and business. We are driven by passion and curiosity. We strive for deep understanding and love new ideas. Our goal is to improve the quality of our decisions as private individuals, as role models and as citizens of this planet – and to inspire others to do so.
///
Description from YT.
"Professor Raffaello D'Andrea from ETH Zurich at ZURICH.MINDS presents: "Feedback Control and the Coming Machine Revolution" -- an amazing display of the future capabilities of machines using flying robots (drones). Institute for Dynamic Systems and Control, Zurichminds 2012, curated by Rolf Dobelli."
Dec 28, 2012
///
* I do not have anything to do with the organizers of this the event, and just wanted to draw attention to this very interesting initiative.
The cover story, by Lev Grossman, is here and discusses DIY Drones. The editors of Time also invited me to write a companion piece in the issue, which is below (they wrote the headline, not me!)
Why We Shouldn’t Fear Personal Drones
By Chris Anderson
Drones, like most robots, are designed for jobs that are “dull, dirty or dangerous.” We know what that means in a military context — everything from endless “loitering” over combat zones to remote-controlled warfare with the pilots safely in a trailer in Nevada — but soon civilian drones will be flying commonly overhead here at home. What will they be doing?
The usual assumption is that it will be police surveillance and general snooping. Interestingly, that’s just what people feared when the computer, which had also been introduced as a military technology, started to be used commercially in the 1960s. The worry then was that computers would be used primarily to spy on us, as an arm of Big Brother. Only decades later, once we all had one, did we figure out that they were better at work and entertainment, communicating with each other and generally being welcome additions to our lives. That’s because we could control them and tailor their use to our own needs, which we did amazingly well.
This change is already underway with drones. Personal versions are small, cheap and easy to use. They cost as little as $300 and are GPS-guided fully-autonomous flying robots (my company, 3D Robotics, is one of many making them). They fly themselves, from takeoff to landing, and can even follow the terrain for miles. There are already more in the hands of amateurs than the military, and some of the uses may surprise you. Civilian drones don’t just do the “dull, dirty and dangerous” jobs better; they can also make the expensive ones cheaper. In a world of Google maps, the advantage of aerial views of the world are clear, but satellites and manned aircraft are expensive and the pictures they take are often too far away or too infrequent to be useful. Drones can get better views, more often. And those shots can be of exactly what you want to see — an anytime, anywhere eye in the sky, controlled by you, not The Man.
Take sports videos. If you’re a windsurfer and want a great YouTube video of your exploits, you’re not going to get that from the shore, and hiring a manned helicopter and camera crew to follow you offshore isn’t cheap. But if you’ve got a “FollowMe” box on your belt, you can just press a button and a quadcopter drone with a camera can take off from the shore, position itself 30 feet up and 30 feet away from you and automatically follow you as you skim the waves, camera trained on you the whole way (when its battery gets low, it can return to the shore and land itself). Fast forward a year or so, and that same FollowMe box will become a FollowMe sticker, which you can put on soccer ball. Now that copter can follow the action of your kid’s soccer game, bringing NFL-quality aerial video to PeeWee sports.
One father has already set his personal drone to follow his kid to the school bus stop. Another team configured a drone to be a personal “periscope”; it flies above your head, giving you a video view from ten feet up. Yet another programmed a drone to fly in front of a runner, like a mock rabbit to a greyhound, encouraging them to pick up the pace.
Commercially, the potential is even greater. Farmers are already using drones to monitor their crops; a weekly overhead picture of a field can give them the information they need to use less chemicals and water on the plants, saving money and the environment. Scientists use drones for wildlife conservation, mapping the nests of endangered species without disturbing them. And energy companies use drones to monitor electric pylons and gas pipelines.
What was once military technology can now be used by children and I’m sure a generation growing up with drones — my kids launch them in the park on weekends — will find better uses than I could ever think of. What we, the technologists, know is that they will soon be cheap and easy enough to be commonplace; what we don’t know is what application will emerge as result. Tomorrow you may think nothing of driving by a farm swarming with robot cropdusters. Or see film sets with hovering cameras. Or skiers followed by personal videodroids. Or, more likely, something I can’t imagine at all that’s better than any of those. That’s what happens when you add “personal” to a technology. It evolves into something new, often more powerful in the hands of regular people than it ever was in the hands of the few.
With the amount of equipment in my X8 is on the increase, so is the weight. Its becoming very difficult and somewhat dangerous to hand launch.
Iv decided to build a catapult. I dont like the idea of a bungee launcher because of the amount of flat space required. some places I fly dont have this.(eg: off a cliff =) ) I really wanted something self-contained and foldable.
The APM flies the X8 really well BTW =)
If anyone wants to build one I have posted all the info and pics here
I have found this link about some paranoid anti drone person.
I am not sure if it was shown here but they stole footage of from black sheeps videos.
I'm very excited to announce that I've been published by Robot Magazine! :) My article describes the ups and downs of my two year experience building Data Bus, my 25mph race rover, for the 2011 and 2012 Sparkfun AVC (Autonomous Vehicle Competition).
The article appears in the Mar-Apr issue (#39) and sheds light on some of the problems I ran int as well as solutions that worked, and describes some of the adventure -- the thrill of success and crushing blows of failure :)

Sad news from the northwest. It sounds like it may become a Class B Misdemeanor to simply own a drone capable of video or photo, and a Class A to fly it.
I blew up my first MinimOSD, and then received my second one, but didn't realize I needed the FTDI cable, so another week went by, but all is good now..
I received my FDTI cable from 3DR today, which i needed to get my MinimOSD loaded and working. Within minutes I had it working and configured. This is a great product and very inexpensive for all that it does! So, I am in a waiting mode for a good time to do another FPV flight, although I feel I should wait until 2.92., I will feel much more comfortable with the inertial navigation in the X-Y.\
I am using the camera from 3DR that is a night cam/ day cam and auto switch's.
I was amazed when I took it outdoors tonight. I live in a rural area that doesn't even have streetlights. There was no moon out and the only source of light was the lights from distant houses in the hills. The camera shows the multitude of pinpoints of light sources and even showed the trees, and other objects that I couldn't see much better with my eyes. I was amazed, I am used to cameras that show nothing in the dark..
My plan of getting some interesting video, (already have a number of subjects in mind) at night looks like it just might work..
Anyway, as soon as I do, I will post the video or some pictures here. I just hope my GoPro 3 Black will do as good!
Here is how it is mounted, (used the bolt that holds an arm on)
A small testimony of "Italian industrial archeology " some company try to resist .
Now that everyone thinks that is possible to produced only in china ... Italian Makers say No! You can 'and you must try to do something more here in Italy !! Virtualrobotix is a farmless company , so we use small company near us for going in production or some great partner around the world :)
There's the little mounting backstage box of VRBRAIN
The first test was doing by a 3d printer but for produce a pcs it need 4 hours ... with a molder only 30 sec for 4 pcs ...now i need to sell it :) Help me to solve my problem ;)
my RepRap 3DPrinter and first printer test ...
original blog post : http://www.virtualrobotix.com/profiles/blogs/vr-brain-enclosure-back-stage-made-in-italy
Best
Roberto
If you feel you want to take it up a notch :P
(moderator's note: originally posted by Kevin Hester, restoring after inadvertent deletion)

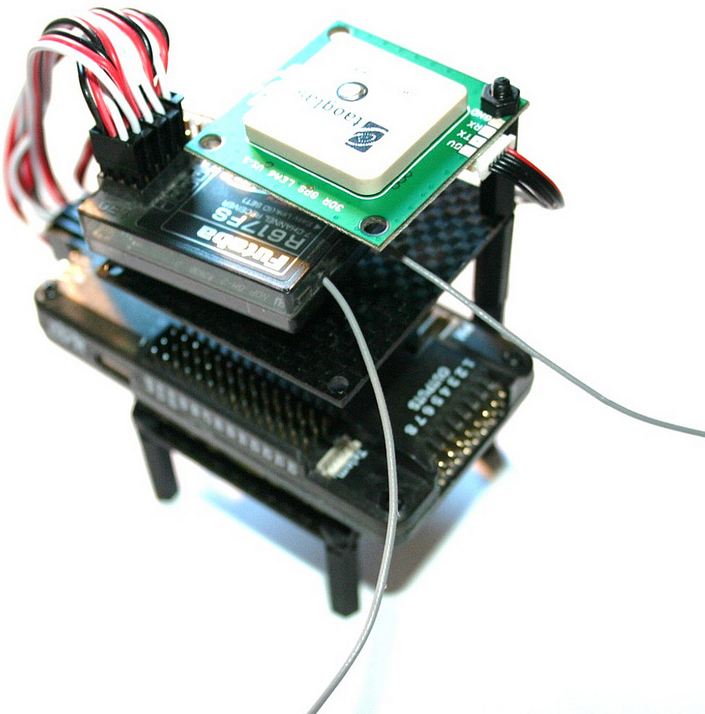
If you are looking for a nice way to mount all of your gear onto your multi rotor frame, you should have a look at our new stack up plates. On the product listing you can choose what components you need so that you can create your own stackup.
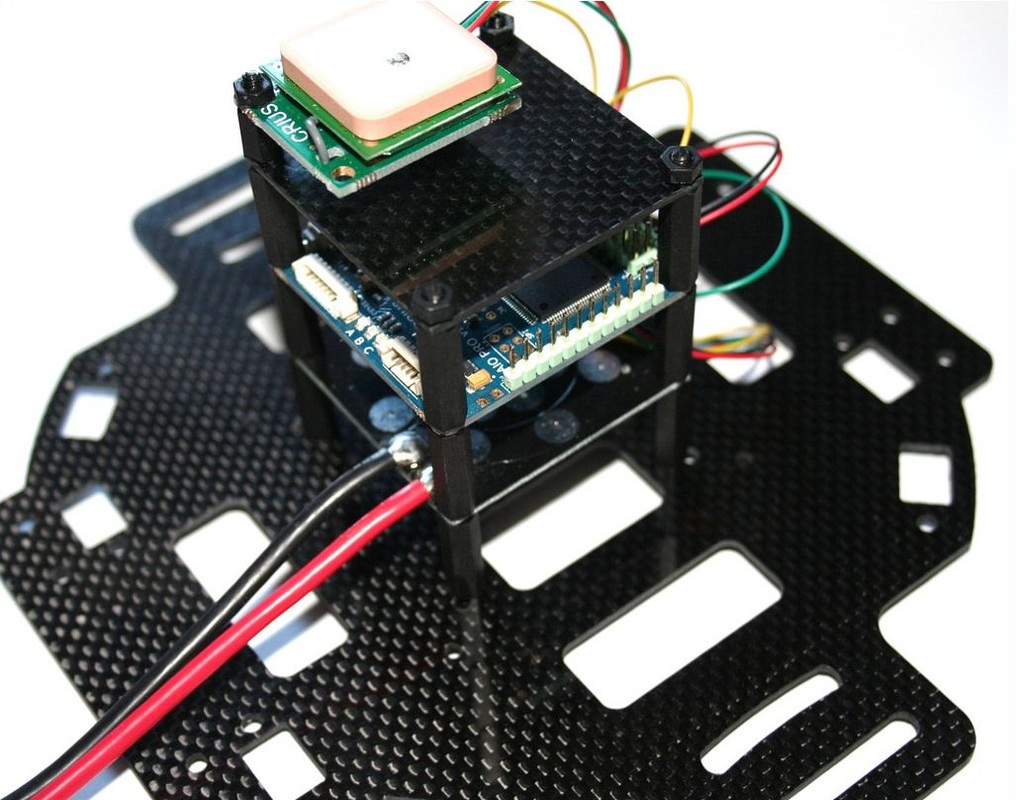 If you are using AIOP or Multiwii boards with the same 5cm x 5cm footprint then you can also mount the included PDB on the stackup as shown.
You can also use some Vibration Dampers on the stackup for the flight controller.
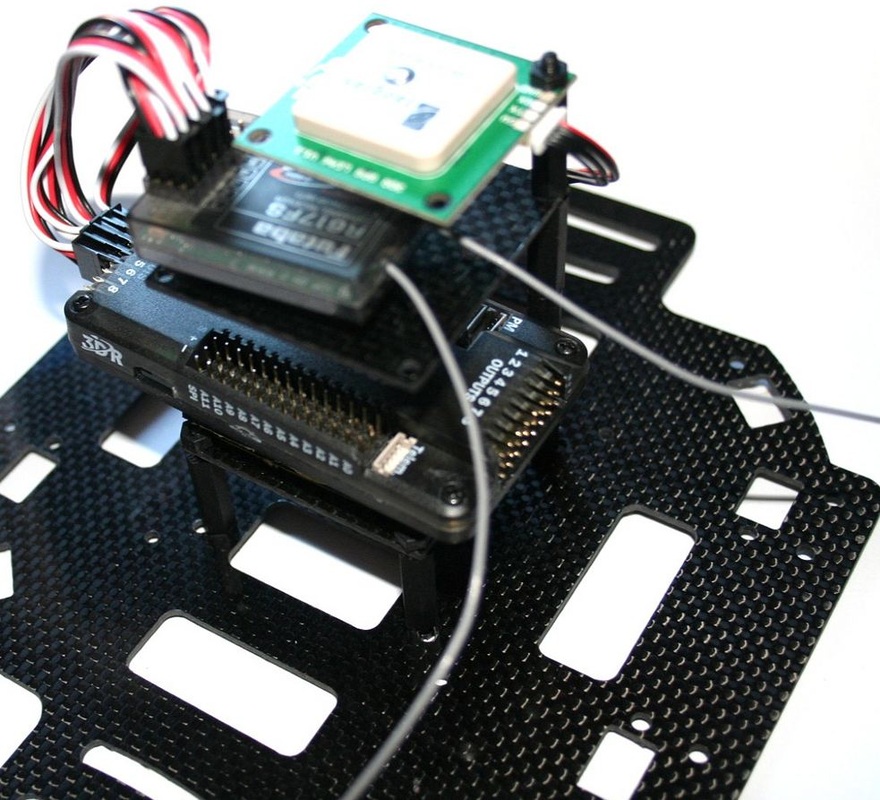 If you are using an ArduPilot Mega 2.5+ board, then you can mount it as shown, you will also need to use some double sided tape to secure the board down. This is a good idea because it also reduces the vibrations on the board so it will perform better.
This is Episode 7 - UAS - Telemetry
DroneCafe - The Daily Cup
I hope you enjoy my video's and find them educational! Check out the home of my Podcast on Diydrones.com or Click HERE!
Episode 5 - Diydrones.com Live Assistance via Skype [03:28]
Episode 4 - Newbies Guide to Diydrones.com [12:34]
***Please let me know if you have any suggestions or ideas for new episodes***
