All Posts (11086)

Sort by
3D Robotics

3689474467?profile=original

From Hackaday:

When [Matt] started building his multirotor helicopter, he was far too involved with building his craft than worrying about small details like how to actually control his helicopter. Everything worked out in the end, though, thanks to his homebrew RC setup built out of a USB joystick and a few XBees.

After a few initial revisions and a lot of chatting on a multirotor IRC room, [Matt] stumbled across the idea of using pulse-position modulation for his radio control setup.

After a few more revisions, [Matt] settled on using an Arduino Pro Mini for his flight computer, paired with a WiFly module. By putting his multicopter into Ad-hoc mode, he can connect to the copter with his laptop via WiFi and send commands without the need for a second XBee.

Now, whenever [Matt] wants to fly his multicopter, he plugs the WiFly module into his MultiWii board, connects his laptop to the copter, and runs a small Python script. It may not be easier than buying a nice Futaba transmitter, but [Matt] can easily expand his setup as the capabilities of his copter fleet

Read more…

Flying over the beautiful Mayacamas Ranch in Calistoga CA, CineStar 8, CS360 with the radian stab system, NEX7, 16mm with ND filter.


Aerial Video: Ziv Marom, zminteractive.com
Special thanks to ayacamasranch.com team for their hospitality and realocate.org, more videos coming soon! ;)

Read more…

3689474353?profile=original


It was a busy weekend. One of my earliest concerns with this project was the lack of an ON/OFF switch that could handle the current of the system and that would not look like something from an old junk box. I wanted it to be easy to use, easy to access (translate: no where near the propellors), and completely remove the battery supply in the event of an unfortunate event.

Enter the Schumacher ArmSafe Arming Kit.

This kit comes with 10 gauge wire and the hardware for nice installation. I didn't use the wire supplied but used 13 gauge wire from my LHS.

After measuring the wire paths and checking the sexes of the required connections (I have EC3 on the PDU and battery), my sketch was turned into a harness.


3689474368?profile=original


After some razor saw work with my favorite plywood, some light drilling, tapping, and other fabricating, the harness was installed on a side deck next to the APM2.


3689474129?profile=original


The home brew camera mount was pulled from a camera pistol grip project from last year and adapted to the arming deck. Behold the complete installation!

3689474320?profile=original


A view with my Philips Qvida pocket camcorder installed...

3689474345?profile=original


This weekend was also spent running down the battery on the Arducopter multiple times. The tether system is working fine. One flight effort was at my friend John's house lauching off his lawn. That was a different experience because the interaction of the grass tugged at the legs causing a different type of compensation for hovering. At times I had to abort due to hanging on the grass and tipping too far over.

Another funny thing to watch were leaves and bugs that happened to be sucked into the down draft. Think leaf mulcher.

I am presenting a program on drones/UAVs at the Anderson Radio Club meeting this Thursday night. John helped me edit some of my video and some he shot into a short movie to present at the meeting. The activities director wants to intro the program with a clip from one of the Mission Impossible movies where a drone is used in an action packed scene. Talk about riding the hype curve...


Read more…

25420.jpgThis is a new product that Hobbyking is selling. It more or less resembles (IMHO) the AR.Drone frame. The motors are place in the center of the arms and the propellers are protected by EPP foam rings.

The 450mm width is measured motor shaft to motor shaft. The actual size of the frame is 835mm which makes it quite big.

To complete this quadcopter you will need 4 motors and 8-10 inch propellers, 4 esc's, a quadcopter control board and a 3S 1300-1800 mah Battery. I think even a bigger battery should work.

The frame is yours for US$ 22.49

More information on the Hobbyking site: http://www.hobbyking.com/hobbyking/store/uh_viewItem.asp?idProduct=25420&aff=5361

Read more…
3D Robotics

Quadcopter used as weed sprayer

3689474302?profile=originalFrom the Science Network of Western Australia:

A REVOLUTIONARY homemade unmanned aerial vehicle is being used by the Department of Food and Agriculture in Albany to help eradicate a noxious weed threatening local bushland.

The “quadcopter” enables weed control workers to carry out “search and destroy” missions on Sydney Golden Wattle trees that are difficult or impossible to reach by conventional means.

Unknown in Albany before the early 1980s, the wattle is now at plague proportions and will have overrun more than 20 per cent of native bushland by 2020 if left unchecked.

The invention is the brainchild of department senior research officer John Moore, who designed and built it over 18 months.

Mr Moore used readily-available, inexpensive high-tech gadgetry and computer components to create the quadcopter for about $1000, a tiny investment when compared to commercial equivalents that can cost up to $30,000.

Popular among aviation hobbyists, the quadcopter has been around for some time.

What makes Mr Moore’s version unique is the way it has been set up to not only locate small stands or individual weeds, but to photograph them and then spray them with weed killer.

(Via Hackaday)

Read more…
3D Robotics

3689474098?profile=originalFrom BoingBoing, news of a new organization that uses some of the same open source principles we use here, but for manned aircraft:

"MakerPlane is an open source aviation organization which will enable people to build and fly their own safe, high quality, reasonable cost plane using advanced personal manufacturing equipment such as CNC mills and 3D printers. The project will also include open source avionics software to enable state-of-the-art digital flight instruments and display capabilities. Basically we are designing an aircraft that can be built on a CNC mill at home, or at a makerspace which is easy to assemble and quick to build. The plans and instructions will be available for free to anyone that wants them!"

MakerPlane is an open source aviation project which will enable people to build and fly their own safe, high quality, reasonable cost plane using advanced personal manufacturing equipment such as CNC mills and 3D printers. The project will also include open source avionics software to enable state-of-the-art digital flight instruments and display capabilities.

Basically we are designing an aircraft that can be built on a computer controlled mill at home, or at a makerspace which is easy to assemble and quick to build. The plans and instructions will be available for free to anyone that wants them!

Read more…

3689474041?profile=original

I've started flying a lot of FPV recently, and I noticed that my Fat Shark Base glasses were getting quite hot after just minutes of use. Using my lab's handheld thermal infrared camera, I took some photos of the goggles and my quad after a few minutes in the air partially to try and troubleshoot the heat problem but mostly just for fun.

The goggles appear to have melted in one spot and "heat shrunk" (see above)

IR image confirms the source of heat is in the same place:

3689474069?profile=originalHas anyone else experienced this? I assume it's a voltage regulator in there but haven't opened them yet.

Here are some thermal snaps of my quad:

3689474166?profile=original

The bright white in the front / center is a 900mhz video transmitter and HoryzonHD camera circuit board (camera itself is below decks)

Read more…
Moderator

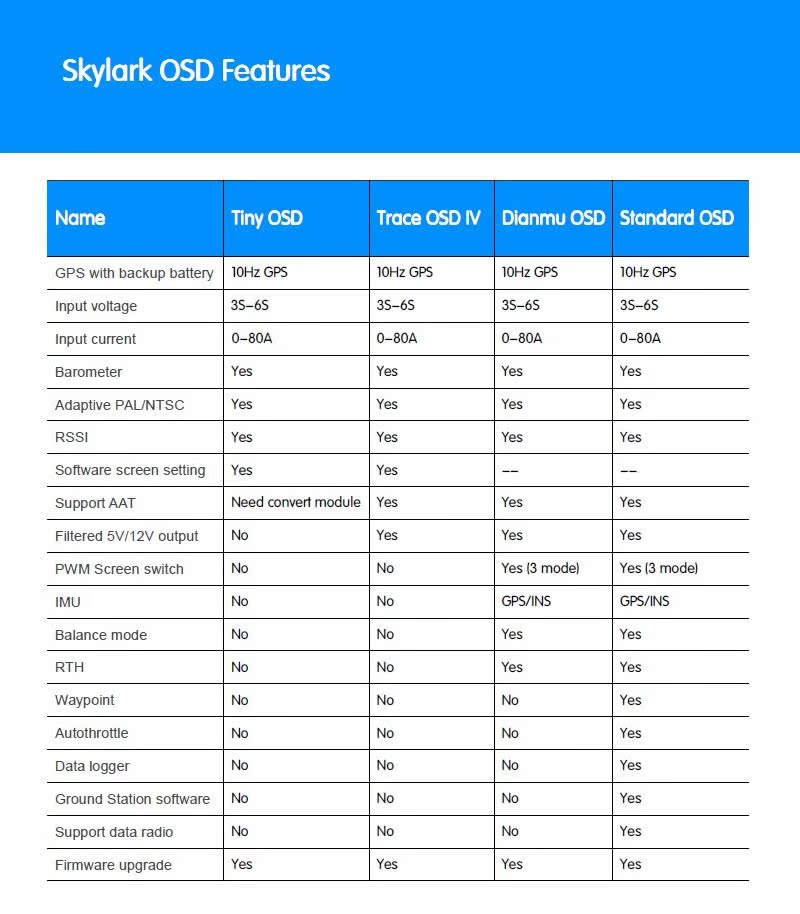
Skylark Dianmu OSD with RTH

2012070314234955781.jpgThis looks rather nice, the Dianmu system only has RTL (return to launch) whereas the Standard system has that plus waypoint ability. (http://www.skylarkfpv.com/en/), RCGroups thread here. Video on the thread or one sample below.

A friend is in the market for a Stabilization/OSD/RTL system and while so far I've been advocating ArduPlane & APM2, he's not very computer savvy, wants as few bugs as possible and wants something as close to plug-n-play as possible and so I am considering recommending this:I like the way all the setup is through the OSD displayed on the screen.

Dianmu is US$198, (more here) Standard is US$298. (more here)

Features below:

T2uGJrXiJNXXXXXXXX_%21%21265677212.jpgOne video sample: https://www.youtube.com/watch?v=EdMJbYRcQVs

Read more…

Ever seen 20.000 people waving at a quad?


Hold your fire! it did not fly over them. ;-)


This weekend we had the XVI International half marathon of Rio with a beautifull day, gorgeous location and 20.000 runners. As I am not into running, I thought it would be a great opportunity to experiment the potential of covering a big event from the privileged birds eye view of a multicopter and it surpassed my expectations!


On top of the nice images, I was really surprised to see the positive crowd reaction and interaction with the quad. They did not feel concerned or threathened by it - after all, it is smal, quiet and never flew above their heads. Instead, they were really excited as if they were playing with it and saluting it. I could even get the audio from their cheers over the noise of the props wash!


I am flying a XA x650 frame / Naza FC+GPS / Jdrones gimbal / Gopro. No post stabilization on this cut! Amazing what a $50 gimbal can do, despite some wind. Got to be really gentle on the sticks though. Gabriel2584 is flying a F450/Naza/Gopro/self-made gimbal. He had some servo jittering problem that required post stabilization.


Let me know your thoughts!

Cheers,

Read more…
3D Robotics

Centeye optical flow copters on TechCrunch!

3689474027?profile=original
Our friend Geoff Barrows, who has been working with us on his great optical flow boards, just got covered by TechCrunch! UPDATE: They've disabled the cool video for embedding, but you can see it here. 

When we first wandered up to the suburban split-level that houses Centeye Inc., we were a bit confused. Could this be the place where a mad roboticist was building tiny robots with insect eyes and brains that could interact with their environment? We rang the doorbell and weren’t disappointed.

Founded by Geoffrey Barrows, Centeye is dedicated to computer vision. They make little electronic eyes that are cheap to reproduce and “see” only a few thousand pixels. He has a staff of two engineers who work with him on designing and building chips and has just released the open source Arudeye board, a tiny Arduino board with camera built-in.

Barrows does everything from his basement. Recent advances in fabrication allow him and his staff to design chips on a computer at home and then send the plans to manufacturers in Asia. They can then mass produce their eyes, driving down the cost per unit to a few dollars. They don’t need a big lab because everything is done remotely.

Their robots are actually proofs-of-concept but they’re really cool. The little helicopters use Centeye eyes to remain stationary in space and other models can avoid objects as they move. Because each eye takes in a small part of the scene, not much computing power is needed to process each bit of input. Like insects, the brain doesn’t have to work very hard to get a lot done.

Centeye has contracts with DARPA but is trying to commercialize their hardware with the Arduino offerings. It’s fascinating to see makers in their own habitat and even more exciting to see them make cool stuff in the oddest of places. Check out the video for more information and you can watch all of our TC Makers episodes here

Read more…

Quadcopter Park Flight with video...

I took the quad out the a nearby park for a more extensive flight.

All went very well, got 10+ minutes of great video.  The quad was carrying a 5000mAh battery and my Contour video camera.  I still am having difficulty identifying the orientation of the quad when it's quite a ways off, you can tell in the video where I am trying to establish which way a given control will move it.


Alignment of the video camera was poor, it was a last minute strap-down with velcro and zip-ties.  I'm working on a more practical undercarriage for the quad that would allow me to better mount/balance the battery and the camer.  This should also allow me to clean up the video, keeping the aircraft out of the frame as well as ensuring that the video is oriented squarely.  As you can see in the video, I've got the camera tilted a bit.


Enjoy.


https://www.youtube.com/watch?v=qZ7Yuoo_8p0

Read more…

MultiWii 2.1 HEXA with GIMBAL

Hi all,

Here is a video i've made with MultiWii 2.1 and my Hexa (Flyduspider) to demonstrate how works Gimbal command.

I have the minimum conf with Arduino Pro Mini and a PPM Sum card to save two output need for Gimbal command, and one for Cam Trigger.

In the code you can chose between 50 Hz 160 Hz and 300 Hz for the servo command, in the video i'm on 50 hertz to start.

Read more…
3D Robotics

3689473926?profile=originalIf you're like me and crash a lot (I'm a terrible pilot), bent motor shafts are a weekly curse. There's no good way to straighten them, so I have to replace the entire motor. That's expensive, and requires a lot of soldering of wires and remounting motors. So good news: now you can just replace the bent part, leaving the rest of the motor soldered and in place! 3DR now sells just the outside enclosure and shaft of the common 3DR 850 motors. They're half the price of the full motor and will save you many minutes of soldering and reassembly time.

(Why not just sell the shaft? Because they're really tightly placed in the enclosures and need special tools to replace).

I've asked them to also see if they can source the aluminum collets that the props fit on. They're soft and also tend to bend and they're hard to find on their own. Stay tuned...

Read more…

autonomous-fixed-wing-drone.png

MIT’s Robust Robotics Group is showing off the work they’ve done with a 2M wingspan drone, culminating in a death-defying flight through a parking garage.

The drone is self-contained. It does depend on starting out with a map of its environment, using this in conjunction with a laser rangefinder and inertial sensors to plot its route and adjust as necessary.

Found on Hackaday: http://hackaday.com/2012/08/16/autonomous-fixed-wing-drone-threads-the-needled-in-a-parking-garage/

Read more…
Distributor

Montreal Mini Maker Faire countdown

3689473890?profile=original

Hi folks, the first Montreal Mini Maker Faire is almost here!  http://www.makerfairemontreal.ca/

Check out the maker section, lots of interesting things will be there on top of the Canada Drones boot.  

I have confirmation form a bunch of guys here that will bring their projects to showcase as well as potentially fly. 

We will have our own secure, dedicated flight zone where we can go and fly our gear. (will require a quick inspection/ hand test when possible clearance to be granted access) 

Here is a quick list of things that I will bring out there. (we will have at least 2 tables under a main tent) 

    - a Quad that will be used to do demo flight (yes on a very secure area! at 3pm Saturday and Sunday) 

    - a QR Ladybird for quick and super secure fun around the boot

    - a 3DR Hexa full equipped with telemetry and camera gimbal. 

    - a jDrones special Hexa (top secret for now!) 

    - some I/O boards to have some LED action :) 

    - a laptop connected to an APM 2.5 to showcase the mission planner and the features. 

    - Some 3DR and jDrones swag 

    - Soldering station, LiPo recharge station / Power  so we can work on the projects and repairs and have fun. 

    - and more!  (rumors has it that there will be CanadaDrones.com coupons on site !) 

When? 

Next weekend! August 25-26 from noon to 6pm (for people helping me /  bringing any equipment we will need to arrive on site around 9am to setup on Saturday)

How to get there and parking? 

http://www.parcolympique.qc.ca/en/how-to-get-here/#5

One VERY important thing is that we are going to share a site used for a rock fest later that day.  Your admission will allow you to stay on site and watch it so security and rules are a bit "extreme" for a Maker Faire but never the less mandatory and will be enforced.  

This is the full list of "rules": http://expmtl.com/en/FAQ/

but for people that will skip this important reading here is some main points

 -  NO SLR CAMERA (it's a rock fest afterall)... if you really really really want to bring SLR camera, let me know as I can potentially have a media badge for you... but really you will need to take really good pictures! hehe

ITEMS NOT ALLOWED ON THE FESTIVAL SITE
Glass bottles and cans
Hard-sided coolers
Musical instruments – unless you are in a ExperienceMTL approved performing band
Megaphones
Fireworks
baseballs, beach balls, footballs soccer balls, etc.
Large sport umbrellas
Folding chairs
Skateboards 
Animals (except Guide dogs)
Large backpacks (camping style)
Tents
Laser pointers
Brought from outside alcoholic beverages
Illegal Drugs and drug paraphernalia
Video / Audio recording equipment – unless you are an Experience Montreal accredited media person.
Professional photo equipment (SLR cameras, i.e. removable lens cameras) – unless you are an Experience Montreal accredited media person.
Items intended for sale / promotion unless they are approved festival merchandise.
Any object that can be used to cause bodily harm

Items that are on the disallowed list will be confiscated. Don’t not bring them to the festival site at all to save yourself the problem!

Hope to see a lot of you there!  I am very excited about this event. 

Dany

www.CanadaDrones.com

Read more…

25382.jpgA search for this product revealed that it has not been discussed before on diydrones.  The FY-901 is an inertial stabilization controller for your multi-rotor aircraft developed by FeiyuTech.

It offers two flight modes which can be remotely selected from your transmitter, even while in flight:
- Auto-Stabilization Mode: In this mode the FY-901 will utilize the 3-axis accelerometer to self level your aircraft
- Standard Mode/3D Control Mode: In this mode the device will utilize the 3-axis gyroscope to sense roll velocity and flight attitude while you keep control for aggressive 3D manouevres.

The flight controller has support for 4 speed controllers. You can configure it for flying in "X"- or "+"-mode as well as for Y3 copters through the switch on top of the casing. The gain screw allow to set gyro gain.

For more information, you can download the manual here: http://shop.fyetech.com/dl/fy901.pdf

Price for the FY-901 controller is US$ 89.00 and it is available from Hobbyking: http://www.hobbyking.com/hobbyking/store/uh_viewitem.asp?idproduct=25382&aff=5361

Read more…
Developer

Here a video of an autonomous flight with a Maxi Swift flying wing fully piloted by the firmware ArduPlaneNG v2.x R5 with an All In One Pro (AIOP) full IMU board.This is a porting of the ArduPlane v2 (v2.4+v2.5) firmware and special addons and improvements for the AIOP board that I have added.
The wind was 15 km/h gusting 22 km/h. The flight was very stable in spite of the gusty wind conditions.

3689473600?profile=original

3689473686?profile=original

Setup:

  • IMU board: All In One Pro (AIOP) v1.0 from CRIUS,
  • GPS: Crius CN-06 (Ublox NEO-6)
  • AirSpeed sensor: MPXV5004DP (from a old ardupilot one shield)
  • firmware ArduPlaneNG V2.x R5, porting of the ArduPlane v2 + special addons for the AIOP v1 IMU board by JLN

3689473718?profile=original

Flying Wing: Maxi Swift from MS Composite (1m40 wingspan)

  • brushless motor Spitz 30 850 kV, 360W with a propeller GWS 10x4.5
  • Lipo: 3S EVO25 2650 mAh
  • Receiver: Turnigy 9X8C v2
  • Transmitter: Turnigy 9x with Er9x firmware

3689473701?profile=original


More infos at: http://diydrones.com/profile/JeanLouisNaudin

Read more…

Melbourne UAV is out of the Outback Challenge

3689473592?profile=original
Hi Guys,
 
Unfortunately down here in Melbourne Australia we have had a very wet winter, which has made it virtually impossible for us to fly our X8 UAV in preparation for the 2012 Outback UAV Challenge. We fly on a private farm about an hour from Melbourne which for months has had either had water laying on the ground or been too muddy to get our cars in.
What this means for us is we didn't get enough Autonomous hours logged for our Deliverable 3 to stay in the competition. It's disappointing because we were pretty confident that this was going to be the year! :)   (Third time lucky and all)
 
The main purpose of this post was to say a big thanks to all our sponsors and people that have helped us along the way.
And a special big thanks to FPVFlying.com for their greatly appreciated support with the
Awesome X8 airframe. Please have a look at the link as it is a great airframe for UAV / FPV use!
 
We would also like to thank all the people that took the time to tweet and leave messages through
It's always amazed me how so many people have taken an interest in a few mates having fun just entering a competition.
 
Best of luck to all the teams that have put in the hard work to get there on the day and I'm guessing the ground will be littered with bottles around Joe this year! It's shaping up to be a great event!
 
 
Cheers,
 
Scott
Read more…

3689473561?profile=original

The test hop was short due to having spit balled the throttle and pitch curves to come out with a head speed of ~1300rpm and a motor speed of ~1-,500rpm

The vibration dampening seems to be more than adequate for both the redundant system and the arducopter itself, however on setting up for the maiden Arducopter control flight I have found that I could not establish mavlink telemetry due to one XBee mount kicking the bucket, this being a $24 part I will have a replacement ordered tomorrow.

Everything is running smoothly for a gasser, and I expect to be making good progress at long last. I am looking at the 3-Axis camera mount code and will be making up the hardware side over the next couple of days, and it is good to know I have a spare APM one I can use as an inertial measurement and stabilization system for the camera mount - I hope to look at creating its own autonomous control where I can set waypoints in the mission planner which will be read as "ground lock targets" for the camera to stay pointing at, while the UAV flies its mission. Another way to start bringing in Hi Res 3D ground mapping.

Here are some pics of the ship and the hardware mounting.


3689473434?profile=original

3689473605?profile=original

3689473659?profile=original

3689473632?profile=original

THe video was flown on the 3X-1000 FBL stab system, which is being used as a redundant backup I can switch to for control while tuning the APM1.

Ben

Read more…