All Posts (11086)

Sort by

MARCY-1 LIFTS OFF

There it is. Marcy-1's first free flight on the golf course.The 900Mhz RC transmitter interferes with the telemetry receiver even though they're on opposite ends of 915Mhz. You need to keep them separated or on different bands, which requires rebuilding the entire transmitter.The notoriously fickle capture compare on the PIC is still extremely hard to get working in the field.

Salute the Mar.

By now, we realized she had a serious roll oscillation which is probably from not having enough weight on the balace beam.

Longest flight.

Last flight, ending in a tree impact.

Marcy-1, warrior copter.THE 900MHZ NIGHTMARE

Tracked down the SI4421 problem to a floating solder joint. The SI4421is electrically identical to the MRF49XA.

Dual 900Mhz receivers for Vika 1 & Marcy 1.

Ancient 72Mhz converter from 3 years ago.

900Mhz converter fits inside the case.

Much better.

900Mhz converter has resistors for all the inputs to prevent overloading.The 900Mhz conversion runs at 9600bps. Manual control now has the full60Hz of the RC transmitter. It was reduced to 50Hz when it was 72Mhz.

After being plagued by broken wires & floating solder joints, the Marcy1 ground station was finally capable of flight.

Vika 1 is also beginning a long hard 900Mhz upgrade. Since the MRF49XAhas only a 16 bit buffer being consumed at 86000bps, getting VikaCopter to output data fast enough requires buffering an entire packet on the flight computer & sending it in 1 shot instead of sending data as it's collected.MICROMAG3 RIDES AGAINSince we didn't win the free $parkfun hibache knife set & no-one knowsif Marcy-1 will work, that leaves digging the old Micromag3 out of thegadget graveyard & fabricating a new Marcy-1 flight computerspecifically for it.A 3rd revision will be necessary. Depending on traffic, these boardscan be fabricated in 1 commute & since we're tax paying renters, thechips are fully recycled.

Spent $30 to find out only Mane Clog Remover, only at Walmart works.Other drain cleaners have additives which prevent the NaOH fromdissolving photoresist. Mind you, you're supposed to use batchpcb.

Etching skills are a bit rusty after the draino experiments.

Size comparison. Went back to single sided boards because they'relighter with our methods.

This one has a simple dipole with choke inductors, no decouplingcapacitors, 1 digital line under the chip & it still works. Filling aground patch & using 3 decoupling capacitors is only necessary formaximum range.

Suspect any inductors above 8nH would do the job but these were whatthe balun had.

Marcy 1 phase 2 with magnetometer grafted on.

& this is the raw & derivative of the magnetometer output at flight RPM. Flight RPM has 144 samples per period. The limiting factor is radio bandwidth, not the magnetometer. It takes 20000bps of radio bandwidth to downlink that. Monocopters take the zero crossings of the derivative to get azimuth & angular rate, but it's not so easy in realtime.
Read more…

Interesting Micro-UAVs

Hi all,I'm a new members interesting by Micro-UAV since many years.If some ideas could interesting somebody, on my website, you could find some reports (made by me and my wife) of M-UAV contest from 2002 to 2008.For example :2007 at Toulouse (France)

2008 at Agra (India)

Actually, I'm working on FPV models and review of equipment.Yesterday, I have pilot the new Drone AR Parrot. Parrot society is in Paris and it was a fantastic experience.

12515-parrotardrone06.jpg

You could see pictures and video in a few time on the web site of this magazineByeChristian
Read more…

Introduction

Hi all,I'm a contracting WAN (large computer network) architect/engineer, and an embedded systems engineer (microprocessor-based stuff mainly, with most experience in netbook and mobile style applications). Before that I was a programmer, focusing on networked applications, and also did a while of AI development.I've been given a part-time funded project of the design of a mid-sized UAV (several to be built), for monitoring and on-demand surveillance of a medium sized property. Under the contract I have, I own all rights to the design, so I decided I'd share what I learn and develop with others.The planned UAV is a mid-sized quad-rotor helicopter, 500mm between rotor center and airframe center, with 200mm blades (for a 400mm rotor). These exact details may change however, and I'll try to keep this blog updated with progress and such.I'll be developing almost everything in-house, including the airframe, avionics, protocols, and ground station equipment. I'll be using pre-designed ICs, motors, and batteries (among other things) for obvious reasons. I'll be manufacturing a lot of the parts and assembly myself.The system is to be fully automated, and will be controlled via a base station server, with a small comms tower. The UAVs will contain mesh networking links, to allow either relayed communications with the base, or basic AI intelligence when they are outside of base range, by direct communication.I'll be posting to update on the sort of things I'm up to, and with more design and implementation details as they come up. I'll hope to follow this post soon with more information on how the system operates.Anyway, looks like a fun site, filled with a lot of knowledgeable people. I think I'm definitely going to enjoy my time here :)-Matt
Read more…
Developer

Ardupilot 2.5 Beta

This is a quick note to let everyone know that Ardupilot 2.5 is feature complete and can be downloaded via SVN. If you're on Windows, use TourtiseSVN and if you're on a OS X like me, try Versions. The code is located here.Once the Beta feedback is in I'll post a zip file of the final version. Information about using SVN can be found on the web. Please post any issues in this blog post, and I'll fix them immediately and re-upload.I'm also building a wiki manual to help with the configuration, but it's an early work in progress. I'll write a lot more this week, but there should be enough content up there to get you going.Use the Airframe tester to configure your new 2.5 header file and familiarize yourself with the startup sequence. Don't use the old 2.4 file, except to copy over your old gain settings. I've tried to keep as many of the values the same, but many values are new as well.By Default the control switch settings are 1 - manual, 2 - Autopilot, 3 - Stabilize. Feel free to change them to whatever you like.Good luck,Jasonp.s. Who thinks Ardupilot needs a logo?
Read more…
T3

GPS sats in view: quality does matter.

Recently a flight in Norway revealed and interesting truth about GPS number of satellites in view: quantity is not quality. The photomission for T3-4 contest ended well, but the message is clear: checking wind is one thing, checking GPS availability is another.

T3-4 Photocontest using EasyUAV from brakar on Vimeo.

This thread explains things:http://www.rcgroups.com/forums/showthread.php?p=14059833#post14059833Compare how few satellites over the horison can fool navigating plane.
Read more…
3D Robotics

DIY Drones on Twitter

DIY Drones is now fully Twitter-enabled! All blog posts are automatically tweeted on @DIYDrones, so please follow us there. Also, you can tweet any blog post or discussion forum post to your own Twitter account by clicking on the Twitter icon below it (circled below).

Finally, you can set your status update message on your MyPage to also post to your own Twitter account by checking the box shown below:

Read more…
3D Robotics

We love and worship AttoPilot, Dean Geodde and the smart team around him, but we're just thankful that they're better at UAVs than they are at the Web. The original attopilot.com website was a bit of a Flash disaster with a pdf order form and then was never updated. Now the site is down in the worst way: it's been showing a Godaddy landing page for the past couple weeks while Dean revamps the site (Dean, please! An "under construction" page is not that hard to put up!).

Fortunately, Chris McNair has taken on the web storefront role with a new site at http://www.emtechnologiesgroup.com/. Unfortunately, it's a bit of a Flash disaster, too. There are no links on the front page that will actually take you to any products, and the closest thing, "Product Brochure", weirdly gives you this:

However, if you click around enough you'll eventually find a "Purchase Here" link at the bottom of the page and that will take you to the storefront shown at the top of this page. It's all clearly a work in progress, and many of the images are missing or of the wrong thing (love the "Our Team" shot of clipart diversity!), so we can assume it will get better soon. Over at the Attopilot user group, Chris has asked for feedback and constructive criticism, so for starters may I suggest: 1) Kill the Flash. It's 2010--we all learned our lesson about Flash-based sites last decade. Just say no! 2) Put the product link on the home page 3) Put a redirect on attopilot.com or at least a page informing people that the company is still in business and to stay tuned for a new website. 4) Add community of some sort. Even a forum or discussion group would be better than nothing.
Read more…
Developer
1 of my 2 Ublox modules has developed a problem. It refuses to get a fix. I am monitoring it with Ucenter and see that it is operating, it is tracking 7 or 8 satellited from inside my house, but it won't get a fix. I notice that it is getting the correct UTC time, but it cannot tell the date! I assume this is why it can't solve for a fix. I have reset the configuration and performed several cold starts. Not sure what else to try??? Any suggestions?
Read more…
Web page ishttp://shrediquette.blogspot.com/And videoshttp://vimeo.com/6766174http://vimeo.com/7420635Back motor tilt by servo and looks very stable and also good 3d capable.You can find in construction and setup manual , detail the tail mechanism. I start to build this tricopter , but hard to find i2c driven esc's and expensive German made.Oguz Dogansoy
Read more…

Video of Houston Police secret aerial drones

Not sure about the reporting style.http://www.boingboing.net/2010/01/12/video-of-houston-pol.html?utm_source=feedburner&utm_medium=feed&utm_campaign=Feed%3A+boingboing%2FiBag+%28Boing+Boing%29Public safety application include:• Mobility• Evacuation• Home land security• Search and rescue• TacticalAre the above applications listed in order of priority?

I wish I had a ground station like this.

Read more…
3D Robotics

Parrot AR.Drone unpacking

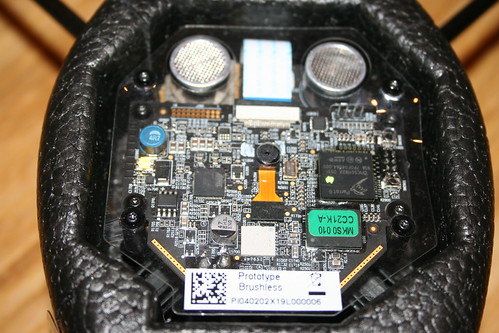
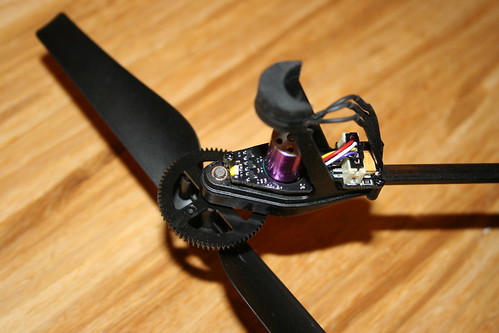
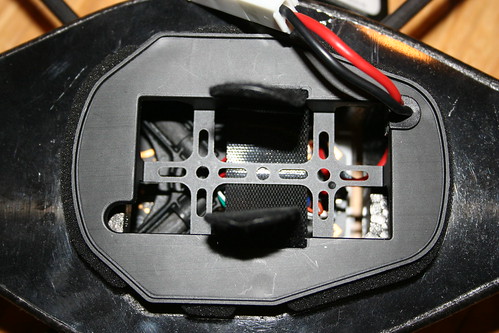
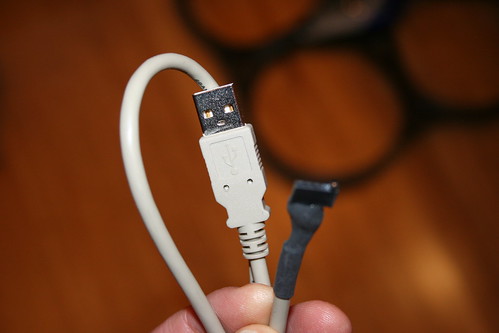
Super excited...the Parrot team sent me two AR.Drones as development kits! (One is for me and the other for a famous game designer friend). They just arrived, and here are some first impressions and closeups. First, I haven't flown it at home yet because you've got to compile the source code with the iPhone SDK and then load it in ad-hoc distribution mode, and I'm not a iPhone developer (yet). But I did get to fly it at CES and it was just as awesome as you've heard. The coolest thing is that when you get in trouble you just take your finger off the iPhone screen and it snaps into hover mode exactly where it is and just stays there, totally locked. Amazing... Here are some photos from the unboxing (these photos are all on Flickr, where you can mouse over them for notes. Just click on the photo and you'll be taken there): IMG_4658 This is the main board, with the Arm9 core in custom Parrot DSP silicon, the downward-facing camera for optical flow, the ultrasonic sensor and the WiFi radio. IMG_4657 This is a closeup of one of the brushless motors and ESC (the quad comes in either brushed or brushless models). This ESC runs at 200Hz. IMG_4660 It comes with a 1000mAh LiPo and charger. IMG_4661 You can see the carbon fiber rods through the battery compartment IMG_4659 Green LEDs in the front; red LEDs in the back IMG_4662 A USB-to-serial cable for hardware interfacing
Read more…

Snellflight 'jumpjet' quadrotor

To add to the subject of quadrotors, there has been a very inexpensive item available here in the UK for the last couple of years. It's called the 'jumpjet' due to it being supplied with a stealth bomber body and this was later augmented with a 'Harrier Jump Jet' body as an accessory. The basic model is about £60 in the UK which roughly equates to about 100 USD. The model is for indoor use as it comes out of the box and can be converted to radio control by and add-on circuit. The basic quadrotor model can be readily flown without the aircraft bodies being fitted.This item was designed in the UK by 'Snellflight' who are a small model design business noted for innovative helicopter designs. The parts are made in China.Here is the website; http://www.snelflight.co.uk/index.htmThere are several videos on the site including an outside flight carrying a video camera and transmitter.
Read more…
3D Robotics

The Parrot AR.Drone was not the only quadcopter at CES. From ArsTechnica, a report on a toy quad with impressive-sounding specs ($299 show price; $399 MSRP). Gyro stabilization and some sort of altitude control (ultrasound). Sounds like it will quickly be sued into extinction by Lucas, but the trend here is clear. The era of cheap and capable quads is upon us. We'll be modding these things for full autonomy and good cameras in no time. What does this mean for the expensive (multi thousand $s) quadcopters from the semi-pro world, such as the Draganfly and Mikrocopter? I know they're more capable, but is it enough to justify the price difference?
Read more…